

Underwater optical beacon recognition based on dual image gray features and gaussian mixture model-triangle threshold algorithm
-
摘要: 基于视觉与光信标导引的水下目标识别是实现水下近距离对接的重要手段。水下光信标的识别精度决定了水下对接目标的定位精度。针对水下光信标识别精度与分割算法运行效率问题, 提出了图像灰度双特征驱动的高斯混合模型(GMM)-三角阈值算法(TTA)。首先, 以图像灰度双特征为指标, 采用支持向量机(SVM)判断水下图像中是否包含光信标; 其次, 设计GMM-TTA算法对包含水下光信标的图像进行分割, 提升水下光信标识别精度; 最后, 通过水下对接实验获得的图像对所提算法进行验证。实验结果表明, 所提算法能够准确识别水下图像中是否包含光信标, 并在图像分割阶段成功抑制了水下强散射晕染, 提取目标平均圆度优于GMM、TTA、最大类间方差法(OTSU)、GMM-OTSU算法。Abstract: Underwater target recognition based on vision and optical beacon guidance is an important method to realize short-range underwater docking. The recognition accuracy of underwater optical beacons determines the positioning precision of underwater docking targets. A dual image gray feature-driven Gaussian Mixture Model (GMM)-Triangle Threshold Algorithm (TTA) is proposed to address the challenges of recognition accuracy and computational efficiency in underwater optical beacon segmentation. Firstly, taking dual image gray features as evaluation indices, the SVM is employed to determine whether an underwater image contains an optical beacon. Secondly, the GMM-TTA algorithm is designed to segment images to improve the recognition accuracy of underwater optical beacons. Finally, the proposed algorithm is verified using underwater images acquired from underwater docking experiments. The experimental results show that the proposed algorithm can accurately identify the existence of optical beacons in underwater images, effectively suppress strong underwater scattering halation during the image segmentation process, and the average roundness of extracted targets is superior to that of GMM, TTA, OTSU and GMM-OTSU algorithms.
-

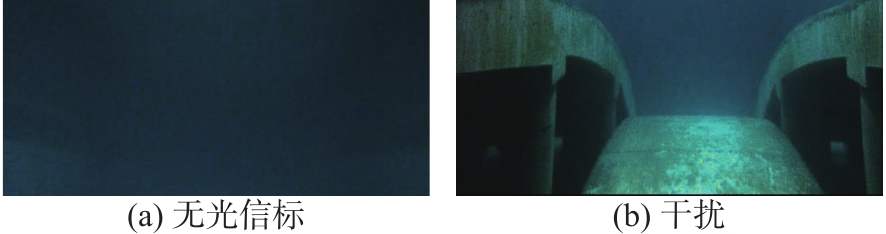
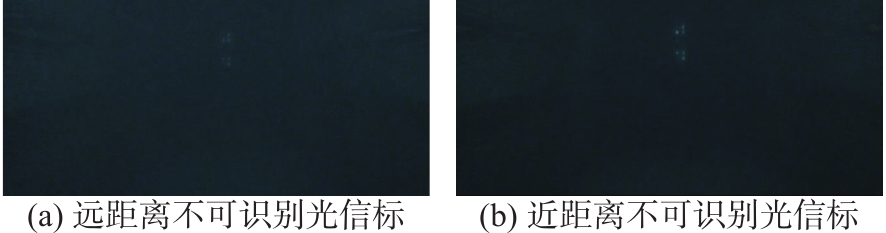
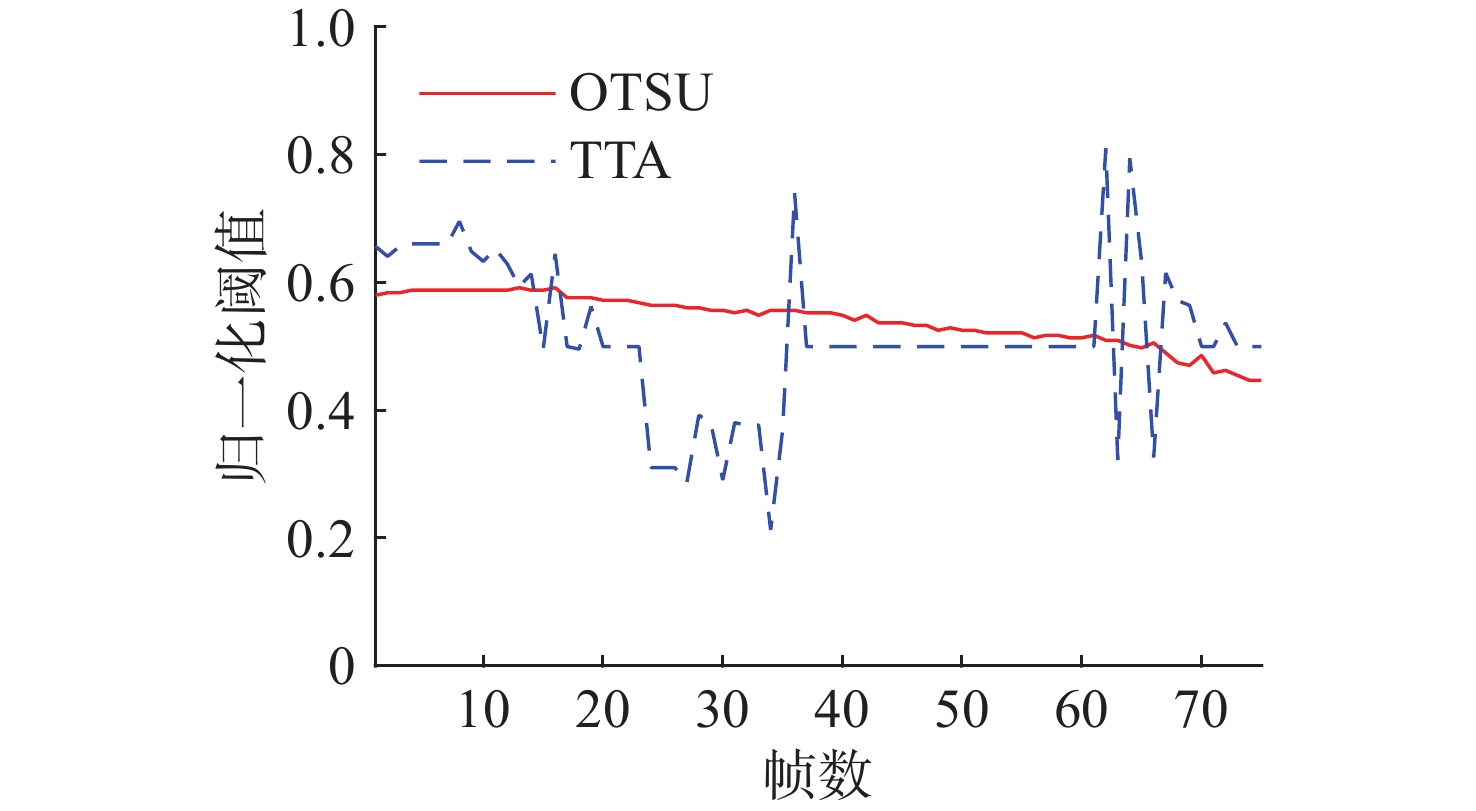
图 2 包含光信标但无法识别的水下图像(工况2)
Figure 2. Underwater images with optical beacons that cannot be recognized (condition 2)
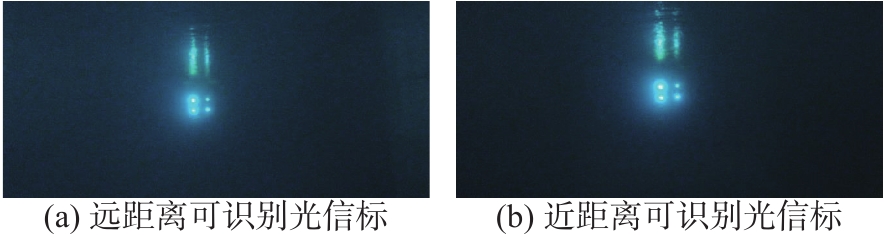
图 3 包含可识别光信标的图像(工况3)
Figure 3. Underwater images with recognizable optical beacons (condition 3)
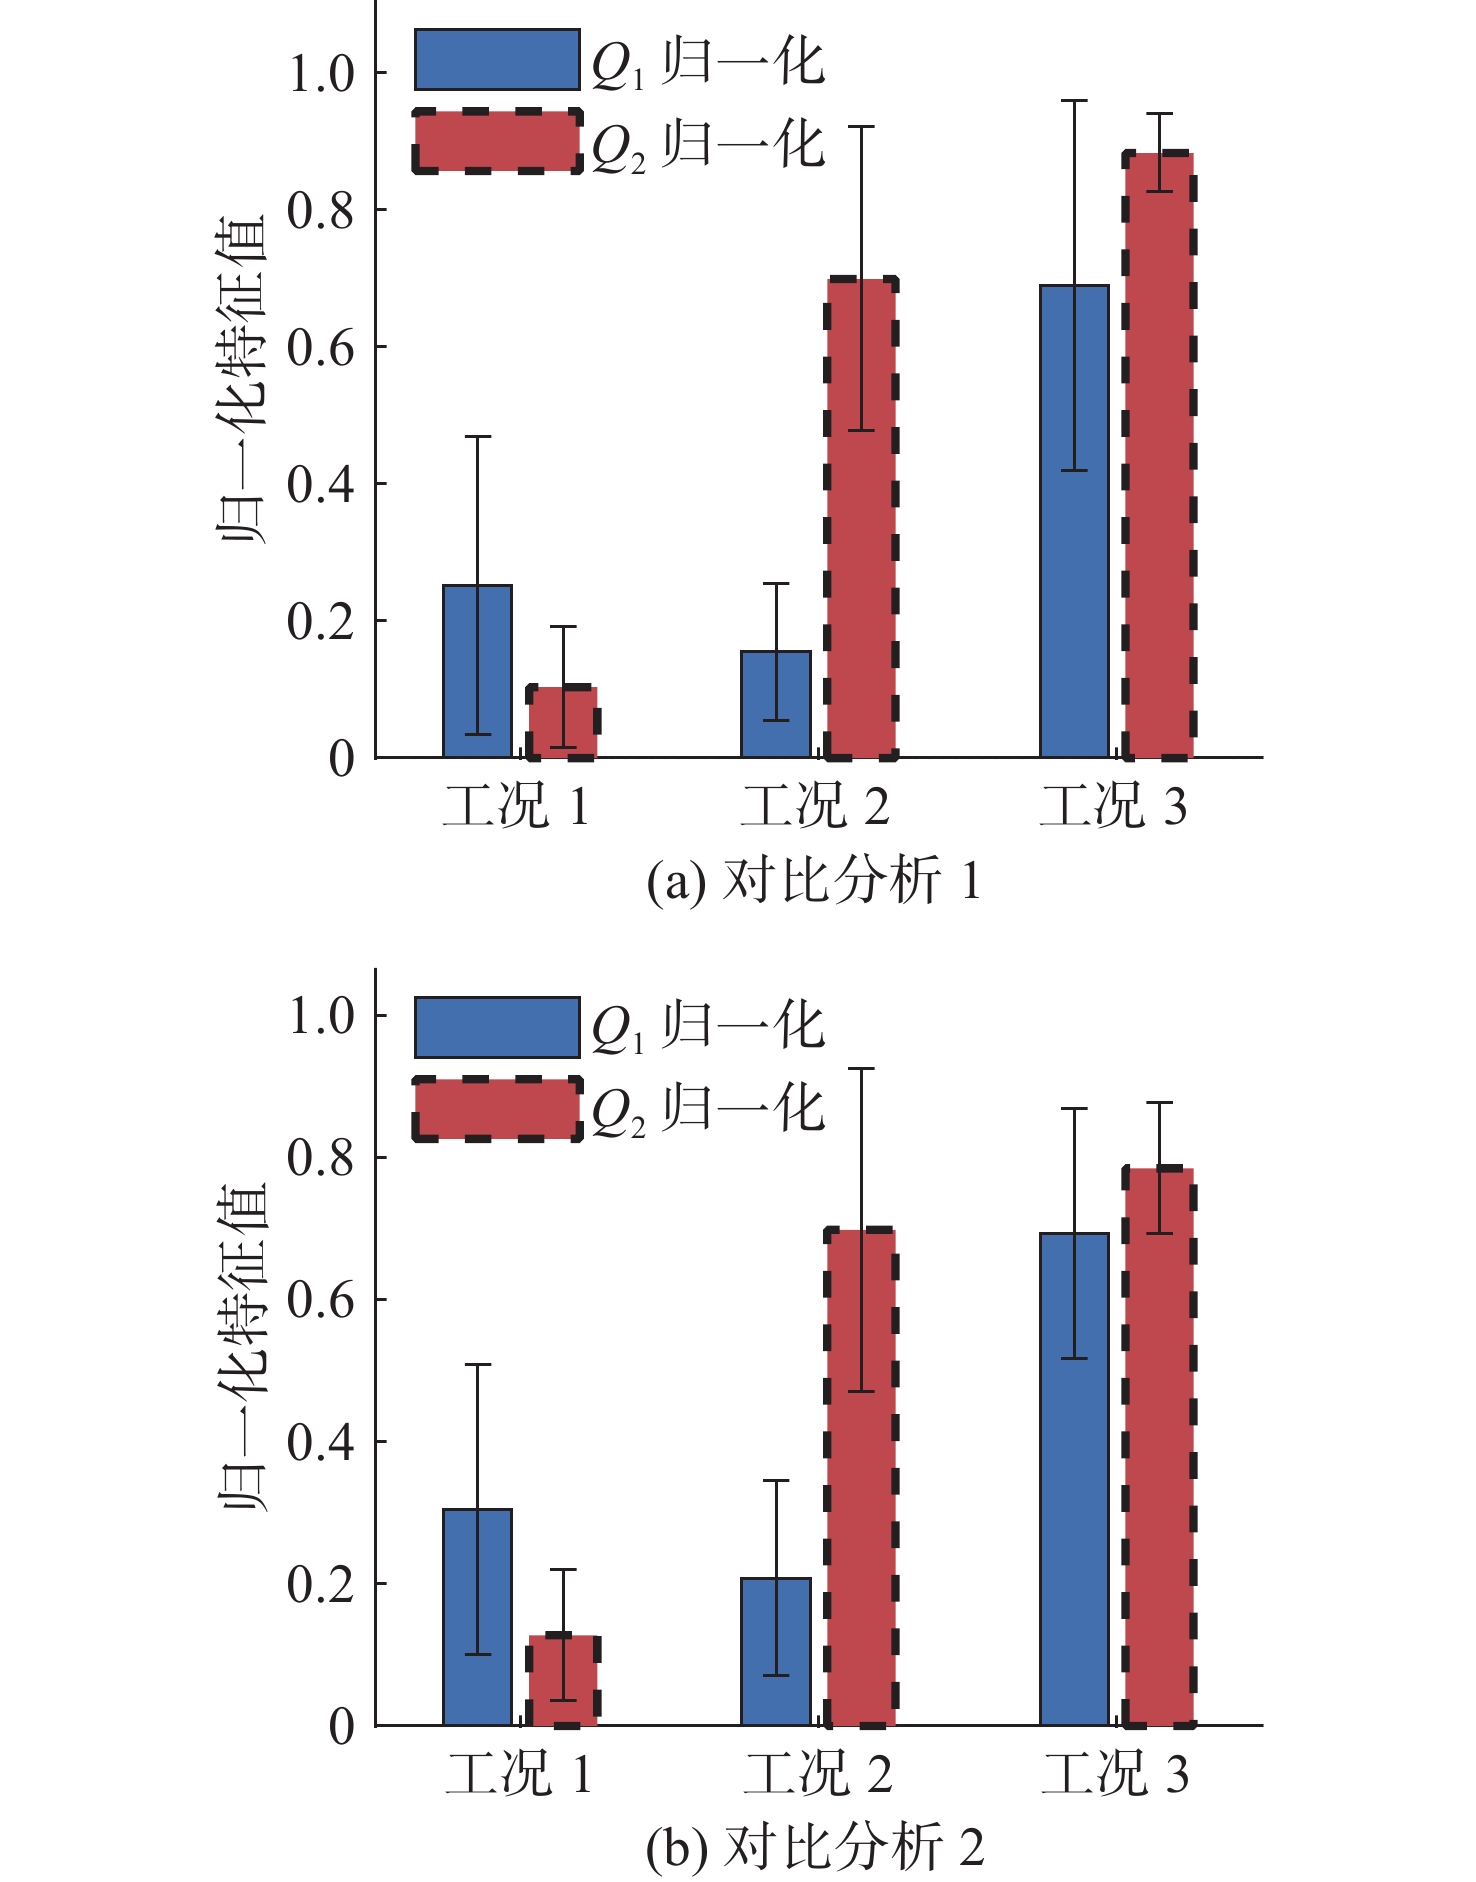
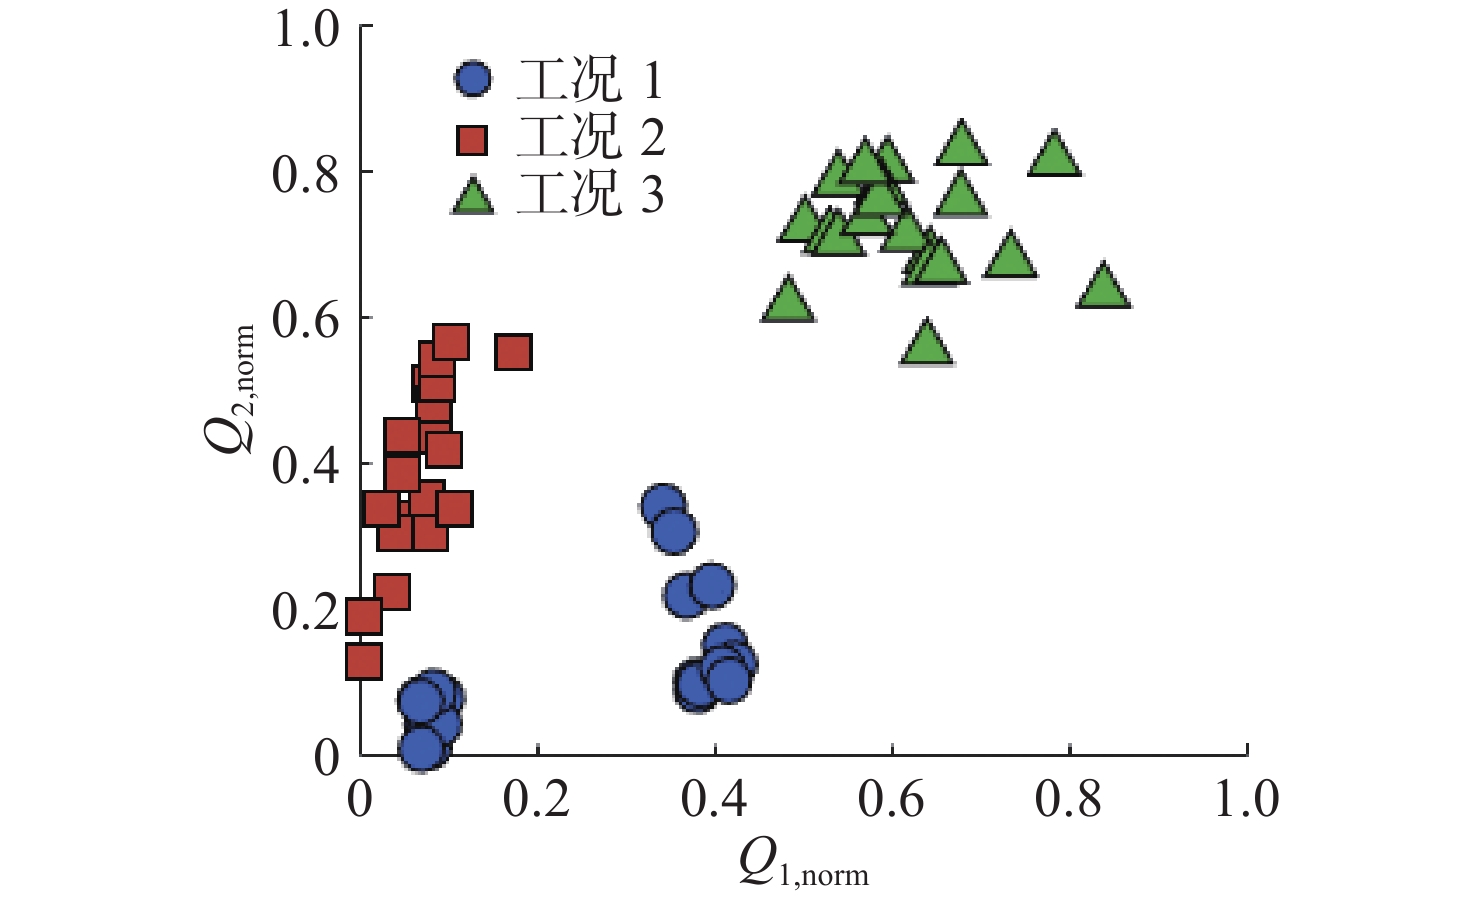
图 4 3类工况下的$ {{\boldsymbol{Q}}}_{{\boldsymbol{1}}{{\_}}{{\bf{norm}}}} $与$ {{\boldsymbol{Q}}}_{2\_\bf{norm}} $
Figure 4. $ {{\boldsymbol{Q}}}_{{\boldsymbol{}}1\_\bf{norm}} $and $ {{\boldsymbol{Q}}}_{{\boldsymbol{2}}\_\bf{norm}} $ under three working conditions
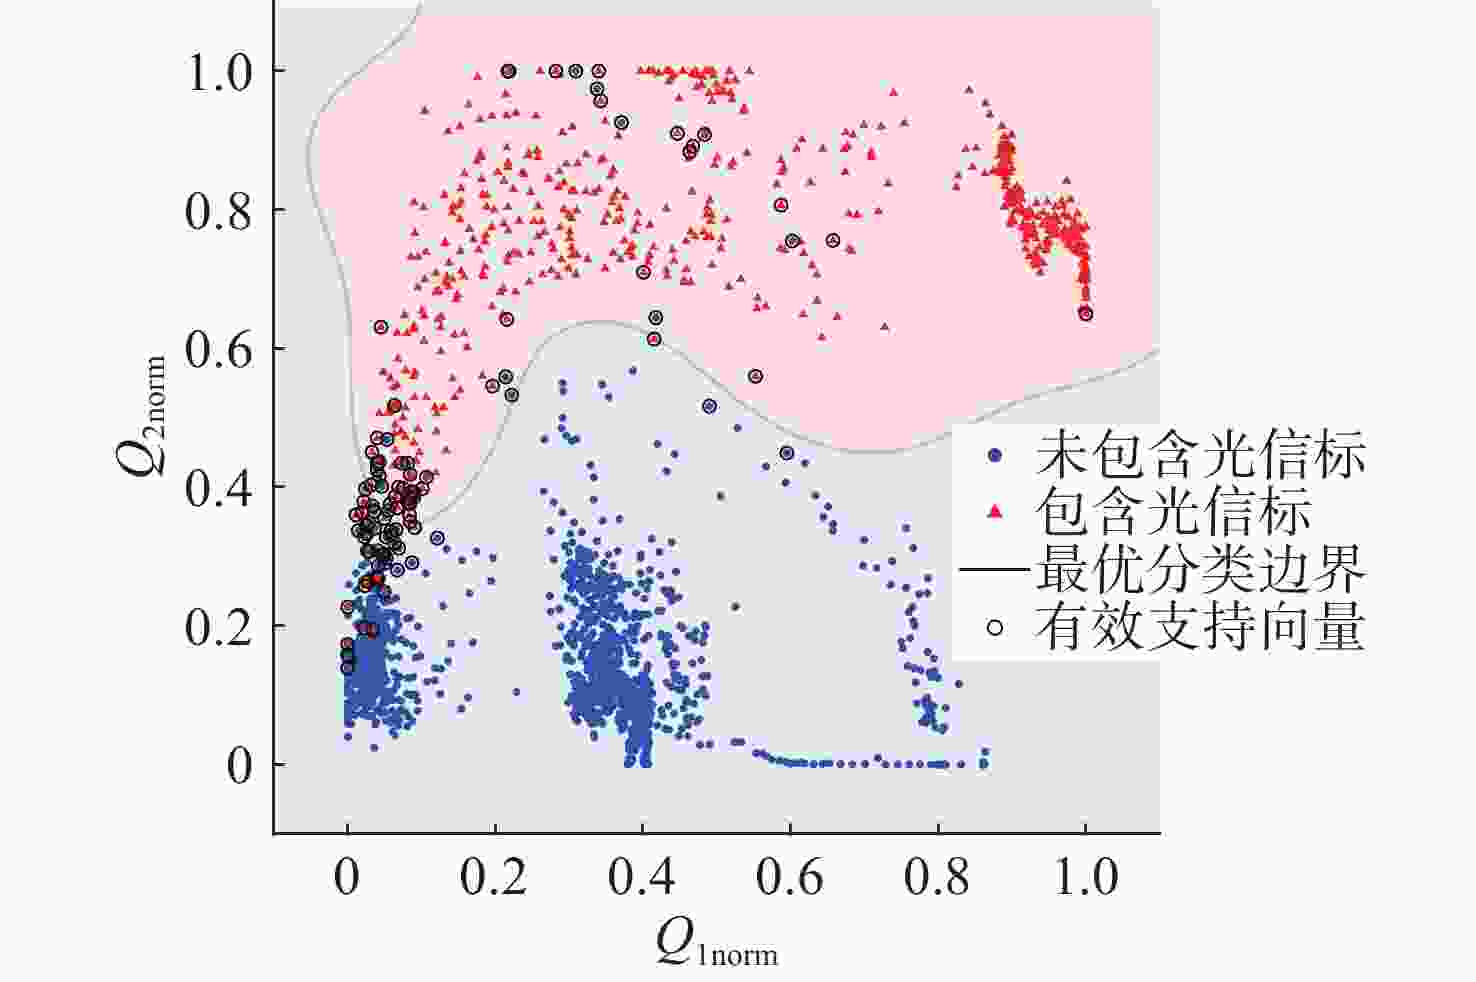
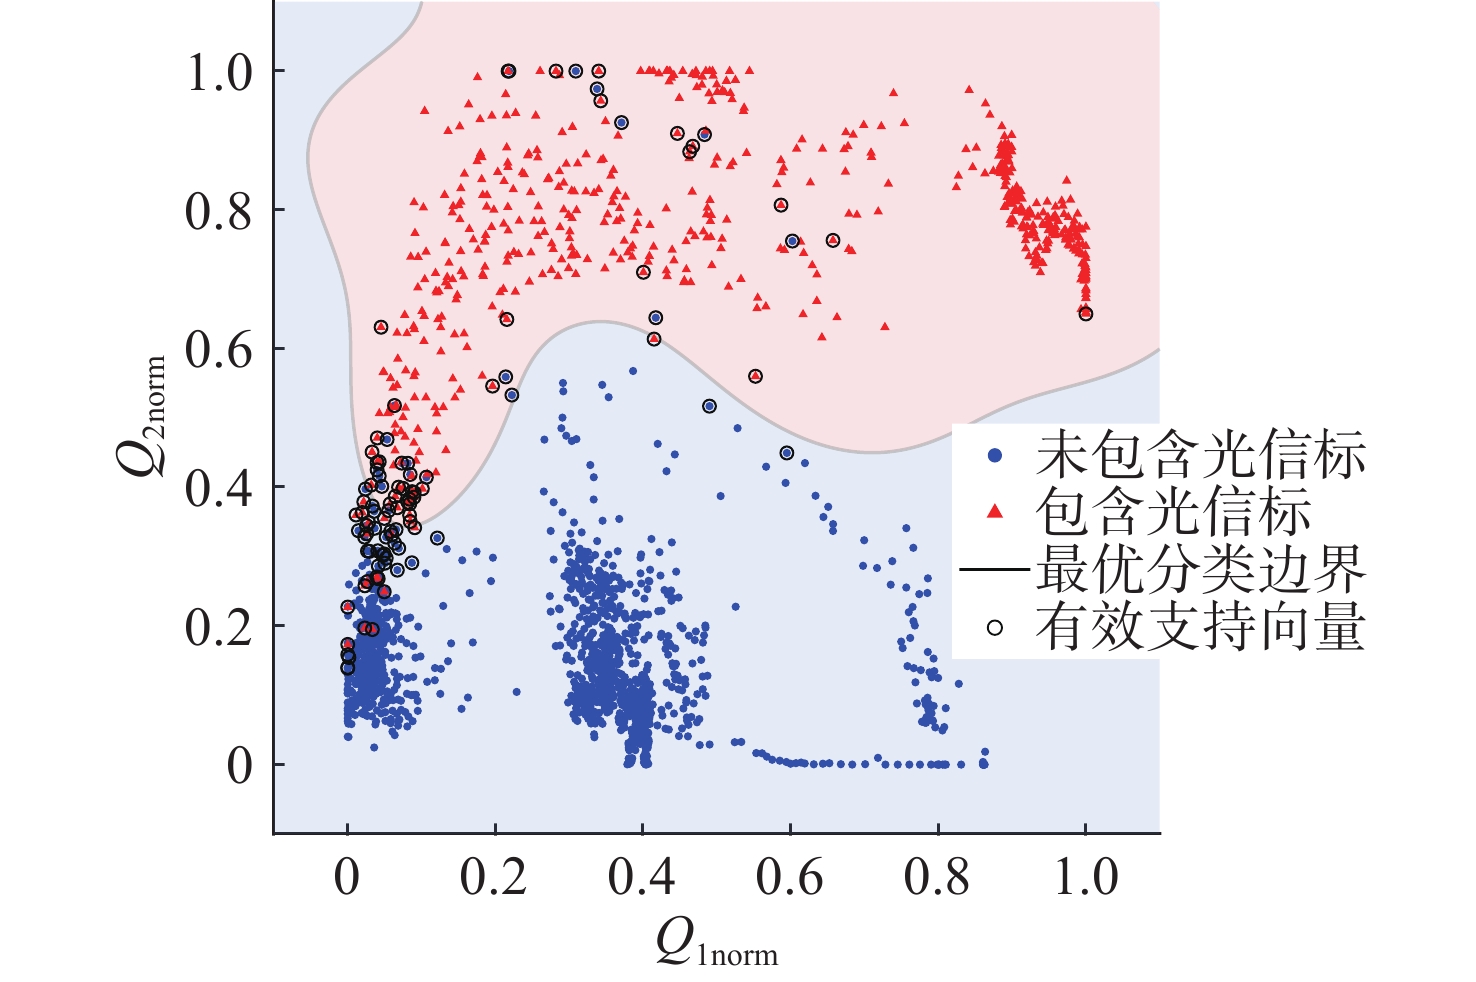
图 6 基于SVM求解的最优决策平面效果图
Figure 6. The effect diagram of the optimal decision plane obtained through the SVM solution
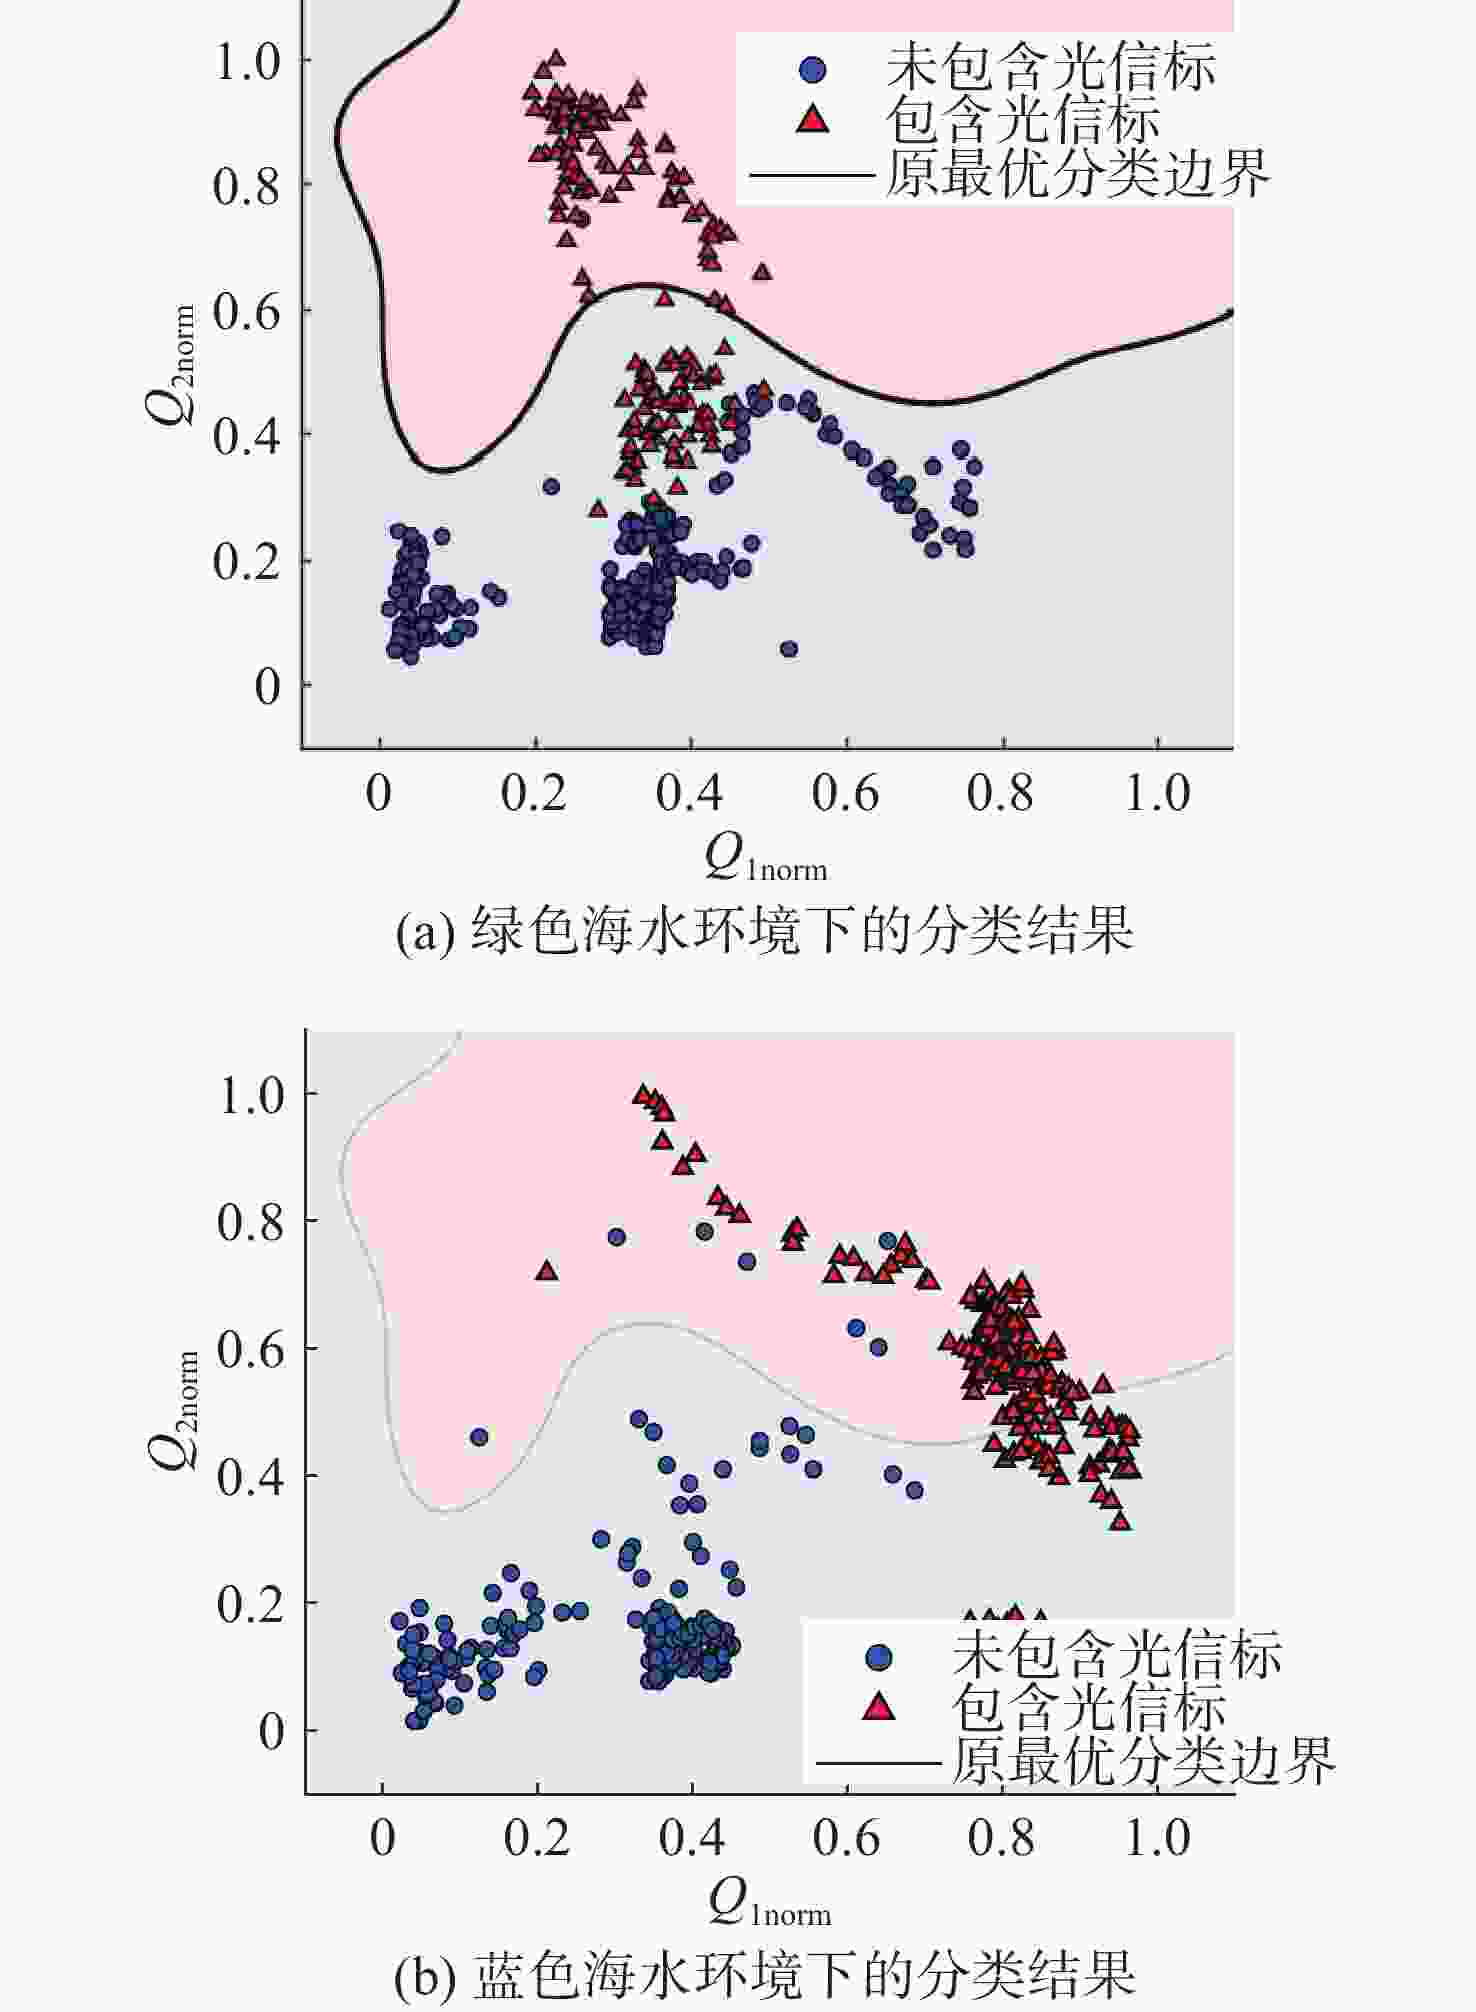
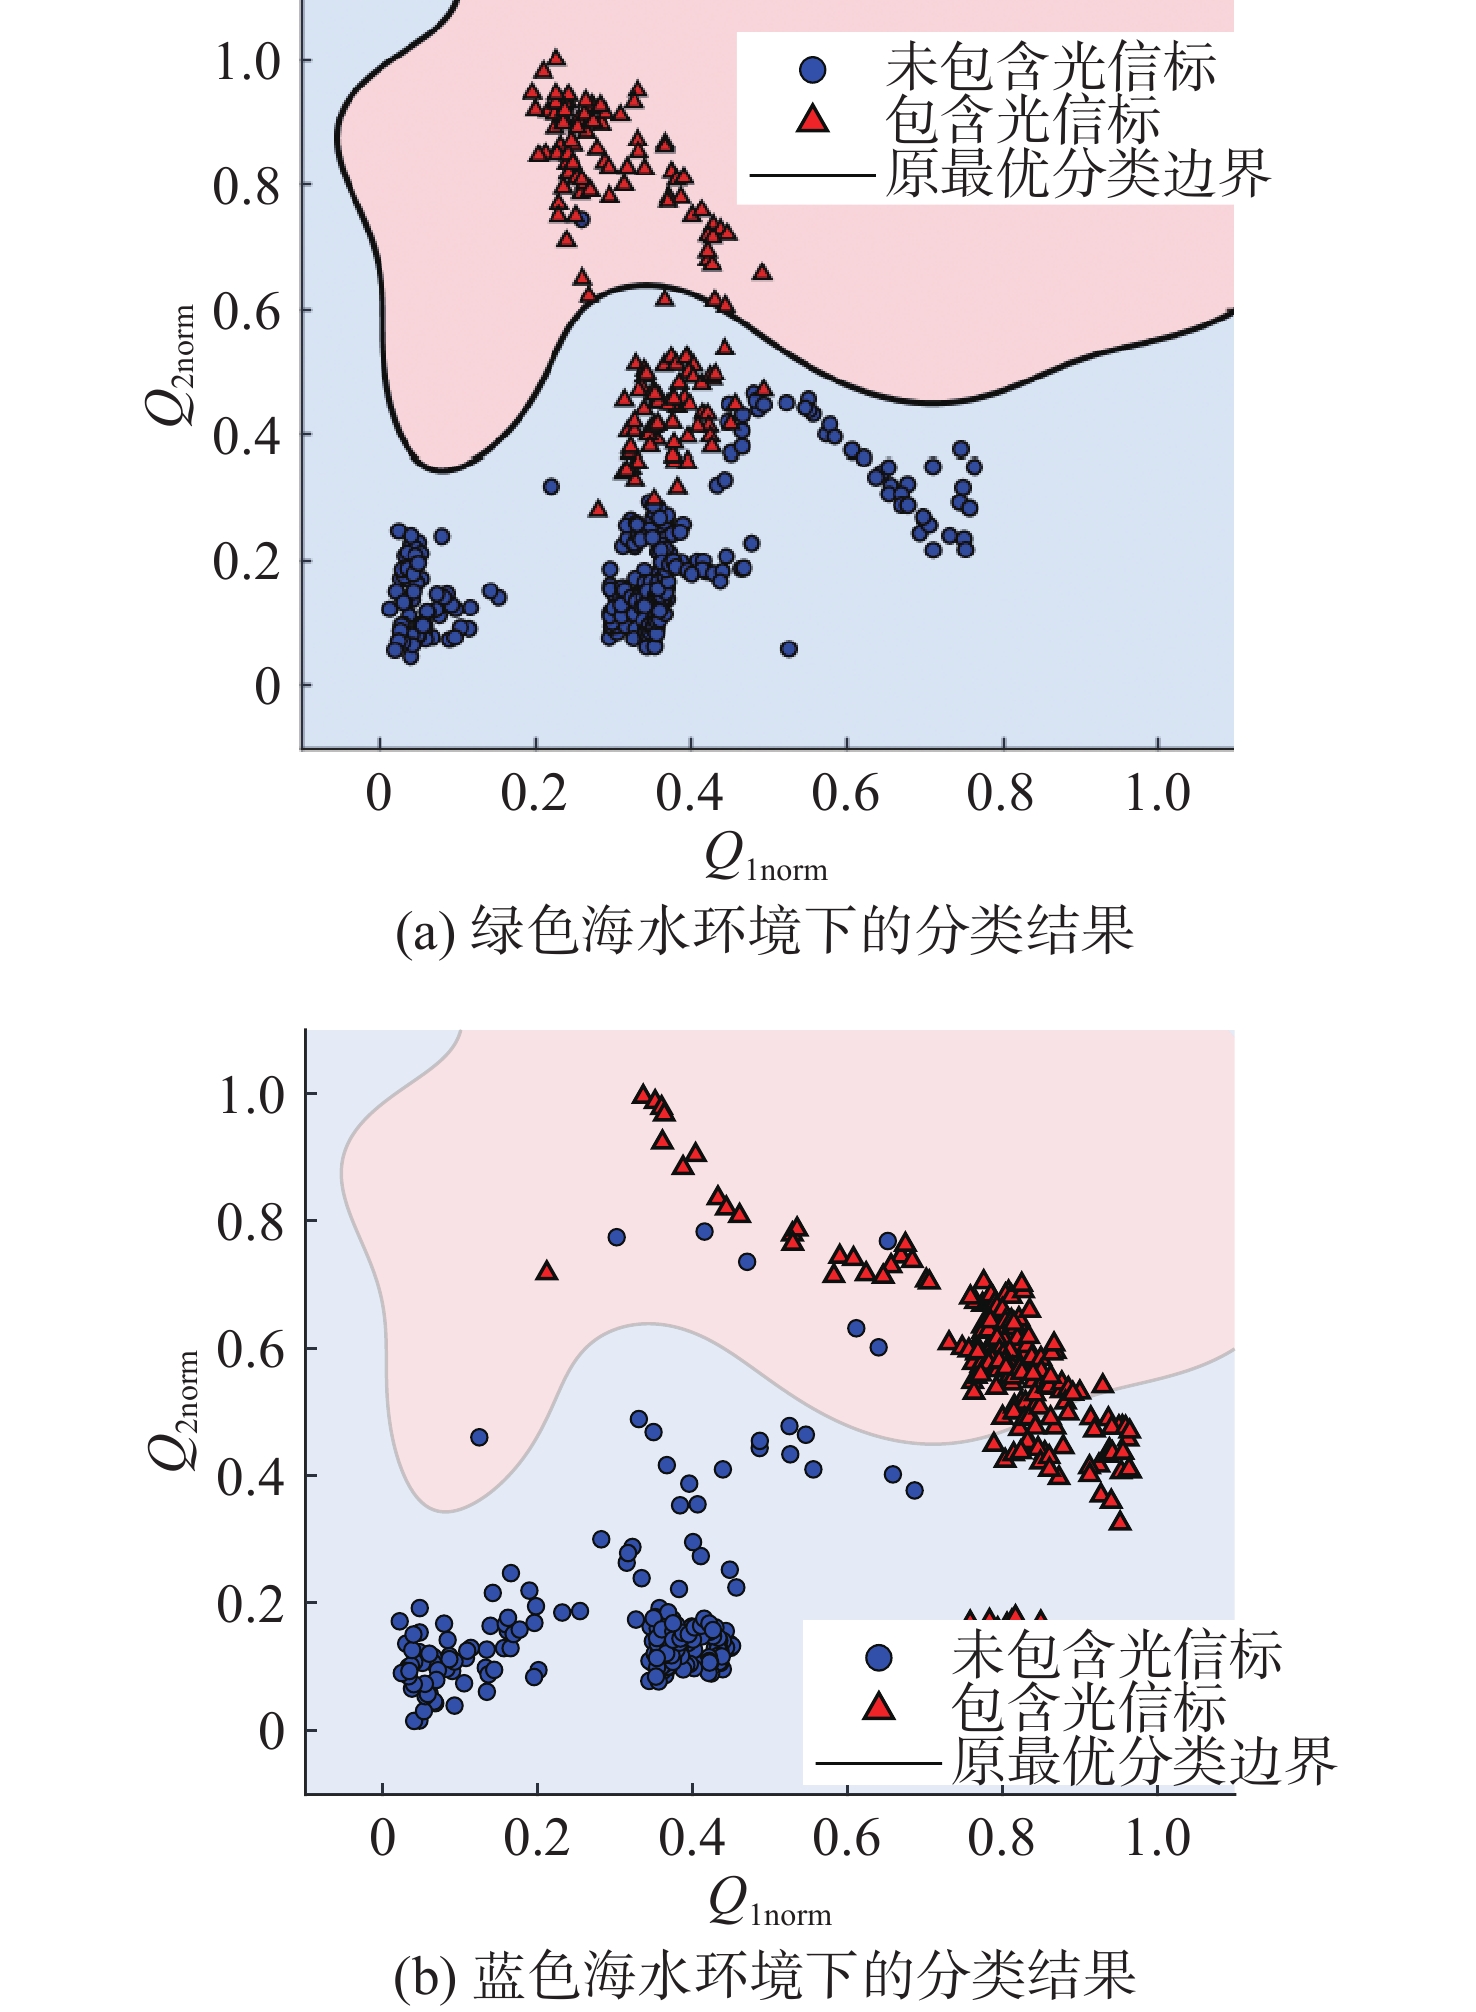
图 7 分类算法泛化性能验证
Figure 7. Generalization performance verification of classification algorithm
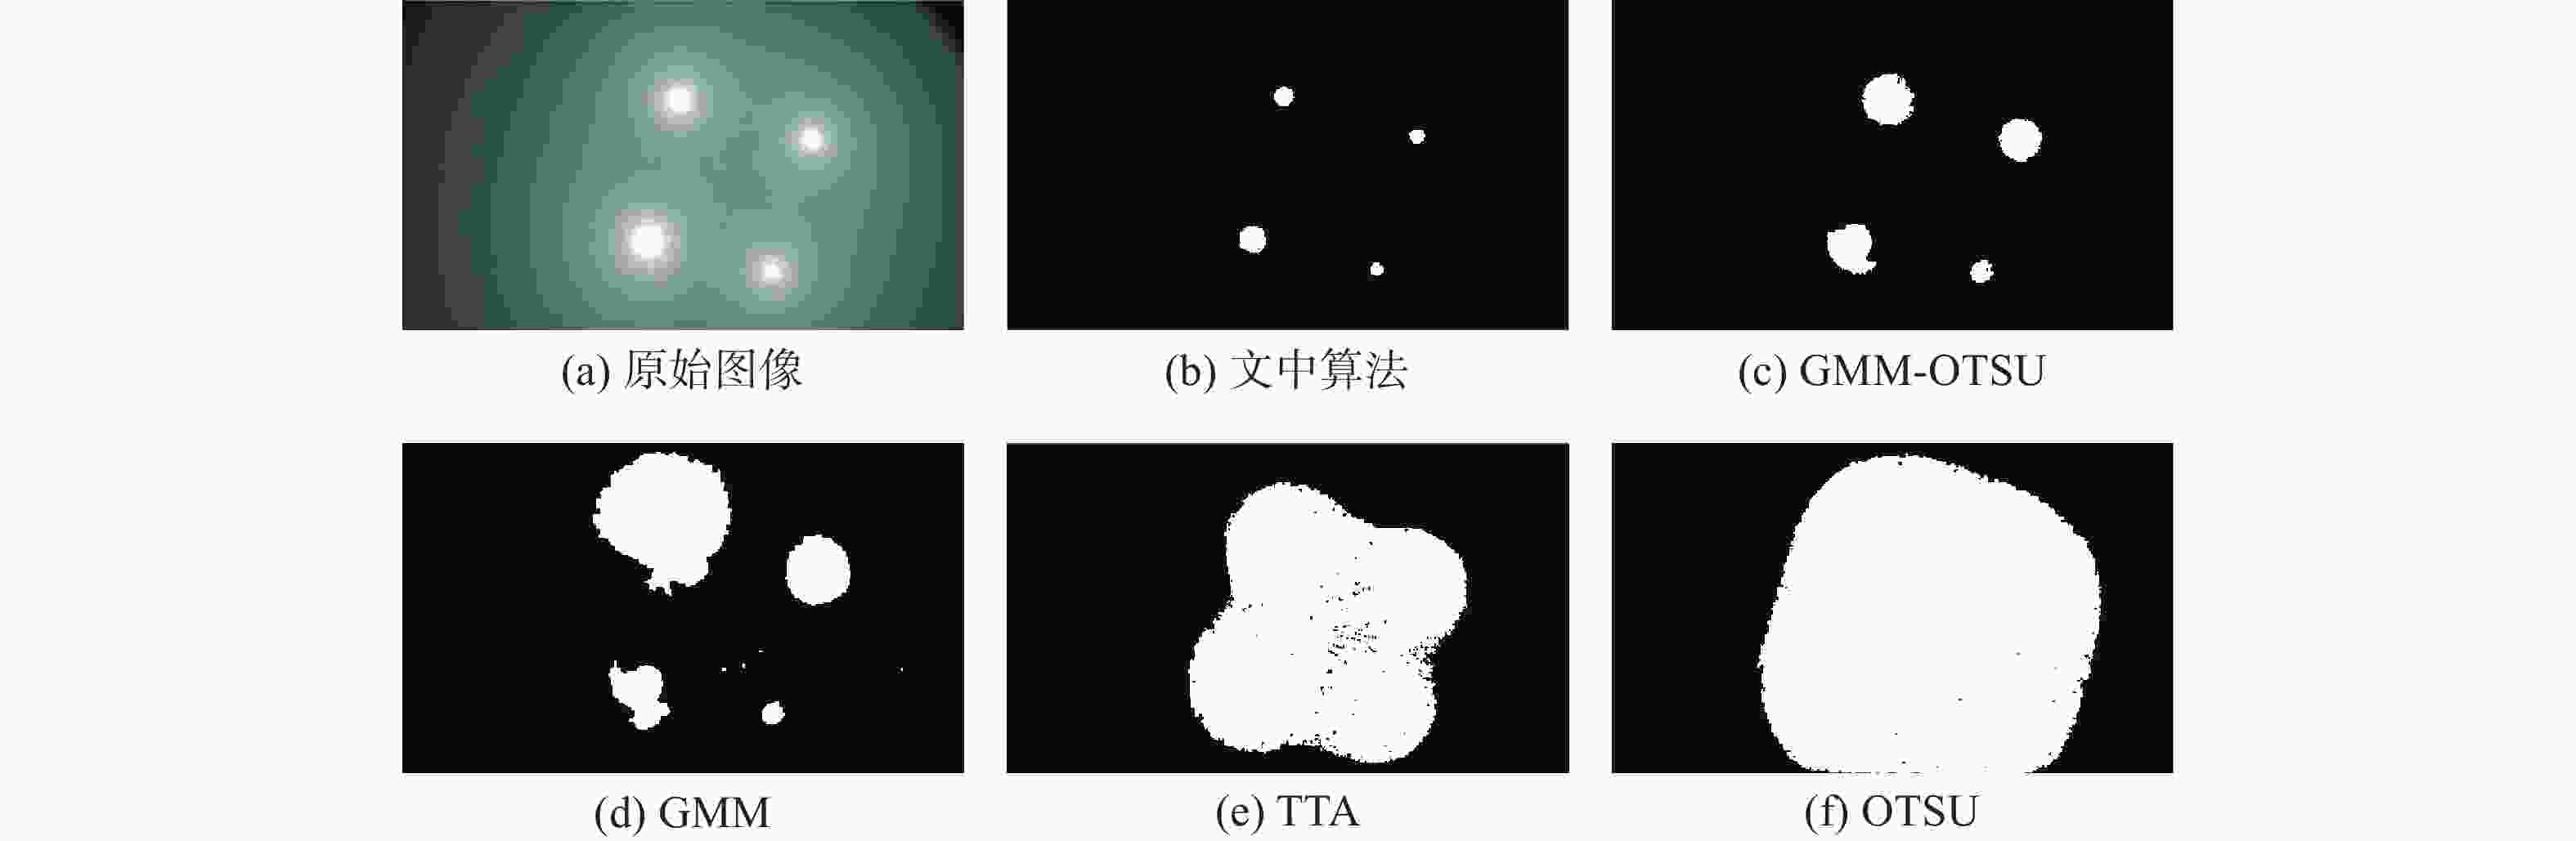
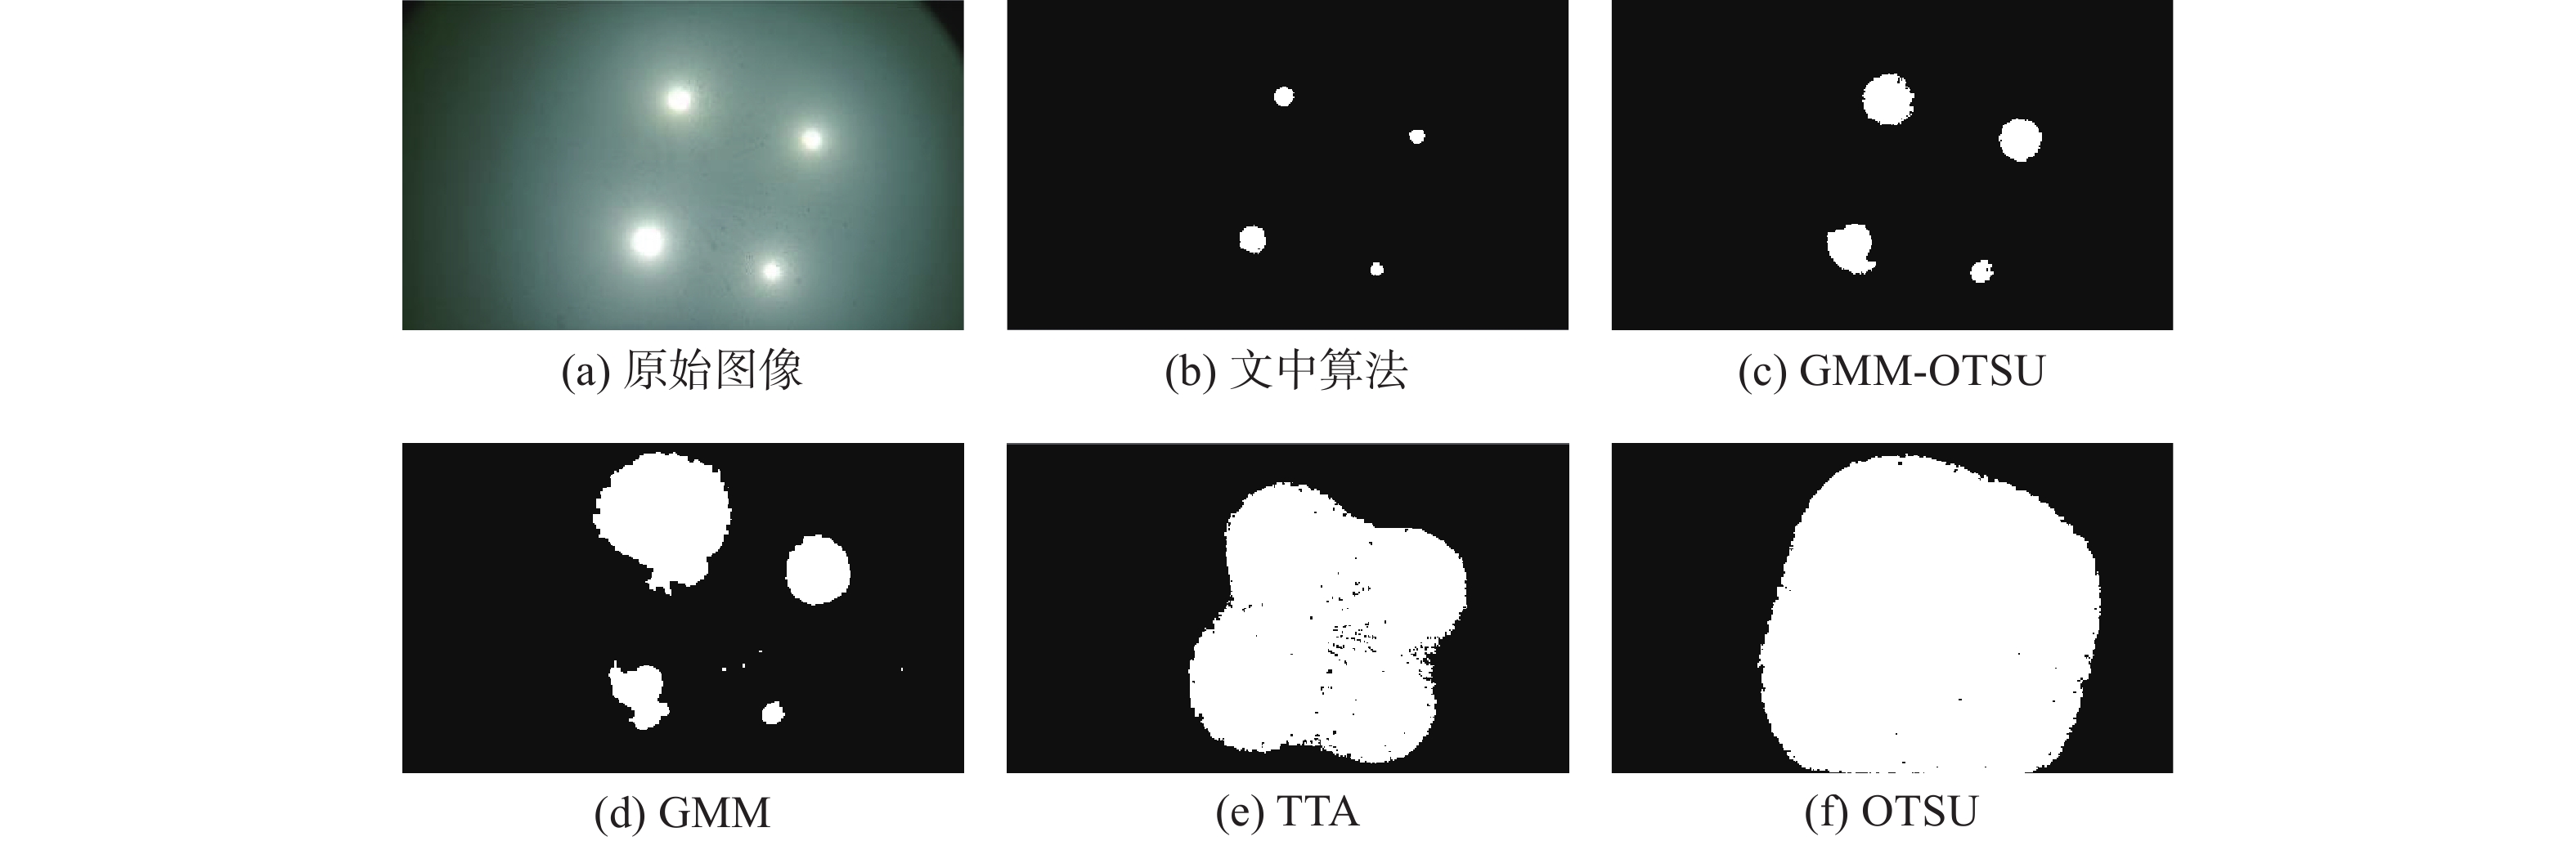
图 10 绿色海水环境下光信标分割结果
Figure 10. Optical beacon segmentation results under green seawater environment
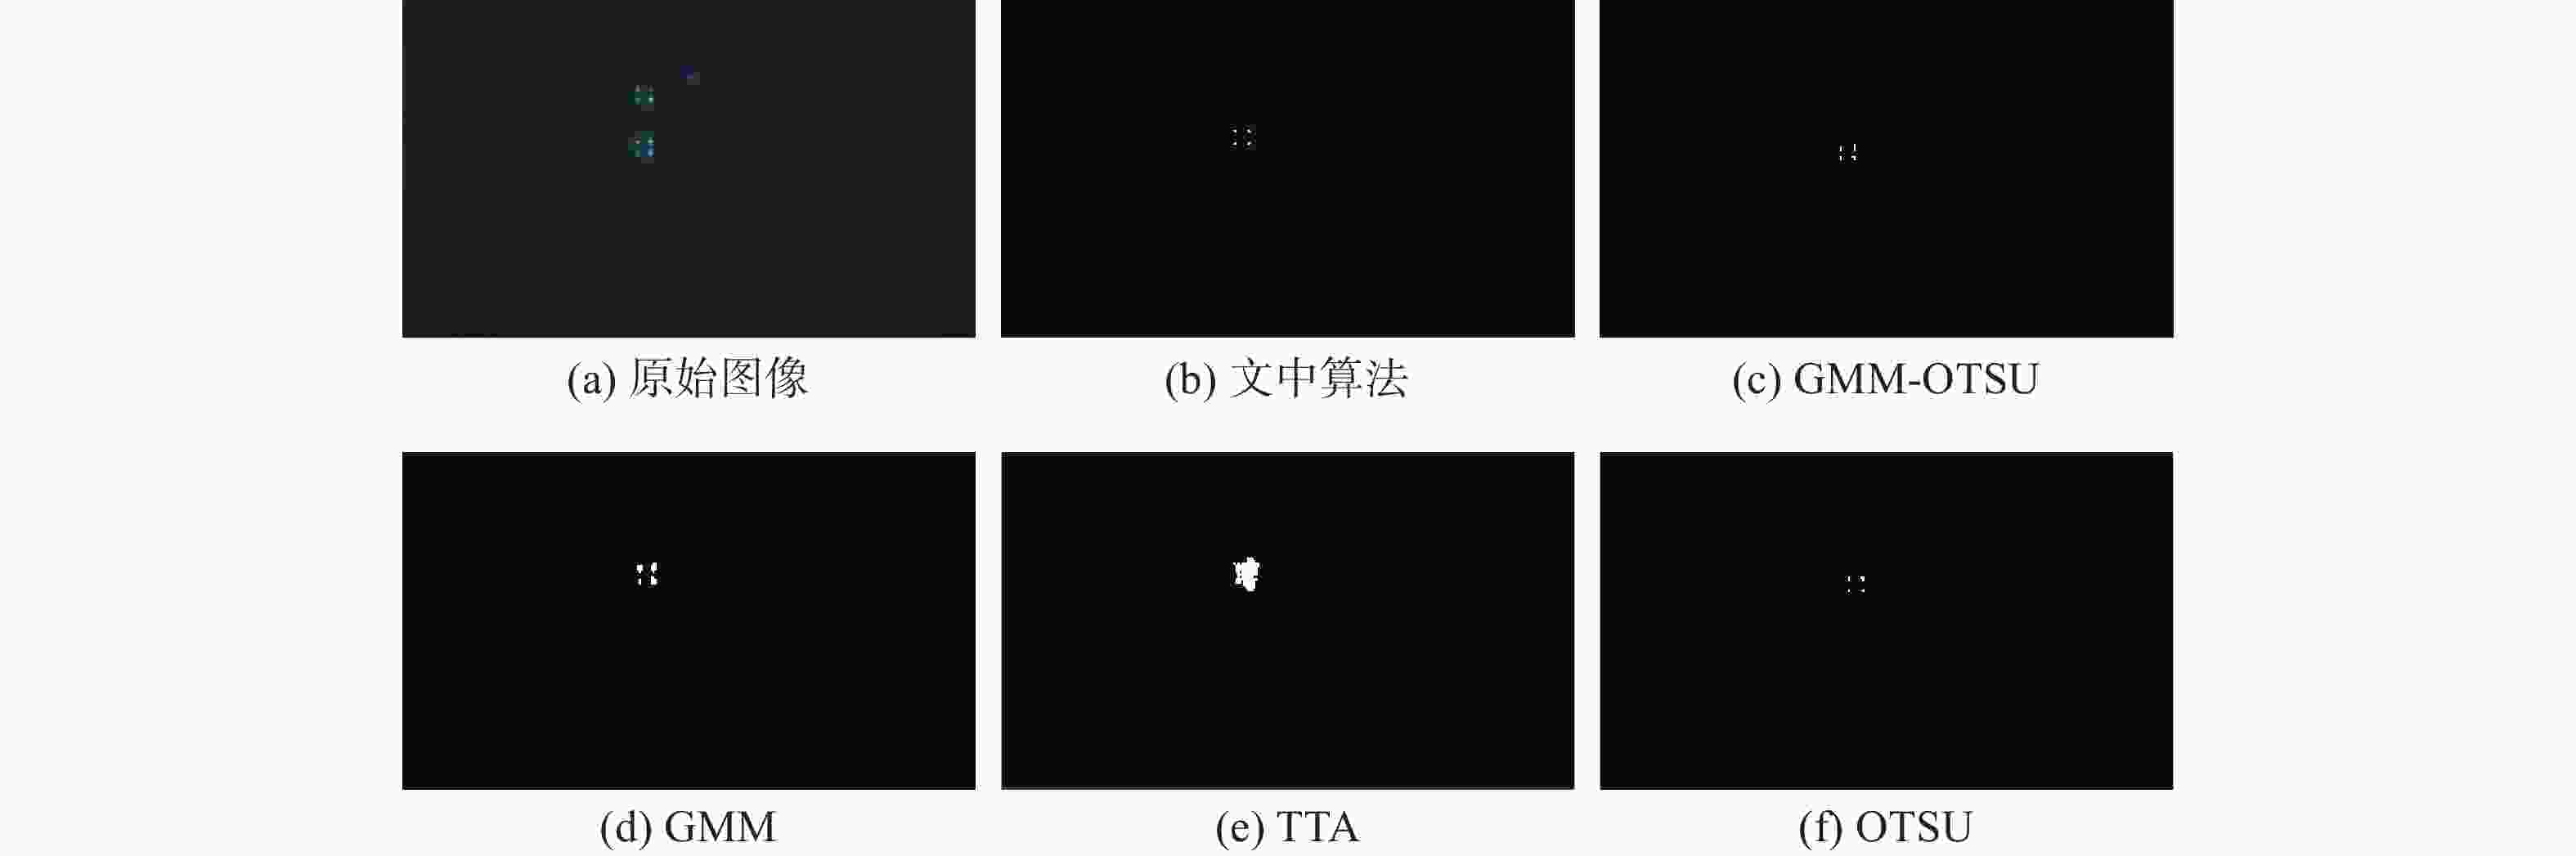
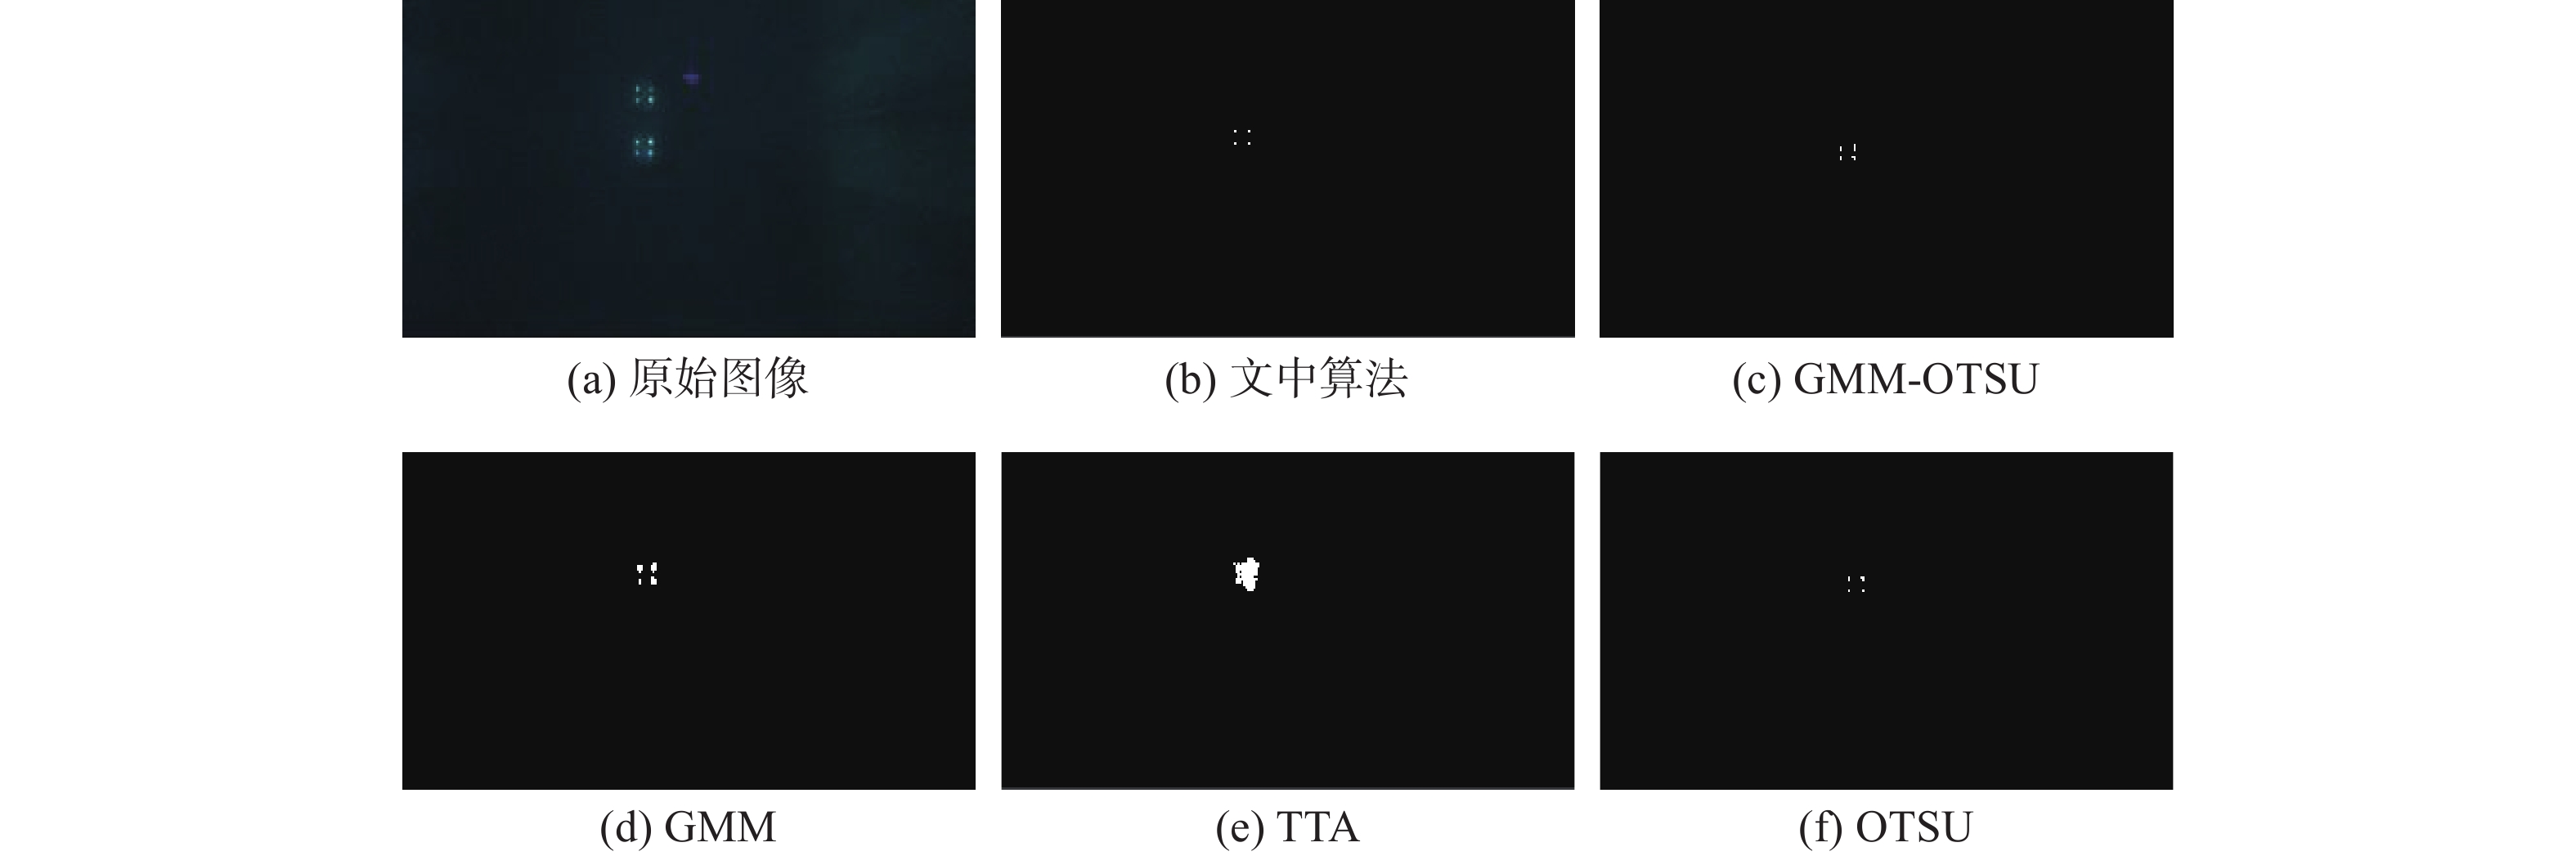
图 11 蓝色海水环境下光信标图像分割结果
Figure 11. Optical beacon segmentation results under blue seawater environment
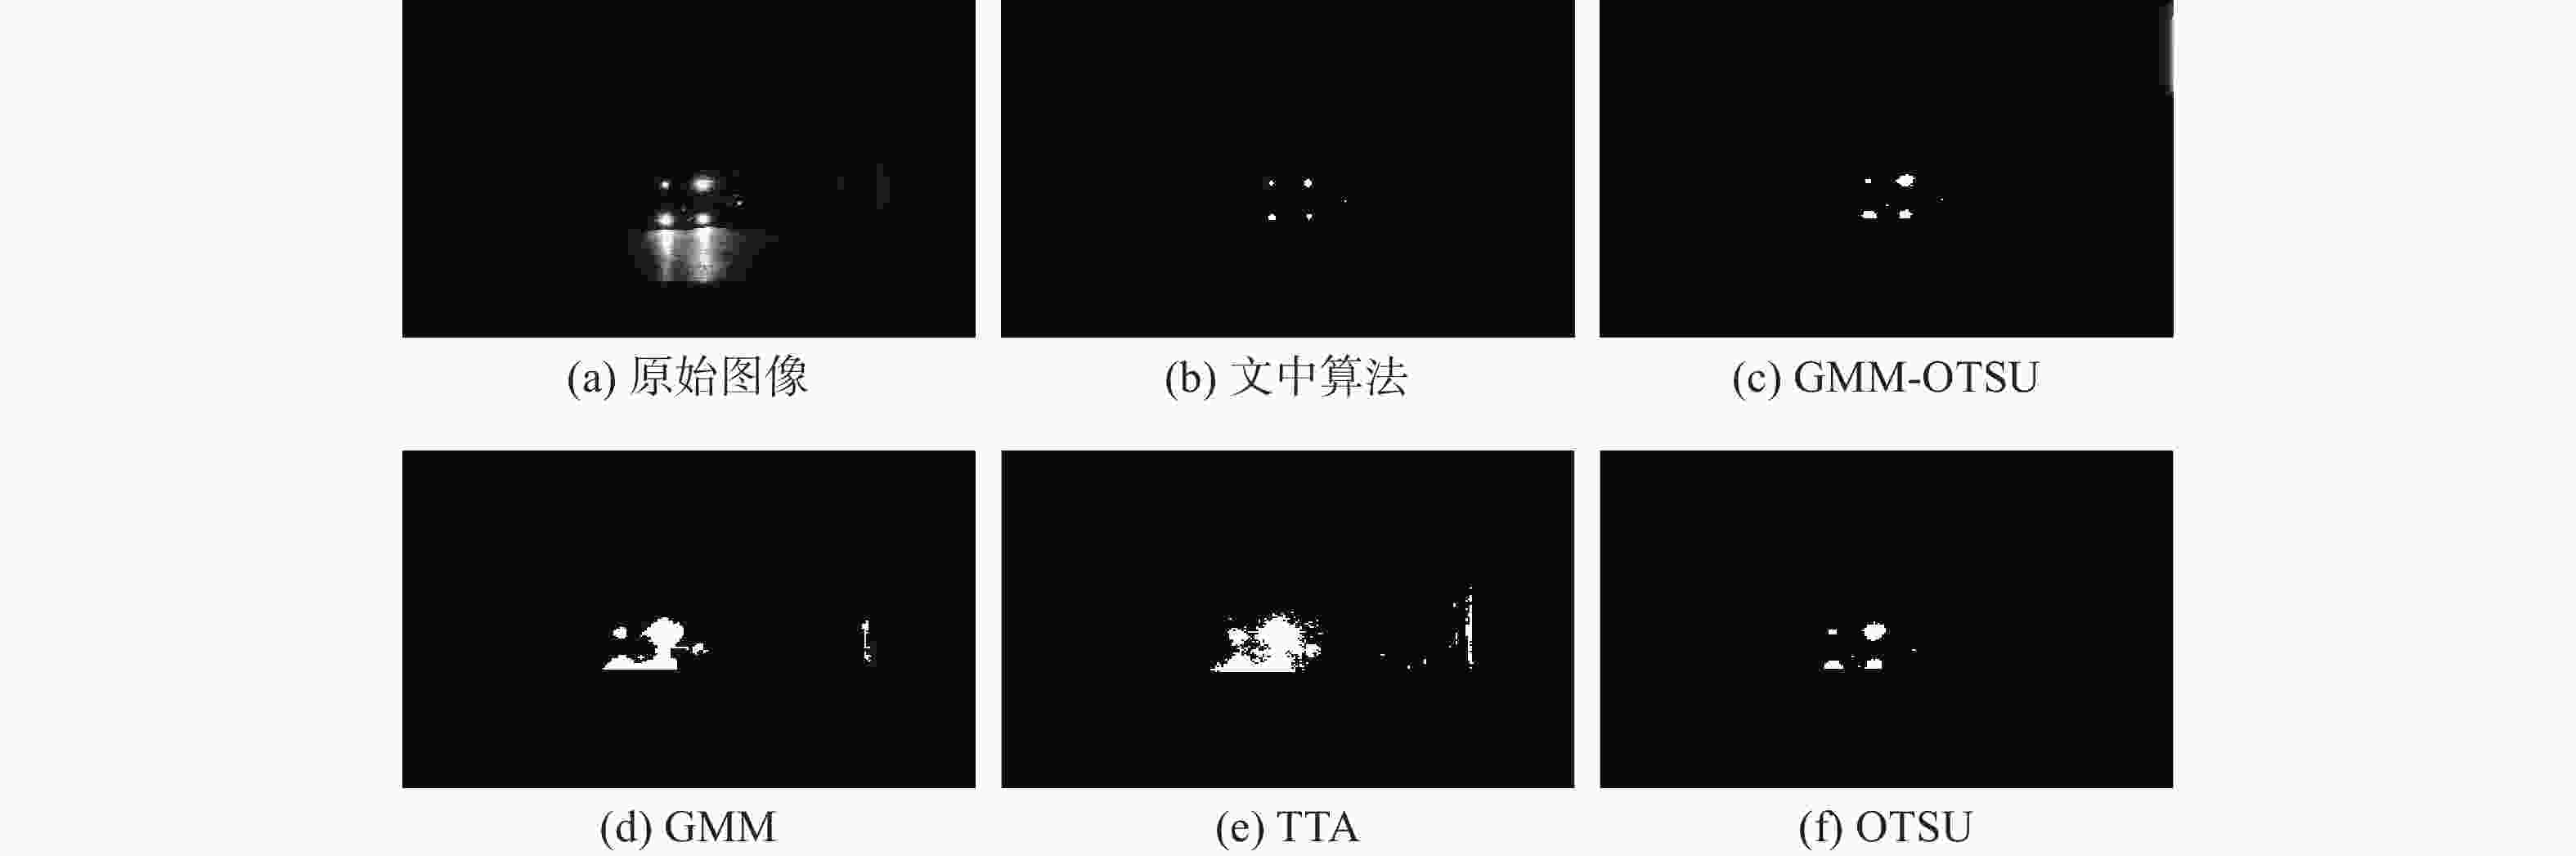
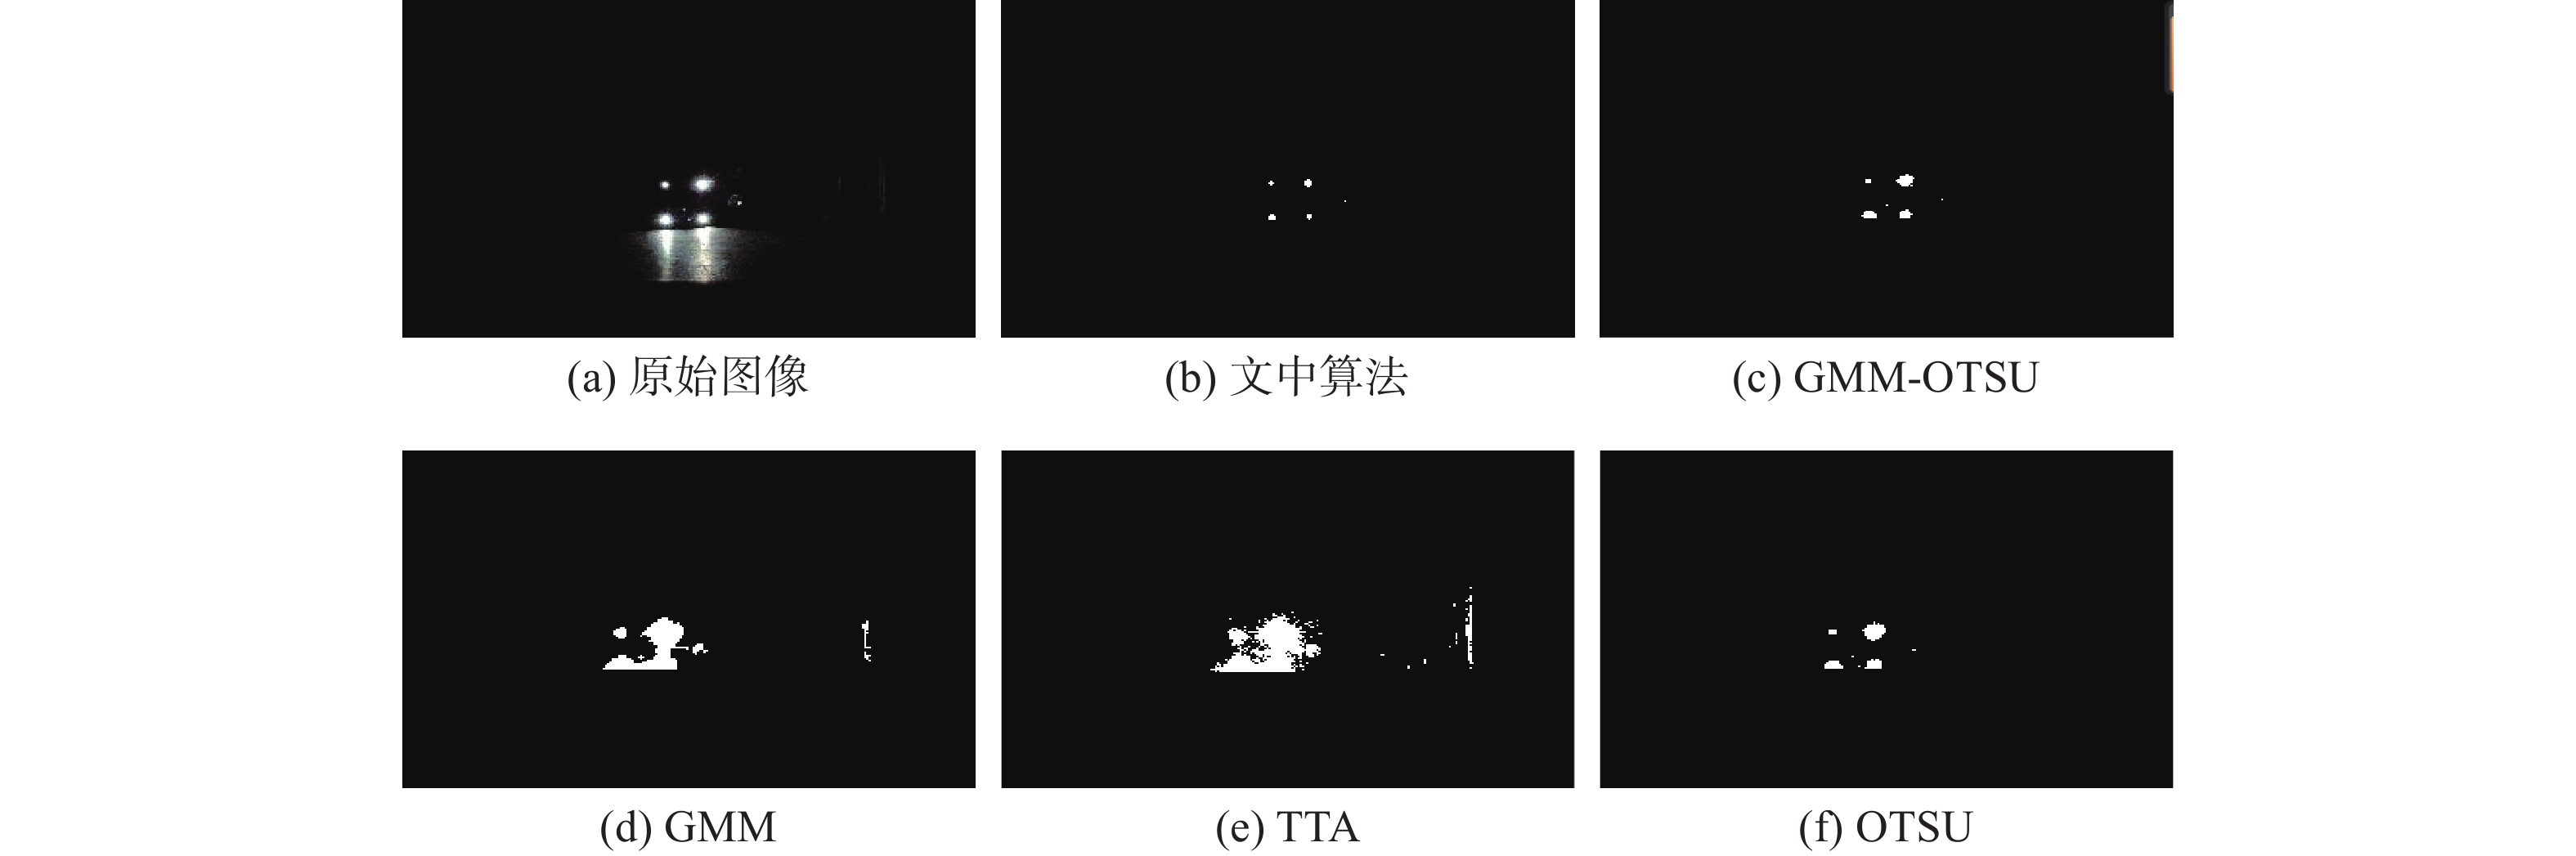
图 12 黑色背景下光信标分割结果
Figure 12. Optical beacon segmentation results under black background
表 1 独立测试集分类结果
Table 1. Classification results on the independent test set
测试数据集 样本数 准确率/% 精确率/% 召回率/% 绿色水体测试集 500 87.4 96.277 76.371 蓝色水体测试集 500 85.6 98.837 54.487 独立测试集 1000 86.5 97.080 67.684  下载: 导出CSV
表 2 SVM模型训练集与测试集样本划分及构成
Table 2. Sample partitioning and composition of training and testing sets for SVM models
数据集 样本数 正样本 负样本 正样本比例/% 用途 训练集 2000 591 1409 29.55 训练 绿色水体测试集 500 156 344 31.2 测试 蓝色水体测试集 500 237 263 47.4 测试
下载: 导出CSV
表 3 不同水体环境下SVM预筛选对算法运行效率的影响
Table 3. The impact of SVM pre-screening on algorithm runtime efficiency under different aquatic environments
数据集 方法 平均
耗时/ms平均
帧率调用
降低/%总耗时
降低/%绿色 GMM-TTA 120.40 8.31 0 0 绿色 SVM+GMM-TTA 60.64 16.49 78.3 49.63 蓝色 GMM-TTA 118.96 8.41 0 0 蓝色 SVM+GMM-TTA 83.01 12.05 59.41 30.22
下载: 导出CSV
表 4 实验场景光学量化条件及结果
Table 4. Optical quantification conditions and results of the experimental scenario
实验场景 透射率均值 采集距
离范围/m采集设备 绿色海水环境 0.632 3~10 ROVMAKER水下
双目相机(视场角 70°)蓝色海水环境 0.880 黑色背景环境 0.987
下载: 导出CSV
表 6 平均圆度计算结果
Table 6. The average roundness calculation results
实验数据集 文中算法 GMM TTA OTSU GMM-OTSU 绿色海水1 0.91 0.69 0.58 0.72 0.85 绿色海水2 0.95 0.75 0.62 0.83 0.91 绿色海水3 0.89 0.55 0.42 0.62 0.79 蓝色海水1 0.73 0.42 0.38 0.62 0.68 蓝色海水2 0.99 0.89 0.80 0.92 0.95 蓝色海水3 0.92 0.85 0.65 0.85 0.88 黑色背景1 0.92 0.71 0.48 0.81 0.87 黑色背景2 0.96 0.77 0.52 0.89 0.93 黑色背景3 0.87 0.53 0.43 0.61 0.82
下载: 导出CSV
表 7 不同数据集下几何质心-灰度加权质心平均一致性误差
Table 7. Geometric centroid-intensity-weighted centroid average consistency error across different datasets
实验数据集 文中算法 GMM TTA OTSU GMM-OTSU 绿色海水1 0.003220 0.7161 2.209 1.298 0.1639 绿色海水2 0.01220 0.8162 1.611 1.158 0.1454 绿色海水3 0.008462 0.6257 1.5232 1.357 0.1432 蓝色海水1 0.0899 0.4118 0.4222 0.3973 0.1253 蓝色海水2 0.1234 0.2962 0.4518 0.4015 0.1535 蓝色海水3 0.0653 0.5069 0.5801 0.4482 0.1637 黑色背景1 0.0052 0.6420 0.9384 0.3644 0.0676 黑色背景2 0.0259 0.5553 1.2836 0.2368 0.0619 黑色背景3 0.0233 0.6660 0.7933 0.2362 0.0832
下载: 导出CSV
-
[1] 高之川, 胡震, 胡晓函. 一种重型AUV水下动态对接回收装置的设计[J]. 舰船科学技术, 2025, 47(15): 77-83. doi: 10.3404/j.issn.1672-7649.2025.15.013Gao Z H, Hu Z, Hu X H. Design of a heavy AUV underwater dynamic docking recovery device[J]. Ship Science and Technology, 2025, 47(15): 77-83. doi: 10.3404/j.issn.1672-7649.2025.15.013 [2] 卢有旺, 夏英凯, 徐国华, 等. 面向UUV对接的视觉引导三维轨迹跟踪控制研究[J]. 中国舰船研究, 2024, 19(1): 290-304. doi: 10.19693/j.issn.1673-3185.03242Lu Y W, Xia Y K, Xu G H, et al. Research on three-dimensional trajectory tracking control based on visual guidance for UUV docking[J]. Chinese Journal of Ship Research, 2024, 19(1): 290-304. doi: 10.19693/j.issn.1673-3185.03242 [3] 纪珣, 冷娜, 郭晖. 水下图像增强与复原技术进展与展望[J]. 计算机辅助设计与图形学学报, 2024, 36(6): 805-830.Ji X, Leng N, Guo H. Underwater image enhancement and restoration techniques: state-of-the-art methods and prospects[J]. Journal of Computer-Aided Design & Computer Graphics, 2024, 36(6): 805-830. [4] Zhong L, Li D, Lin M, et al. A fast binocular localisation method for AUV docking[J]. Sensors, 2019, 19(7): 1735. doi: 10.3390/s19071735 [5] Bosch J, Gracias N, Ridao P, et al. Close-range tracking of underwater vehicles using light beacons[J]. Sensors, 2016, 16(4): 429. doi: 10.3390/s16040429 [6] Zhang B, Zhong P, Yang F, et al. Fast underwater optical beacon finding and high accuracy visual ranging method based on deep learning[J]. Sensors, 2022, 22(20): 7940. doi: 10.3390/s22207940 [7] 王嘉, 关夏威, 张昊, 等. 结合背景建模的水下运动发光目标阈值分割方法[J]. 水下无人系统学报, 2025, 33(1): 92-98. doi: 10.11993/j.issn.2096-3920.2024-0107Wang J, Guan X W, Zhang H, et al. Threshold-based segmentation method for underwater moving luminous targets combined with background modeling[J]. Journal of Unmanned Undersea Systems, 2025, 33(1): 92-98. doi: 10.11993/j.issn.2096-3920.2024-0107 [8] Zhang J, Su H, Zhang T, et al. Multi-scale fusion underwater image enhancement based on HSV color space equalization[J]. Sensors, 2025, 25(9): 2850. doi: 10.3390/s25092850 [9] 习腾彦, 袁丽华, 王树鹏. 基于局部对比度的自适应Top-Hat红外小目标检测[J]. 激光与光电子学进展, 2023, 60(16): 1628003. doi: 10.3788/lop222850Xi T Y, Yuan L H, Wang S P. Adaptive Top-Hat infrared small target detection based on local contrast[J]. Laser & Optoelectronics Progress, 2023, 60(16): 1628003. doi: 10.3788/lop222850 [10] 高绍姝, 金伟其, 王延江, 等. 灰度融合图像目标与背景感知对比度客观评价模型[J]. 红外与激光工程, 2015, 44(5): 1660-1665. doi: 10.3969/j.issn.1007-2276.2015.05.047Gao S S, Jin W Q, Wang Y J, et al. Target-background perceptual contrast metric for gray fusion images[J]. Infrared and Laser Engineering, 2015, 44(5): 1660-1665. doi: 10.3969/j.issn.1007-2276.2015.05.047 [11] Dong L, Huo Y. A new open-set recognition method for fault diagnosis of AUV[J]. Applied Sciences, 2026, 16(7): 3526. doi: 10.3390/app16073526 [12] Yin B, Shi H, Liu Q. A wideband transient signal detection method based on nonlinear support vector machine[C]//2023 4th Information Communication Technologies Conference(ICTC), 2023: 208-212. [13] Li Y, Zhong X, Liu H, et al. Urban built-up area extraction using triangle threshold algorithm and Naive Bayes classification model with multidata fusion[J/OL]. Scientific Reports, 2025, 15(1): 40175. DOI: 10.1038/s41598-025-23986-w. [14] 张军, 代科学, 李国辉. 基于HSV颜色空间和码本模型的运动目标检测[J]. 系统工程与电子技术, 2008, 30(3): 423-427. doi: 10.3321/j.issn:1001-506X.2008.03.008Zhang J, Dai K X, Li G H. Moving objects detection based on HSV color-space and codebook model[J]. Systems Engineering and Electronics, 2008, 30(3): 423-427. doi: 10.3321/j.issn:1001-506X.2008.03.008 [15] Jin Z, Ma Y, Min L, et al. Variational image dehazing with a novel underwater dark channel prior[J]. Inverse Probl. Imaging, 2024, 19: 334-354. [16] Drews P, Nascimento E, Moraes F, et al. Transmission estimation in underwater single images[C]//Proceedings of the IEEE international conference on computer vision workshops. 2013: 825-830. [17] Otsu N. A threshold selection method from gray-level histograms[J]. Automatica, 1975, 11: 285-296. doi: 10.1016/0005-1098(75)90044-8 [18] 周立波, 张华龙, 王海波, 等. 面向复杂干扰背景的锥套识别与位姿估计方法[J]. 光电工程, 2025, 52(12): 250367. doi: 10.12086/oee.2025.250367Zhou L B, Zhang H L, Wang H B, et al. Cone-drogue recognition and pose estimation method for complex interference background[J]. Opto-Electronic Engineering, 2025, 52(12): 250367. doi: 10.12086/oee.2025.250367 [19] 赵卫东, 陈为胜, 朱军, 等. 基于线结构光中心线亚像素提取与优化算法[J]. 安徽工业大学学报(自然科学版), 2025, 42(6): 652-659. doi: 10.12415/j.issn.1671-7872.25001Zhao W D, Chen W S, Zhu J, et al. Subpixel extraction and optimization algorithm for line-structured light centerline[J]. Journal of Anhui University of Technology (Natural Science), 2025, 42(6): 652-659. doi: 10.12415/j.issn.1671-7872.25001 -

 下载:

 点击查看大图
计量
- 文章访问数: 3
- HTML全文浏览量: 1
- PDF下载量: 6
- 被引次数: 0