

Bayesian Space-Time Adaptive Target Detector in Reverberation Edge Environments
-
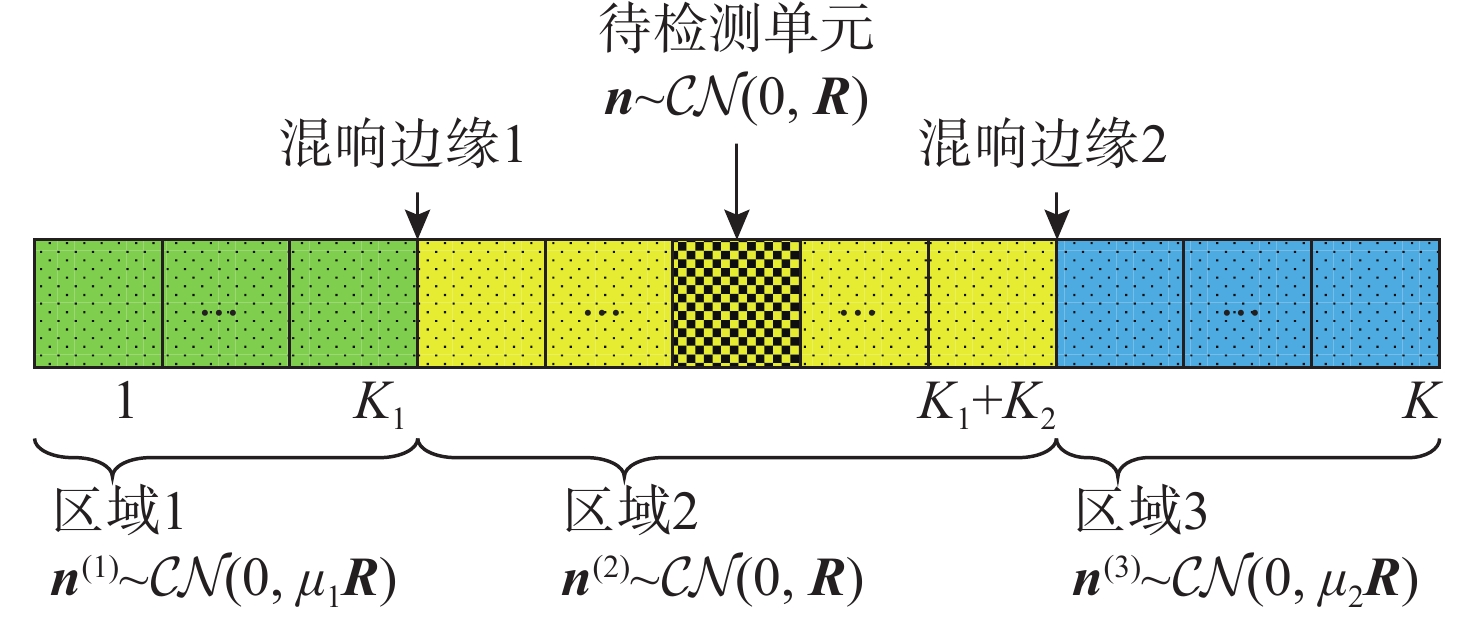
摘要: 主动声呐在混响边缘环境中面临接收数据非均匀问题, 导致与待检测单元背景统计特性一致的辅助数据数量锐减; 与此同时现有检测方法利用数据的样本协方差矩阵估计混响协方差矩阵时精度有限, 导致目标检测性能不可避免地出现损失。文中针对上述问题, 基于贝叶斯检验方法进行了混响边缘环境下的两步广义似然比目标检测研究, 提出混响边缘环境下的贝叶斯厄米特目标检测器(BH-TD-REE)和混响边缘环境下的贝叶斯谱对称目标检测器(BS-TD-REE)2种自适应检测方法。BH-TD-REE和BS-TD-REE方法均将混响协方差矩阵视为随机变量, 采用最大后验估计准则代替传统的样本协方差估计。此外, BS-TD-REE方法还利用混响协方差矩阵的谱对称特性, 等效扩展了辅助数据数量, 降低检测器对均匀辅助数据的需求。仿真结果表明, 所提方法较传统方法有效提升了目标检测性能和鲁棒性, 在辅助数据数量受限情况下的检测性能优势更显著。
-
关键词:
- 自适应检测 /
- 混响边缘 /
- 贝叶斯检验 /
- 两步广义似然比目标检测
Abstract: Active sonar faces the problem of non-uniform data in reverberation edge environments, leading to a sharp decrease in the amount of auxiliary data consistent with the background statistical characteristics of the cell under test. Meanwhile, existing methods utilize the sample covariance matrix of data when estimating the reverberant covariance matrix, which has limited the estimation accuracy, inevitably resulting in a loss of target detection performance. To address the above issues, this paper conducts research on two-step generalized likelihood ratio detection methods in reverberant edge environments based on Bayesian target detection, proposing two adaptive target detection methods: Bayesian Hermitian Target Detector in Reverberation Edge Environment, BH-TD-REE, and Bayesian Symmetric Target Detector in Reverberation Edge Environment, BS-TD-REE. Both the BH-TD-REE and BS-TD-REE methods treat the reverberation covariance matrix as a random variable and adopt the maximum a posteriori estimation criterion instead of the sample covariance estimation. Furthermore, the BS-TD-REE method also utilizes the spectral symmetry property of the reverberation covariance matrix, effectively expanding the number of auxiliary data and reducing the detector's demand for uniform auxiliary data. Simulation results show that both proposed methods effectively improve target detection performance and robustness, while the detection performance advantage is more significant under limited auxiliary data quantity. -
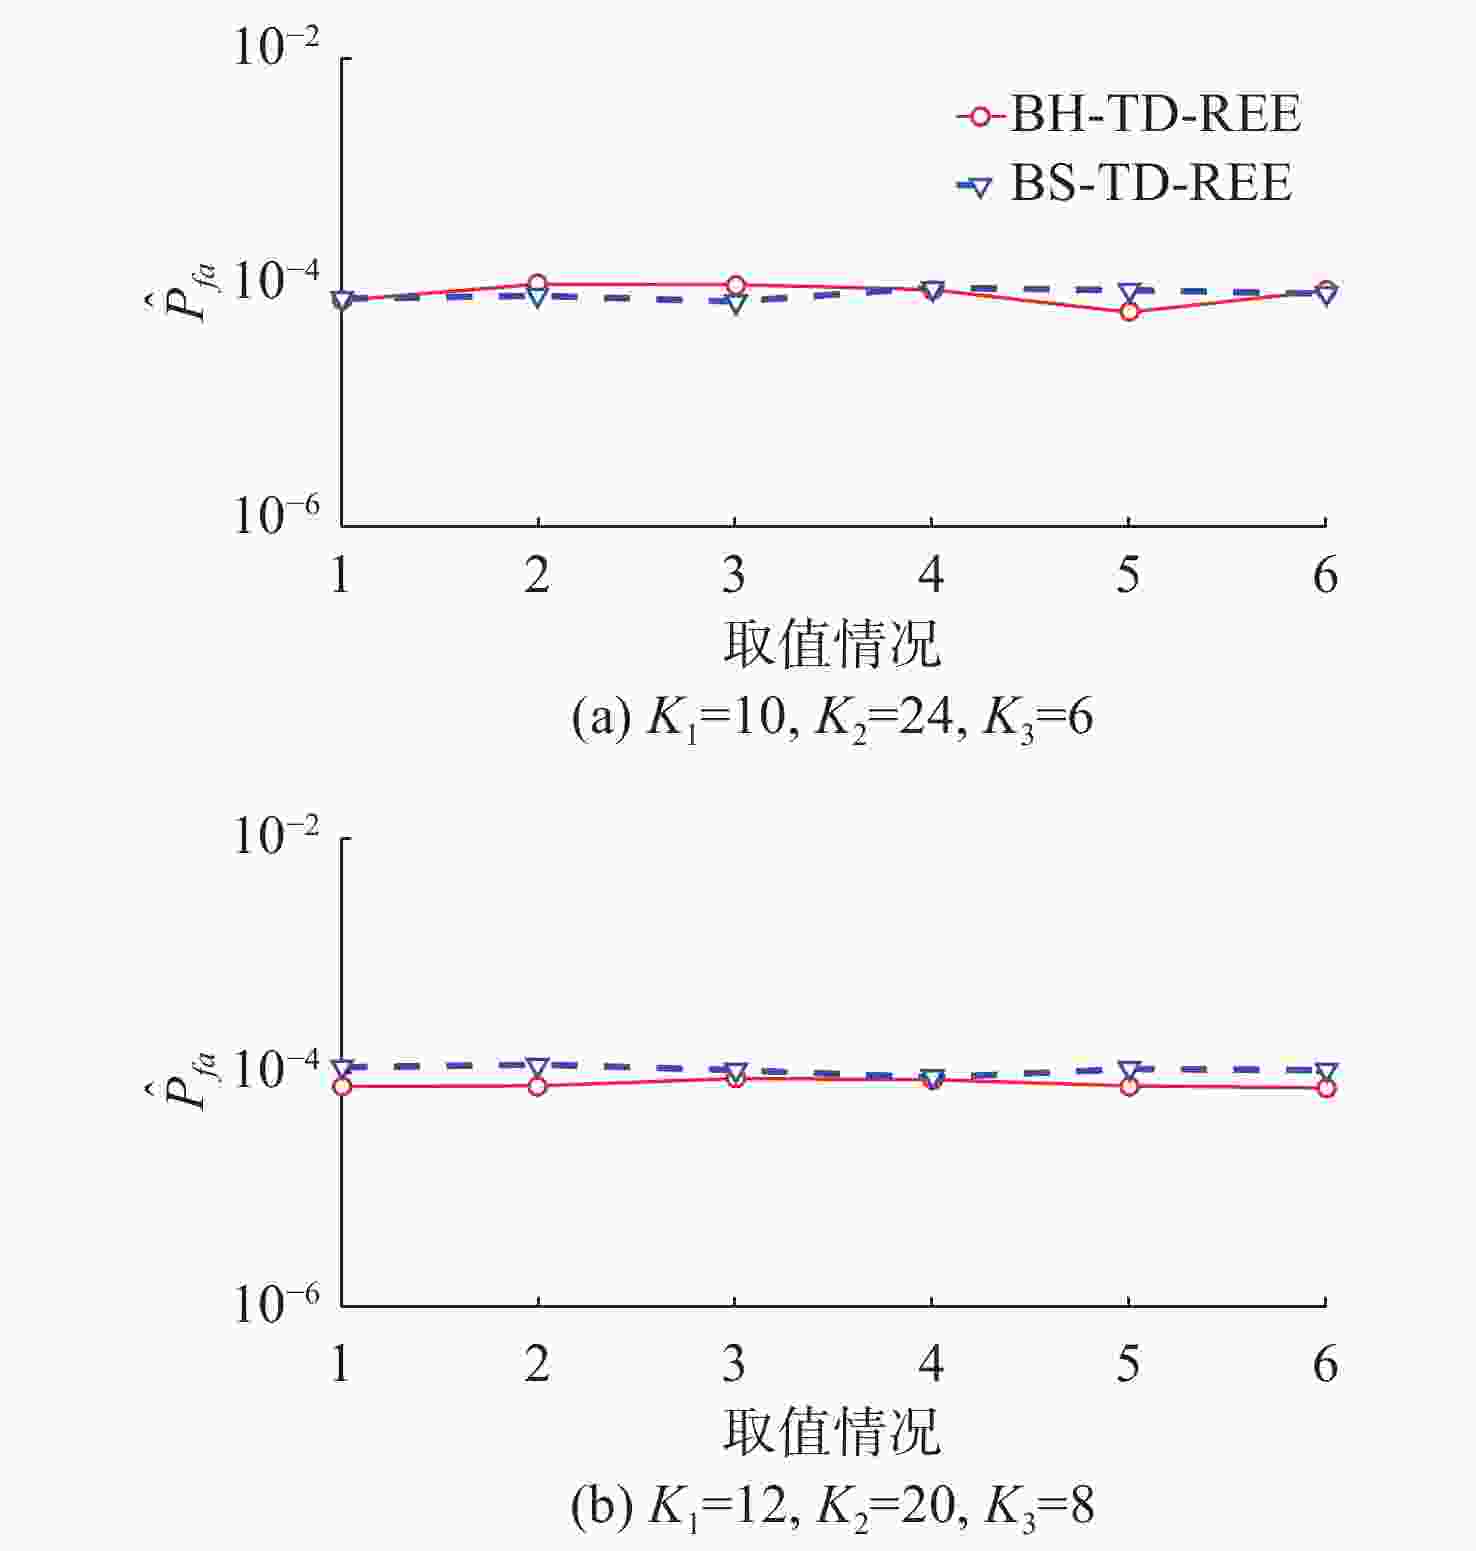
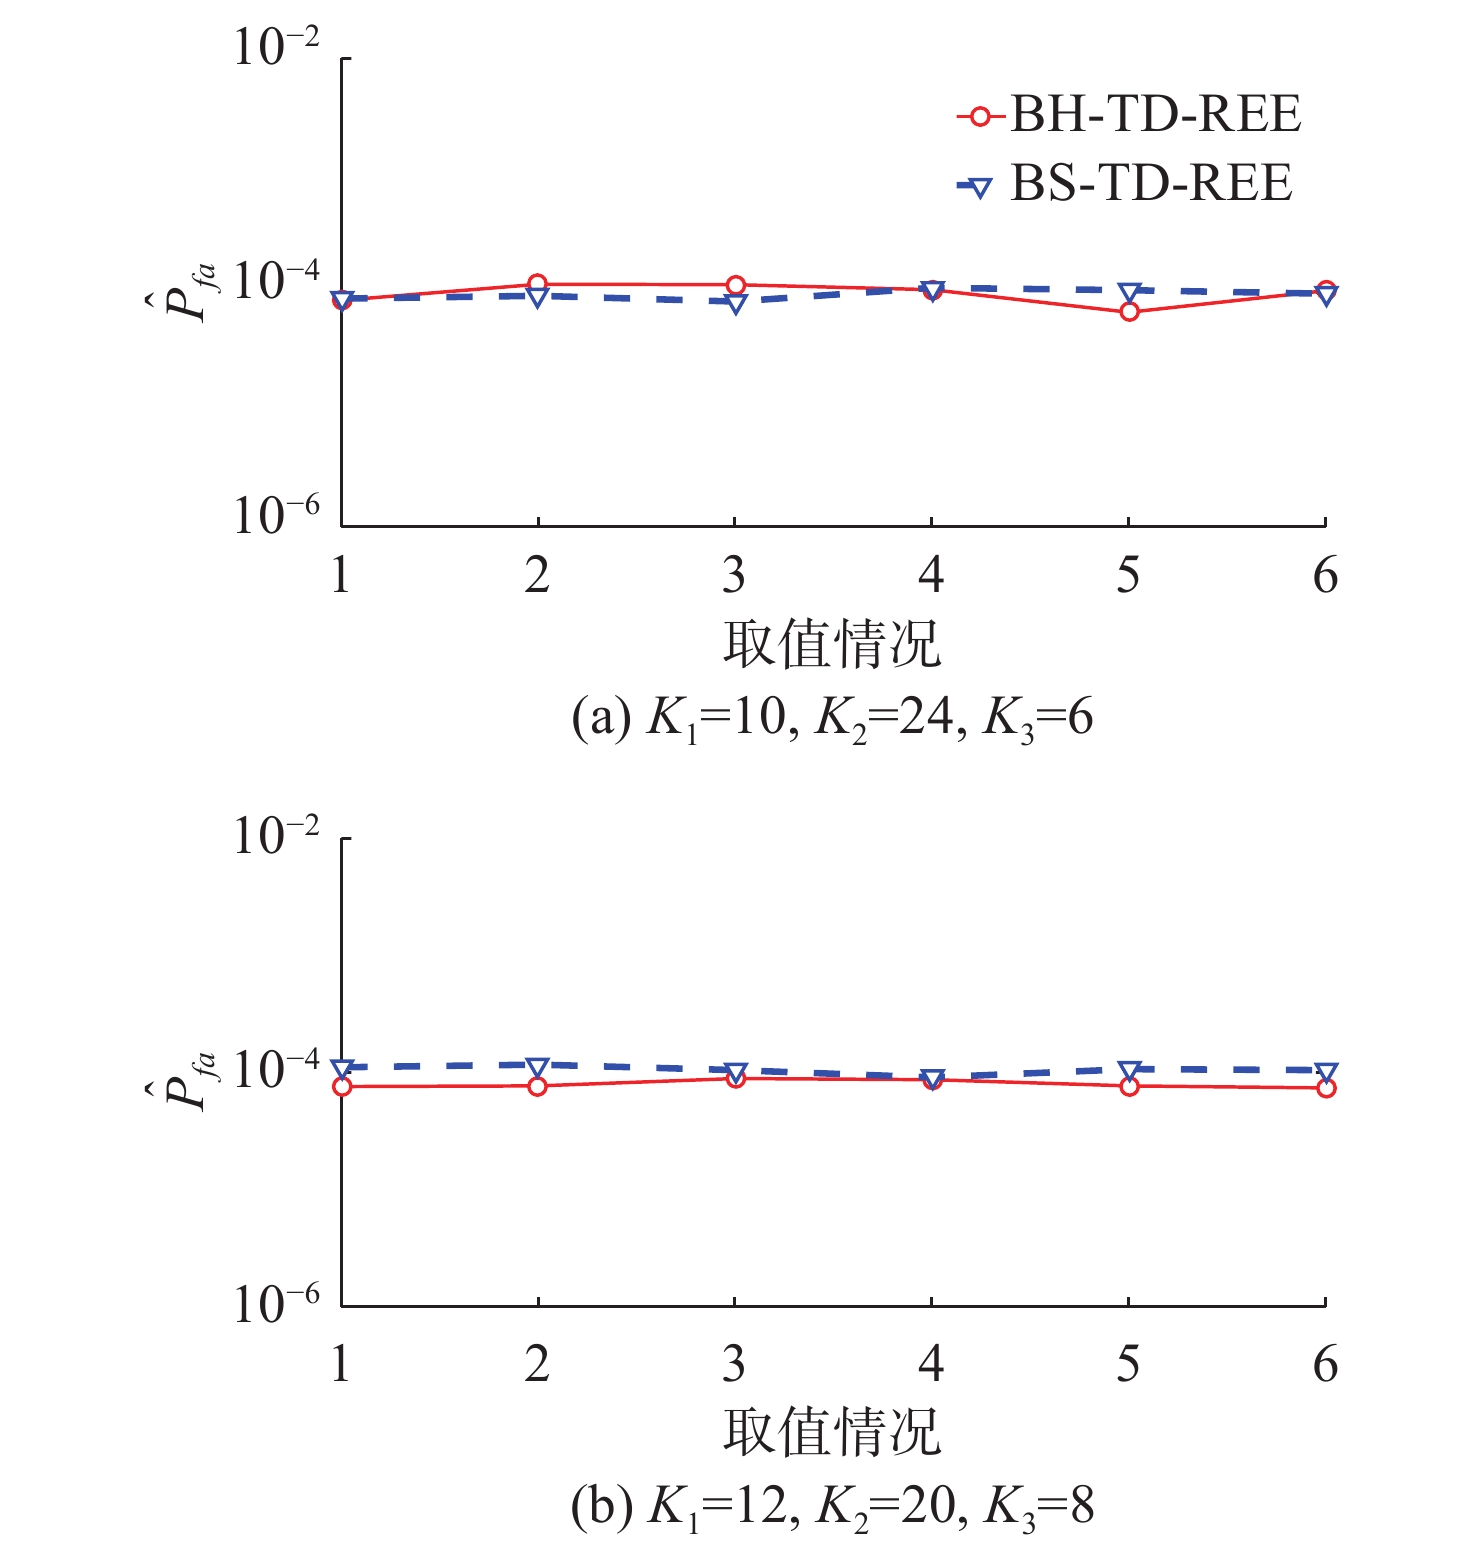
图 4 $ {\bf{RPR}}_{{\boldsymbol{1}}} $和$ {\bf{RPR}}_{{\boldsymbol{2}}} $不同取值下的$ {\hat{{\boldsymbol{P}}}}_{{\boldsymbol{fa}}} $曲线
Figure 4. The $ {\hat{{\boldsymbol P}}}_{{\boldsymbol{fa}}} $ curves under different values of $ {\mathbf{RPR}}_{{\boldsymbol{1}}} $ and $ {\bf{RPR}}_{{\boldsymbol{2}}} $
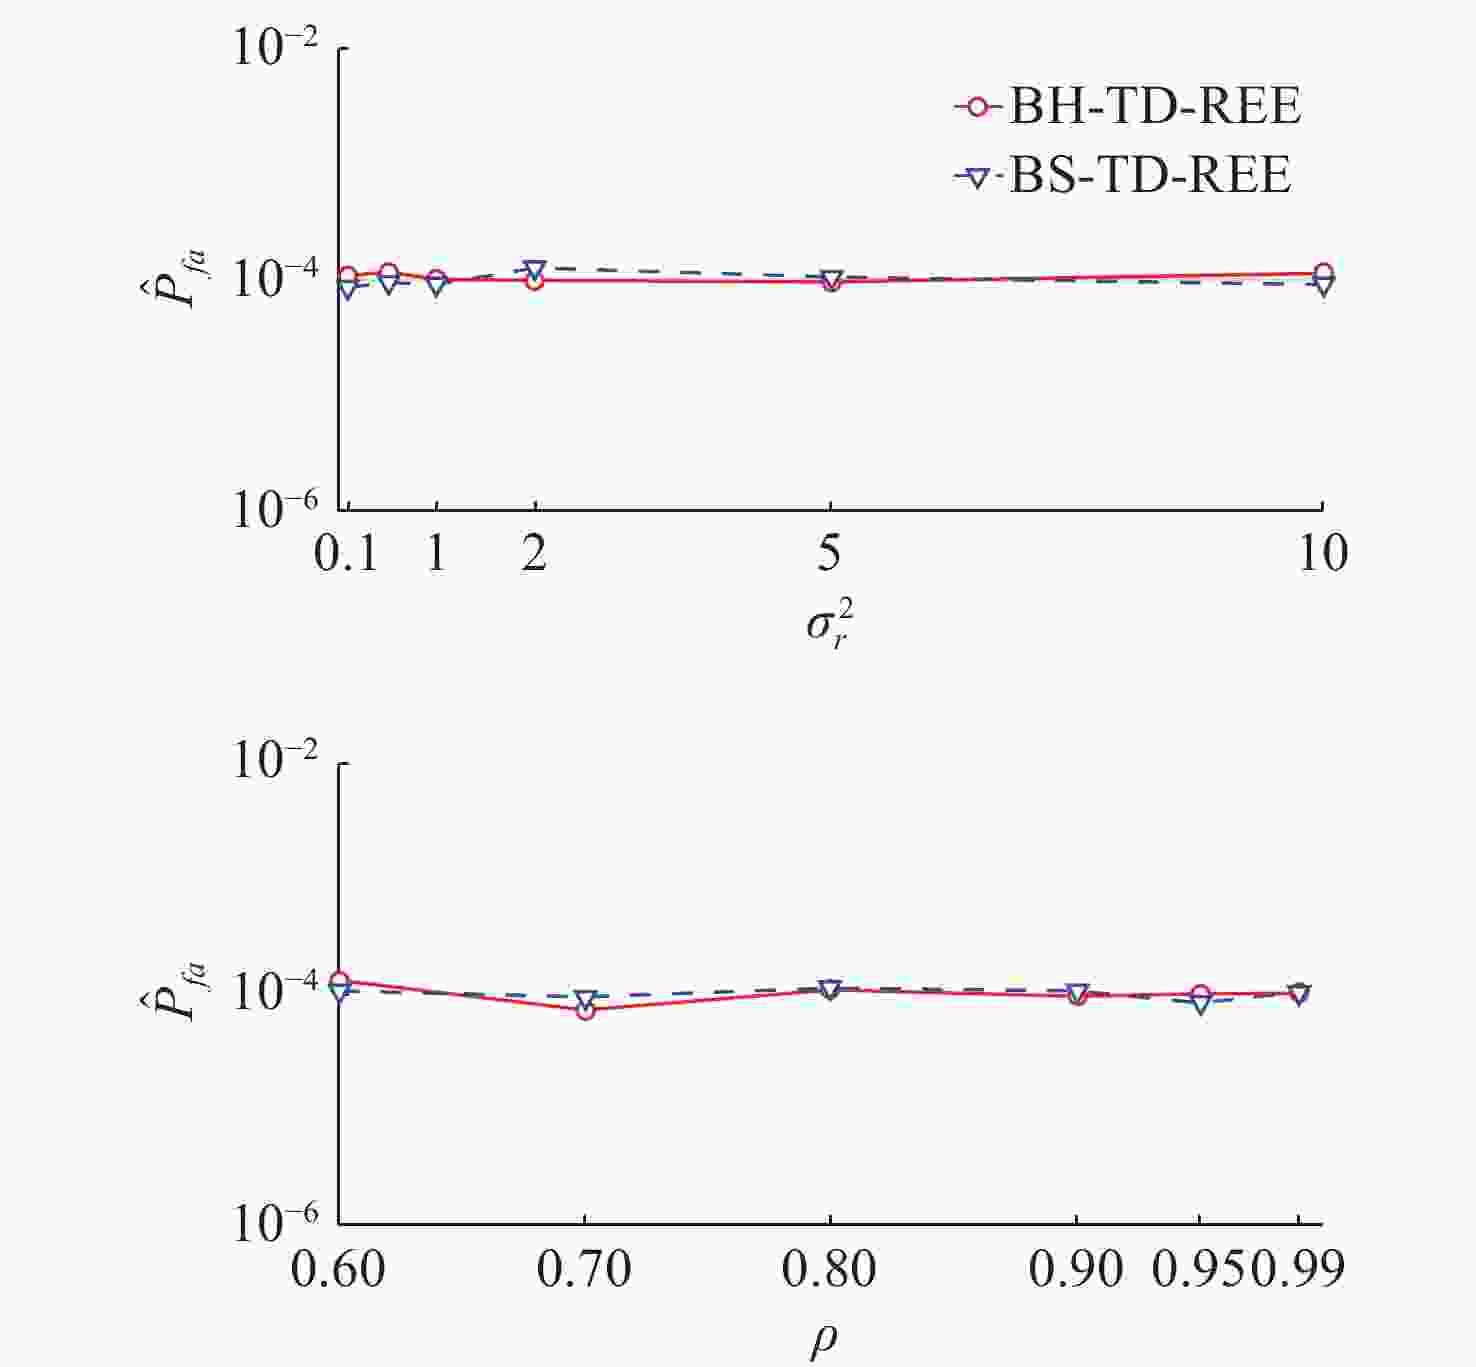
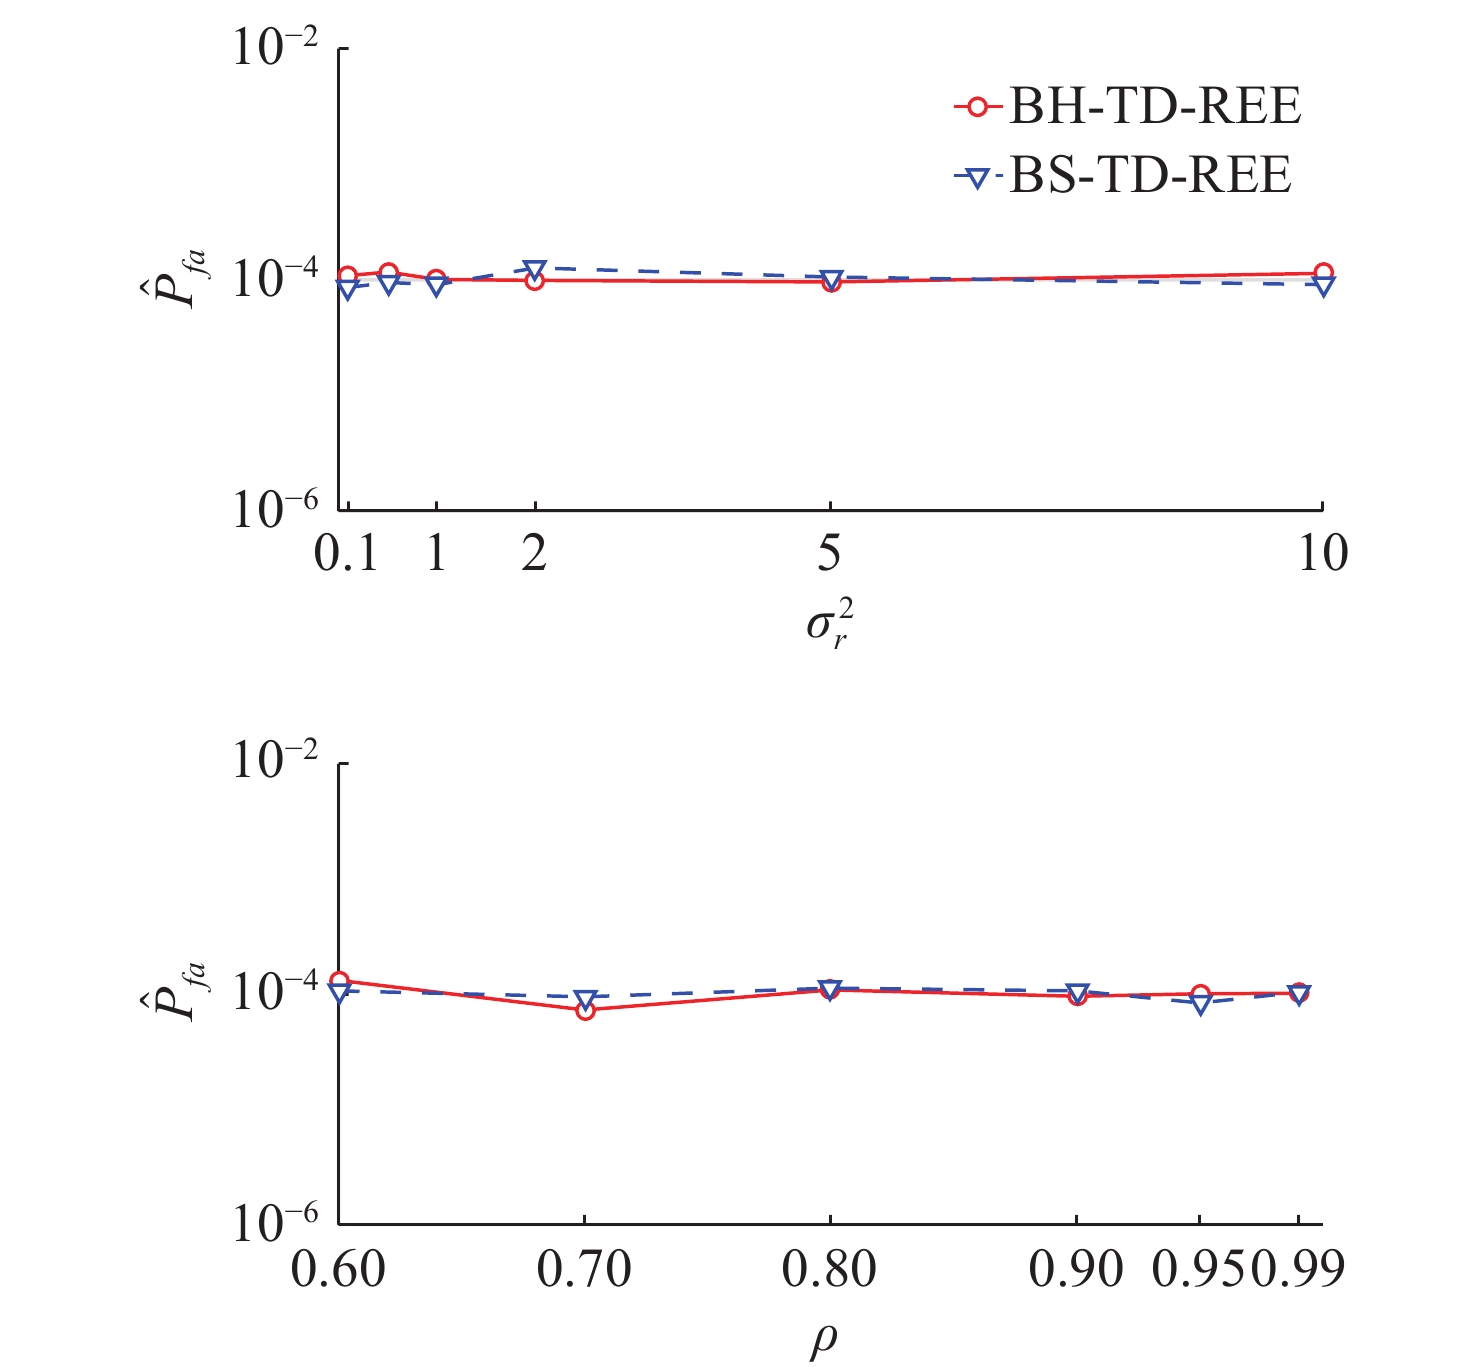
图 5 $ {{\boldsymbol{\sigma}} _{{\boldsymbol{r}}}^{{\boldsymbol{2}}}} $和$ {\boldsymbol{\rho}} $不同取值下的$ {\hat{{\boldsymbol{P}}}}_{{\boldsymbol{fa}}} $曲线
Figure 5. The $ {\hat{{\boldsymbol P}}}_{{\boldsymbol{fa}}} $ curves under different values of $ {\boldsymbol \sigma }_{{\boldsymbol{r}}}^{{\boldsymbol{2}}} $ and $ {\boldsymbol \rho } $
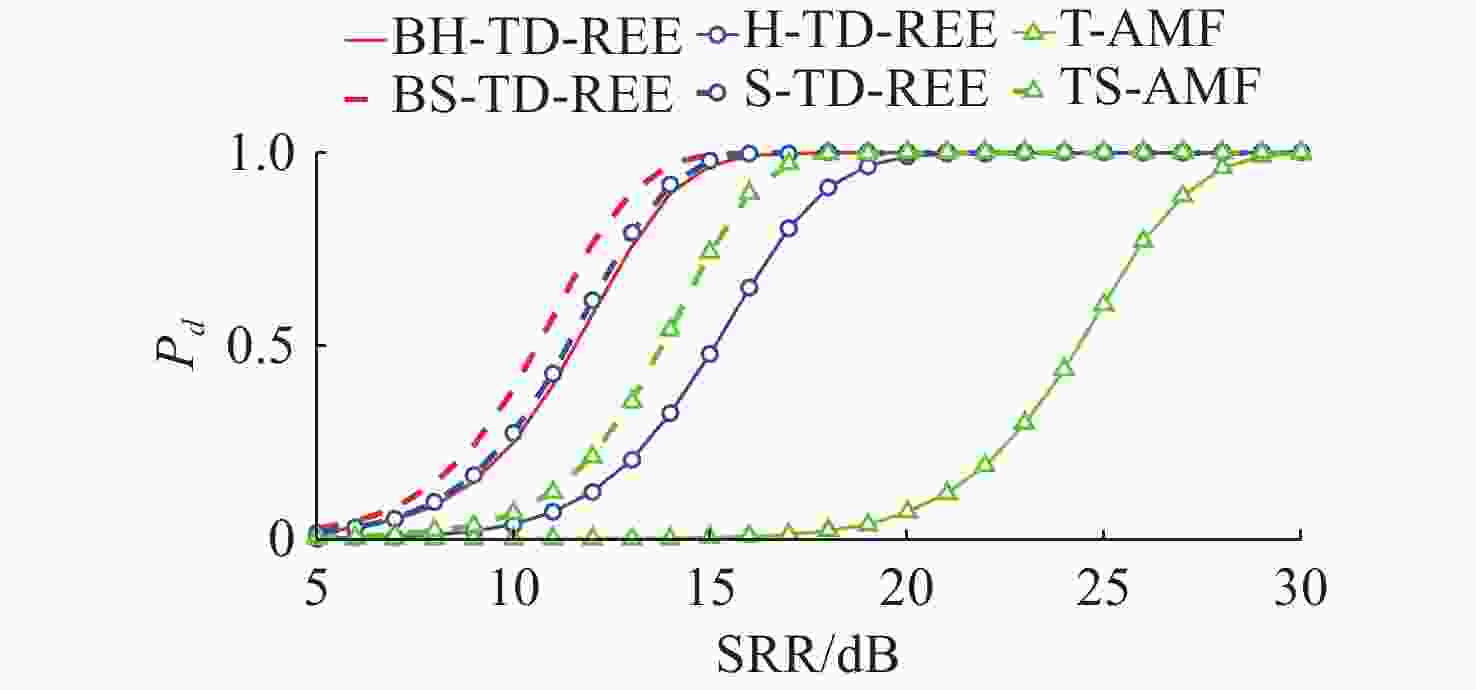
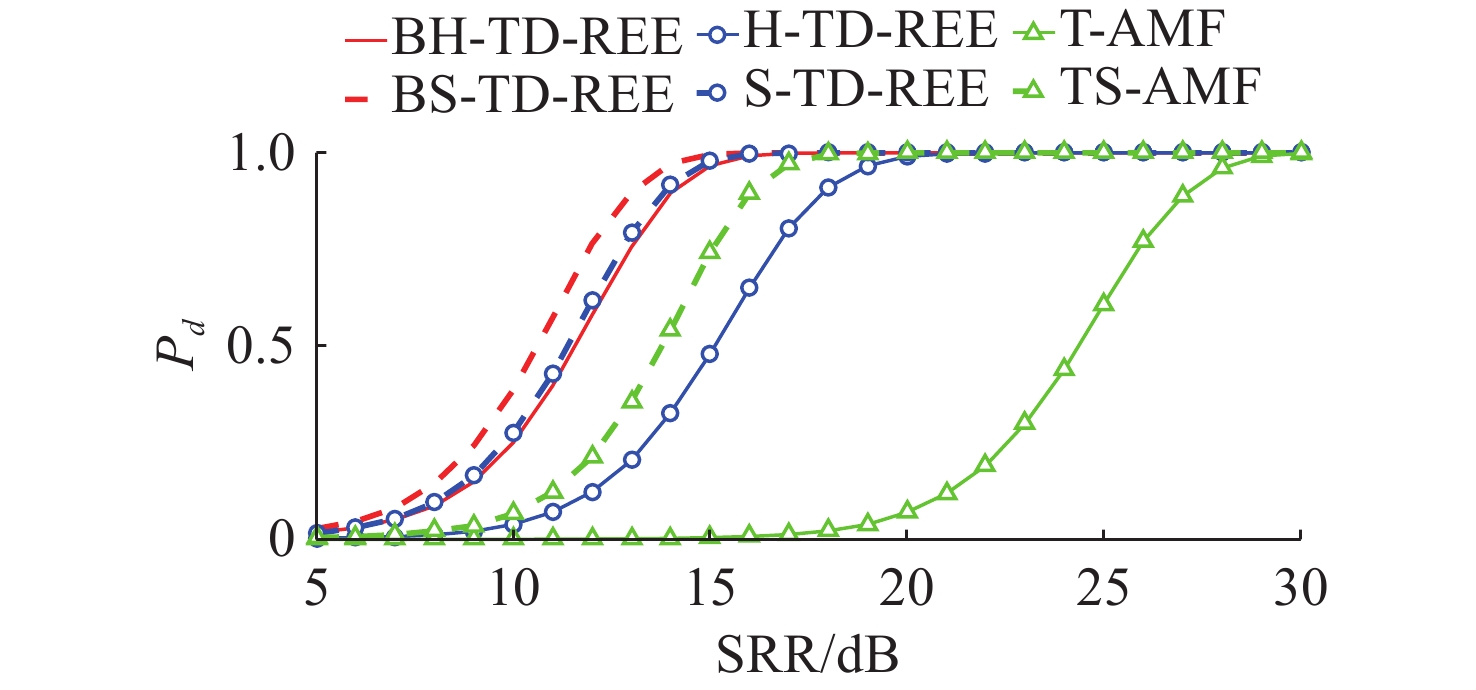
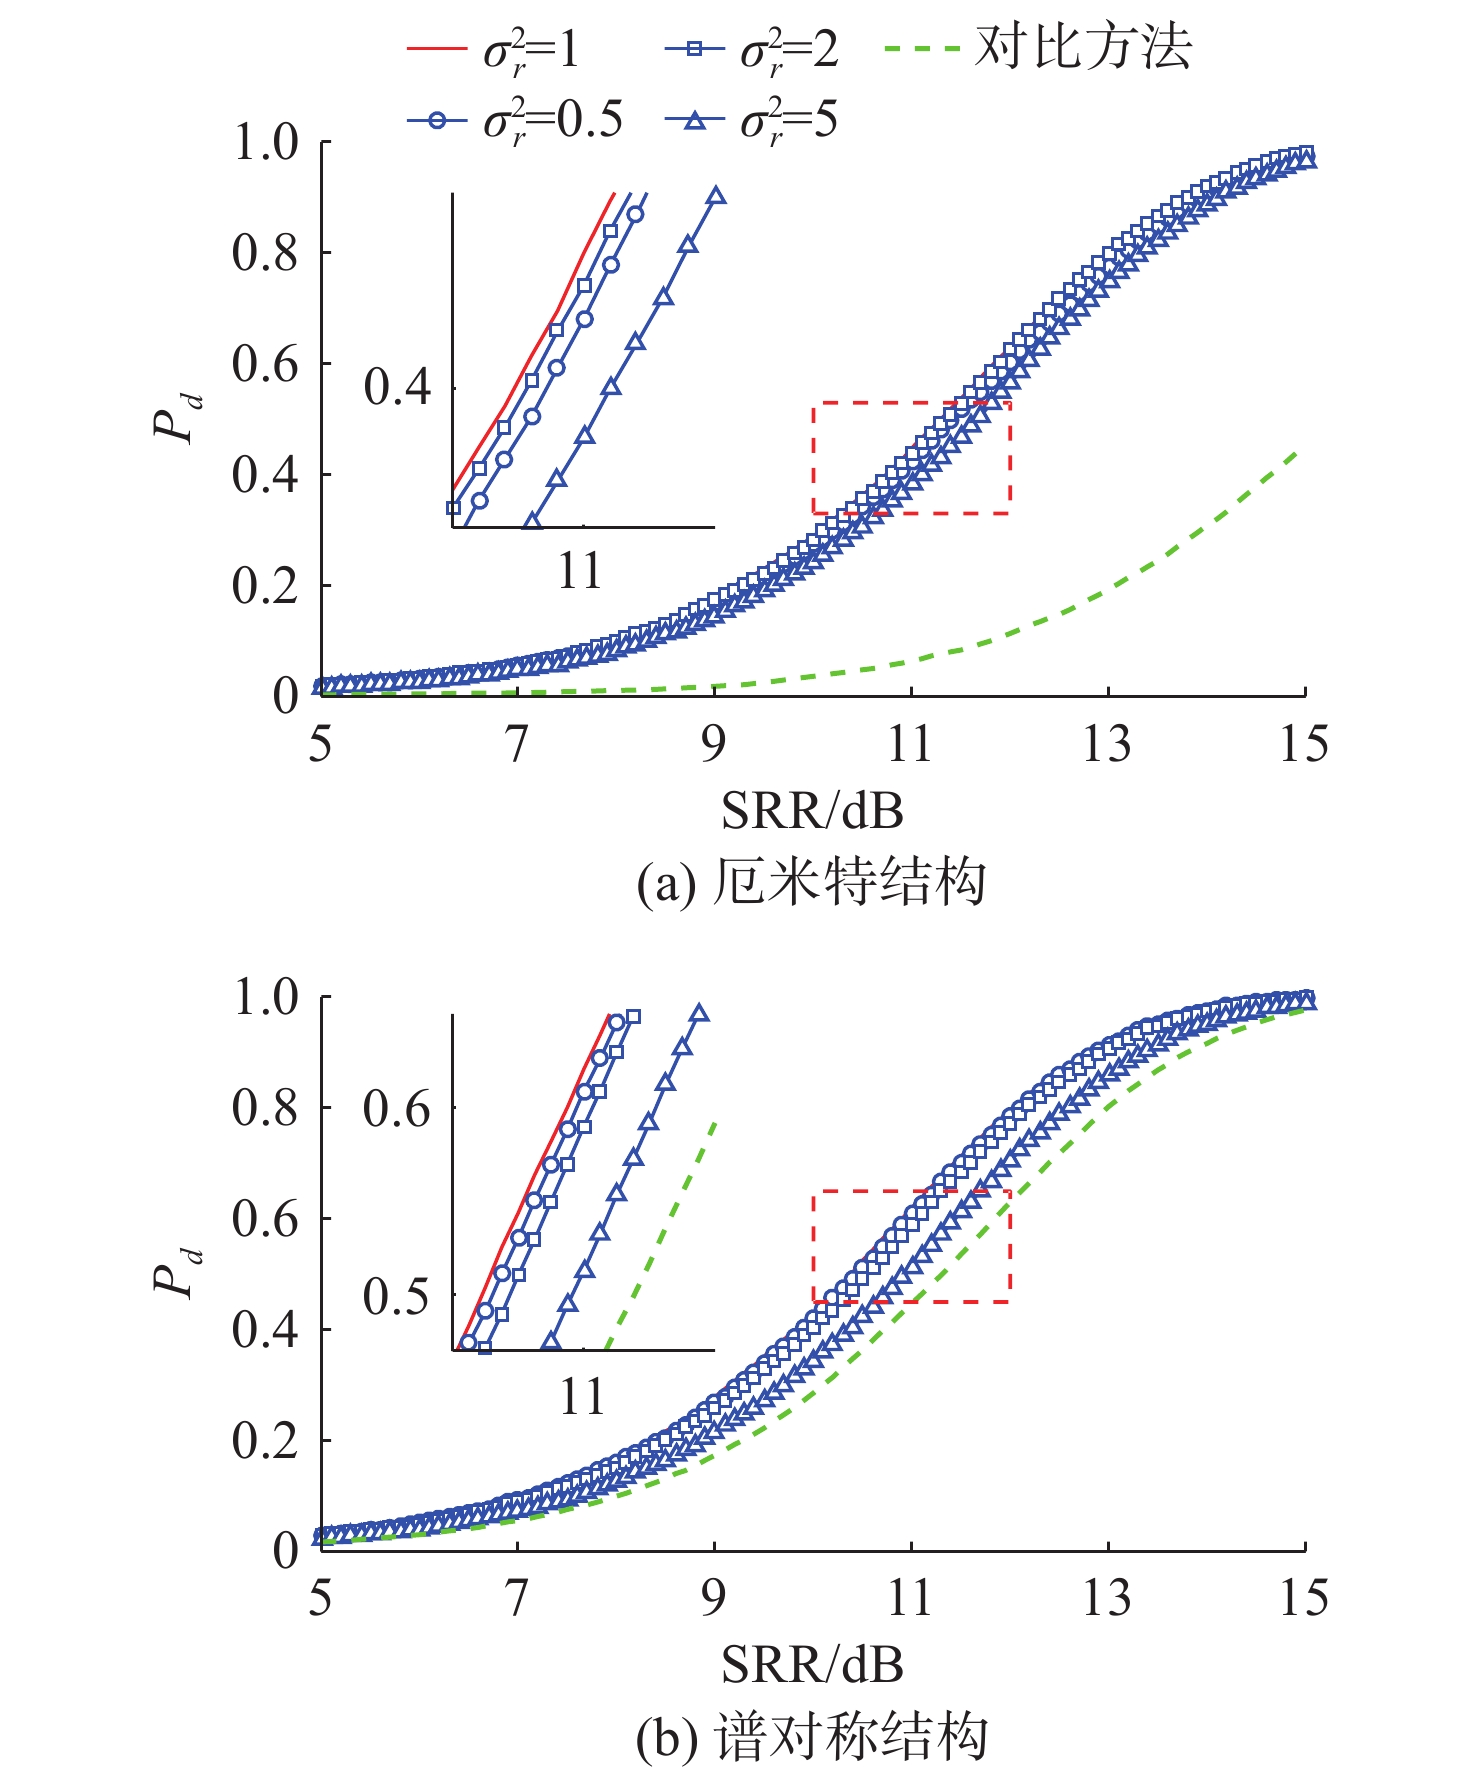
图 6 辅助数据数量充足时$ {P}_{d} $随$ \text{SRR} $的变化曲线
Figure 6. The $ {{\boldsymbol P}}_{d} $ curves with $ \mathbf{SRR} $ when the auxiliary data quantity is sufficient
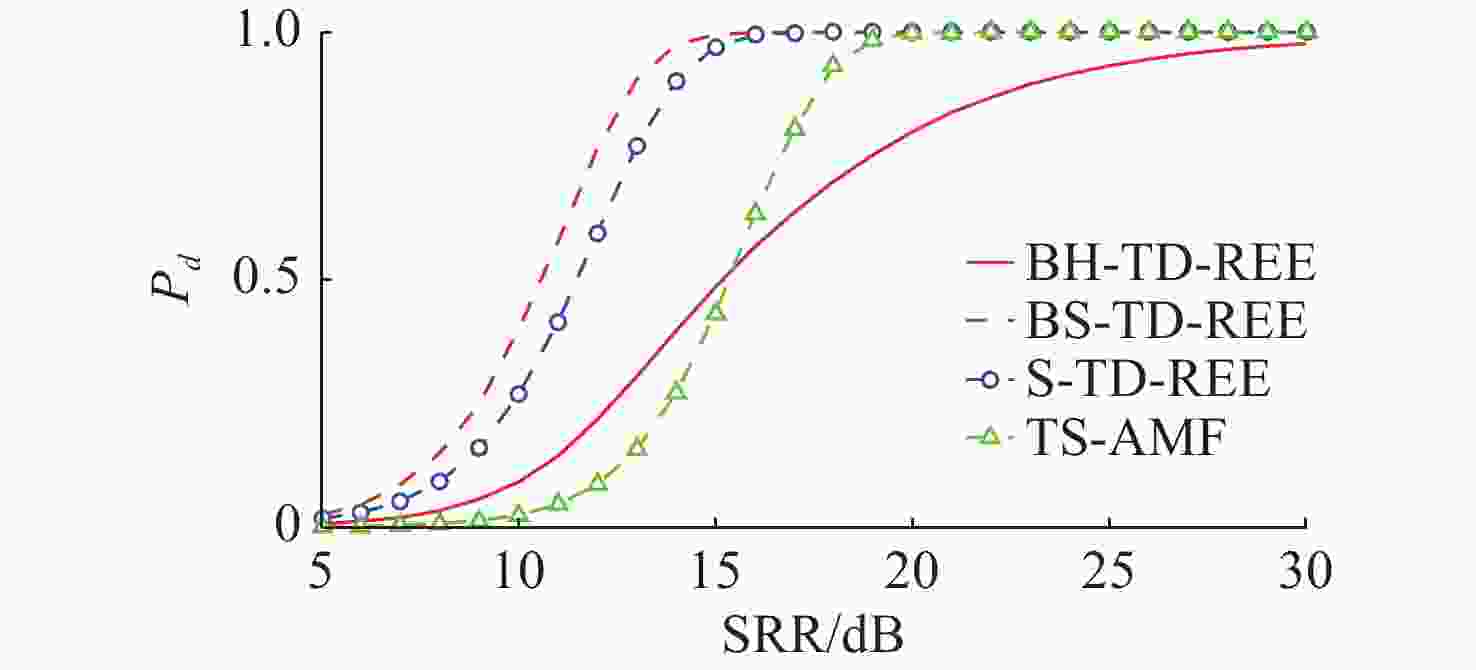
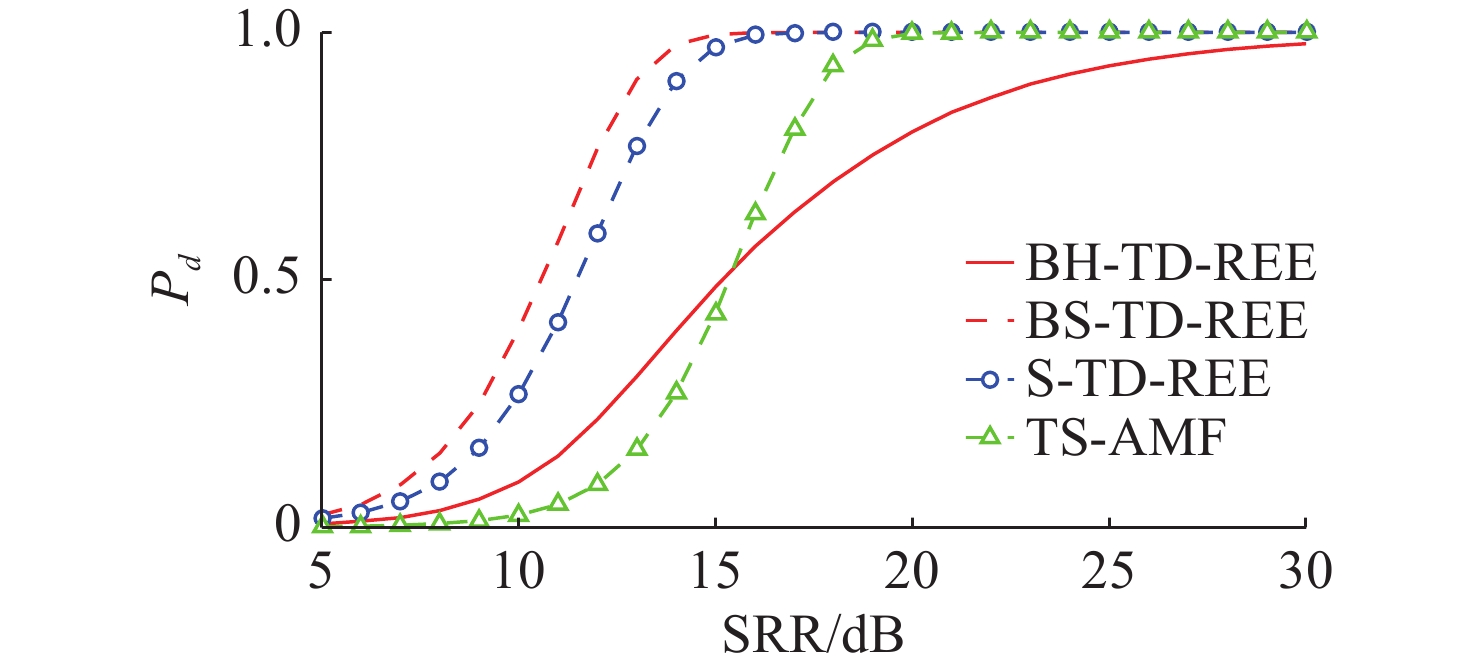
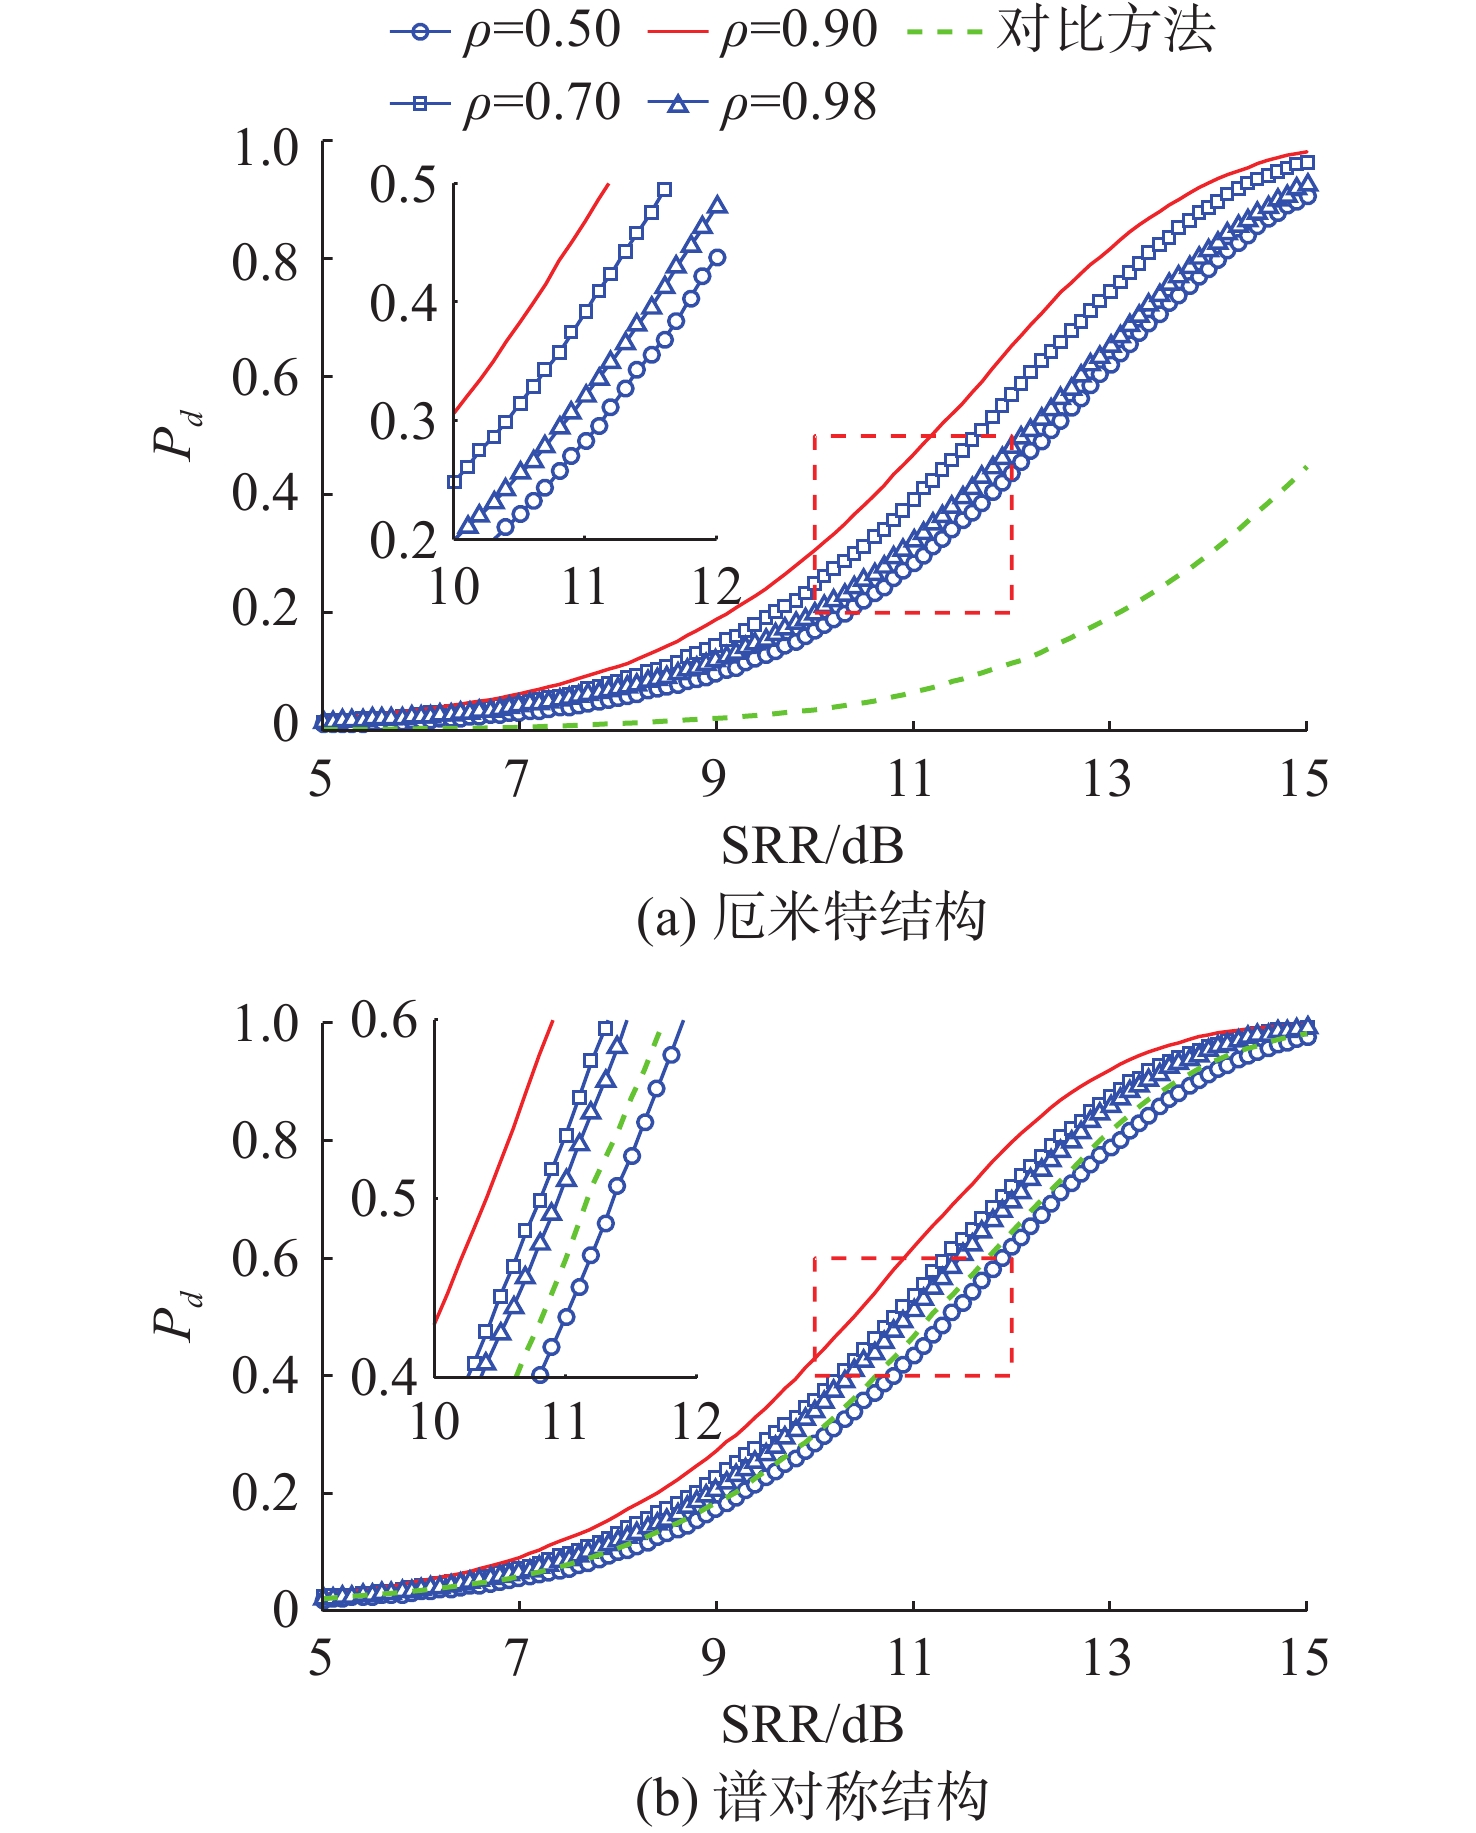
图 7 辅助数据数量受限时$ {{\boldsymbol{P}}}_{{\boldsymbol{d}}} $随$ \bf{SRR} $的变化曲线
Figure 7. The $ {{\boldsymbol P}}_{{\boldsymbol{d}}} $ curves with $ \mathbf{SRR} $ when the auxiliary data quantity is limited
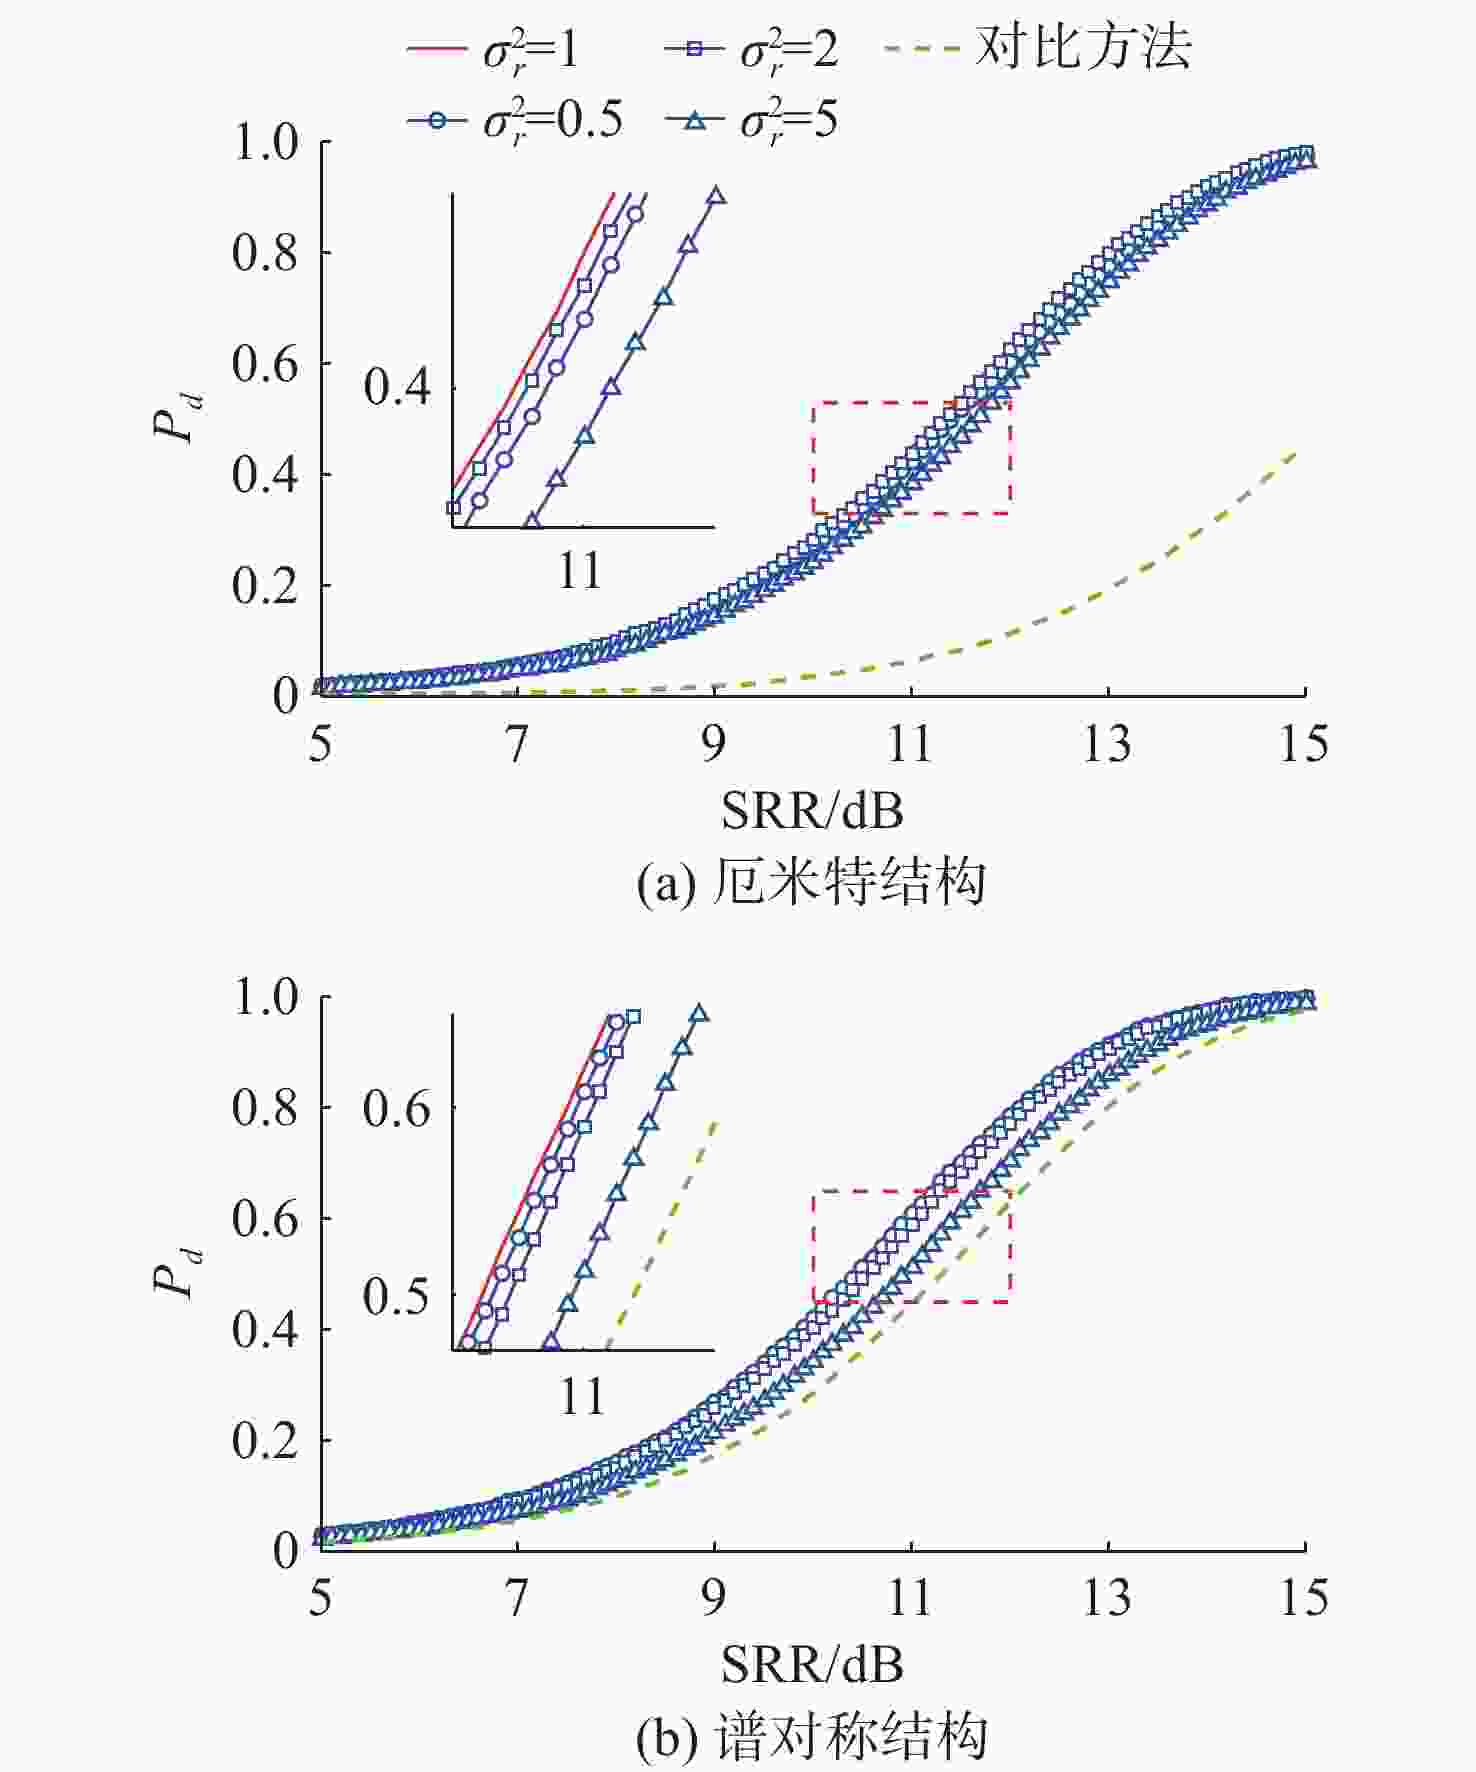
图 8 $ \sigma _{r}^{2} $失配时$ {P}_{d} $随$ \text{SRR} $的变化曲线
Figure 8. The $ {{\boldsymbol P}}_{d} $ curves with $ \mathbf{SRR} $ when $ {\boldsymbol \sigma }_{r}^{2} $ mismatch occurs
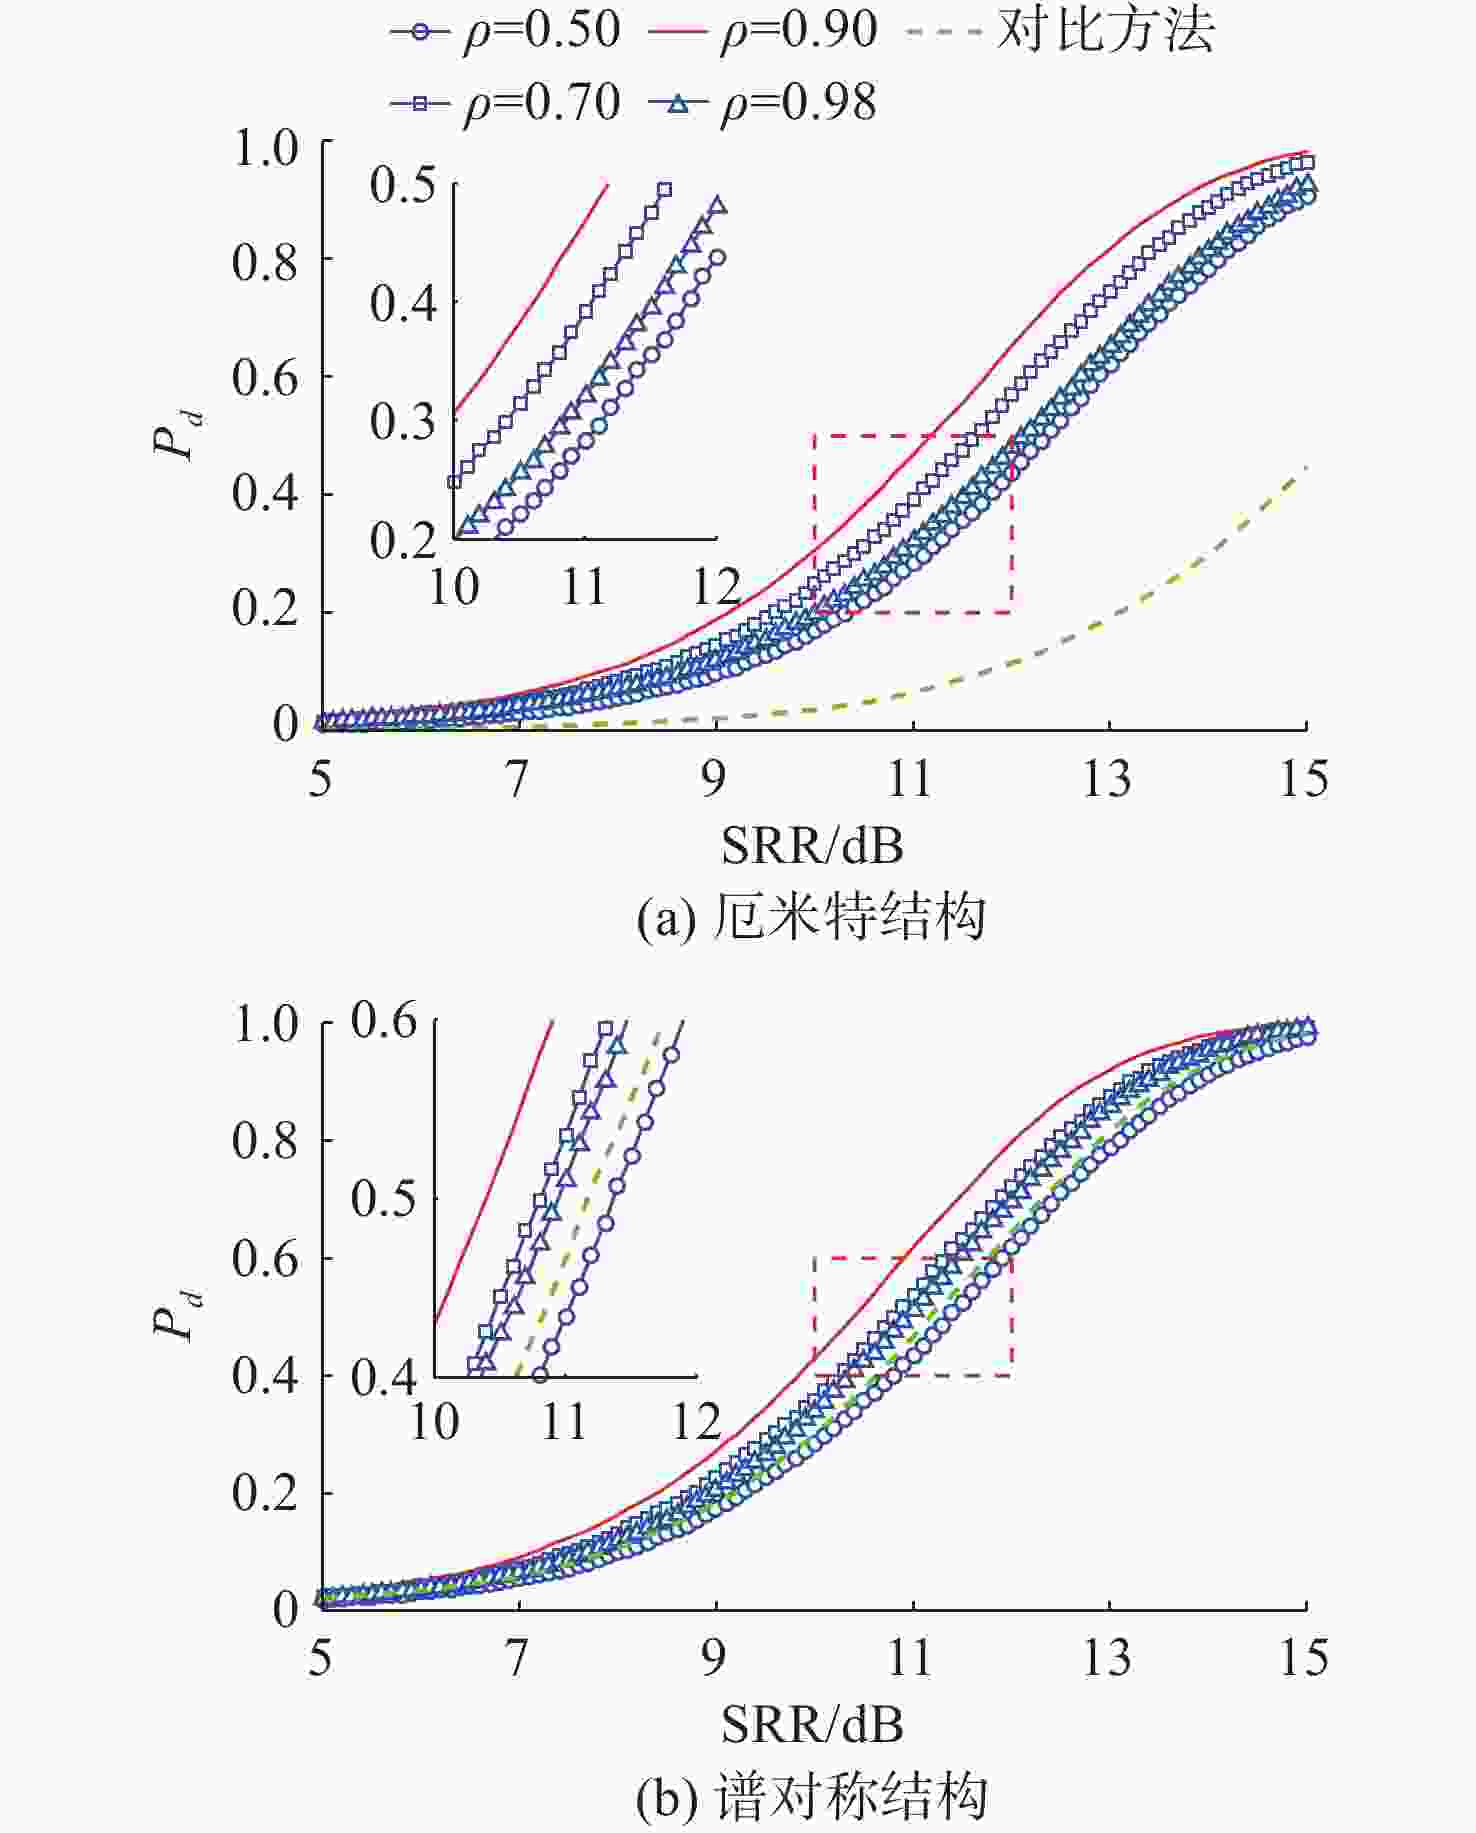
图 9 $ \rho $失配时$ {P}_{d} $随$ \text{SRR} $的变化曲线
Figure 9. The $ {{\boldsymbol P}}_{d} $ curves with $ \mathbf{SRR} $ when $ {\boldsymbol \rho } $ mismatch occurs
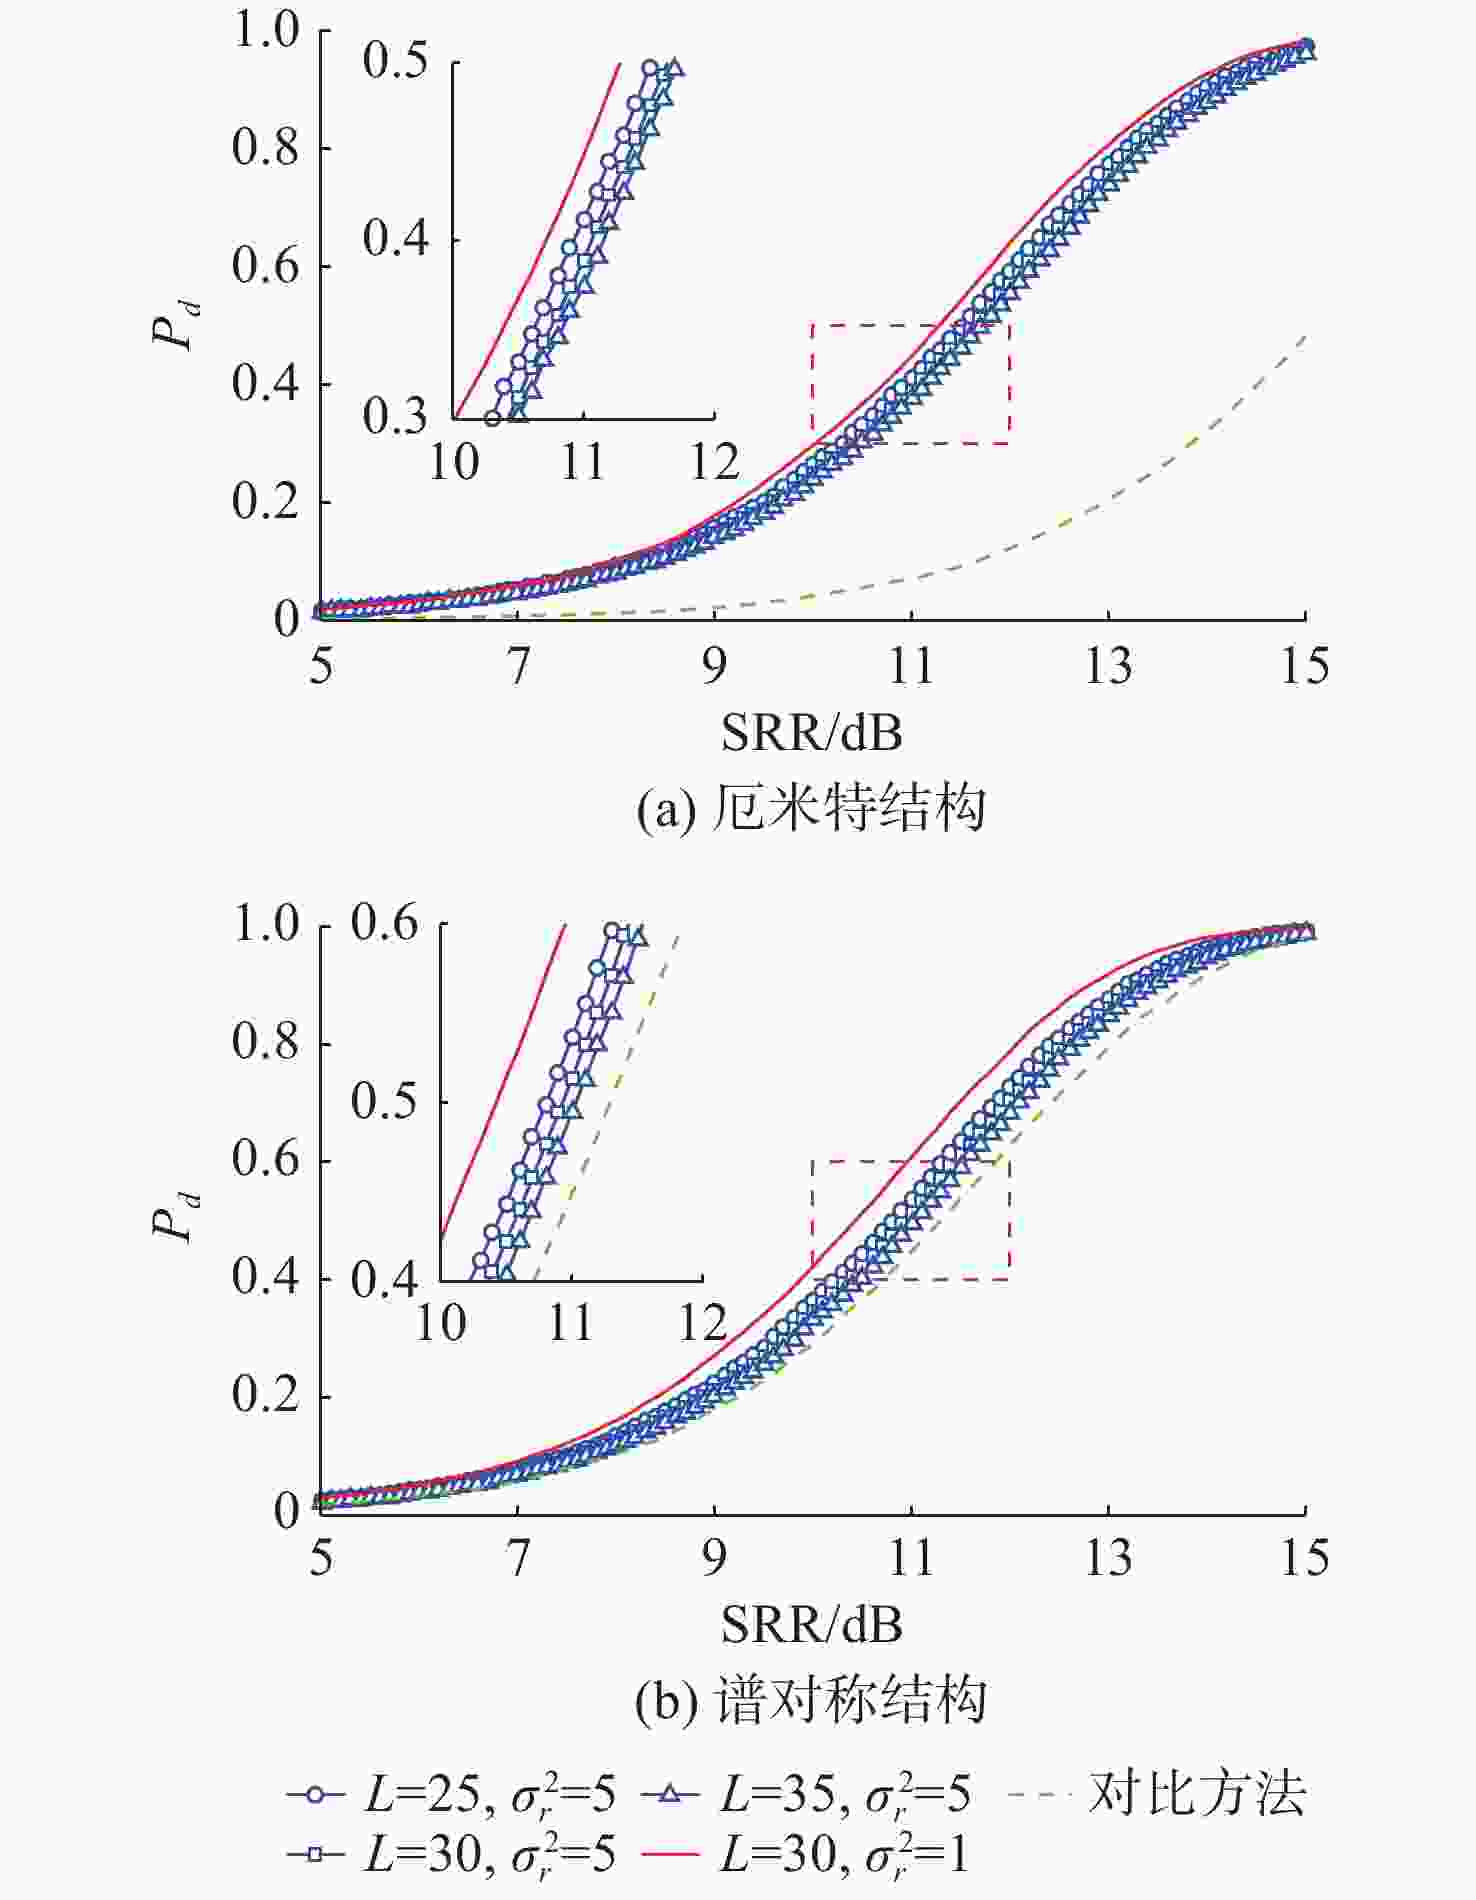
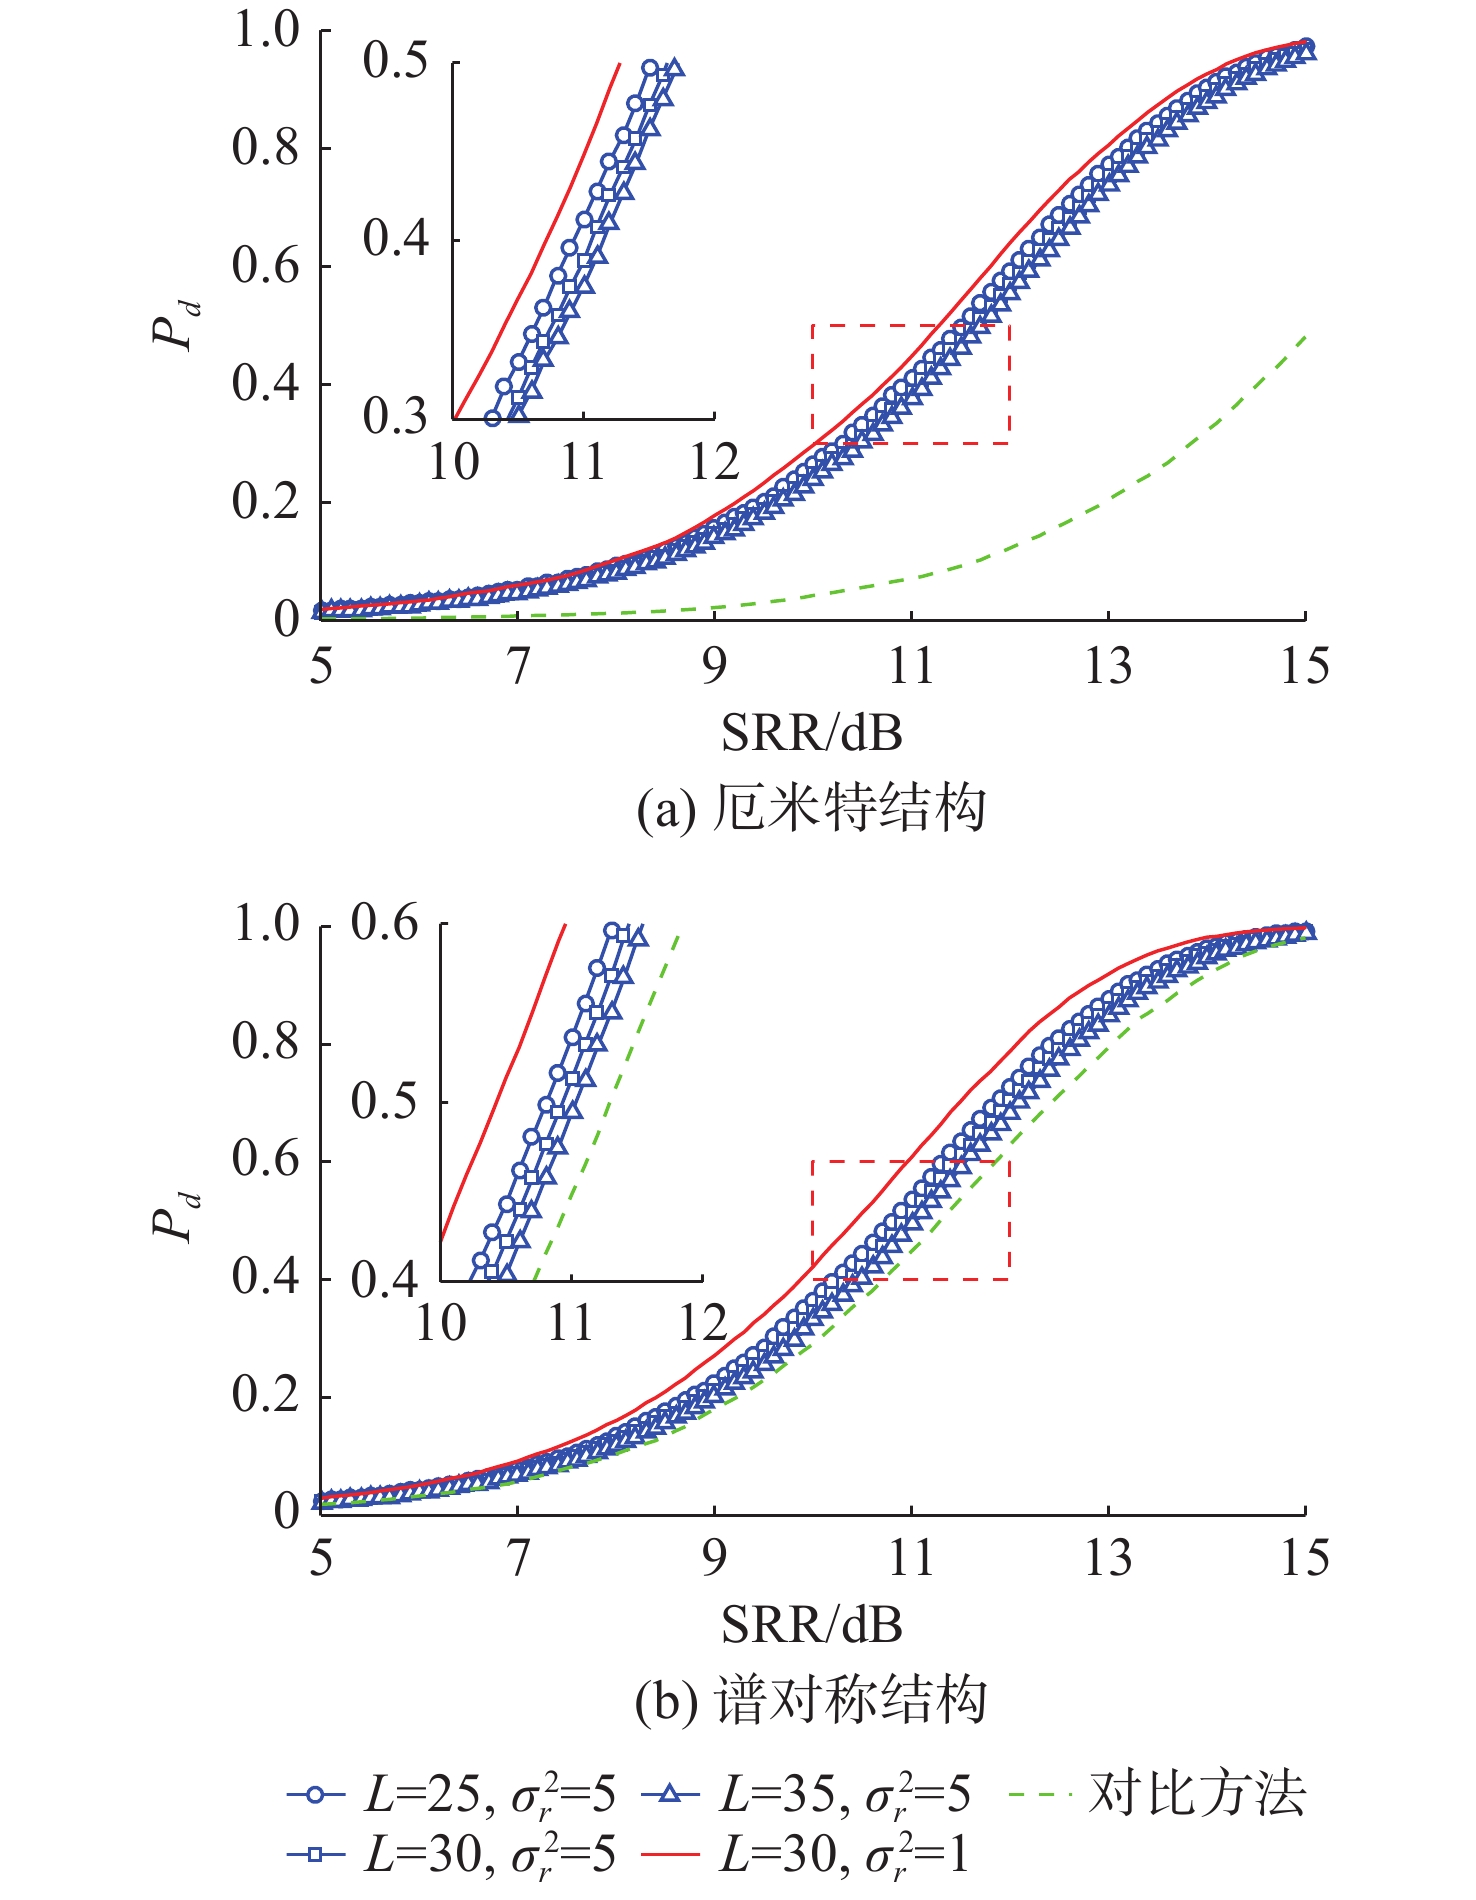
图 10 ${\boldsymbol{ \sigma }}_{{\boldsymbol{r}}}^{{\boldsymbol{2}}} $失配时$ {\boldsymbol{L}} $不同取值下$ {{\boldsymbol{P}}}_{{\boldsymbol{d}}} $随$ \bf{SRR} $的变化曲线
Figure 10. The $ {{\boldsymbol P}}_{{\boldsymbol{d}}} $ curve with $ \mathbf{SRR} $ under different values of $ {\boldsymbol L} $ when $ {\boldsymbol \sigma }_{{\boldsymbol{r}}}^{{\boldsymbol{2}}} $ mismatch occurs
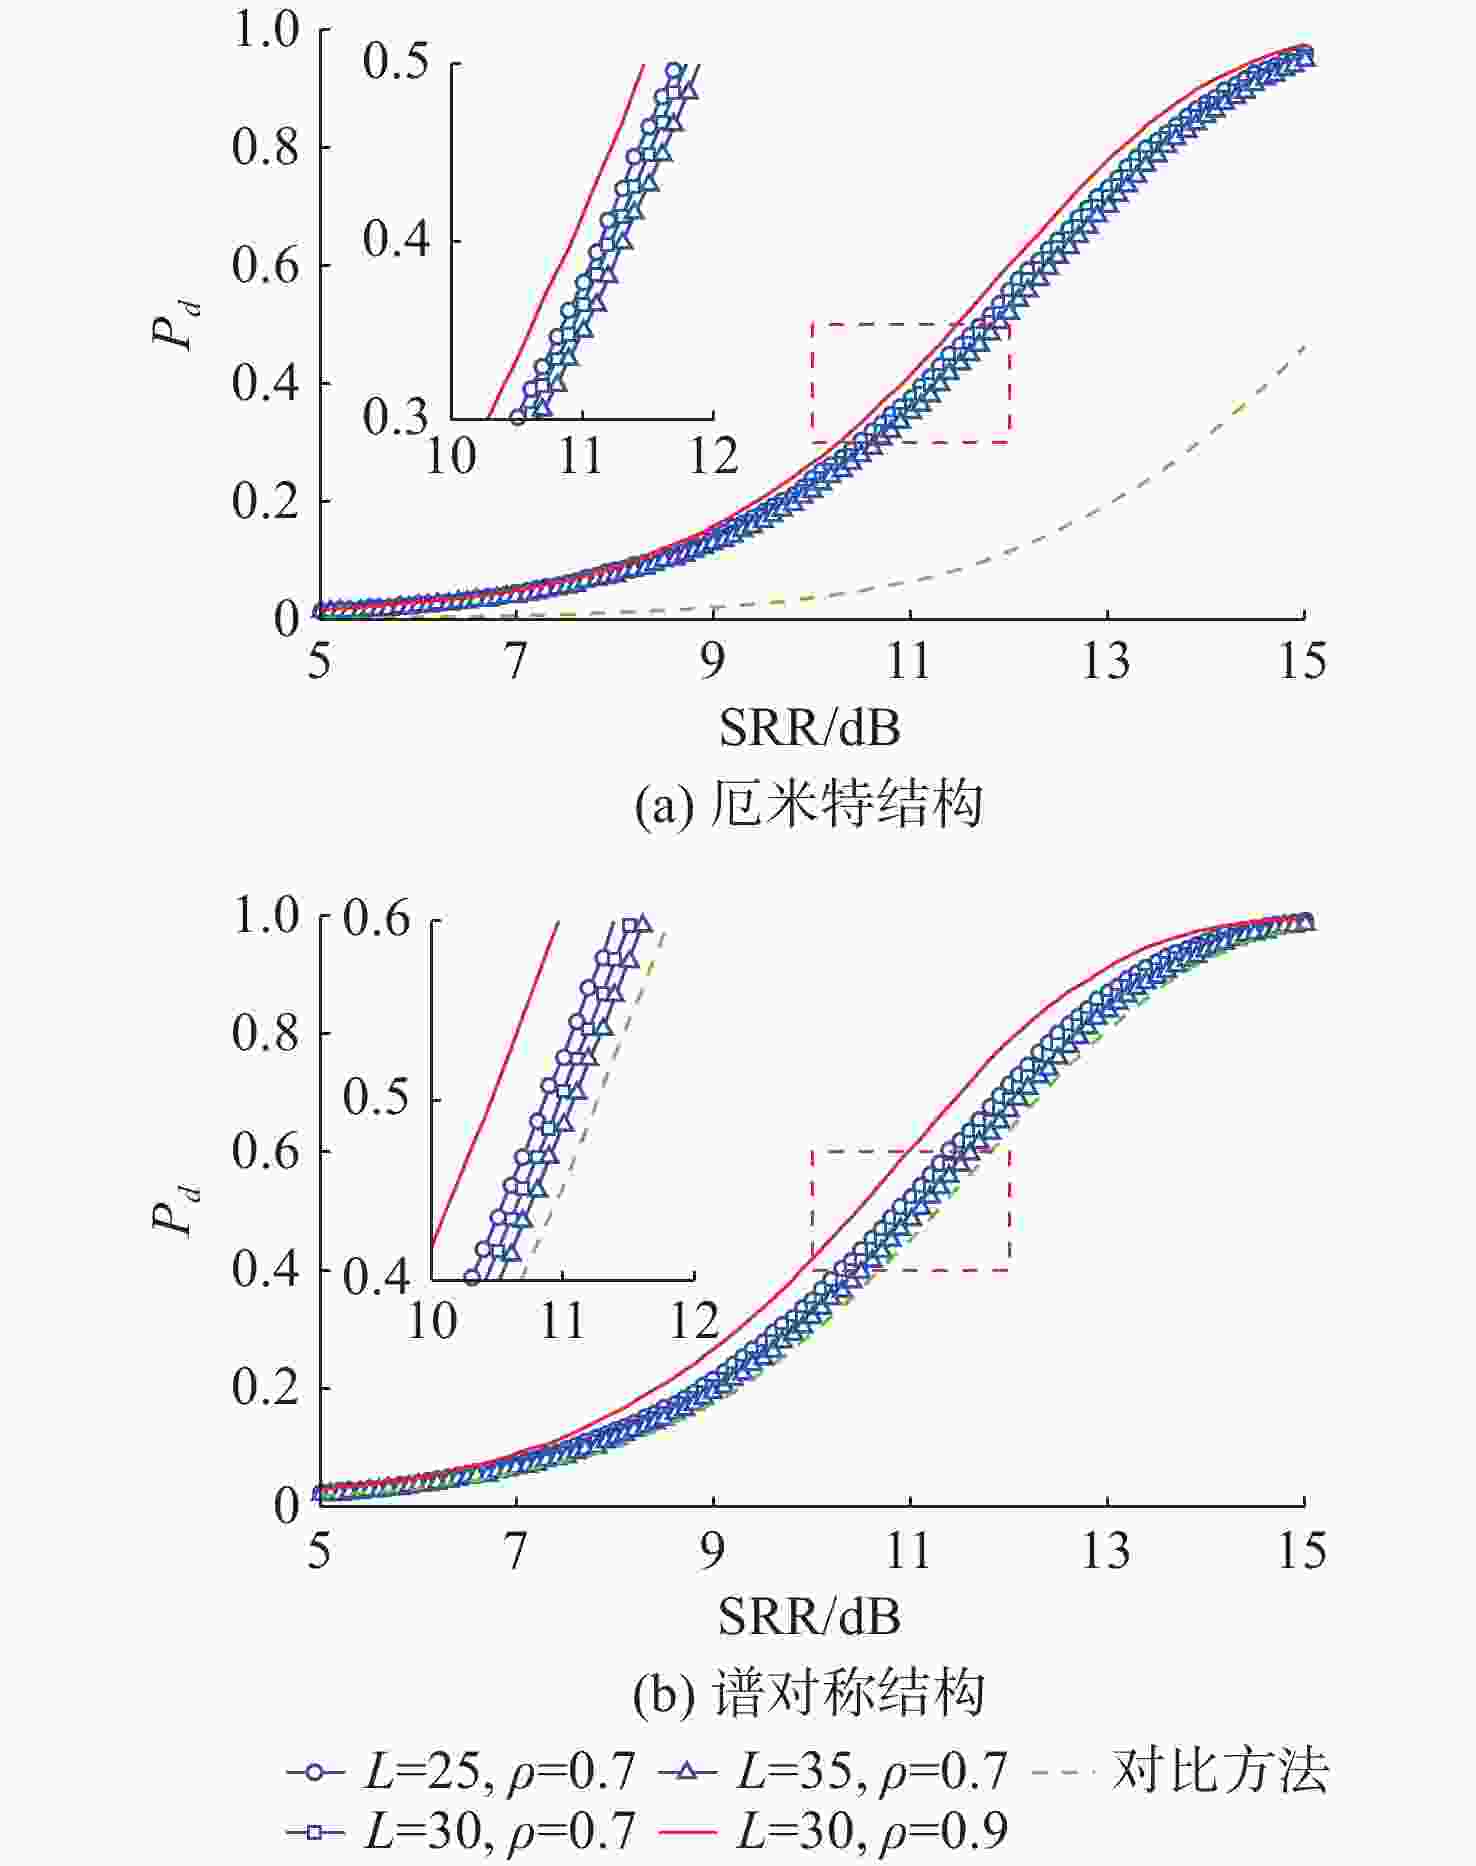
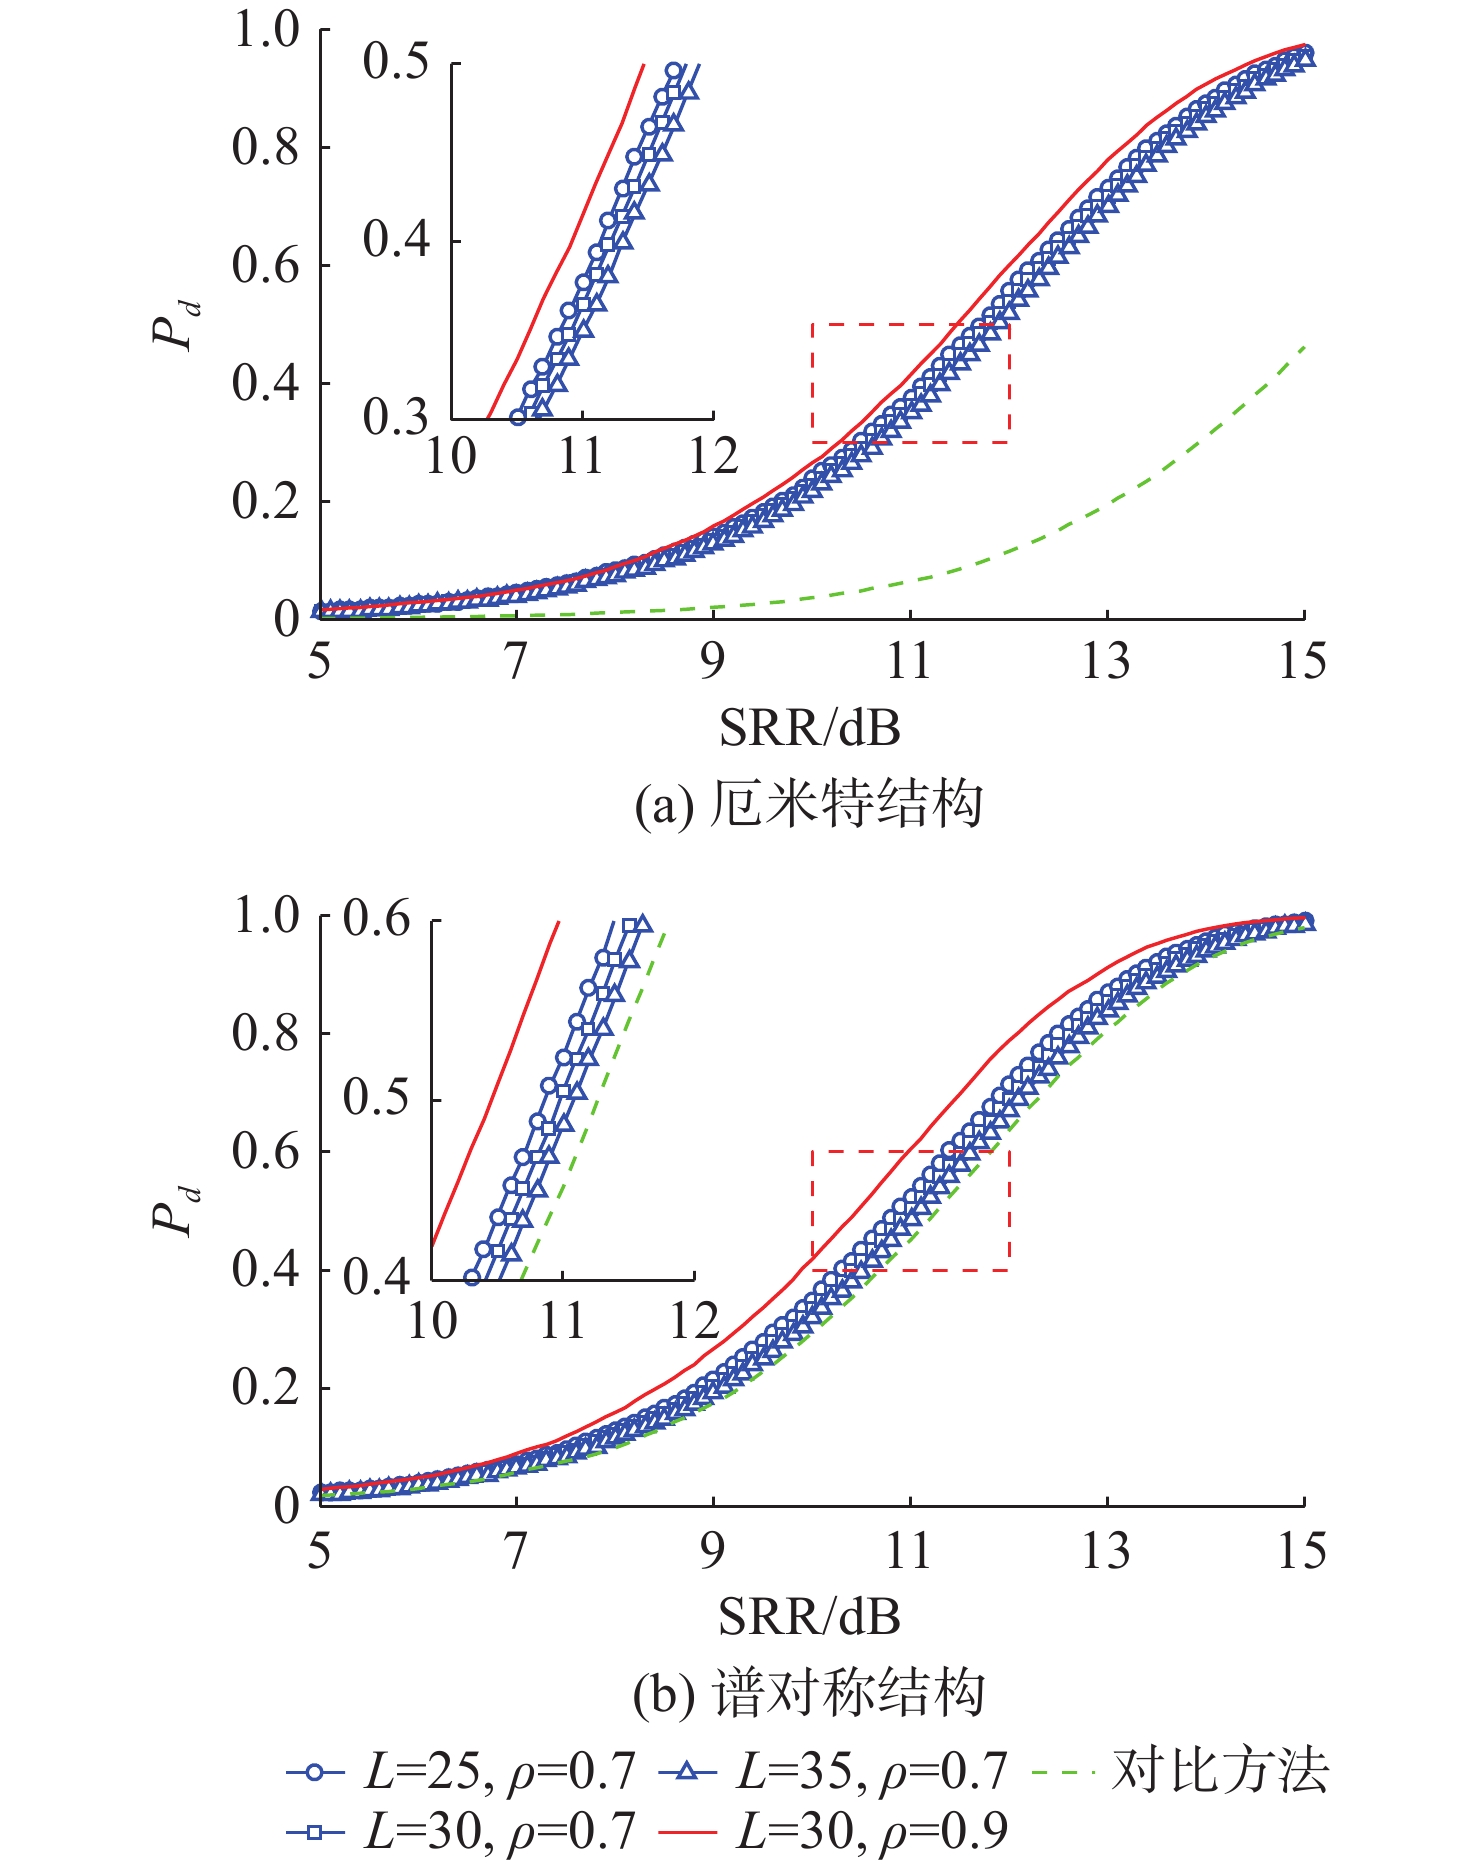
图 11 $ {\boldsymbol{\rho}} $失配时$ {\boldsymbol{L}} $不同取值下$ {{\boldsymbol{P}}}_{{\boldsymbol{d}}} $随$ \bf{SRR} $的变化曲线
Figure 11. The $ {{\boldsymbol P}}_{{\boldsymbol{d}}} $ curve with $ \mathbf{SRR} $ under different values of $ {\boldsymbol L} $ when $ {\boldsymbol \rho } $ mismatch occurs
表 1 对比方法的判决式
Table 1. Decision rule of comparative methods
检测方法 判决式 H-TD-REE $ \dfrac{\text{det}\left({\boldsymbol z}{{\boldsymbol z}}^{\text{H}}+\tilde{{\boldsymbol S}}\right)}{\text{det}\left(\left({\boldsymbol z}-\hat{\alpha }{{\boldsymbol v}}_{t}\right){\left({\boldsymbol z}-\hat{\alpha }{{\boldsymbol v}}_{t}\right)}^{\text{H}}+\tilde{{\boldsymbol S}}\right)}\begin{array}{c}{H}_{1}\\\gtrless \\{H}_{0}\end{array}\eta $ S-TD-REE $ \dfrac{\text{det}\left({{\boldsymbol z}}_{r}{\boldsymbol z}_{r}^{\text{T}}+{{\boldsymbol z}}_{i}{\boldsymbol z}_{i}^{\text{T}}+{\tilde{{\boldsymbol S}}}_{S}\right)}{\text{det}\left({\tilde{{\boldsymbol u}}}_{1}\tilde{{\boldsymbol u}}_{1}^{\text{T}}+{\tilde{{\boldsymbol u}}}_{2}\tilde{{\boldsymbol u}}_{2}^{\text{T}}+{\tilde{{\boldsymbol S}}}_{S}\right)}\begin{array}{c}{H}_{1}\\\gtrless \\{H}_{0}\end{array}\eta $ T-AMF $ \dfrac{{\left| {{\boldsymbol z}}^{\text{H}}{\boldsymbol S}_{2}^{-1}{{\boldsymbol v}}_{t}\right| }^{2}}{{{{{\boldsymbol v}}_{t}}}^{\text{H}}{\boldsymbol S}_{2}^{-1}{{\boldsymbol v}}_{t}}\begin{array}{c}{H}_{1}\\\gtrless \\{H}_{0}\end{array}\eta $ TS-AMF $ \dfrac{\left\{\begin{array}{c}{\left({\boldsymbol v}_{tr}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol z}}_{r}+{\boldsymbol v}_{ti}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol z}}_{i}\right)}^{2}\\+{\left({\boldsymbol v}_{tr}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol z}}_{i}+{\boldsymbol v}_{ti}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol z}}_{r}\right)}^{2}\end{array}\right\}}{{\boldsymbol v}_{tr}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol v}}_{tr}+{\boldsymbol v}_{ti}^{\text{T}}{\boldsymbol S}_{S2}^{-1}{{\boldsymbol v}}_{ti}}\begin{array}{c}{H}_{1}\\\gtrless \\{H}_{0}\end{array}\eta $  下载: 导出CSV
表 2 $ {\bf{RPR}}_{{\bf{1}}} $和$ {\bf{RPR}}_{{\bf{2}}} $的不同取值情况
Table 2. The different values of $ {\mathbf{RPR}}_{{\bf{1}}} $ and $ {\bf{RPR}}_{{\bf{2}}} $
取值情况 1 2 3 4 5 6 $ {\text{RPR}}_{1} $(dB) 7 7 −7 −7 7 10 $ {\text{RPR}}_{2} $(dB) 9 −9 9 −9 15 15
下载: 导出CSV
-
[1] 刘伯胜, 雷家煜. 水声学原理[M]. 哈尔滨: 哈尔滨工程大学出版社, 2010. [2] 郝程鹏, 闫晟, 徐达等. 主动声纳恒虚警处理技术[M]. 北京: 人民邮电出版社, 2021. [3] 孙梦茹. 水下相干干扰环境下的多通道自适应检测研究[D]. 北京: 中国科学院声学研究所, 2021: 4. [4] 刘维建. 多通道雷达信号自适应检测技术研究[D]. 长沙: 国防科学技术大学, 2014: 1-3. [5] Kelly E J. An adaptive detection algorithm[J]. IEEE Transactions on Aerospace and Electronic Systems, 1986, AES-22(2): 115-127. [6] Chen W S, Reed I S. A new CFAR detection test for radar[J]. Digital Signal Processing, 1991, 1(4): 198-214. doi: 10.1016/1051-2004(91)90113-Y [7] Robey F C, Fuhrmann D R, Kelly E J, et al. A CFAR adaptive matched filter detector[J]. IEEE Transactions on Aerospace and Electronic Systems, 1992, 28(1): 208-216. doi: 10.1109/7.135446 [8] Braham Himed, William L. Melvin. Analyzing space-time adaptive processors using measured data[C]//The Thirty-First Asilomar Conference on Signals, Systems and Computers, 1997: 930-935. [9] Tang B, Liu J, Huang Z, et al. Adaptive target detection in Gaussian clutter edges[J]. IEEE Transactions on Aerospace and Electronic Systems, 2020, 56(2): 1662-1673. doi: 10.1109/TAES.2019.2930019 [10] 徐达. 多通道声呐混响边缘检测及目标检测方法研究[D]. 北京: 中国科学院大学, 2021: 79-95. [11] 王天琪, 郝程鹏, 殷超然等. 混响边缘环境下的自适应目标检测方法[C]//中国高科技产业化研究会智能信息处理产业化分会. 第十七届全国信号和智能信息处理与应用学术会议论文集. 北京: 《计算机工程与应用》编辑部, 2023: 96-103. [12] 王天琪. 混响边缘环境下的主动声呐自适应检测算法研究[D]. 中国科学院声学研究所, 2024. [13] Li P, Huang B, Wang W Q. Knowledge-aided bayesian detection of distributed target for FDA-MIMO radar in gaussian clutter[J]. IEEE Transactions on Radar Systems, 2024, 2: 344-354. doi: 10.1109/TRS.2024.3378125 [14] Jing P C, Gao Y C, et al. A Bayesian approach for dual-knowledge-aided target detection and performance analysis in heterogeneous environments[J]. Signal Processing, 2025, 230: 109852. doi: 10.1016/j.sigpro.2024.109852 [15] Li K, Luo J Y, et al. Improved variational bayes for space-time adaptive processing[J]. Remote Sensing, 2025, 27(3): 242. [16] Hao C, Orlando D, Liu J, et al. Advances in adaptive radar detection and range estimation[M]. Berlin: Springer Nature Singapore, 2022. [17] A. De Maio, A. Farina, G. Foglia. knowledge-aided bayesian radar detectors & their application to live data[J]. IEEE Transactions on Aerospace and Electronic Systems, 2010, 46(1): 170-183. [18] 郝程鹏, 闫晟, 张宇轩. 主动声呐空时自适应处理技术[M]. 北京: 科学出版社, 2023. [19] 徐文, 鄢社锋, 季飞等. 海洋信息获取、传输、处理及融合前沿研究评述[J]. 中国科学(信息科学), 2016, 46(8): 1053-1085. [20] Lutkepohl H. Handbook of matrices[M]. New York: Wiley, 1997. -

 下载:

 点击查看大图
计量
- 文章访问数: 2
- HTML全文浏览量: 0
- PDF下载量: 0
- 被引次数: 0