

Design and dynamic analysis of suspended UVPMS for visual-assisted grasping of polymetallic nodules
-
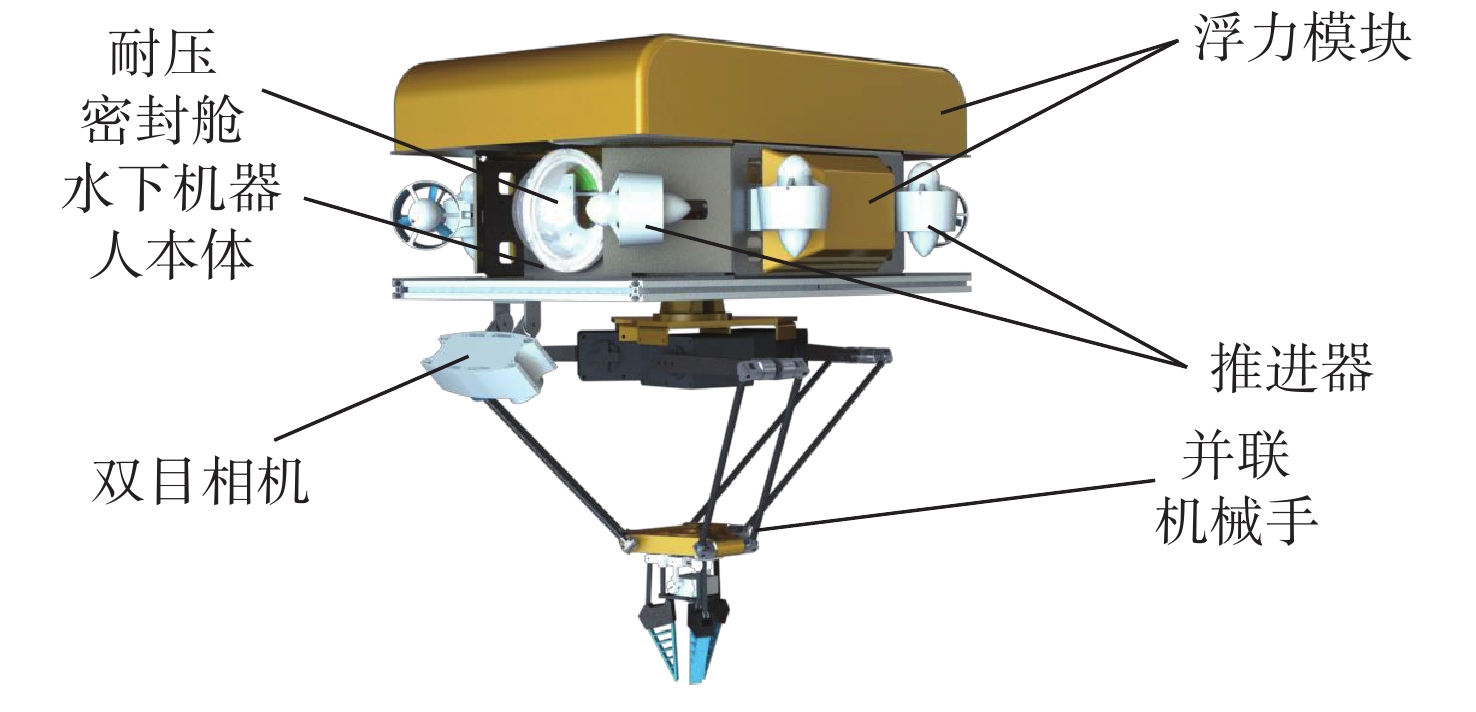
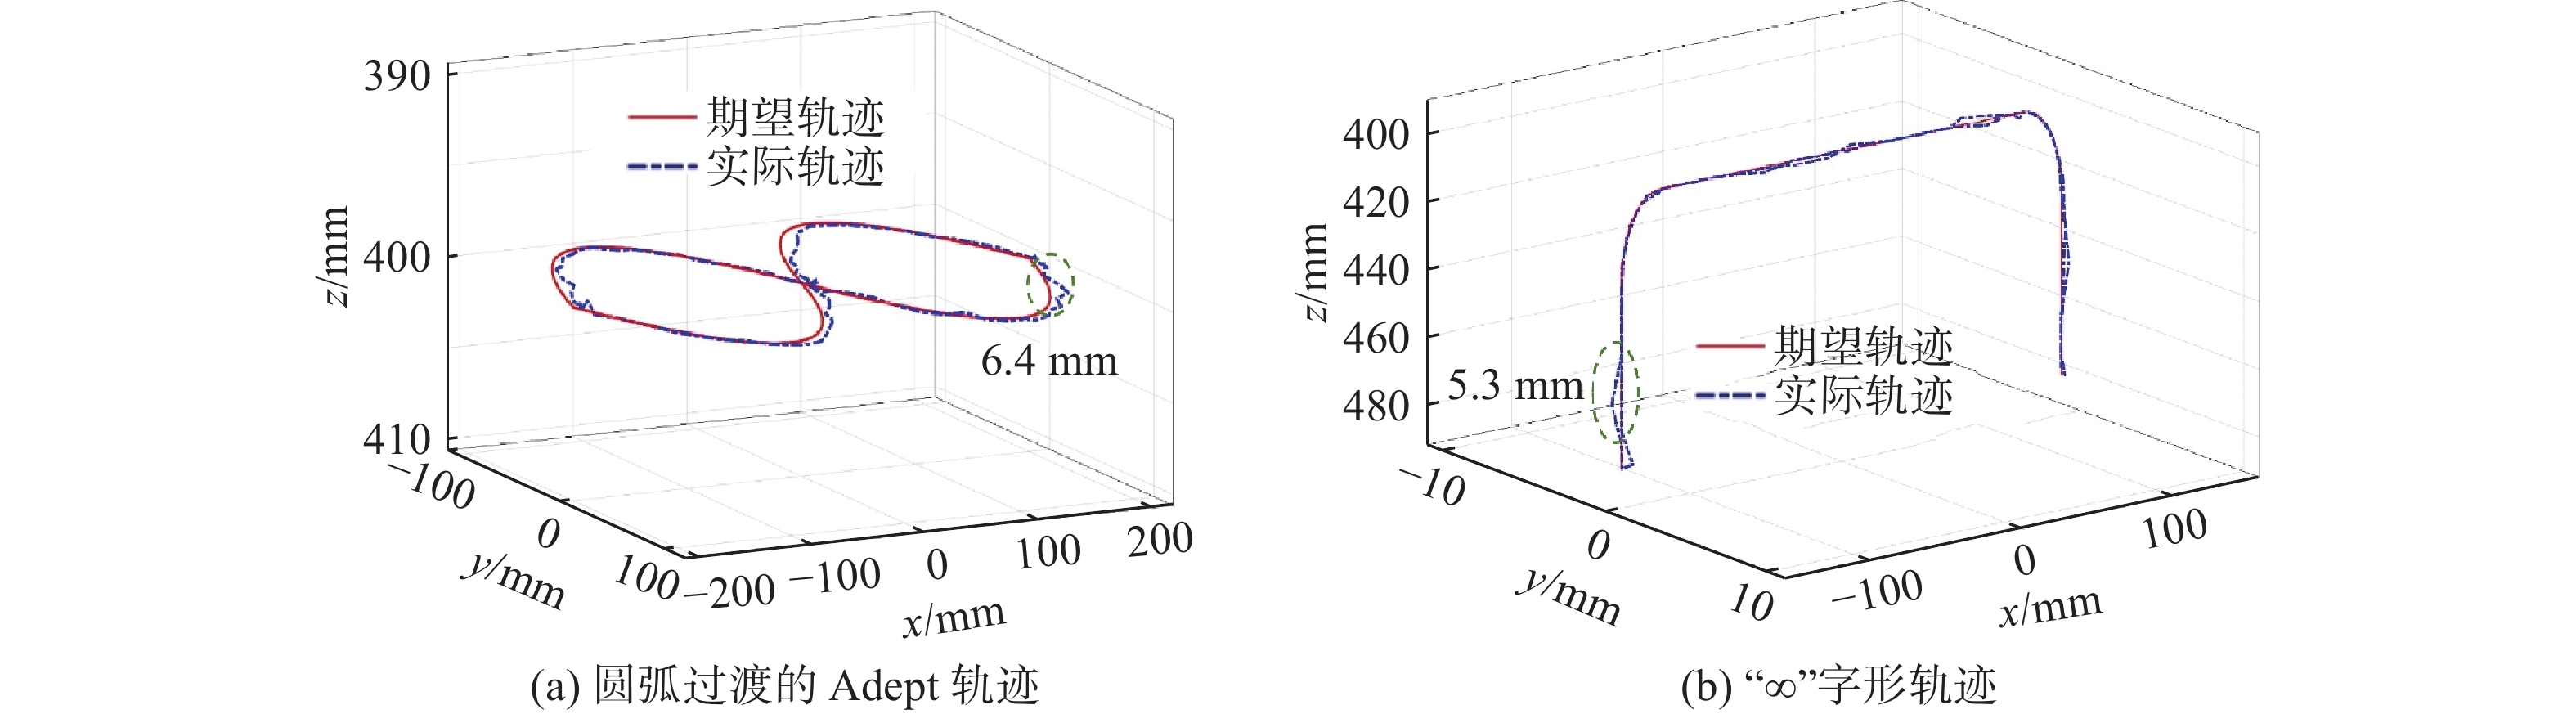
摘要: 针对传统履带式深海采矿装备在作业过程中易引起海床扰动、沉积物羽流扩散以及软底质环境下通过性受限等问题, 提出了一种面向多金属结核视觉辅助抓取的悬浮式水下机器人-并联机械手操作系统(UVPMS)。该系统采用框架式悬浮本体, 搭载下置式Delta并联机械手并集成双目视觉感知, 以实现水下金属结核的识别、定位与引导抓取。文中介绍了该系统总体方案设计、Delta机构运动学分析及多体耦合动力学建模分析, 构建了由图像预处理、改进YOLOv8识别、基于极线约束的双目匹配、目标区域质心提取和视觉引导抓取执行流程。并开展陆上轨迹跟踪实验及水下多金属结核模拟物抓取实验, 在沉积物扰动和悬浮颗粒干扰条件下, 抓取成功率为67.3%, 水下抓取综合误差约为15 mm。结果表明, 所提出的悬浮式UVPMS能够在模拟深海扰动环境下完成多金属结核模拟物的识别、定位与低扰动视觉辅助抓取。Abstract: Aiming at the problems of seabed disturbance, sediment plume diffusion and limited trafficability in soft sediment environment caused by traditional crawler deep-sea mining equipment during operation, this paper proposes an underwater vehicle-parallel manipulator system (UVPMS) for visual-assisted grasping of polymetallic nodules. The system uses a frame-type suspension body, equipped with an under-mounted Delta parallel manipulator and integrated binocular vision perception to realize the identification, positioning and guided grasping of underwater metal nodules. Aiming at the system, the overall scheme design, Delta mechanism kinematics analysis and multi-body coupling dynamics modeling analysis are carried out in this paper. The execution process of image preprocessing, improved YOLOv8 recognition, binocular matching based on epipolar constraint, centroid extraction of target area and visual guided grasping is constructed. In the land trajectory tracking experiment, the maximum spatial tracking errors of the Delta parallel manipulator executing the Adept trajectory and the '∞'-shaped trajectory are 5.3 mm and 6.4 mm, respectively. The Precision, Recall and mAP @ 0.5 of the improved YOLOv8 model reached 96.0%, 94.6% and 96.5%, respectively. Under the condition of fixed body, the average absolute ranging error of binocular vision is about 9 mm, and the comprehensive error of end positioning after hand-eye transformation is 11 mm. A total of 55 continuous grasping tests were carried out in the grasping experiment of underwater polymetallic nodule simulant. Under the conditions of sediment disturbance and suspended particle interference, the success rate of grasping was 67.3%, and the comprehensive error of underwater grasping was about 15 mm. The results show that the proposed suspended UVPMS can complete the identification, positioning and low-disturbance visual-assisted grasping of polymetallic nodule simulants in a simulated deep-sea disturbance environment.
-
Key words:
- deep-sea mining /
- undersea vehicle /
- manipulator system /
- delta parallel manipulator /
- visual grasping
-
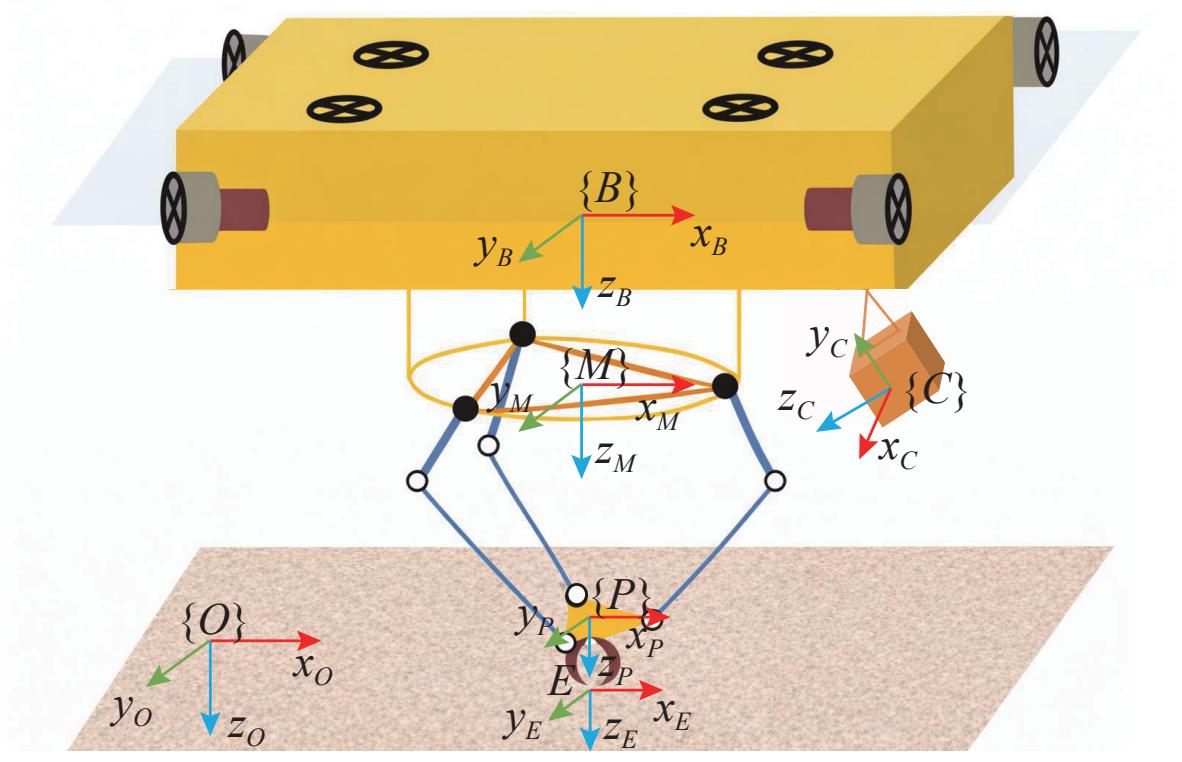
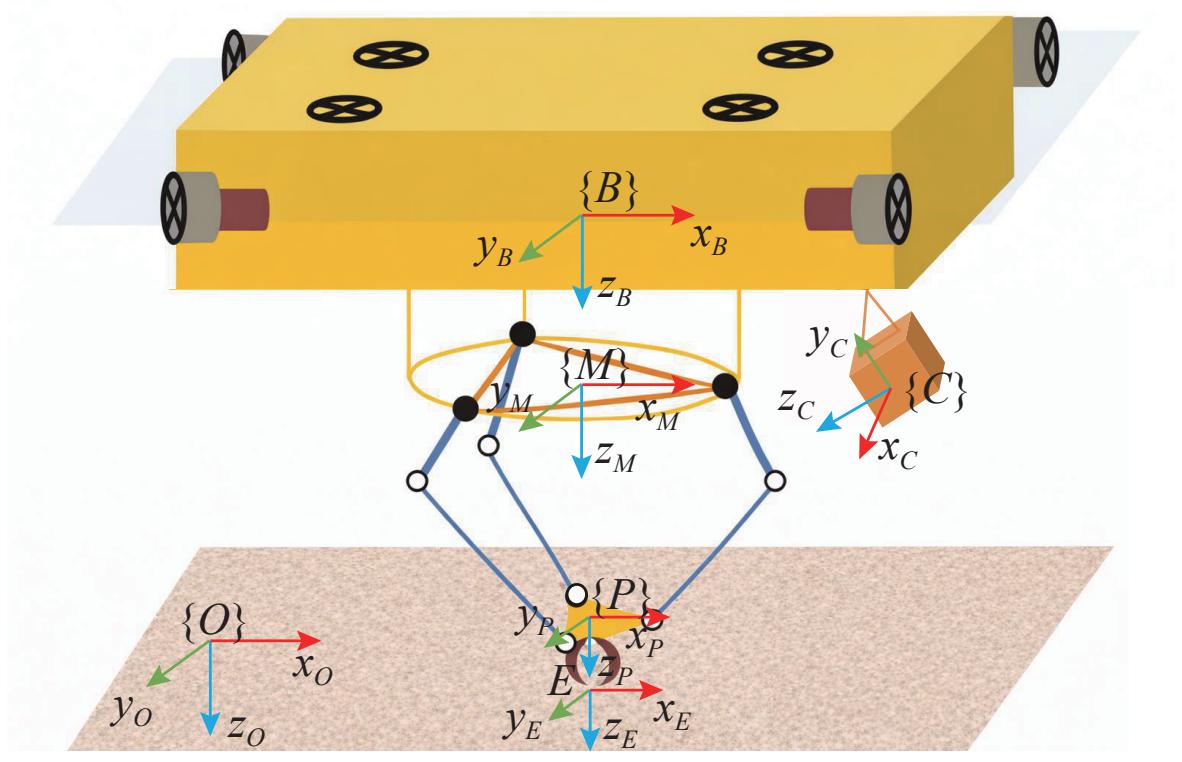
图 2 悬浮式UVPMS简化模型与坐标系定义
Figure 2. Simplified model and coordinate system definition of suspended UVPMS
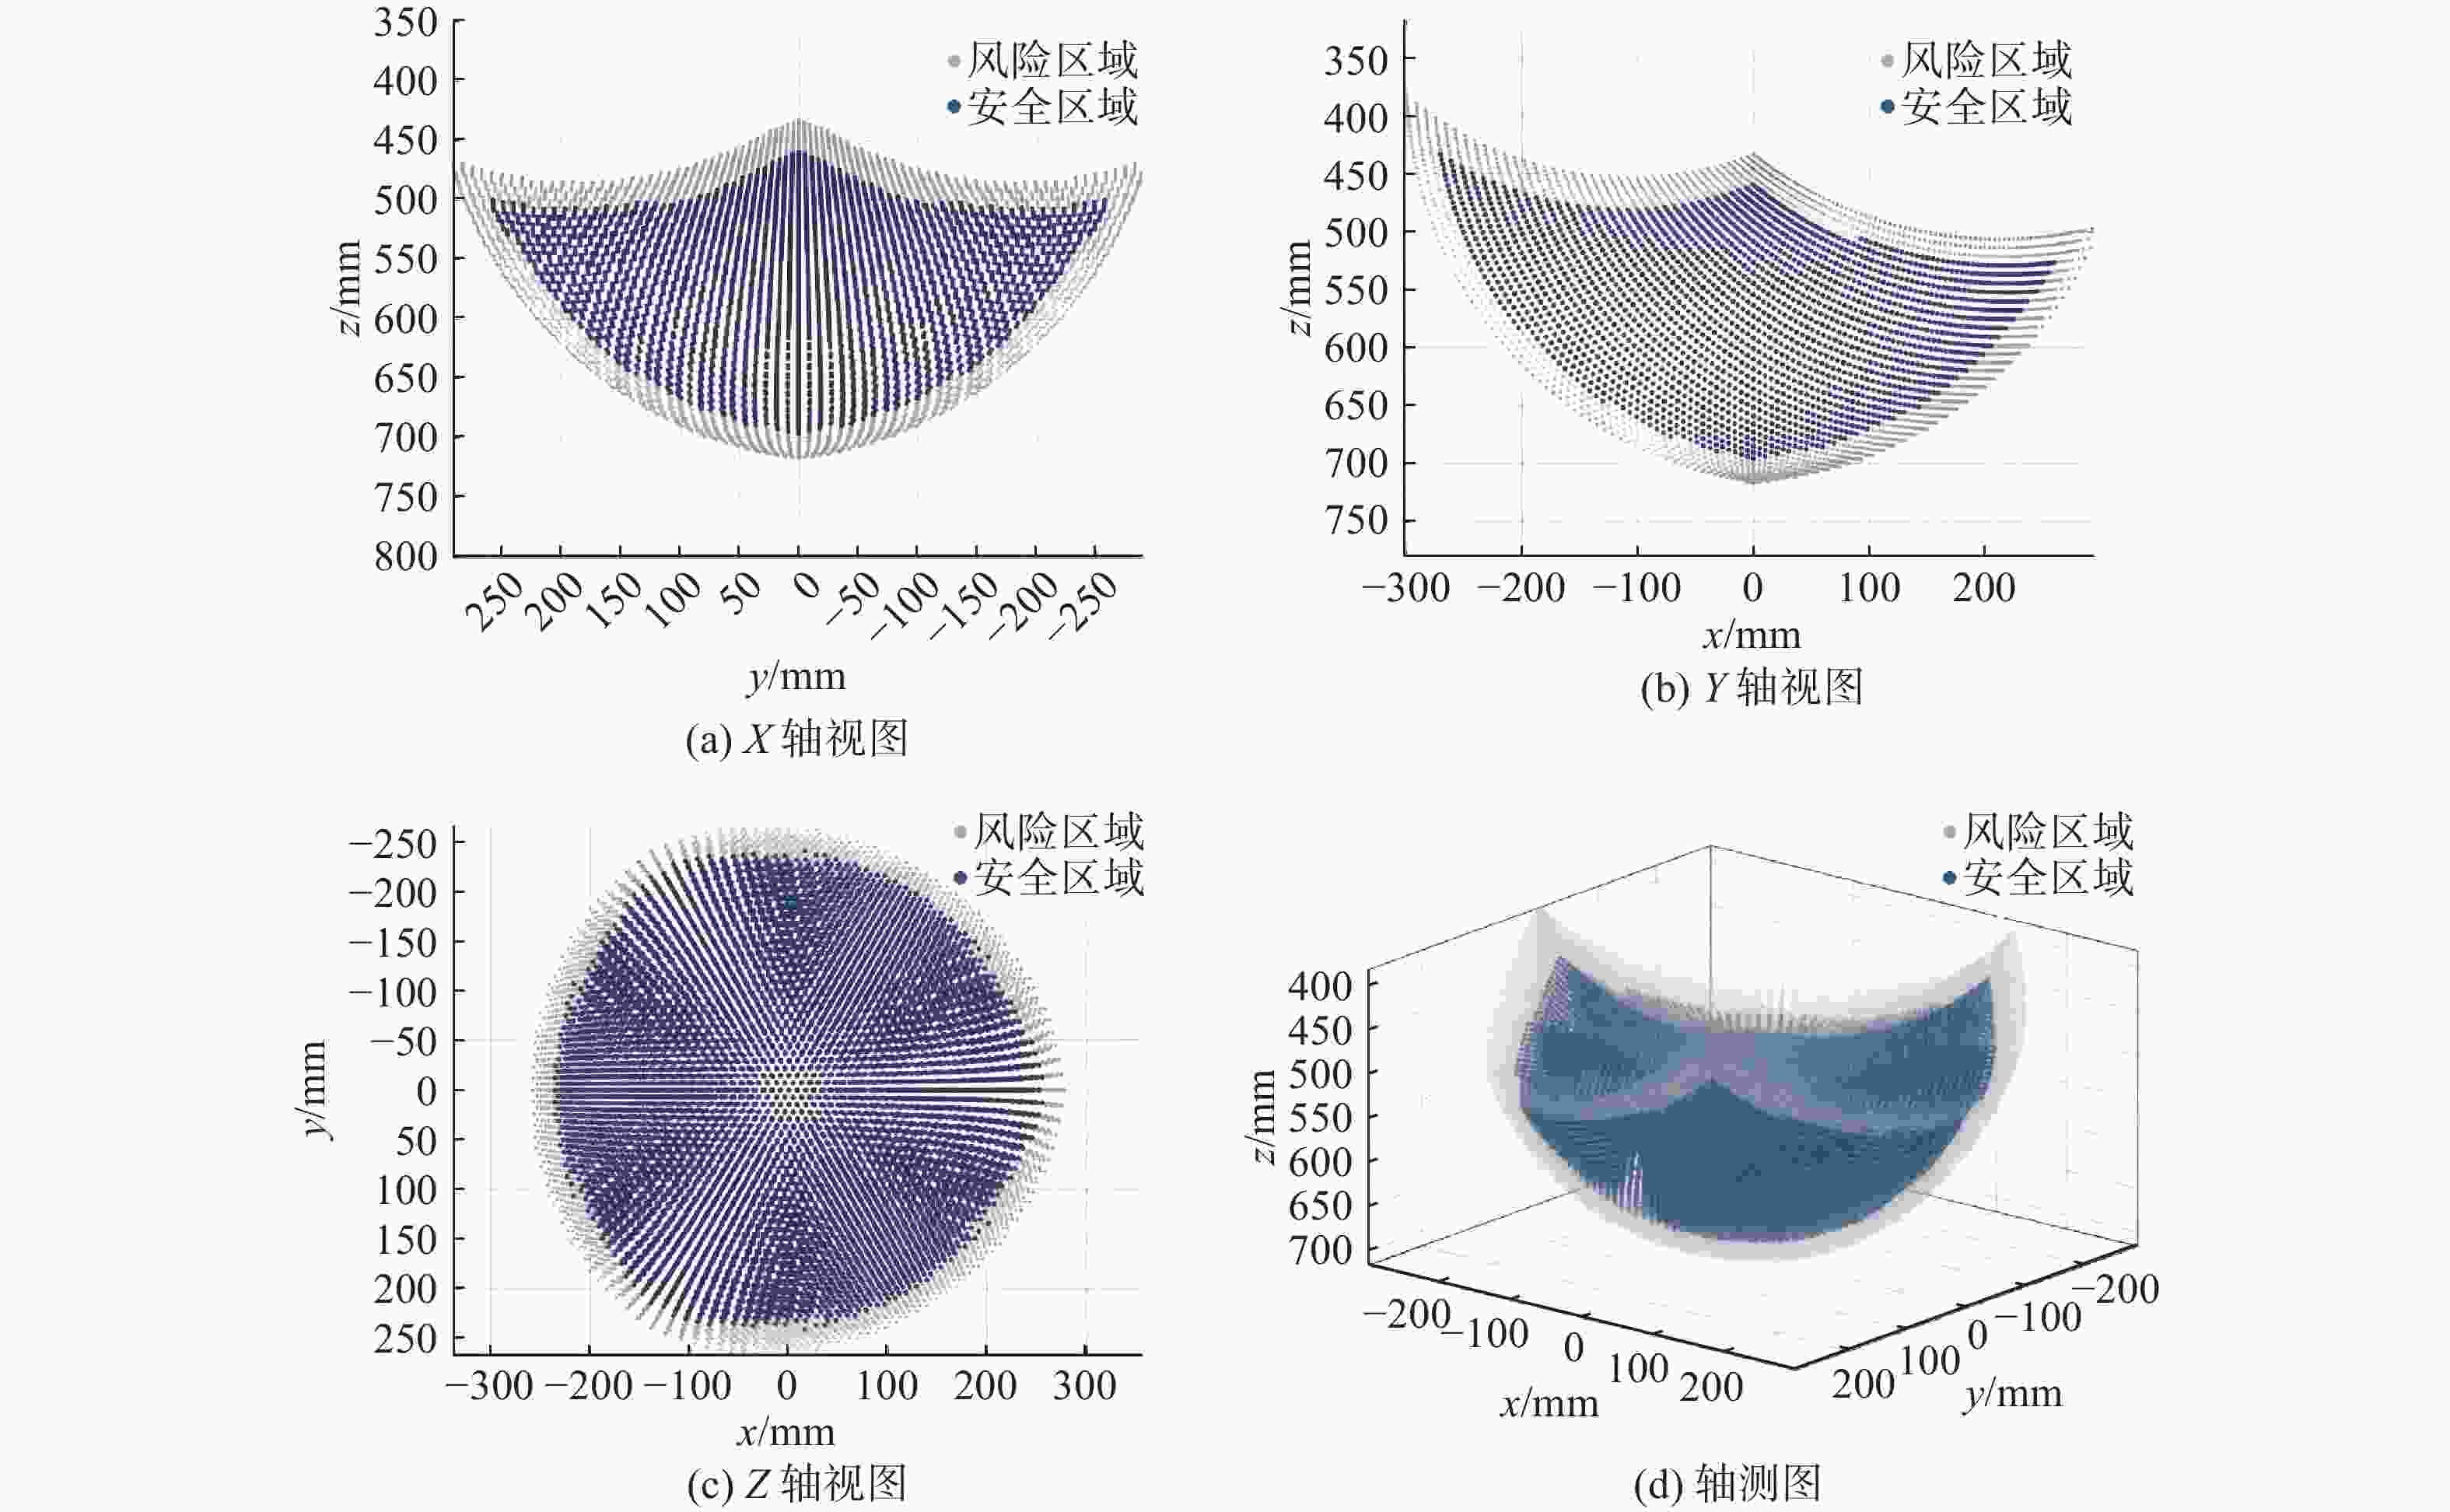
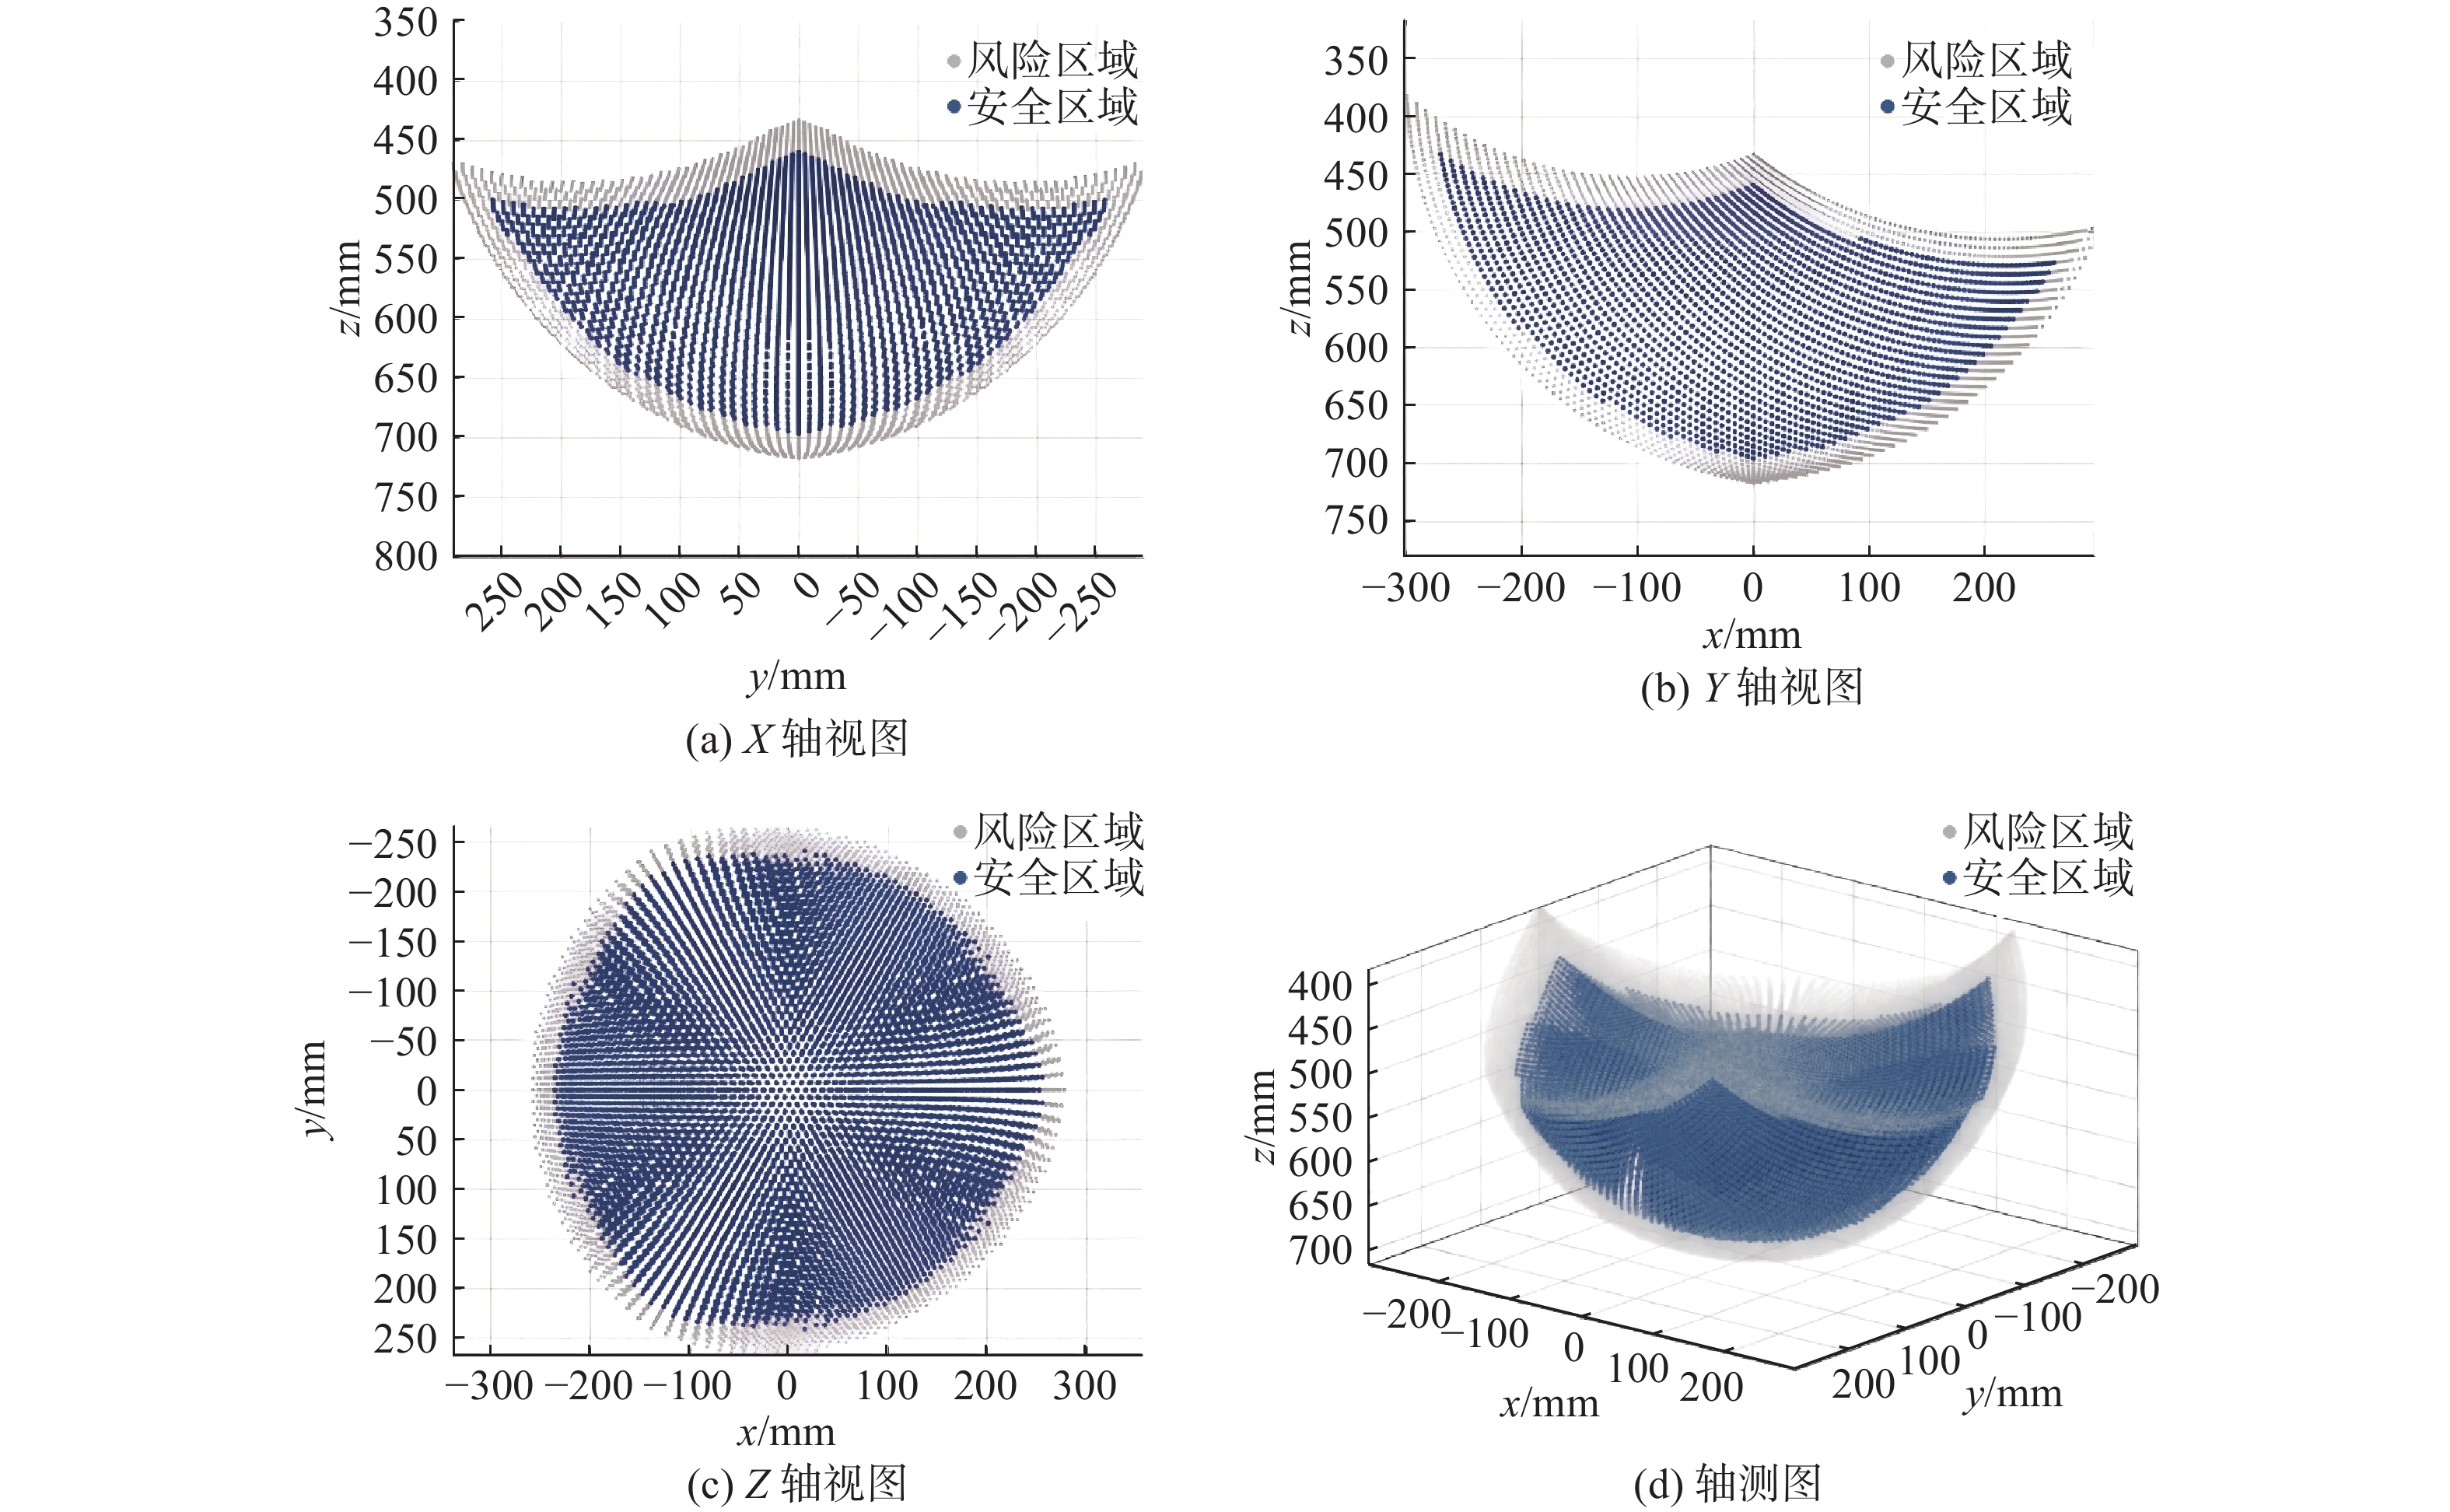
图 3 Delta并联机构工作空间与安全边界
Figure 3. Workspace and safety boundary of Delta parallel mechanism
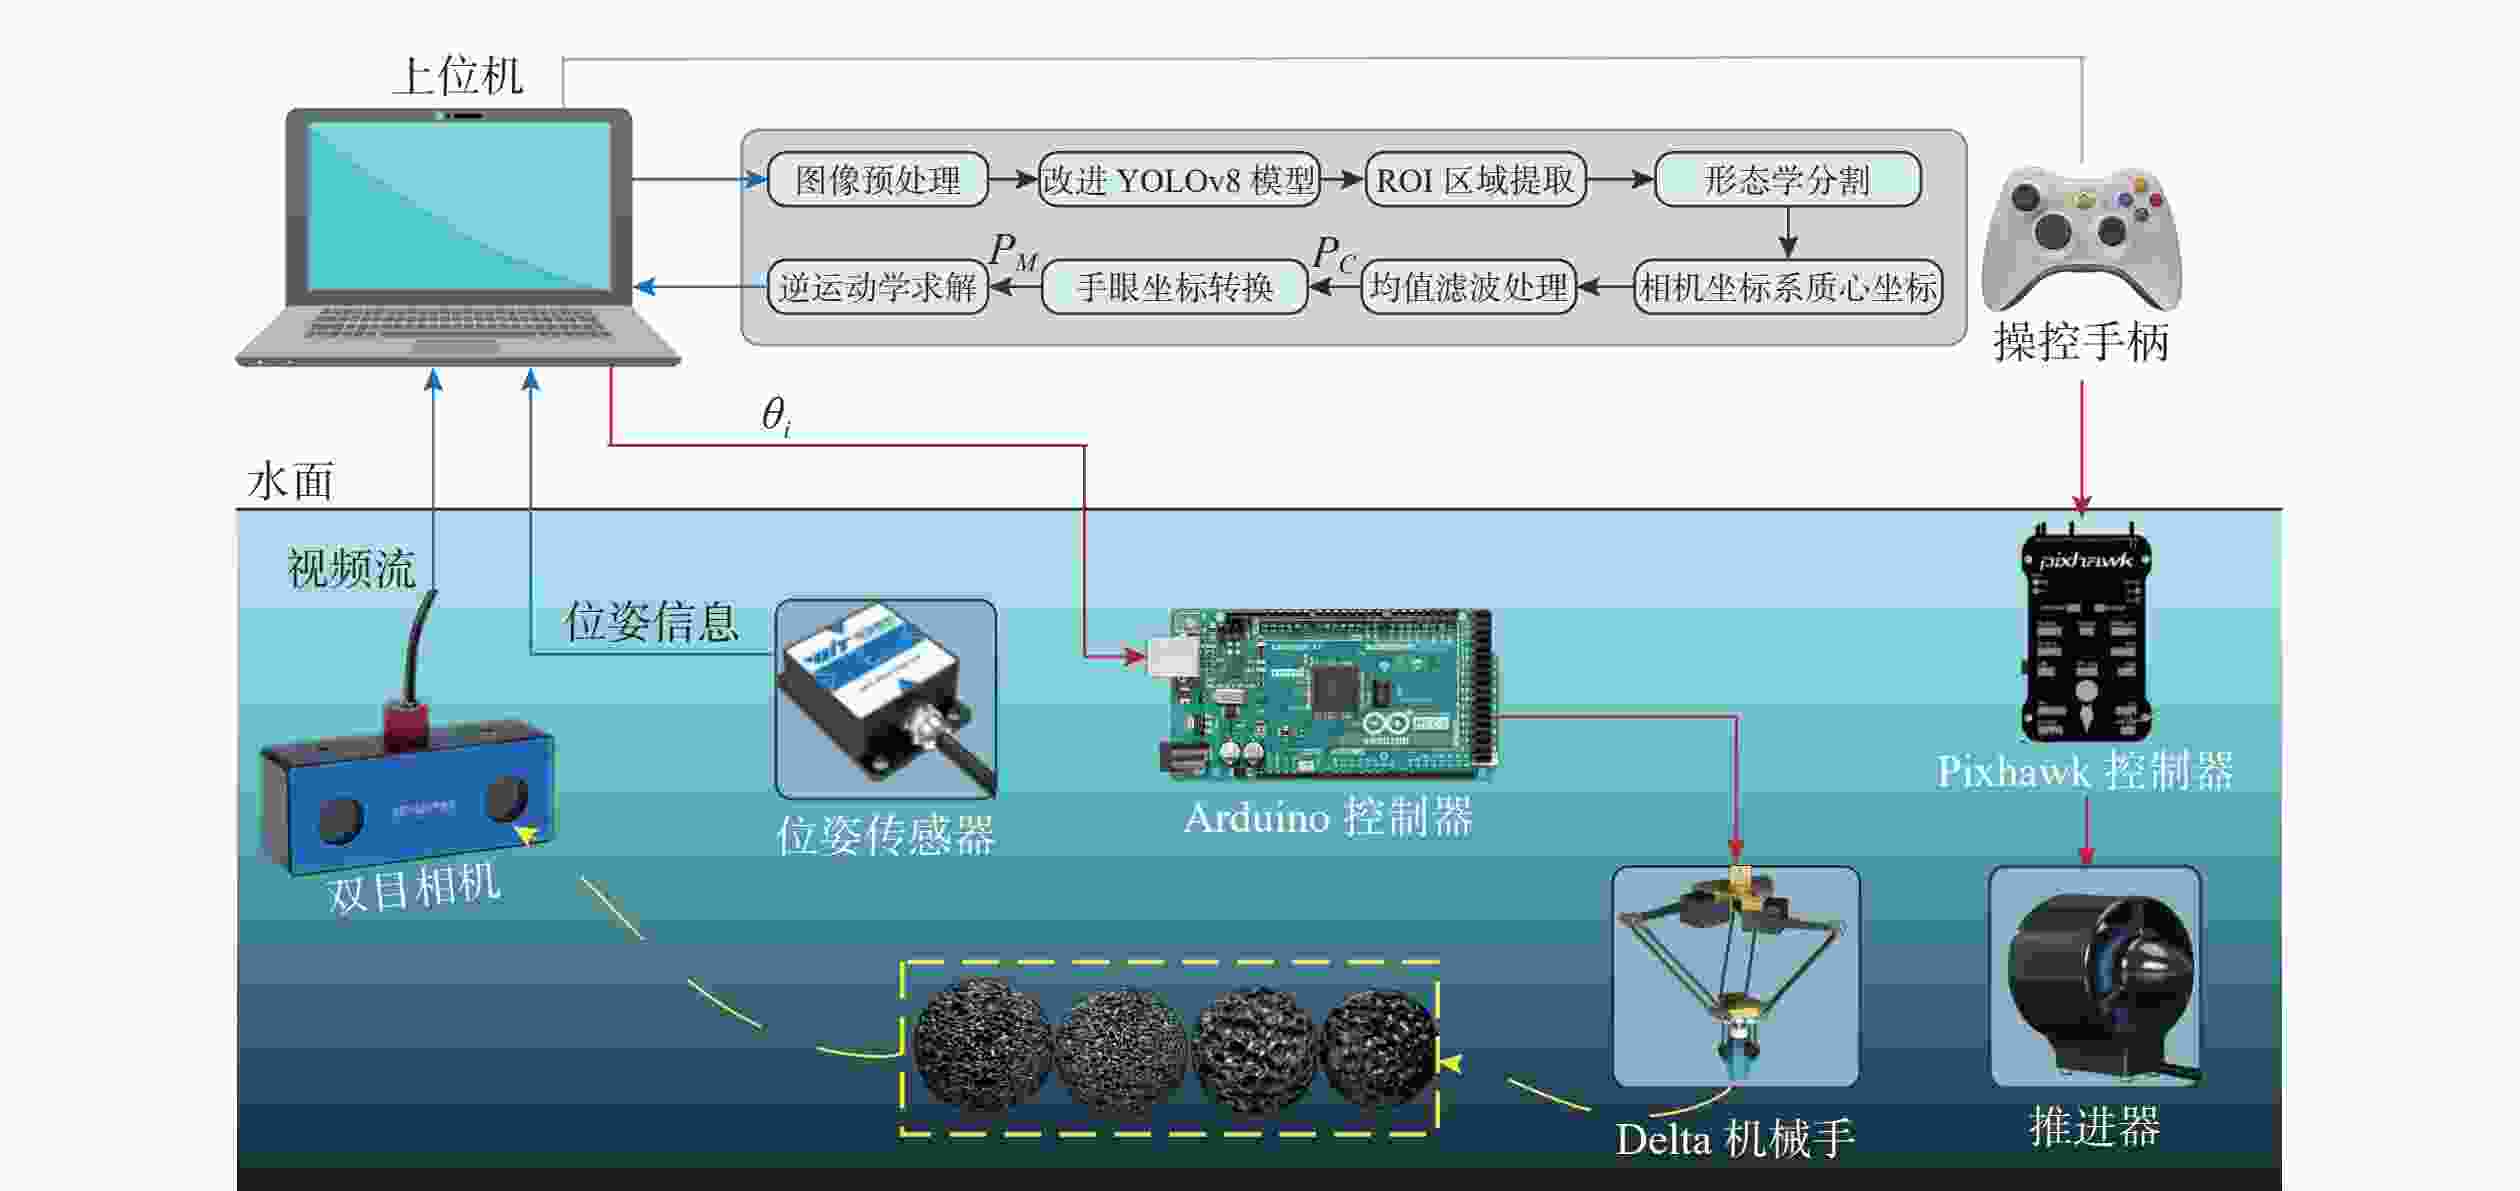
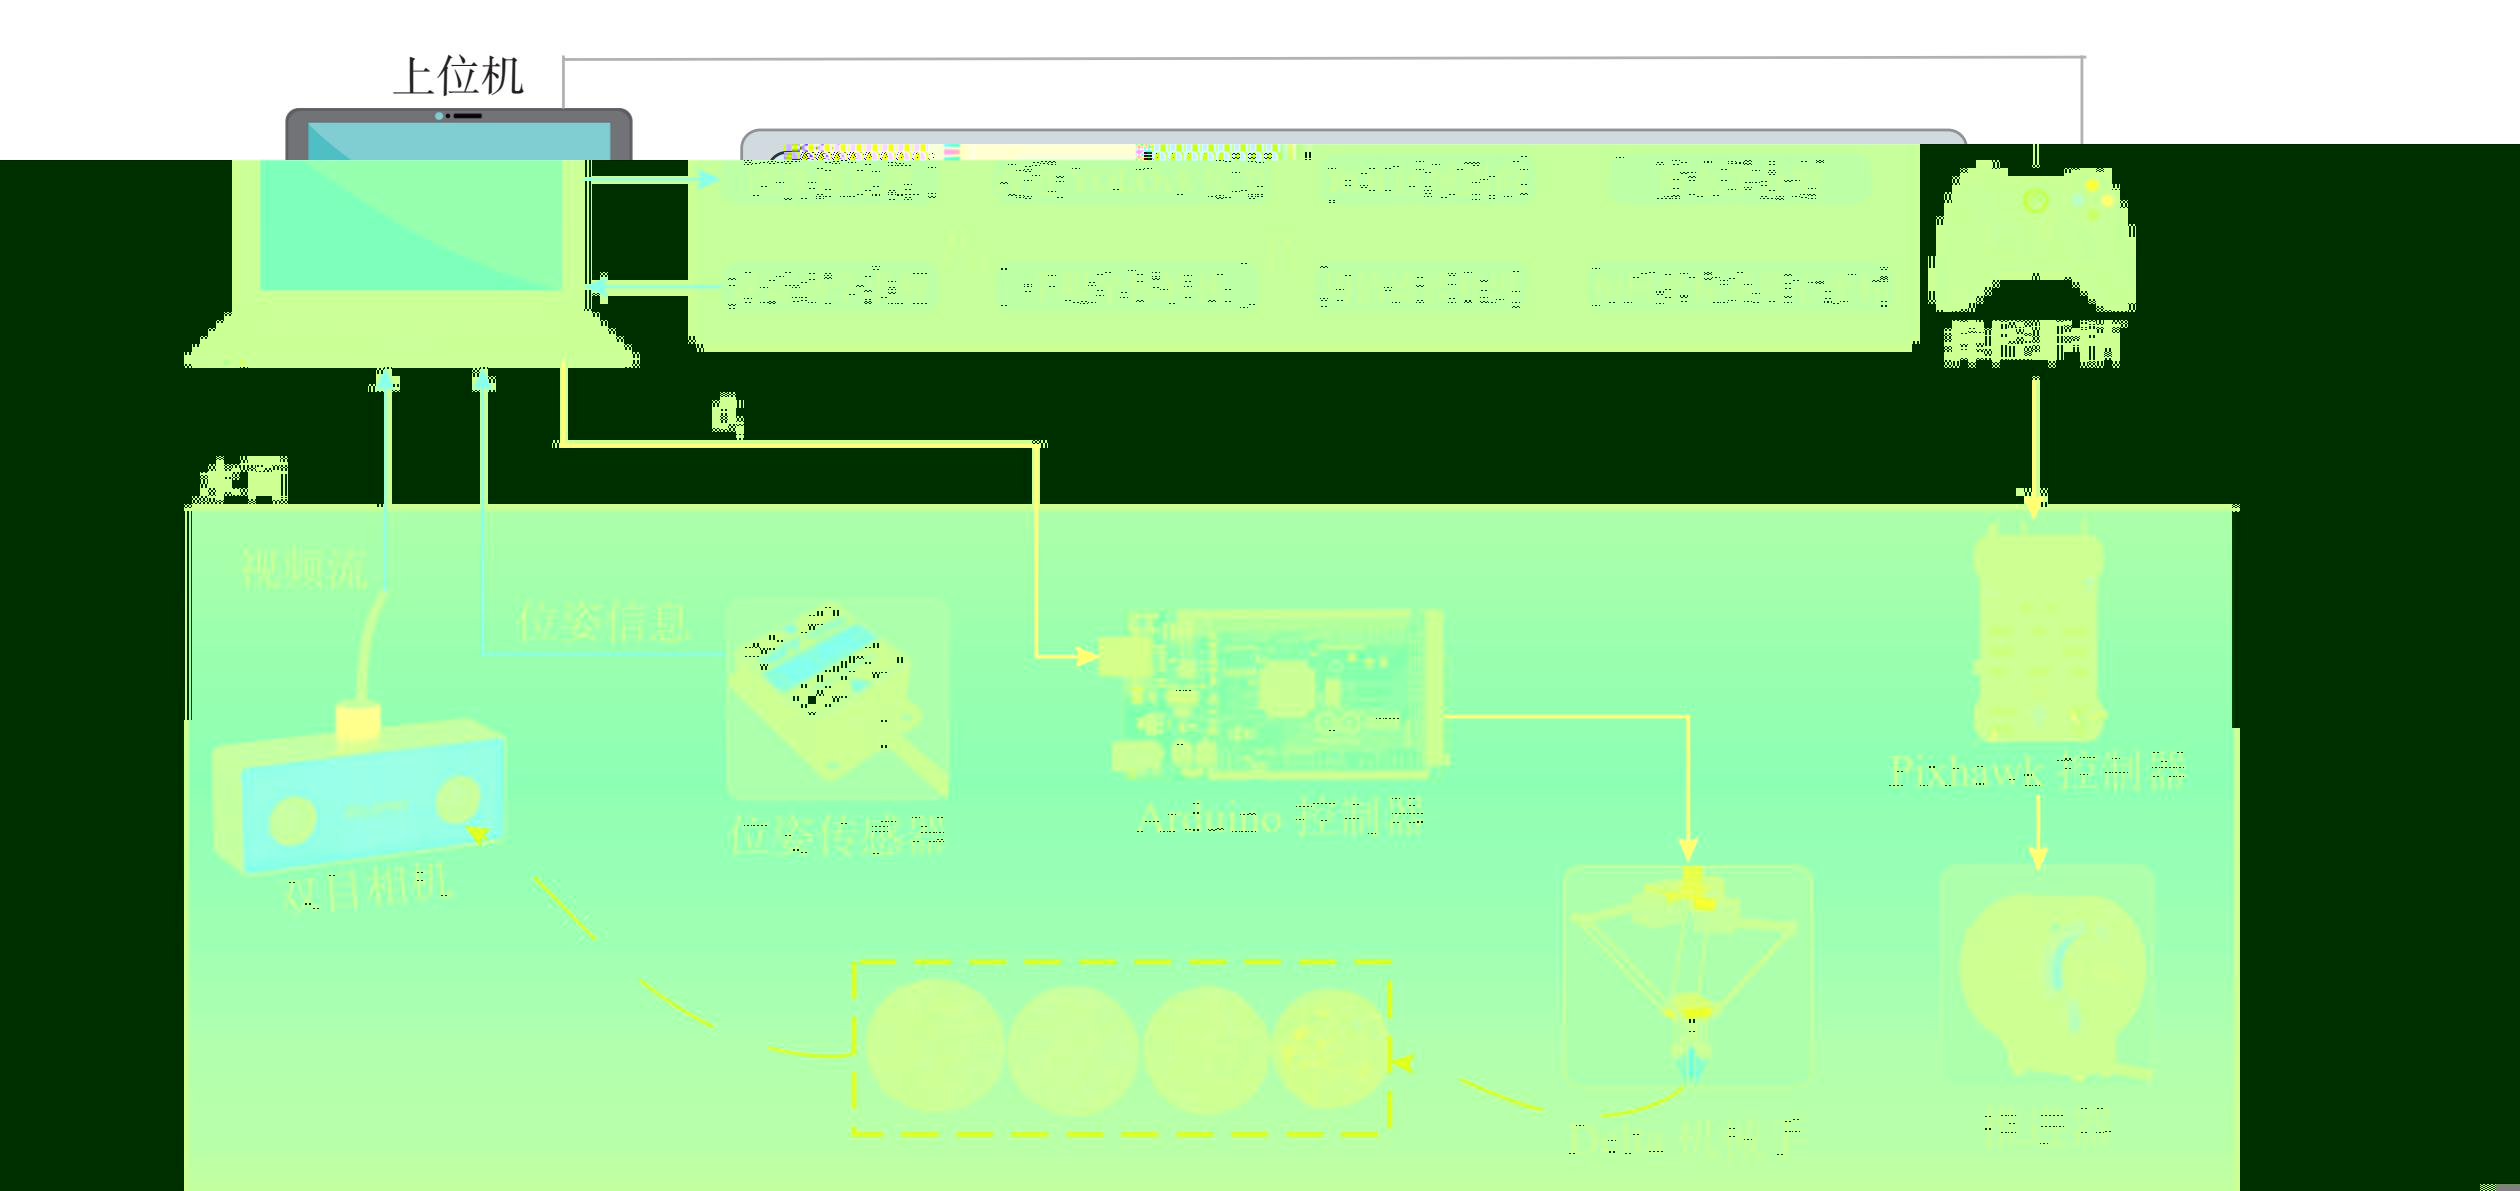
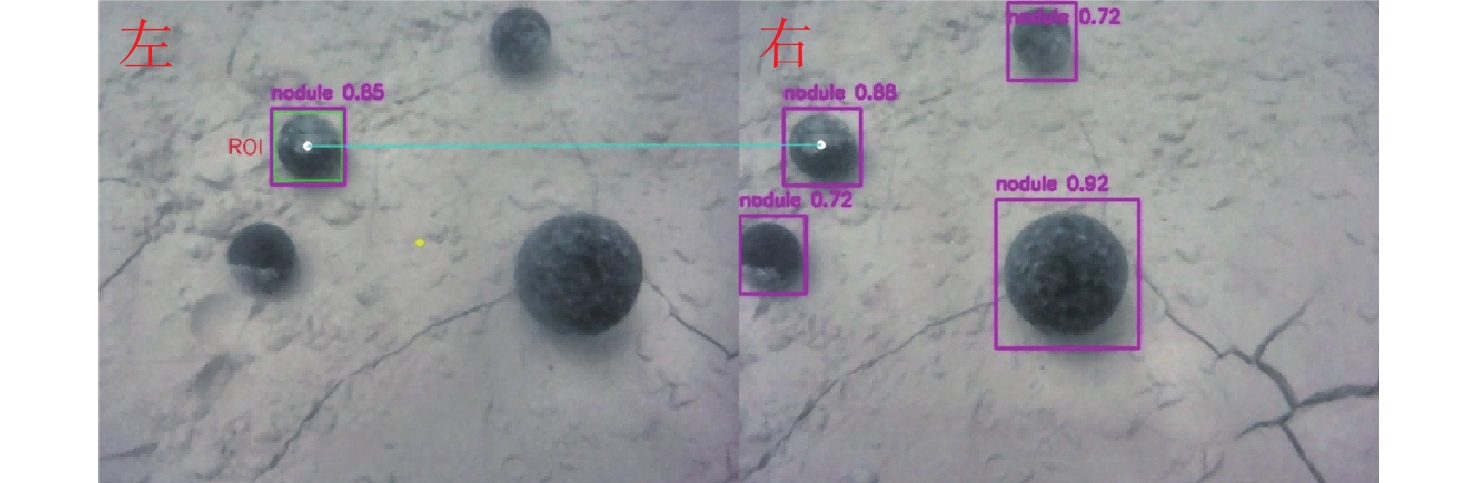
图 4 双目视觉控制系统整体架构图
Figure 4. The overall architecture diagram of binocular vision control system
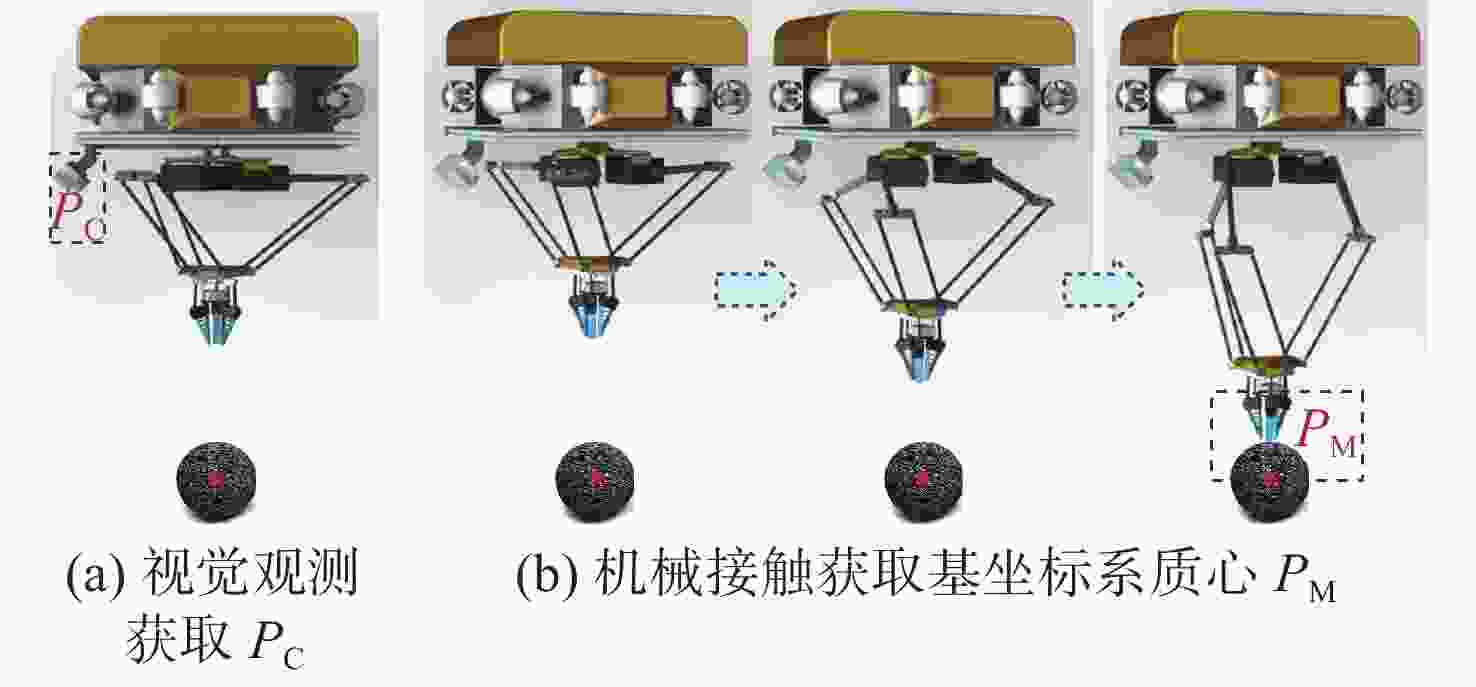
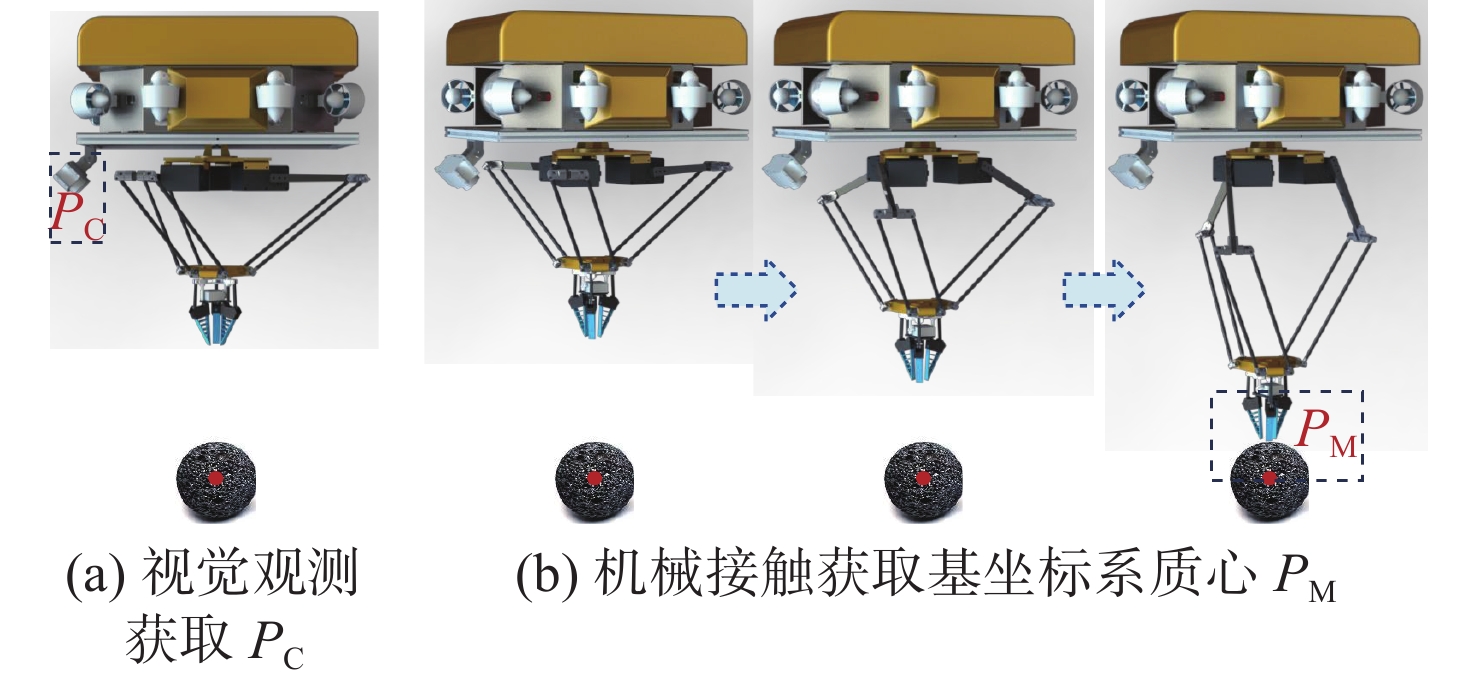
图 5 视觉观测-机械接触标定策略示意图
Figure 5. Visual observation-mechanical contact calibration strategy diagram
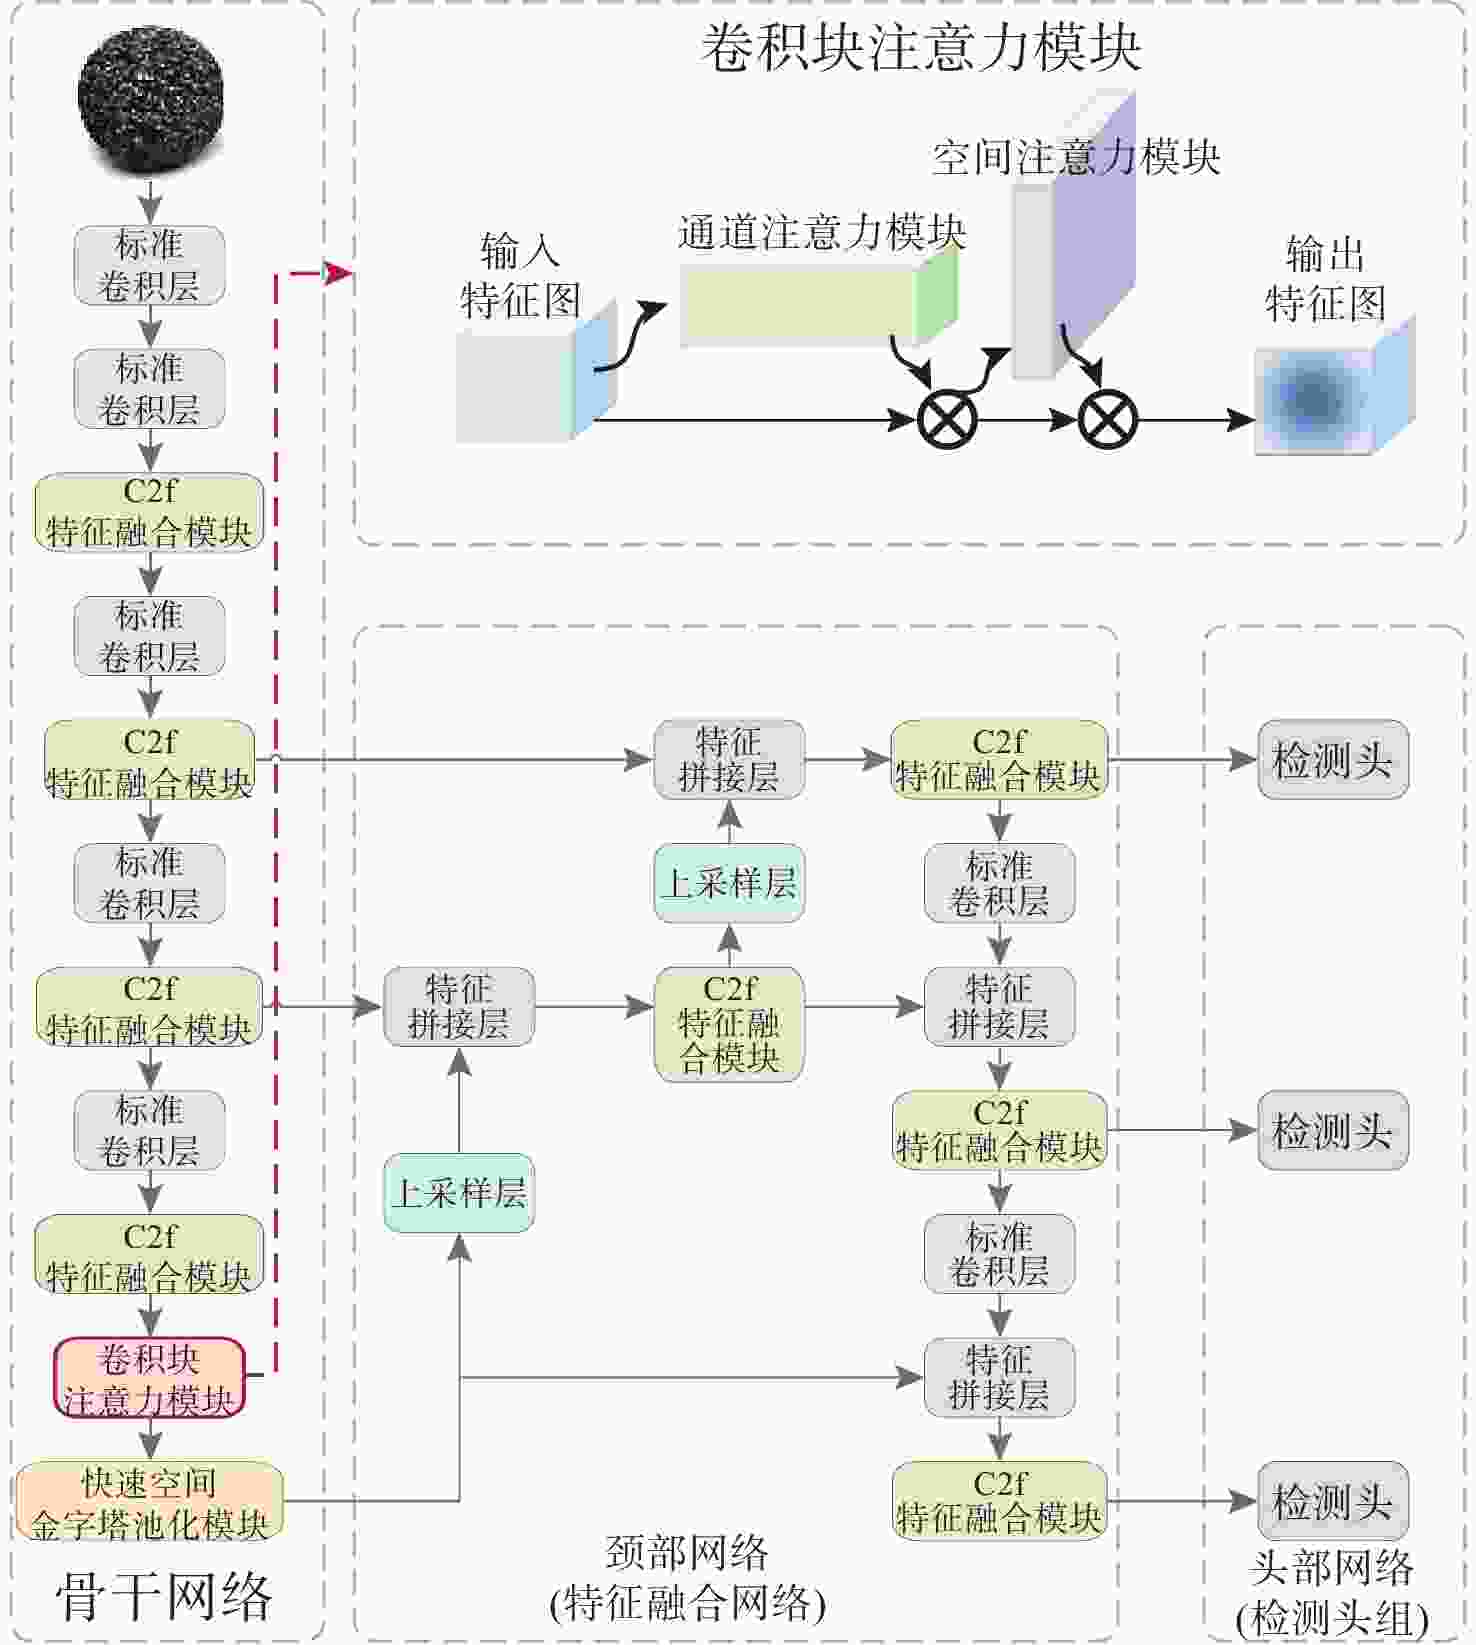
图 8 融合CBAM注意力模块的改进YOLOv8网络结构图
Figure 8. Network structure of the improved YOLOv8 with CBAM attention module
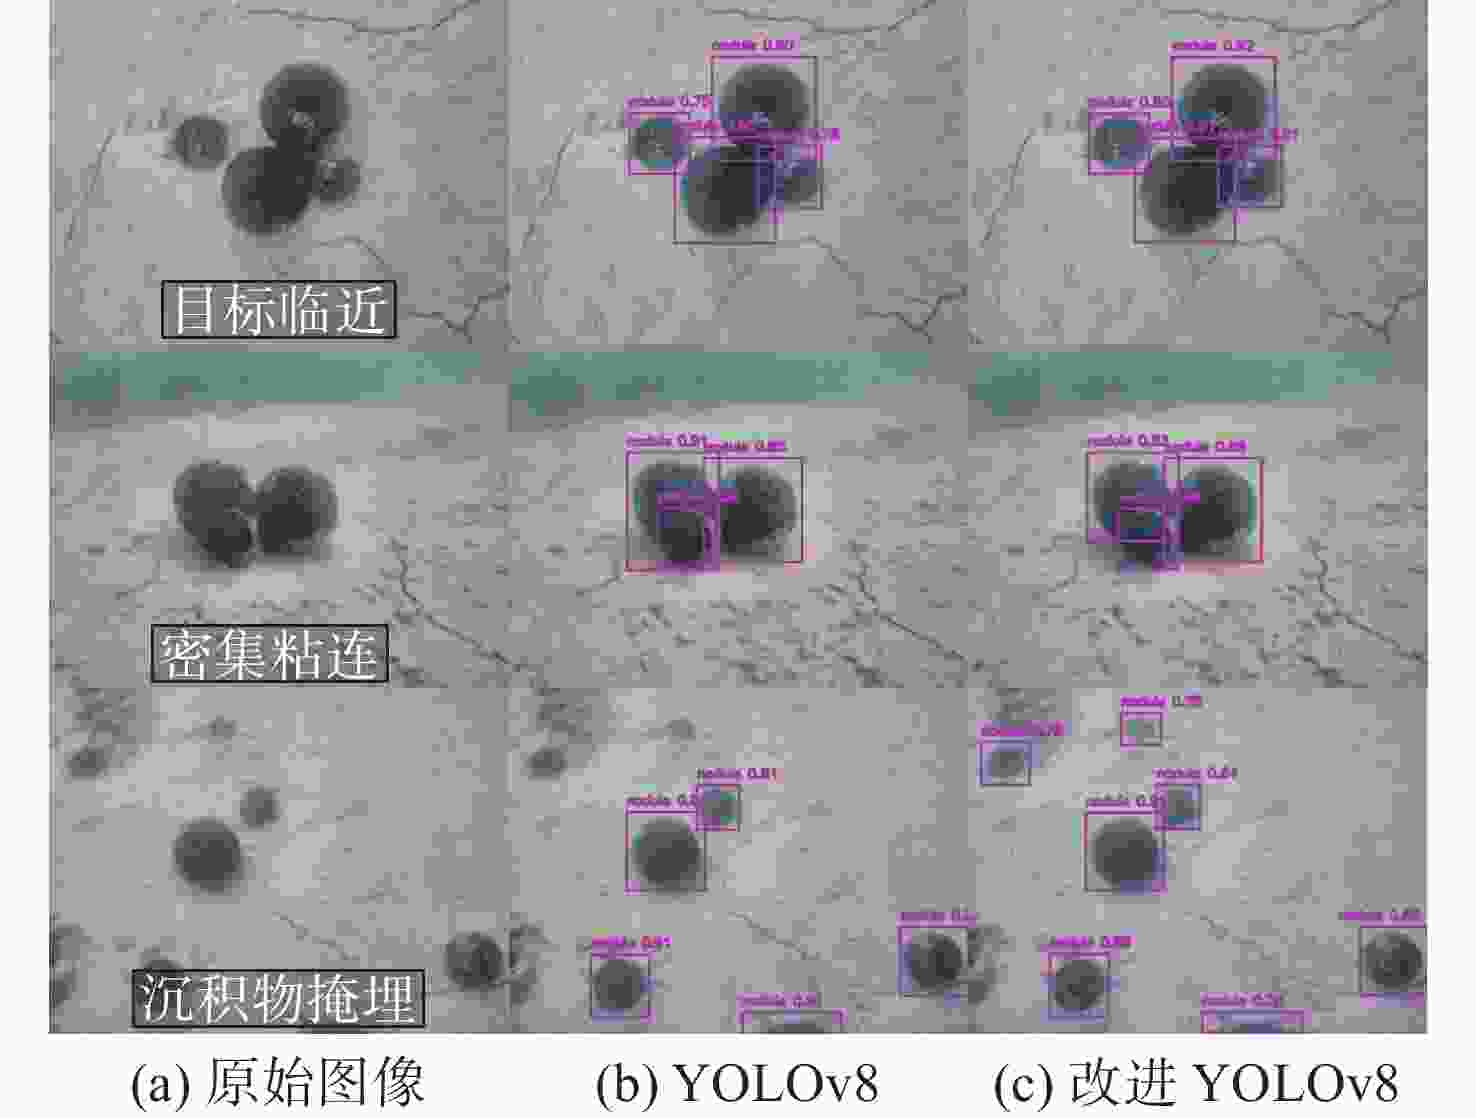
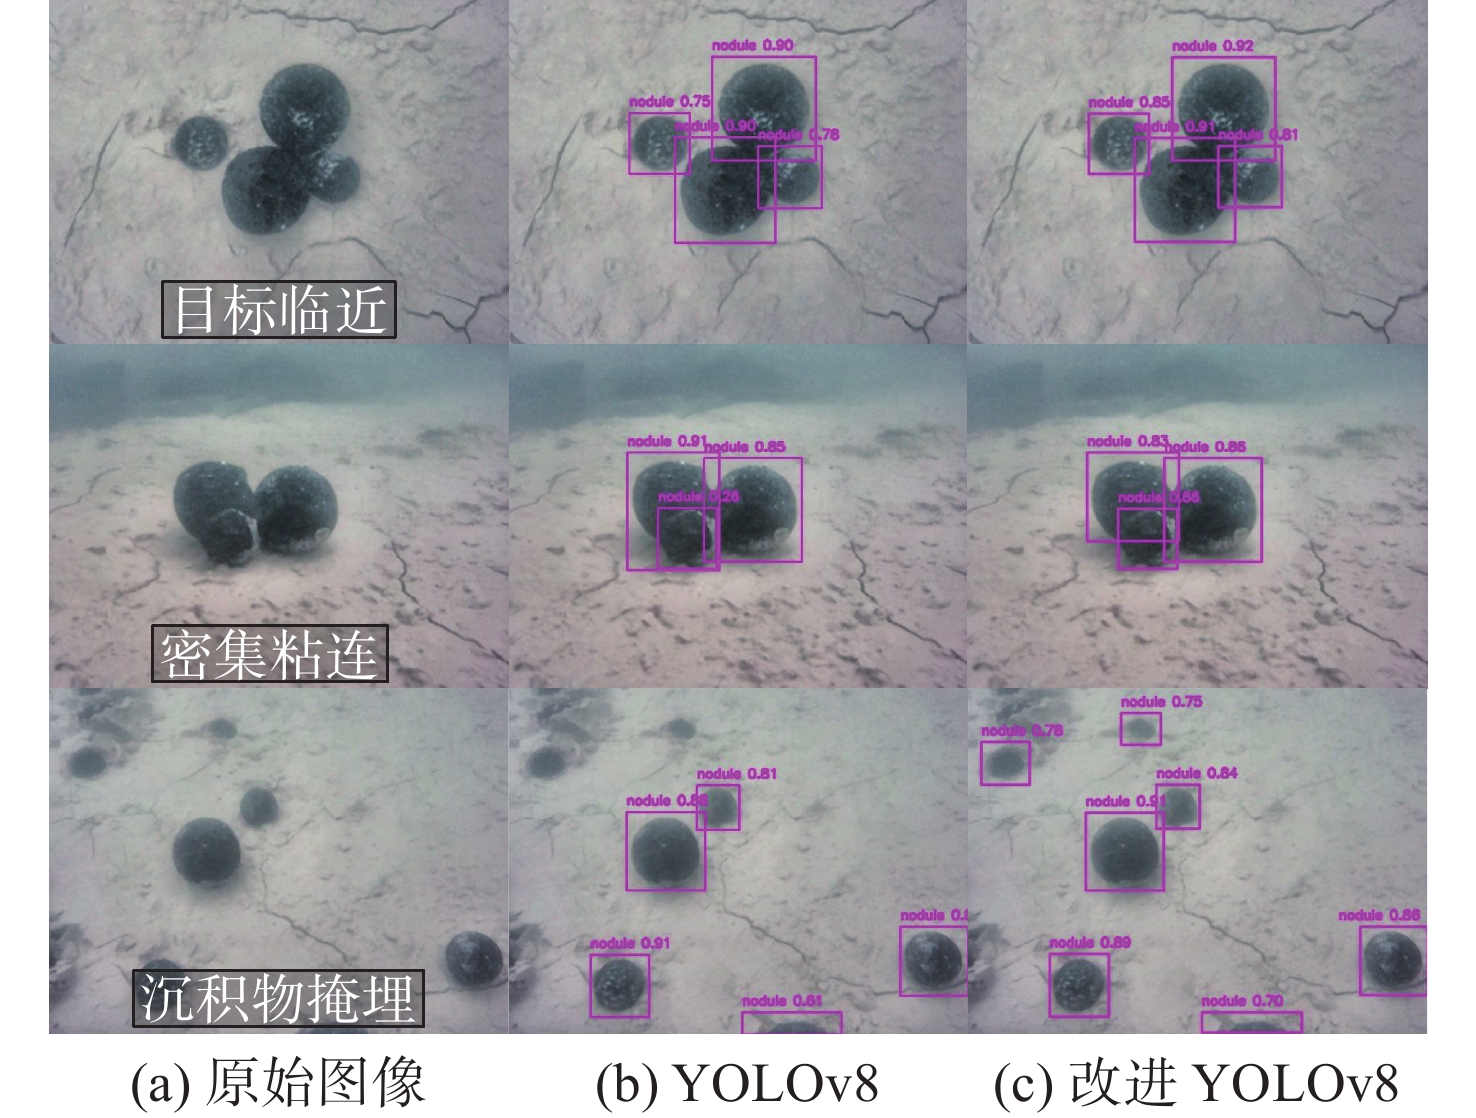
图 9 YOLOv8与改进YOLOv8的识别效果对比图
Figure 9. The recognition effect comparison diagram of YOLOv8 and improved YOLOv8
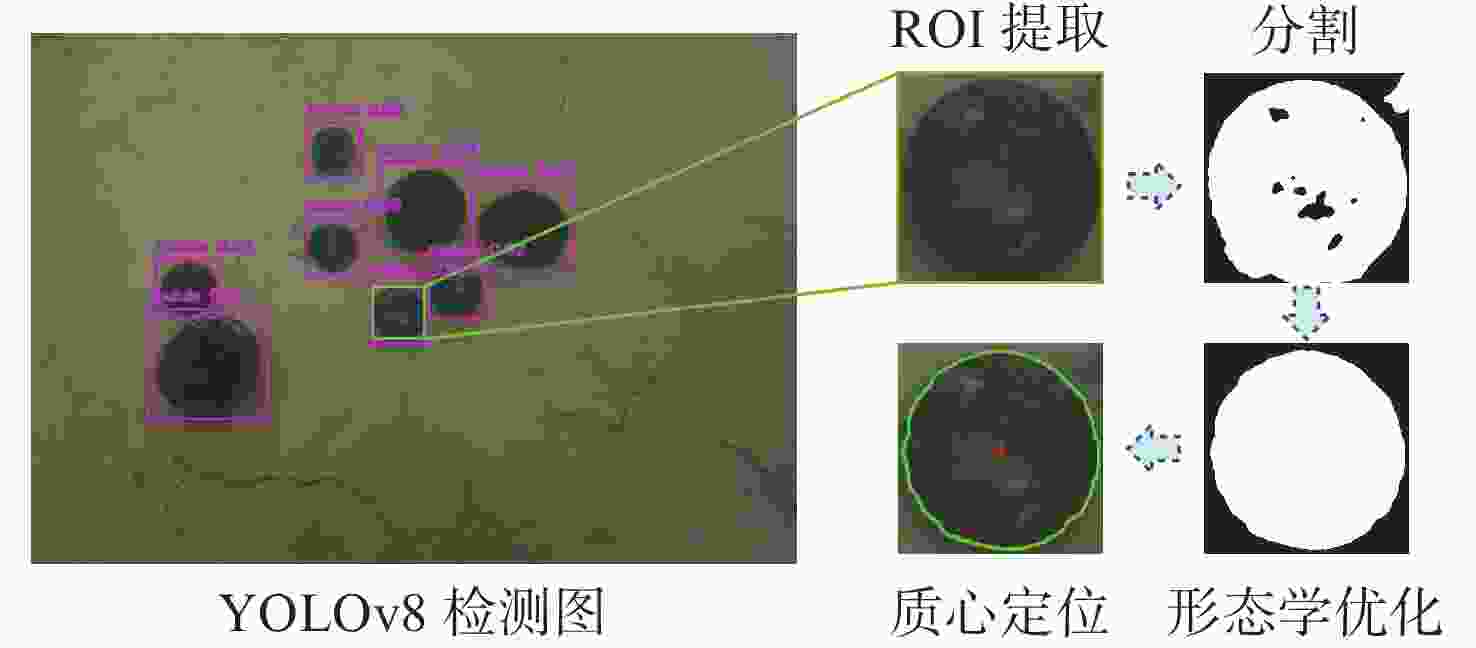
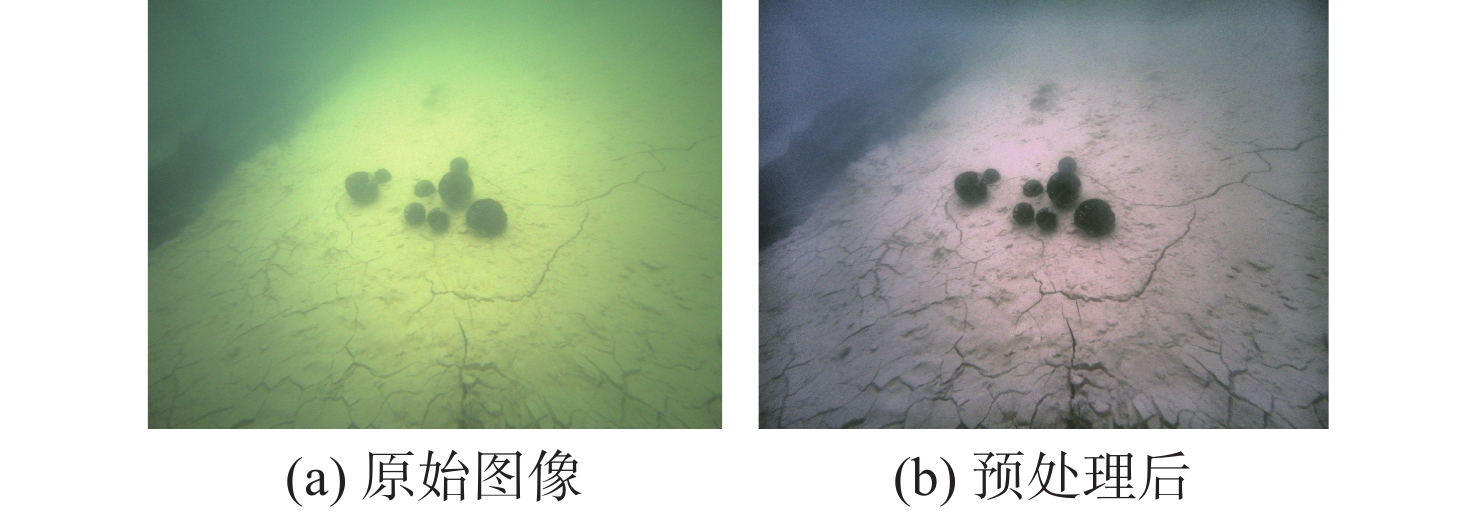
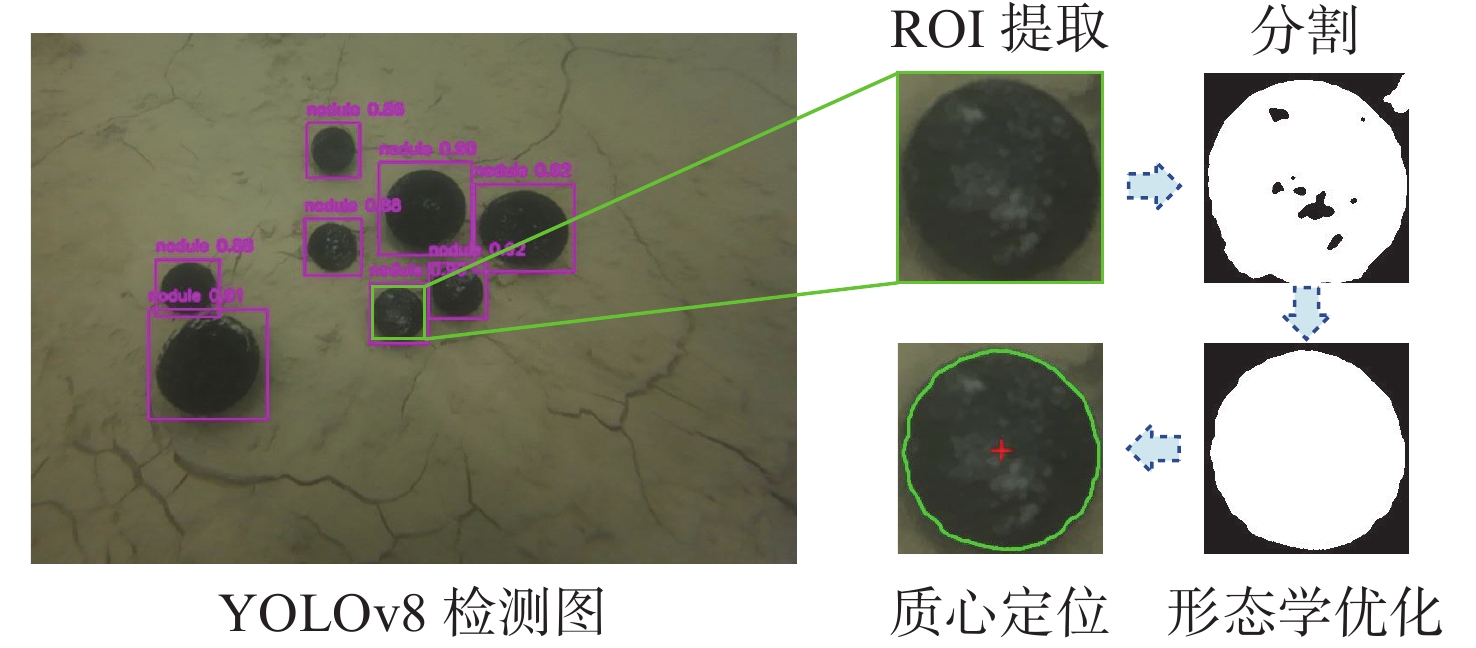
图 10 ROI提取、分割与质心定位流程效果图
Figure 10. Effect diagram of ROI extraction, segmentation and centroid localization process
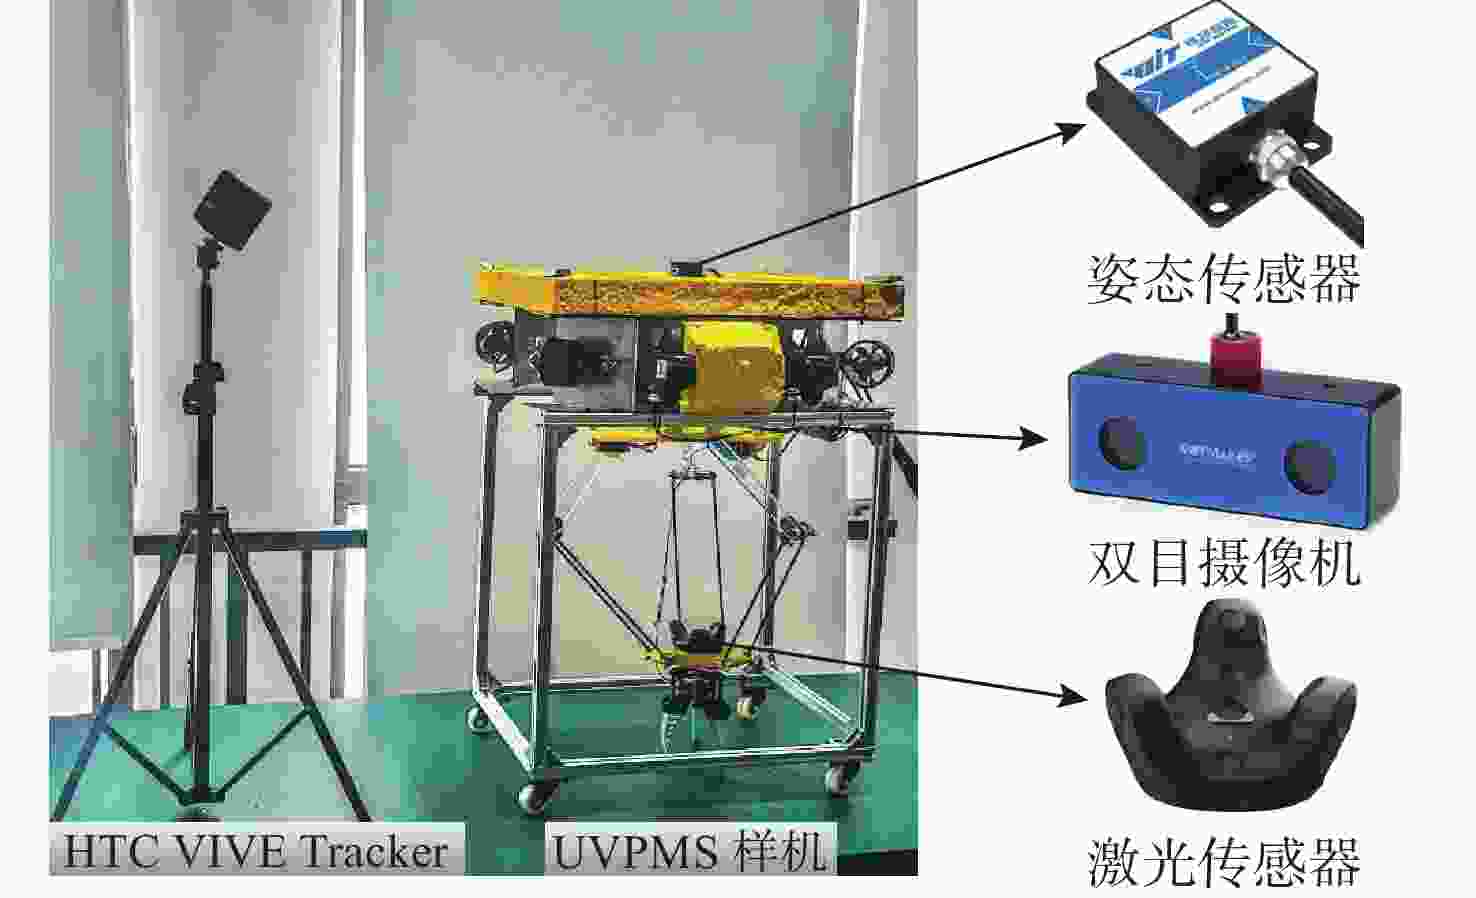
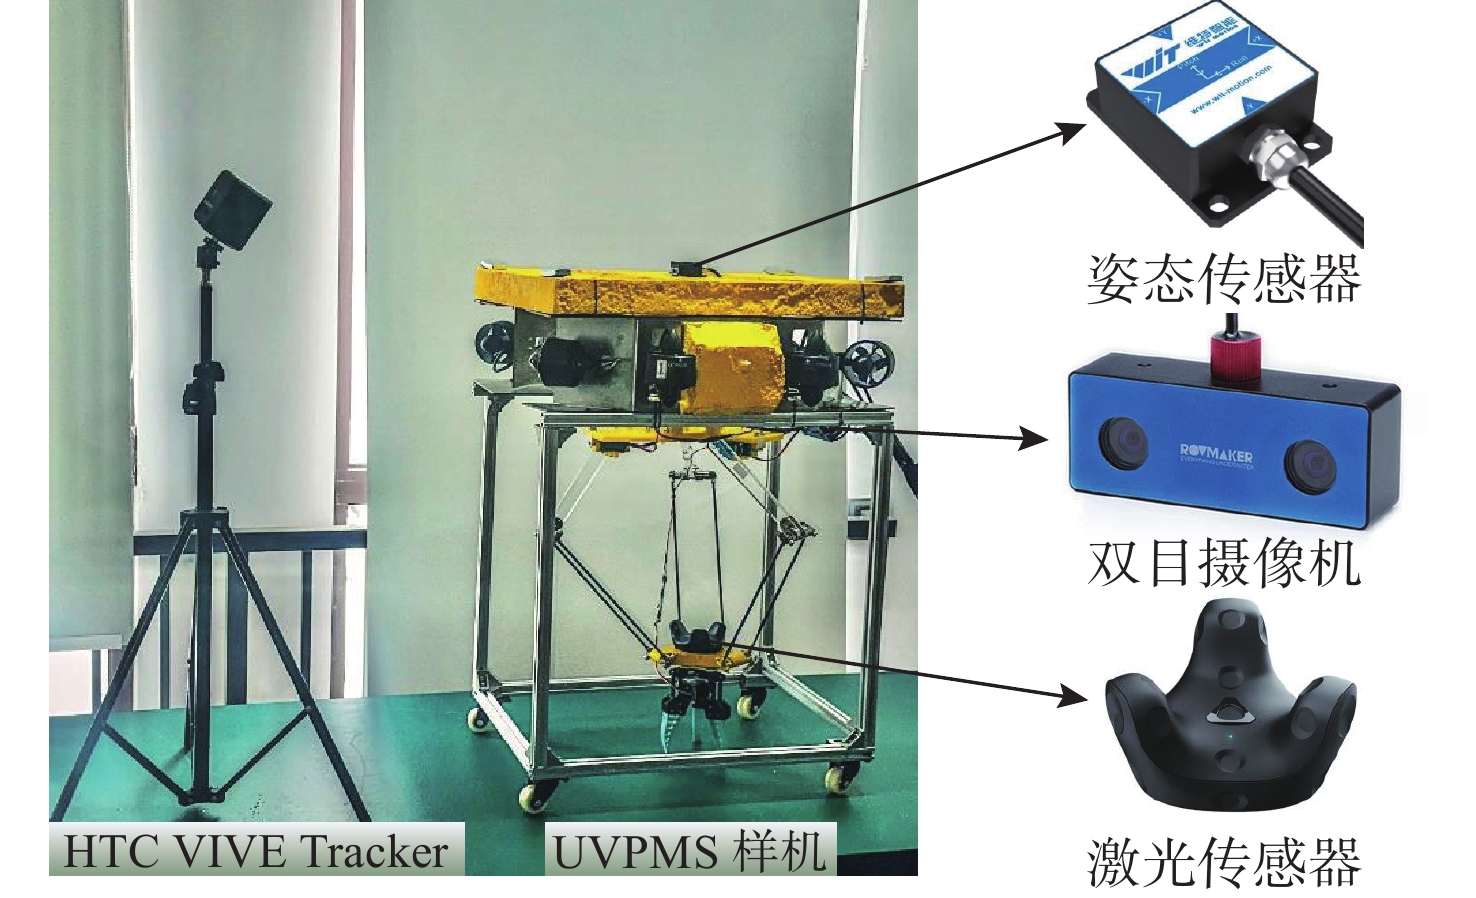
图 12 悬浮式UVPMS物理样机实物及传感器安装分布图
Figure 12. Suspended UVPMS physical prototype and sensor installation distribution map
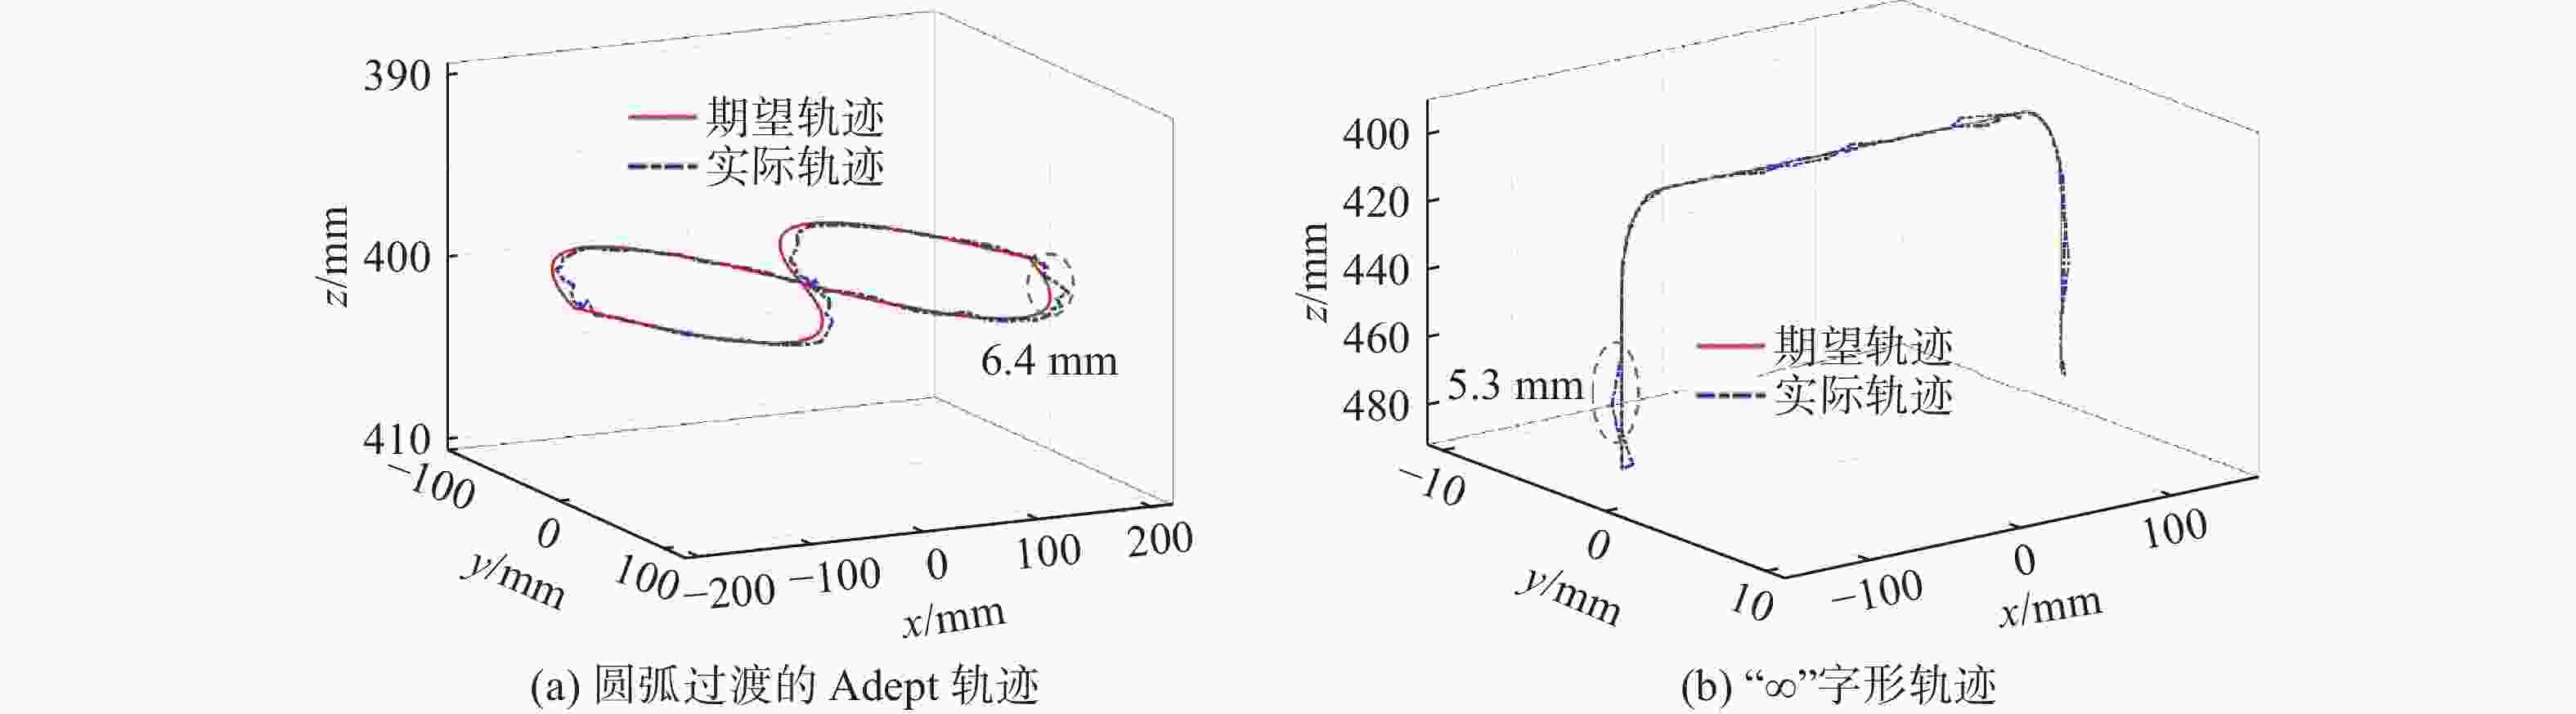
图 13 陆上环境机械手末端实际跟踪轨迹与期望轨迹对比图
Figure 13. Comparison of the actual tracking trajectory and the expected trajectory of the end of the land environment manipulator
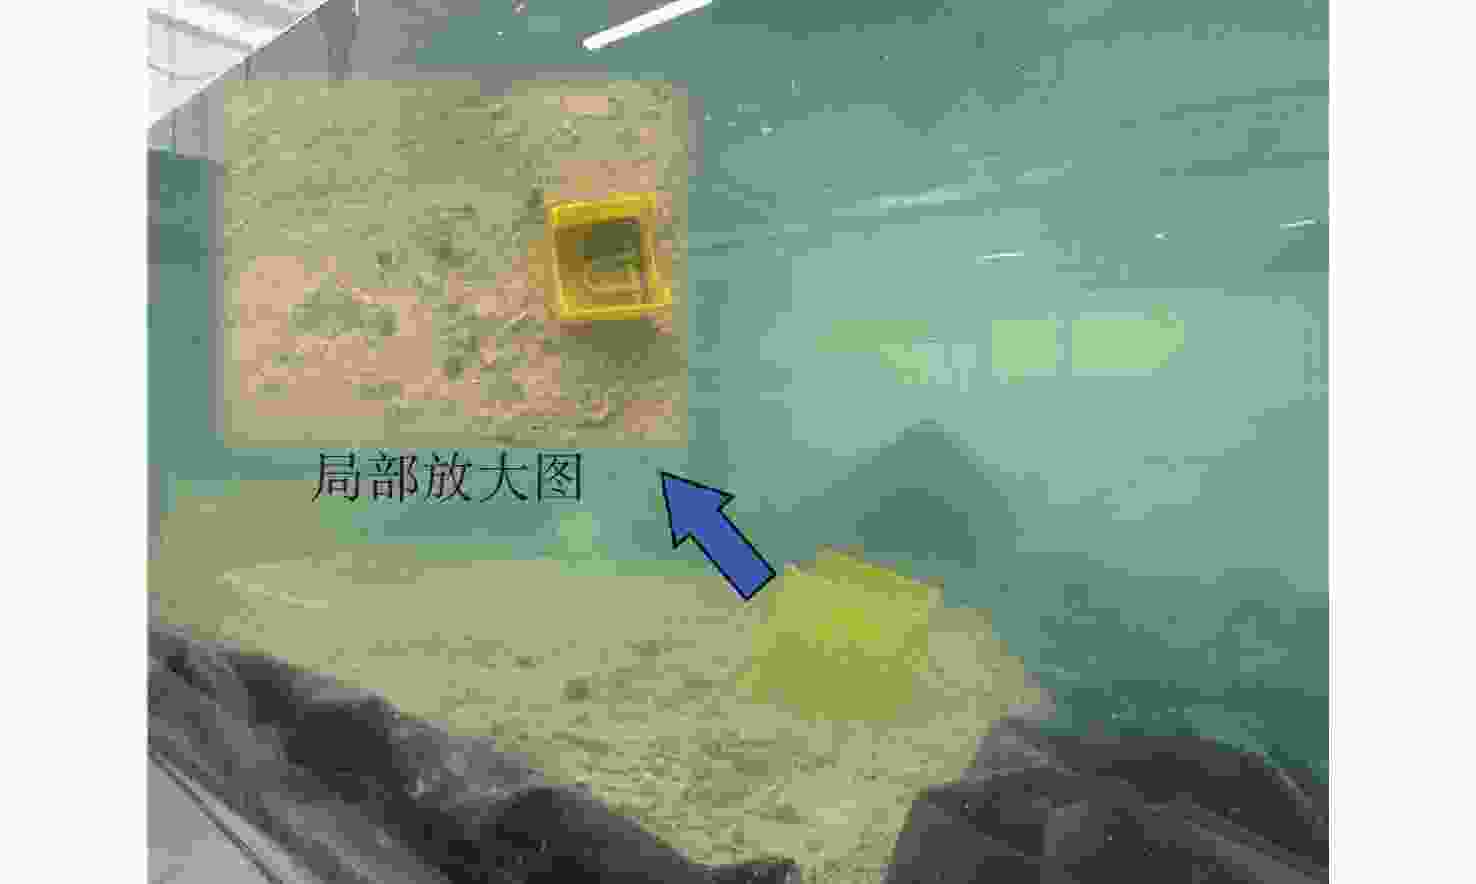
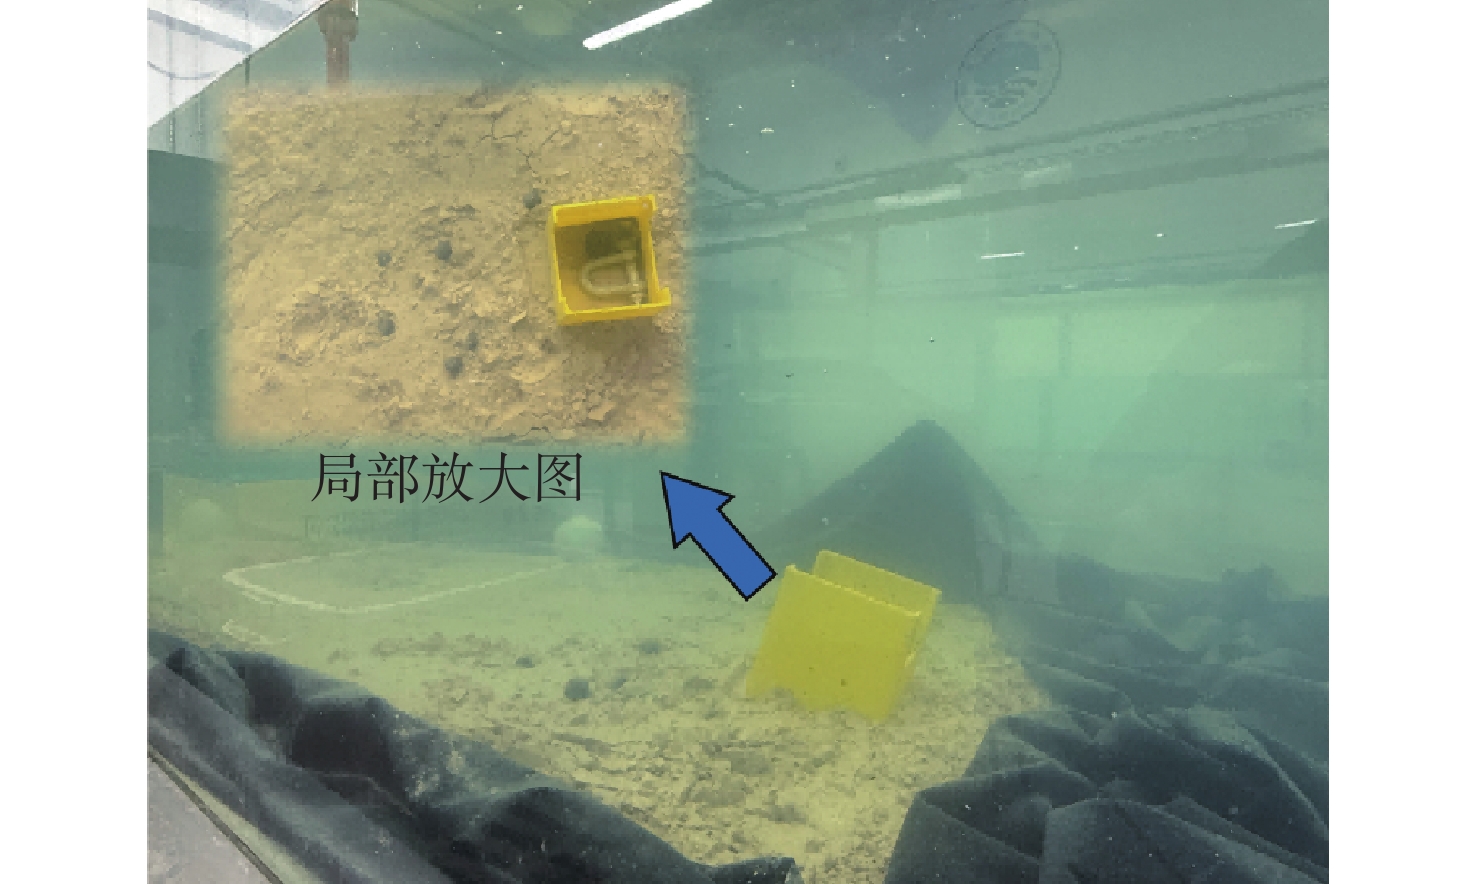
图 14 深海采矿作业模拟水池及复合底质环境
Figure 14. Deep-sea mining operation simulation pool and composite substrate environment
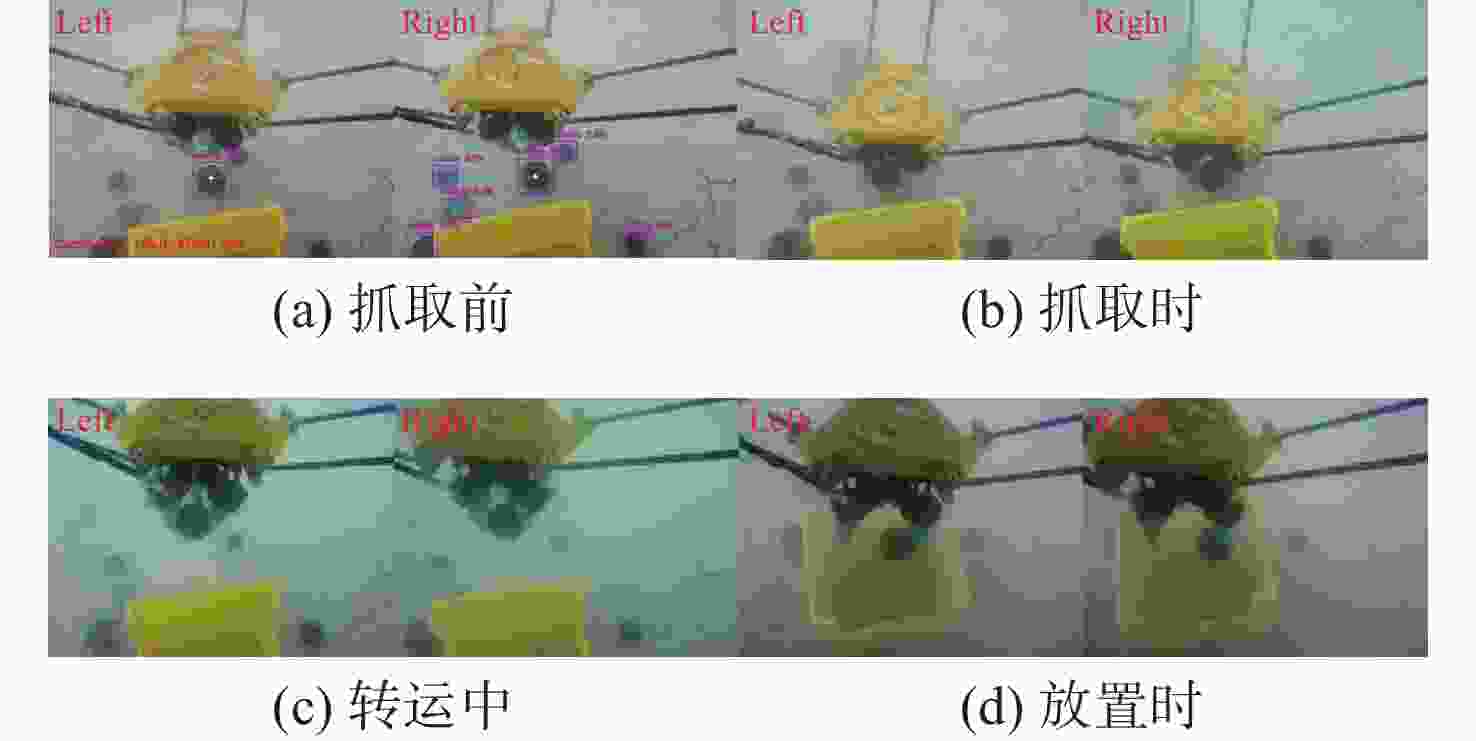
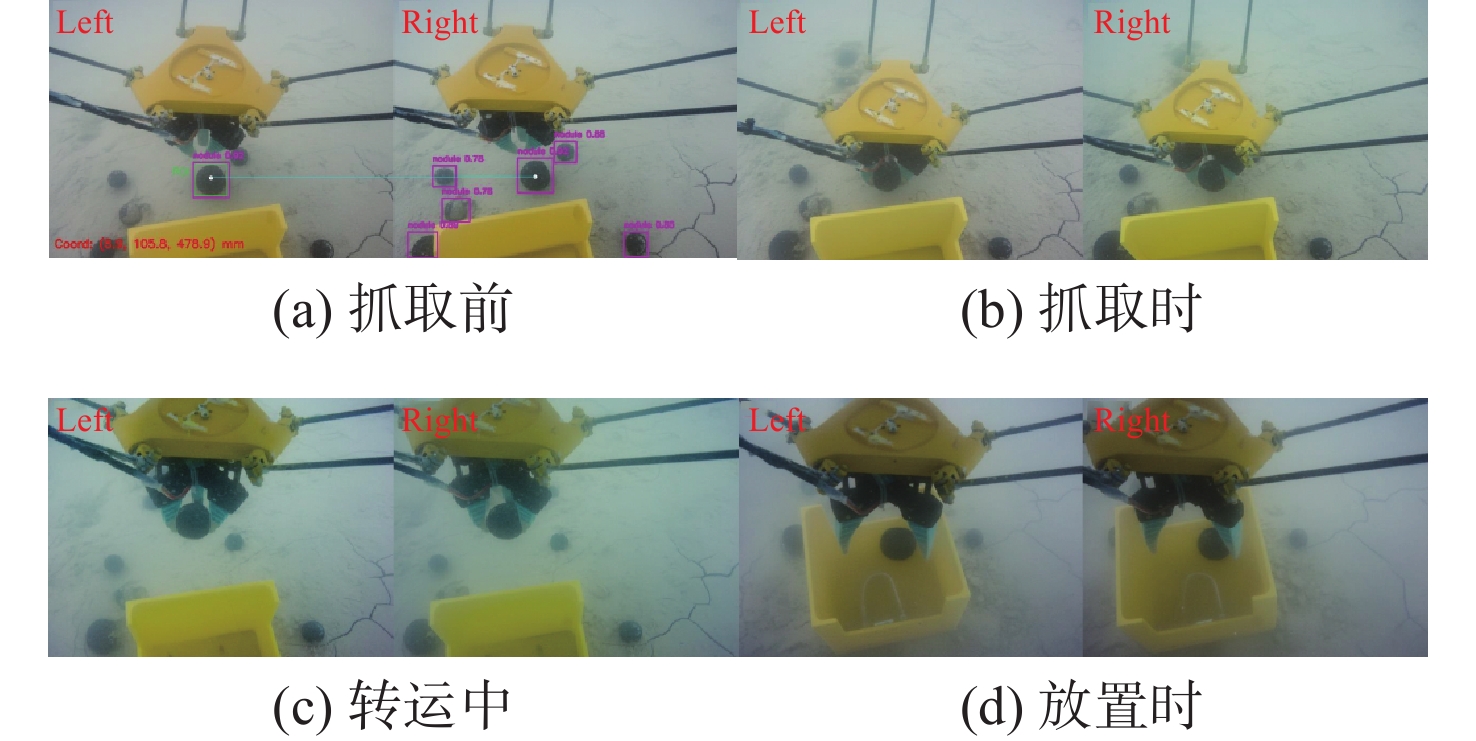
图 15 悬浮式UVPMS在水池环境下的抓取与放置作业流程
Figure 15. Grabbing and placing process of suspended UVPMS in pool environment
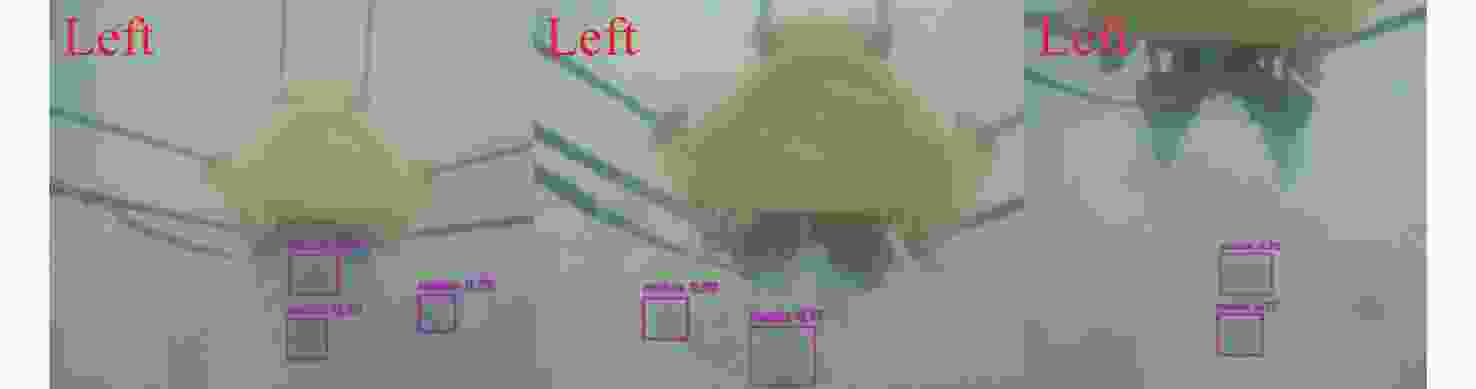
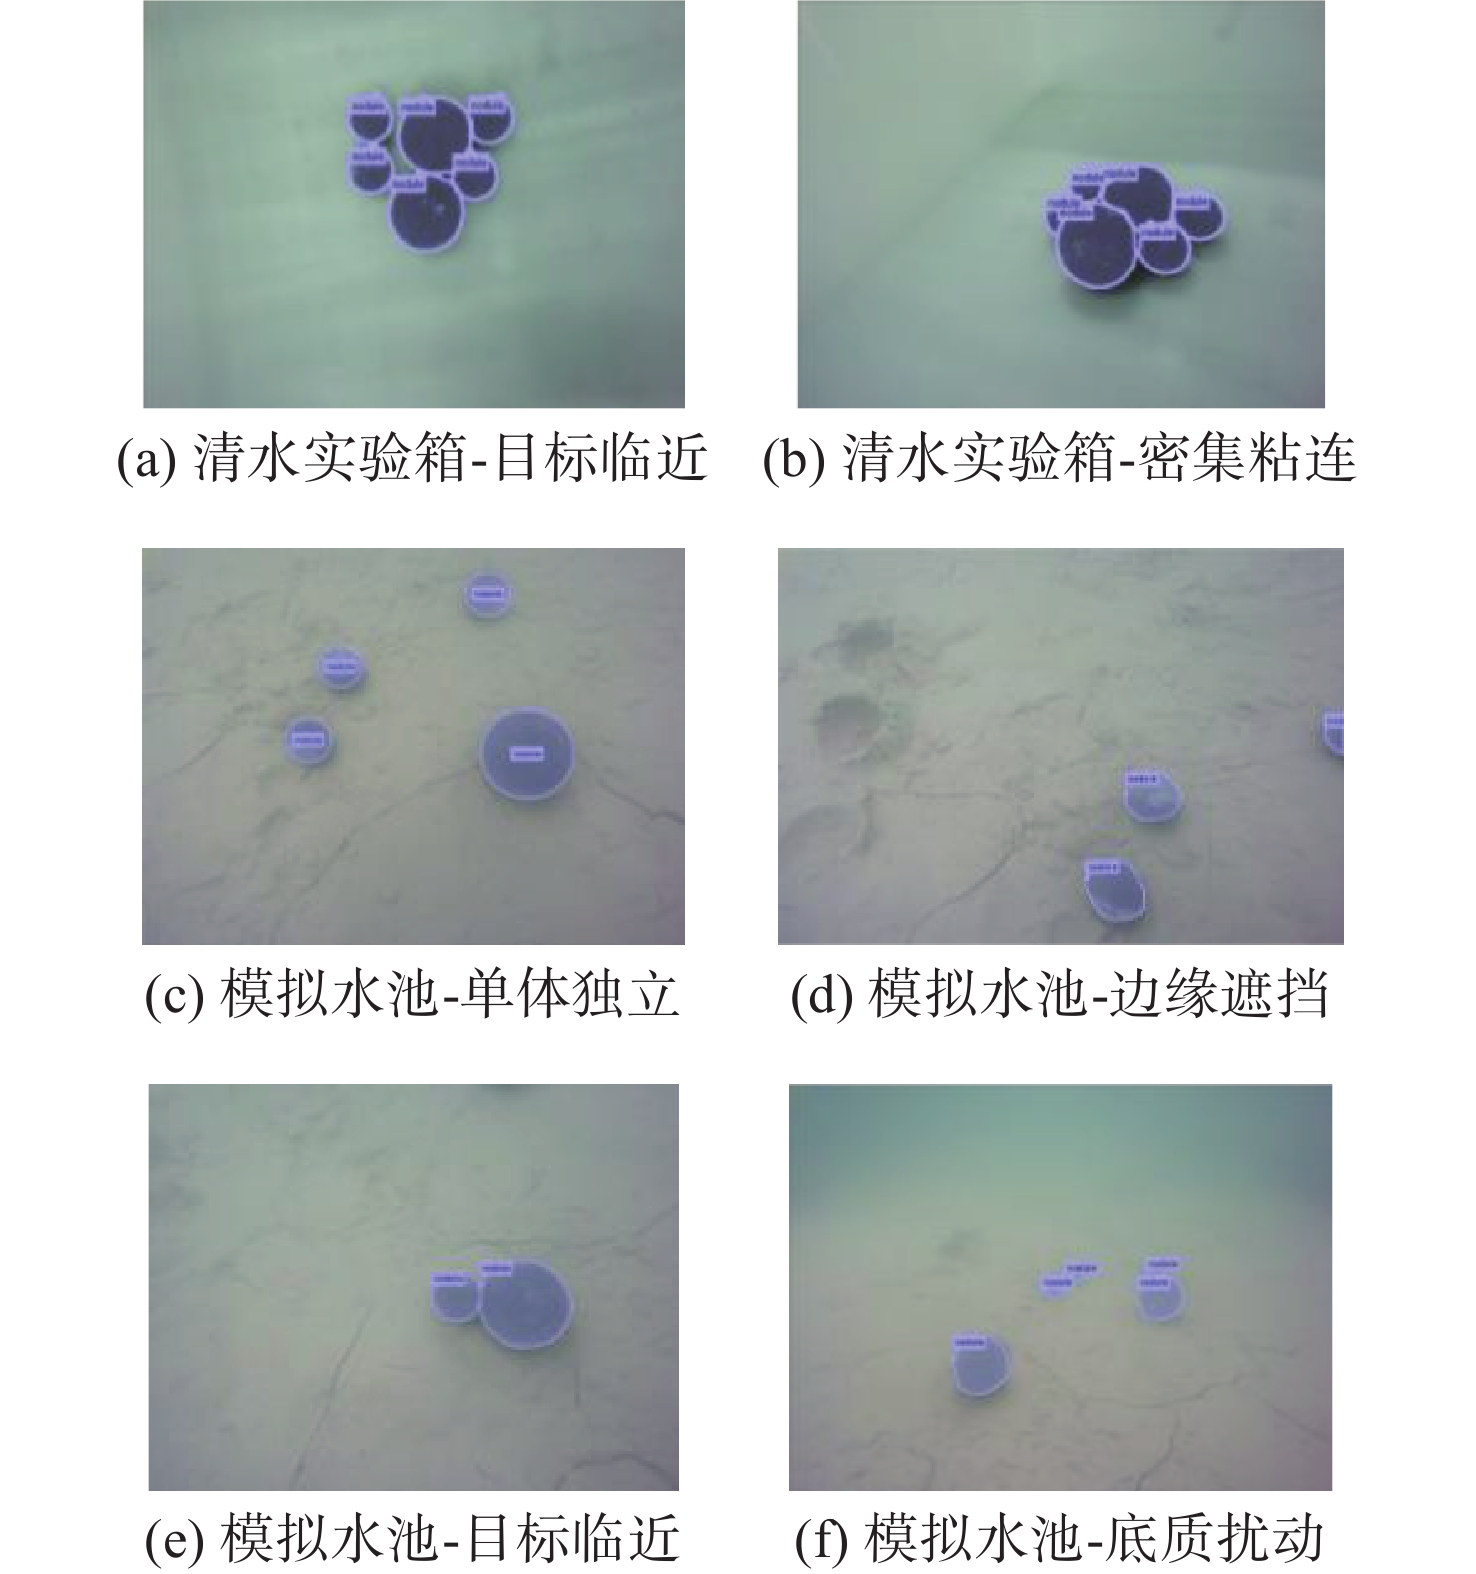
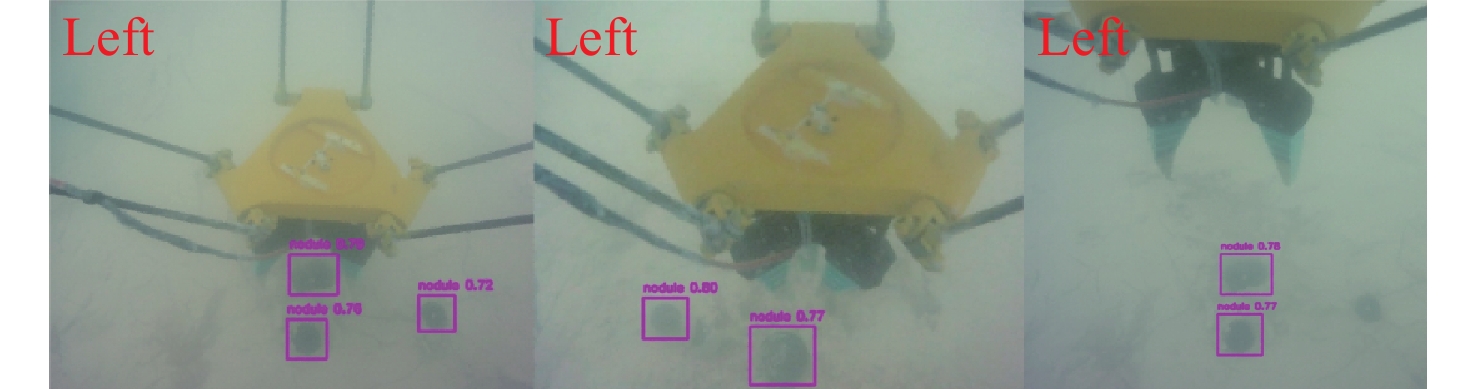
图 16 悬浮式UVPMS多次抓取后的识别效果
Figure 16. The recognition effect of suspended UVPMS after multiple grabs
表 1 系统主要设计参数
Table 1. Main design parameters of the system
参数 数值/说明 本体尺寸 800 mm × 600 mm × 300 mm 作业方式 悬浮式近底视觉辅助抓取 本体结构 顶部浮力模块, 中部耐压
密封舱, 下置作业机构推进器配置 8台水下推进器, 水平推进组
与垂直推进组组合布置视觉单元 水下双目相机, 前端俯视布置 作业对象 多金属结核模拟物, 粒径约
30~50 mm实验水池 5 m × 3 m × 1 m, 实验水深约0.85 m 底质模拟 400目钠质膨润土铺设
稀软沉积物环境 下载: 导出CSV
表 2 Delta并联机构关键参数
Table 2. Key parameters of Delta parallel mechanism
参数 数值 静平台半径$ R $/mm $ 125 $ 主动臂杆长$ {L}_{1} $/mm $ 180 $ 从动臂杆长$ {L}_{2} $/mm $ 300 $ 动平台半径$ r $/mm $ 70 $
下载: 导出CSV
表 3 悬浮式UVPMS核心部件动力学参数
Table 3. Dynamic parameters of core components of suspended UVPMS
部件 质量$ /\text{kg} $ 转动惯量$ /(\times {10}^{-3}\text{ kg}\cdot {\text{m}}^{2}) $ 绕X轴的
转动惯量绕Y轴的
转动惯量绕Z轴的
转动惯量水下机器人本体 63.5 2 399 3 842 5 294 静平台与舵机 1.5 4.581 0 4.581 0 8.583 0 动平台负载 1.0 5.824 0 3.865 0 4.708 0 主动臂 0.5 1.633 0 1.6330 0.085 0 从动臂 0.1 1.461 0 1.461 0 0.003 6
下载: 导出CSV
表 4 不同检测算法在多金属结核数据集上的性能对比
Table 4. Performance comparison of different detection algorithms on polymetallic nodule datasets
模型 精确
率/%召回
率/%mAP@0.5 mAP@
0.5:0.95CLE
/$ \text{pixel} $FPS YOLOv5n 88.4 85.1 89.2 65.8 5.20 136.1 YOLOv8n 92.1 89.5 92.8 71.5 4.15 141.8 YOLOv10n 91.5 90.2 93.1 72.8 3.95 109.6 改进YOLOv8 96.0 94.6 96.5 78.2 2.10 116.6
下载: 导出CSV
表 5 连续抓取失败案例统计与原因分析
Table 5. Statistics and cause analysis of continuous grasping failure cases
失败类型 具体表现 原因 失败
次数占失败样
本比例/%占全部样
本比例/%视觉识别/质心提取不稳定 检测框抖动、质心偏移、局部漏检 悬浮颗粒遮挡、图像浑浊、目标边缘模糊 7 38.9 12.7 目标被推移 夹持器下探后目标滚动或滑移 下探中心与目标中心存在横向偏差,
夹爪接触不对称6 33.3 10.9 夹持中心偏移 夹持器闭合但未有效包覆目标 视觉测量误差、手眼映射误差、本体微小
漂移及机械手执行误差累积5 27.8 9.1
下载: 导出CSV
-
[1] Calderon J L, Smith N M, Bazilian M D, et al. Critical mineral demand estimates for low-carbon technologies: What do they tell us and how can they evolve?[J]. Renewable and Sustainable Energy Reviews, 2024, 189: 113938. doi: 10.1016/j.rser.2023.113938 [2] Feichtner I, Ginzky H. The struggle at the International Seabed Authority over deep sea mineral resources[J]. NPJ Ocean Sustainability, 2024, 3(1): 63. doi: 10.1038/s44183-024-00098-y [3] Hein J R, Koschinsky A, Kuhn T. Deep-ocean polymetallic nodules as a resource for critical materials[J]. Nature Reviews Earth & Environment, 2020, 1(3): 158-169. doi: 10.1038/s43017-020-0027-0 [4] Wang C, Zhou S, Shu X, et al. Deep-sea mining: a potential solution to secure critical energy minerals availability[J]. npj Ocean Sustainability, 2025, 4(1): 59. doi: 10.1038/s44183-025-00162-1 [5] Xu Z, Liu Y, Yang G, et al. Research on contact model of track-soft sediment and traction performance of four-tracked seabed mining vehicle[J]. Ocean Engineering, 2022, 259: 111902. doi: 10.1016/j.oceaneng.2022.111902 [6] Konoplin A, Krasavin N, Yurmanov A, et al. Development of a control system for underwater vehicles with multilink manipulators performing contact manipulation operations[J]. Journal of Marine Science and Engineering, 2024, 12(7): 1126. doi: 10.3390/jmse12071126 [7] Chang Z, Zhang Y, Zheng Z, et al. Dynamics simulation of grasping process of underwater vehicle-manipulator system[J]. Journal of Marine Science and Engineering, 2021, 9(10): 1131. doi: 10.3390/jmse9101131 [8] Simoni R, Rodríguez P R, Cieślak P, et al. Design and kinematic analysis of a 6-DOF foldable/deployable Delta parallel manipulator with spherical wrist for an I-AUV[C]//Oceans 2019-Marseille, 2019: 1-10. [9] 蒋绍博, 吴玉玮, 丁海旭, 等. 水下捕捞机械手结构设计与研究[J]. 机械研究与应用, 2020, 33(1): 116-120. doi: 10.16576/j.cnki.1007-4414.2020.01.032 [10] Yang M, Xiao L, Chen C, et al. Fast visual servo for rapidly seafood capturing of underwater delta robots[C]//2023 IEEE International Conference on Robotics and Biomimetics (ROBIO), 2023: 1-6. [11] Scholberg I. Modelling and Control of Underwater Vehicle-Mamipulator System[C]//Proceedings of the 3rd Conference on Marine Craft Maneuvering and Control (MCMC'94), 1994: 45-57. [12] Tarn T J, Shoults G A, Yang S P. A dynamic model of an underwater vehicle with a robotic manipulator using Kane’s method[J]. Autonomous Robots, 1996, 3(2): 269-283. doi: 10.1007/bf00141159 [13] McLain T W, Rock S M. Development and experimental validation of an underwater manipulator hydrodynamic model[J]. The International Journal of Robotics Research, 1998, 17(7): 748-759. doi: 10.1177/027836499801700705 [14] Shang D, Li X, Yin M, et al. Dynamic modeling and rotation control for flexible single-link underwater manipulator considering flowing water environment based on modified morison equation[J]. Ocean Engineering, 2024, 291: 116427. doi: 10.1016/j.oceaneng.2023.116427 [15] Jaffe J S. Computer modeling and the design of optimal underwater imaging systems[J]. IEEE journal of oceanic engineering, 2002, 15(2): 101-111. doi: 10.1109/48.50695 [16] 喻俊志, 孔诗涵, 孟岩. 水下视觉环境感知方法与技术[J]. 机器人, 2022, 44(2): 224-235. doi: 10.13973/j.cnki.robot.210323Yu J Z, Kong S H, Meng Y. Methods and technologies for visual perception of underwater environment[J]. Robot, 2022, 44(2): 224-235. doi: 10.13973/j.cnki.robot.210323 [17] Zhang F, Cao W, Gao J, et al. Underwater object detection algorithm based on an improved YOLOv8[J]. Journal of Marine Science and Engineering, 2024, 12(11): 1991. doi: 10.3390/jmse12111991 [18] Jian M, Yang N, Tao C, et al. Underwater object detection and datasets: a survey[J]. Intelligent Marine Technology and Systems, 2024, 2(1): 9. doi: 10.1007/s44295-024-00023-6 [19] Hutchinson S, Hager G D, Corke P I. A tutorial on visual servo control[J]. IEEE Transactions on Robotics and Automation, 2002, 12(5): 651-670. [20] Huang H, Bian X, Cai F, et al. A review on visual servoing for underwater vehicle manipulation systems automatic control and case study[J]. Ocean Engineering, 2022, 260: 112065. doi: 10.1016/j.oceaneng.2022.112065 [21] Gao J, Liang X, Chen Y, et al. Hierarchical image-based visual serving of underwater vehicle manipulator systems based on model predictive control and active disturbance rejection control[J]. Ocean Engineering, 2021, 229: 108814. doi: 10.1016/j.oceaneng.2021.108814 -

 下载:


 点击查看大图
计量
- 文章访问数: 4
- HTML全文浏览量: 0
- PDF下载量: 0
- 被引次数: 0