

Research Progress And Development Trend Of Underwater Positioning Technology For Underwater Robots
-
摘要: 水下定位是水下机器人实现自主作业的核心支撑技术, 受海水电磁屏蔽、声波传播干扰与极端环境约束, 其难度远高于陆地与空中定位。文中系统梳理了水下定位技术从单一声学定位、多源融合定位到智能化集群化定位的演进历程, 分类阐述了声学基线、多普勒测速、惯性导航、地球物理场辅助及视觉光学辅助等基础定位技术的原理、性能与工程适配性, 并分析了多源组合定位与分布式集群定位的技术架构与应用场景, 总结了人工智能、量子传感等前沿技术的研究进展; 在此基础上, 从核心器件、长航时精度、环境鲁棒性及工程化体系维度剖析了当前技术面临的核心挑战, 同时量化对比了国内外技术差距; 最后前瞻性预判了未来四大发展趋势。文中构建了完整的水下定位技术体系框架, 明确了各类技术的性能边界与适配场景, 可为我国水下定位技术的自主创新与工程应用提供理论参考。Abstract: With the further implementation of China’s strategy of building a maritime power, the large-scale application of deep-sea equipment such as underwater robots has placed an urgent demand on underwater positioning technology with high precision, high reliability and long endurance. Constrained by physical factors including electromagnetic shielding in seawater, acoustic propagation interference and extreme environments, the international high-end market remains monopolized by foreign enterprises. Although China has achieved a leap from following to keeping pace with global advanced technologies, it still faces bottlenecks such as low localization rate of core components. Focusing on underwater robot positioning, this paper systematically reviews the three-stage evolution of underwater positioning technology, classifies and expounds the principles, performance and engineering applications of various positioning technologies, analyzes core challenges and predicts four major development trends, so as to provide theoretical references for the independent innovation and engineering application of China’s underwater positioning technology.
-
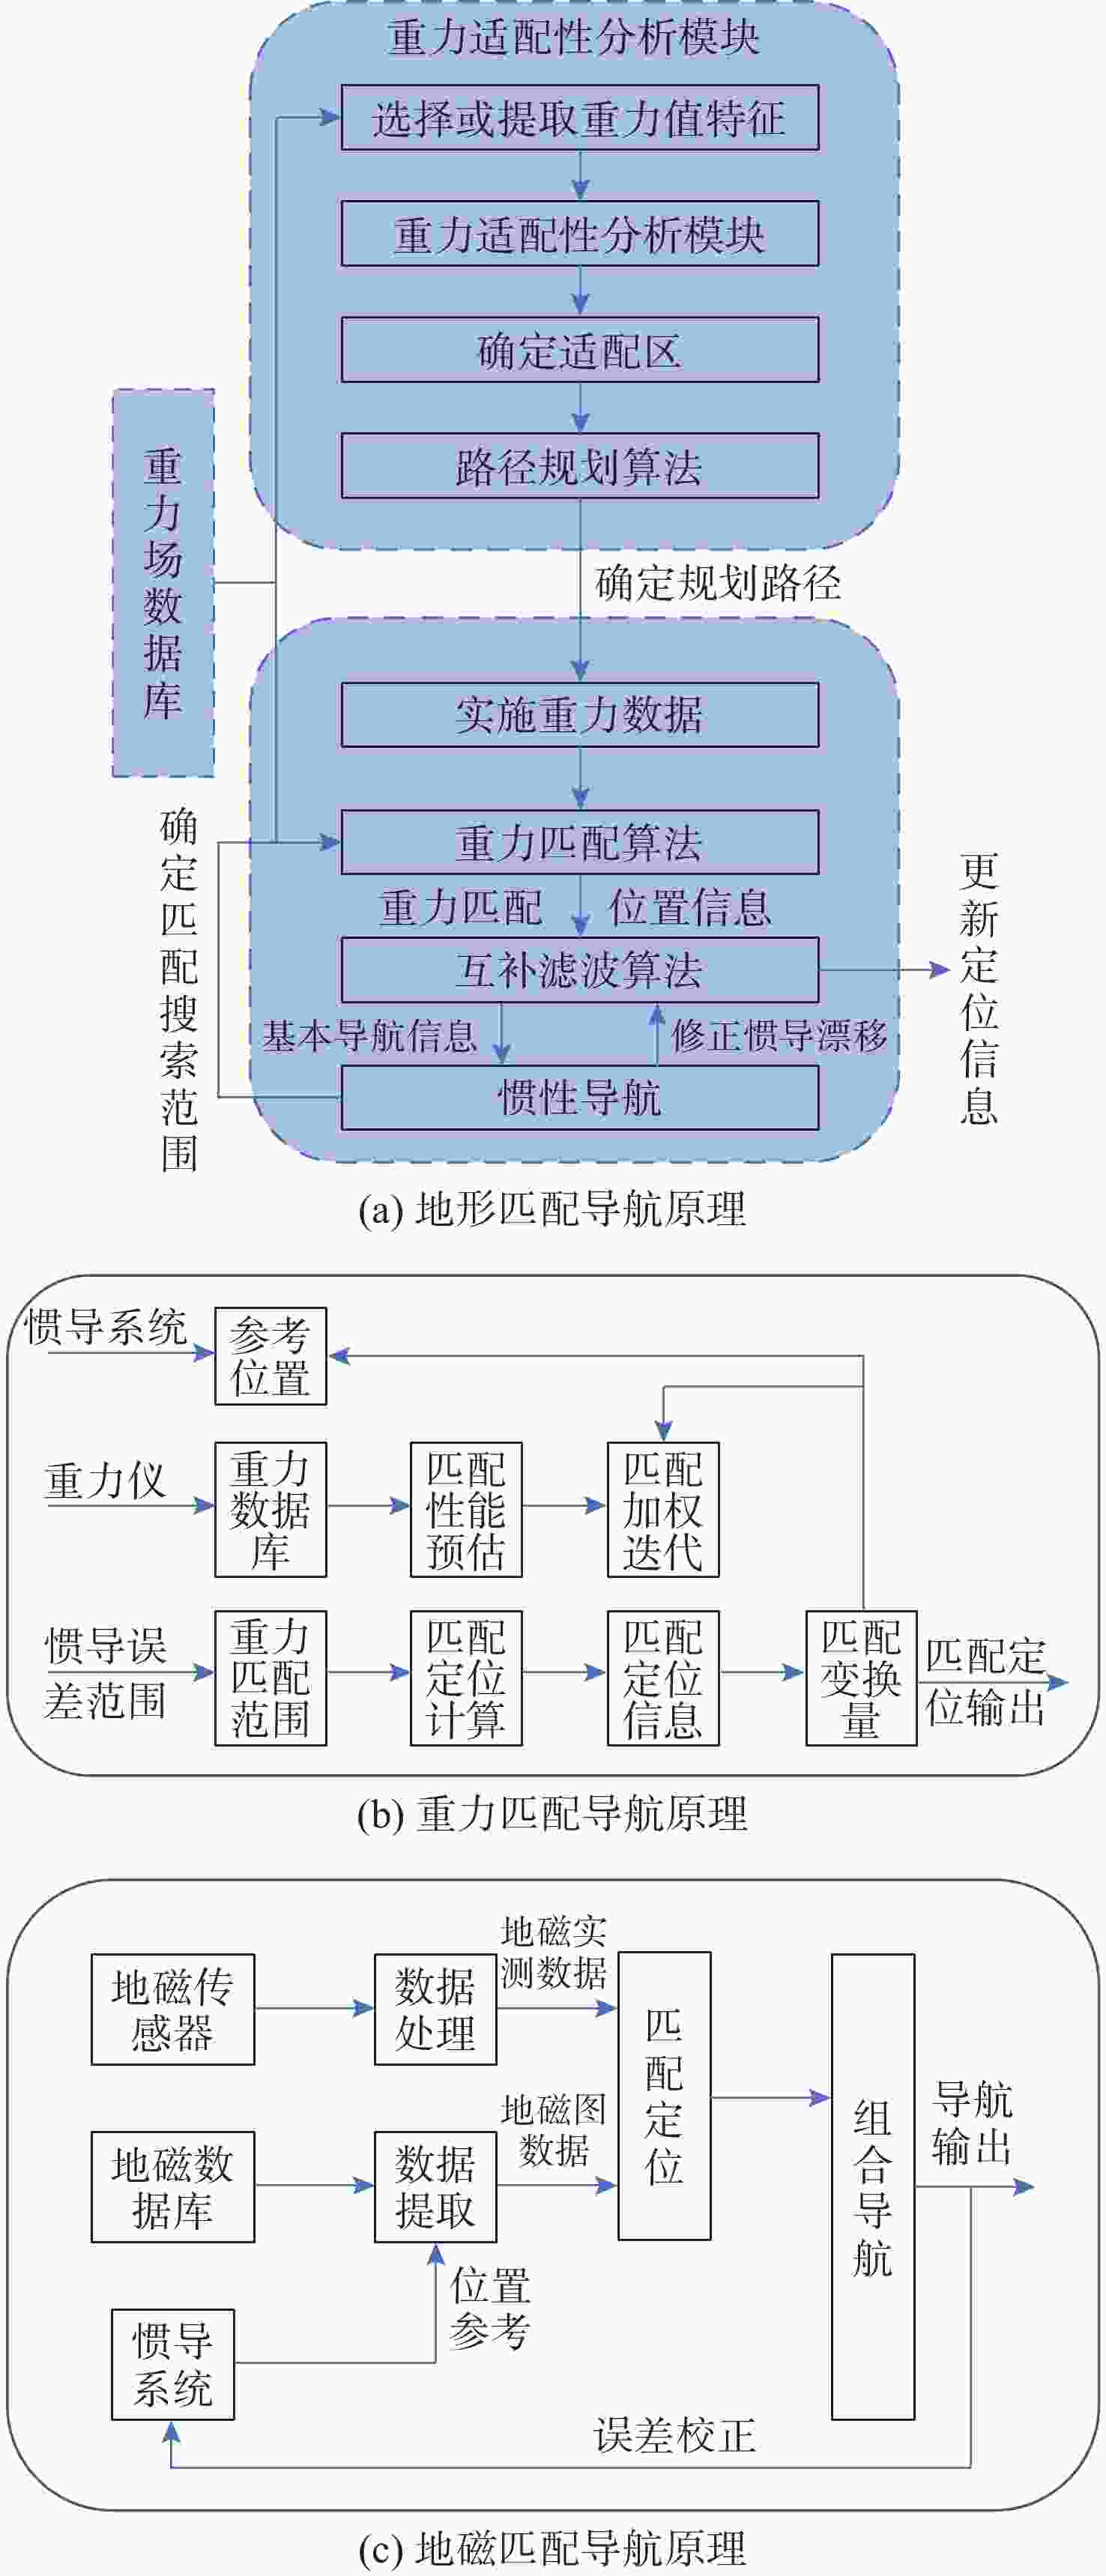
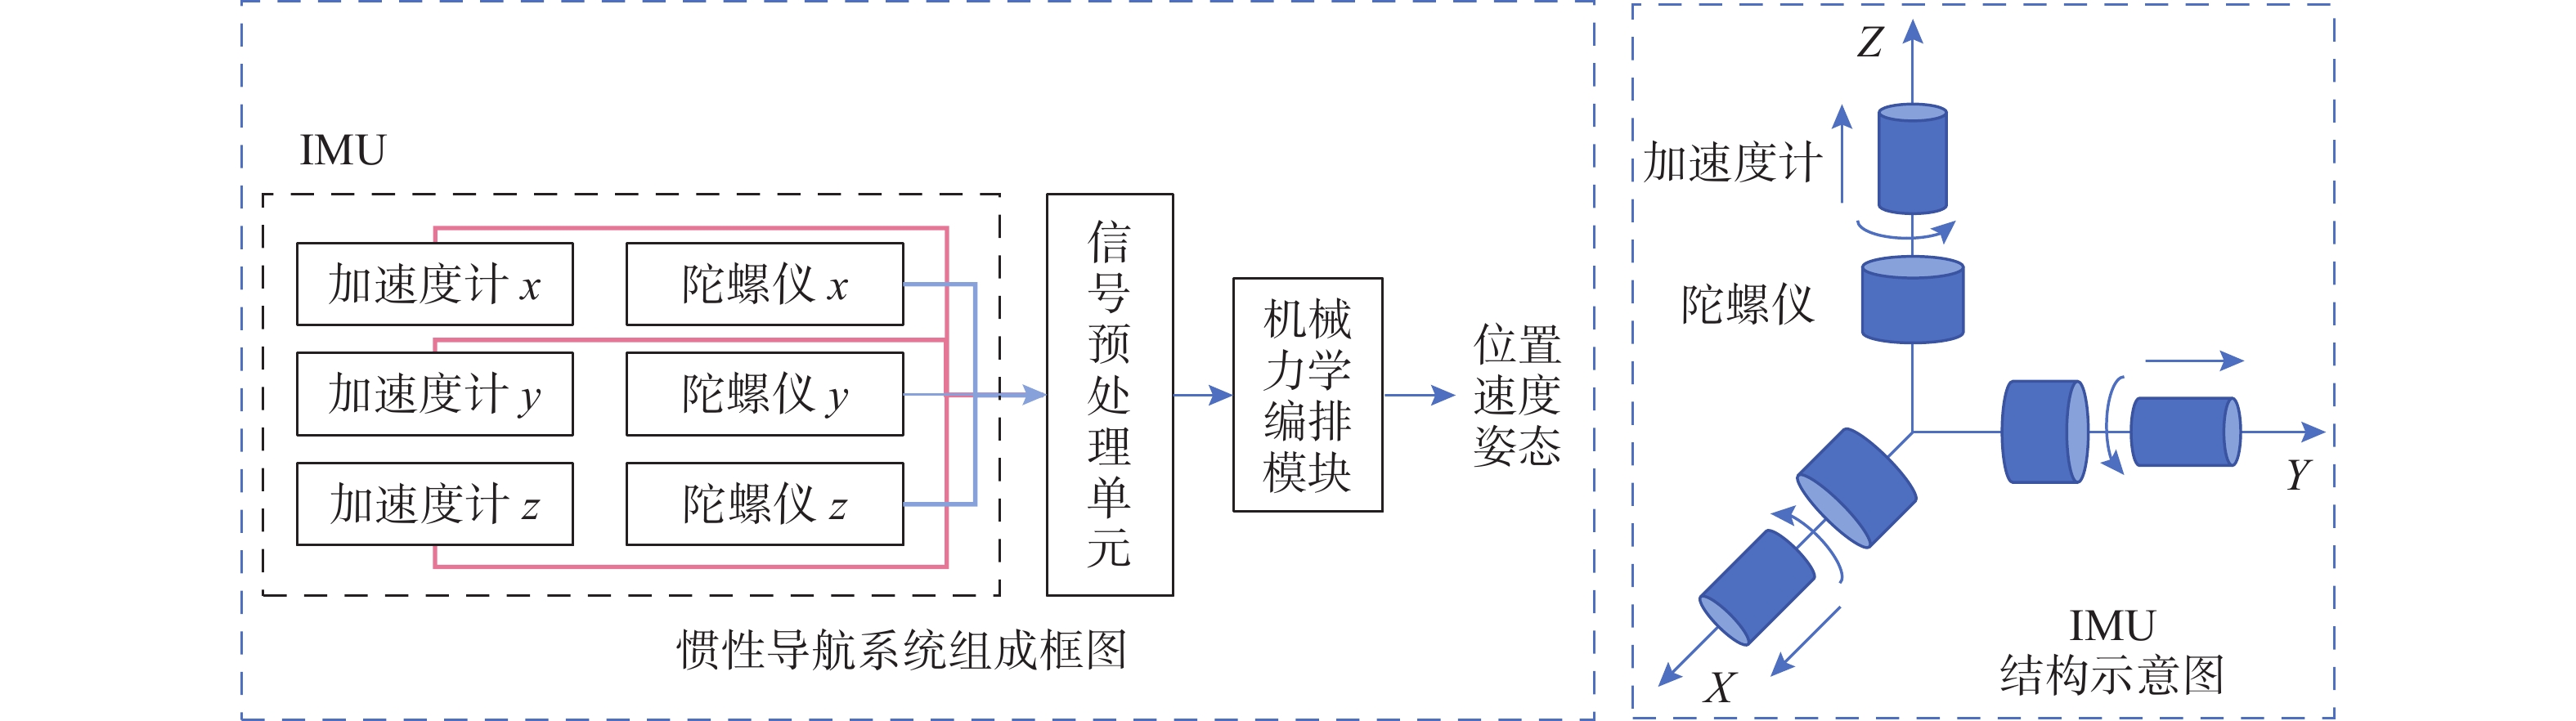
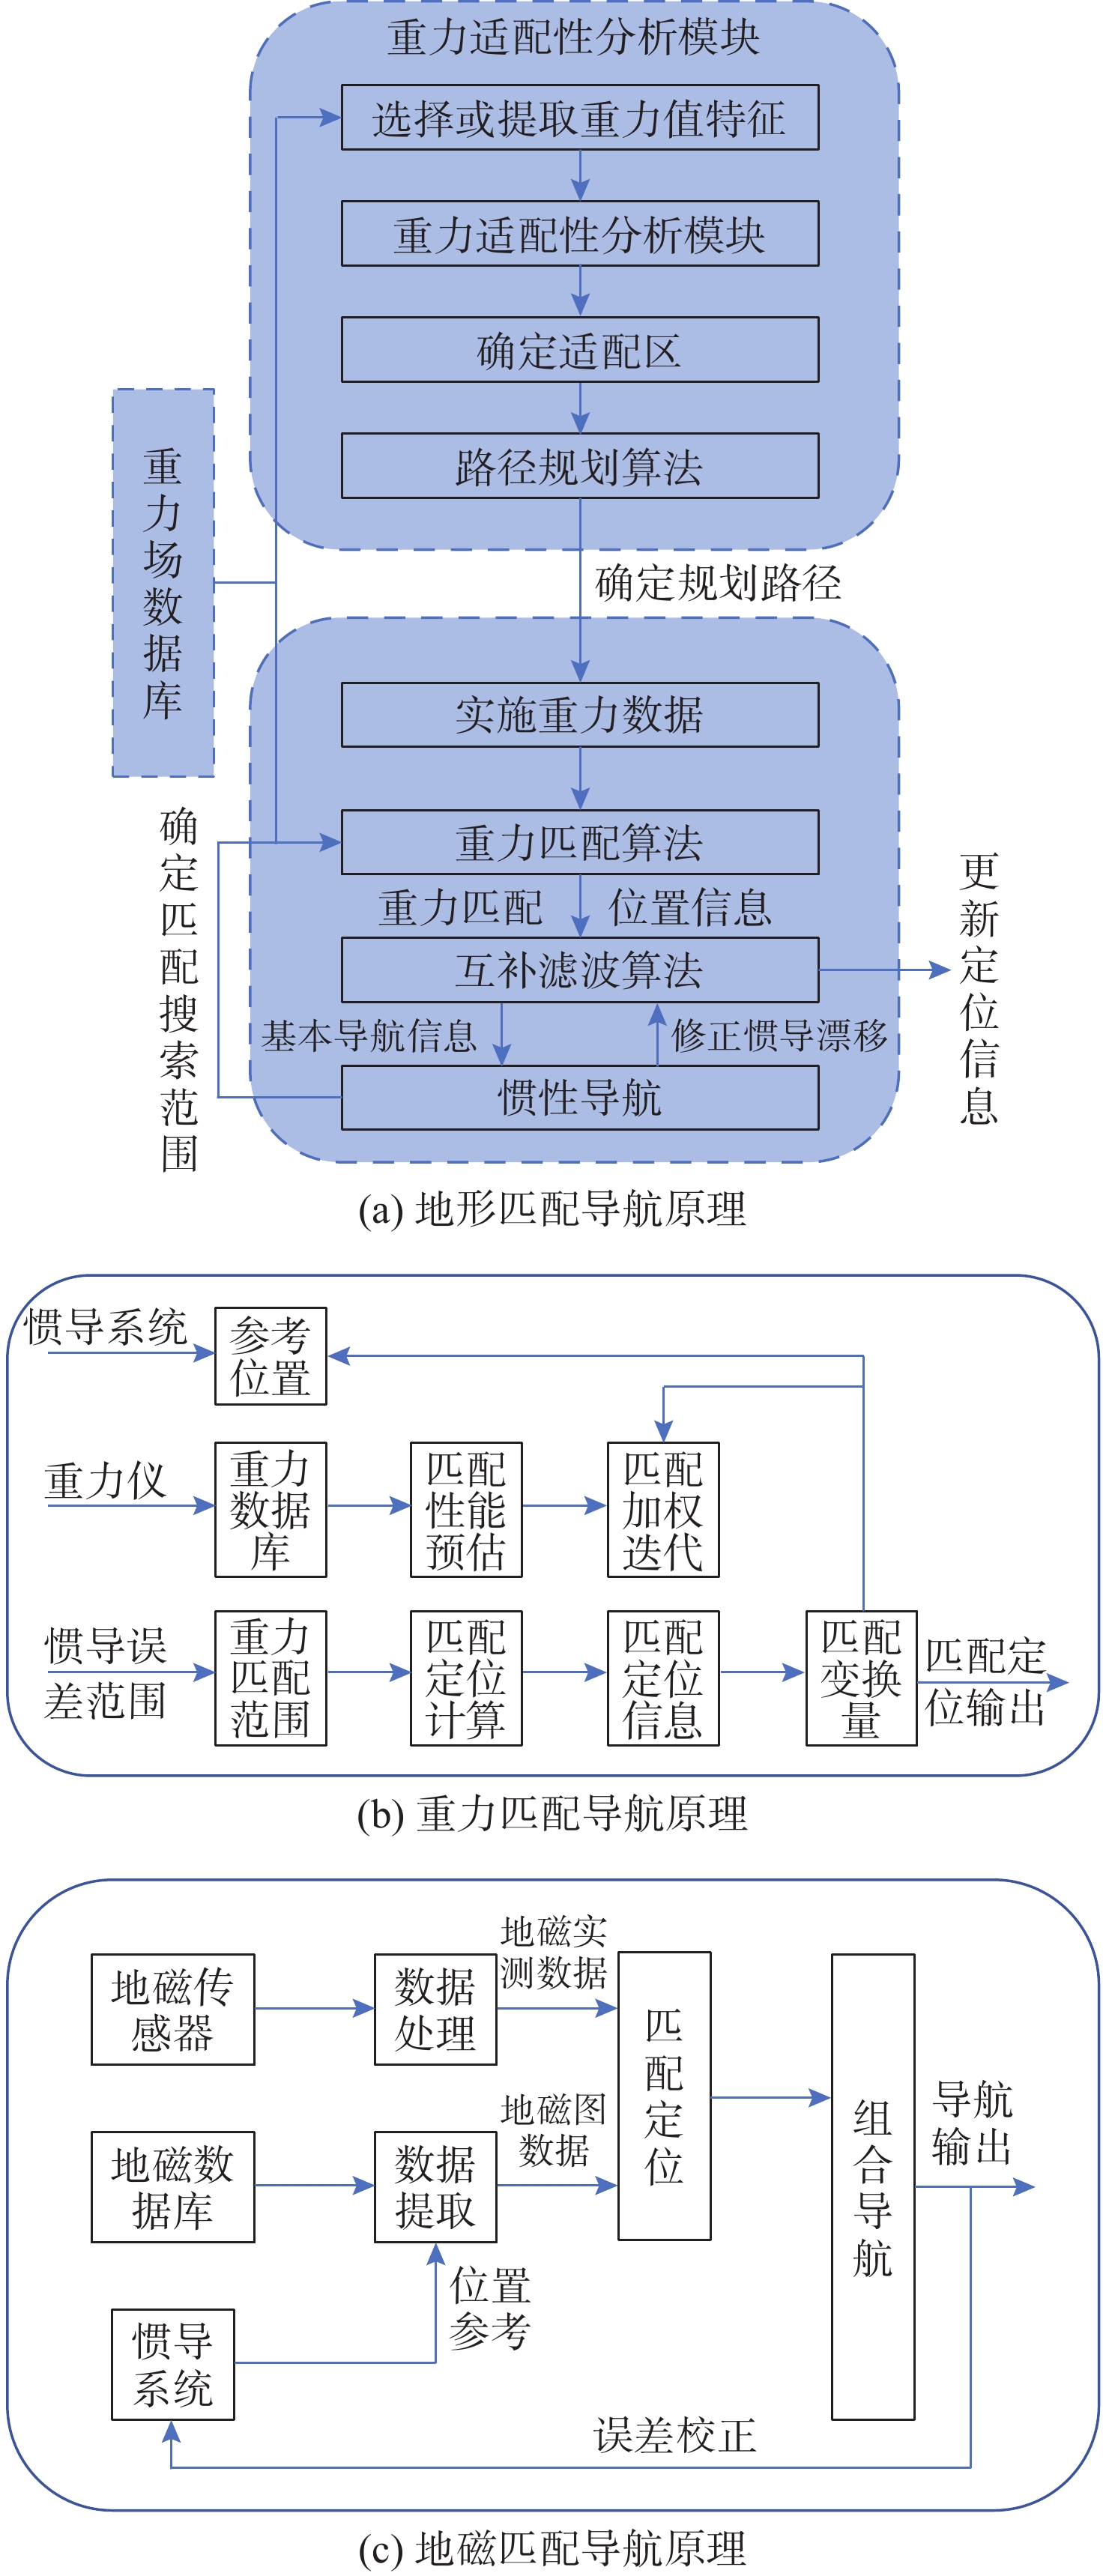
图 5 地球物理场辅助定位技术原理示意图
Figure 5. Schematic of the principle of geophysical field aided positioning technology
表 1 各类水下定位技术性能对比表
Table 1. Performance comparison of various underwater positioning technologies
技术类型 定位精度 作用范围 核心优势 主要局限 基础定位技术 LBL定位 厘米级 百米~千米 精度最高、作用范围广、不依赖母船、
支持多目标定位信标部署回收复杂、前期校准耗时 SBL定位 分米~米级 十米~百米 系统结构简单、部署灵活、成本较低 精度随水深下降 USBL定位 分米级 米~千米 体积小重量轻、集成度高、实时性好 精度低于LBL、受影响大 DVL 测速精度0.1% 0~200米 测速精度高、更新快、提供三维
速度姿态信息平坦地形/浑浊海域易失效 单信标定位 分米~米级 百米~千米 系统极简、部署成本低 受水声信道干扰和姿态误差影响大 SINS 误差随时间累积 无限制(自主) 完全自主、无信号暴露、不受环境干扰 误差随时间累积 地形匹配导航 米级 无限制(依赖地形特征) 自主性强、精度较高、技术相对成熟 不适用于平坦地形、声呐探测
精度随水深下降重力匹配导航 几百米~千米级 全海域 全海域适用、不受水深地形限制 重力信号微弱、基准图构建难度大 地磁匹配导航 几十米~几百米 无限制(依赖地磁特征) 设备体积小、功耗低、无源无累积误差 受地磁变化和金属结构干扰 视觉SLAM定位 厘米级 几米~几十米 短距离精度高、定位建图一体化、
可实现环境感知受水体浊度和光照影响极大、
浑浊海域失效激光/光学定位 毫米级 几米~几十米 精度极高、实时性好、空间分辨率高 仅适用于浅海短距离场景 组合定位技术 INS-DVL组合 分米级 无限制(自主) 最经典方案、自主性强、成本适中 无绝对位置修正 INS-USBL/LBL组合 厘米~分米级 几百米~几千米 定期修正INS累积误差、精度高、
适配深海精密作业依赖外部声学信标、部署复杂 INS-地形匹配组合 米级 地形特征丰富区域 全自主长航时、无外部依赖 依赖高精度地形数据库 多源异构融合 分米级 全海域 高冗余性、强鲁棒性综合性能最优 系统复杂度高、算力需求大  下载: 导出CSV
-
[1] 赵羿羽, 孟德鑫, 王传荣, 等. 我国深海装备技术发展研究[J]. 船舶工程, 2024, 46(7): 128-135 doi: 10.13788/j.cnki.cbgc.2024.07.16Zhao Y Y, Meng D X, Wang C R, et al. Research on the development of deep-sea equipment technology in China[J]. Ship Engineering, 2024, 46(7): 128-135. doi: 10.13788/j.cnki.cbgc.2024.07.16 [2] 中华人民共和国国民经济和社会发展第十四个五年规划和2035年远景目标纲要[J]. 中国水利, 2021, (6): 1-38.Outline of the 14th Five-Year Plan for National Economic and Social Development of the People’s Republic of China and Vision 2035[J]. China Water Conservancy, 2021, (6): 1-38. [3] Yang Y X, Xu T H, Xue S Q. Progresses and prospects of marine geodetic datum and marine navigation of China[J]. Acta Geodaetica et Cartographica Sinica, 2017, 46(1): 1-8. doi: 10.11947/j.agcs.2017.20160519 [4] 井中武, 张昊楠, 刘冰, 等. 水下定位精度优化的AUV航路规划方法[J]. 哈尔滨工程大学学报, 2025, 46(1): 111-118 doi: 10.11990/jheu.202303002Jing Z W, Zhang H N, Liu B, et al. AUV path planning method for underwater positioning accuracy optimization[J]. Journal of Harbin Engineering University, 2025, 46(1): 111-118. doi: 10.11990/jheu.202303002 [5] 严浙平, 王璐. UUV水下定位方法的研究现状与进展[J]. 哈尔滨工程大学学报, 2017, 38(7): 989-1000. doi: 10.11990/jheu.201608067Yan Z P, Wang L. Research status and progress of UUV underwater positioning method[J]. Journal of Harbin Engineering University, 2017, 38(7): 989-1000. doi: 10.11990/jheu.201608067 [6] 邢国强, 李东兵, 隋毅, 等. 国外水下导航技术发展现状分析[J]. 飞航导弹, 2021(5): 80-84. doi: 10.16338/j.issn.1009-1319.20210813Xing G Q, Li D B, Sui Y, et al. Analysis of the development status of underwater navigation technology abroad[J]. Aerodynamic Missile Journal, 2021(5): 80-84. doi: 10.16338/j.issn.1009-1319.20210813 [7] 候倍倍, 谢于晨, 邱岚. 基于移动节点预测的水声传感器网络定位算法[J]. 传感器与微系统, 2026, 45(1): 155-160. doi: 10.13873/J.1000-9787(2026)01-0155-06Hou B B, Xie Y C, Qiu L. Underwater acoustic sensor network localization algorithm based on mobile node prediction[J]. Transducer and Microsystem Technologies, 2026, 45(1): 155-160. doi: 10.13873/J.1000-9787(2026)01-0155-06 [8] 李乐新. 打捞工程中海底机器人自主导航与定位技术的优化研究[J]. 珠江水运, 2025(17): 100-102. doi: 10.14125/j.cnki.zjsy.2025.17.023Li L X. Research on the optimization of autonomous navigation and positioning technology of submarine robots in salvage engineering[J]. Pearl River Water Transport, 2025(17): 100-102. doi: 10.14125/j.cnki.zjsy.2025.17.023 [9] 张纪元. 基于先验地图的水下检测机器人焊缝引导与位姿控制研究[D]. 北京: 北京石油化工学院, 2025: 40. [10] 冯金鹿. 水下定位用浮标数据管控系统研制[D]. 哈尔滨: 哈尔滨工程大学, 2015: 55. [11] 孙林祥. 水下机器人定位与作业臂控制方法研究[D]. 哈尔滨: 哈尔滨理工大学, 2024: 46. [12] 张居成. 深水长基线定位导航技术研究[D]. 哈尔滨: 哈尔滨工程大学, 2014: 3. [13] 李壮. 短基线定位关键技术研究[D]. 哈尔滨: 哈尔滨工程大学, 2013: 2. [14] 田春和. 超短基线定位误差综合分析及实验[J]. 水道港口, 2015, 36(6): 605-608. doi: 10.3969/j.issn.1005-8443.2015.06.027Tian C H. Comprehensive analysis and experiment of ultra-short baseline positioning error[J]. Journal of Waterway and Harbor, 2015, 36(6): 605-608. doi: 10.3969/j.issn.1005-8443.2015.06.027 [15] 刘伟. 惯性导航技术在海上装备中的应用[J]. 天津航海, 2025(4): 45-47. doi: 10.3969/j.issn.1005-9660.2025.04.014Liu W. Application of inertial navigation technology in marine equipment[J]. Tianjin Navigation, 2025(4): 45-47. doi: 10.3969/j.issn.1005-9660.2025.04.014 [16] 陈静, 管春洋, 张吉先, 等. 水下组合导航系统DVL时间延迟估计方法[J]. 战术导弹技术, 2023(4): 69-77. doi: 10.16358/j.issn.1009-1300.20230060Chen J, Guan C Y, Zhang J X, et al. DVL time delay estimation method for underwater integrated navigation system[J]. Tactical Missile Technology, 2023(4): 69-77. doi: 10.16358/j.issn.1009-1300.20230060 [17] 张珈畅, 贾春, 邹兆波, 等. 水下多平台协同定位技术发展综述[J]. 导航定位与授时, 2026, 13(1): 77-96 doi: 10.19306/j.cnki.2095-8110.2026.01.006Zhang J C, Jia C, Zou Z B, et al. Overview of the development of underwater multi-platform cooperative positioning technology[J]. Navigation Positioning and Timing, 2026, 13(1): 77-96. doi: 10.19306/j.cnki.2095-8110.2026.01.006 [18] 佟昊阳, 陆渭林. 人工智能技术在无人潜航器近场定位中的应用[J]. 宇航计测技术, 2026, 46(1): 16-20. doi: 10.12060/j.issn.1000-7202.2026.01.04Tong H Y, Lu W L. Application of artificial intelligence technology in near-field positioning of unmanned underwater vehicles[J]. Journal of Astronautic Metrology and Measurement, 2026, 46(1): 16-20. doi: 10.12060/j.issn.1000-7202.2026.01.04 [19] 周晓纪, 张永伟, 马守磊, 等. 中国工程科技2040技术预见方法体系及其应用[J]. 中国工程科学, 2024, 26(5): 117-127. doi: 10.15302/J-SSCAE-2024.05.012Zhou X J, Zhang Y W, Ma S L, et al. China engineering science and technology 2040 technology foresight method system and its application[J]. Strategic Study of CAE, 2024, 26(5): 117-127. doi: 10.15302/J-SSCAE-2024.05.012 [20] 刘松. 双模水声通信仿真及其在OMAPL138平台上的实现[D]. 哈尔滨: 哈尔滨工程大学, 2017: 2. [21] 赵杰超, 金浩, 陈健, 等. 水上应急救援关键装备技术现状与发展[J]. 中国机械工程, 2022, 33(4): 432-451,458. doi: 10.3969/j.issn.1004-132X.2022.04.007Zhao J C, Jin H, Chen J, et al. Current status and development of key equipment technology for water emergency rescue[J]. China Mechanical Engineering, 2022, 33(4): 432-451,458. doi: 10.3969/j.issn.1004-132X.2022.04.007 [22] 朱尚阳. 基于AUV平台的水声定位通信信标设计[D]. 哈尔滨: 哈尔滨工程大学, 2024: 4. [23] 杨紫. 声呐浮标探测系统中高可靠的通信协议设计及实现[D]. 成都: 电子科技大学, 2025: 4. [24] 段佳雨. 船载水声定位系统信号处理平台设计[D]. 哈尔滨: 哈尔滨工程大学, 2024: 15. [25] 张炳生. 水下声学高精度定位算法的研究[D]. 西安: 长安大学, 2019: 1. [26] 于燕婷, 许江宁, 林恩凡, 等. 单信标水声定位技术研究现状及应用展望[J]. 导航定位学报, 2022, 10(2): 13-20. doi: 10.3969/j.issn.2095-4999.2022.02.002Yu Y T, Xu J N, Lin E F, et al. Research status and application prospect of single beacon underwater acoustic positioning technology[J]. Journal of Navigation and Positioning, 2022, 10(2): 13-20. doi: 10.3969/j.issn.2095-4999.2022.02.002 [27] 童余德, 查峰, 黄晓颖, 等. 一种单信标测距辅助INS的导航方法[J]. 中国惯性技术学报, 2024, 32(6): 586-591,597. doi: 10.13695/j.cnki.12-1222/o3.2024.06.008Tong Y D, Cha F, Huang X Y, et al. A single beacon ranging aided INS navigation method[J]. Journal of Chinese Inertial Technology, 2024, 32(6): 586-591,597. doi: 10.13695/j.cnki.12-1222/o3.2024.06.008 [28] 陈允锋, 陶健龙. 基于改进扩展卡尔曼滤波的AUV单信标定位研究[J]. 舰船电子对抗, 2023, 46(2): 72-78 doi: 10.16426/j.cnki.jcdzdk.2023.02.014Chen Y F, Tao J L. Research on AUV single beacon positioning based on improved extended Kalman filter[J]. Ship Electronic Warfare, 2023, 46(2): 72-78. doi: 10.16426/j.cnki.jcdzdk.2023.02.014 [29] Deng C T, Huang C Y, Zhao H, et al. A review of geomagnetic matching navigation algorithms[J]. Science Technology and Engineering, 2012, 12(24): 6125-6131. [30] 郑伟, 付腾达, 李钊伟, 等. 潜器水下重力匹配导航研究进展[J]. 科学技术与工程, 2022, 22(18): 7721-7734. doi: 10.3969/j.issn.1671-1815.2022.18.001Zheng W, Fu T D, Li Z W, et al. Research progress of underwater gravity matching navigation for submersible[J]. Science Technology and Engineering, 2022, 22(18): 7721-7734. doi: 10.3969/j.issn.1671-1815.2022.18.001 [31] 张静远, 谌剑, 李恒, 等. 水下地形辅助导航技术的研究与应用进展[J]. 国防科技大学学报, 2015, 37(3): 128-135. doi: 10.11887/j.cn.201503021Zhang J Y, Chen J, Li H, et al. Research and application progress of underwater terrain aided navigation technology[J]. Journal of National University of Defense Technology, 2015, 37(3): 128-135. doi: 10.11887/j.cn.201503021 [32] 丁鹏, 杨申申, 王磊, 等. 水下地形匹配导航研究综述[J]. 科学技术与工程, 2024, 24(14): 5690-5706. doi: 10.12404/j.issn.1671-1815.2310169Ding P, Yang S S, Wang L, et al. Review of underwater terrain matching navigation[J]. Science Technology and Engineering, 2024, 24(14): 5690-5706. doi: 10.12404/j.issn.1671-1815.2310169 [33] 范刚, 殷国玲, 刘晓进, 等. 水下潜航器重力辅助导航技术研究进展与分析[J]. 兵器装备工程学报, 2026, 47(3): 353-363. doi: 10.11809/bqzbgcxb2026.03.039Fan G, Yin G L, Liu X J, et al. Research progress and analysis of gravity-assisted navigation technology for underwater submersibles[J]. Journal of Ordnance Equipment Engineering, 2026, 47(3): 353-363. doi: 10.11809/bqzbgcxb2026.03.039 [34] 李雄伟, 刘建业, 康国华. Tercom地形高程辅助导航系统发展及应用研究[J]. 中国惯性技术学报, 2006, 14(1): 34-40. doi: 10.3969/j.issn.1005-6734.2006.01.008Li X W, Liu J Y, Kang G H. Development and application of Tercom terrain elevation aided navigation system[J]. Journal of Chinese Inertial Technology, 2006, 14(1): 34-40. doi: 10.3969/j.issn.1005-6734.2006.01.008 [35] 赵建虎, 欧阳永忠, 王爱学. 海底地形测量技术现状及发展趋势[J]. 测绘学报, 2017, 46(10): 1786-1794 doi: 10.11947/j.agcs.2017.20170276Zhao J H, Ouyang Y Z, Wang A X. Current situation and development trend of seabed topographic survey technology[J]. Acta Geodaetica et Cartographica Sinica, 2017, 46(10): 1786-1794. doi: 10.11947/j.agcs.2017.20170276 [36] Gao D Y, Hu B Q, Chang L B, et al. An aided navigation method based on strapdown gravity gradiometer[J]. Sensors, 2021, 21(3): 829. doi: 10.3390/s21030829 [37] Andersen O B, Forsberg R, Knudsen P, et al. Comparison of altimetric and ship borne marine gravity over ice-free and ice-covered polar seas[C]//Geodesy on the Move, 1998: 492-497. [38] 张文君, 马腾, 李晔, 等. 水下地磁导航方法综述[J]. 哈尔滨工程大学学报, 2025, 46(12): 2583-2595 doi: 10.11990/jheu.202412012Zhang W J, Ma T, Li Y, et al. A review of underwater geomagnetic navigation methods[J]. Journal of Harbin Engineering University, 2025, 46(12): 2583-2595. doi: 10.11990/jheu.202412012 [39] 许峰. 基于视觉SLAM的水下作业智能定位与导航算法研究[J]. 船舶物资与市场, 2025, 33(7): 121-123. doi: 10.19727/j.cnki.cbwzysc.2025.07.037Xu F. Research on intelligent positioning and navigation algorithm for underwater operation based on visual SLAM[J]. Marine Equipment/Materials & Marketing, 2025, 33(7): 121-123. doi: 10.19727/j.cnki.cbwzysc.2025.07.037 [40] 高剑, 何耀祯, 陈依民, 等. 水下航行器视觉控制技术综述[J]. 水下无人系统学报, 2024, 32(2): 282-294 doi: 10.11993/j.issn.2096-3920.2023-0061Gao J, He Y Z, Chen Y M, et al. Overview of visual control technology for underwater vehicles[J]. Journal of Unmanned Undersea Systems, 2024, 32(2): 282-294. doi: 10.11993/j.issn.2096-3920.2023-0061 [41] Davison A J. Real-time simultaneous localisation and mapping with a single camera[C]//Proceedings Ninth IEEE International Conference on Computer Vision, 2003: 265-270. [42] Liu T, Xu C, Qiao Y, et al. Particle filter SLAM for vehicle localization[PP/OL]. V2. arXiv (2024-02-20)[2026-10-10]. https://doi.org/10.48550/arXiv.2402.07429. [43] Grisetti G, Kümmerle R, Stachniss C, et al. A tutorial on graph-based SLAM[J]. IEEE Intelligent Transportation Systems Magazine, 2011, 2(4): 31-43. [44] Hu C, Zhu S, Song W. Real-time underwater 3D reconstruction based on monocular image[C]//2022 IEEE International Conference on Robotics and Biomimetics (ROBIO), 2022: 1239-1244. [45] White S N, Kirkwood W, Sherman A, et al. Development and deployment of a precision underwater positioning system for in situ laser Raman spectroscopy in the deep ocean[J]. Deep Sea Research Part I: Oceanographic Research Papers, 2005, 52(12): 2376-2389. doi: 10.1016/j.dsr.2005.09.002 [46] 石浩男, 赵凯华, 胡浩丰, 等. 水下激光测距技术研究进展(特邀)[J]. 激光与光电子学进展, 2025, 62(19): 241-256. doi: 10.3788/LOP251499Shi H N, Zhao K H, Hu H F, et al. Research progress of underwater laser ranging technology (invited)[J]. Laser & Optoelectronics Progress, 2025, 62(19): 241-256. doi: 10.3788/LOP251499 [47] 辛光红, 林甄, 汪源. 基于激光多普勒测振技术的水下声源定位方法[J]. 激光杂志, 2026, 47(3): 217-222 doi: 10.14016/j.cnki.jgzz.2026.03.217Xin G H, Lin Z, Wang Y. Underwater sound source localization method based on laser Doppler vibrometry[J]. Laser Journal, 2026, 47(3): 217-222. doi: 10.14016/j.cnki.jgzz.2026.03.217 [48] 梁钟泓, 谢元平, 张永健, 等. 基于协方差变换的INS/DVL全球组合导航算法[J]. 中国惯性技术学报, 2022, 30(2): 159-167. doi: 10.13695/j.cnki.12-1222/o3.2022.02.004Liang Z H, Xie Y P, Zhang Y J, et al. INS/DVL global integrated navigation algorithm based on covariance transformation[J]. Journal of Chinese Inertial Technology, 2022, 30(2): 159-167. doi: 10.13695/j.cnki.12-1222/o3.2022.02.004 [49] 徐博, 郝芮, 王超, 等. 基于倒置声学基阵的INSUSBL组合导航算法研究[J]. 海洋技术学报, 2017, 36(5): 46-54. doi: 10.3969/j.issn.1003-2029.2017.05.008Xu B, Hao R, Wang C, et al. Research on INSUSBL integrated navigation algorithm based on inverted acoustic array[J]. Journal of Ocean Technology, 2017, 36(5): 46-54. doi: 10.3969/j.issn.1003-2029.2017.05.008 [50] 成月, 曹园山, 赵俊波, 等. 非高斯噪声背景的水下INS-LBL组合导航方法[J]. 舰船科学技术, 2024, 46(15): 121-124. doi: 10.3404/j.issn.1672-7649.2024.15.021Cheng Y, Cao Y S, Zhao J B, et al. Underwater INS-LBL integrated navigation method under non-Gaussian noise background[J]. Ship Science and Technology, 2024, 46(15): 121-124. doi: 10.3404/j.issn.1672-7649.2024.15.021 [51] 秦洪懋, 王希, 王广才, 等. 基于因子图优化的紧耦合INS/USBL/DVL导航方案[J]. 战术导弹技术, 2023(4): 37-47,68. doi: 10.16358/j.issn.1009-1300.20230054Qin H M, Wang X, Wang G C, et al. Tightly coupled INS/USBL/DVL navigation scheme based on factor graph optimization[J]. Tactical Missile Technology, 2023(4): 37-47,68. doi: 10.16358/j.issn.1009-1300.20230054 [52] 程志雄, 陈昶雷, 董星犴, 等. 自主水下航行器海底地形与重磁场匹配方法[J]. 哈尔滨工程大学学报, 2026, 47(5): 929-940. doi: 10.11990/jheu.202601011Cheng Z X, Chen C L, Dong X X, et al. Matching method of seabed topography and gravity and magnetic field for autonomous underwater vehicle[J]. Journal of Harbin Engineering University, 2026, 47(5): 929-940. doi: 10.11990/jheu.202601011 [53] 凡志朋, 柴华, 王虎彪. 基于重力匹配定位的SINS水下长航时误差校正方案[J]. 中国惯性技术学报, 2025, 33(12): 1167-1174. doi: 10.13695/j.cnki.12-1222/o3.2025.12.001Fan Z P, Chai H, Wang H B. SINS underwater long-endurance error correction scheme based on gravity matching positioning[J]. Journal of Chinese Inertial Technology, 2025, 33(12): 1167-1174. doi: 10.13695/j.cnki.12-1222/o3.2025.12.001 [54] 邢奥成, 李海兵, 阚宝玺, 等. 海洋地磁导航关键技术及发展趋势[J]. 导航定位与授时, 2025, 12(2): 1-14 doi: 10.19306/j.cnki.2095-8110.2025.02.001Xing A C, Li H B, Kan B X, et al. Key technologies and development trends of marine geomagnetic navigation[J]. Navigation Positioning and Timing, 2025, 12(2): 1-14. doi: 10.19306/j.cnki.2095-8110.2025.02.001 [55] 丁硕硕. 基于多传感器融合的水下SLAM方法研究[D]. 哈尔滨工程大学, 2023: 45. [56] 张国良. 基于大深度的SINS/DVL/USBL组合导航技术研究[D]. 哈尔滨: 哈尔滨工程大学, 2019: 3. [57] 孙铜, 徐卫明. AUV集群协同定位技术研究进展[J]. 兵器装备工程学报, 2026, 47(1): 353-362. doi: 10.11809/bqzbgcxb2026.01.040Sun T, Xu W M. Research progress of AUV cluster cooperative positioning technology[J]. Journal of Ordnance Equipment Engineering, 2026, 47(1): 353-362. doi: 10.11809/bqzbgcxb2026.01.040 [58] Zhang L, Wu S, Tang C, et al. UUV cluster distributed navigation fusion positioning method with information geometry[J]. Journal of Marine Science and Engineering, 2025, 13(4): 696. doi: 10.3390/jmse13040696 [59] 赵书音. 基于图神经网络的水下协同定位方法研究[D]. 哈尔滨: 哈尔滨工业大学, 2025: 15. [60] Wu Y, Low K H, Lv C. Cooperative path planning for heterogeneous unmanned vehicles in a search-and-track mission aiming at an underwater target[J]. IEEE Transactions on Vehicular Technology, 2020, 69(6): 6782-6787. doi: 10.1109/TVT.2020.2991983 [61] Teng M, Yuan G, Mingxiao Y, et al. Multi-AUV cooperative localization system without bottom tracking velocity assistance[J]. Measurement Science and Technology, 2025, 36(10): 106302. doi: 10.1088/1361-6501/ae035e [62] Wang Q, He B, Zhang Y, et al. An autonomous cooperative system of multi-AUV for underwater targets detection and localization[J]. Engineering Applications of Artificial Intelligence, 2023, 121(2): 105907. [63] 赵吉祥, 秦志亮, 马本俊, 等. 基于深度学习的水下声源定位方法研究综述[J]. 哈尔滨工程大学学报, 2026, 47(4): 877-890. doi: 10.11990/jheu.202411016Zhao J X, Qin Z L, Ma B J, et al. Review of underwater sound source localization methods based on deep learning[J]. Journal of Harbin Engineering University, 2026, 47(4): 877-890. doi: 10.11990/jheu.202411016 [64] 刘志华, 安凯晨, 刘嘉琦, 等. 大规模UASNs中强化学习修正误差的迭代定位[J]. 南京信息工程大学学报, 2026, 18(4): 533-544. doi: 10.13878/j.cnki.jnuist.20250409005Liu Z H, An K C, Liu J Q, et al. Iterative localization of reinforcement learning correction errors in large-scale UASNs[J]. Journal of Nanjing University of Information Science and Technology, 2026, 18(4): 533-544. doi: 10.13878/j.cnki.jnuist.20250409005 [65] 刘明, 孟子洋. 一种基于深度学习的水下环境单目SLAM算法研究[J]. 重庆理工大学学报(自然科学), 2025, 39(7): 127-135.Liu M, Meng Z Y. Research on a monocular SLAM algorithm for underwater environment based on deep learning[J]. Journal of Chongqing University of Technology (Natural Science), 2025, 39(7): 127-135. [66] Han F, Yao J, Zhu H, et al. Underwater image processing and object detection based on deep CNN method[J]. Journal of Sensors, 2020, 2020: 1-20. [67] Yu Y, Si X, Hu C, et al. A review of recurrent neural networks: LSTM cells and network architectures[J]. Neural Computation, 2019, 31(7): 1235-1270. doi: 10.1162/neco_a_01199 [68] 彭铎, 查海音, 曹坚, 等. 基于CNN-LSTM声速预测的水下移动节点定位算法[J]. 电子测量与仪器学报, 2024, 38(11): 146-157. doi: 10.13382/j.jemi.B2407531Peng D, Cha H Y, Cao J, et al. Underwater mobile node localization algorithm based on CNN-LSTM sound velocity prediction[J]. Journal of Electronic Measurement and Instrumentation, 2024, 38(11): 146-157. doi: 10.13382/j.jemi.B2407531 [69] Chowdhury I M, Phung V Q, Ahmed I, et al. Next-generation underwater localization: artificial intelligence-based and energy-aware approaches[J]. Applied Ocean Research, 2025, 165: 104842. doi: 10.1016/j.apor.2025.104842 [70] Wu P, Zhang H, Shi Y, et al. Real-time estimation of underwater sound speed profiles with a data fusion convolutional neural network model[J]. Applied Ocean Research, 2024, 150: 104088. doi: 10.1016/j.apor.2024.104088 [71] 曹兴科, 郑焱, 刘三军. 基于多普勒频移的水下移动目标定位算法[J]. 佳木斯大学学报(自然科学版), 2025, 43(12): 149-152. doi: 10.3969/j.issn.1008-1402.2025.12.038Cao X K, Zheng Y, Liu S J. Underwater moving target localization algorithm based on Doppler frequency shift[J]. Journal of Jiamusi University (Natural Science Edition), 2025, 43(12): 149-152. doi: 10.3969/j.issn.1008-1402.2025.12.038 [72] 颜炳阳. 面向水下光通信网络的融合定位方法[D]. 大连: 大连理工大学, 2024: 25. [73] 邝文俊, 万伏彬, 钟曜宇, 等. 基于量子重力探测技术的水下匹配导航仿真分析与评估[J]. 智能安全, 2023, 2(4): 68-80. doi: 10.12407/j.issn.2097-2075.2023.04.068Kuang W J, Wan F B, Zhong Y Y, et al. Simulation analysis and evaluation of underwater matching navigation based on quantum gravity detection technology[J]. Artificial Intelligence Security, 2023, 2(4): 68-80. doi: 10.12407/j.issn.2097-2075.2023.04.068 [74] 刘晓晨, 张琳英, 王炫伊, 等. 水下生物导航行为研究综述[J]. 导航与控制, 2025, 24(2): 27-47 doi: 10.3969/j.issn.1674-5558.2025.02.003Liu X C, Zhang L Y, Wang X Y, et al. Review of underwater biological navigation behavior[J]. Navigation and Control, 2025, 24(2): 27-47. doi: 10.3969/j.issn.1674-5558.2025.02.003 [75] Lohmann K J, Hester J T, Lohmann C M F. Long-distance navigation in sea turtles[J]. Ethology Ecology & Evolution, 11(1): 1-23. [76] Au W W L. Echolocation in dolphins[M]. Springer New York, 2000. [77] 许鹏丽. 基于偏振信息的水下航向测量方法研究[D]. 哈尔滨: 哈尔滨工业大学, 2025: 3. [78] 辛润宏, 张然, 褚金奎, 等. 基于Snell窗及偏振模式的水下载体航姿测量[J]. 光学精密工程, 2024, 32(12): 1801-1811. doi: 10.37188/OPE.20243212.1801Xin R H, Zhang R, Chu J K, et al. Underwater vehicle attitude measurement based on Snell window and polarization mode[J]. Optics and Precision Engineering, 2024, 32(12): 1801-1811. doi: 10.37188/OPE.20243212.1801 [79] 李佳璐. 组合状态下的水下声学导航滤波算法研究[D]. 西安: 长安大学, 2023: 18. [80] 高英杰. 基于水声网络节点的合作式目标定位系统设计[D]. 哈尔滨工程大学, 2016: 4. [81] 赵安邦, 何文翔, 董海防, 等. 声速分布深海超短基线定位算法[J]. 系统仿真学报, 2009, 21(15): 4763-4767. doi: 10.16182/j.cnki.joss.2009.15.012Zhao A B, He W X, Dong H F, et al. Sound velocity distribution deep-sea ultra-short baseline positioning algorithm[J]. Journal of System Simulation, 2009, 21(15): 4763-4767. doi: 10.16182/j.cnki.joss.2009.15.012 [82] 狄冰, 高辉, 徐亚国. 长基线定位系统在海洋油气开发中的应用[J]. 北京石油化工学院学报, 2015, 23(4): 35-39. doi: 10.3969/j.issn.1008-2565.2015.04.008Di B, Gao H, Xu Y G. Application of long baseline positioning system in offshore oil and gas development[J]. Journal of Beijing Institute of Petrochemical Technology, 2015, 23(4): 35-39. doi: 10.3969/j.issn.1008-2565.2015.04.008 [83] 张同伟, 秦升杰, 唐嘉陵, 等. 深海长基线定位系统现状及展望[J]. 测绘通报, 2018(10): 75-78,106 doi: 10.13474/j.cnki.11-2246.2018.0319Zhang T W, Qin S J, Tang J L, et al. Status and prospect of deep-sea long baseline positioning system[J]. Bulletin of Surveying and Mapping, 2018(10): 75-78,106. doi: 10.13474/j.cnki.11-2246.2018.0319 [84] 尹伟伟, 郭士荦. 非卫星水下导航定位技术综述[J]. 舰船电子工程, 2017, 37(3): 8-11. doi: 10.3969/j.issn.1672-9730.2017.03.003Yin W W, Guo S L. Review of non-satellite underwater navigation and positioning technology[J]. Ship Electronic Engineering, 2017, 37(3): 8-11. doi: 10.3969/j.issn.1672-9730.2017.03.003 [85] 黄浩. 多核DSP超短基线定位系统信号处理平台设计[D]. 哈尔滨: 哈尔滨工程大学, 2019: 3. [86] 魏博文, 吕文红, 范晓静, 等. AUV导航技术发展现状与展望[J]. 水下无人系统学报, 2019, 27(1): 1-9. doi: 10.11993/j.issn.2096-3920.2019.01.001Wei B W, Lv W H, Fan X J, et al. Development status and prospect of AUV navigation technology[J]. Journal of Unmanned Undersea Systems, 2019, 27(1): 1-9. doi: 10.11993/j.issn.2096-3920.2019.01.001 [87] Salavasidis G, Harris C A, Mcphail S, et al. Terrain aided navigation for long range AUV operations at arctic latitudes[C]//2016 IEEE/OES Autonomous Underwater Vehicles (AUV), 2016: 115-123. [88] 黄学涛, 贾福鑫, 肖泽鸿, 等. 自主水下航行器在极地的应用现状与关键技术[J]. 舰船科学技术, 2024, 46(16): 1-9. doi: 10.3404/j.issn.1672-7649.2024.16.001Huang X T, Jia F X, Xiao Z H, et al. Application status and key technologies of autonomous underwater vehicles in the polar region[J]. Ship Science and Technology, 2024, 46(16): 1-9. doi: 10.3404/j.issn.1672-7649.2024.16.001 [89] Tian M, Liang Z, Liao Z, et al. A polar robust Kalman filter algorithm for DVL-aided SINSs based on the ellipsoidal Earth model[J]. Sensors, 2022, 22(20): 7879. doi: 10.3390/s22207879 [90] 马杰, 余逸飞, 朱小东, 等. 面向水下目标搜寻与探摸的多装备协同作业系统[J]. 中国航海, 2023, 46(1): 136-142. doi: 10.3969/j.issn.1000-4653.2023.01.019Ma J, Yu Y F, Zhu X D, et al. A multi-equipment cooperative operation system for underwater target search and exploration[J]. Navigation of China, 2023, 46(1): 136-142. doi: 10.3969/j.issn.1000-4653.2023.01.019 [91] 黄泽鹏, 冉德禄, 阮永好. 超短基线定位和流速剖面在圣杯屿沉船水下考古中的应用[J]. 科技导报, 2024, 42(14): 116-124.Huang Z P, Ran D L, Ruan Y H. Application of ultra-short baseline positioning and velocity profile in underwater archaeology of the Shengbeiyu shipwreck[J]. Science & Technology Review, 2024, 42(14): 116-124. [92] Liu J, Yu T, Wu C, et al. A low-cost and high-precision underwater integrated navigation system[J]. Journal of Marine Science and Engineering, 2024, 12(2): 200. doi: 10.3390/jmse12020200 [93] 金博楠, 徐晓苏, 张涛, 等. 超短基线定位技术及在海洋工程中的应用[J]. 导航定位与授时, 2018, 5(4): 8-20. doi: 10.19306/j.cnki.2095-8110.2018.04.002Jin B N, Xu X S, Zhang T, et al. Ultra-short baseline positioning technology and its application in marine engineering[J]. Navigation Positioning and Timing, 2018, 5(4): 8-20. doi: 10.19306/j.cnki.2095-8110.2018.04.002 [94] 张涛, 夏茂栋, 张佳宇, 等. 水下导航定位技术综述[J]. 全球定位系统, 2022, 47(4): 1-16. doi: 10.12265/j.gnss.2022094Zhang T, Xia M D, Zhang J Y, et al. Overview of underwater navigation and positioning technology[J]. GNSS World of China, 2022, 47(4): 1-16. doi: 10.12265/j.gnss.2022094 [95] 周文健, 高春峰, 李金龙, 等. 水下重力匹配导航关键技术及其研究进展[J]. 导航定位学报, 2024, 12(1): 59-69. doi: 10.16547/j.cnki.10-1096.20240108Zhou W J, Gao C F, Li J L, et al. Key technologies and research progress of underwater gravity matching navigation[J]. Journal of Navigation and Positioning, 2024, 12(1): 59-69. doi: 10.16547/j.cnki.10-1096.20240108 -

 下载:

 点击查看大图
计量
- 文章访问数: 5
- HTML全文浏览量: 1
- PDF下载量: 0
- 被引次数: 0
图(5) / 表(1)