

Adaptive LPV-MPC and NFTSM-ESO Cooperative Control Method for Underactuated AUV
-
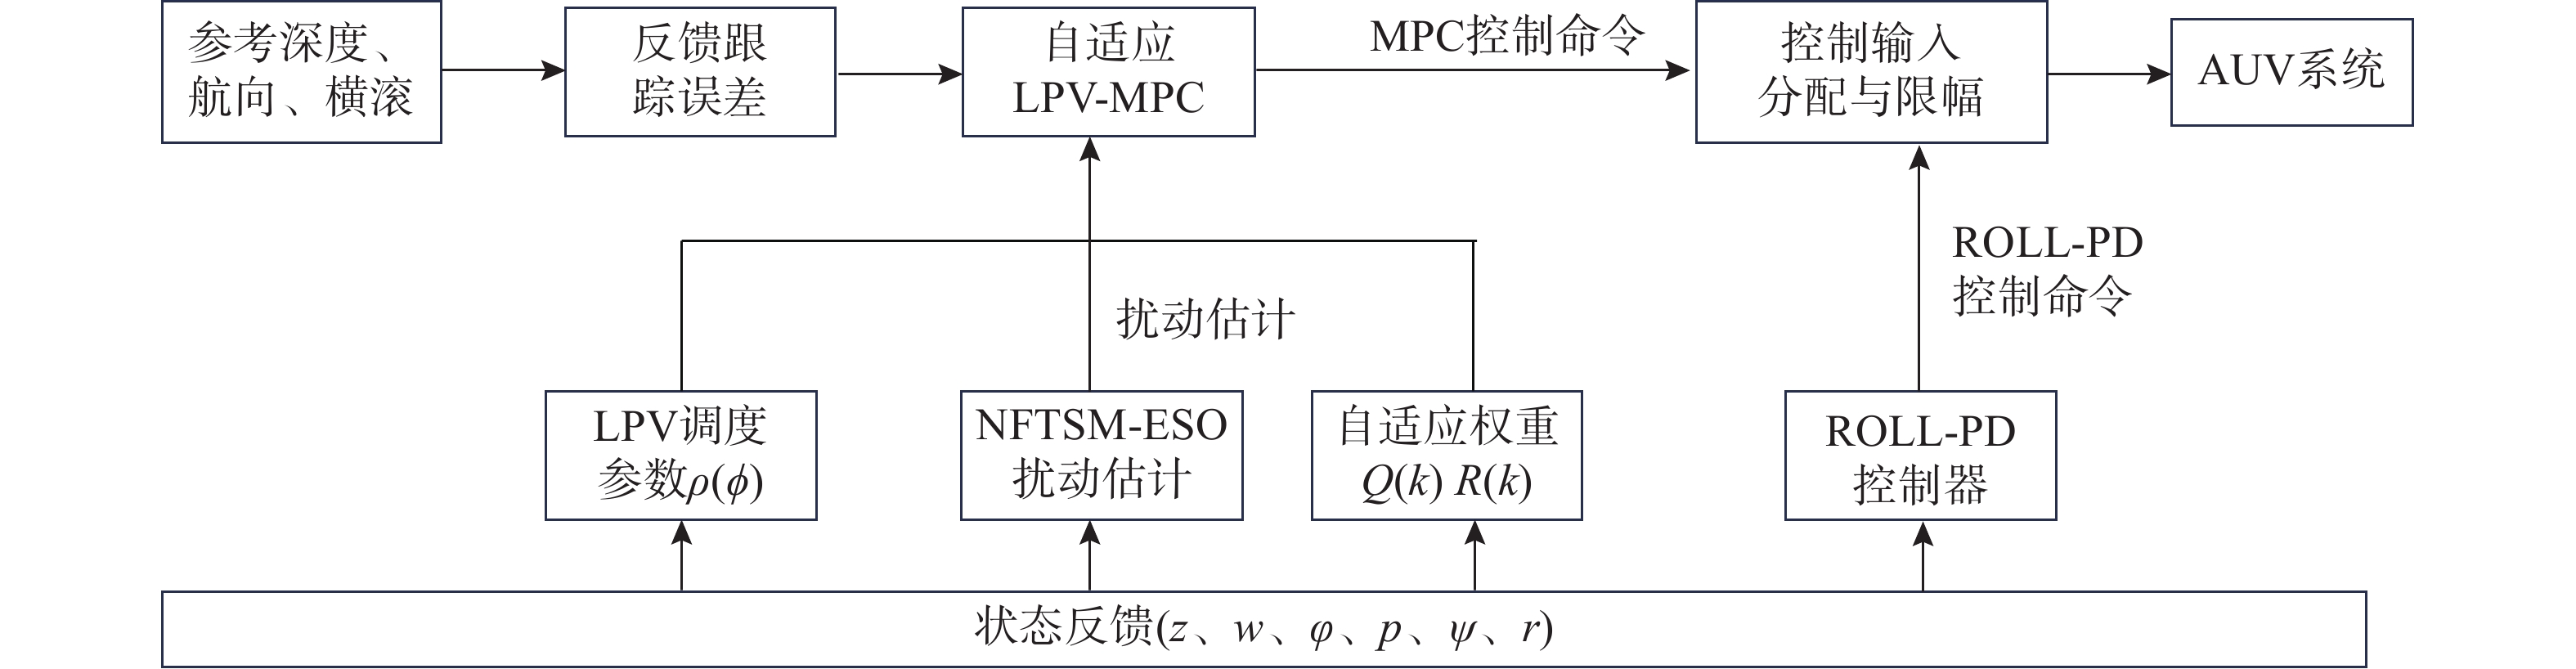
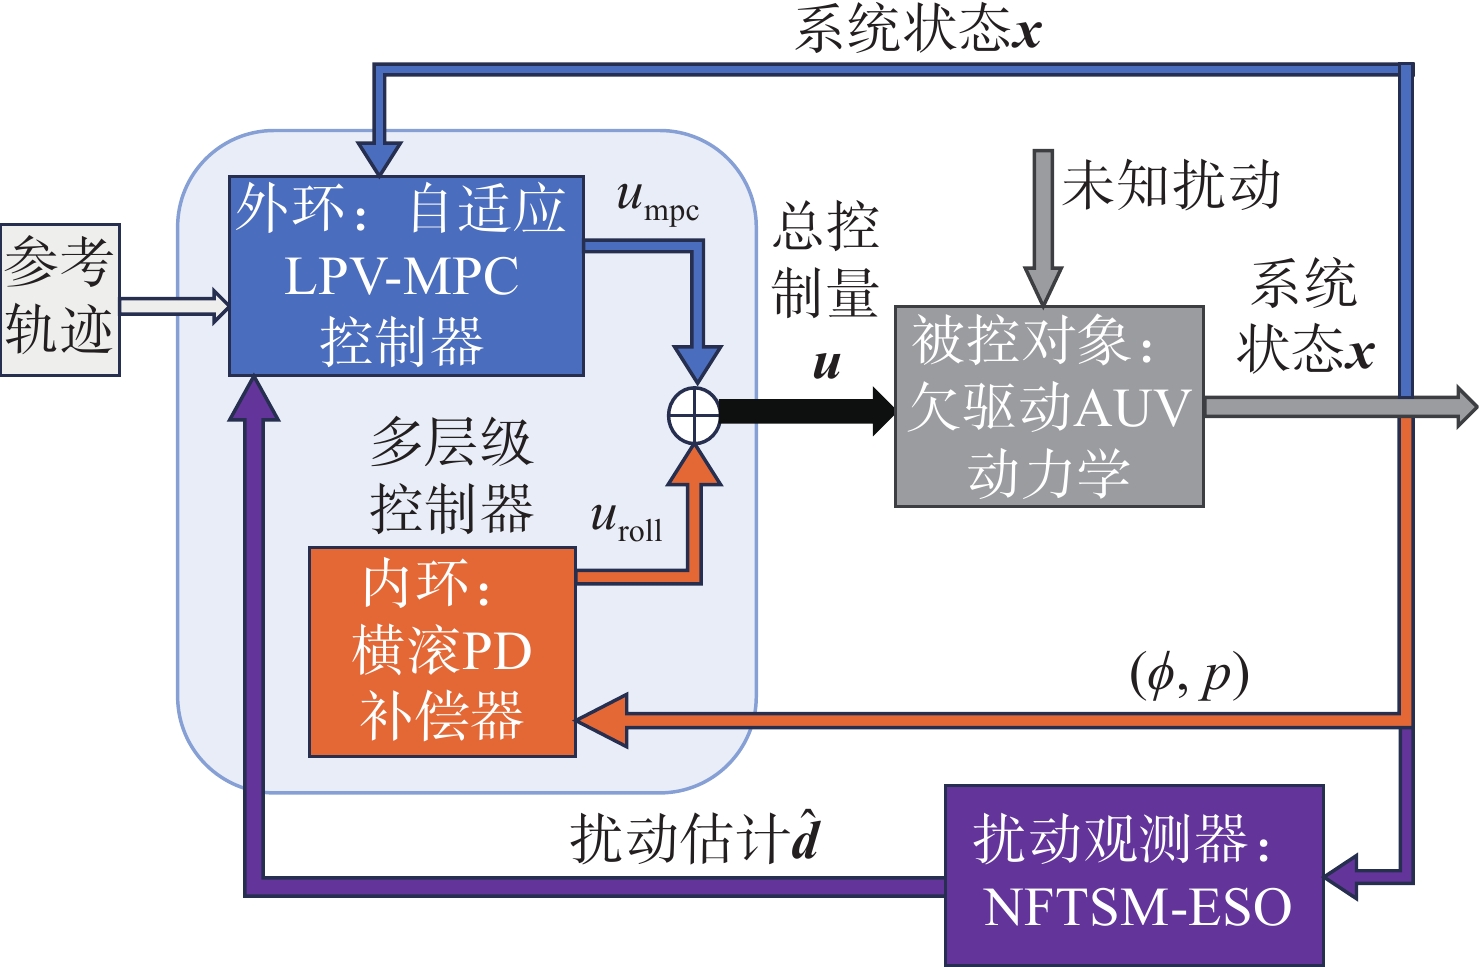
摘要: 针对欠驱动自主水下航行器(AUV)在深度-航向跟踪与横滚姿态稳定过程中面临的横移/横滚无独立执行器、舵面耦合、输入约束以及时变海流扰动等问题, 提出一种融合自适应线性变参数模型预测控制(LPV-MPC)、非奇异快速终端滑模扩展状态观测器(NFTSM-ESO)与横滚-比例微分(Roll-PD)内环的协同控制方法。基于升沉舵、方向舵在横滚姿态下的有效舵效变化, 建立随横滚角调度的深度-横滚-航向LPV误差模型, 用以刻画横滚姿态对深度和航向通道的耦合影响。在此基础上, 设计误差-扰动双指标驱动的自适应LPV-MPC, 在舵角幅值、舵角变化率和横滚软约束下在线求解控制增量序列, 生成约束可行的舵角指令。进一步构造NFTSM-ESO对海流、波浪诱导力矩、水动力参数不确定性及未建模项形成的总扰动进行快速、平滑估计, 并将扰动估计作为前馈补偿与权重调度依据。横滚PD内环在方向舵通道内提供高带宽横滚阻尼补偿, 降低横滚-航向耦合对外环预测模型的影响。仿真结果及消融实验表明, 所提方法相较于标准MPC+LESO、固定权重LPV-MPC以及无横滚内环方案, 可降低深度误差、航向误差和横滚振荡, 并保持舵角约束可行性, 为欠驱动AUV在复杂扰动环境下的深度-航向协同控制提供一种可解释、实时性较强的控制框架。Abstract: This paper addresses depth-heading tracking and roll stabilization of underactuated autonomous undersea vehicles (AUVs) subject to missing sway/roll actuation, rudder-induced channel coupling, actuator constraints, and time-varying marine disturbances. A cooperative control framework integrating adaptive linear parameter-varying model predictive control (LPV-MPC), a nonsingular fast terminal sliding mode extended state observer (NFTSM-ESO), and a roll proportional-derivative(PD) inner loop is proposed. A roll-angle-scheduled depth-roll-heading LPV error model is first established by describing the variation of elevator and rudder effectiveness under roll attitude, so that the influence of roll on the depth and heading channels can be incorporated into the prediction model. An error-disturbance-driven adaptive LPV-MPC is then developed to solve a constrained control-increment sequence under rudder magnitude, rudder-rate, and roll soft constraints, thereby producing feasible rudder-angle commands. The NFTSM-ESO rapidly and smoothly estimates lumped disturbances caused by currents, wave-induced moments, hydrodynamic uncertainty, and unmodeled dynamics; the estimates are used for feedforward compensation and weight scheduling. A roll PD inner loop is superimposed on the rudder channel to provide high-bandwidth roll damping and reduce roll-heading coupling in the outer prediction loop. Simulation and ablation results demonstrate that the proposed method outperforms standard MPC+LESO, fixed-weight LPV-MPC, and the scheme without roll inner-loop compensation in depth error, heading error, roll suppression, and constraint feasibility.
-
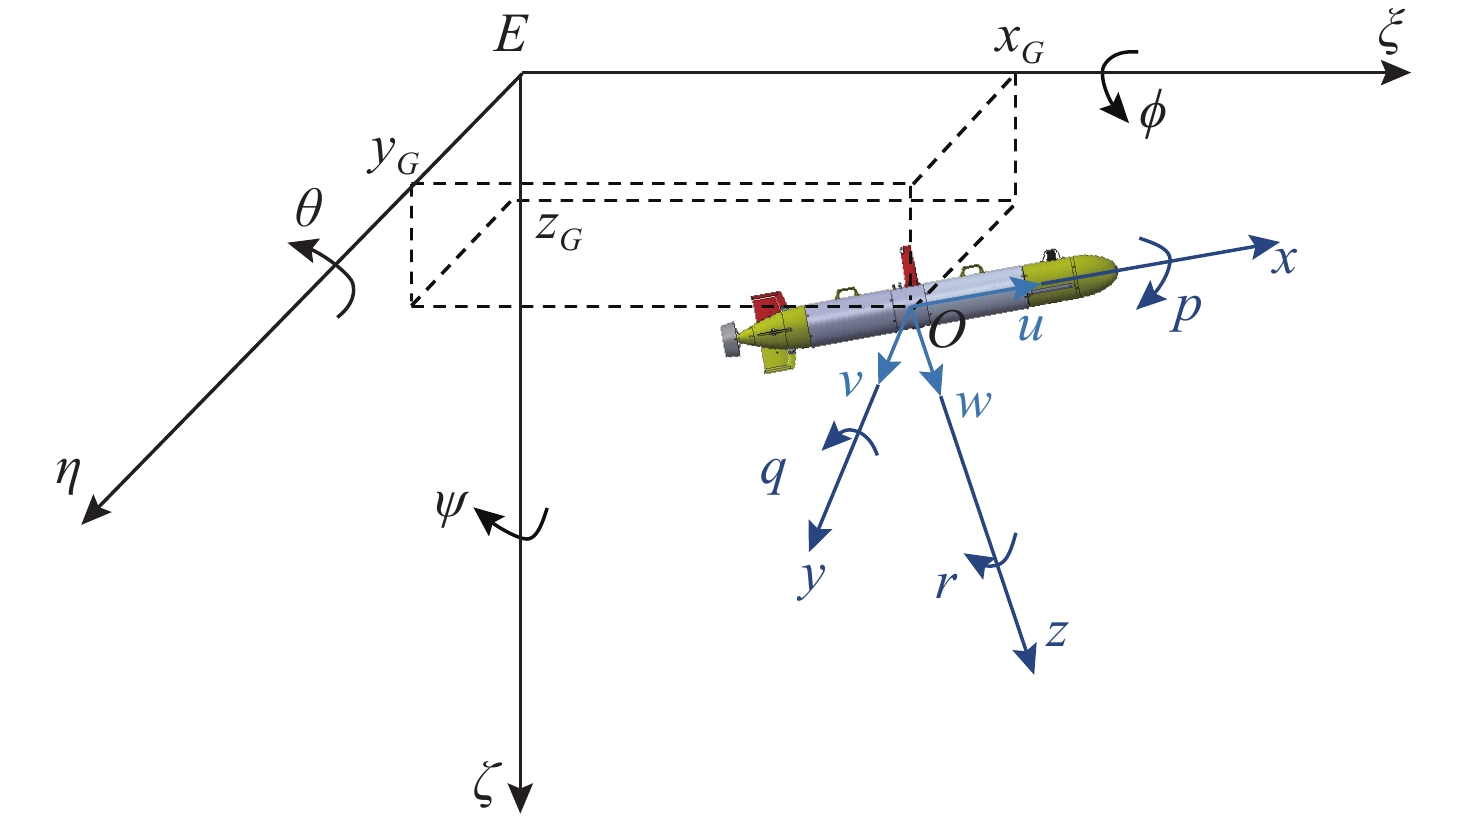
表 1 AUV运动参数与符号定义
Table 1. AUV motion parameters and symbol definitions
参数 符号 参数 符号 参数 符号 参数 符号 纵荡 $ x $ 横滚角 $ \phi $ 纵向线速度 $ u $ 横滚角速度 $ p $ 横荡 $ y $ 纵倾角 $ \theta $ 横向线速度 $ v $ 纵倾角速度 $ q $ 垂荡 $ {\textit{z}} $ 偏航角 $ \psi $ 垂向线速度 $ w $ 偏航角速度 $ r $  下载: 导出CSV
表 2 控制器参数设置
Table 2. Controller parameter settings
参数 符号 数值 预测时域 $ {N}_{p} $ 20 控制时域 $ {N}_{c} $ 3 基准状态权重 $ {Q}_{0} $ $ \text{diag}\left(200,1,10,1,200,1\right) $ 基准控制增量权重 $ {R}_{0} $ $ \text{diag}\left(1,1\right) $ 自适应权重范围 $ {\lambda }_{Q},{\lambda }_{R} $ $ \left[1.0,4.0\right] $, $ \left[1.0,6.0\right] $ 滑模面增益系数 $ {\beta }_{1} $、$ {\beta }_{2} $ 3.0, 6.0 NFTSM幂次因子 $ \alpha $ 0.6 Roll-PD增益 $ K_{p}^{\phi },K_{d}^{\phi } $ 1.7, 0.5
下载: 导出CSV
表 3 扰动观测器性能对比
Table 3. Comparison of perturbation observer performance
通道 指标 LESO NFTSM-ESO 改善幅度
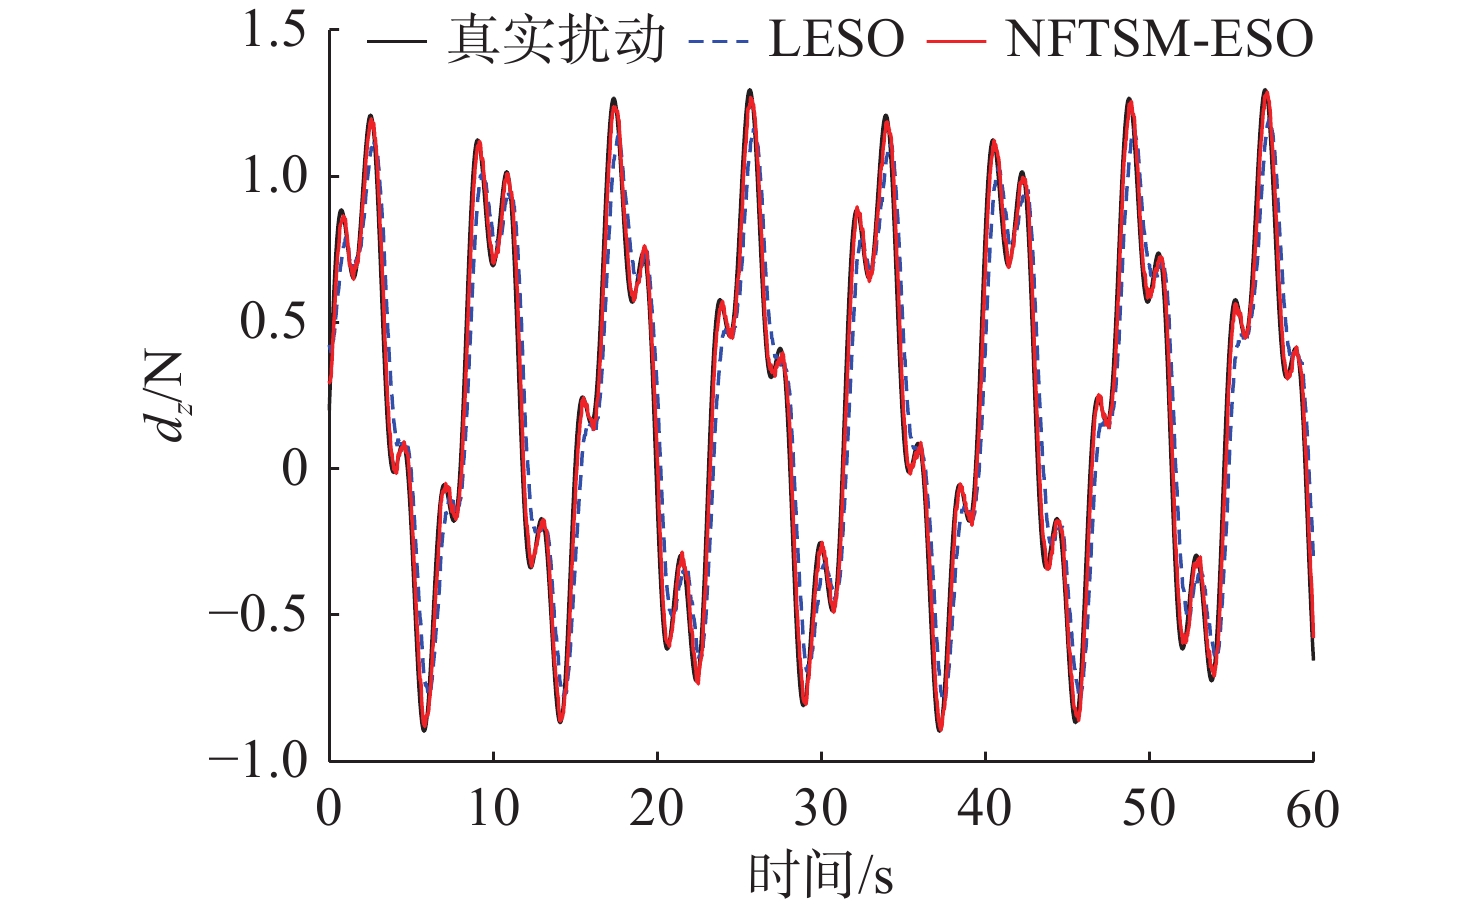
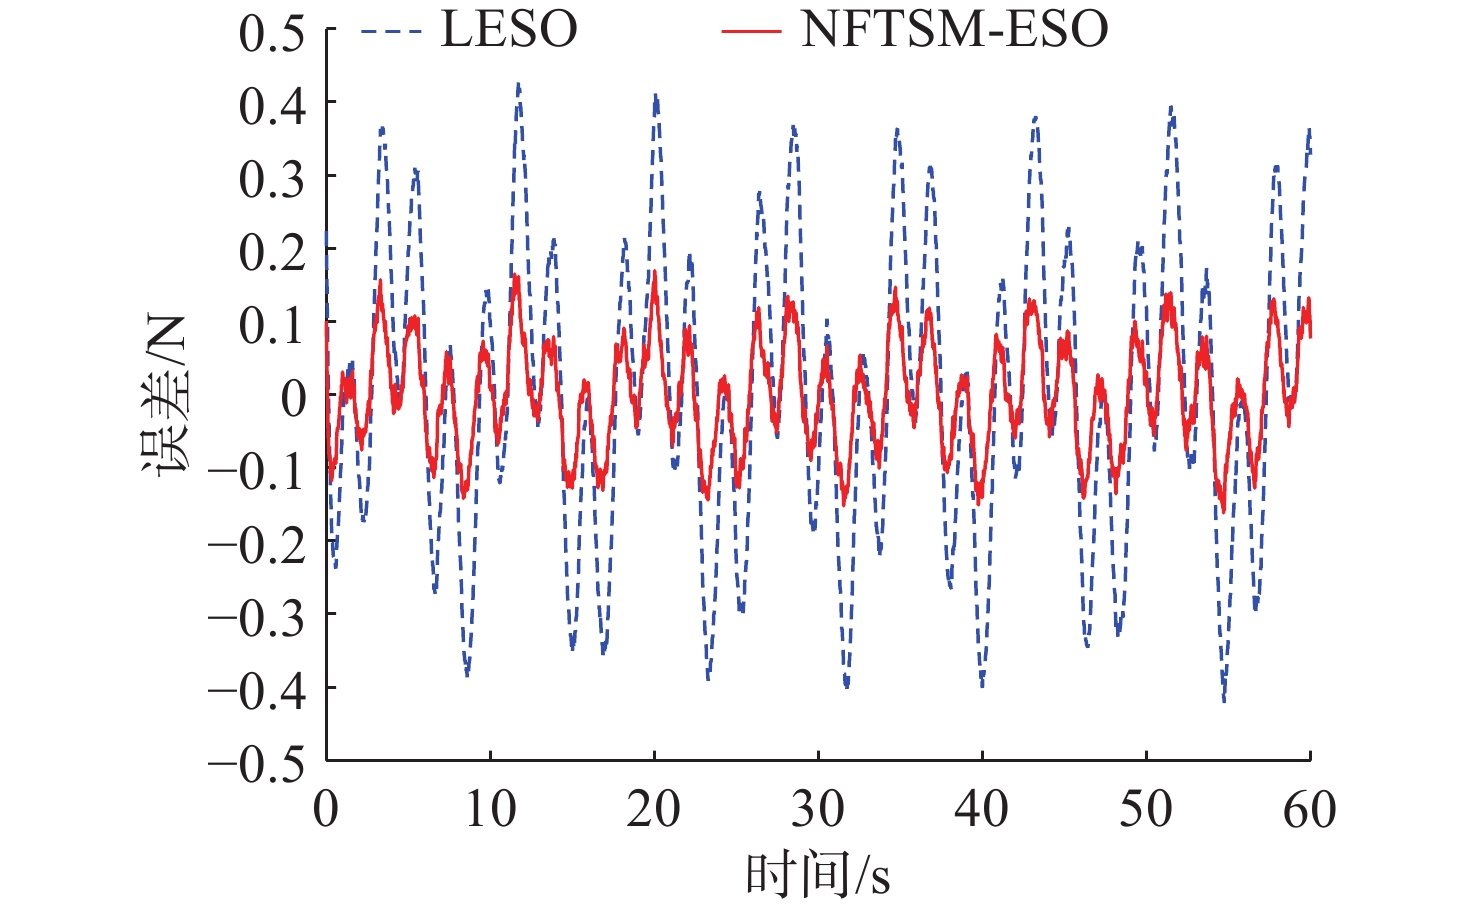
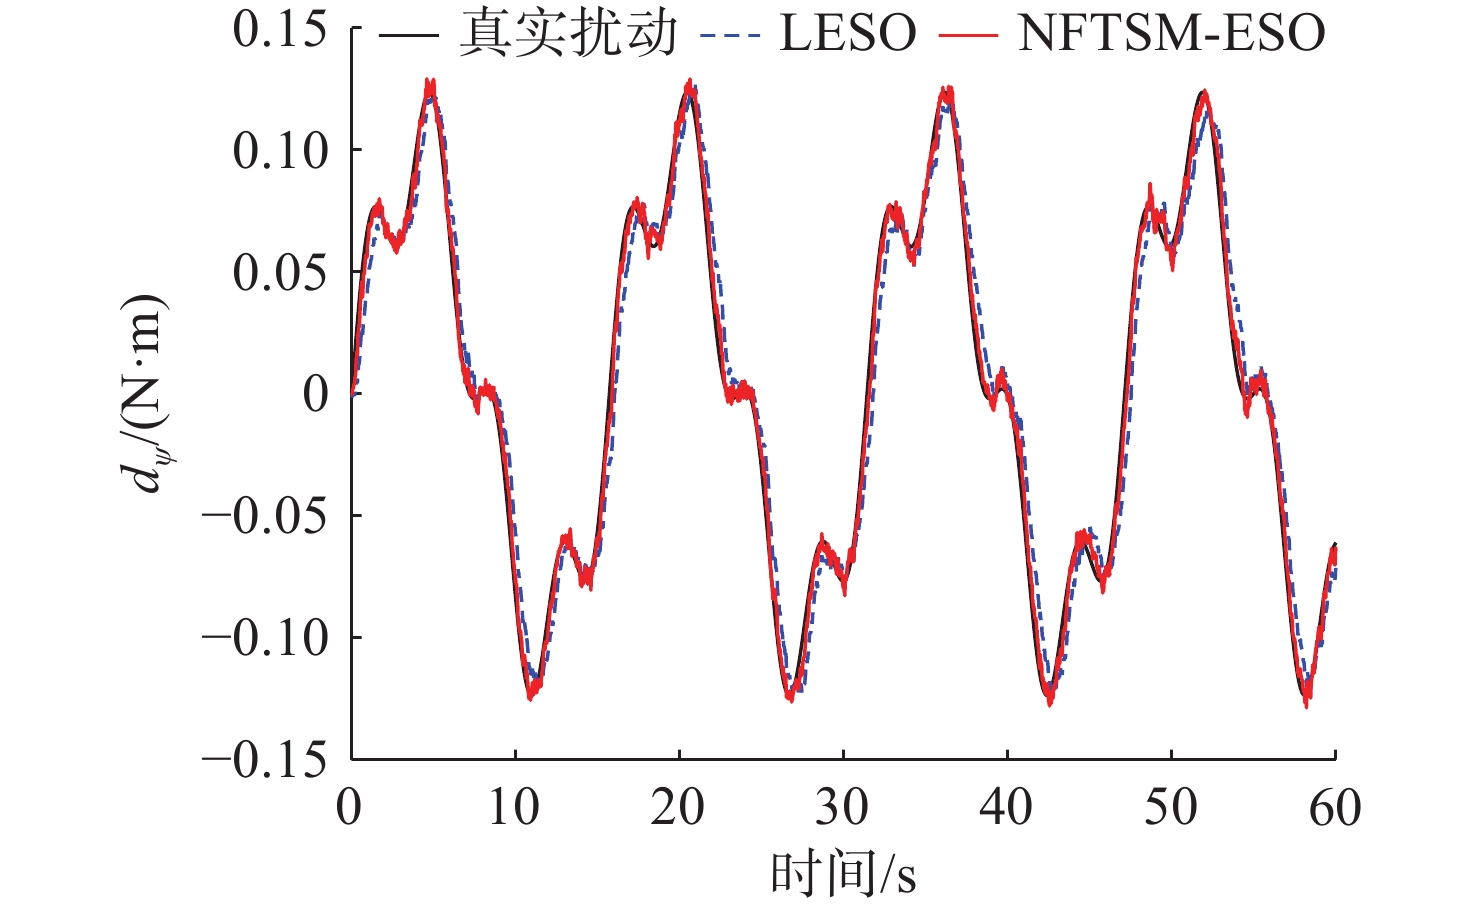
(降低)/%深度扰动 RMSE/N 0.186 0.071 61.8 MAE/N 0.141 0.052 63.1 收敛时间/s 1.64 0.78 52.4 估计误差 STD/N 0.118 0.046 61.0 航向扰动 RMSE/(N·m) 0.053 0.022 58.5 MAE/(N·m) 0.041 0.017 58.5 相位滞后/s 0.18 0.05 72.2 估计误差 STD/(N·m) 0.036 0.015 58.3
下载: 导出CSV
表 4 自适应参数统计特性
Table 4. Statistical properties of adaptive parameters
参数 最小值 最大值 均值 调节行为解析 $ {\lambda }_{Q} $ 1.30 2.96 2.13 初始快速机动阶段显著增大, 以强化状态跟踪精度; 进入稳态后动态回落, 以降低不必要控制能量 $ {\lambda }_{R} $ 1.12 1.36 1.24 整体保持相对平稳, 在扰动增强时适度增大, 以防止控制输入高频抖动 $ {k}_{\text{roll}} $ 1.14 1.72 1.43 与横滚扰动强度相关, 在转向或侧向扰动增强时提高横滚阻尼能力
下载: 导出CSV
表 5 消融实验性能对比
Table 5. Comparison of ablation experiment performance
方法 深度
RMSE/m航向
RMSE/(°)航向峰
值误差/(°)横滚
峰值/(°)横滚
STD /(°)控制能量
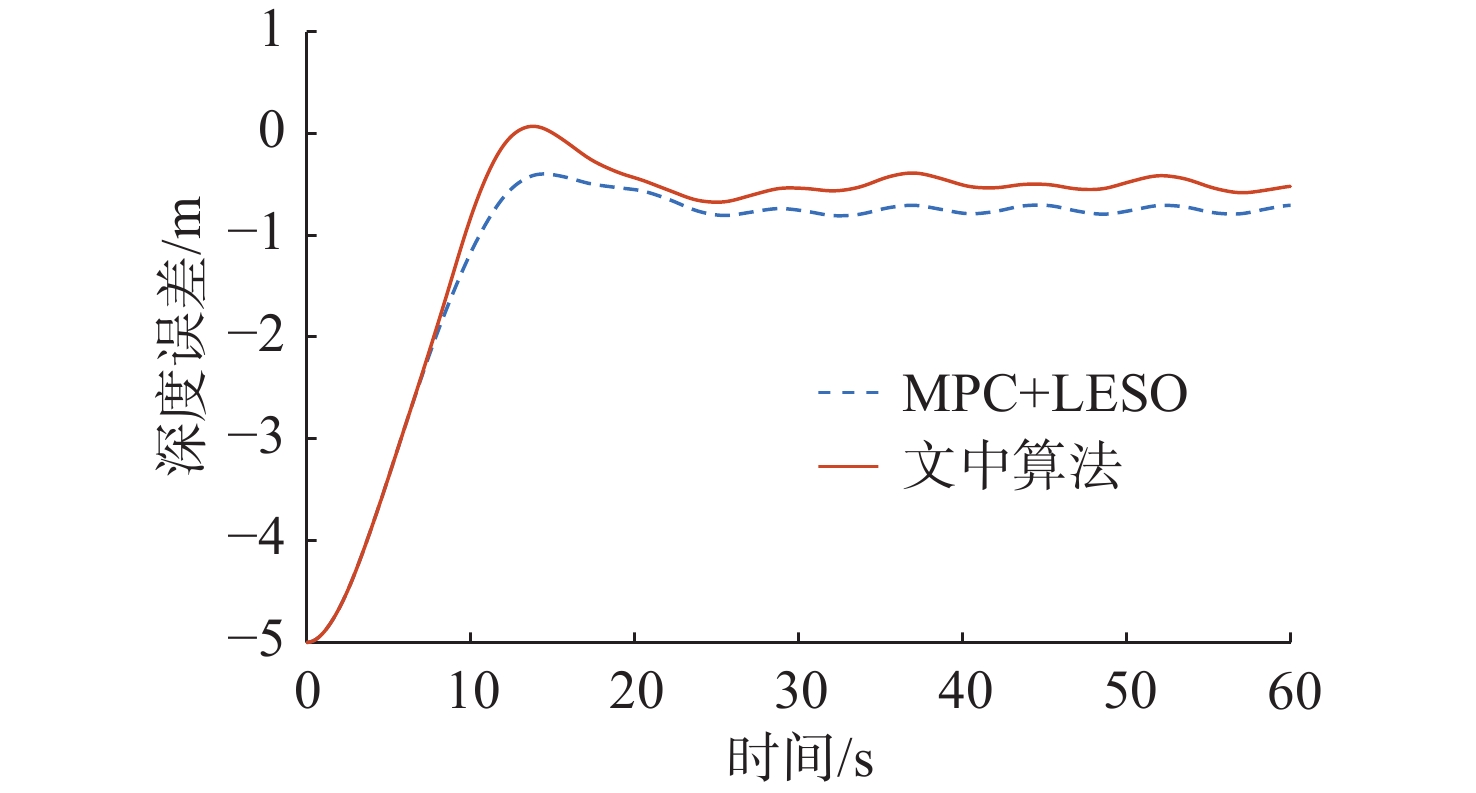
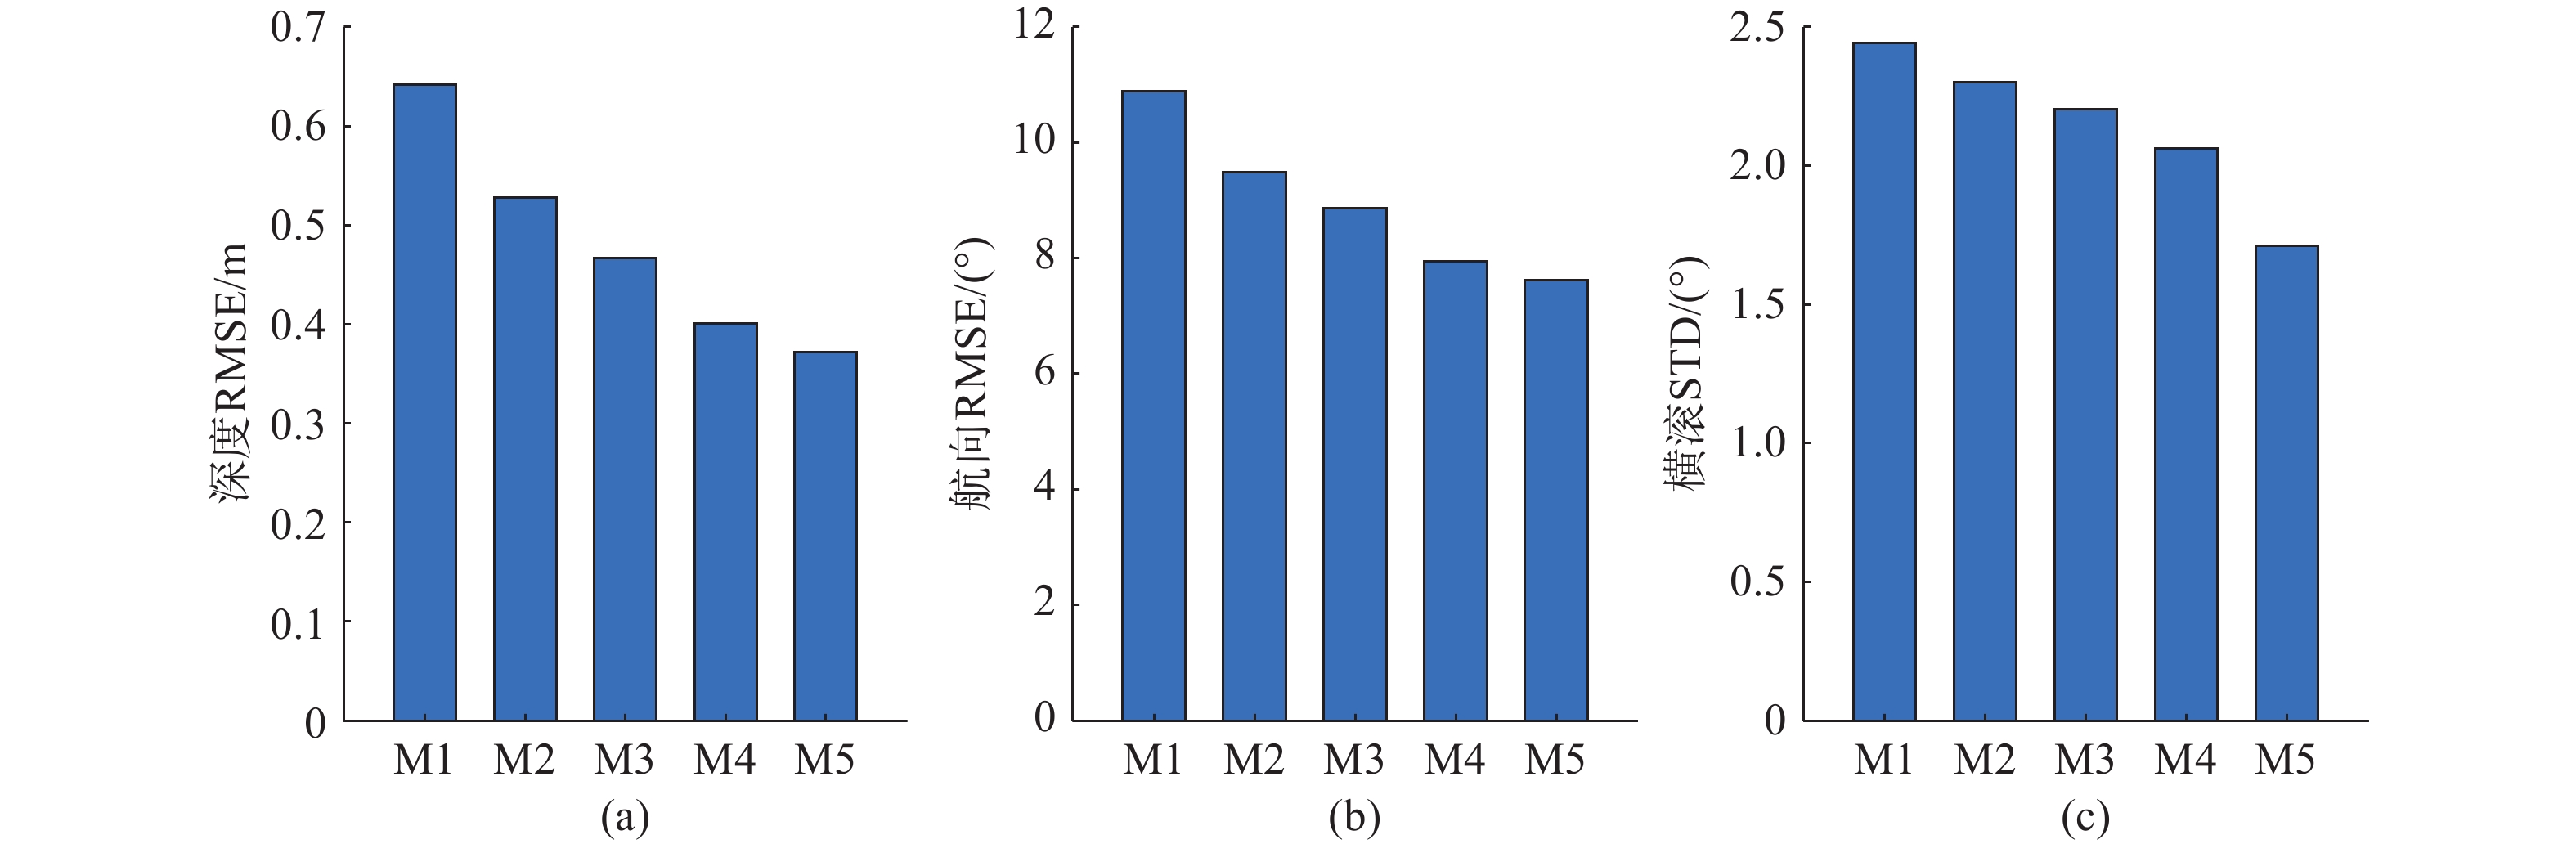
归一化M1: MPC+LESO 0.642 10.890 17.71 4.31 2.441 1.00 M2: LPV-MPC+LESO 0.528 9.487 15.88 4.05 2.301 1.06 M3: Adaptive LPV-MPC+LESO 0.467 8.863 14.76 3.92 2.204 1.09 M4: Adaptive LPV-MPC+NFTSM-ESO 0.401 7.948 13.54 3.71 2.061 1.11 M5: Adaptive LPV-MPC+NFTSM-ESO+Roll-PD 0.372 7.616 12.65 2.87 1.710 1.14
下载: 导出CSV
表 6 权重调度策略对比
Table 6. Comparison of Weighting Scheduling Strategies
策略 深度RMSE/m 航向RMSE/(°) 控制总变差 舵角饱和次数 说明 固定权重 0.421 8.18 3.62 11 响应平稳但大误差阶段收敛较慢 仅误差调度 0.389 7.84 3.91 18 跟踪改善但扰动阶段控制偏激进 误差-扰动双指标调度 0.372 7.62 3.45 6 兼顾跟踪精度、抗扰性和控制平滑性
下载: 导出CSV
表 7 实时计算时间统计
Table 7. Real-time calculation time statistics
模块 平均
时间/ms最大
时间/ms占采样周
期比例/%LPV参数更新与矩阵构造 0.12 0.31 1.55 NFTSM-ESO更新 0.05 0.14 0.70 自适应权重计算 0.03 0.08 0.40 QP求解 1.26 4.73 23.65 Roll-PD与饱和处理 0.01 0.03 0.15 总计 1.47 5.29 26.45
下载: 导出CSV
-
[1] 田逸宁, 张舜, 张洪星, 等. 用于海底管道巡检的常驻型水下机器人[J]. 船舶工程, 2024, 46(S1): 303-308.Tian Y N, Zhang S, Zhang H X. et al. Resident underwater robot for submarine pipeline inspection[J]. Ship Engineering, 2024, 46(S1): 303-308. [2] 张瑞涛, 薛彬. 水下无人装备发展、应用与展望[J]. 航天电子对抗, 2024, 40(5): 59-64. doi: 10.3969/j.issn.1673-2421.2024.05.015Zhang R T, Xue B. Development, application and prospects of underwater unmanned equipment[J]. Aerospace Electronic Warfare, 2024, 40(5): 59-64. doi: 10.3969/j.issn.1673-2421.2024.05.015 [3] 杜佳璐, 李健. 欠驱动水下机器人三维轨迹跟踪有限时间预设性能控制[J]. 控制理论与应用, 2022, 39(2): 383-392. doi: 10.7641/CTA.2021.10113Du J L, LI J. Finite-time prescribed performance control for the three-dimension trajectory tracking of underactuated autonomous underwater vehicles[J]. Control Theory And Applications, 2022, 39(2): 383-392. doi: 10.7641/CTA.2021.10113 [4] Liu Y, An S, Wang L, et al. Predefined time backstepping control with an adaptive predefined time disturbance observer for underactuated AUV under unknown external disturbance[J]. Ocean Engineering, 2025, 340: 122382. doi: 10.1016/j.oceaneng.2025.122382 [5] Xu J, Sui Z, Wang W, et al. An adaptive discrete integral terminal sliding mode control method for a two-joint manipulator[J]. Processes, 2024, 12(6): 1106. doi: 10.3390/pr12061106 [6] Jokar H, Serajgah S A. A nonsingular fast terminal sliding mode control scheme for robust trajectory tracking of the underactuated EvoBot modular mobile robot in the vertical plane[J]. ISA Trans, 2025, 165: 83-97. doi: 10.1016/j.isatra.2025.06.013 [7] Budiyono A. Model predictive control for autonomous underwater vehicle[J]. Indian Journal of Geo-marine Sciences, 2011, 40(2): 191-199. [8] Shen C, Shi Y, Buckham B. Trajectory tracking control of an autonomous underwater vehicle using Lyapunov-based model predictive control[J]. IEEE Transactions on Industrial Electronics, 2018, 65(7): 5796-5805. doi: 10.1109/TIE.2017.2779442 [9] Heshmati-alamdari S, Karras G C, Marantos P, et al. A robust model predictive control approach for underwater robotic vehicles[J]. IEEE Trans Control Syst Technol, 2020, 28(6): 2352-2363. doi: 10.1109/TCST.2019.2939248 [10] Yang H, Li B, Zuo Z, et al. Tube-based MPC for LPV systems with external disturbances using interval predictors[J]. IEEE Transactions on Industrial Informatics, 2024, 20(3): 3060-3069. doi: 10.1109/TII.2023.3300472 [11] 王翔, 吴益飞, 高阳, 等. 基于扩展状态观测器的伺服系统特征建模和自适应滑模控制[J]. 南京理工大学学报, 2019, 43(3): 261-268+274. doi: 10.14177/j.cnki.32-1397n.2019.43.03.002Wang X, Wu Y F, Gao Y. et al. Extended state observer-based characteristic modeling and adaptive sliding-mode control for servo systems[J]. Journal Of Nanjing University Of Science And Technology, 2019, 43(3): 261-268+274. doi: 10.14177/j.cnki.32-1397n.2019.43.03.002 [12] Han J Q. From PID to active disturbance rejection control[J]. IEEE Trans. Ind. Electron., 2009, 56(3): 900-906. doi: 10.1109/TIE.2008.2011621 [13] Cui R, Chen L, Yang C, et al. Extended state observer-based integral sliding mode control for an underwater robot with unknown disturbances and uncertain nonlinearities[J]. IEEE Trans Ind Electron, 2017, 64(8): 6785-6795. doi: 10.1109/TIE.2017.2694410 [14] Peng Z, Wang J, Han Q. Path-following control of autonomous underwater vehicles subject to velocity and input constraints via neurodynamic optimization[J]. IEEE Trans Ind Electron, 2019, 66(11): 8724-8732. doi: 10.1109/TIE.2018.2885726 [15] Kong S, Sun J, Qiu C, et al. ESO-based controller with model predictive governor for 3D trajectory tracking of underactuated underwater vehicles[J]. IEEE Transactions on Industrial Informatics, 2021, 17(8): 5577-5588. -

 下载:






 点击查看大图
计量
- 文章访问数: 3
- HTML全文浏览量: 2
- PDF下载量: 0
- 被引次数: 0