

Research on Sensorless Heavy-Load Startup Method for Subsea Long-Cable-Fed PMSM
-
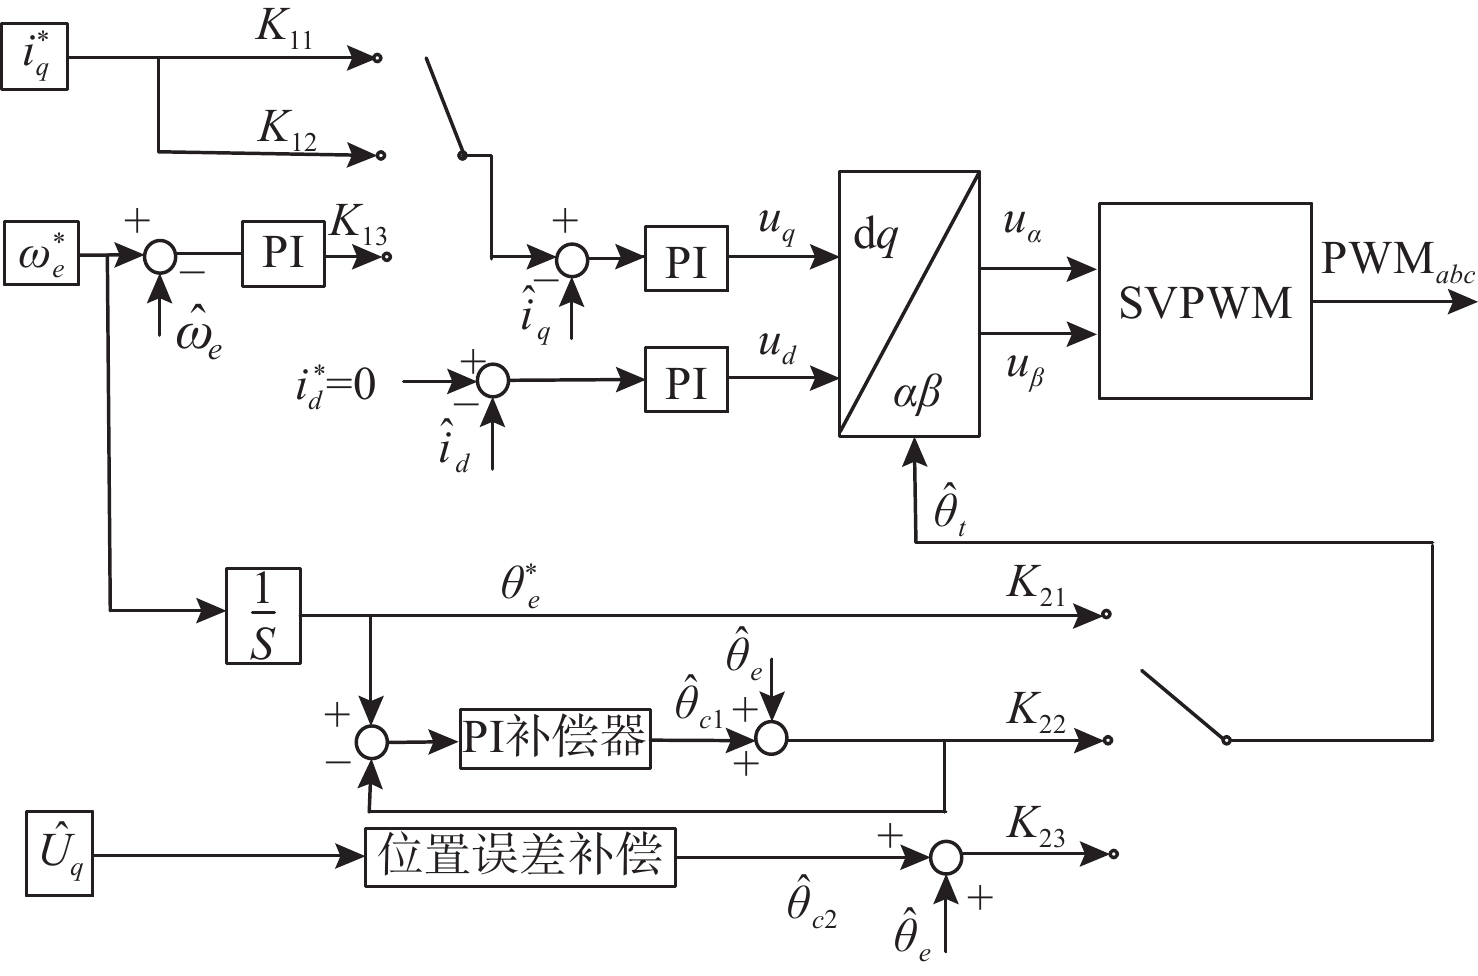
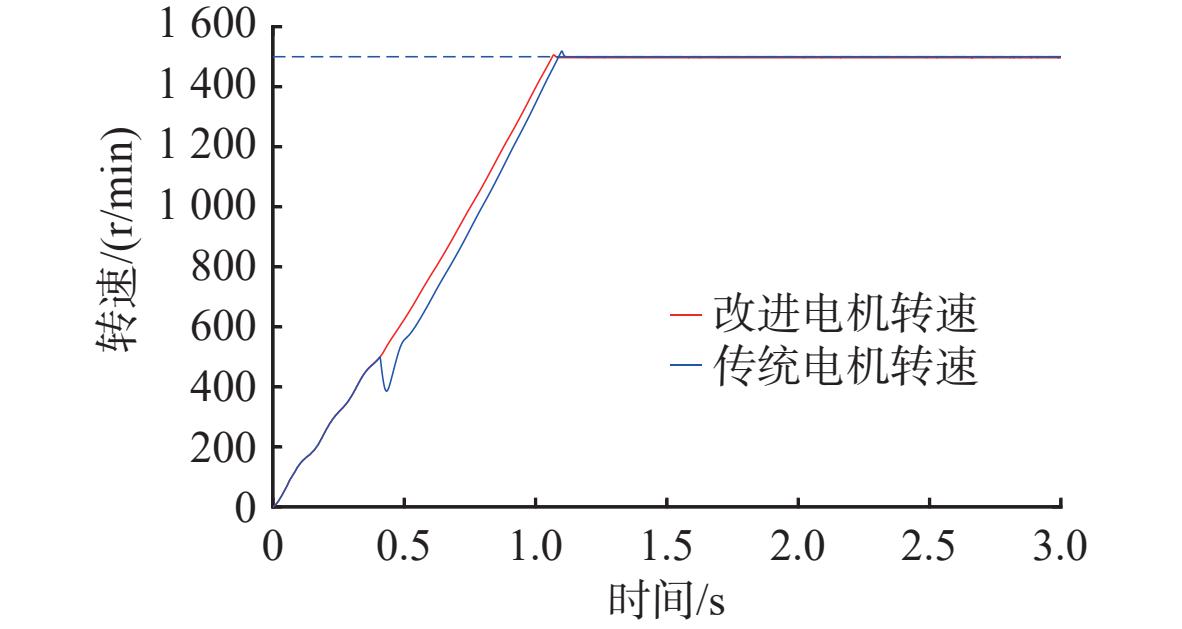
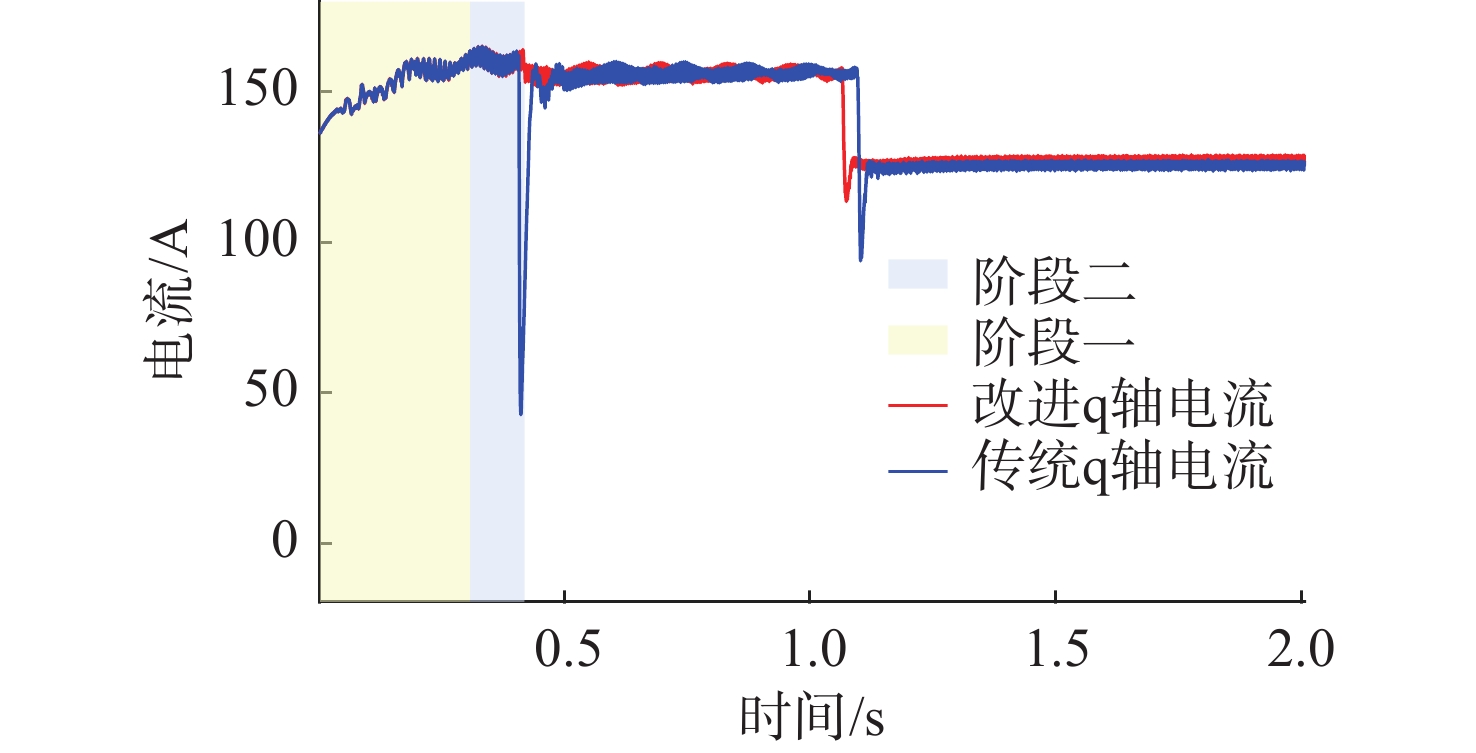
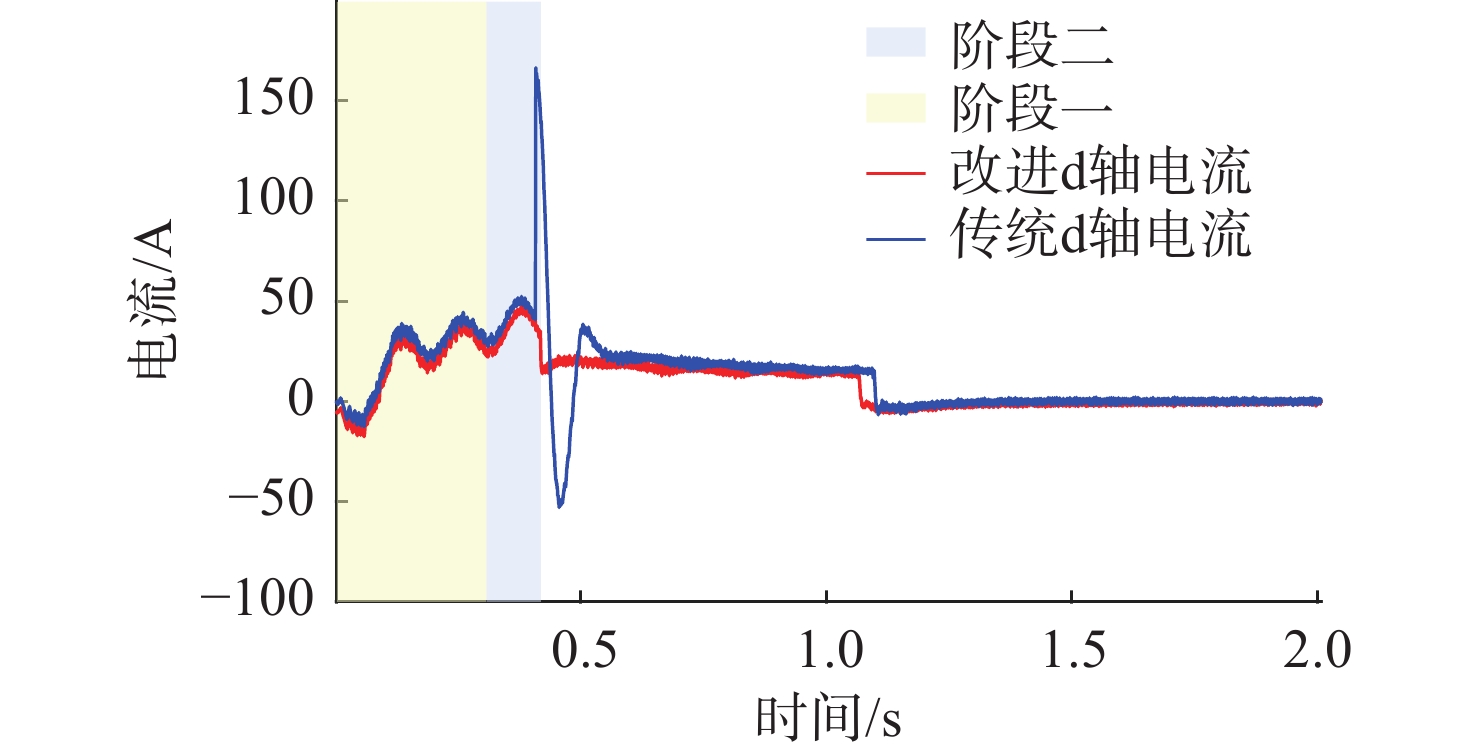
摘要: 针对水面母船通过长脐带缆驱动水下永磁同步电机的重载起动困难和过渡过程不稳定等问题, 提出一种基于电机侧转子位置估计和三阶段平滑切换的新型无位置传感器控制方案。首先, 构建“水下观测-水上控制”的分布式架构, 减少电流电压采样的失真度, 从而提高转子位置估计的准确性; 其次, 设计包含I-f流频比加速、给定坐标系预同步及闭环误差在线补偿的三阶段起动和切换方法。最后, 仿真结果表明, 相较于两阶段切换策略, 文中方法在重载工况下, 由开环I-f控制切换至闭环转速控制时, 转速振荡峰值、q轴电流振荡幅值分别下降83.7%、88.5%, 有效改善了长电缆重载起动的平稳性, 提升了系统可靠性与鲁棒性。Abstract: To address the challenges of heavy-load startup and smooth transition in subsea permanent magnet synchronous motors driven by surface vessels via long umbilical cables, this paper proposes a novel sensorless control scheme based on motor-side rotor position estimation and a three-stage smooth transition strategy. First, a distributed architecture comprising "subsea observation and surface control" is constructed. This architecture effectively mitigates the distortion in current and voltage sampling, thereby enhancing the accuracy of rotor position estimation. Second, a three-stage startup method is designed, encompassing I-f open-loop acceleration, given reference frame pre-synchronization, and online compensation of closed-loop errors. Simulation results indicate that the proposed strategy significantly outperforms the conventional two-stage switching method during the handover from open-loop I-f control to closed-loop speed control. Specifically, under heavy load conditions, the peak speed oscillation and the q-axis current ripple amplitude are mitigated by approximately 83.7% and 88.5%, respectively. Consequently, the starting stability under long-cable and heavy-load conditions is markedly improved, further bolstering system reliability and robustness.
-
Key words:
- sensorless control /
- I-f startup /
- long-cable-fed /
- smooth transition
-
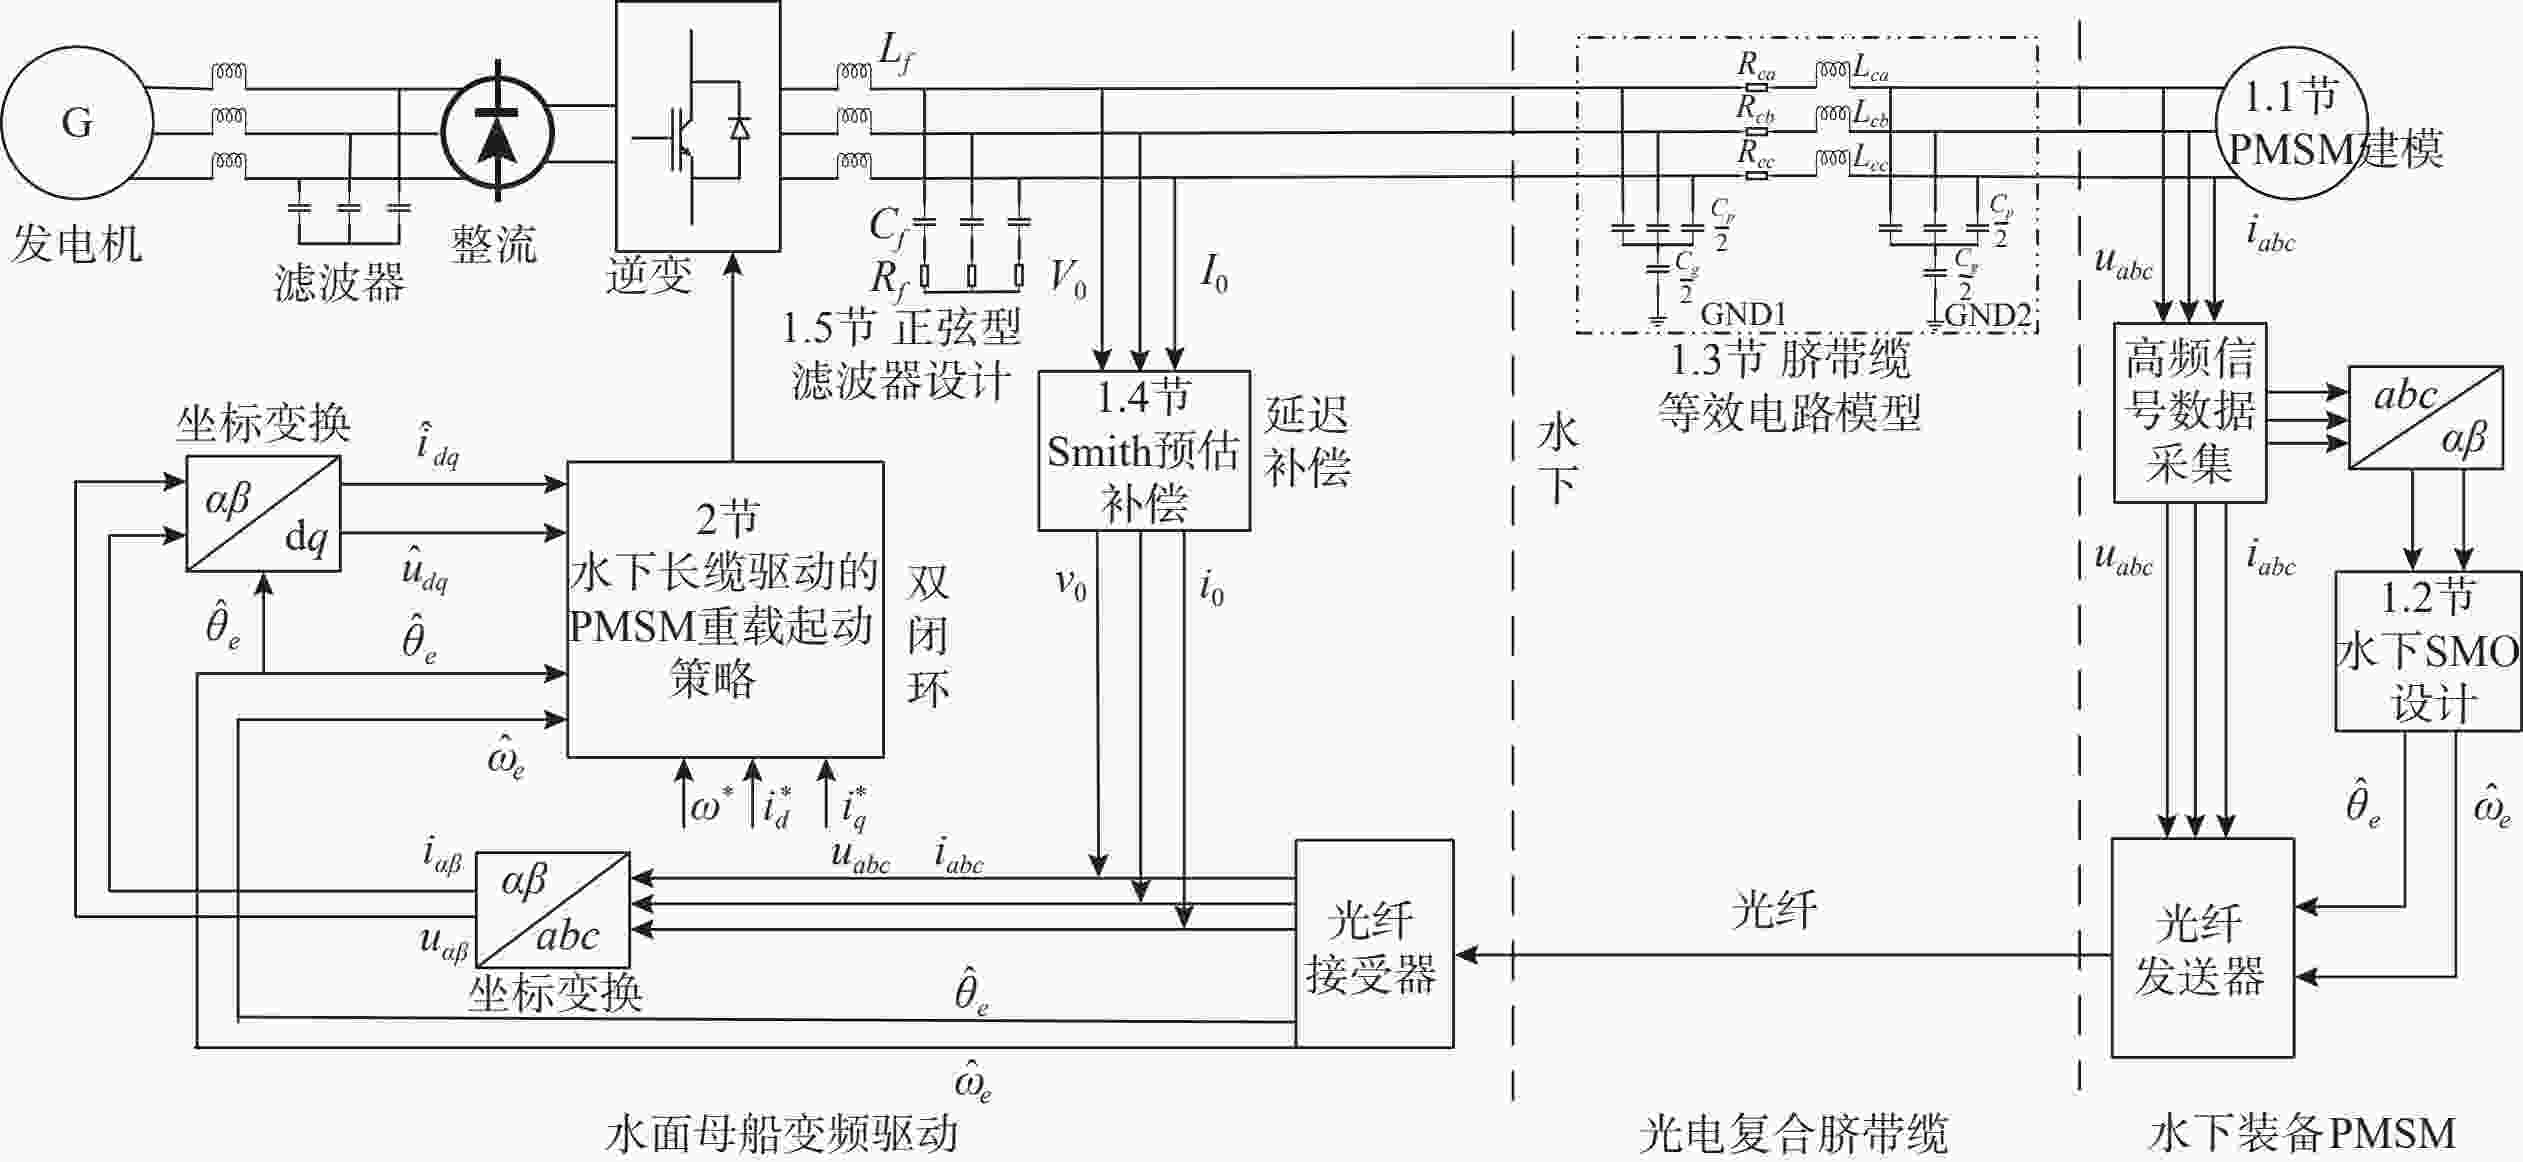
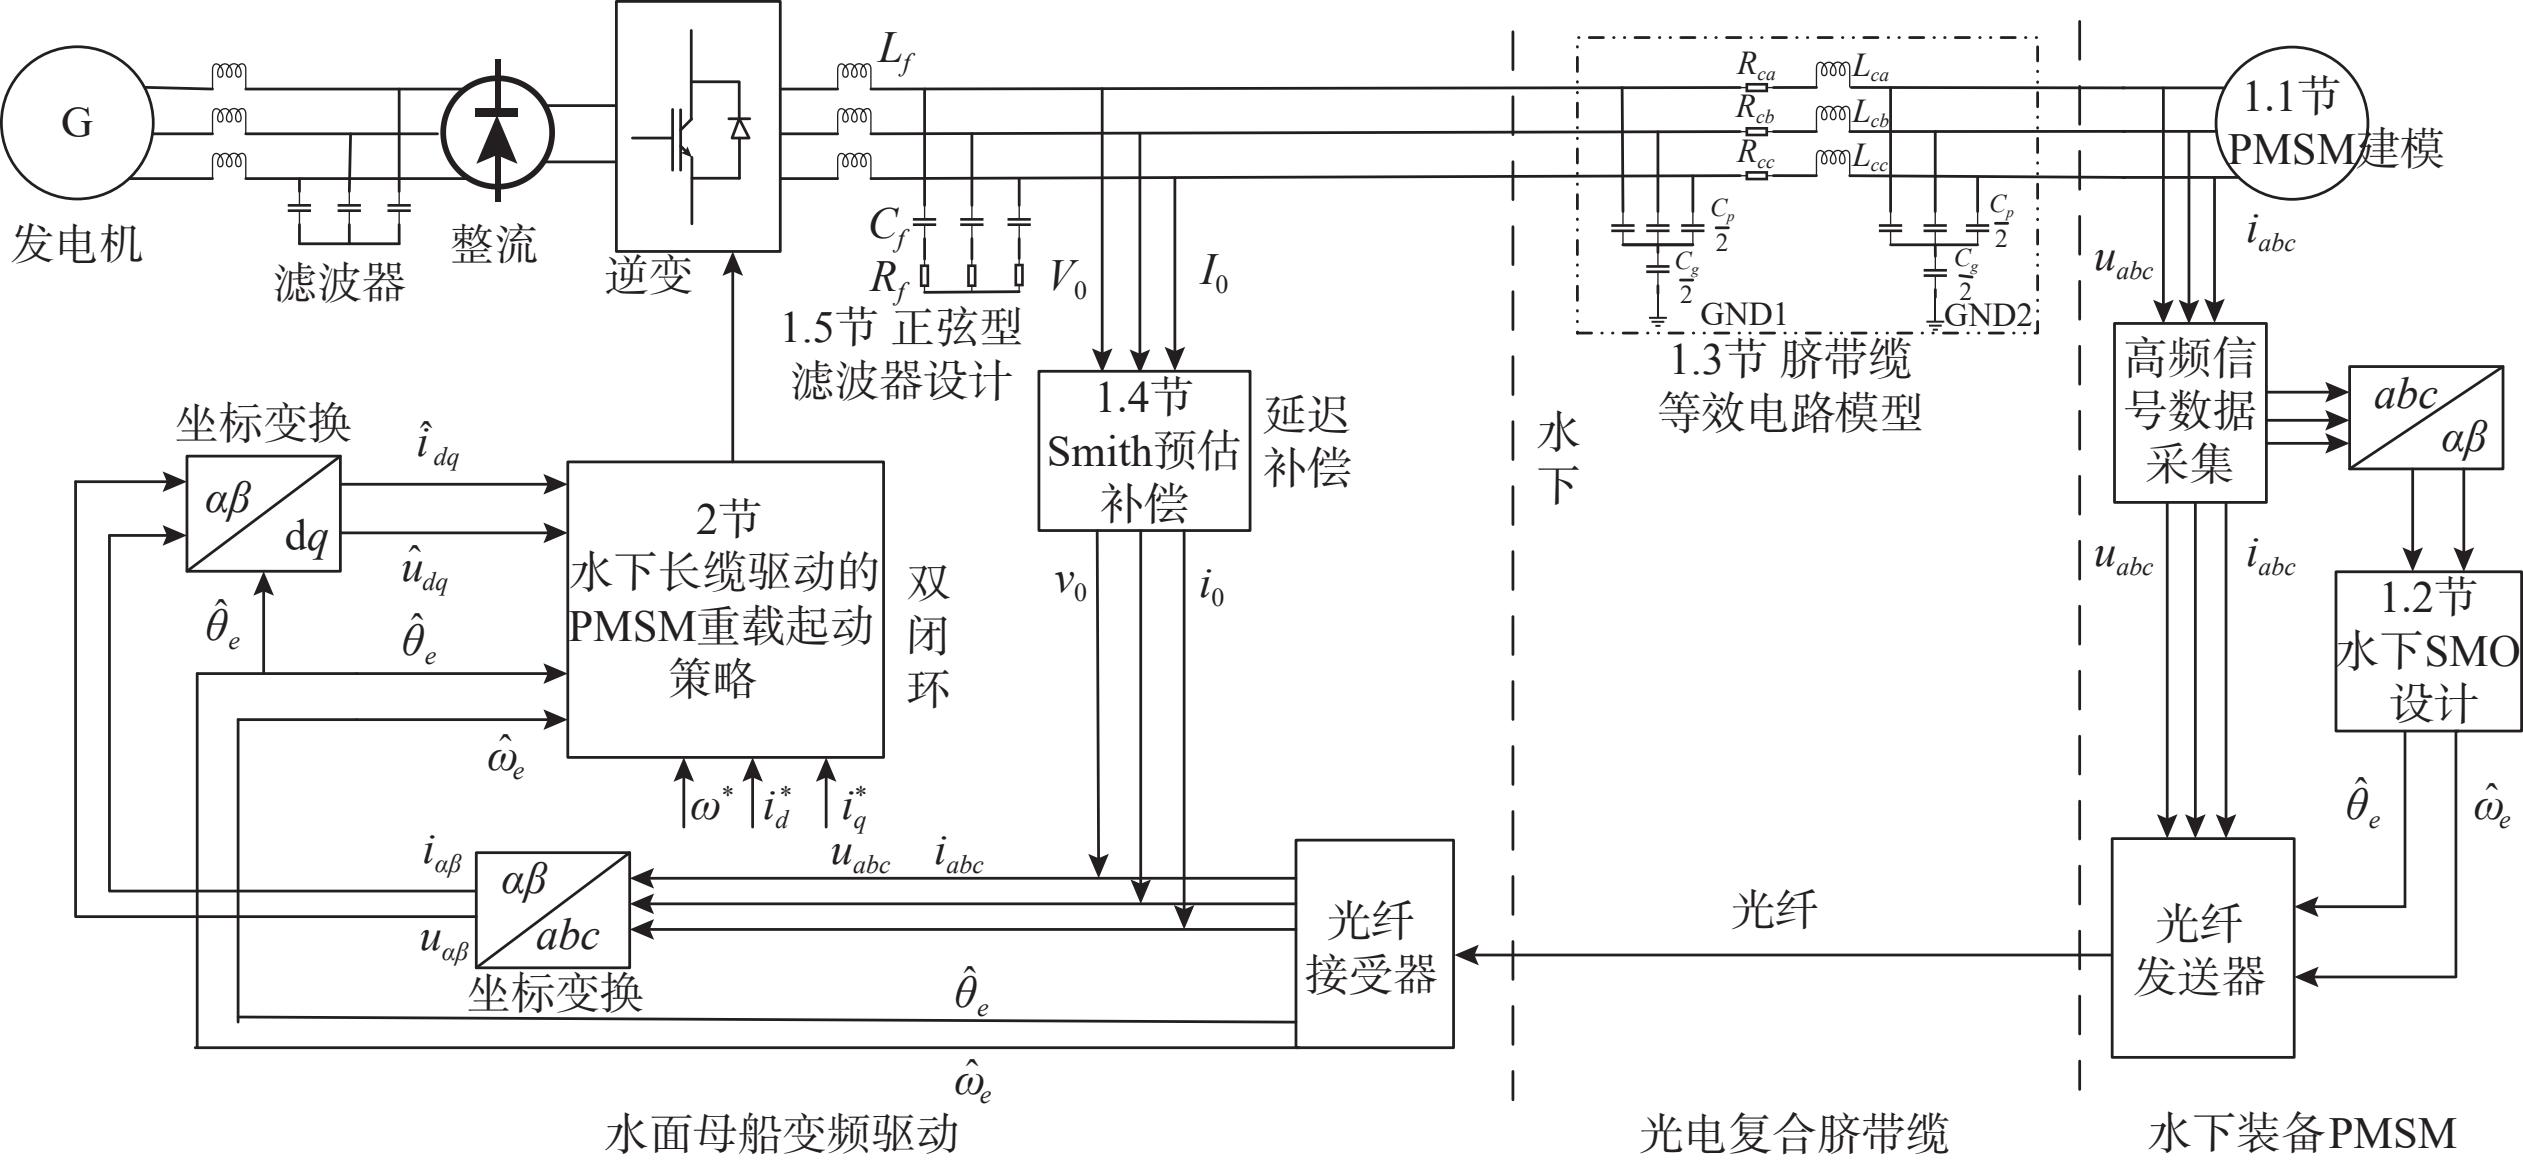
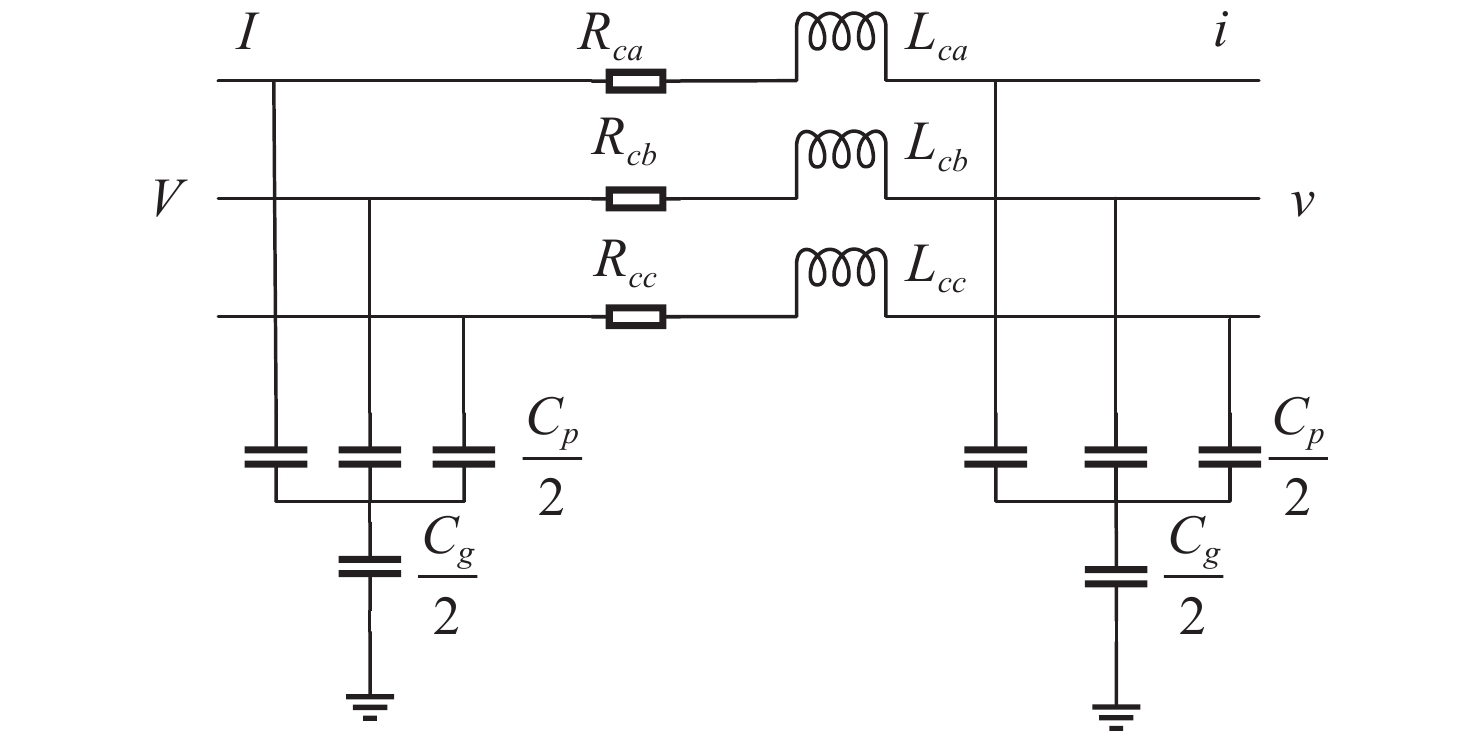
图 1 适用于深海作业的具有长电缆连接PMSM驱动系统
Figure 1. PMSM drive system with long cable connection for deep-sea operation
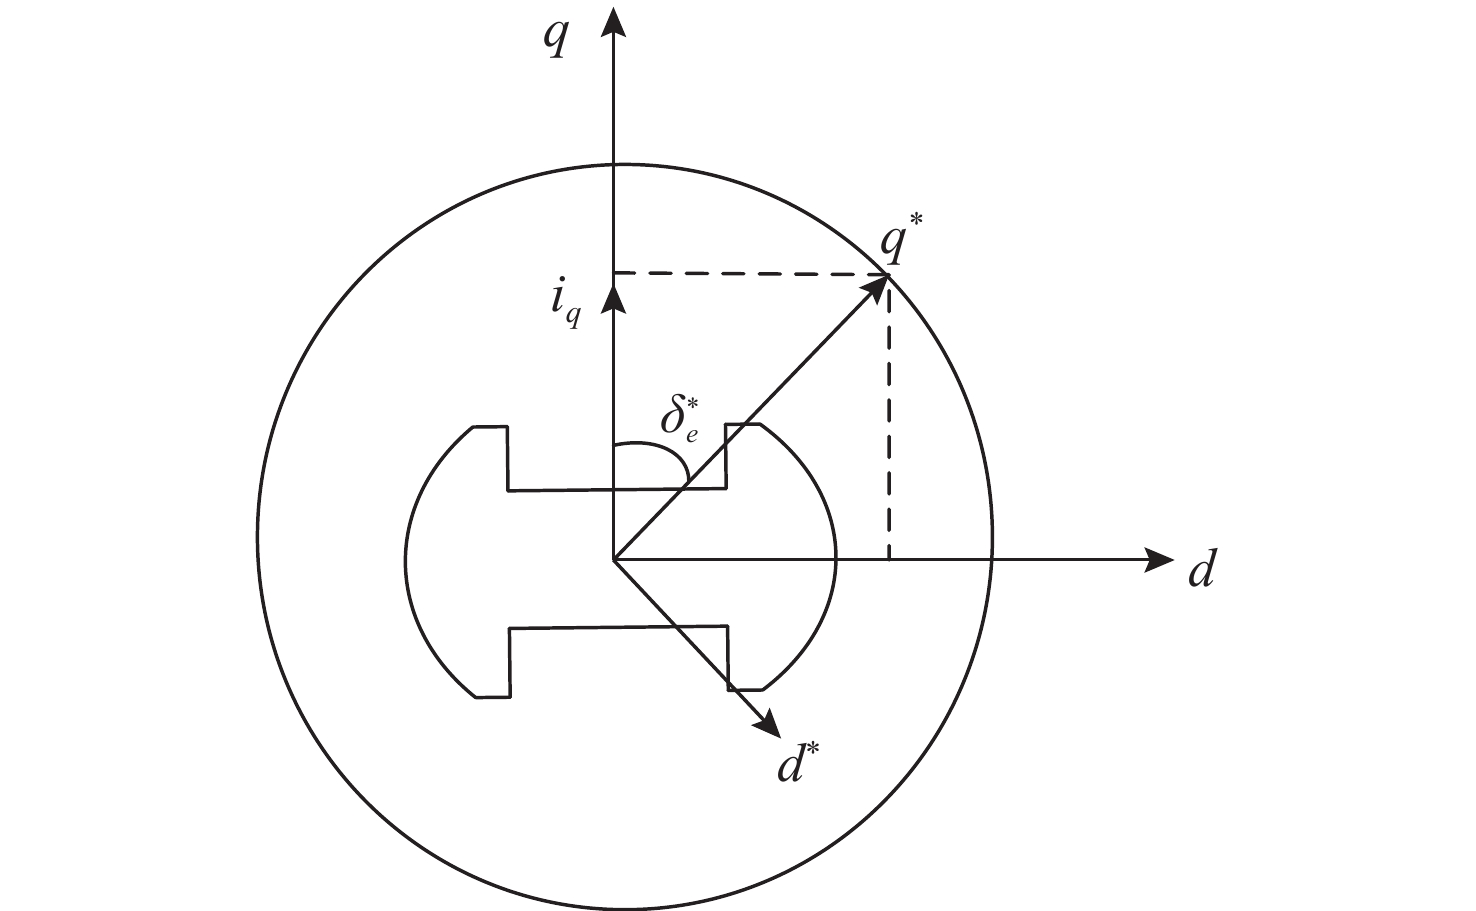
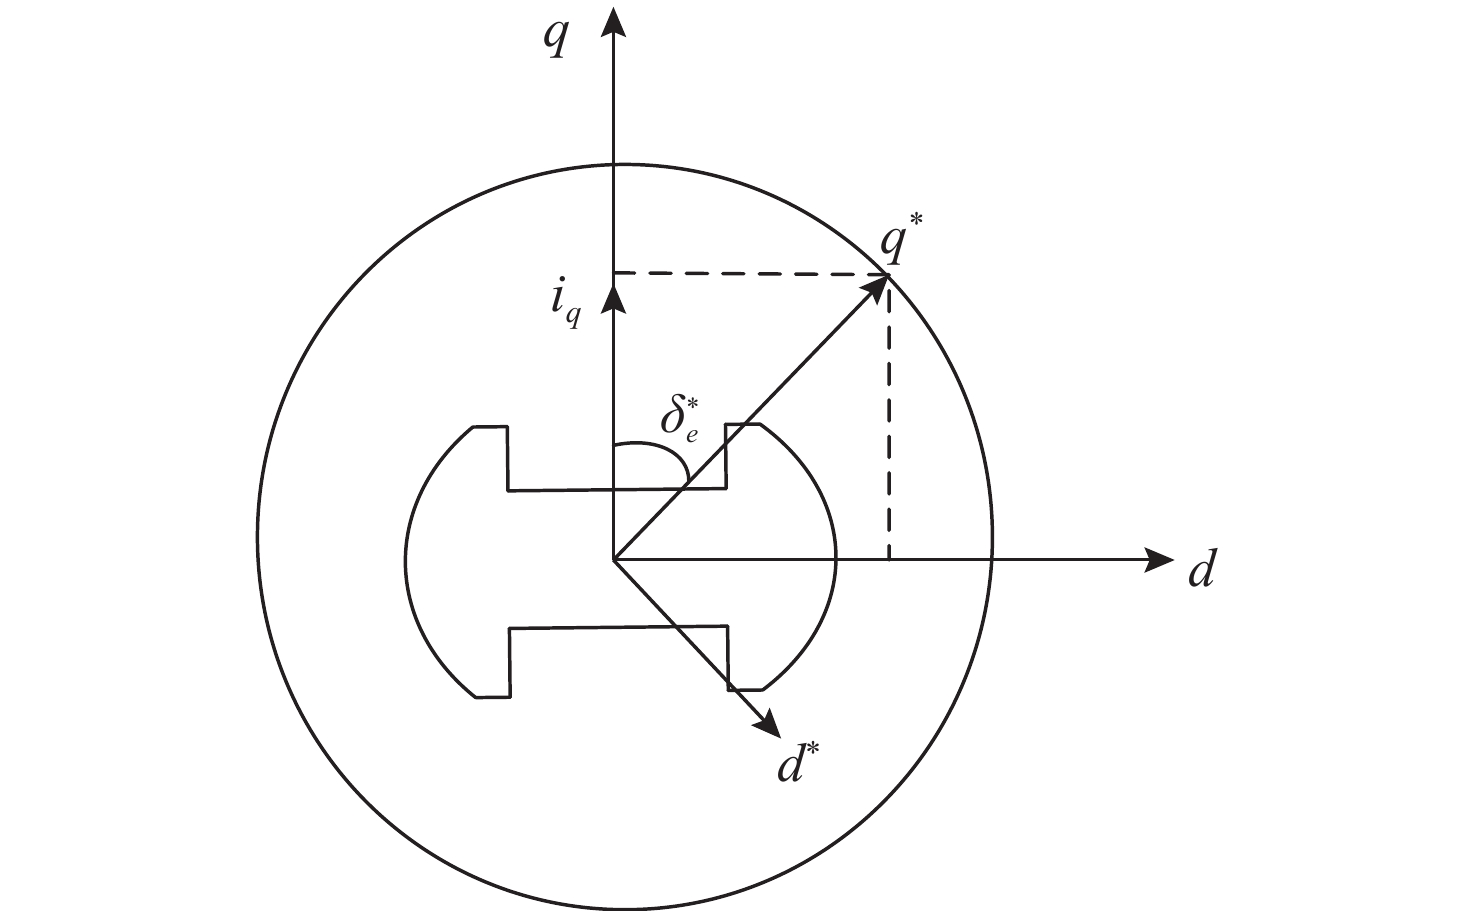
图 4 阶段1的给定同步d*-q*参考坐标系和实际转子d-q坐标系的关系图
Figure 4. Relationship diagram between the given synchronous d*-q* reference frame and the actual rotor d-q frame in stage 1
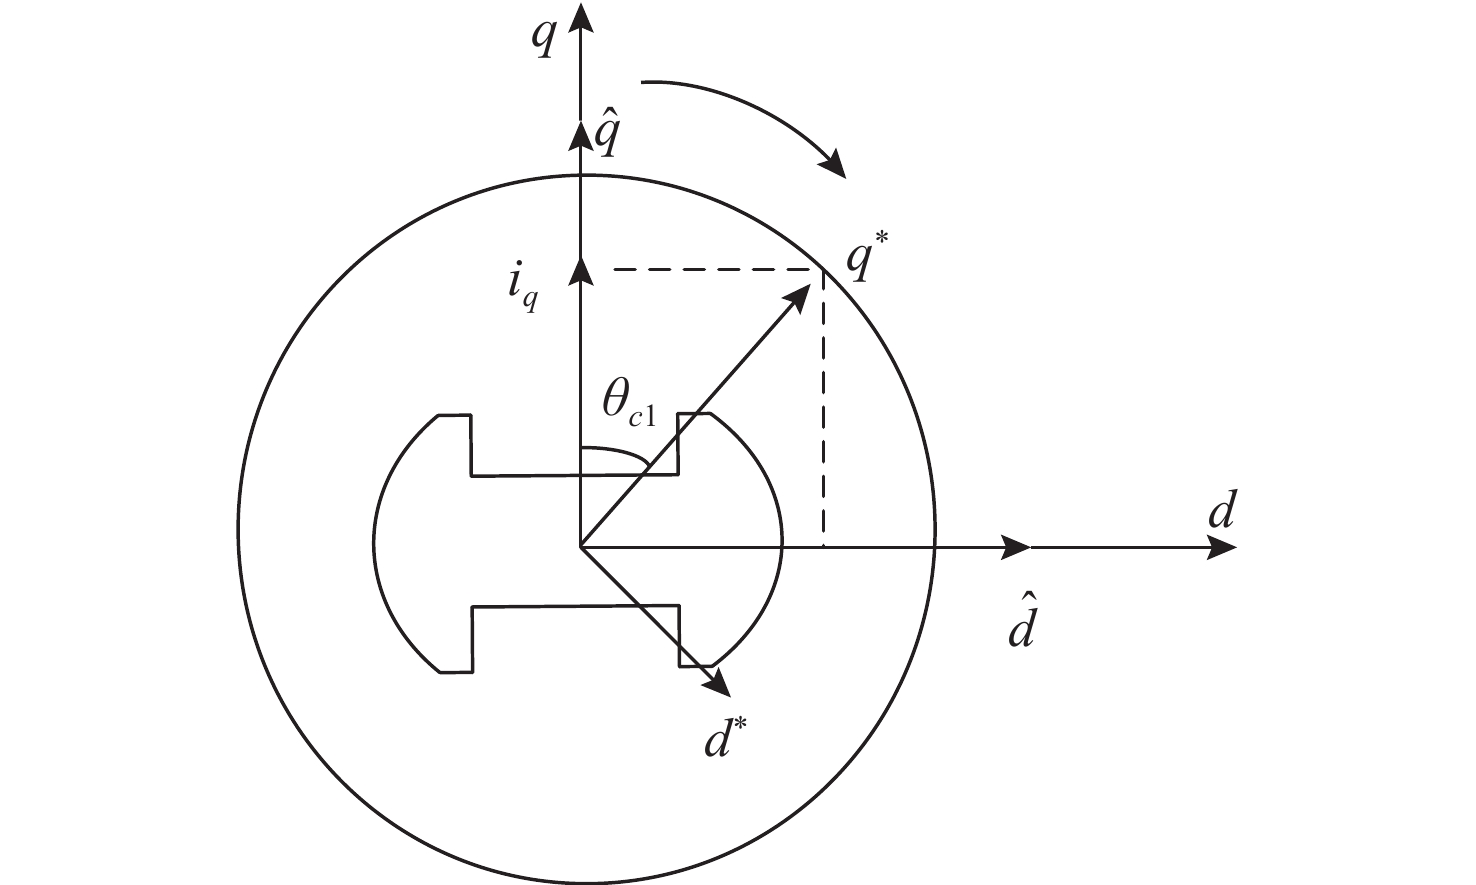
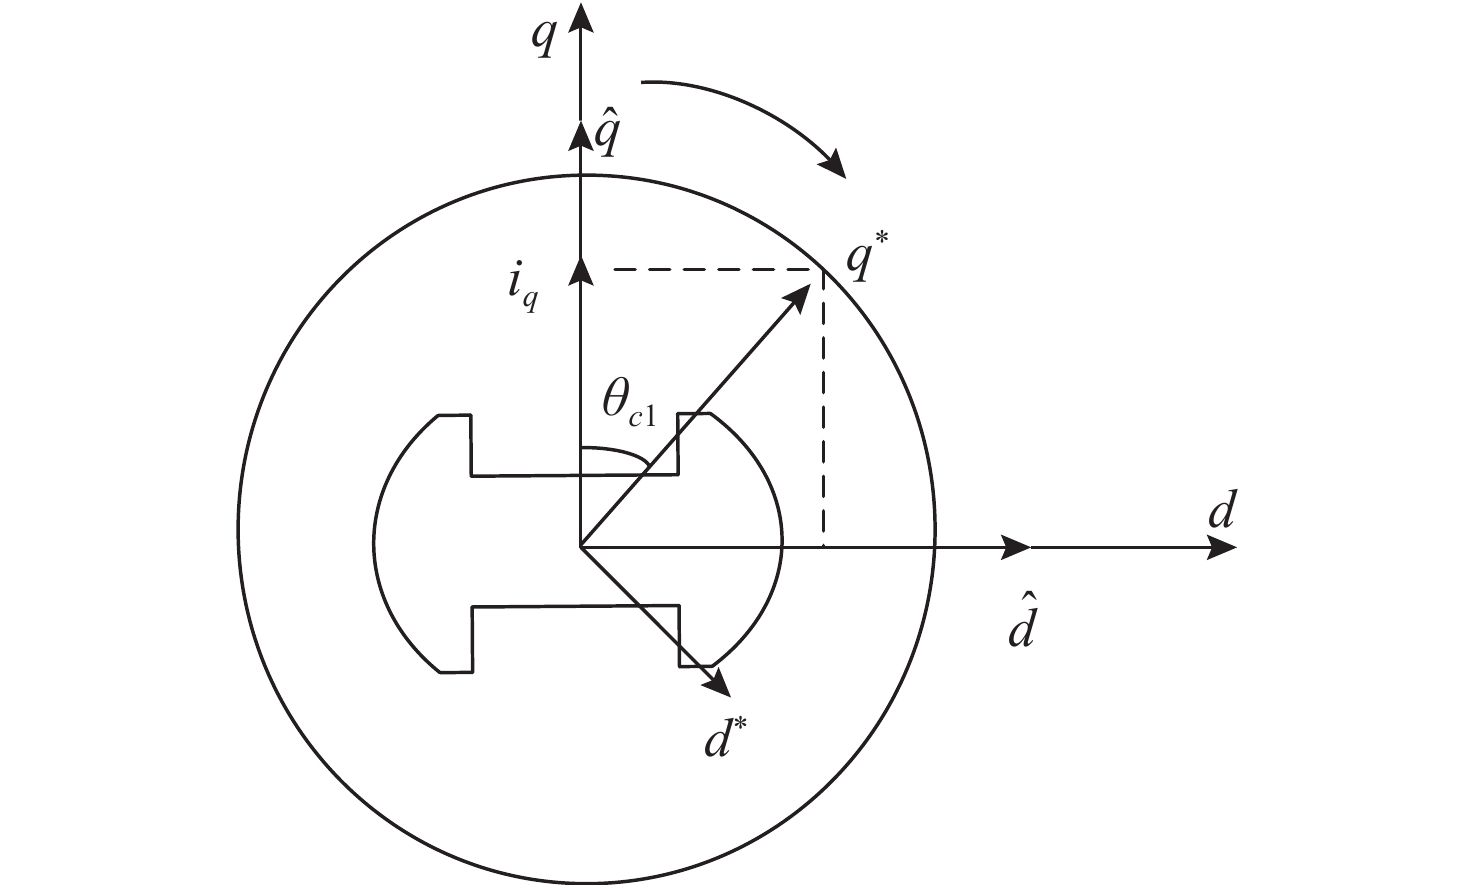
图 5 阶段2的给定同步d*-q*参考坐标系、实际转子d-q坐标系和估计$ \hat{\mathrm{d}} $-$ \hat{\mathrm{q}} $坐标系的关系图
Figure 5. Relationship diagram between the given synchronous d*-q* reference frame, the actual rotor d-q frame, and the estimated $ \hat{\mathbf{d}} $-$ \hat{\mathbf{q}} $frame in stage 2
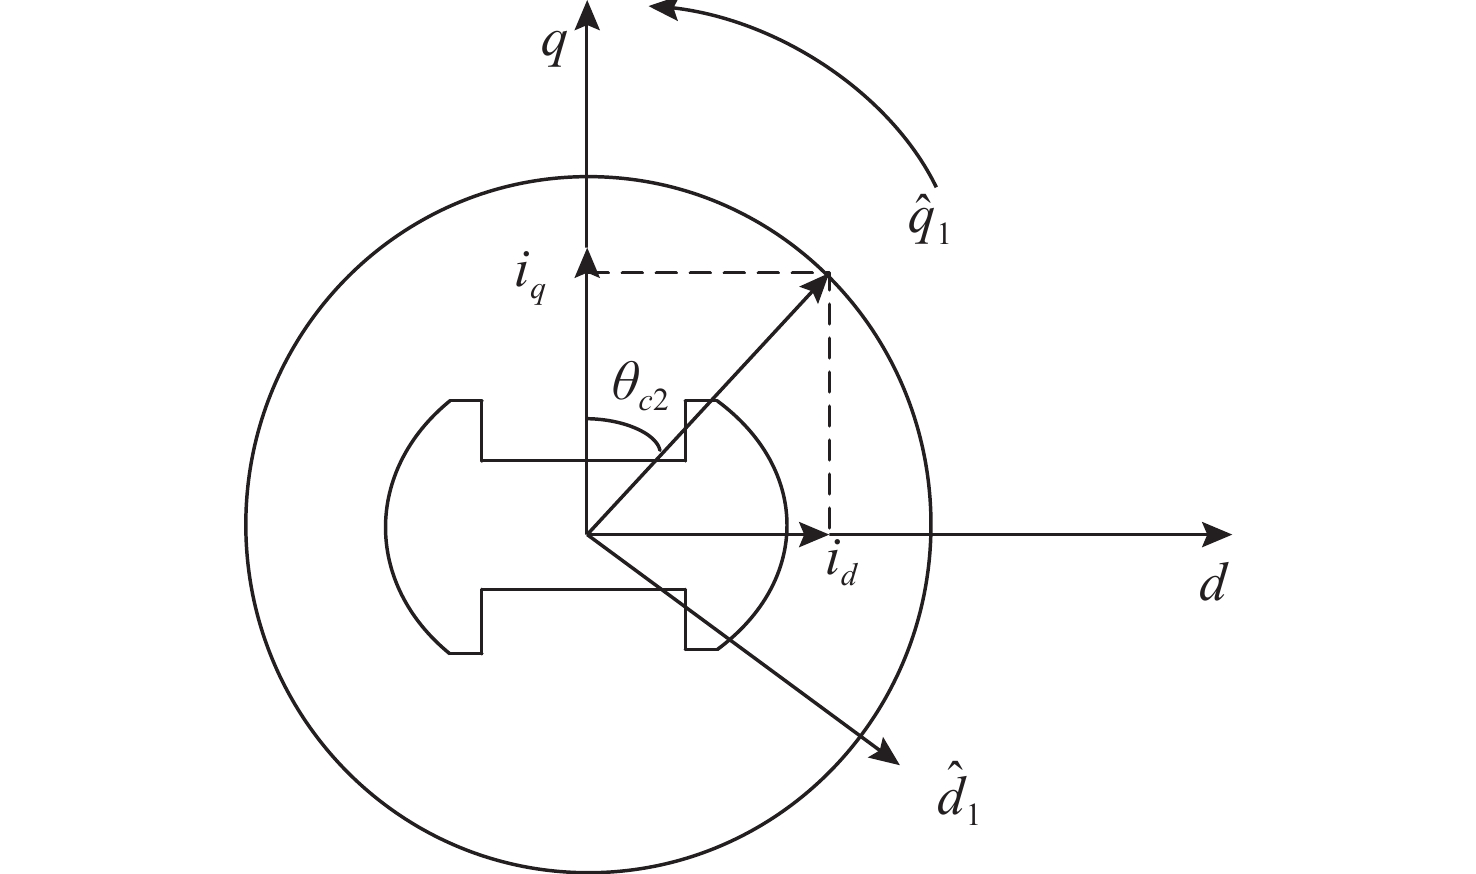
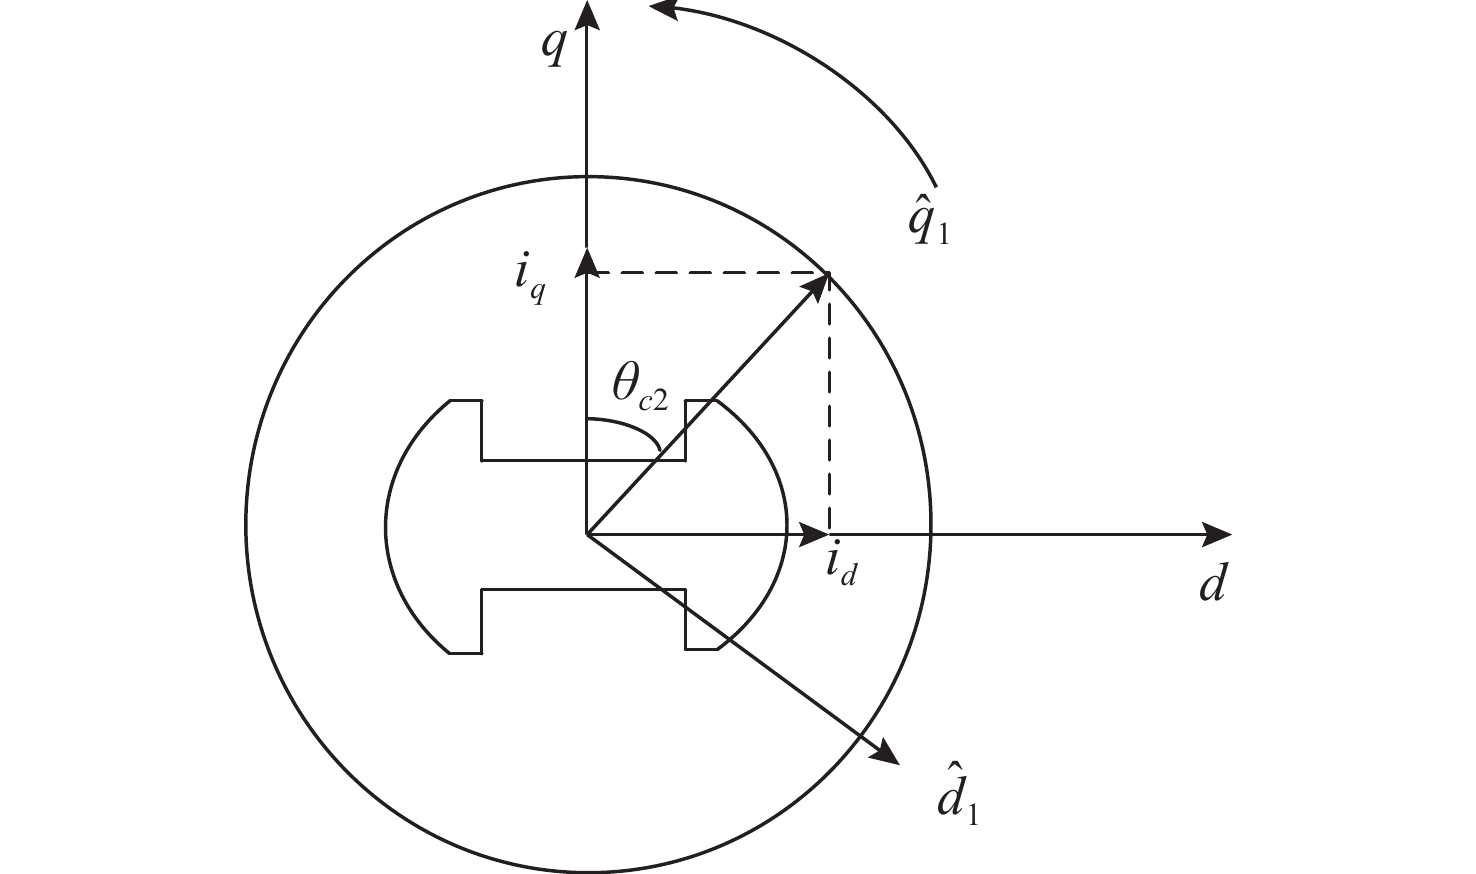
图 6 阶段3的给定同步d*-q*参考坐标系和$ \hat{\mathrm{d}} $-$ \hat{\mathrm{q}} $估计坐标系的关系图
Figure 6. Relationship diagram between the virtual synchronous d*-q* reference frame and the $ \hat{\mathbf{d}} $-$ \hat{\mathbf{q}} $ estimated frame in stage 3
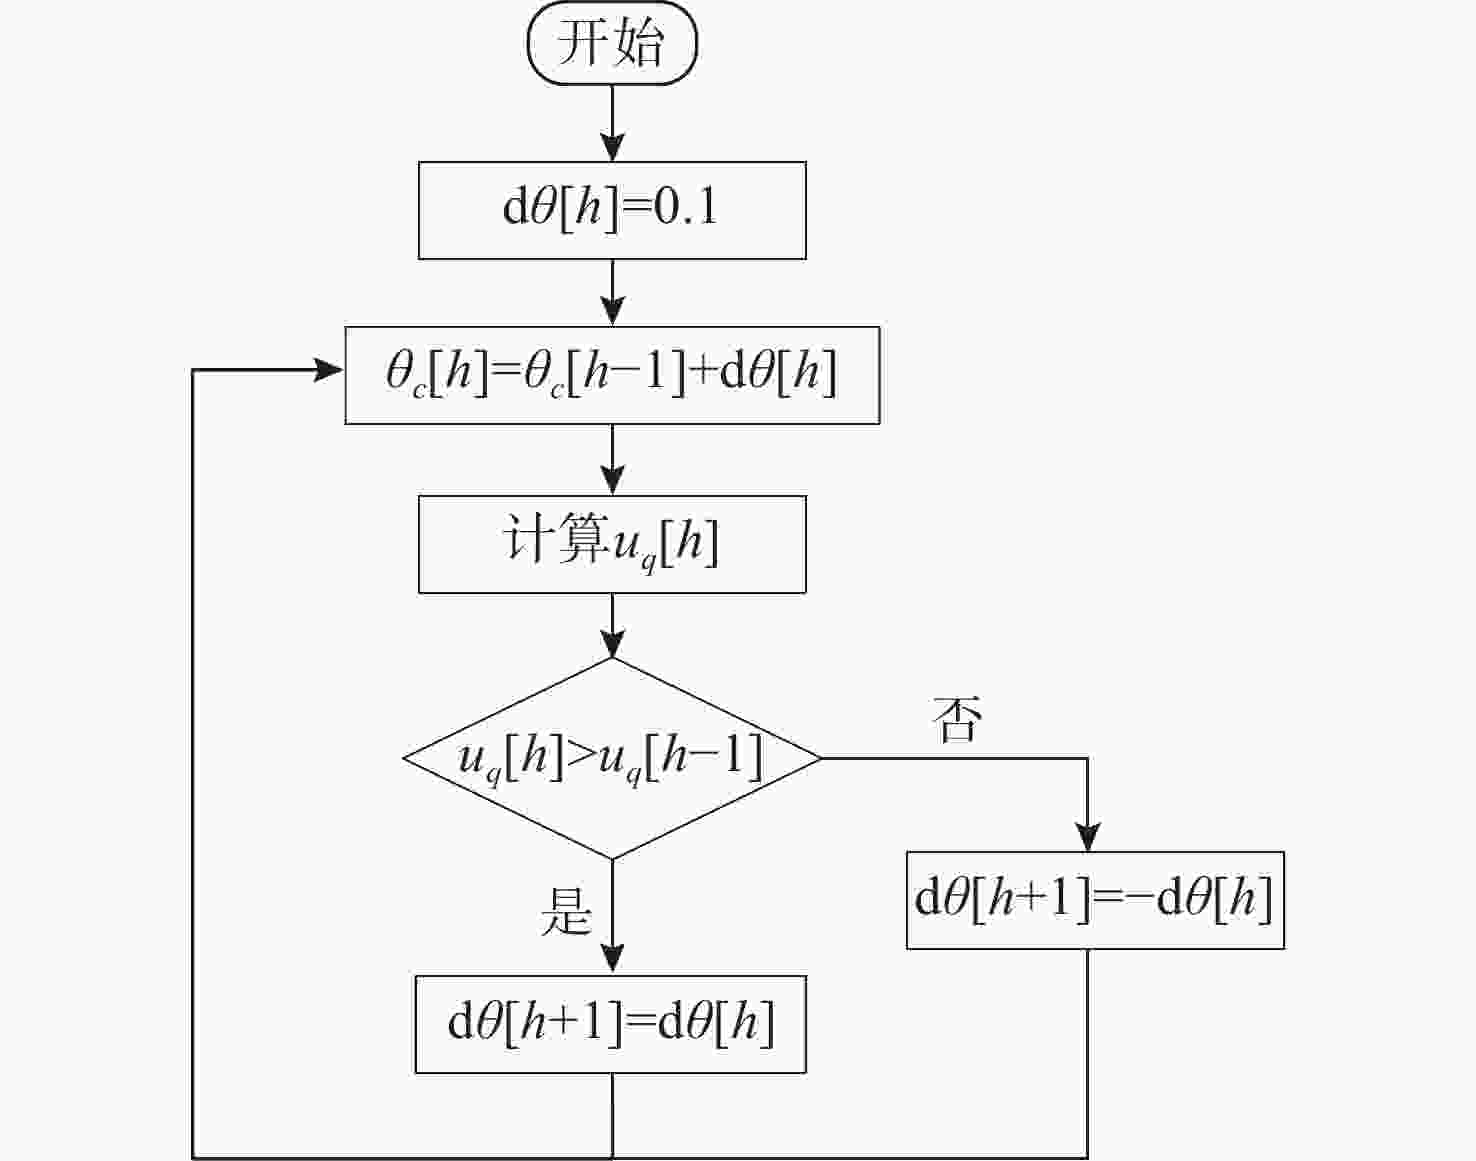
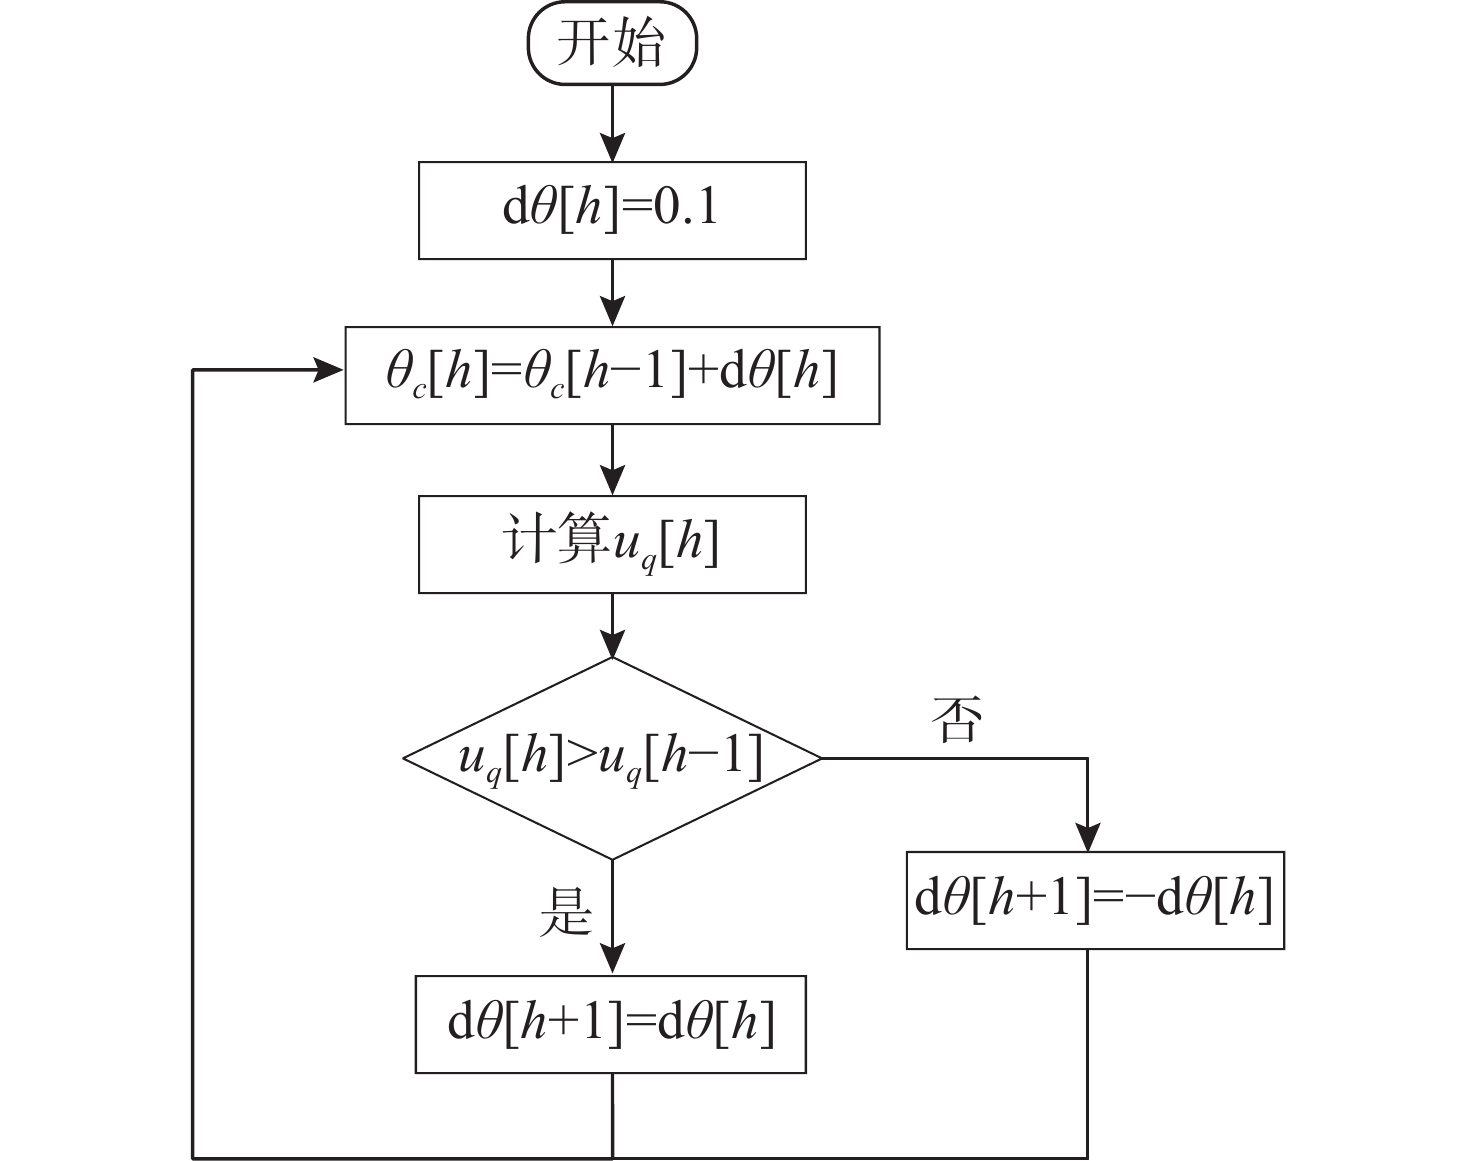
图 7 位置误差补偿策略算法流程
Figure 7. Flow chart of the proposed position error compensation algorithm
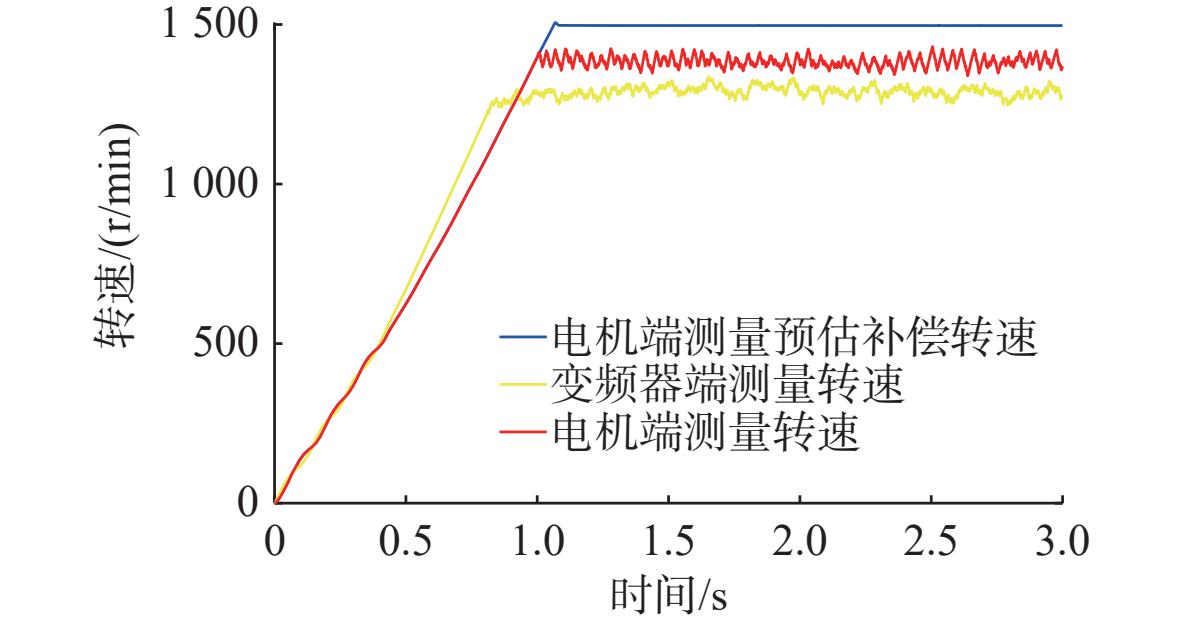
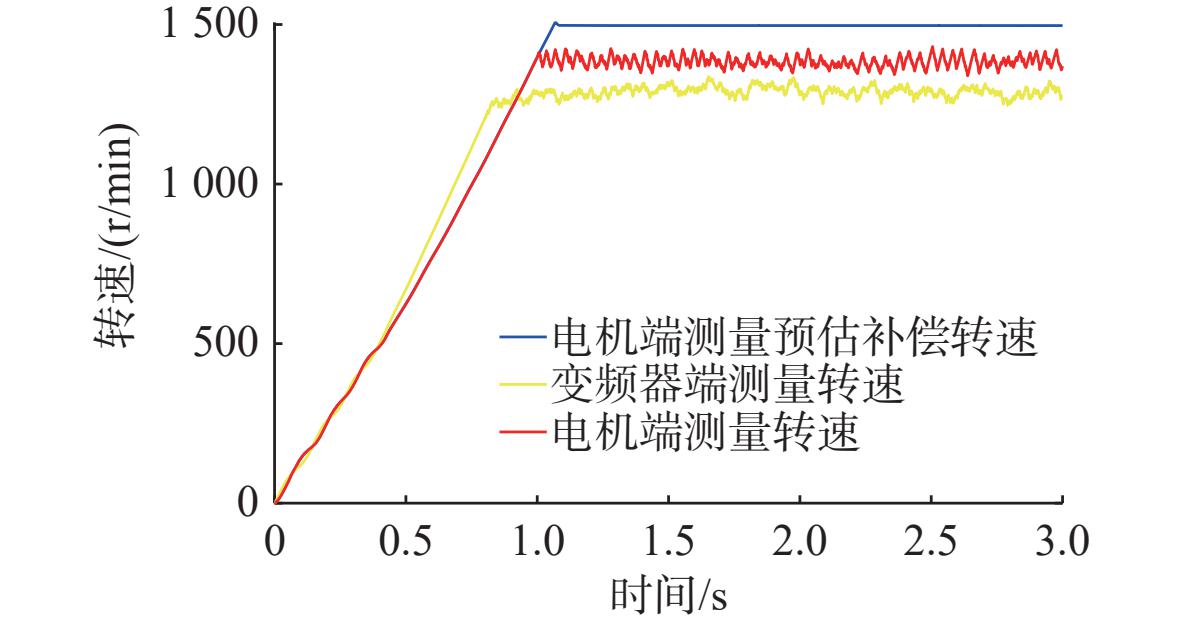
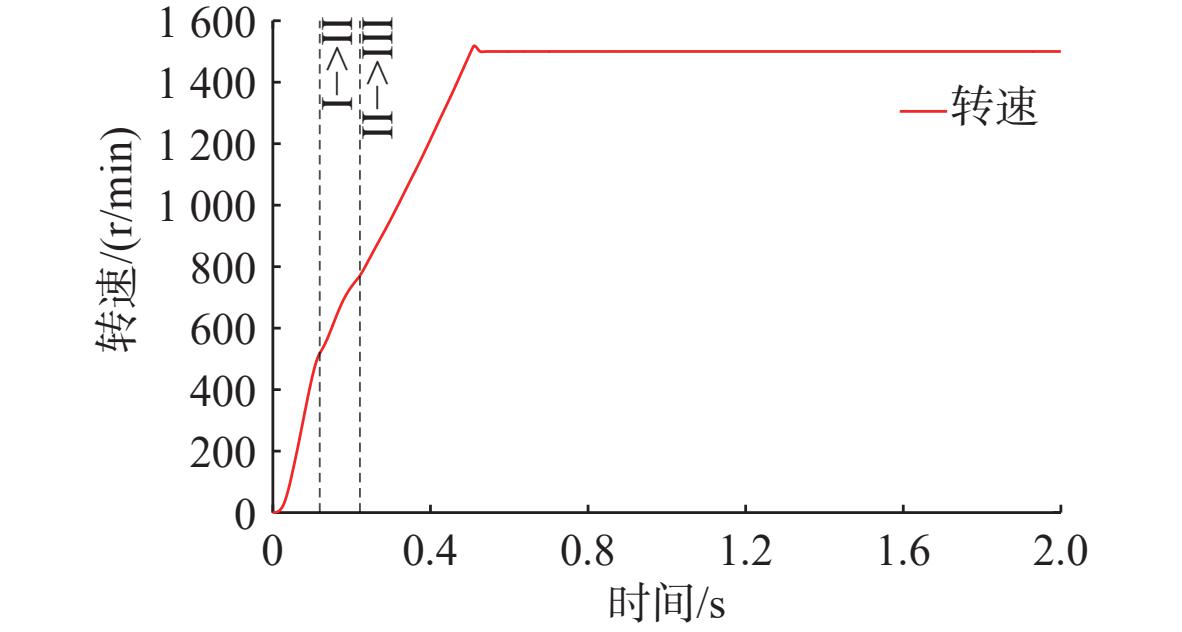
图 8 不同位置方法测量信号闭环控制的电机转速对比示意图
Figure 8. Comparison diagram of motor speed measured by different position methods
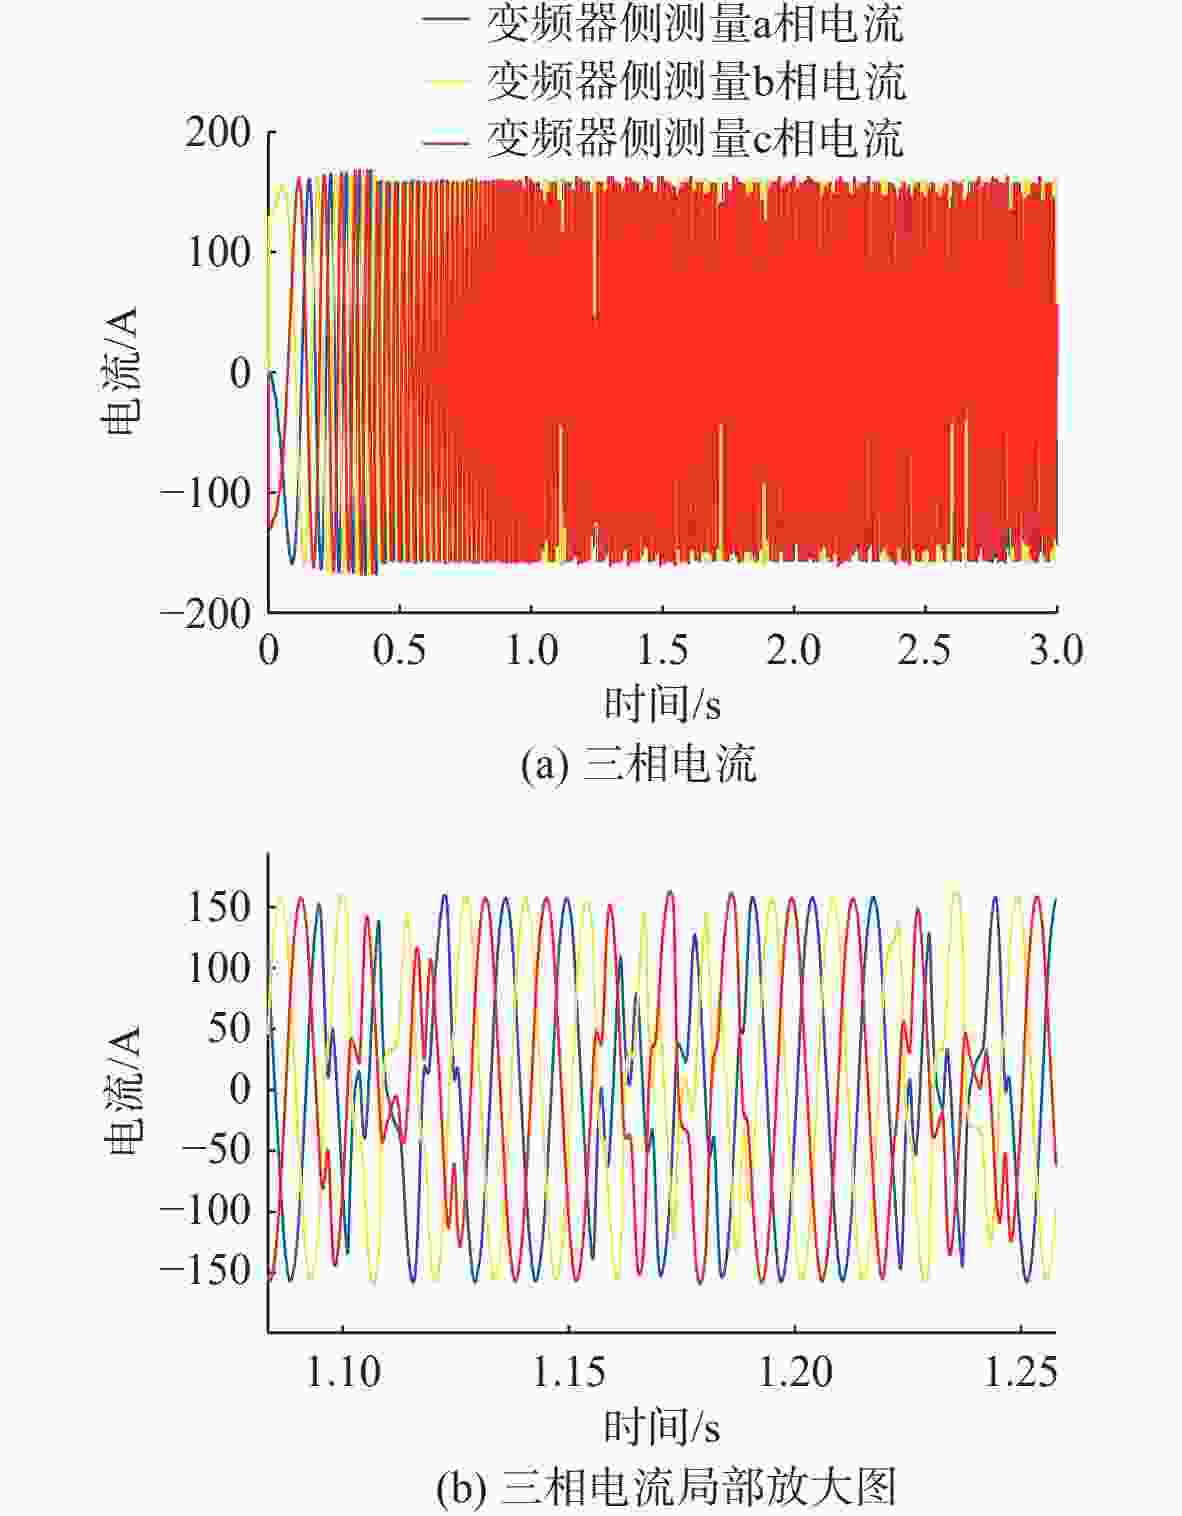
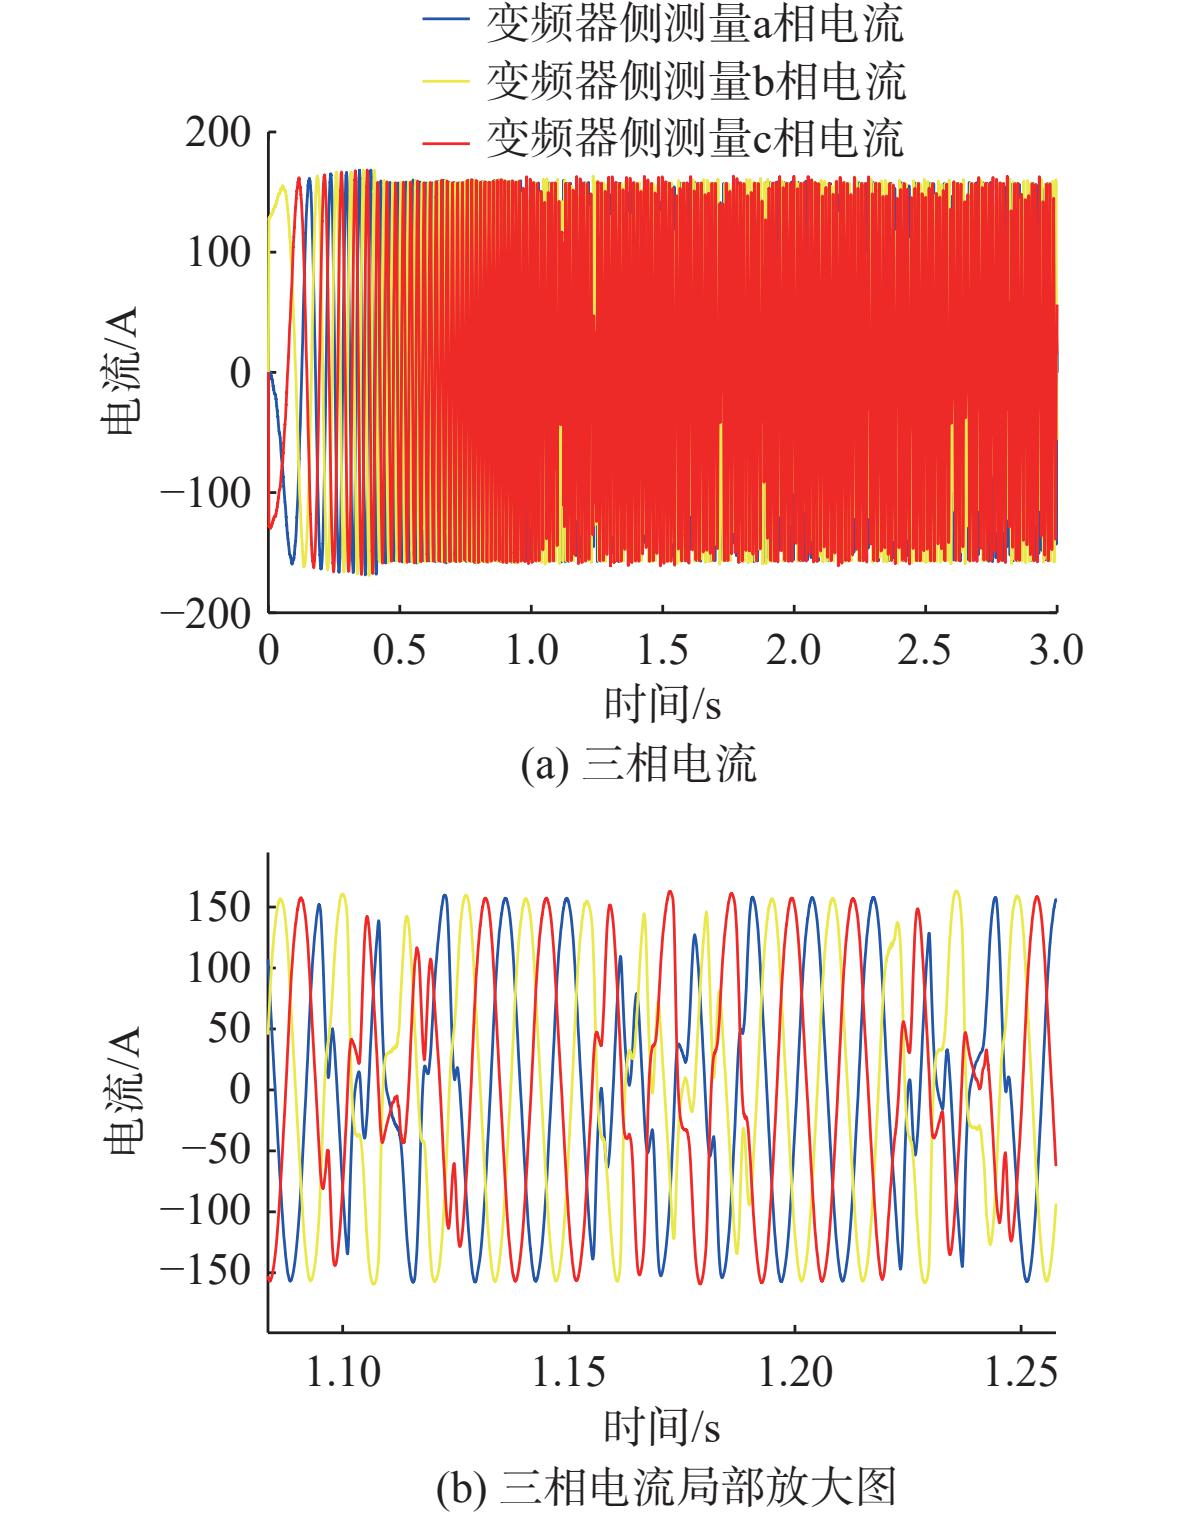
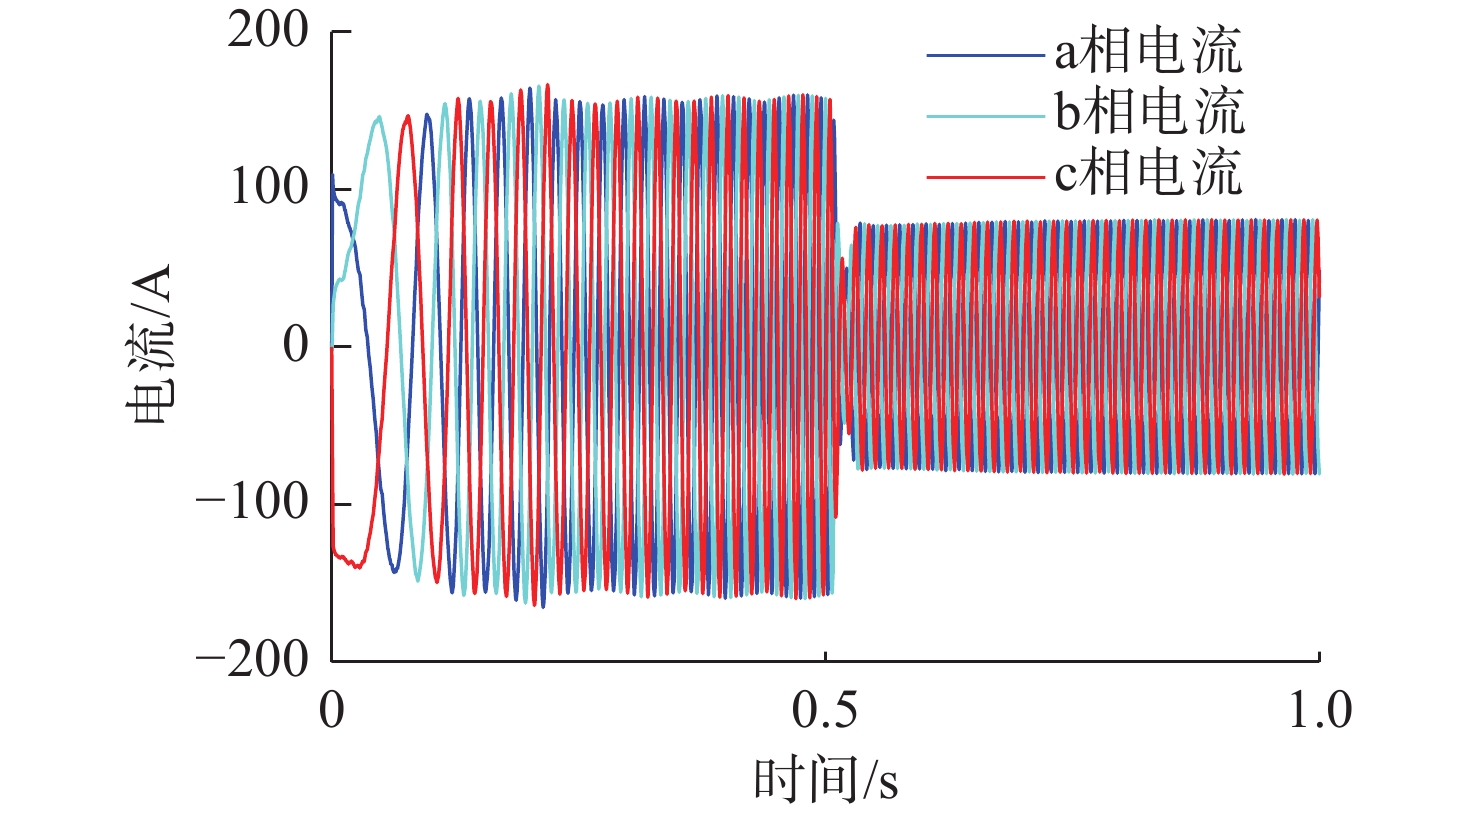
图 9 变频器侧测量信号闭环控制的电机三相电流
Figure 9. Three-phase currents of the motor measured at the cable input
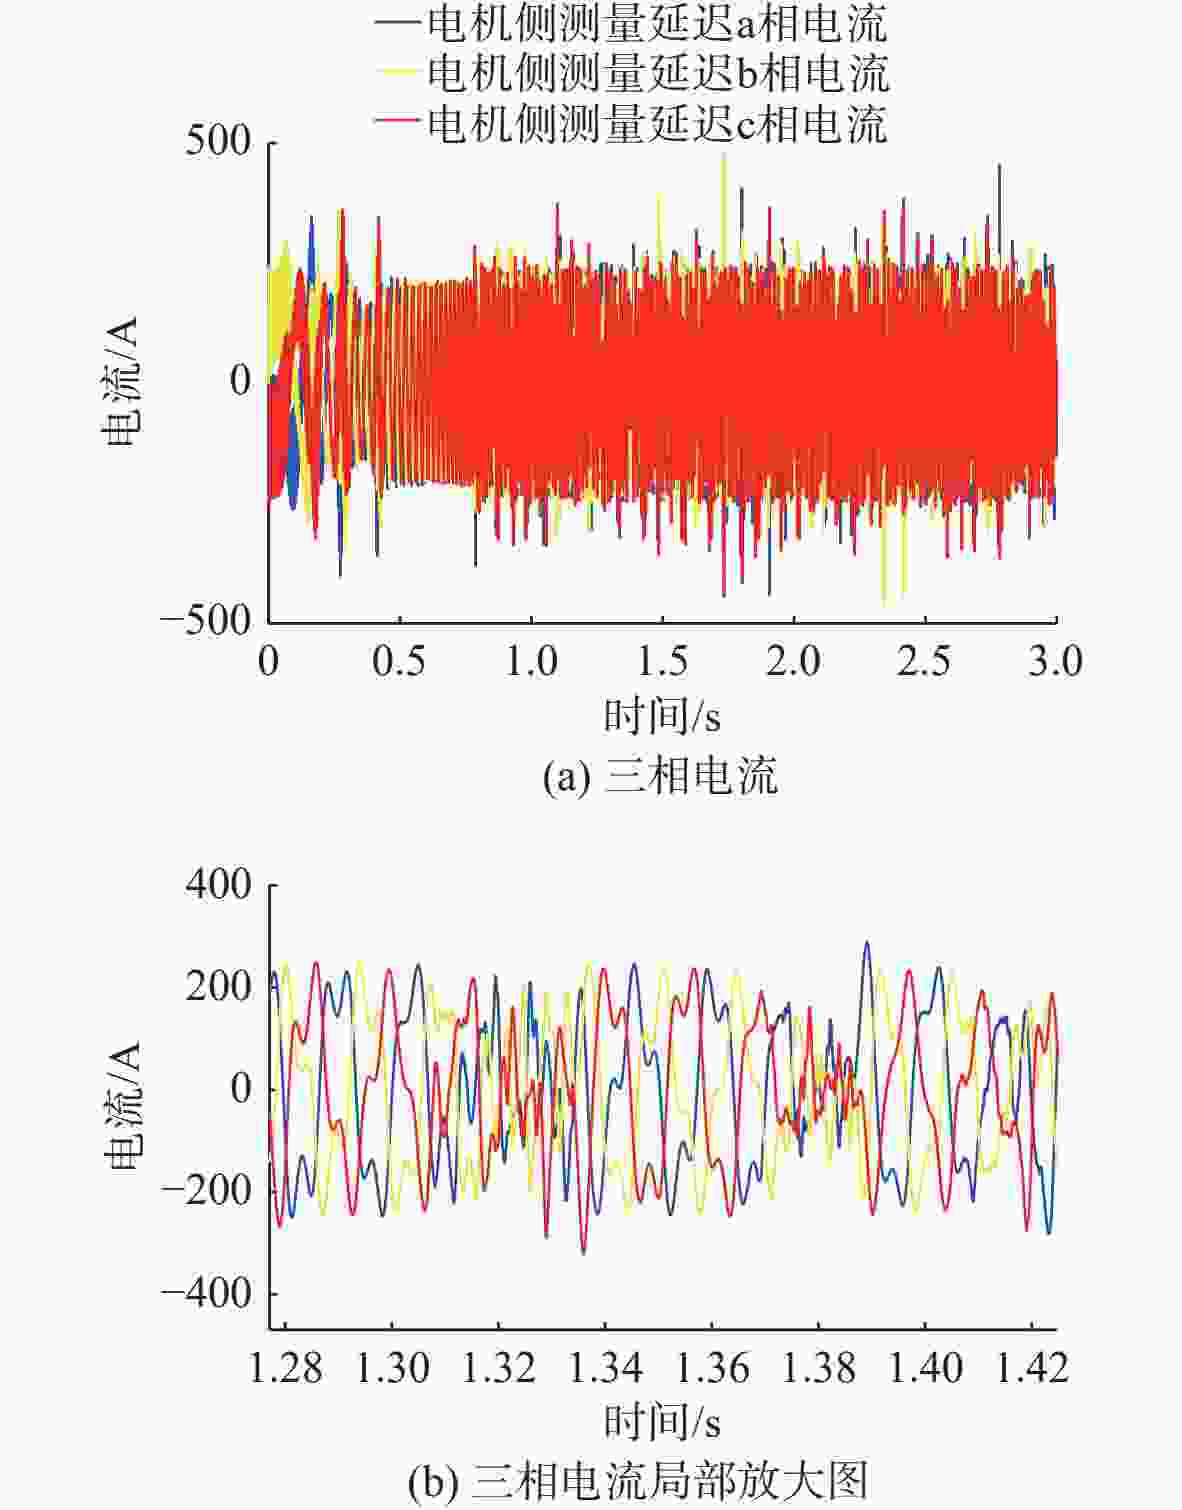
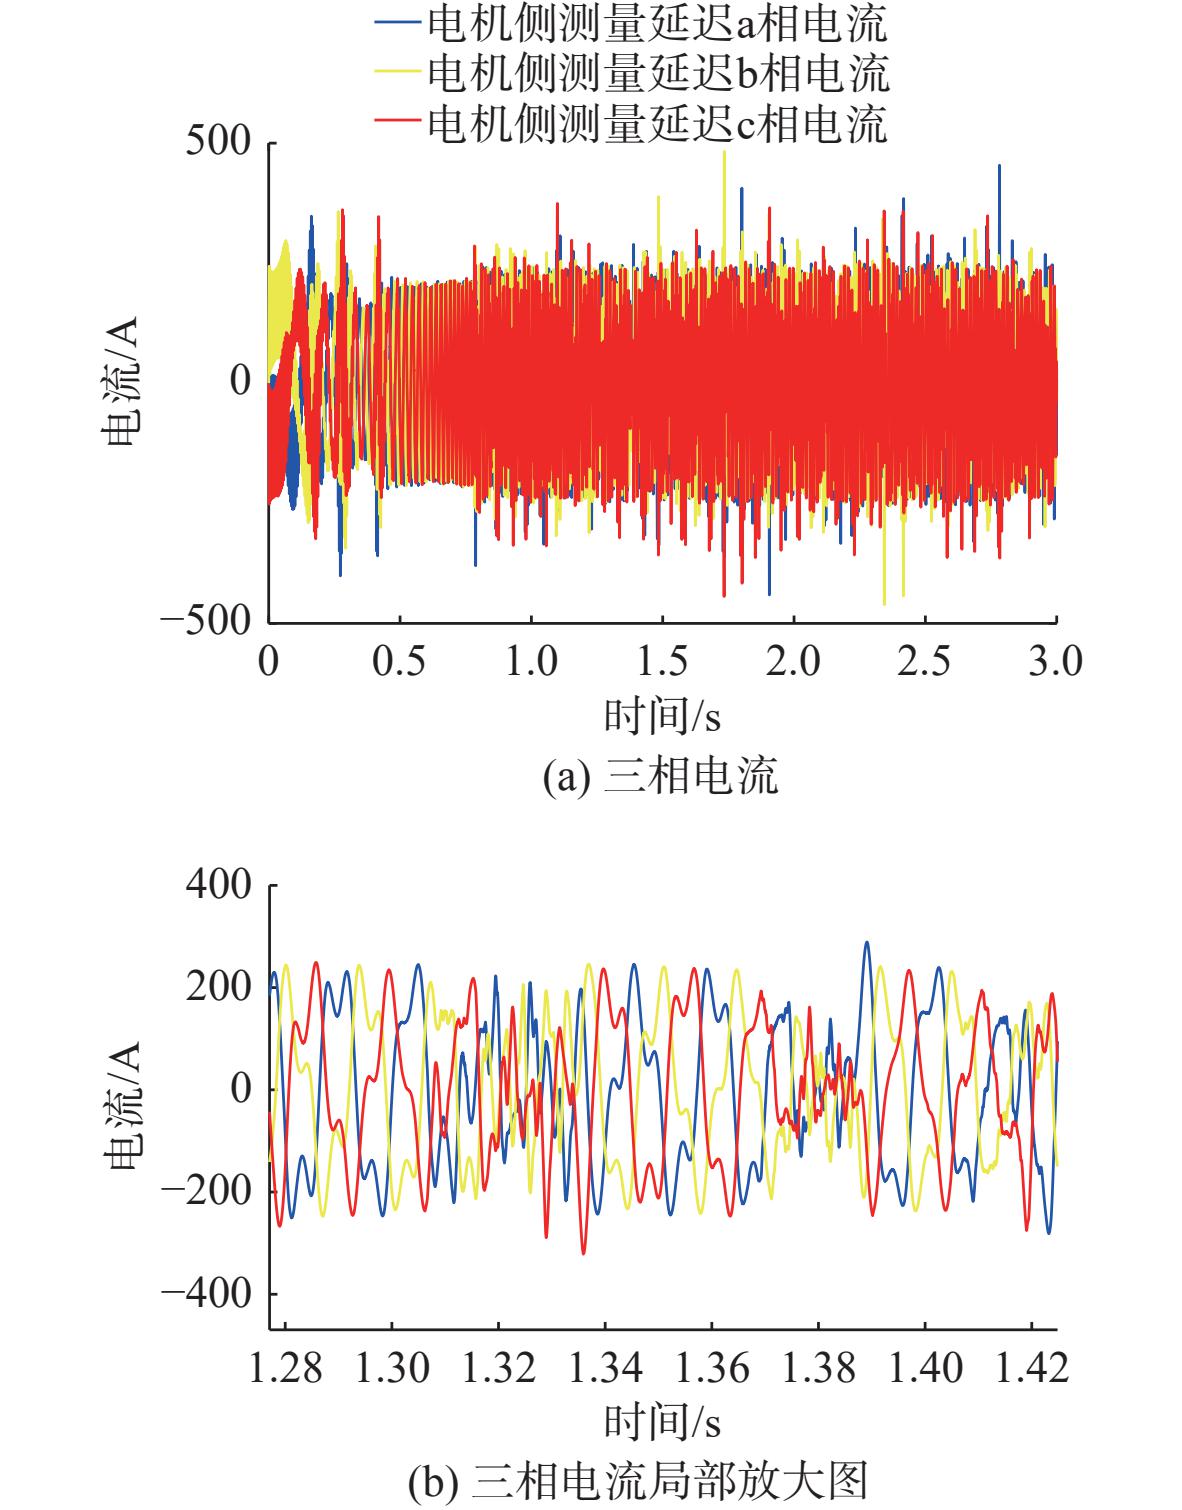
图 10 电机侧测量信号闭环控制的电机三相电流
Figure 10. Three-phase currents of the motor measured at the cable end
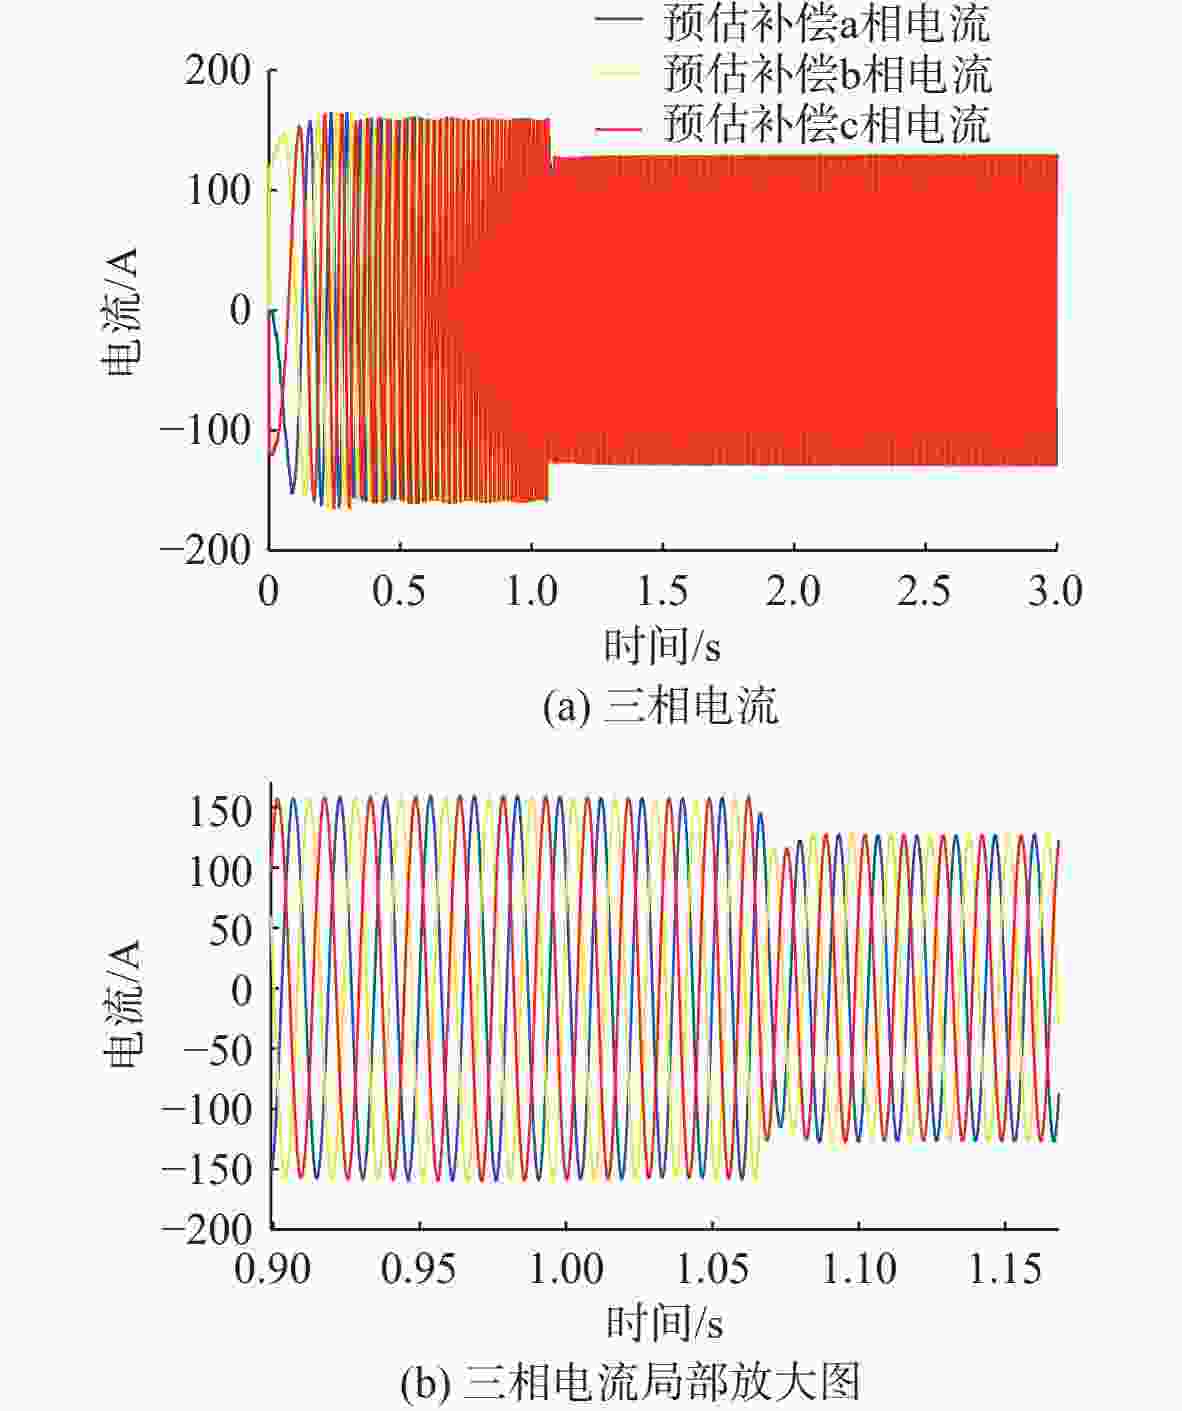
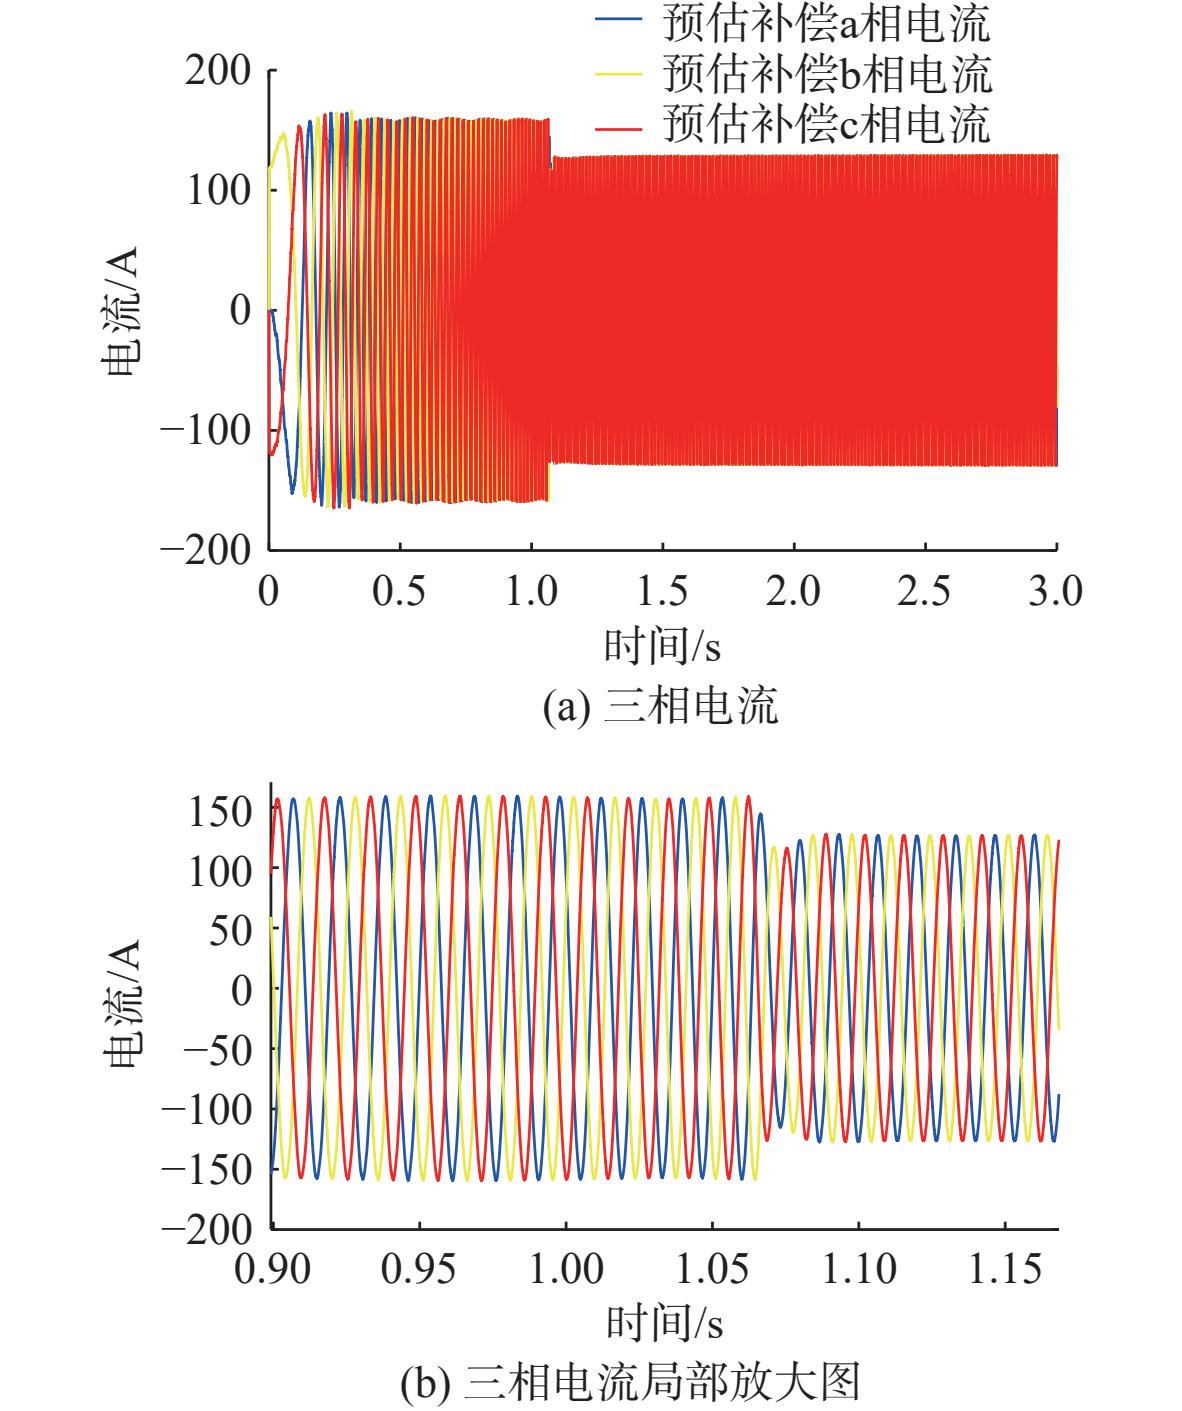
图 11 延迟补偿闭环控制的电机三相电流
Figure 11. Three-phase currents of the motor with delay compensation
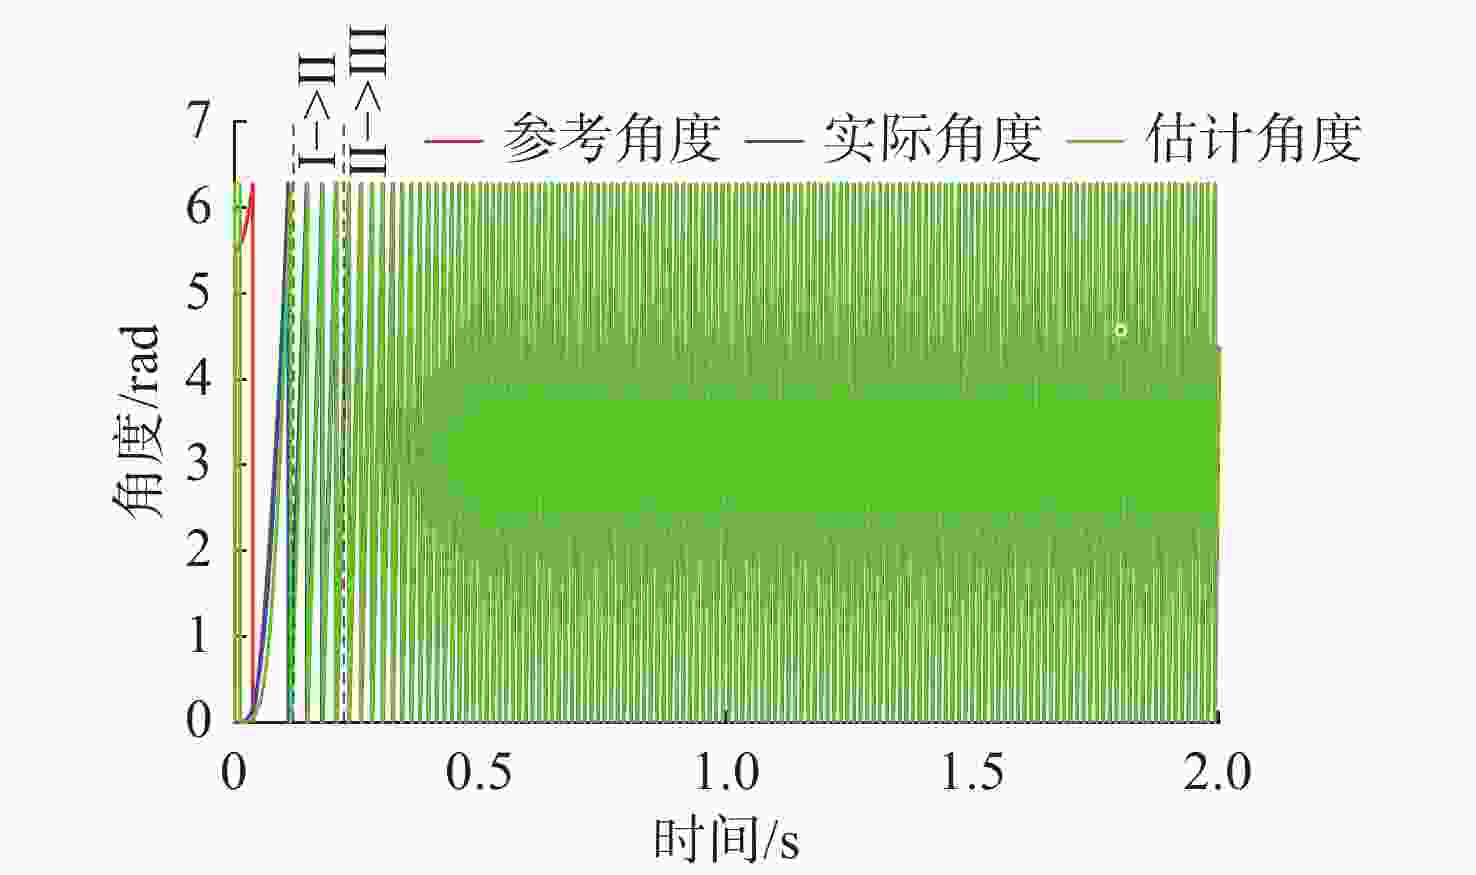
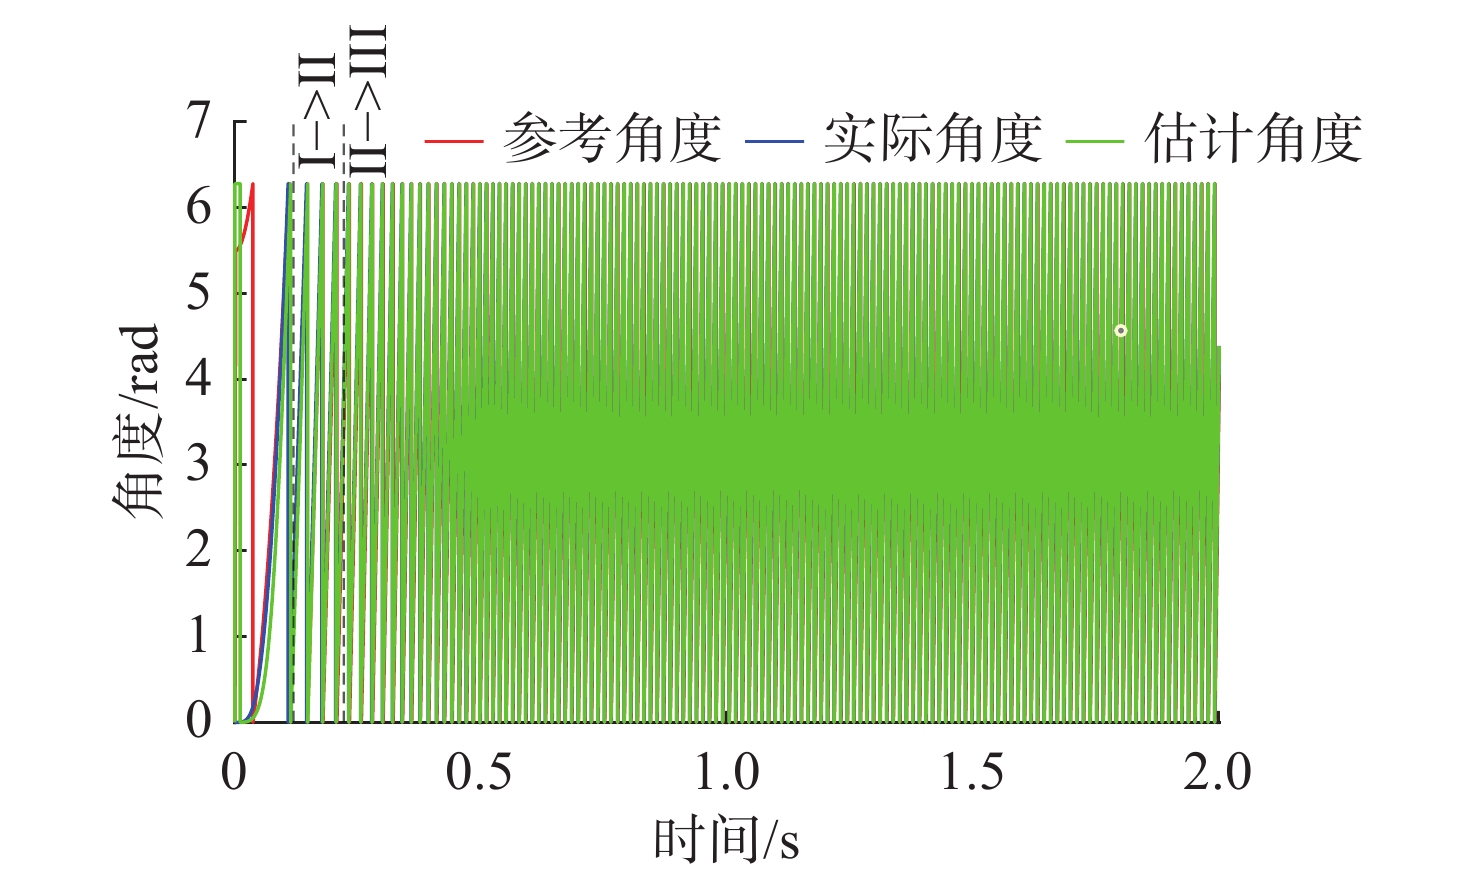
图 14 电机参考角度、实际角度和估计角度的仿真波形
Figure 14. Simulated waveforms of the motor reference angle, actual angle and estimated angle
表 1 仿真系统参数
Table 1. Simulated system parameters
参数 符号 参数值 单位 额定功率 P 150 kW 额定电流 I 110 A 额定电压 U 875 V 极对数 np 3 对 直轴电感 Ld 3.7 mH 交轴电感 Lq 8.3 mH 定子电阻 R 0.071 Ω 永磁体磁通量 λf 1.59 Wb 额定转速 n 1500 r/min  下载: 导出CSV
表 2 电缆建模系统参数值
Table 2. Cable modeling system parameter values
参数 符号 参数值 单位 自阻 Rs 0.89 Ω 互阻 Rm 0.47 Ω 自感 Ls 4.7×10⁻⁴ H 互感 Lm 3.7×10⁻⁴ H 相位电容 Cp 2×10⁻⁷ F 接地电容 Cg 6×10⁻⁷ F
下载: 导出CSV
表 3 不同负载条件下与传统方法对比效果
Table 3. Performance comparison with the conventional method under varying load conditions
负载条件 转速振荡峰值
减小量(r/min)q轴电流冲击
减小量(A)d轴电流冲击
减小量(A)90%负载 103.98 104.30 114.28 50%负载 124.15 126.37 118.59 20%负载 135.26 130.71 122.93
下载: 导出CSV
-
[1] Azadeh Y, Choksi K, Mirza A B, et al. Cable and motor winding impedance interactions in motor drive systems and its impact on HF overvoltages[J]. IEEE Transactions on Power Electronics, 2024, 39(1): 1244-1253. doi: 10.1109/TPEL.2023.3322639 [2] 张明明, 刘维亭, 魏海峰, 等. 基于滑模观测器的PMSM单相霍尔位置传感器故障容错控制算法[J]. 水下无人系统学报, 2019, 27(6): 651-657. doi: 10.11993/j.issn.2096-3920.2019.06.008Zhang M M, Liu W T, Wei H F, et al. Fault-tolerant control algorithm of single-phase hall position sensor based on sliding mode observer for PMSM[J]. Journal of Unmanned Undersea Systems, 2019, 27(6): 651-657. doi: 10.11993/j.issn.2096-3920.2019.06.008 [3] Wu Y X, Choksi K, Hassan M U, et al. An extendable and accurate high-frequency modelling of three-phase cable for prediction of reflected wave phenomenon[C]//2022 IEEE Applied Power Electronics Conference and Exposition(APEC), 2022: 944-950. [4] Wang L, Ho C N M, Canales F, et al. High-frequency modeling of the long-cable-fed induction motor drive system using TLM approach for predicting overvoltage transients[J]. IEEE Transactions on Power Electronics, 2010, 25(10): 2653-2664. doi: 10.1109/TPEL.2010.2047027 [5] Bernardi F, Lorenzani E, Savi F, et al. Output voltage overshoot suppression control for multilevel inverter architectures[C]//IECON 2022 – 48th Annual Conference of the IEEE Industrial Electronics Society, 2022: 1-6. [6] Strom J P, Korhonen J, Tyster J, et al. Active du/dt—new output-filtering approach for inverter-fed electric drives[J]. IEEE Transactions on Industrial Electronics, 2011, 58(9): 3840-3847. doi: 10.1109/TIE.2010.2093480 [7] Yunus S, Ming W, Ugalde-loo C E. Motor overvoltage mitigation using SiC-based zero-voltage switching inverter[J]. IEEE Transactions on Power Electronics, 2024, 39(1): 1195-1208. doi: 10.1109/TPEL.2023.3316591 [8] Bahrami-fard M, Korrani M G, Rastegar M, et al. Advanced startup and smooth transition to sensorless field oriented control for CSI-fed PMSM drives in submersible pumps[J]. IEEE Transactions on Power Electronics, 2025, 40(9): 12402-12415. doi: 10.1109/TPEL.2025.3567425 [9] Thangarajan K, Soundarrajan A. Performance comparison of permanent magnet synchronous motor (PMSM) drive with delay compensated predictive controllers[J]. Microprocessors and Microsystems, 2020, 75: 103081. doi: 10.1016/j.micpro.2020.103081 [10] Hosseini S A, Toulabi M, Dobakhshari A S, et al. Delay compensation of demand response and adaptive disturbance rejection applied to power system frequency control[J]. IEEE Transactions on Power Systems, 2020, 35(3): 2037-2046. doi: 10.1109/TPWRS.2019.2957125 [11] 陈尧伟, 曾庆军, 戴晓强, 等. 基于参数辨识的水下推进永磁同步电机无位置传感器控制[J]. 水下无人系统学报, 2021, 29(4): 442-450. doi: 10.11993/j.issn.2096-3920.2021.04.011Chen Y W, Zeng Q J, Dai X Q, et al. Sensorless control of underwater propulsion PMSM based on parameter identification[J]. Journal of Unmanned Undersea Systems, 2021, 29(4): 442-450. doi: 10.11993/j.issn.2096-3920.2021.04.011 [12] Benevieri A, Formentini A, Marchesoni M, et al. Sensorless control with switching frequency square wave voltage injection for SPMSM with low rotor magnetic anisotropy[J]. IEEE Transactions on Power Electronics, 2023, 38(8): 10060-10072. doi: 10.1109/TPEL.2023.3270357 [13] Zhang L, Chen Z, Yu X, et al. Sliding-mode-based robust output regulation and its application in PMSM servo systems[J]. IEEE Transactions on Industrial Electronics, 2023, 70(2): 1852-1860. doi: 10.1109/TIE.2022.3163536 [14] Xu Y, Lin C, Xing J, et al. I-f starting rapid and smooth transition method of full-speed sensorless control for low current harmonic ultra-high-speed PMSM[C]//2022 IEEE Applied Power Electronics Conference and Exposition (APEC). Houston, TX, USA: IEEE, 2022: 1820-1826. [15] Nair S V, Hatua K, Prasad N. V. P. R. D, et al. A quick I-f starting of PMSM drive with pole slipping prevention and reduced speed oscillations[J]. IEEE Transactions on Industrial Electronics, 2021, 68(8): 6650-6661. doi: 10.1109/TIE.2020.3005070 [16] Wang Z, Lu K, Blaabjerg F. A simple startup strategy based on current regulation for back-EMF-based sensorless control of PMSM[J]. IEEE Transactions on Power Electronics, 2012, 27(8): 3817-3825. doi: 10.1109/TPEL.2012.2186464 [17] Stirban A, Boldea I, Andreescu G D, et al. Motion sensorless control of BLDC PM motor with offline FEM info assisted state observer[C]//2010 12th International Conference on Optimization of Electrical and Electronic Equipment. Brasov, Romania: IEEE, 2010: 321-328. [18] Song X D, Fang J C, Han B C, et al. Adaptive compensation method for high-speed surface PMSM sensorless drives of EMF-based position estimation error[J]. IEEE Transactions on Power Electronics, 2016, 31(2): 1438-1449. doi: 10.1109/TPEL.2015.2423319 -

 下载:

 点击查看大图
计量
- 文章访问数: 5
- HTML全文浏览量: 2
- PDF下载量: 1
- 被引次数: 0