

Compact Sensorless Control for Underwater Propulsion Using Single-Current-Sensor Reconstruction
-
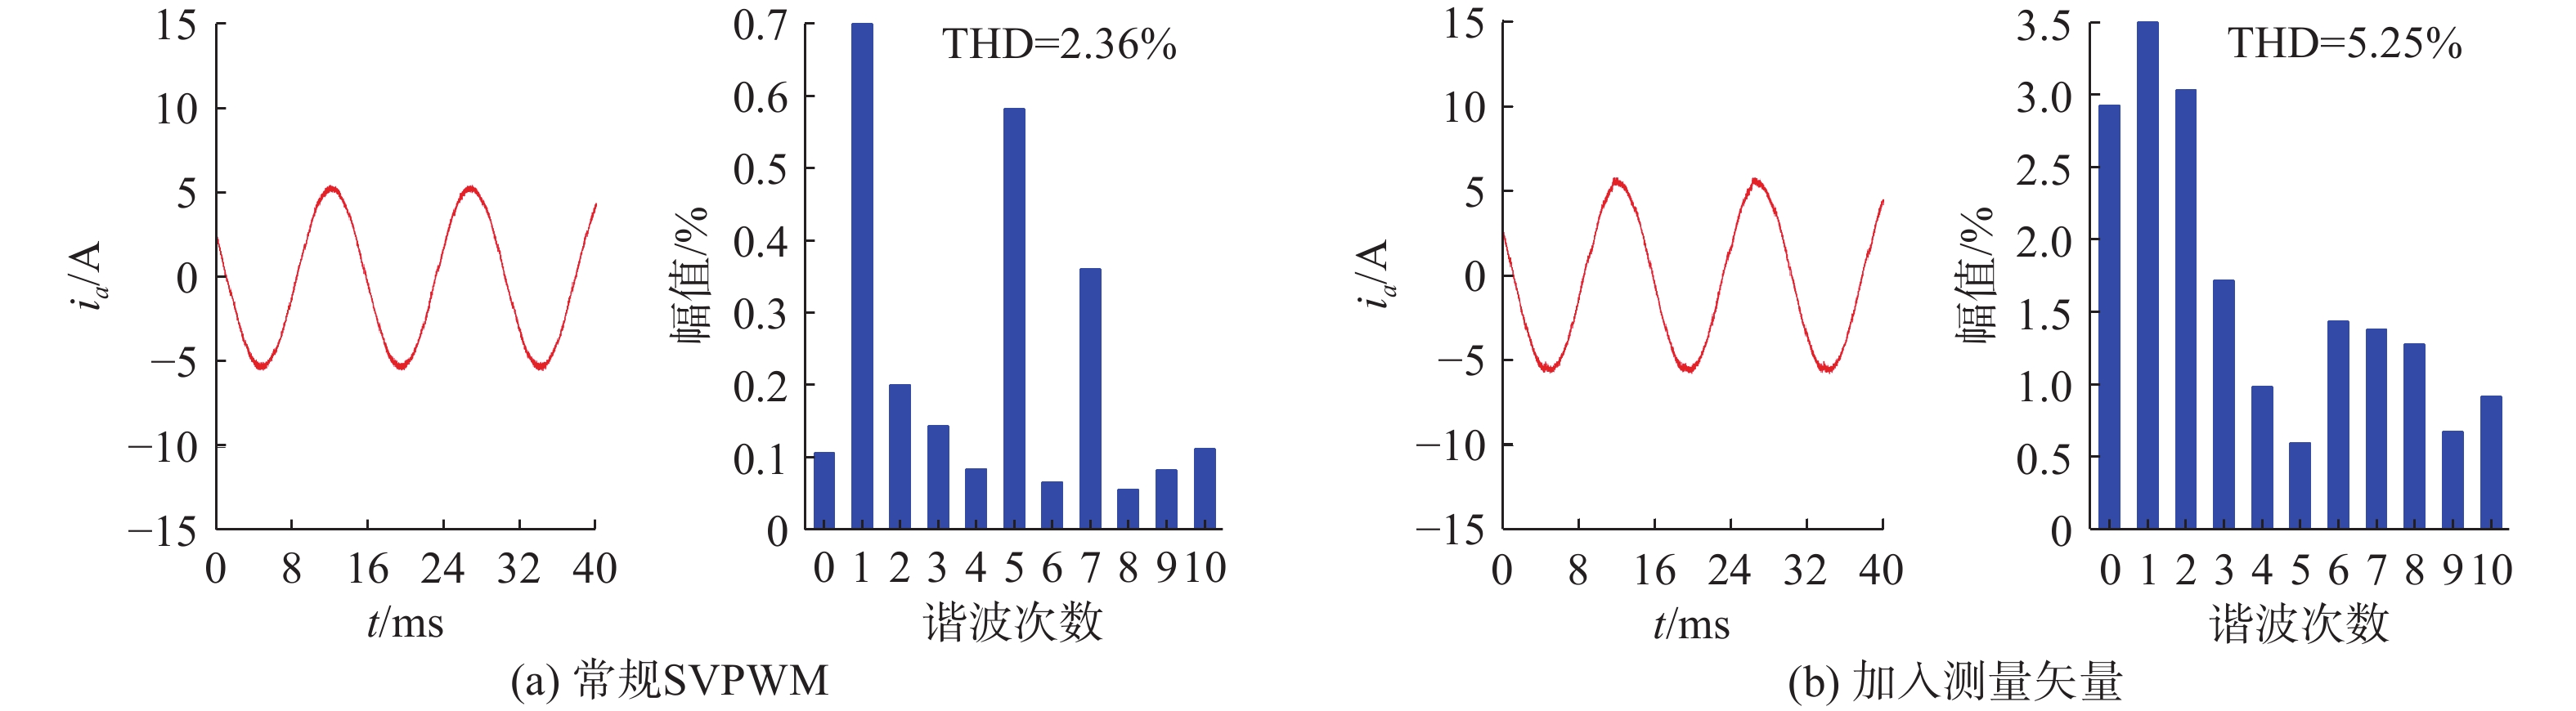
摘要: 水下作业平台的推进系统通常被集成在狭窄的舱体中, 空间布局高度受限。传统永磁同步电机矢量控制系统依赖于多个电流传感器与位置传感器, 不仅挤占了功率器件的散热空间, 而且在深海高压腐蚀环境中面临更高的传感器失效风险。为应对上述问题, 文中提出一种紧凑型无感控制方案, 融合单电流传感器技术与扩展卡尔曼滤波(EKF), 以简化系统硬件结构。针对单电流传感器技术存在的测量盲区问题, 通过优化空间矢量调制时序, 在有效电压矢量作用时间不足时主动插入专用的非零测量矢量, 以构建稳定的电流采样窗口, 从而有效改善重构相电流波形的畸变。此外, 为了提升系统在动态负载下的响应速度, 改进了EKF观测器, 将负载转矩作为扩展状态变量进行实时辨识, 并通过前馈补偿机制增强系统对负载扰动的抑制能力。实验结果表明, 重构电流波形与实际电流波形高度吻合。与传统EKF、滑模观测器(SMO)、龙贝格-滑模观测器(L-SMO)相比, 改进EKF在转速波动抑制与恢复速度上表现更优。所提方案在简化硬件结构的同时, 兼备高精度与强鲁棒性的控制性能, 适用于复杂水下作业环境。Abstract: The propulsion system of underwater operating platform is typically integrated within narrow compartment, imposing severe constraints on spatial layout. Traditional vector control system for Permanent Magnet Synchronous Motor relies on multiple current sensor and a position sensor. This not only occupies the thermal dissipation space required for power device but also increases the risk of sensor failure in harsh deep-sea environment characterized by high pressure and corrosion.To address these challenges, this paper proposes a compact sensorless control scheme that integrates single current sensor technology with an Extended Kalman Filter (EKF) to simplify the hardware architecture. To overcome the measurement blind spot inherent in single current sensor sampling, the scheme optimizes Space Vector Pulse Width Modulation timing. Specifically, when the duration of the effective voltage vector is insufficient for sampling, a non-zero measurement vector is dynamically inserted to create a stable current sampling window. This effectively suppresses distortion in the reconstructed phase current waveform.Furthermore, to enhance the system response speed under dynamic load, this paper improves the EKF observer by incorporating the load torque as an extended state variable for real-time estimation. A feedforward compensation mechanism is employed to bolster the system ability to suppress load disturbance.Experimental results demonstrate that the reconstructed current waveform closely matches the actual current waveform. Compared to traditional EKF, sliding mode observer (SMO) and Luenberger sliding mode observer (L-SMO), the improved EKF exhibits superior performance in suppressing speed fluctuation and achieving faster recovery.The proposed solution successfully simplifies the hardware structure while achieving control performance with high precision and strong robustness, making it highly suitable for complex underwater operating environment.
-

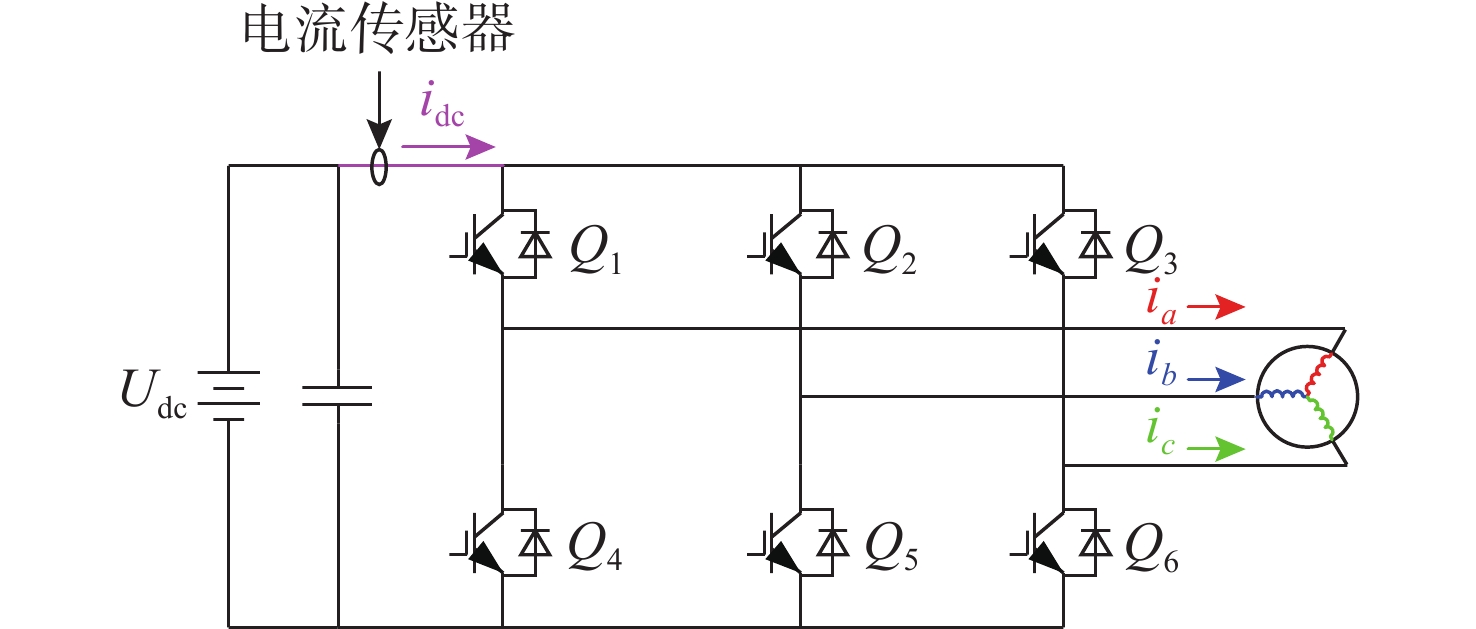
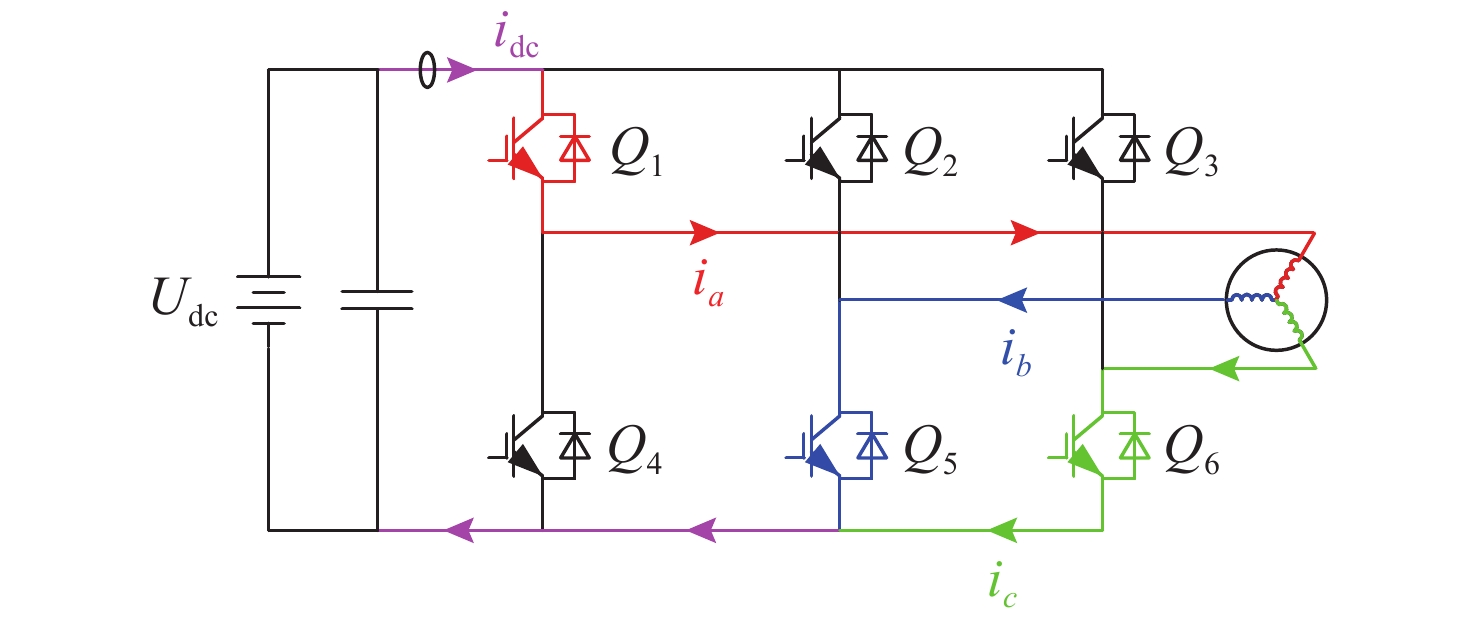
图 3 电压矢量$ {V}_{1}(100) $作用时的电流路径
Figure 3. Current path during voltage vector $ {V}_{1}(100) $ activation
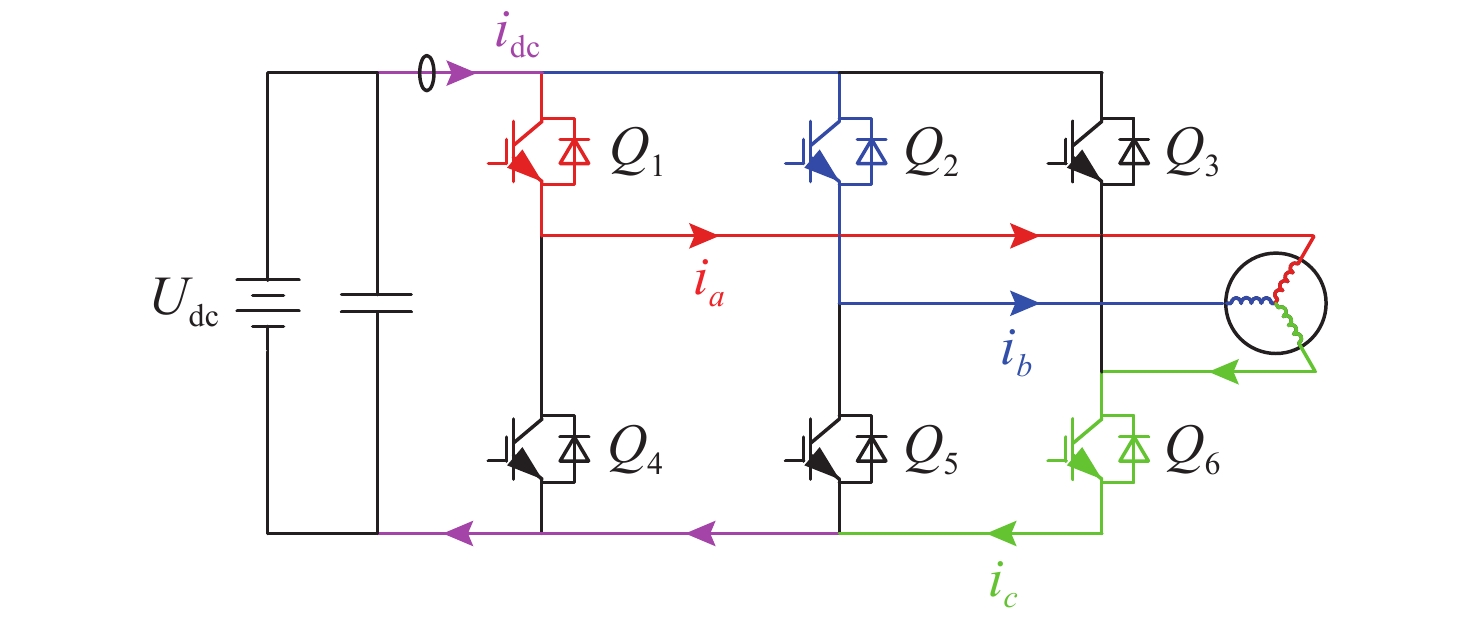
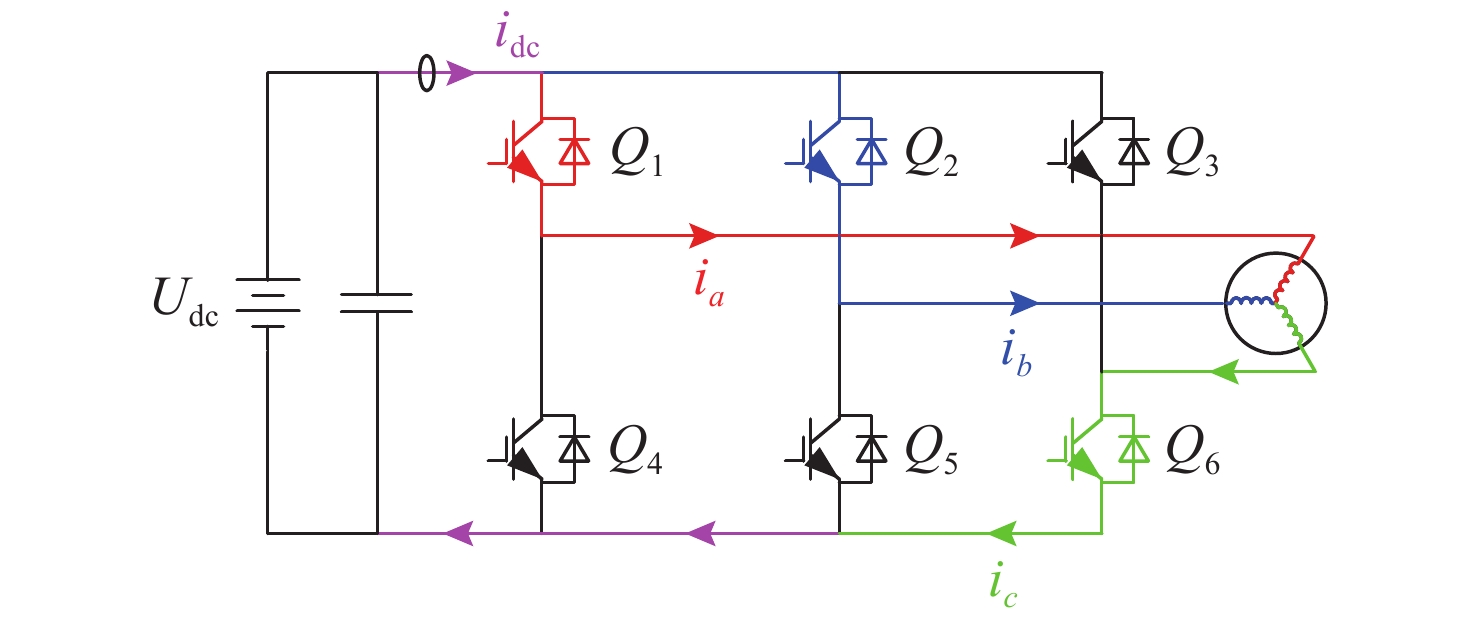
图 4 电压矢量$ {\boldsymbol{V}}_{2}(110) $作用时的电流路径
Figure 4. Current path during voltage vector $ {\boldsymbol{V}}_{2}(110) $ activation
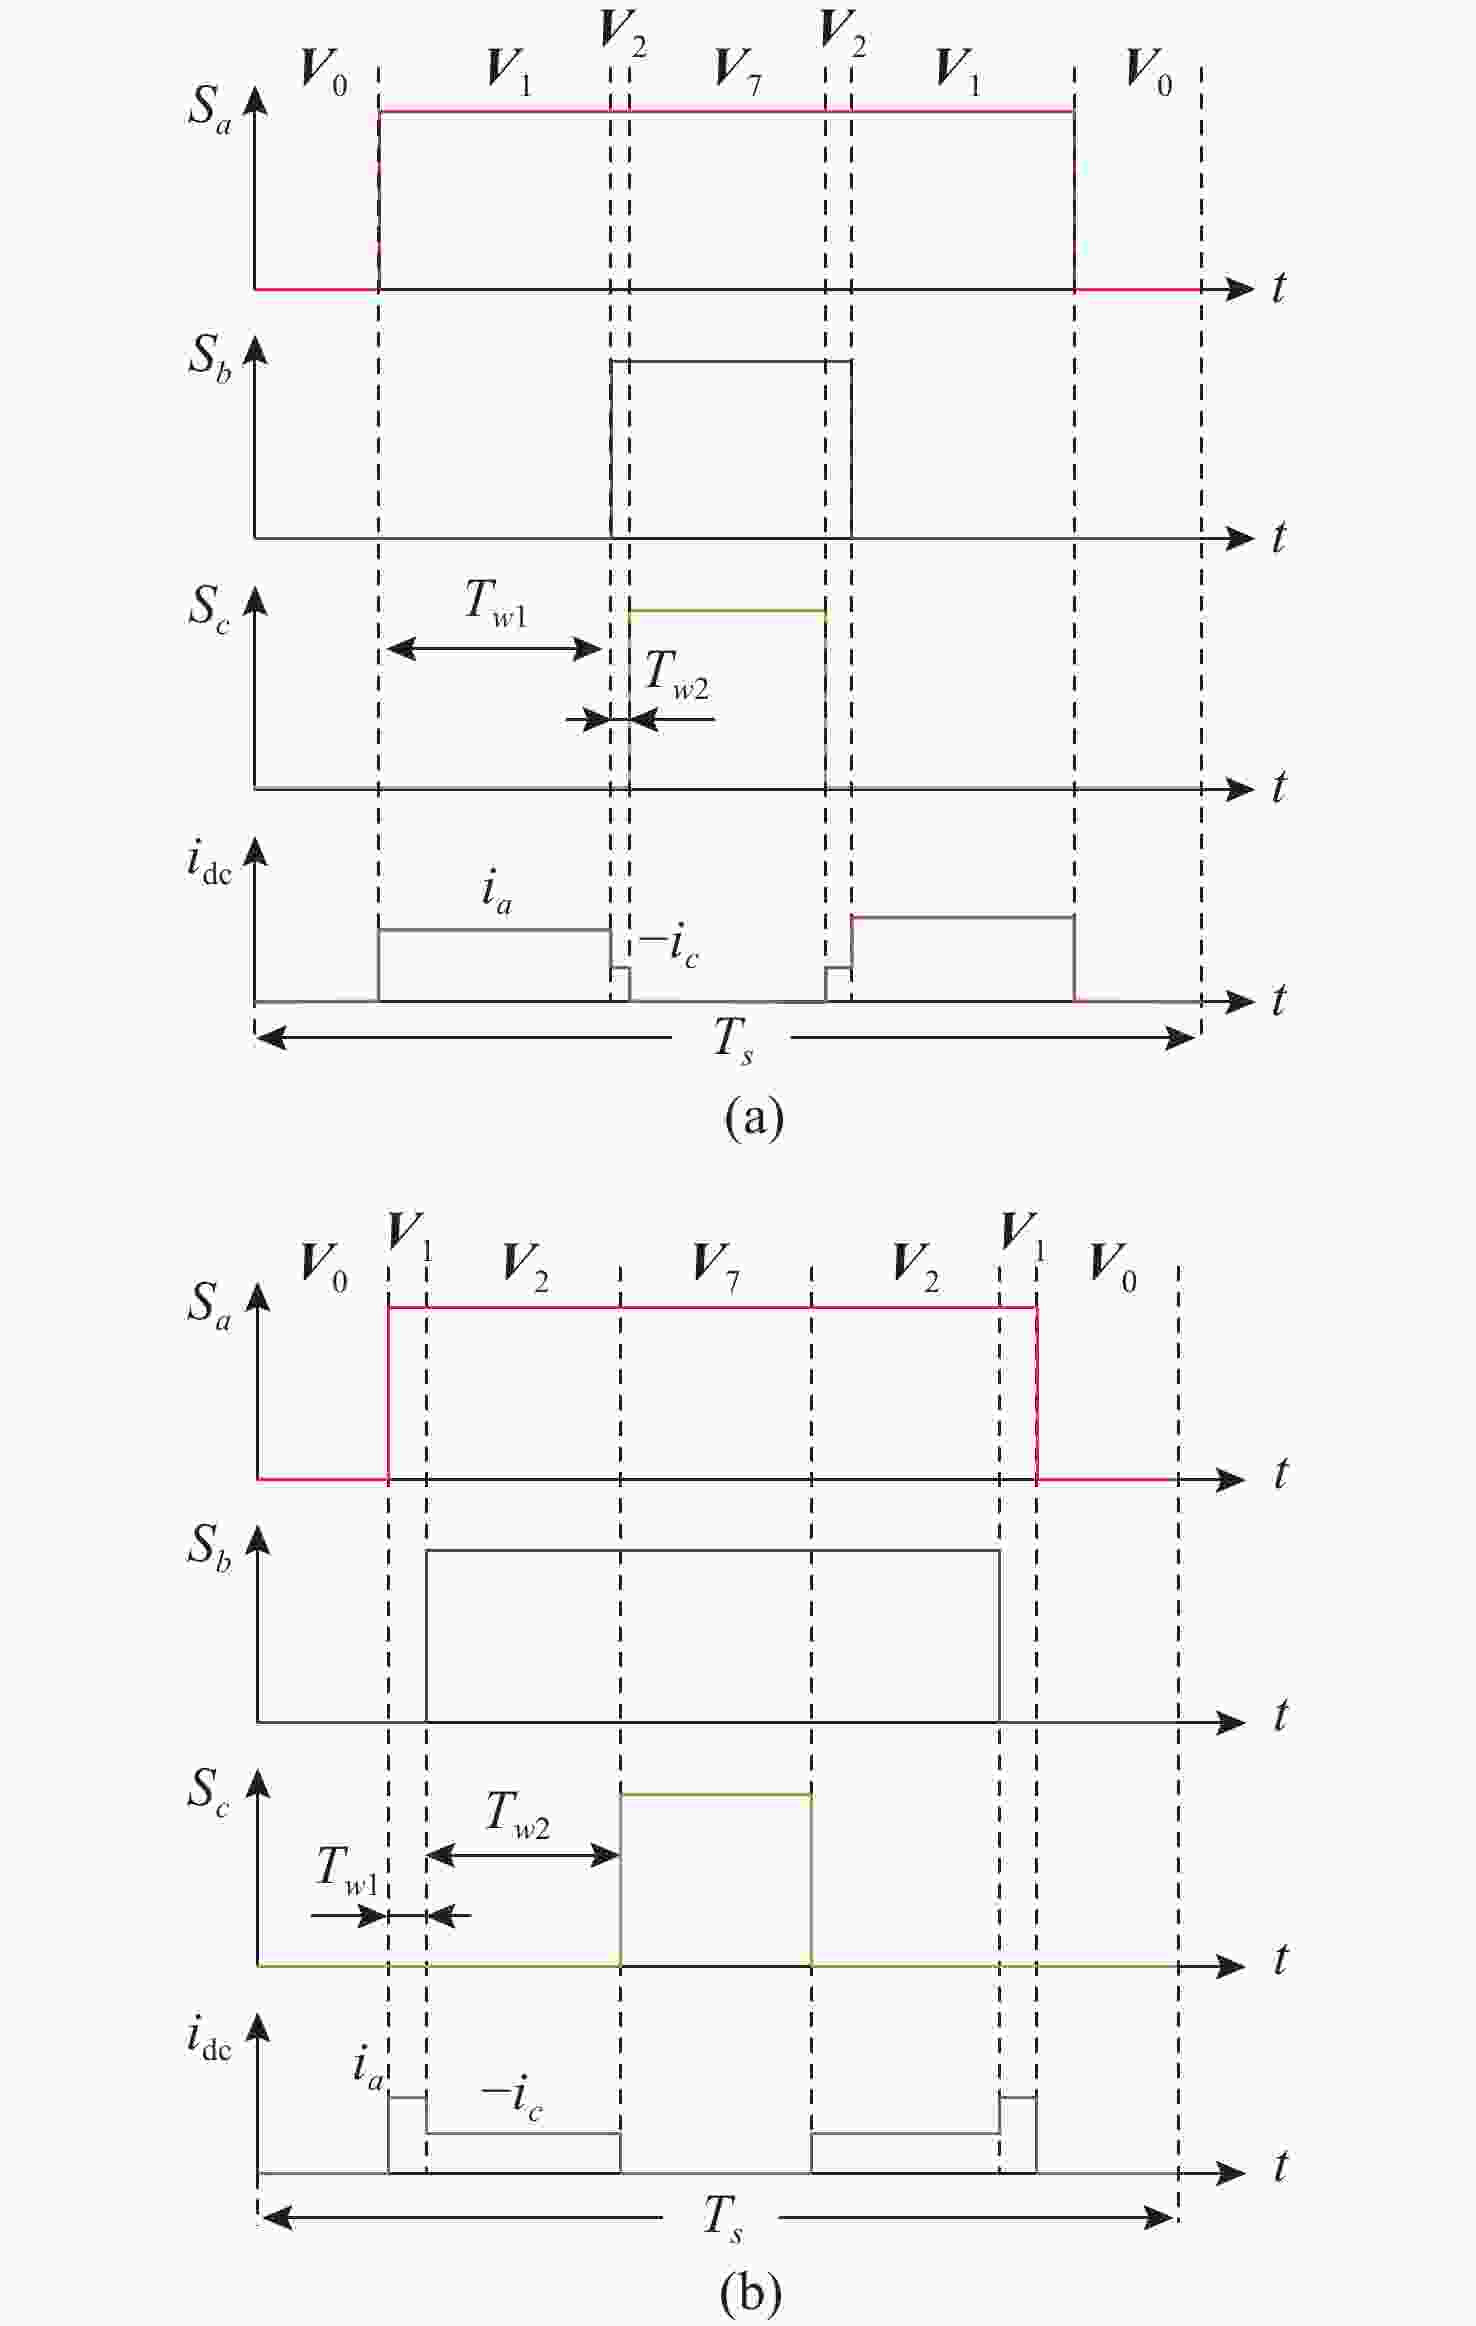
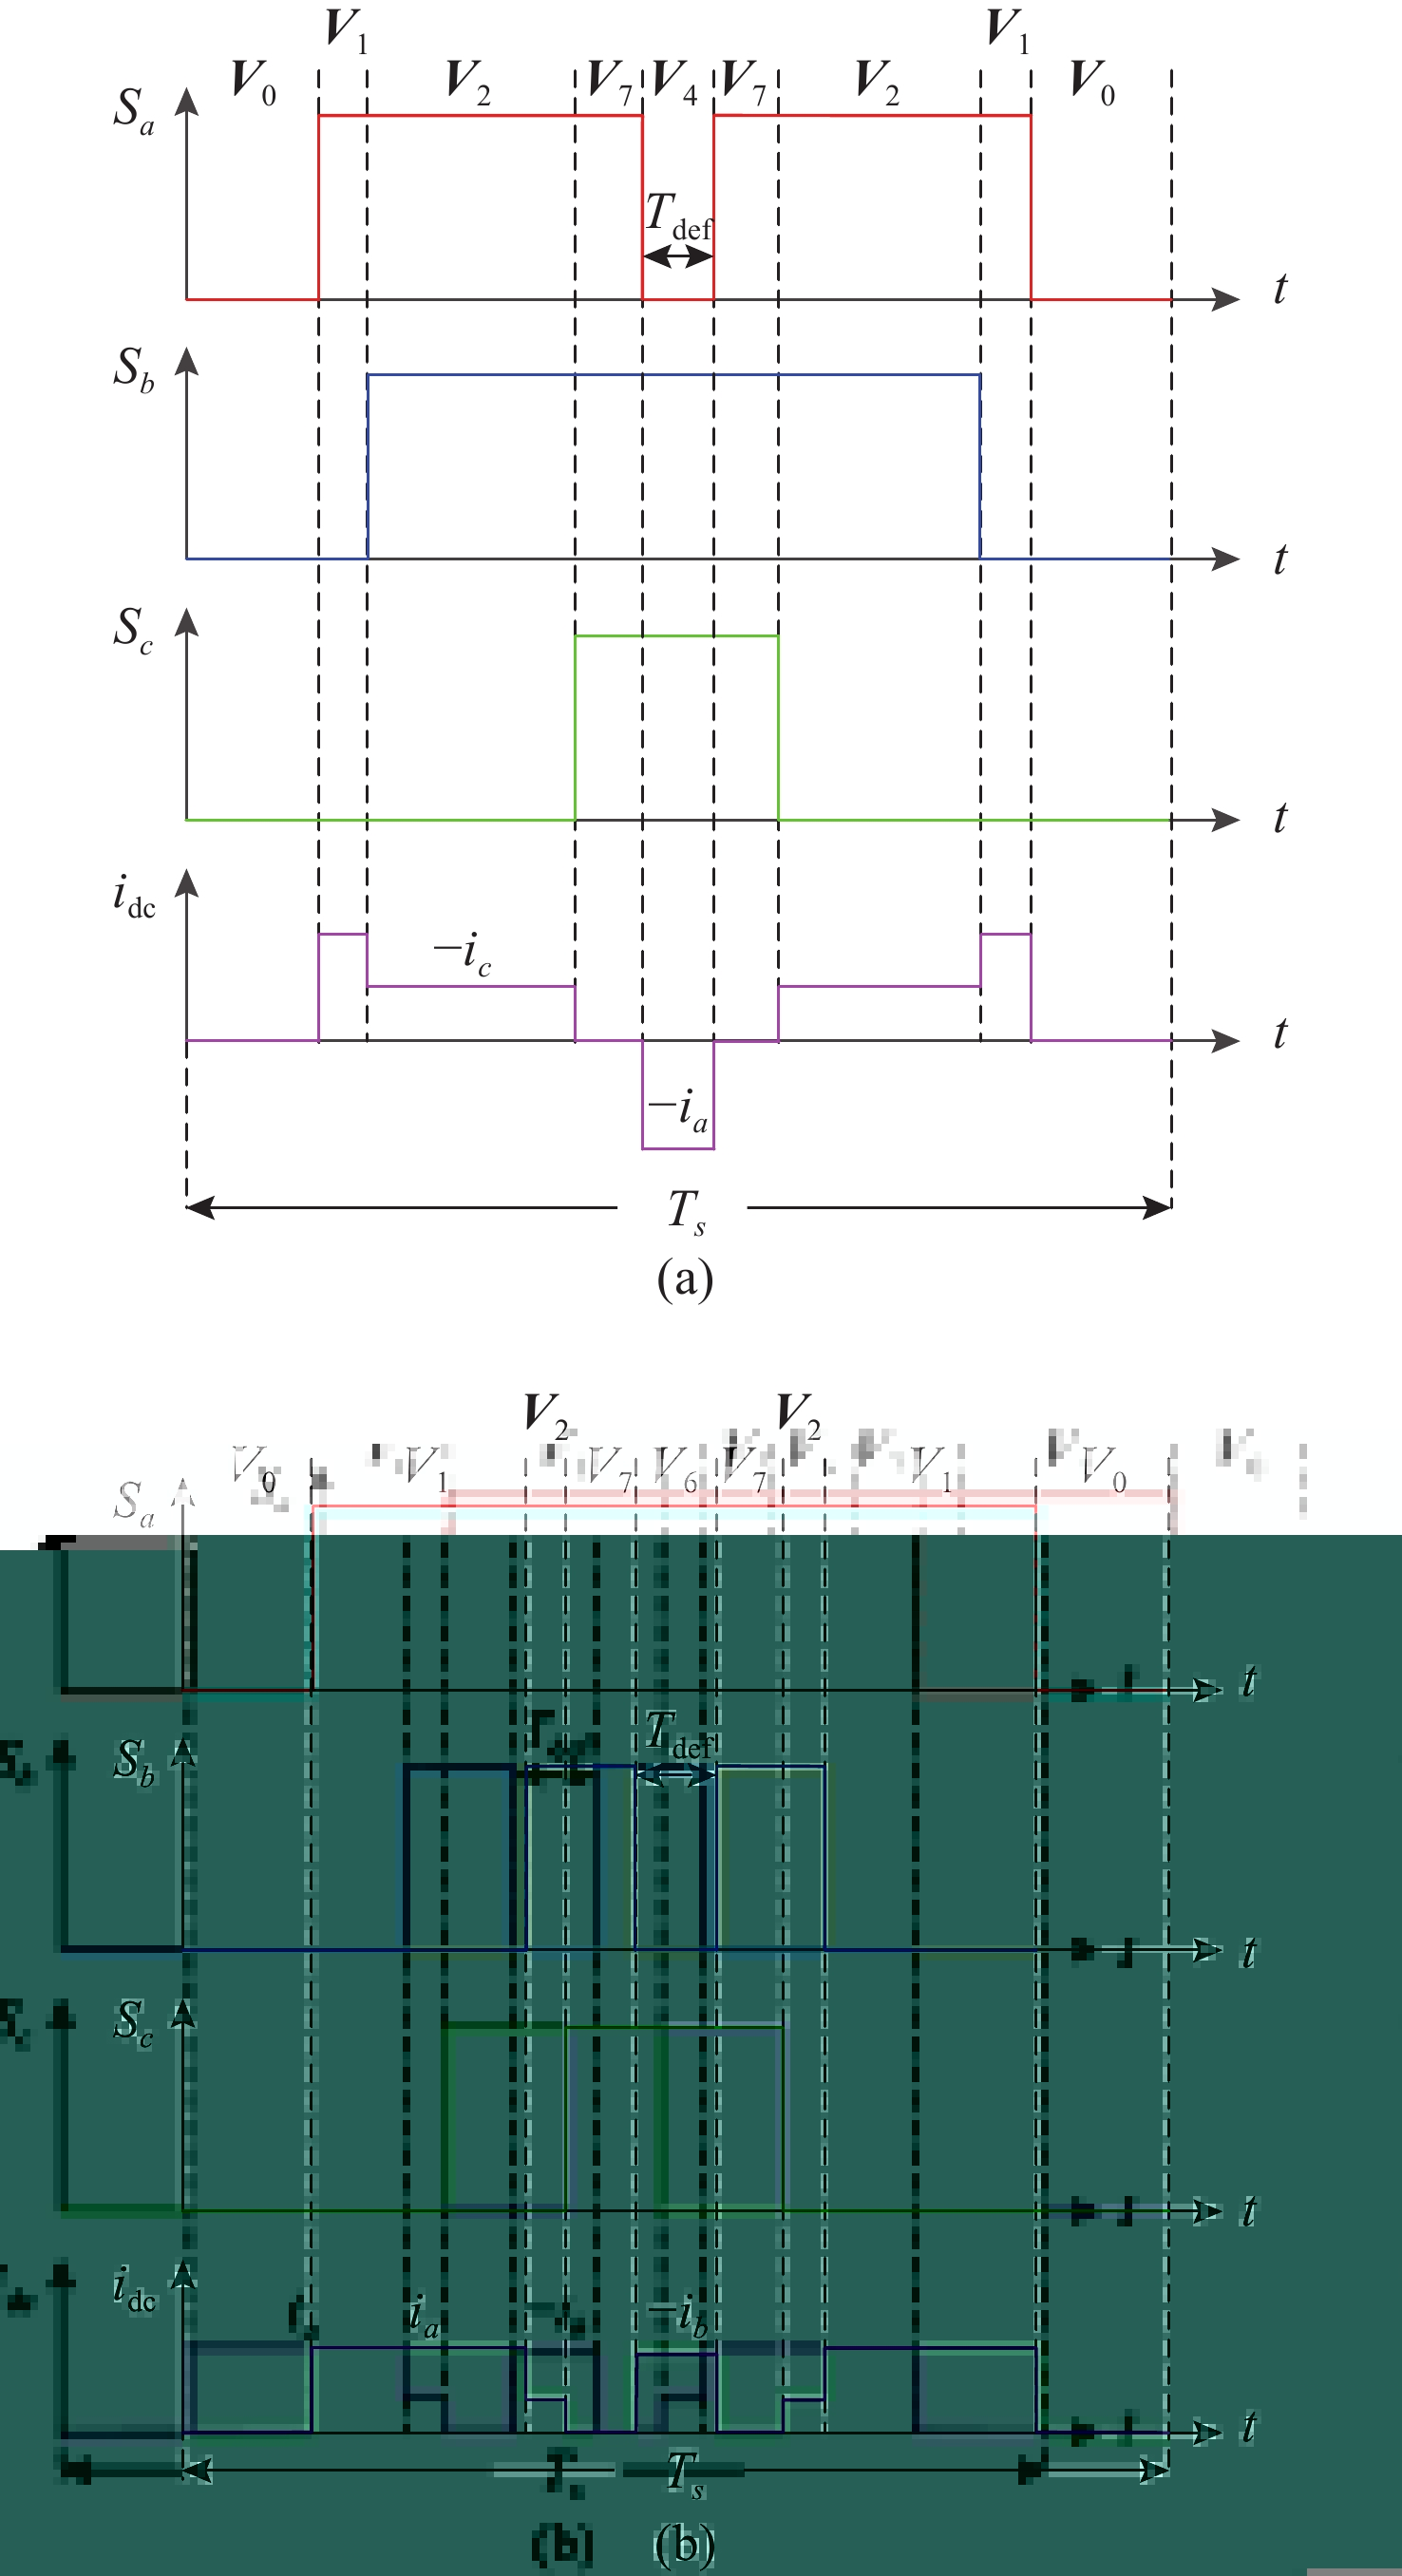
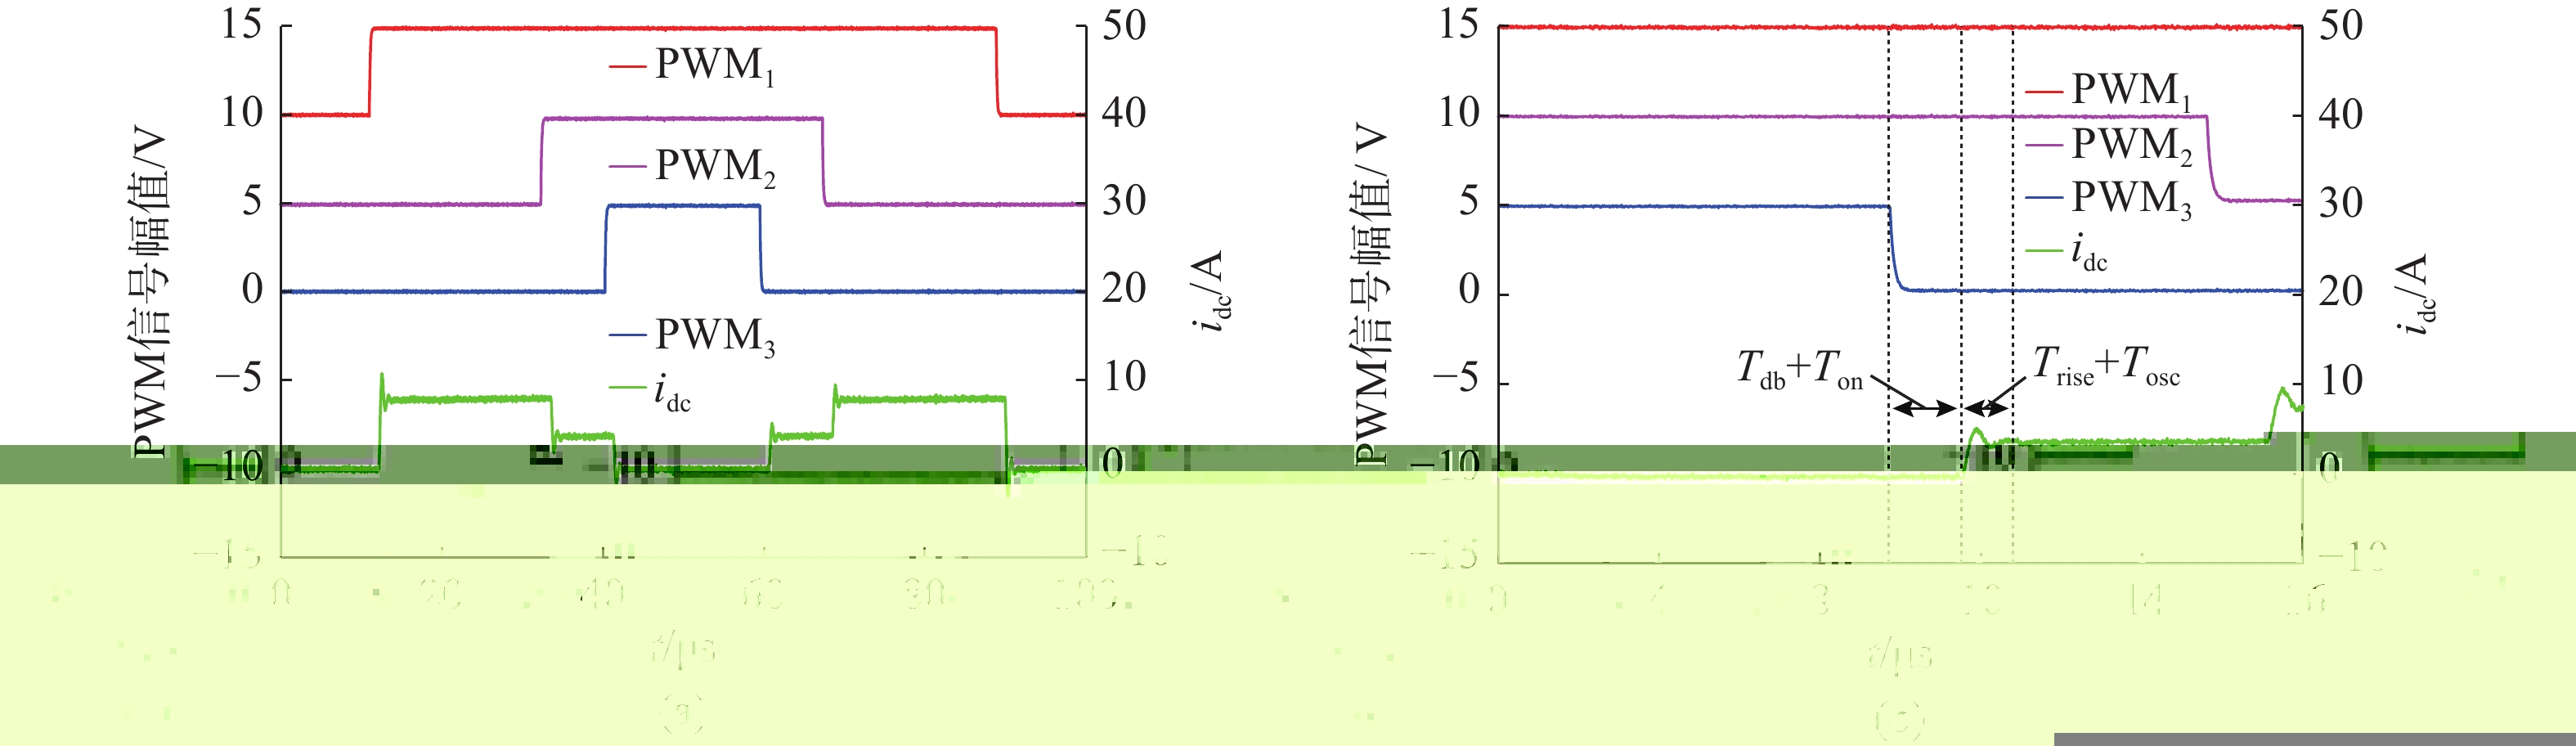
图 8 第1扇区边界上的开关信号与直流母线电流
Figure 8. Switching signals and DC bus current at sector I boundary
图 9 插入测量矢量之后的第I扇区边界上的开关信号与直流母线电流
Figure 9. Switching signals and DC bus current at sector I boundary with inserted measurement vector
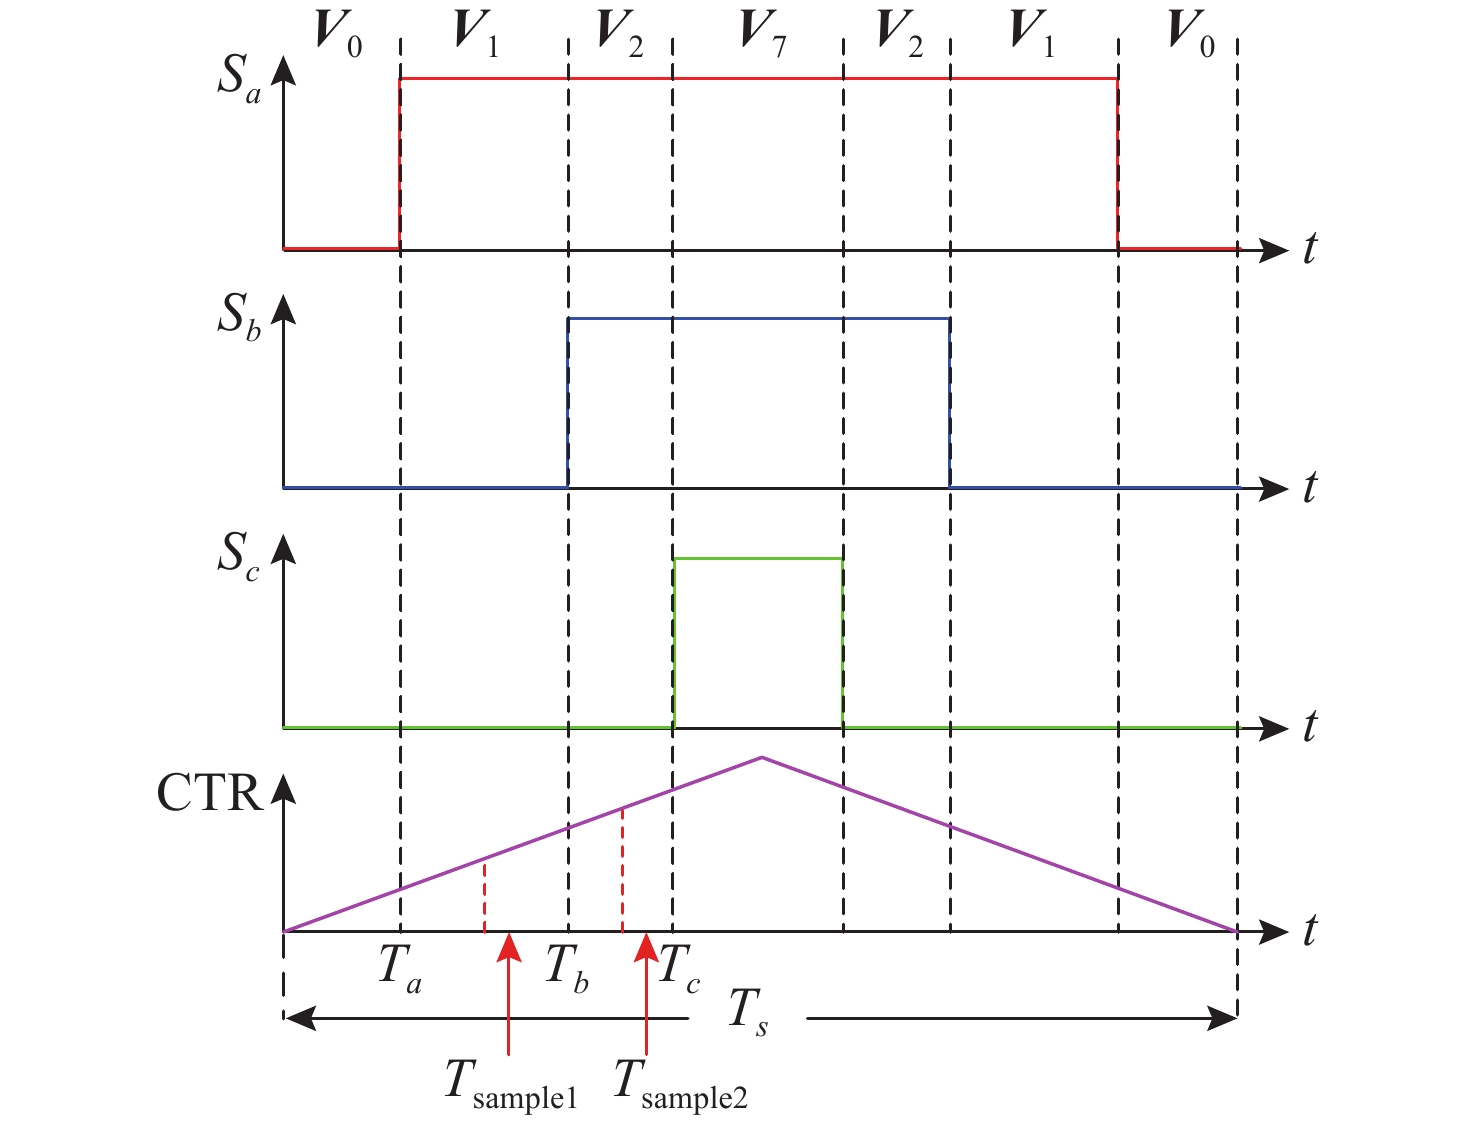
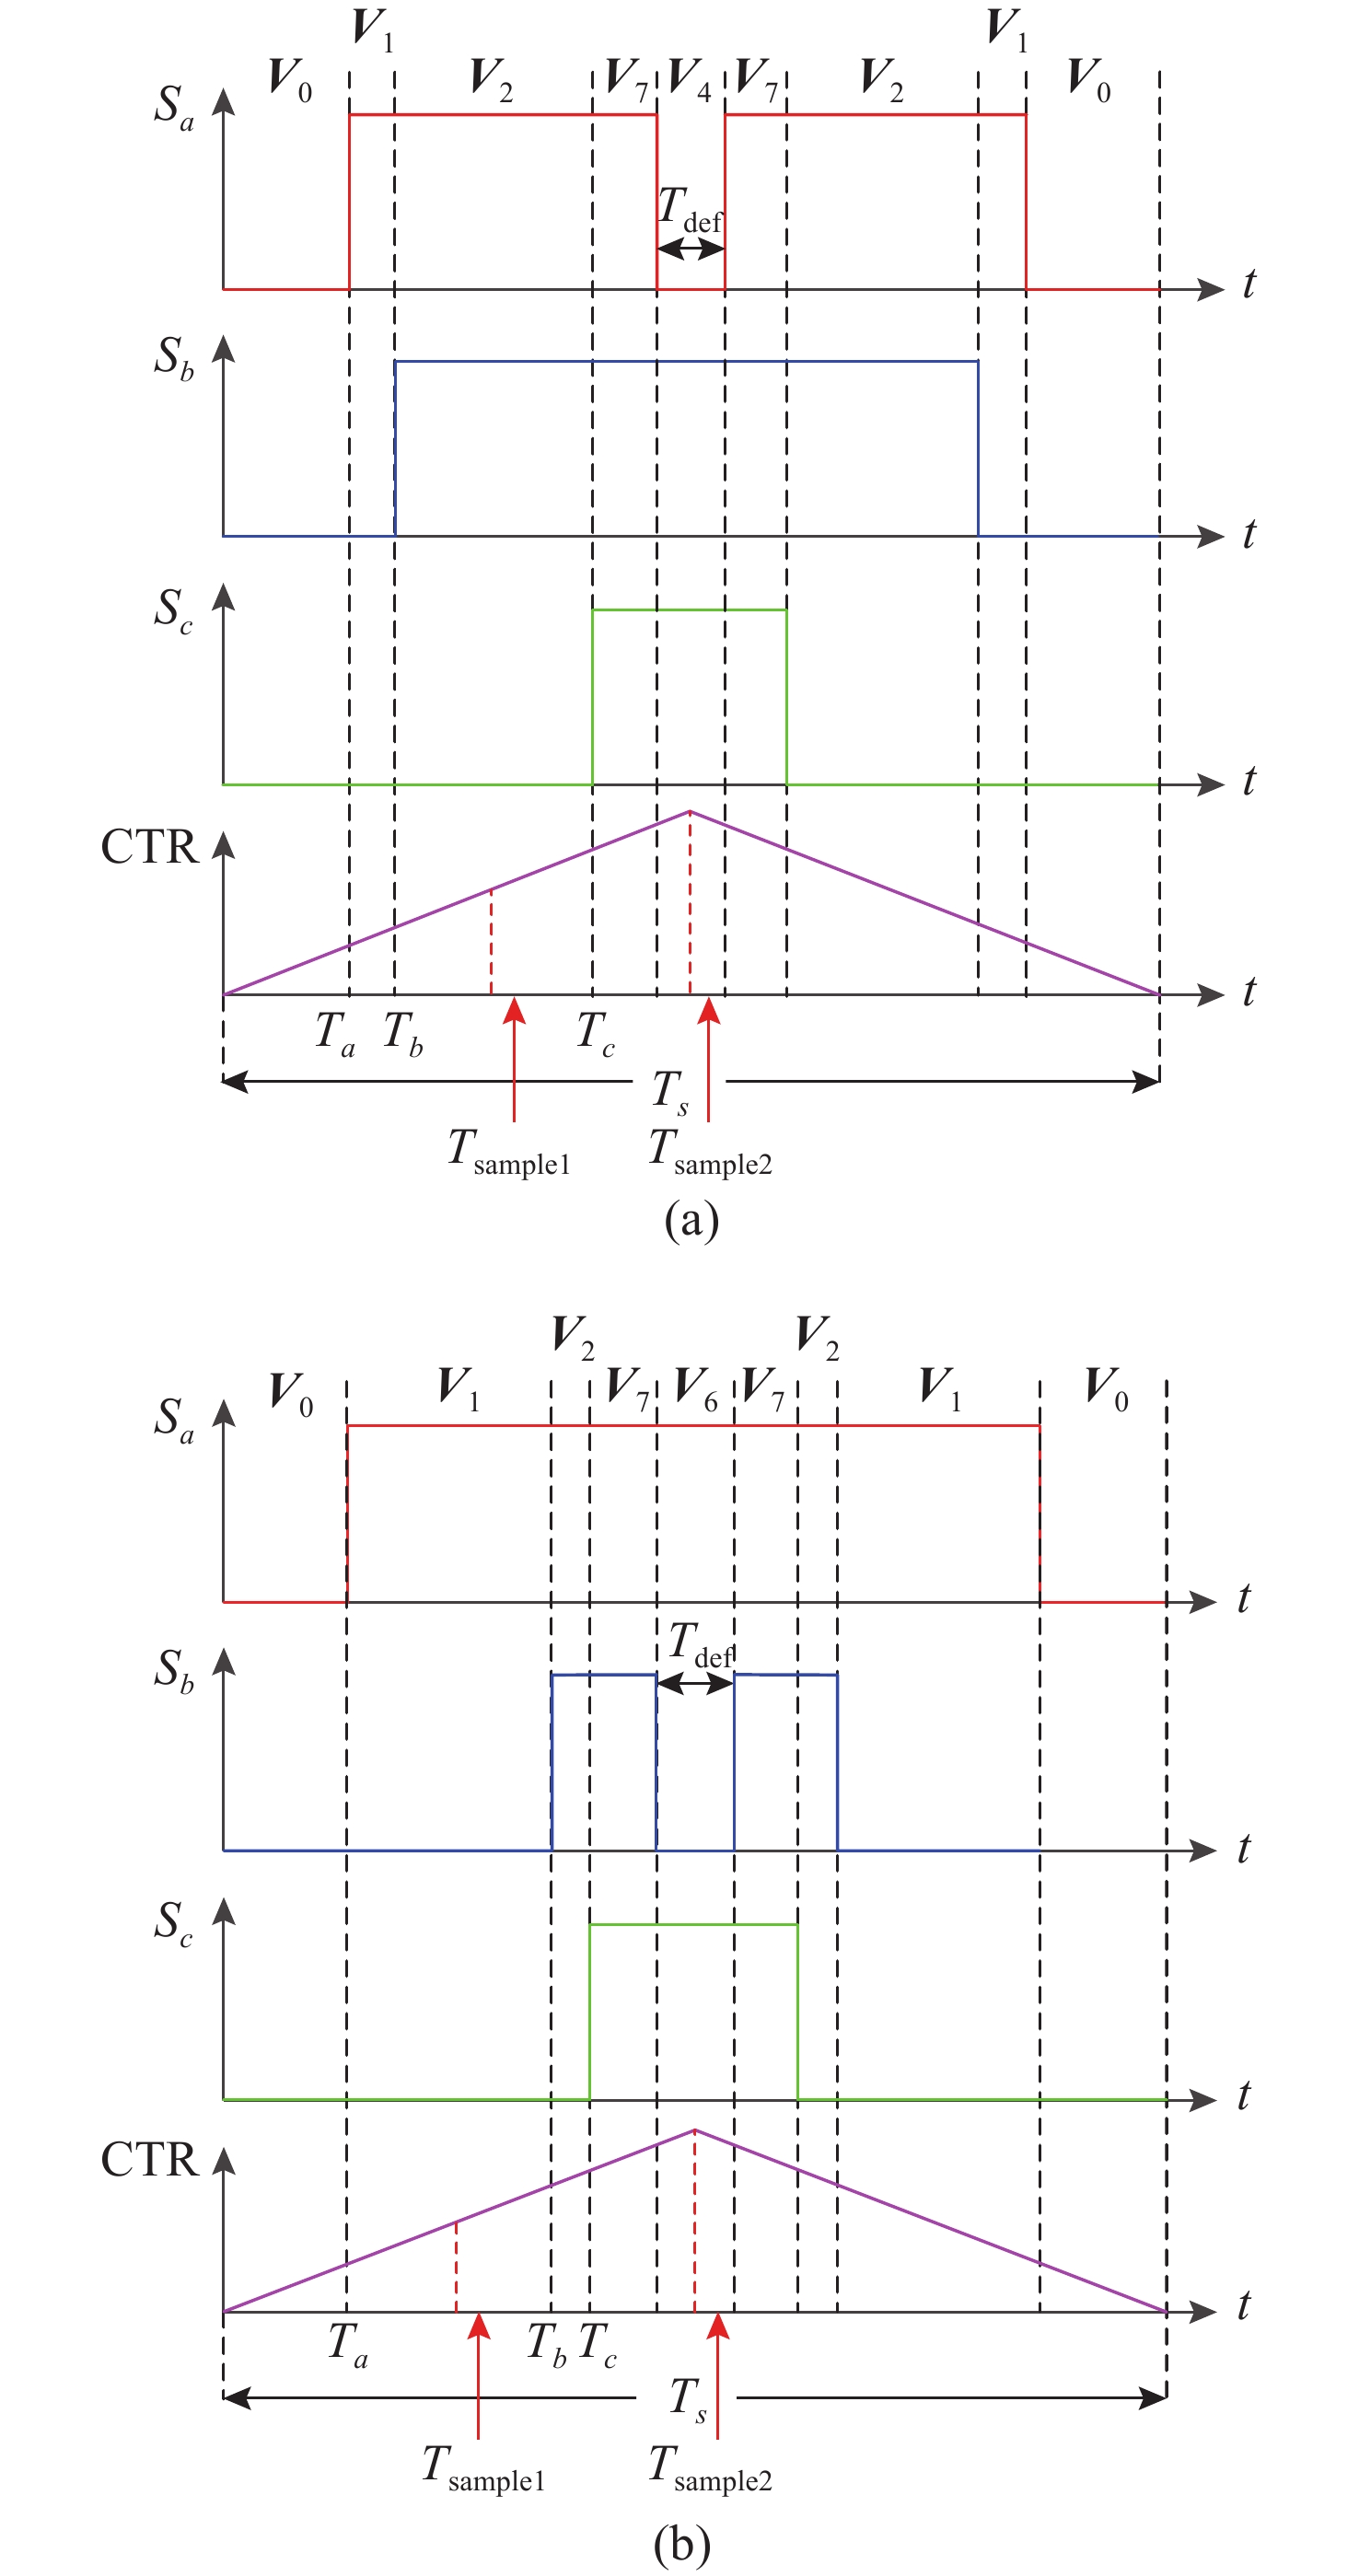
图 11 插入测量矢量之后的第 I 扇区边界上的开关信号与采样时间
Figure 11. Switching signals and sampling time at sector I boundary with inserted measurement vector
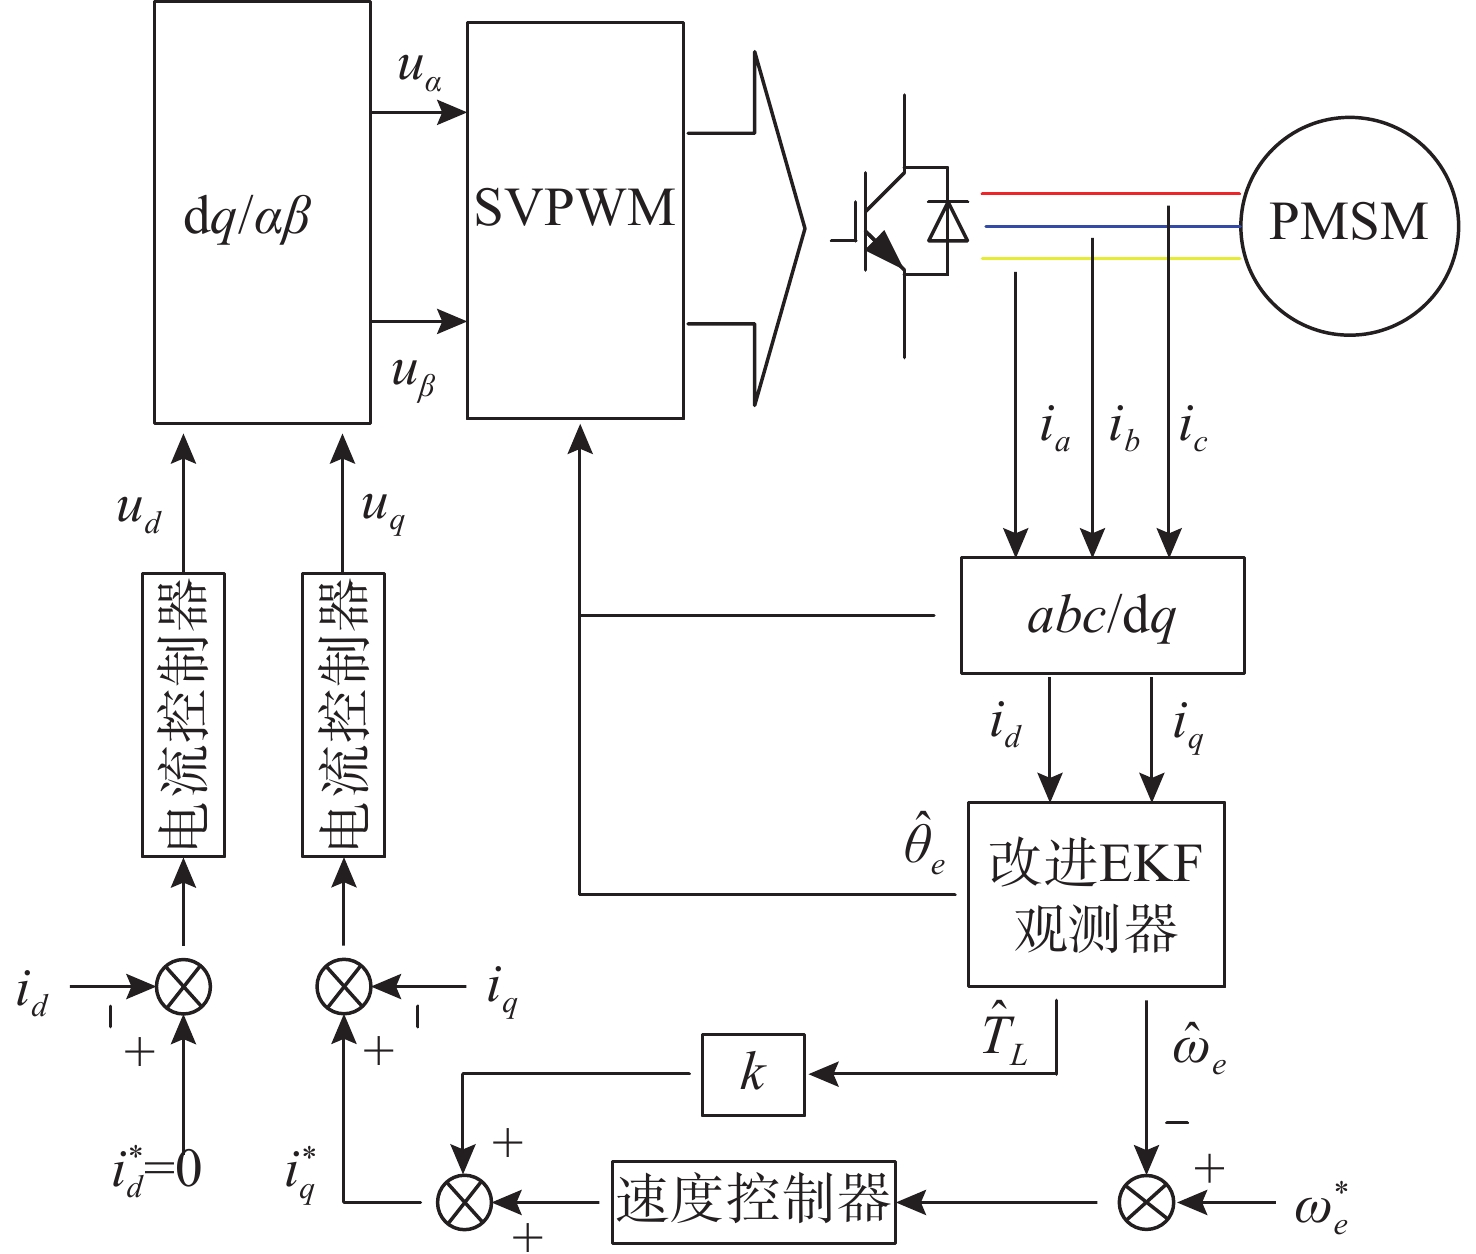
图 12 无感控制系统框图
注: 上标*表示对应物理量的参考值, 上标^表示对应物理量的估计值; PMSM(permanent magnet synchronous motor)为永磁同步电机。
Figure 12. Sensorless control system block diagram
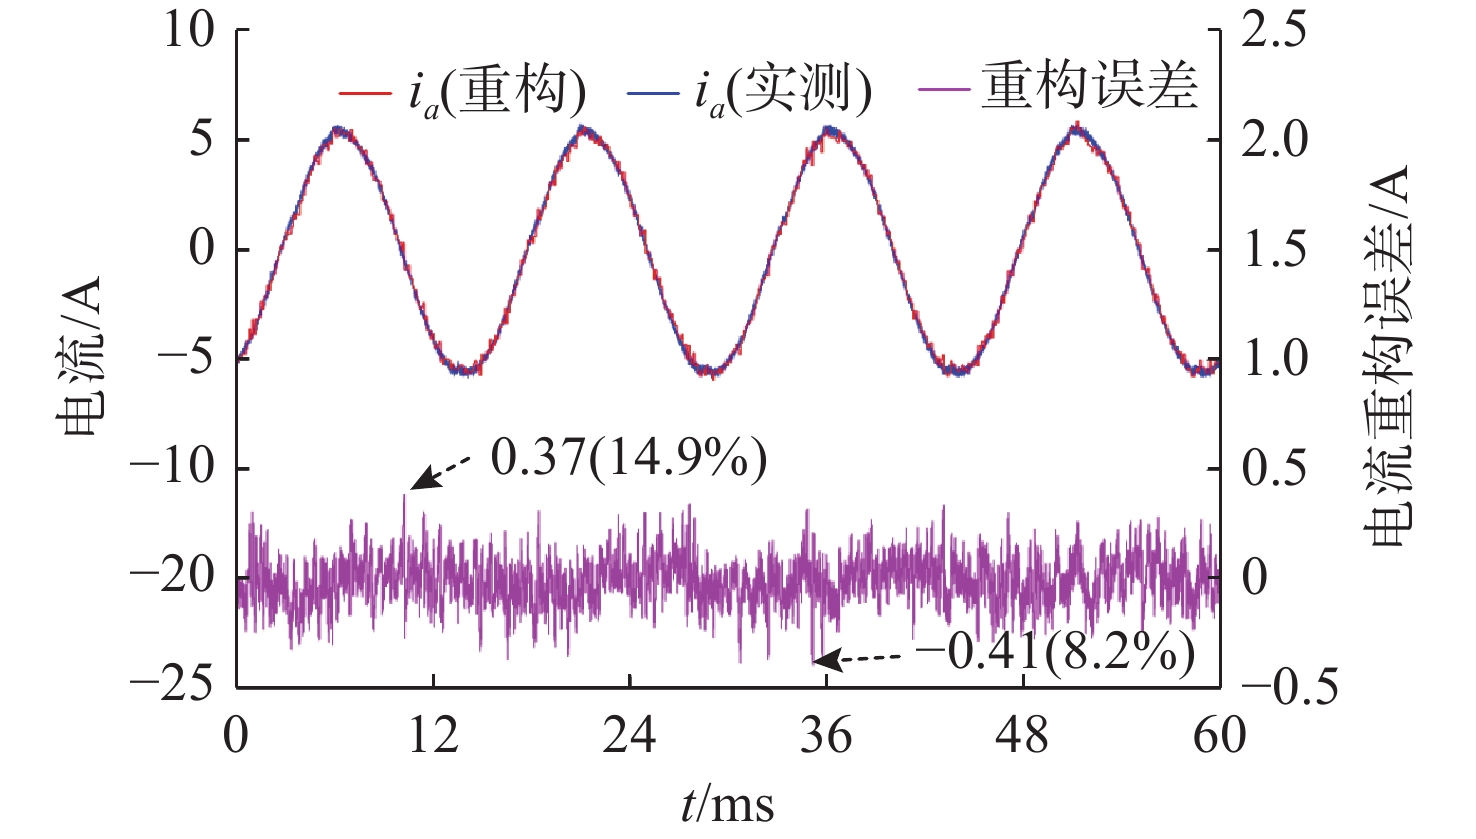
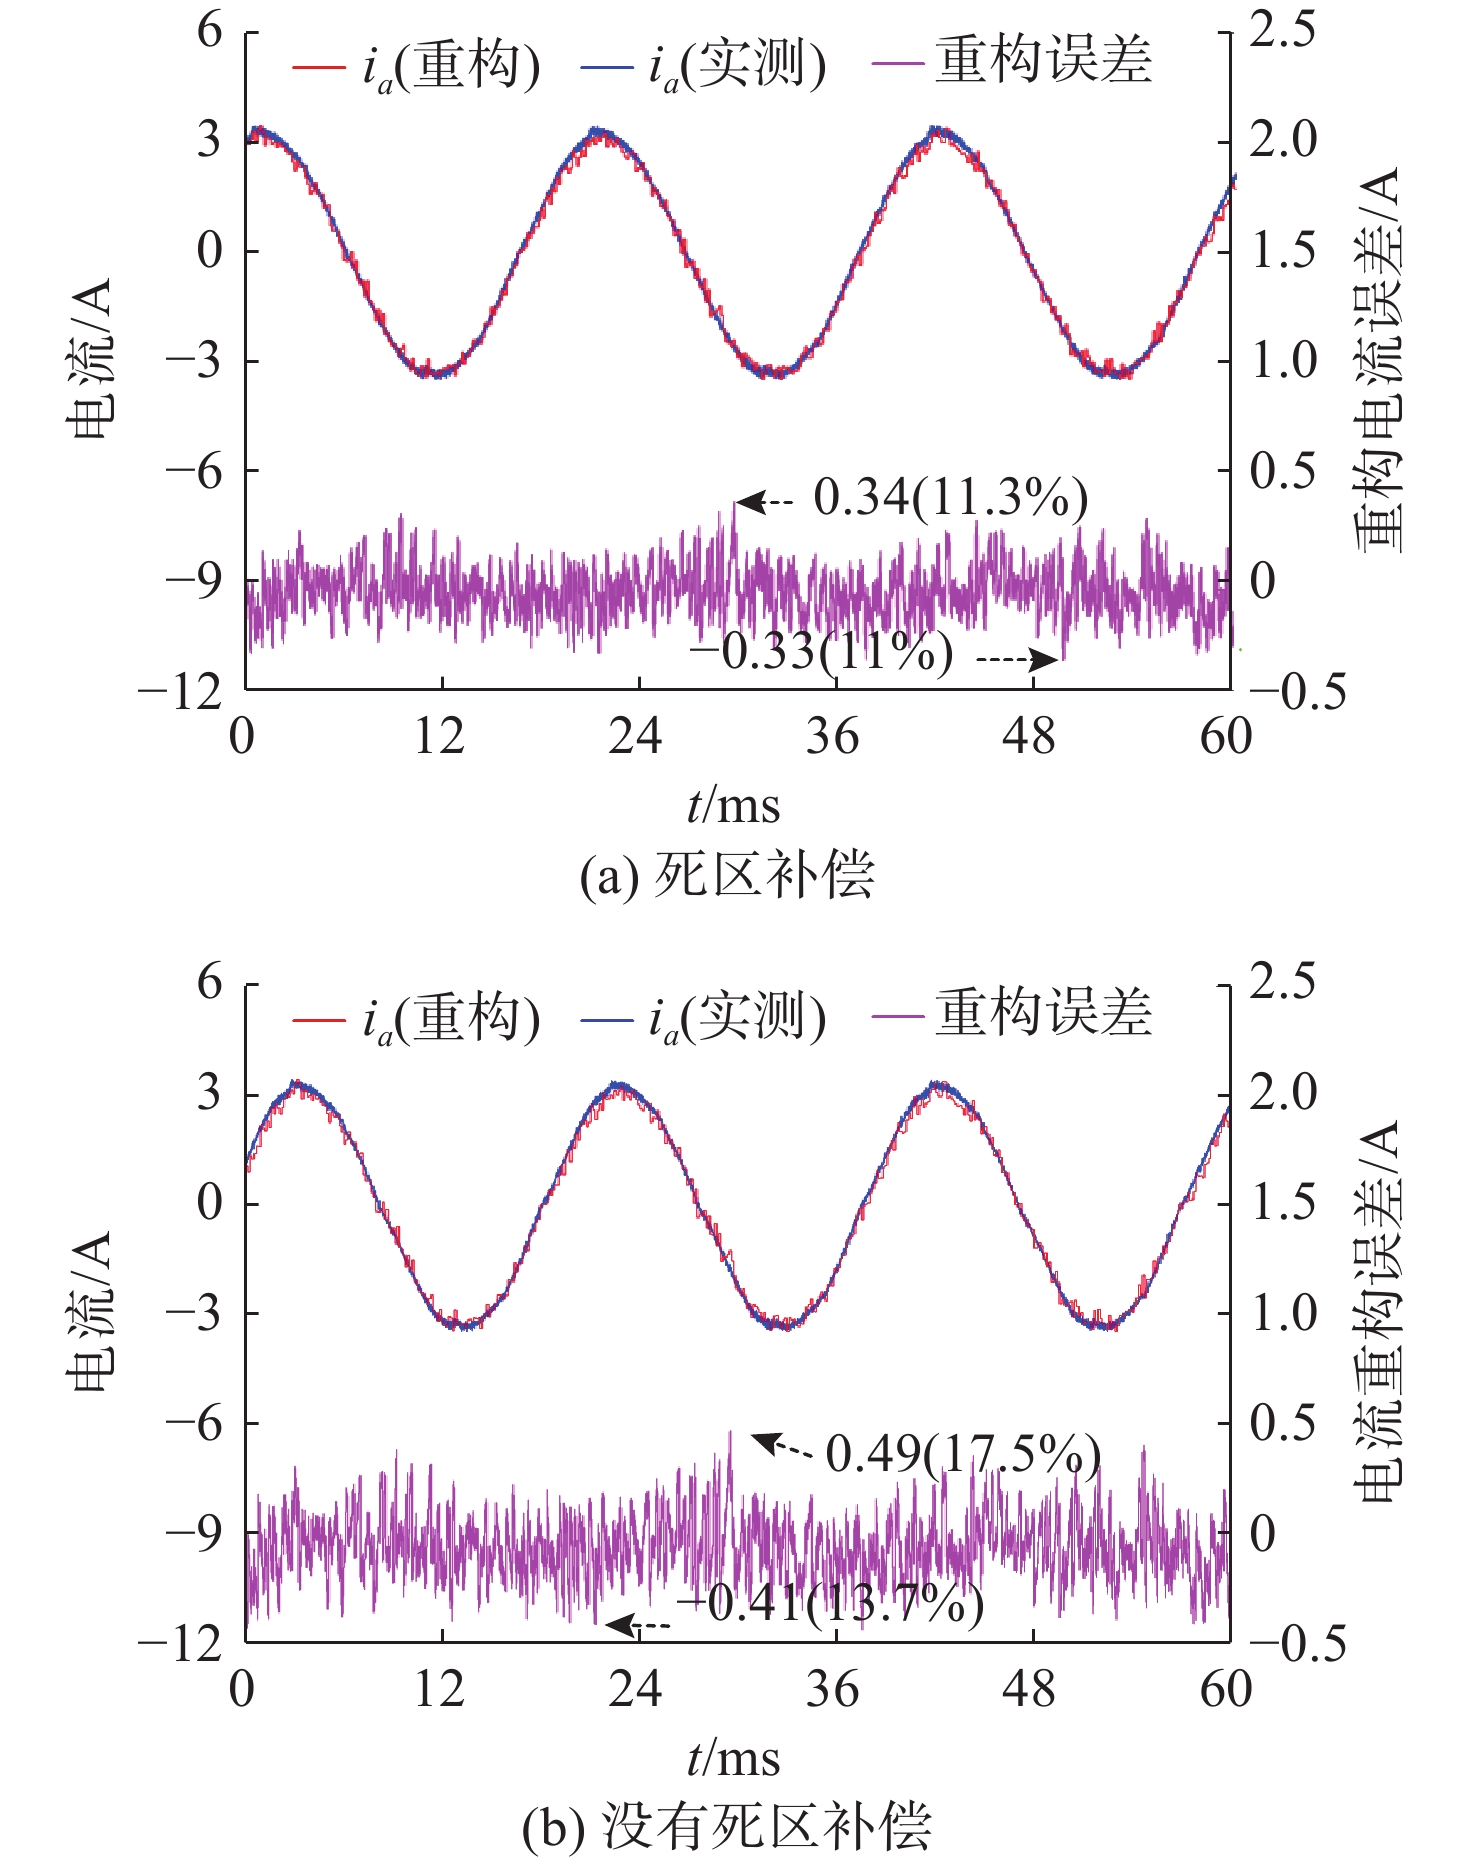
图 19 高速时的实际相电流波形和重构相电流波形
Figure 19. Actual and reconstructed phase current waveform at high speed condition
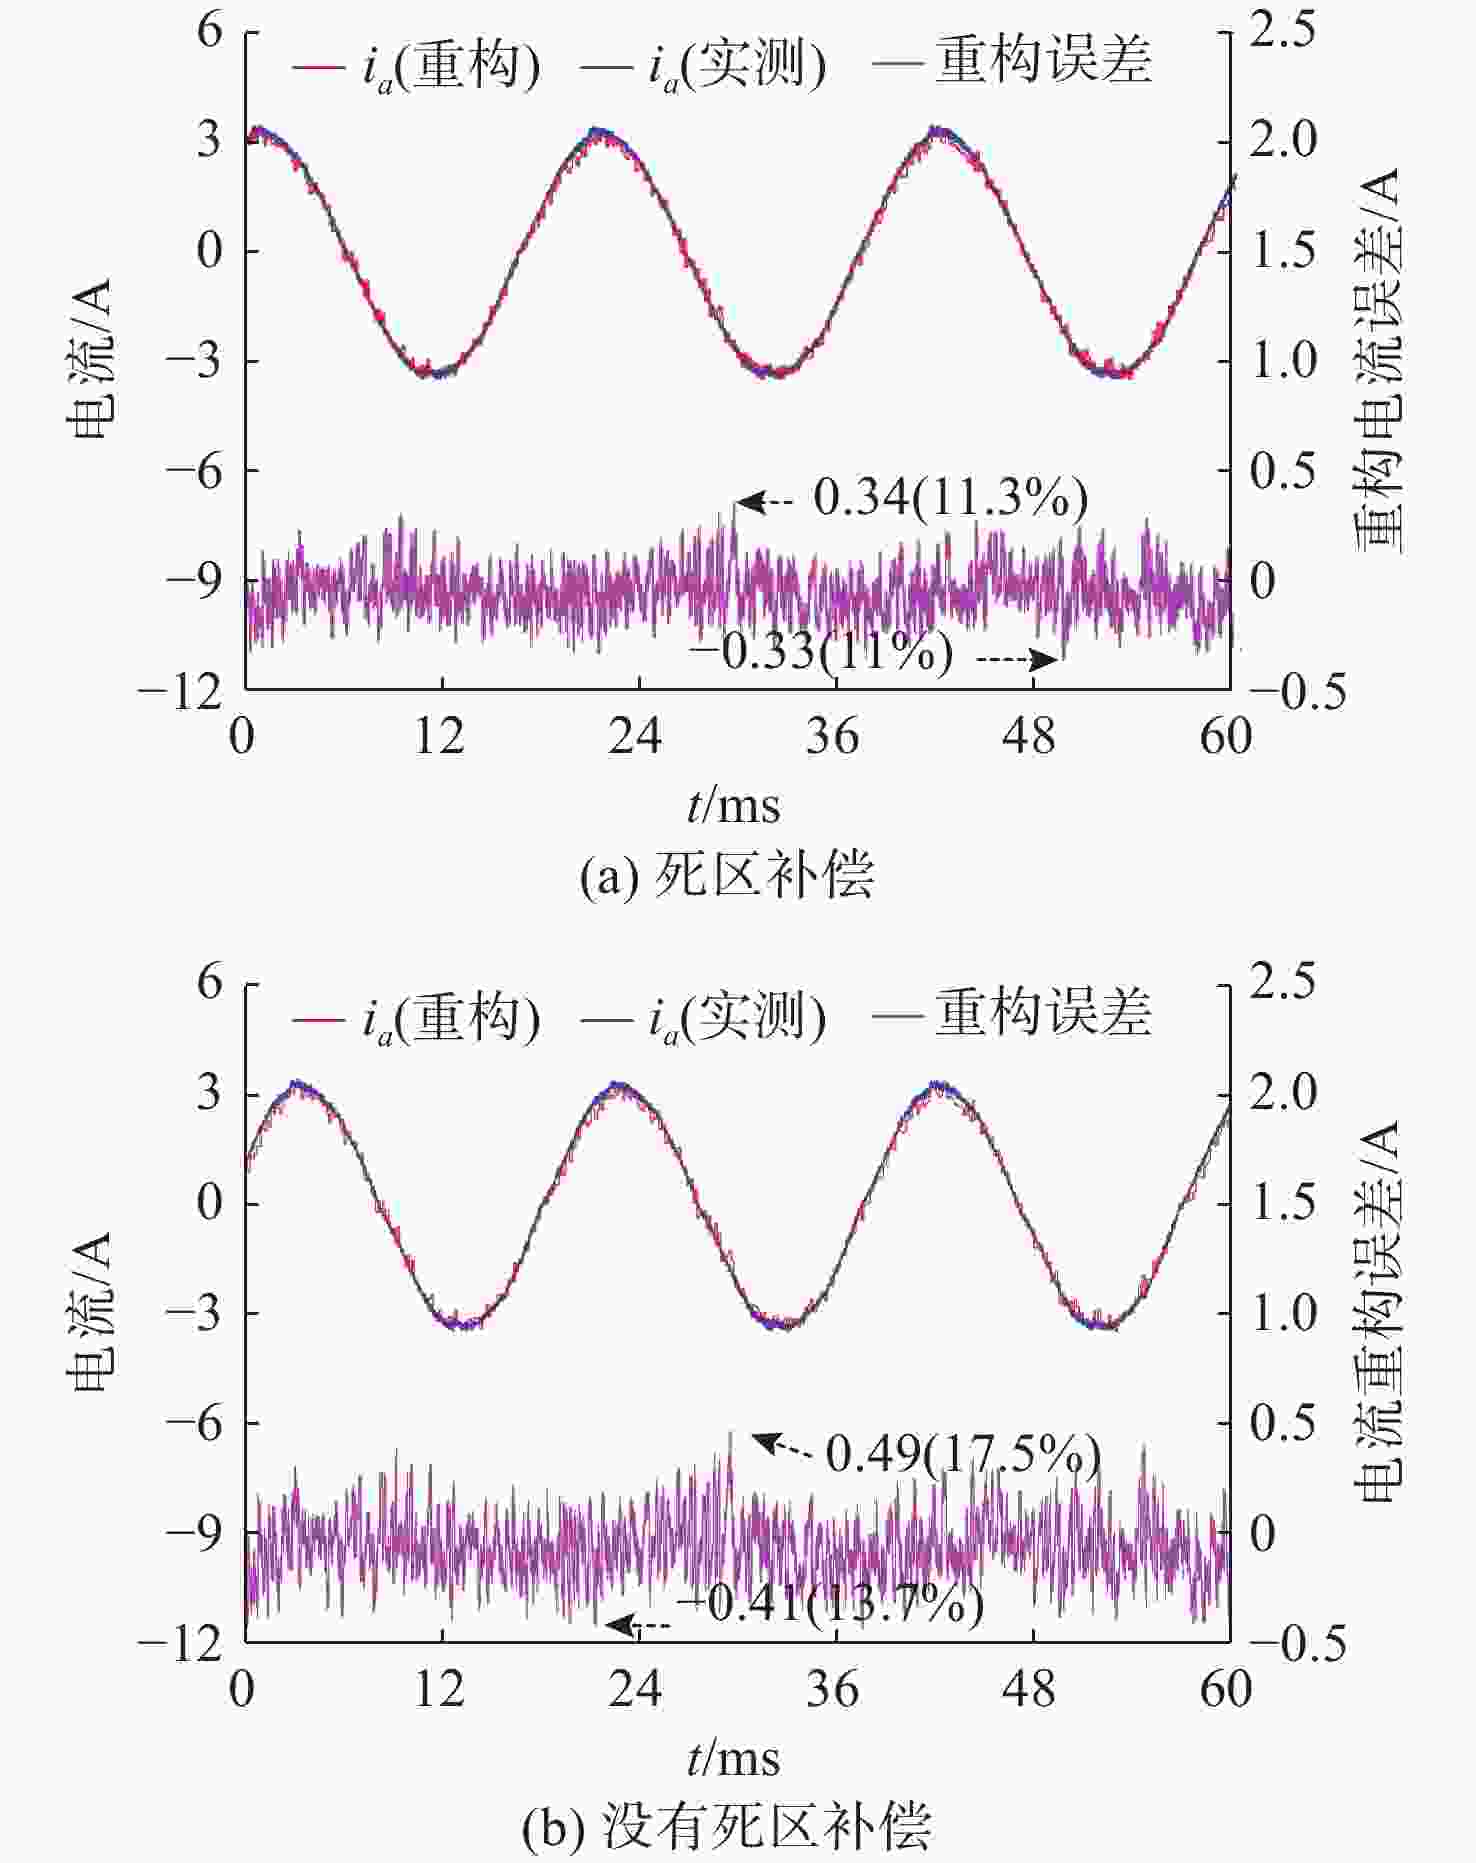
图 20 低速时的实际相电流波形和重构相电流波形
Figure 20. Actual and reconstructed phase current waveform at low speed condition
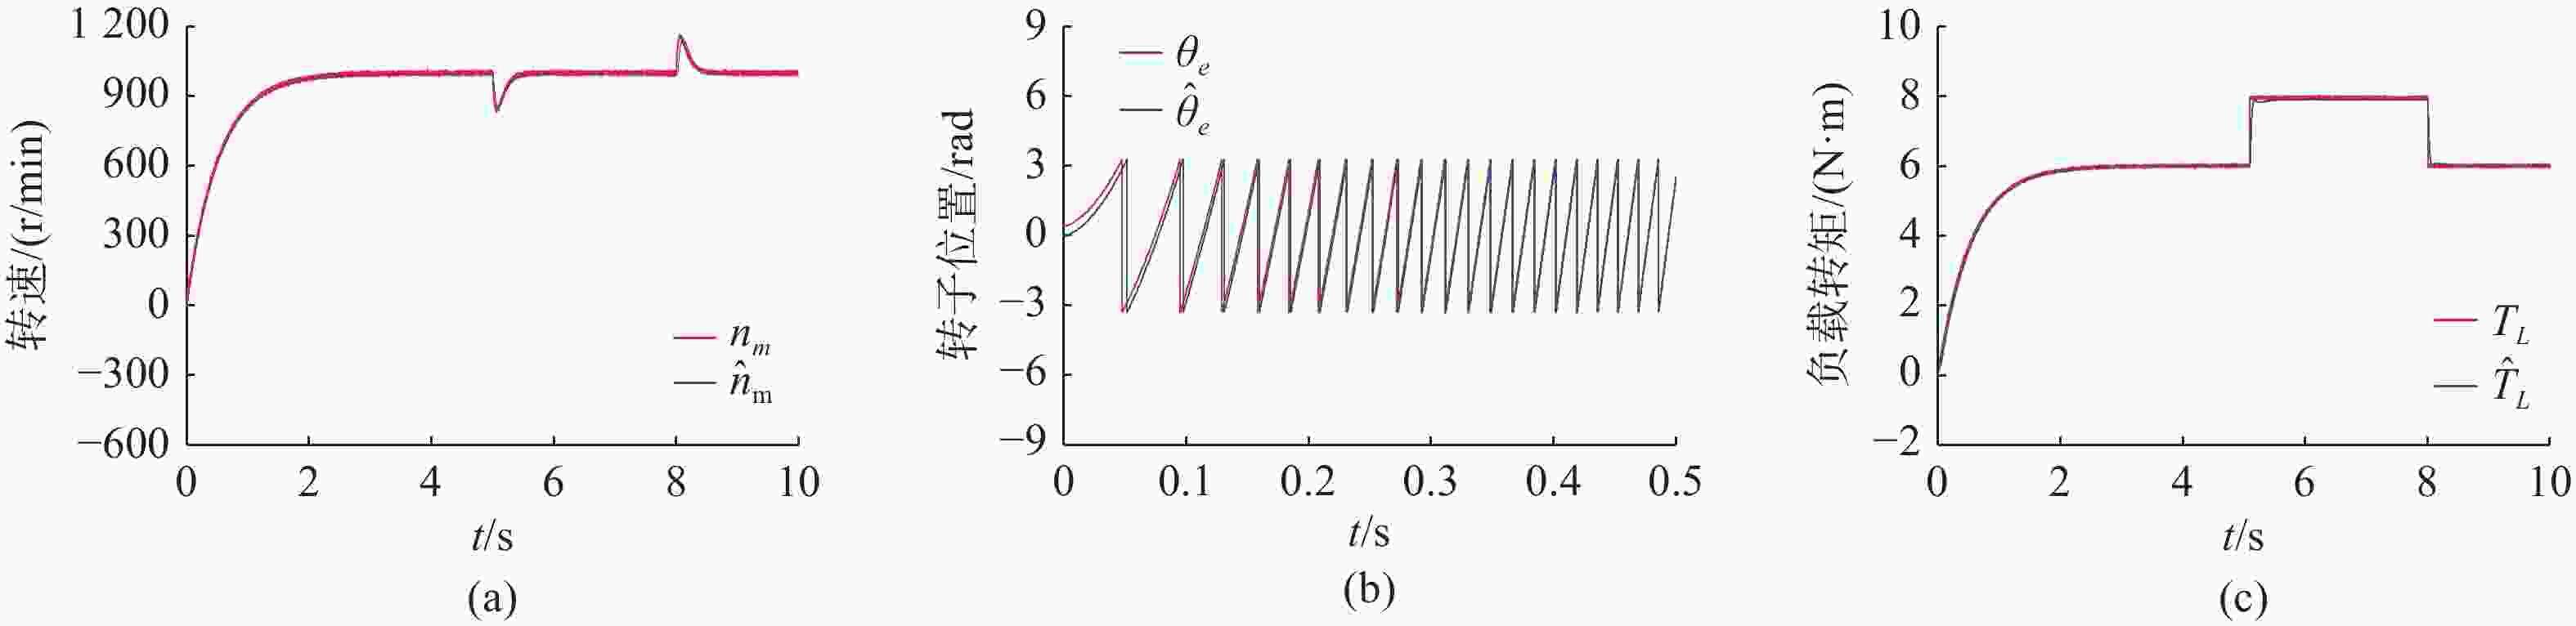
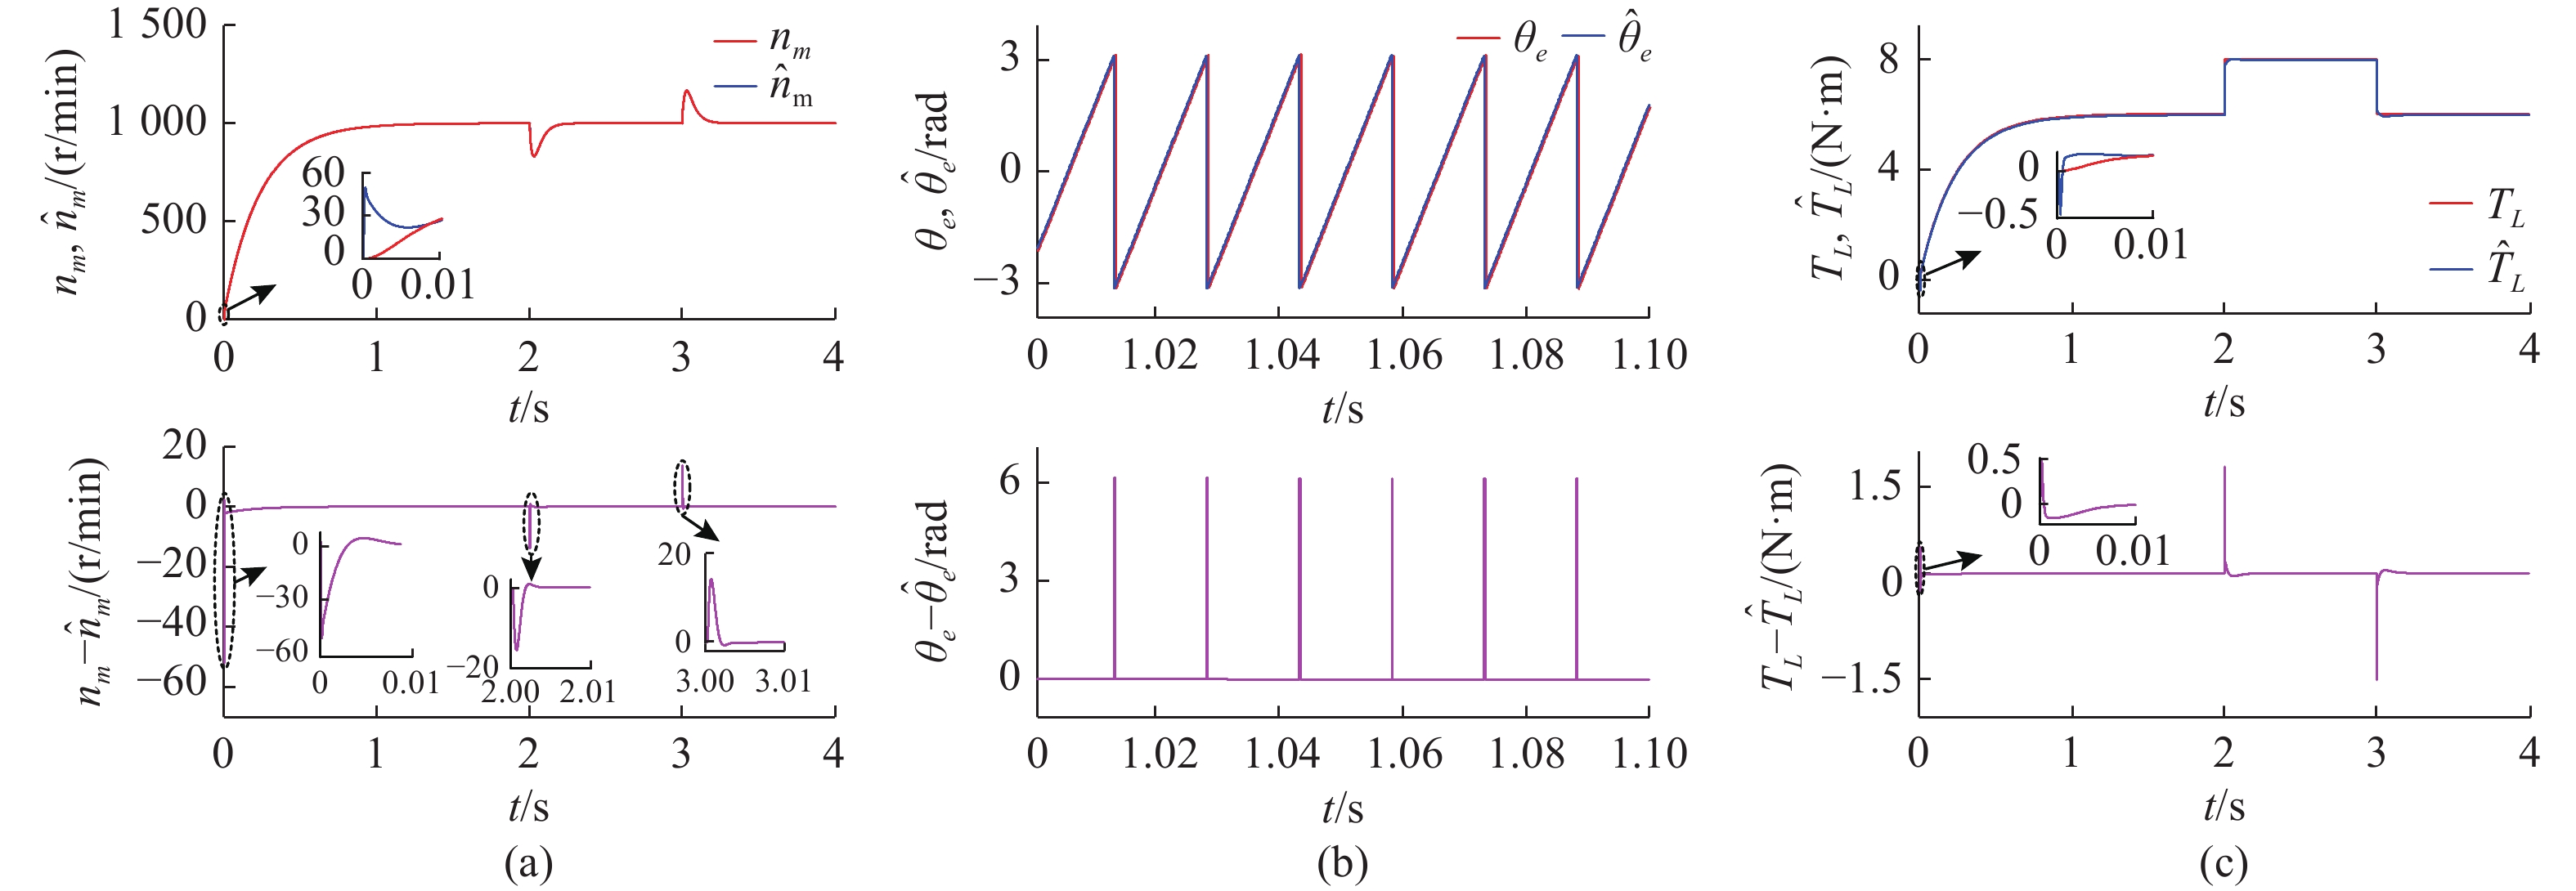
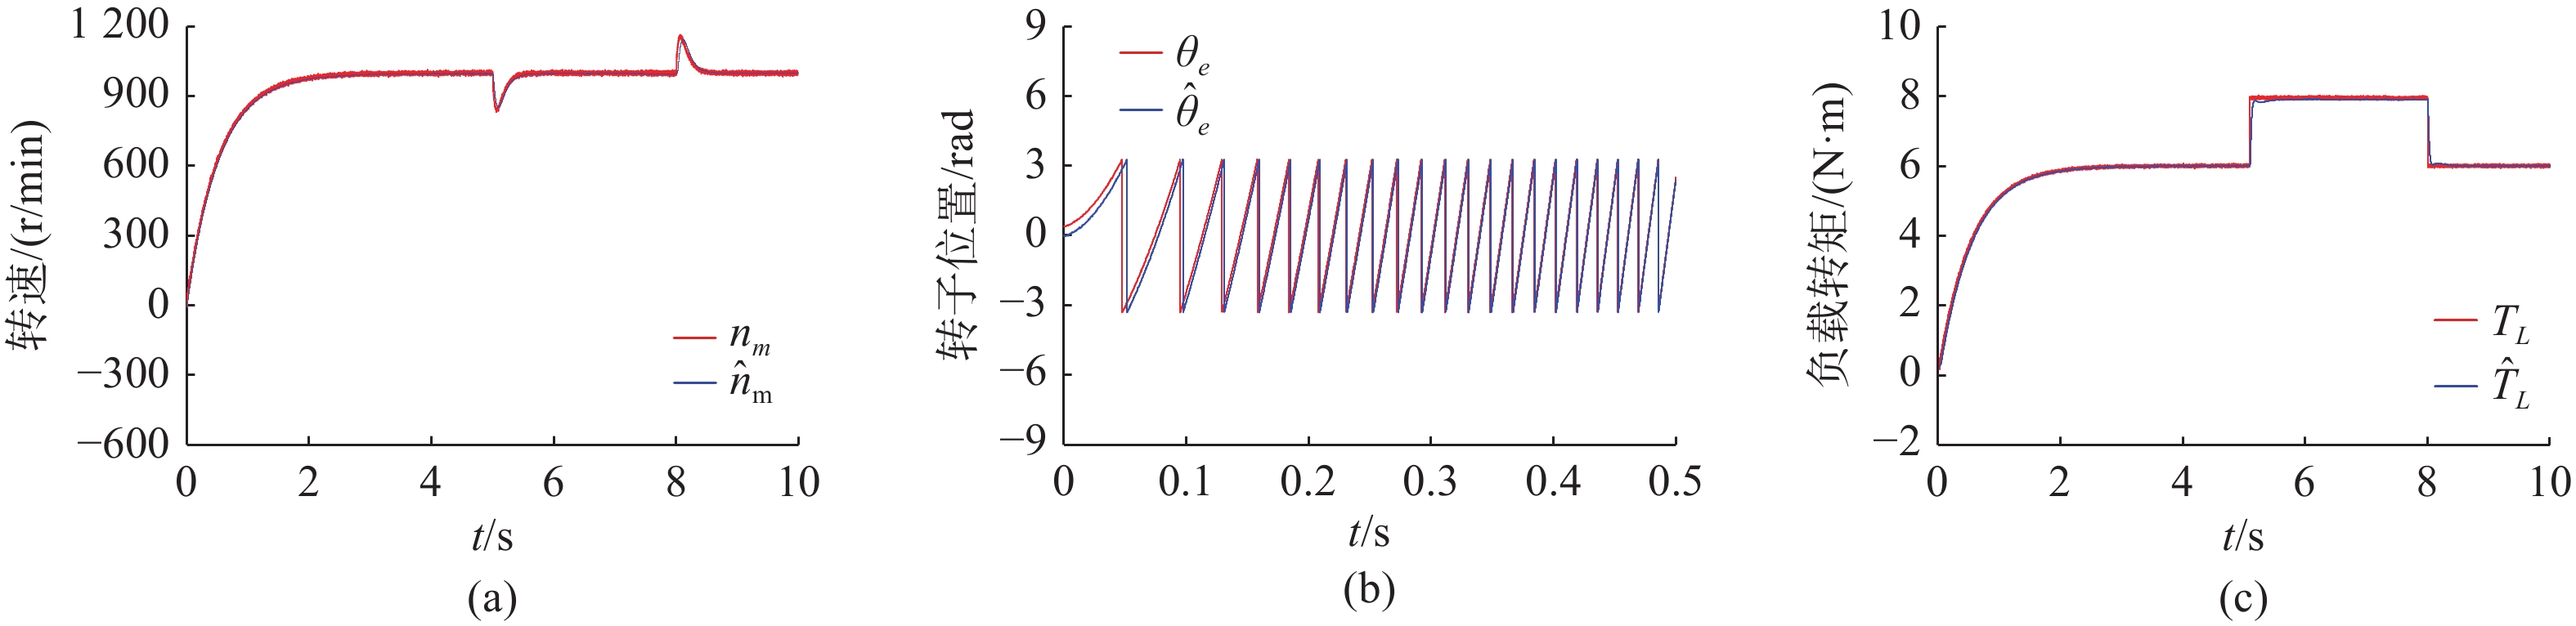
图 21 估计与实测转速、转子位置及负载转矩的对比
Figure 21. Comparison of estimated and measured speed, rotor position, and load torque
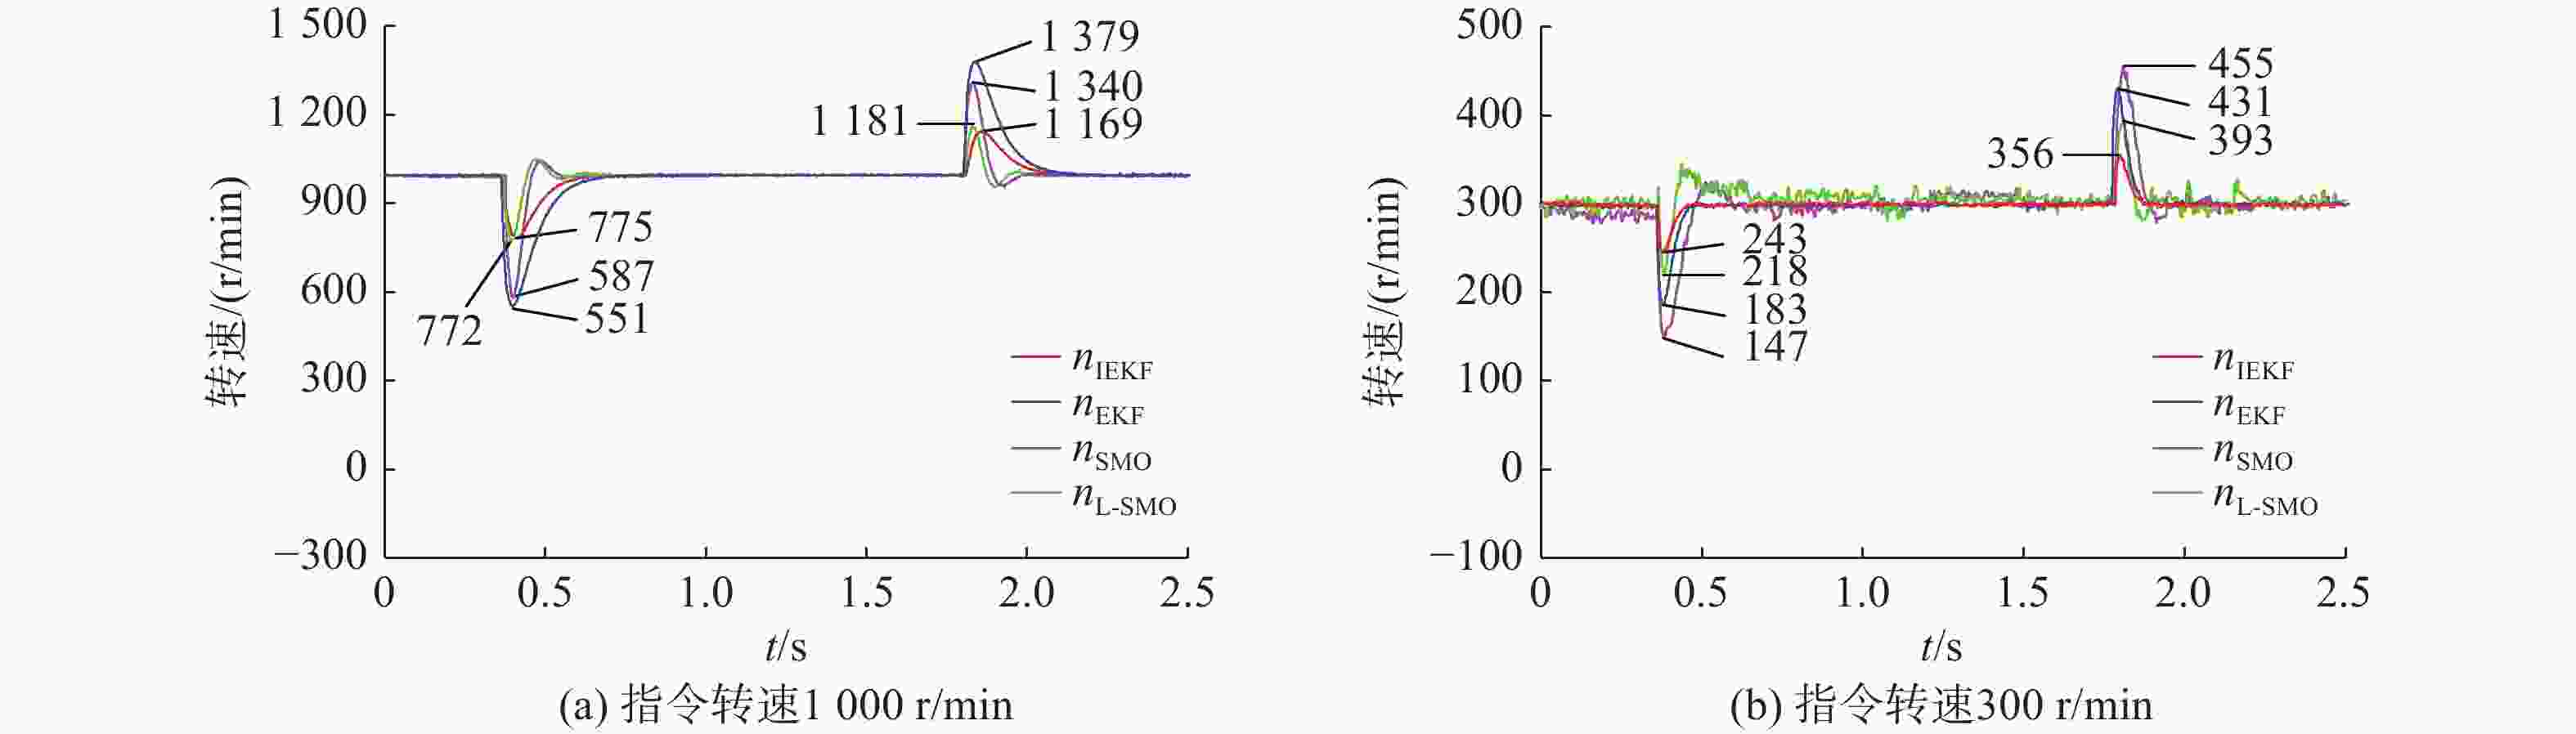
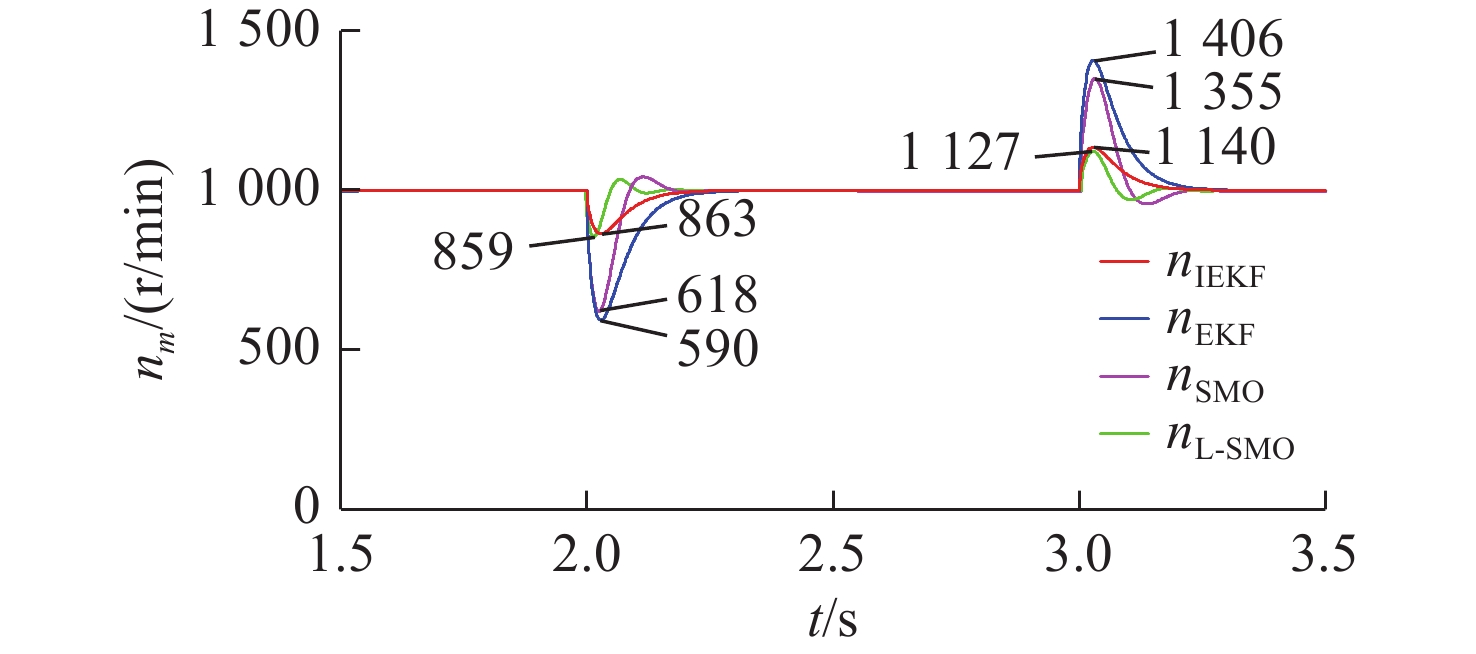
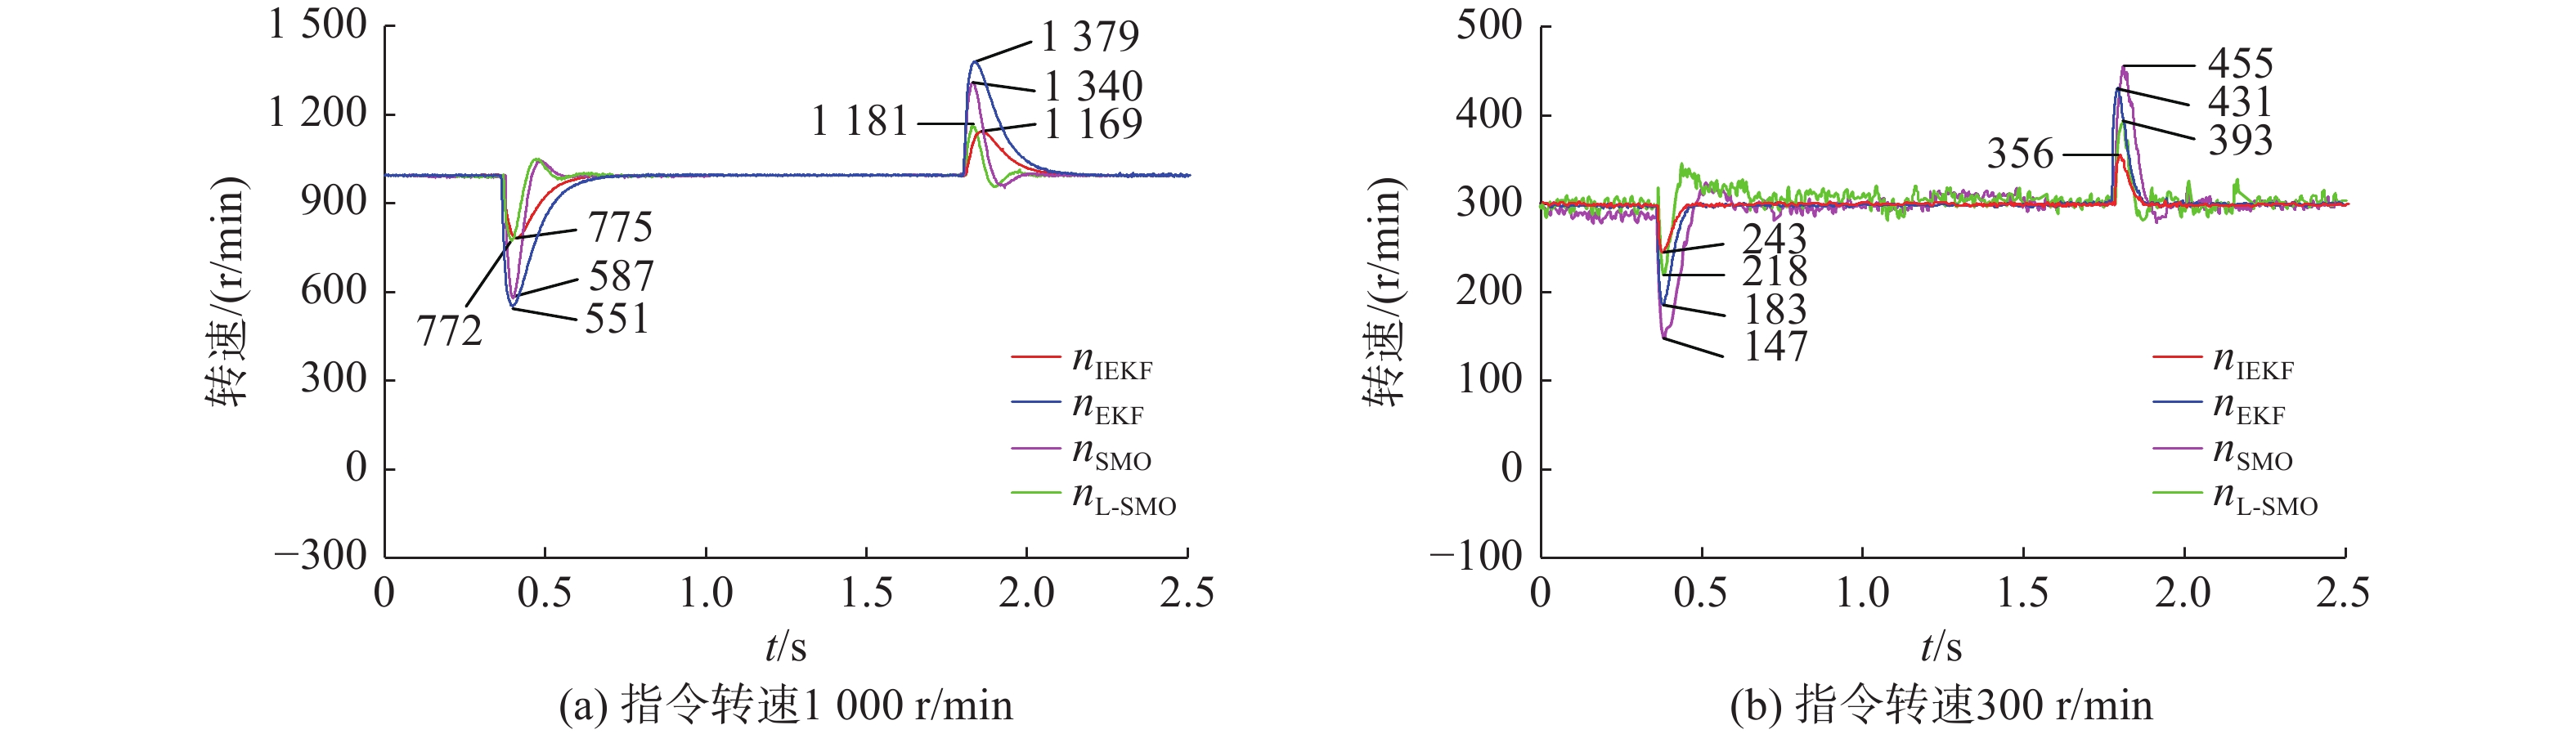
图 22 不同无感控制方法在加减载时的性能对比
Figure 22. Performance comparison of different sensorless control methods under loading and unloading conditions
表 1 直流母线电流与电机相电流的关系
Table 1. Relationship between DC bus current and motor phase current
基本电压矢量 直流母线电流 $ {\boldsymbol{V}}_{1}(100) $ $ {i}_{a} $ $ {\boldsymbol{V}}_{2}(110) $ $ -{i}_{c} $ $ {\boldsymbol{V}}_{3}(010) $ $ {i}_{b} $ $ {\boldsymbol{V}}_{4}(011) $ $ -{i}_{a} $ $ {\boldsymbol{V}}_{5}(001) $ $ {i}_{c} $ $ {\boldsymbol{V}}_{6}(101) $ $ -{i}_{b} $  下载: 导出CSV
表 2 电压矢量作用时间与测量矢量
Table 2. Voltage vector action time and measurement vector
扇区 基本电压矢量作用时间调整 测量矢量选取 I $ {T}_{1} \lt {T}_{\min } $ $ {T}_{1}+{T}_{\text{def}}, {T}_{2} $ $ {\boldsymbol{V}}_{4} $ $ {T}_{2} \lt {T}_{\min } $ $ {T}_{1}-{T}_{\text{def}}, {T}_{2}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{6} $ II $ {T}_{2} \lt {T}_{\min } $ $ {T}_{2}+{T}_{\text{def}}, {T}_{3}-{T}_{\text{def}} $ $ {\boldsymbol{V}}_{4} $ $ {T}_{3} \lt {T}_{\min } $ $ {T}_{2}, {T}_{3}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{6} $ Ⅲ $ {T}_{3} \lt {T}_{\min } $ $ {T}_{3}+{T}_{\text{def}}, {T}_{4} $ $ {\boldsymbol{V}}_{6} $ $ {T}_{4} \lt {T}_{\min } $ $ {T}_{3}-{T}_{\text{def}}, {T}_{4}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{2} $ IV $ {T}_{4} \lt {T}_{\min } $ $ {T}_{4}+{T}_{\text{def}}, {T}_{5}-{T}_{\text{def}} $ $ {\boldsymbol{V}}_{6} $ $ {T}_{5} \lt {T}_{\min } $ $ {T}_{4}, {T}_{5}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{2} $ V $ {T}_{5} \lt {T}_{\min } $ $ {T}_{5}+{T}_{\text{def}}, {T}_{6} $ $ {\boldsymbol{V}}_{2} $ $ {T}_{6} \lt {T}_{\min } $ $ {T}_{5}-{T}_{\text{def}}, {T}_{6}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{4} $ VI $ {T}_{6} \lt {T}_{\min } $ $ {T}_{1}-{T}_{\text{def}}, {T}_{6}+{T}_{\text{def}} $ $ {\boldsymbol{V}}_{2} $ $ {T}_{1} \lt {T}_{\min } $ $ {T}_{1}+{T}_{\text{def}}, {T}_{6} $ $ {\boldsymbol{V}}_{4} $
下载: 导出CSV
表 3 永磁同步电机主要参数
Table 3. Parameters of permanent magnet synchronous motor
参数 数值 磁链/Wb 0.175 定子电阻/Ω 2.874 定子交轴电感/mH 8.4 定子直轴电感/mH 8.4 极对数 4 额定转速/(r/min) 1 500 额定电流/A 10 转动惯量/(kg·m2) 0.010 2 粘滞系数 0.01
下载: 导出CSV
-
[1] Hasan K, Ahmad S, Liaf A F, et al. Oceanic challenges to technological solutions: a review of autonomous underwater vehicle path technologies in biomimicry, control, navigation, and sensing[J]. IEEE Access, 2024(12): 46202-46231. doi: 10.1109/access.2024.3380458 [2] Neira J, Sequeiros C, Huamani R, et al. Review on unmanned underwater robotics, structure designs, materials, sensors, actuators, and navigation control[J]. Journal of Robotics, 2021(1): 5542920. doi: 10.1155/2021/5542920 [3] Ahn H, Park H, Kim C, et al. A review of state-of-the-art techniques for PMSM parameter identification[J]. Journal of Electrical Engineering & Technology, 2020, 15(3): 1177-1187. doi: 10.1007/s42835-020-00398-6 [4] Singh S, Singh S N, Tiwari A N. PMSM drives and its application: an overview[J]. Recent Advances in Electrical & Electronic Engineering, 2023, 16(1): 4-16. [5] Petillot Y R, Antonelli G, Casalino G, et al. Underwater robots: From remotely operated vehicles to intervention-autonomous underwater vehicles[J]. IEEE Robotics & Automation Magazine, 2019, 26(2): 94-101. doi: 10.1109/MRA.2019.2908063 [6] 张立广, 朱修辉, 姚明亮, 等. 基于脉宽调制中点采样移相的无刷直流电机相电流重构方法[J]. 电机与控制应用, 2025, 52(7): 758-768.Zhang L G, Zhu X H, Yao M L, et al. Phase current reconstruction method for brushless DC motor based on pulse width modulation midpoint sampling phase shift[J]. Electric Machines & Control Application, 2025, 52(7): 758-768. [7] 许观达, 肖飞, 连传强, 等. 三相永磁同步电机单电流传感器矢量控制策略[J]. 电力系统保护与控制, 2022, 50(23): 104-111. doi: 10.19783/j.cnki.pspc.220211Xu G D, Xiao F, Lian C Q, et al. Vector control strategy of three-phase permanent magnet synchronous motor with single current sensor[J]. Power System Protection and Control, 2022, 50(23): 104-111. doi: 10.19783/j.cnki.pspc.220211 [8] Gu Y, Ni F, Yang D, et al. Switching-state phase shift method for three-phase-current reconstruction with a single dc-link current sensor[J]. IEEE Transactions on Industrial Electronics, 2011, 58(11): 5186-5194. doi: 10.1109/TIE.2011.2123854 [9] 顾义坤, 倪风雷, 杨大鹏, 等. 基于母线电流传感器的相电流重构方法[J]. 电机与控制学报, 2009, 13(6): 811-816. doi: 10.15938/j.emc.2009.06.019Gu Y K, Ni F L, Yang D P, et al. Phase current reconstruction method based on DC-link current sensor[J]. Electric Machines and Control, 2009, 13(6): 811-816. doi: 10.15938/j.emc.2009.06.019 [10] Wang C M, Lin S K. A simple single shunt current reconstruction approach for low-cost permanent magnet synchronous motor drives[C]//2015 International Automatic Control Conference (CACS). 2015: 79-84. [11] Song Y, Lu J, Hu Y, et al. Expanding limit of minimum sampling time using auxiliary vectors for PMSM drives with single DC-link current sensor[J]. IEEE Transactions on Industrial Electronics, 2022, 70(4): 3437-3448. doi: 10.1109/tie.2022.3174279 [12] Lee H, Hong S, Choi J, et al. Sector-based analytic overmodulation method[J]. IEEE Transactions on Industrial Electronics, 2019, 66(10): 7624-7632. doi: 10.1109/TIE.2018.2883270 [13] Zhao J, Nalakath S, Emadi A. A high frequency injection technique with modified current reconstruction for low-speed sensorless control of IPMSMs with a single DC-link current sensor[J]. IEEE Access, 2019, 7: 136137-136147. doi: 10.1109/ACCESS.2019.2942148 [14] Zuo Y, Lai C, Iyer K L V. A review of sliding mode observer based sensorless control methods for PMSM drive[J]. IEEE Transactions on Power Electronics, 2023, 38(9): 11352-11367. doi: 10.1109/TPEL.2023.3287828 [15] Kashif M, Singh B. Modified active-power MRAS based adaptive control with reduced sensors for PMSM operated solar water pump[J]. IEEE Transactions on Energy Conversion, 2022, 38(1): 38-52. doi: 10.1109/tec.2022.3197564 [16] 张国强, 杜锦华. 永磁同步电机无位置传感器控制技术综述[J]. 电机与控制应用, 2024, 51(1): 1-13. doi: 10.12177/emca.2023.165Zhang G Q, Du J H. Review of position sensorless control technology for permanent magnet synchronous motors[J]. Electric Machines & Control Application, 2024, 51(1): 1-13. doi: 10.12177/emca.2023.165 [17] 刘计龙, 肖飞, 沈洋, 等. 永磁同步电机无位置传感器控制技术研究综述[J]. 电工技术学报, 2017, 32(16): 76-88. doi: 10.19595/j.cnki.1000-6753.tces.160741Liu J L, Xiao F, Shen Y, et al. Position-sensorless control technology of permanent-magnet synchronous motor—a review[J]. Transactions of China Electrotechnical Society, 2017, 32(16): 76-88. doi: 10.19595/j.cnki.1000-6753.tces.160741 [18] Wang G, Valla M, Solsona J. Position sensorless permanent magnet synchronous machine drives—A review[J]. IEEE Transactions on Industrial Electronics, 2020, 67(7): 5830-5842. doi: 10.1109/TIE.2019.2955409 [19] Tuovinen T, Hinkkanen M. Signal-injection assisted full-order observer with parameter adaptation for synchronous reluctance motor drives[C]//2013 IEEE Energy Conversion Congress and Exposition. Denver, CO, USA, 2013: 3488-3495. [20] Prabhakaran K K, Karthikeyan A. Electromagnetic torque-based model reference adaptive system speed estimator for sensorless surface mount permanent magnet synchronous motor drive[J]. IEEE Transactions on Industrial Electronics, 2020, 67(7): 5936-5947. doi: 10.1109/TIE.2020.2965499 [21] Lu W, Zhang Z, Wang D, et al. A new load torque identification sliding mode observer for permanent magnet synchronous machine drive system[J]. IEEE Transactions on Power Electronics, 2019, 34(8): 7852-7862. doi: 10.1109/TPEL.2018.2881217 [22] Hou Q, Ding S, Yu X. Composite super-twisting sliding mode control design for PMSM speed regulation problem based on a novel disturbance observer[J]. IEEE Transactions on Energy Conversion, 2020, 36(4): 2591-2599. [23] Yang C, Song B, et al. Adaptive identification of nonlinear friction and load torque for PMSM drives via a parallel-observer-based network with model compensation[J]. IEEE Transactions on Power Electronics, 2023, 38(5): 5875-5897. doi: 10.1109/TPEL.2023.3239609 [24] Wang L, Tang Z, Zhang P, et al. Double extended sliding mode observer-based synchronous estimation of total inertia and load torque for PMSM-driven spindle-tool systems[J]. IEEE Transactions on Industrial Informatics, 2022, 19(7): 8496-8507. doi: 10.1109/tii.2022.3218858 [25] Zhu C, Tu Q, Jiang C, et al. Global fast terminal sliding mode control strategy for permanent magnet synchronous motor based on load torque Luenberger observer[J]. IEICE Electronics Express, 2021, 18(19): 20210348. doi: 10.1587/elex.18.20210348 -

 下载:




 点击查看大图
计量
- 文章访问数: 1
- HTML全文浏览量: 1
- PDF下载量: 0
- 被引次数: 0