Latest Articles

Articles in press have been peer-reviewed and accepted, which are not yet assigned to volumes/issues, but are citable by Digital Object Identifier (DOI).
Display Method:
Study on Flow-Induced Vibration and Acoustic Radiation Characteristics of LUUV with Internal Frame-Stiffened Thin-Shell Wet Compartments
ZHANG Xuan, ZHU Min, DUAN Hao, ZHANG Ming, HE Zhirong, YANG Zhuangtao
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0155
Abstract:
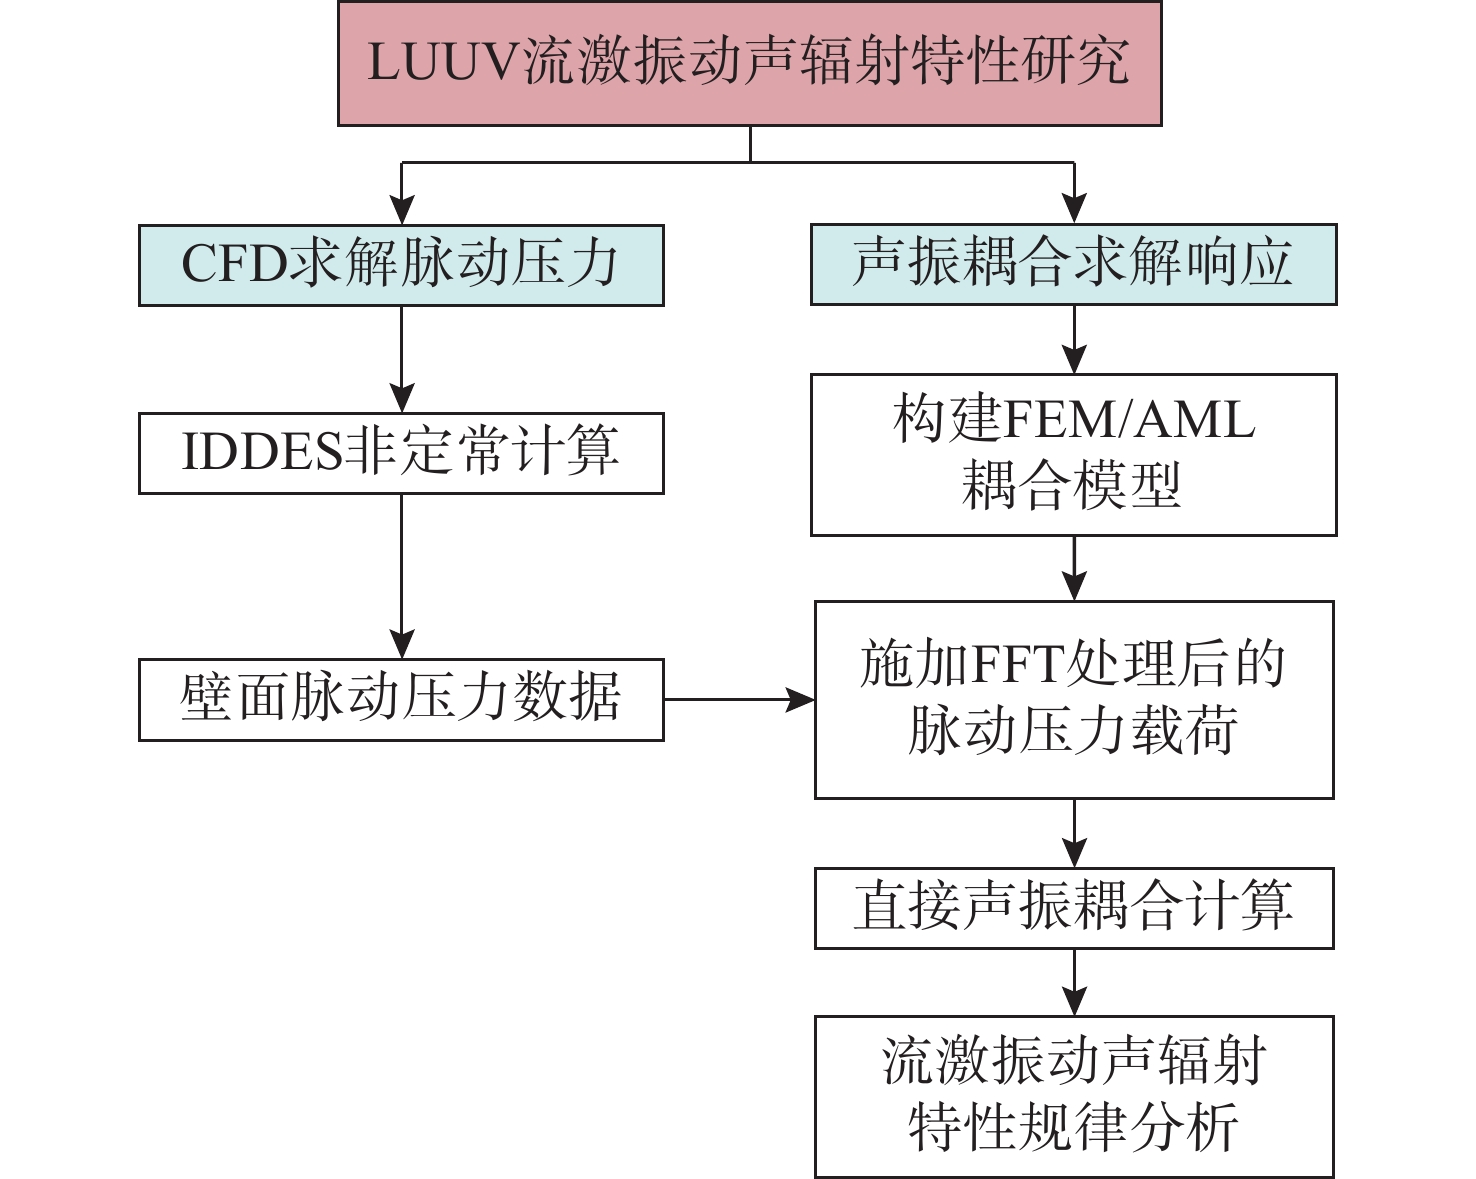
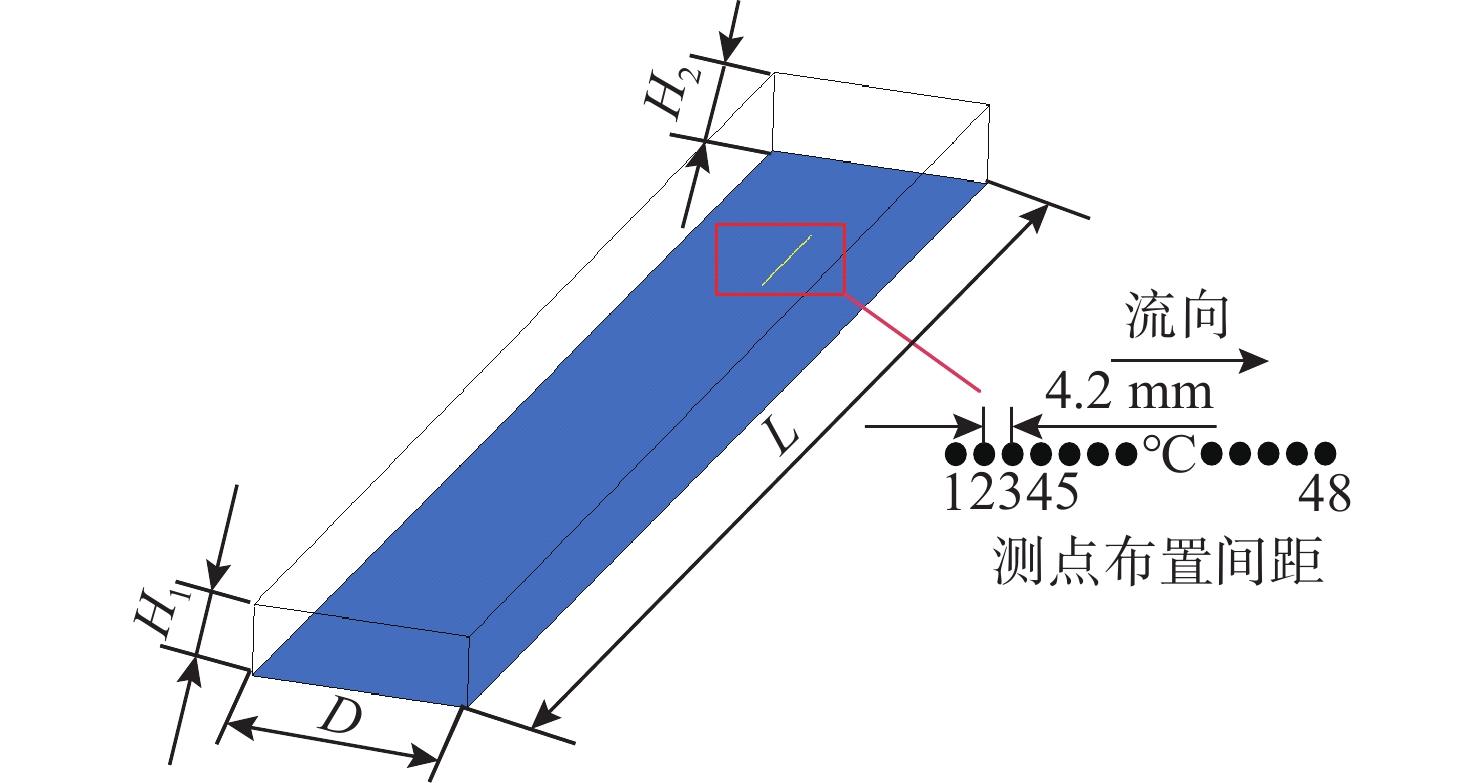
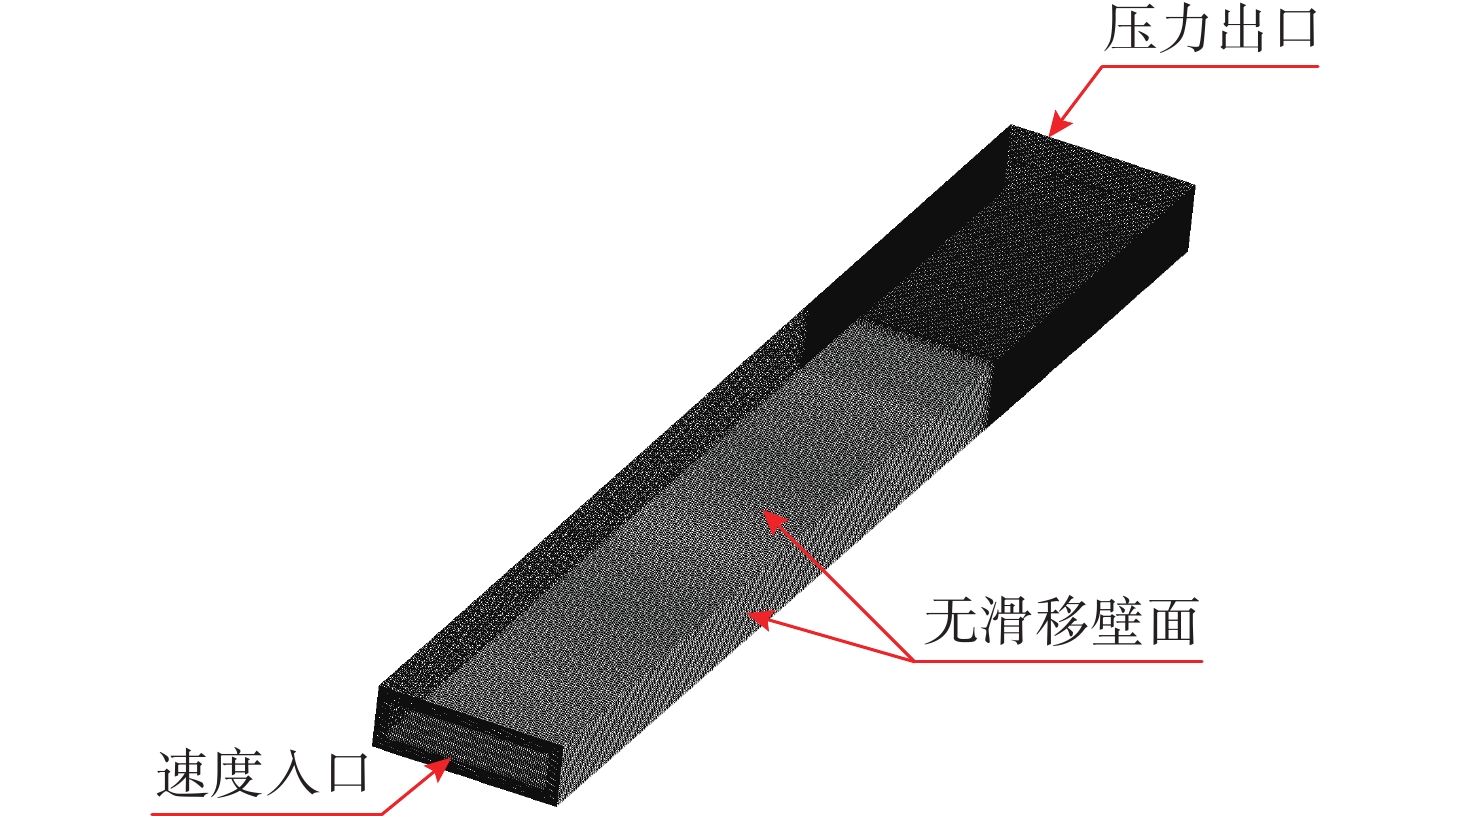
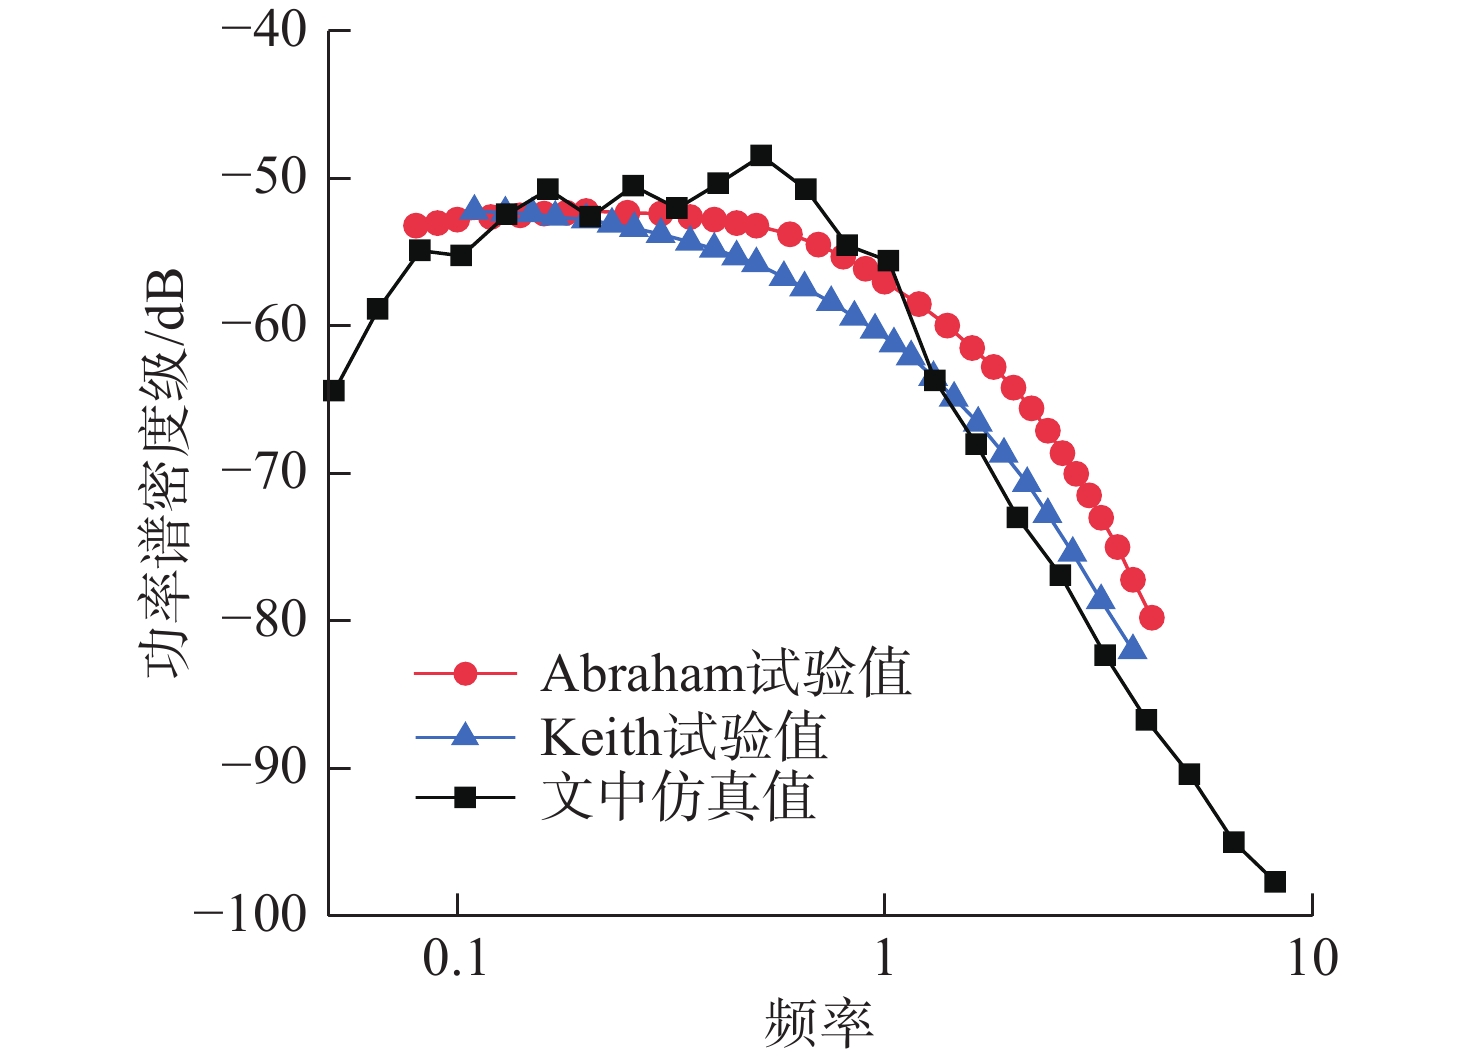
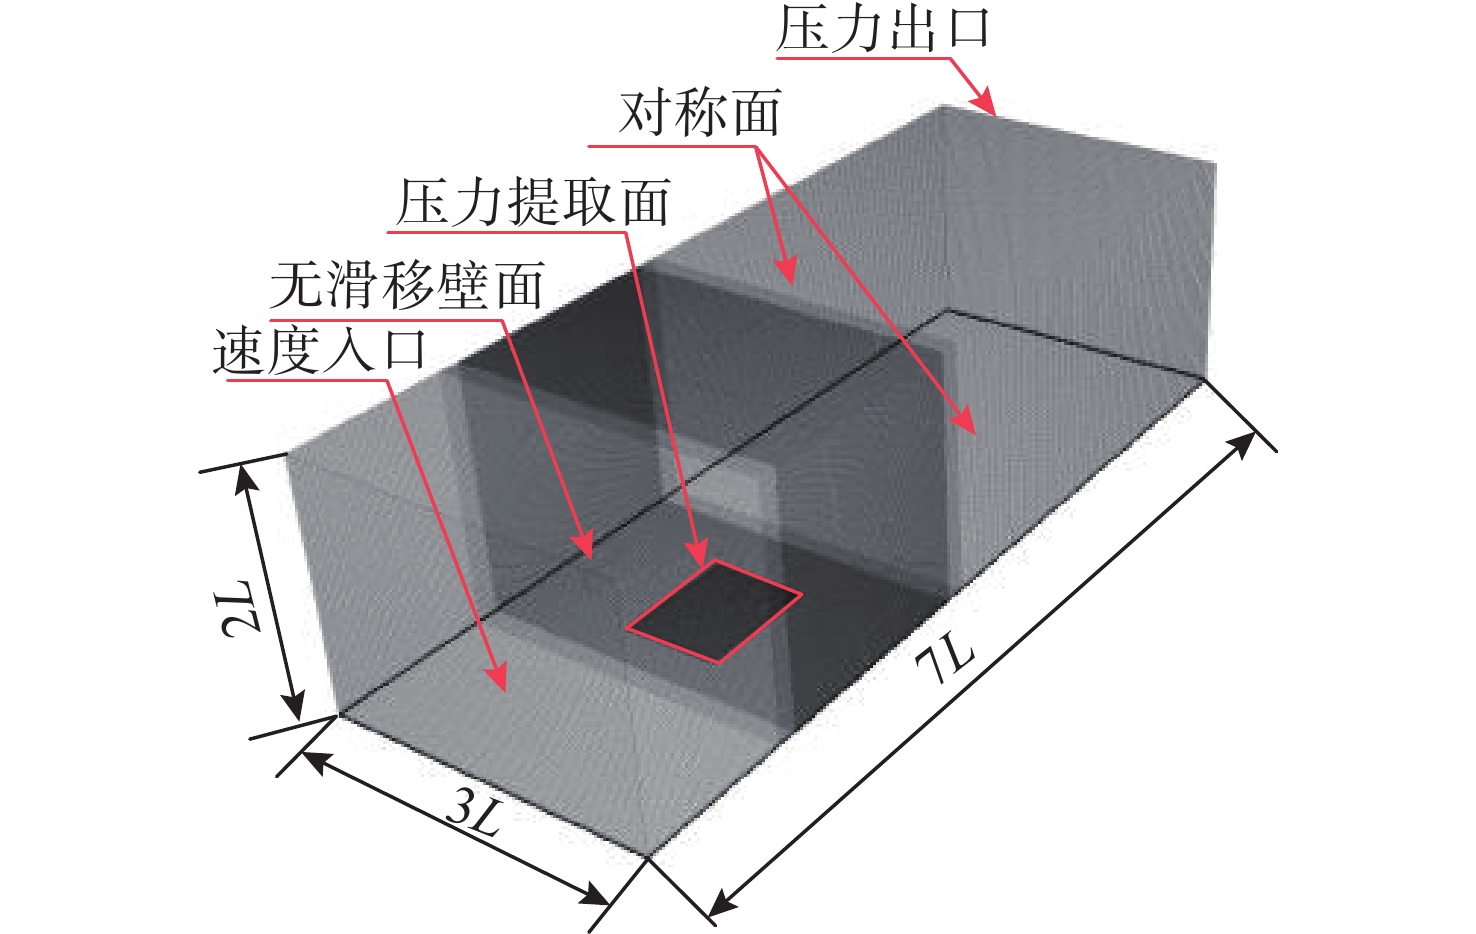
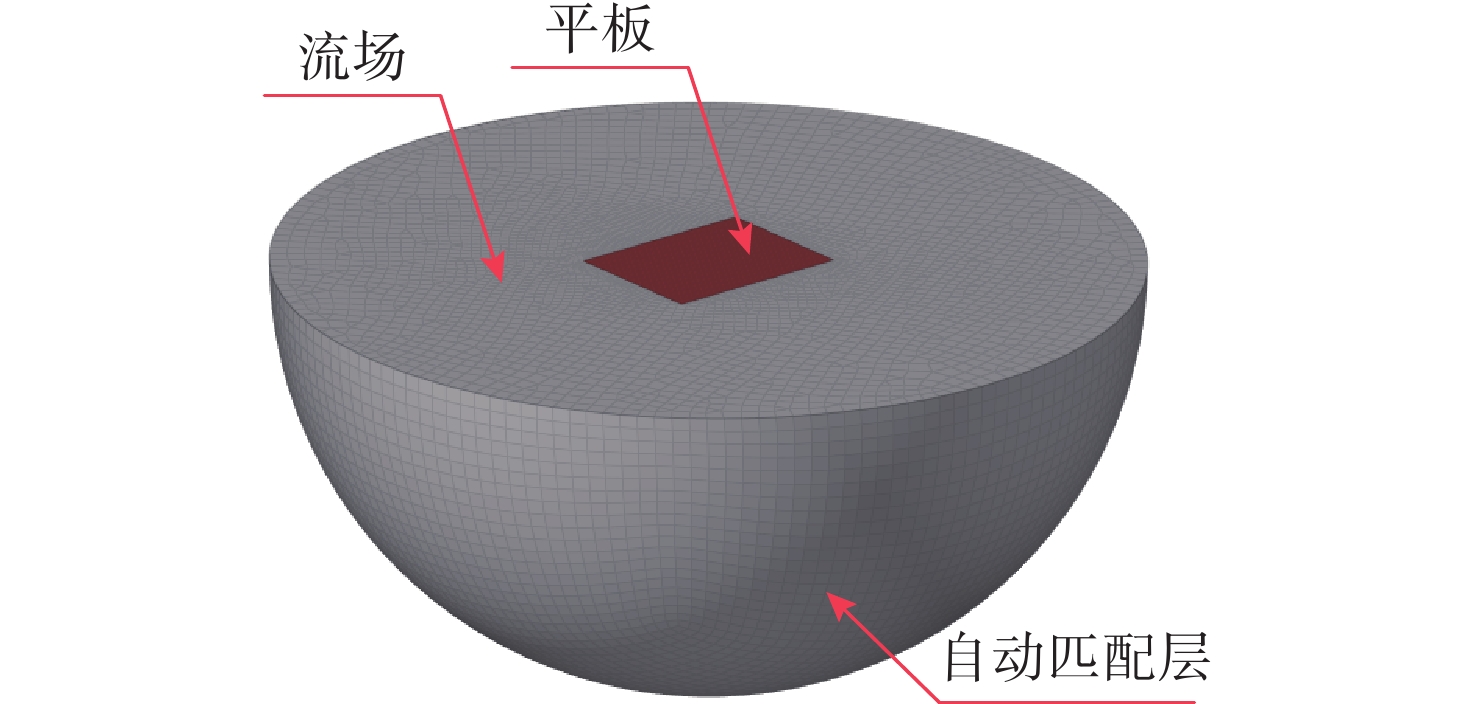
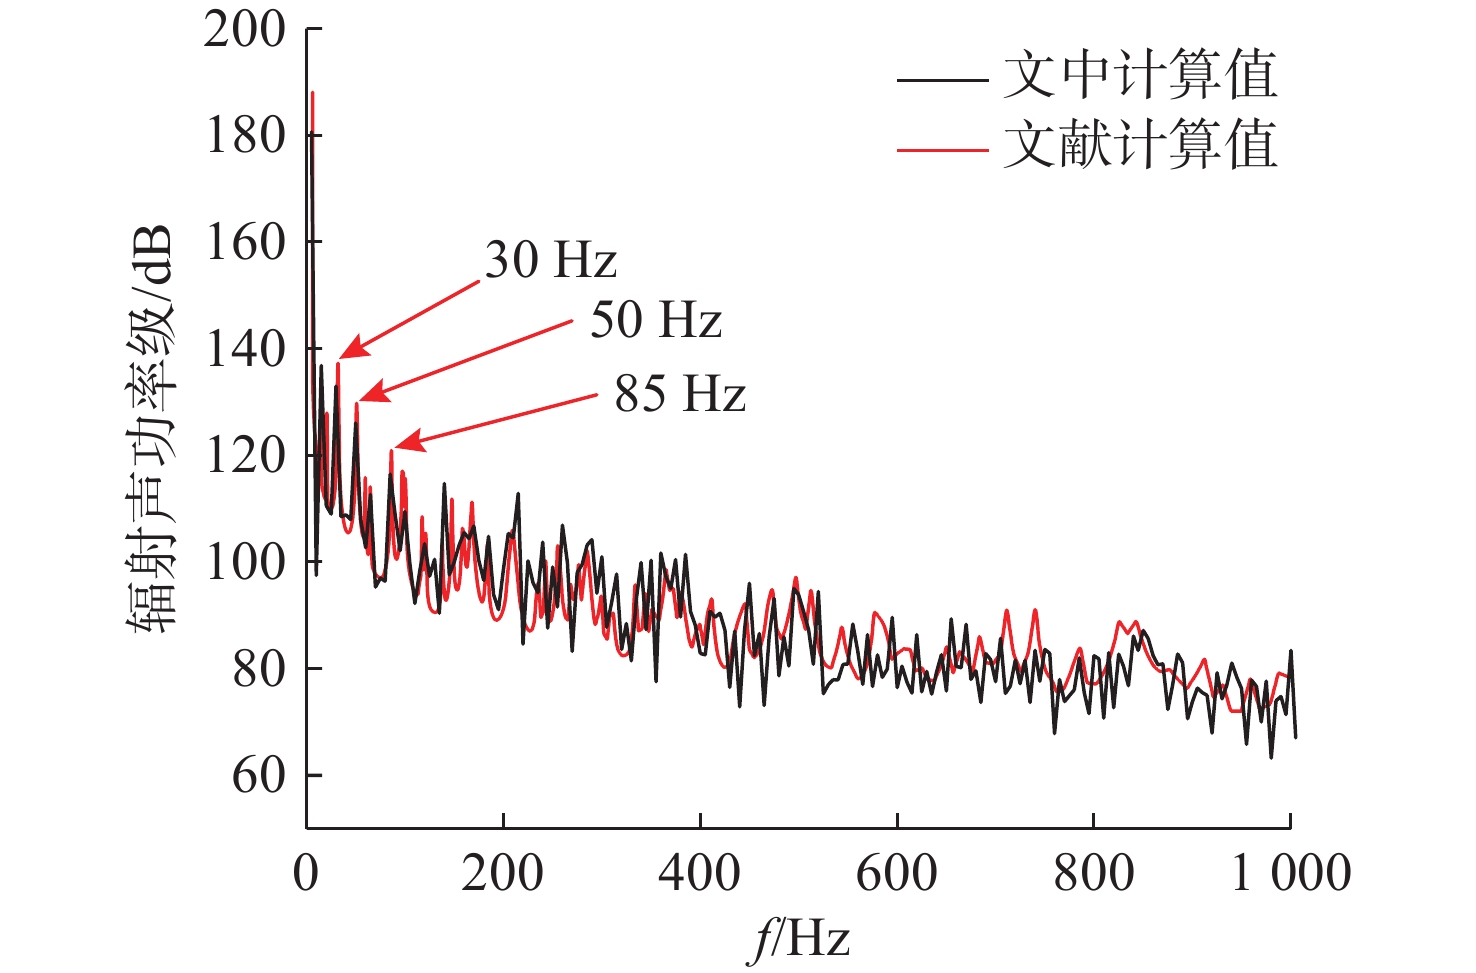
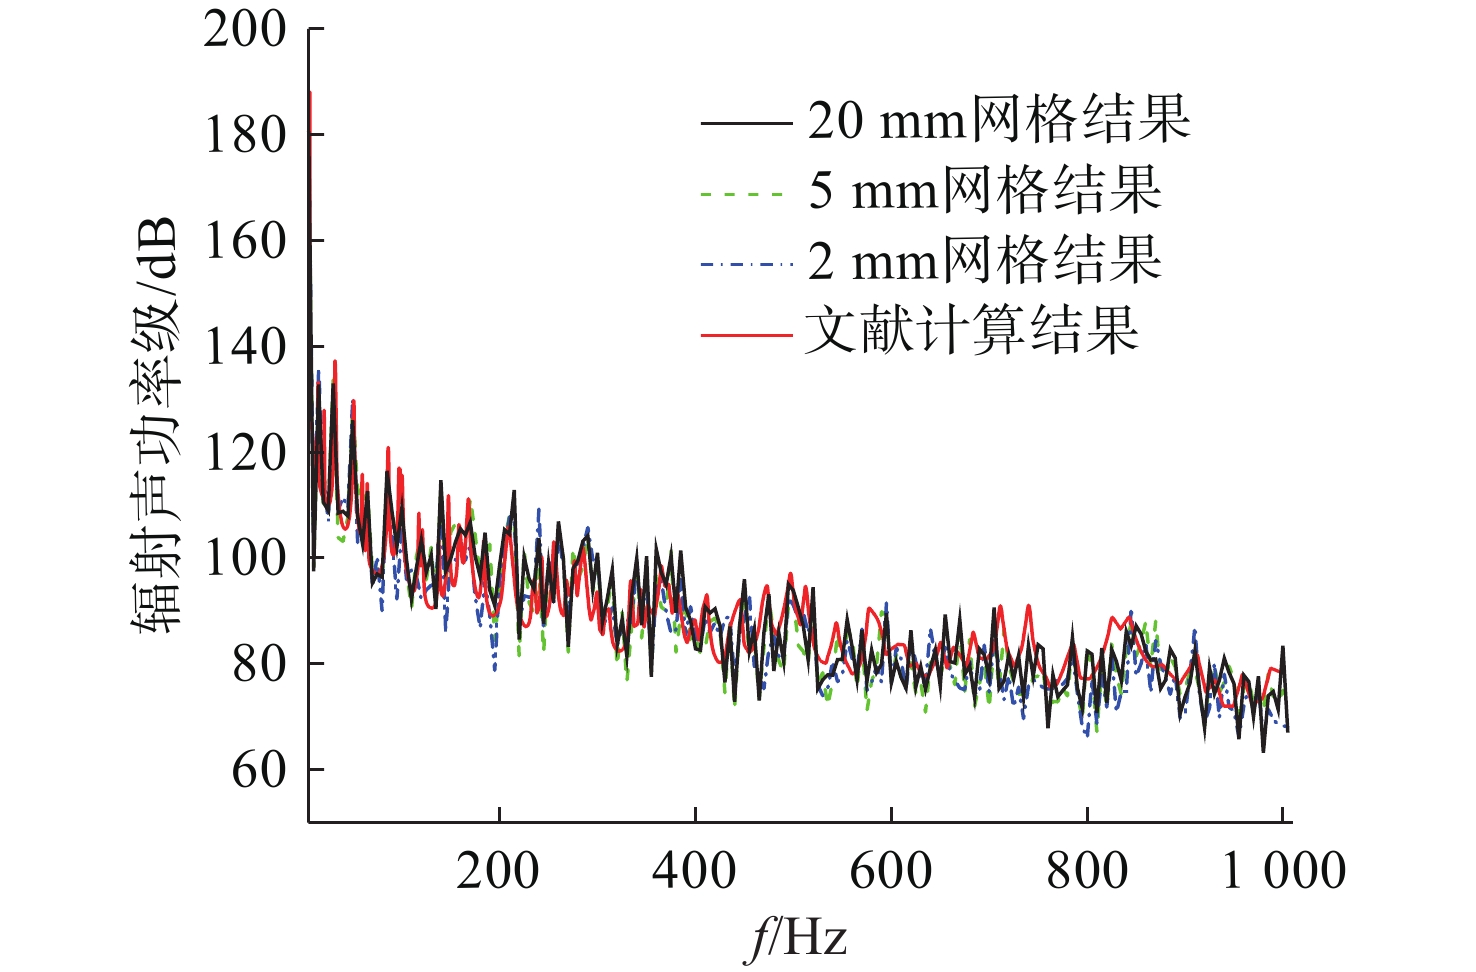
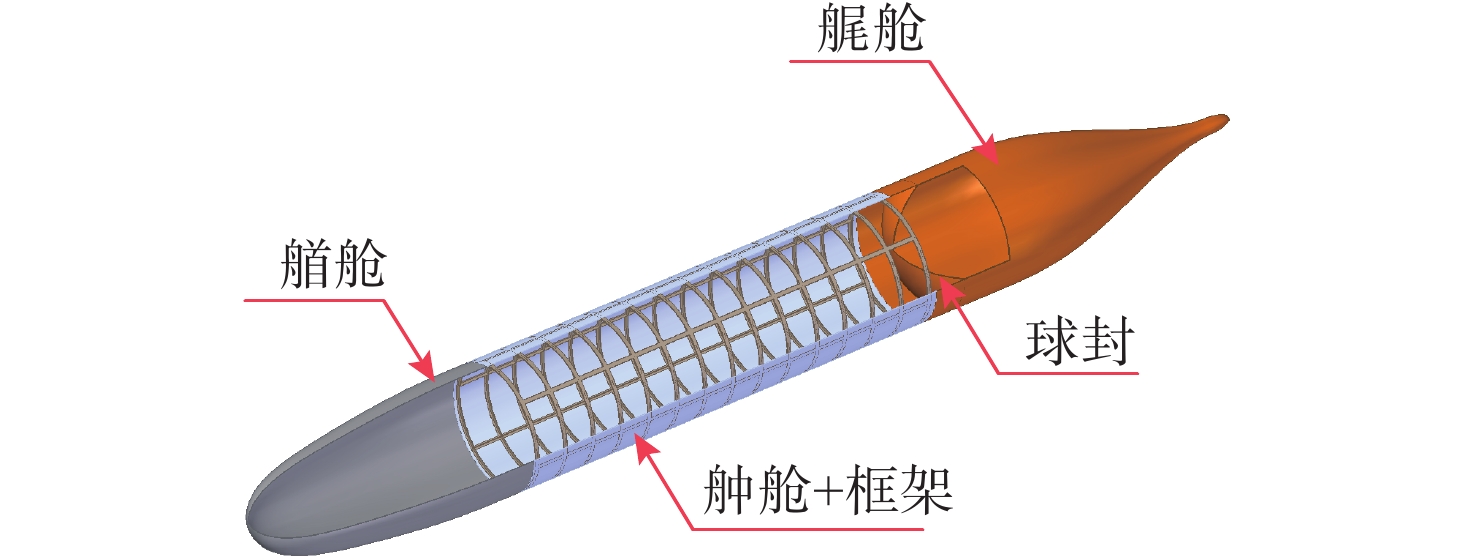
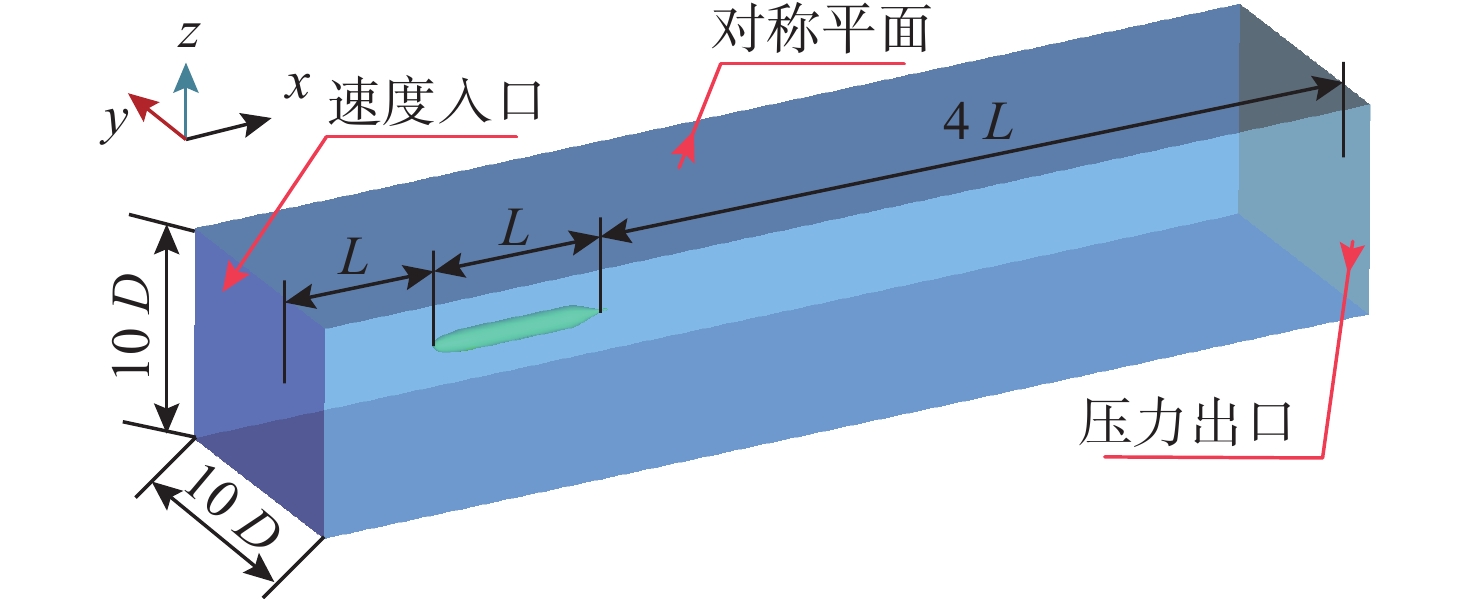
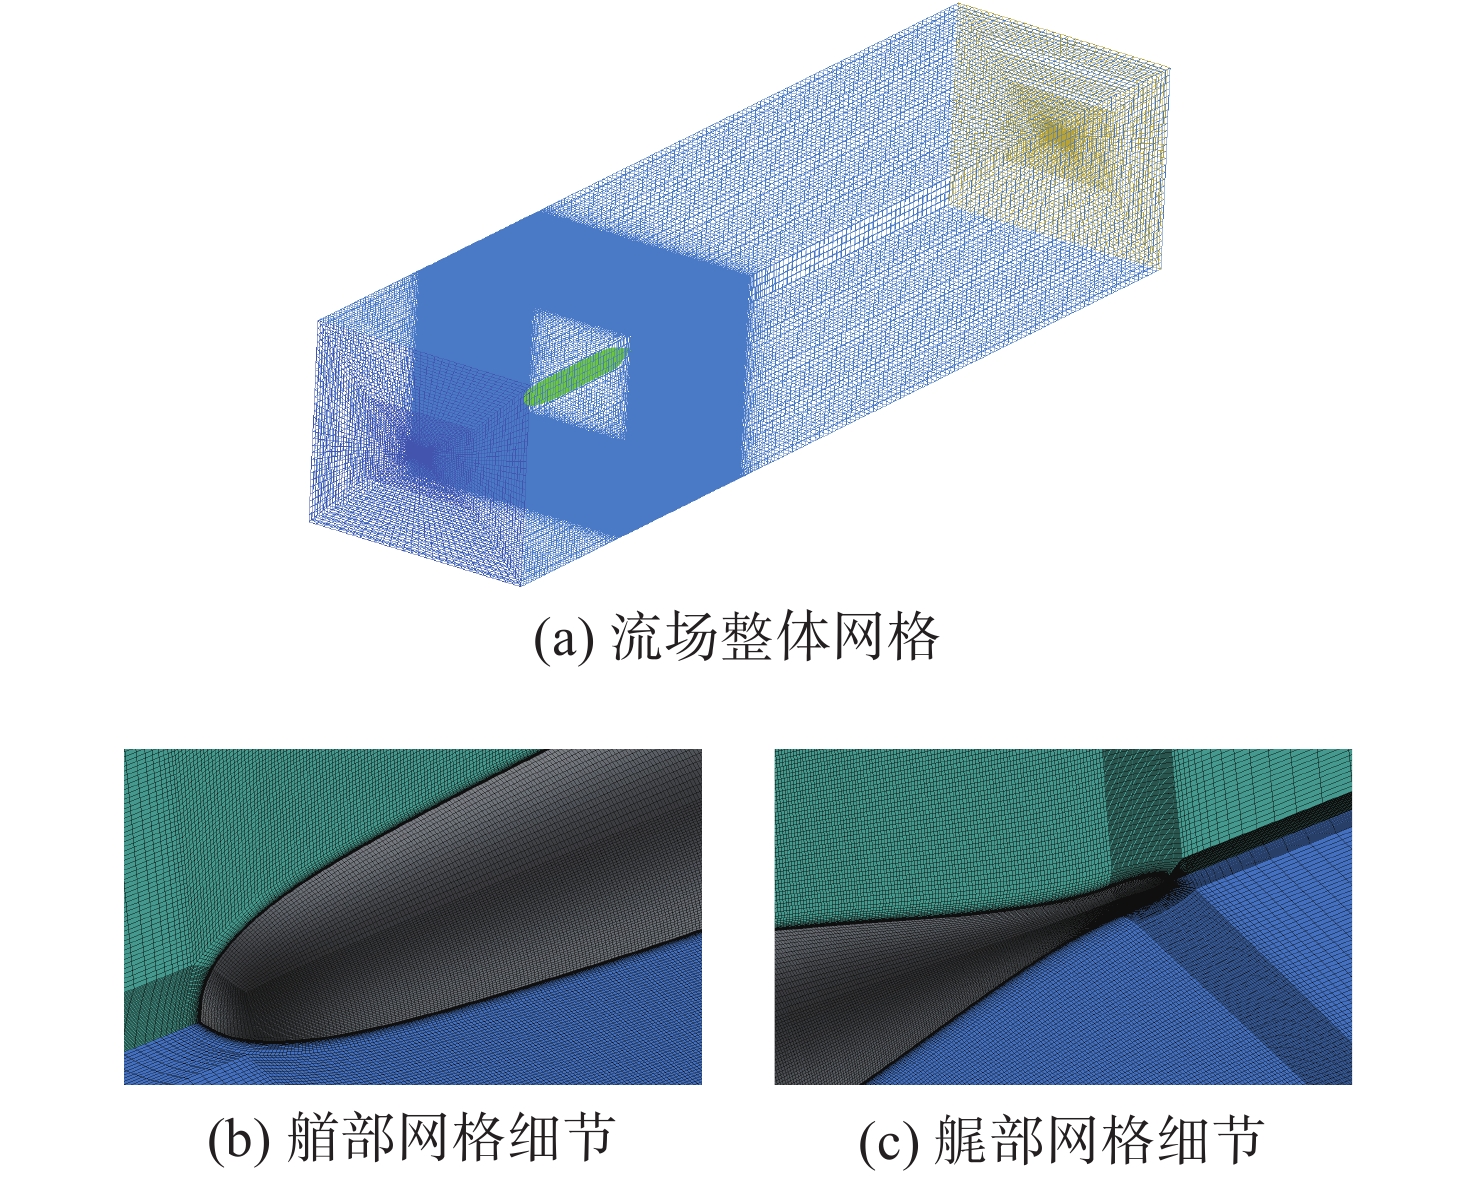
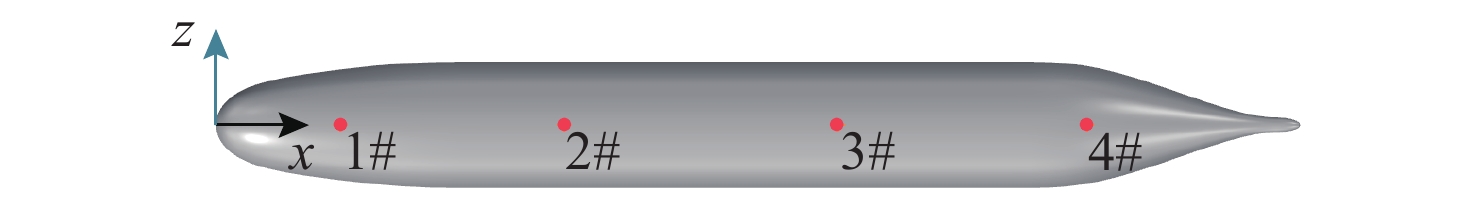
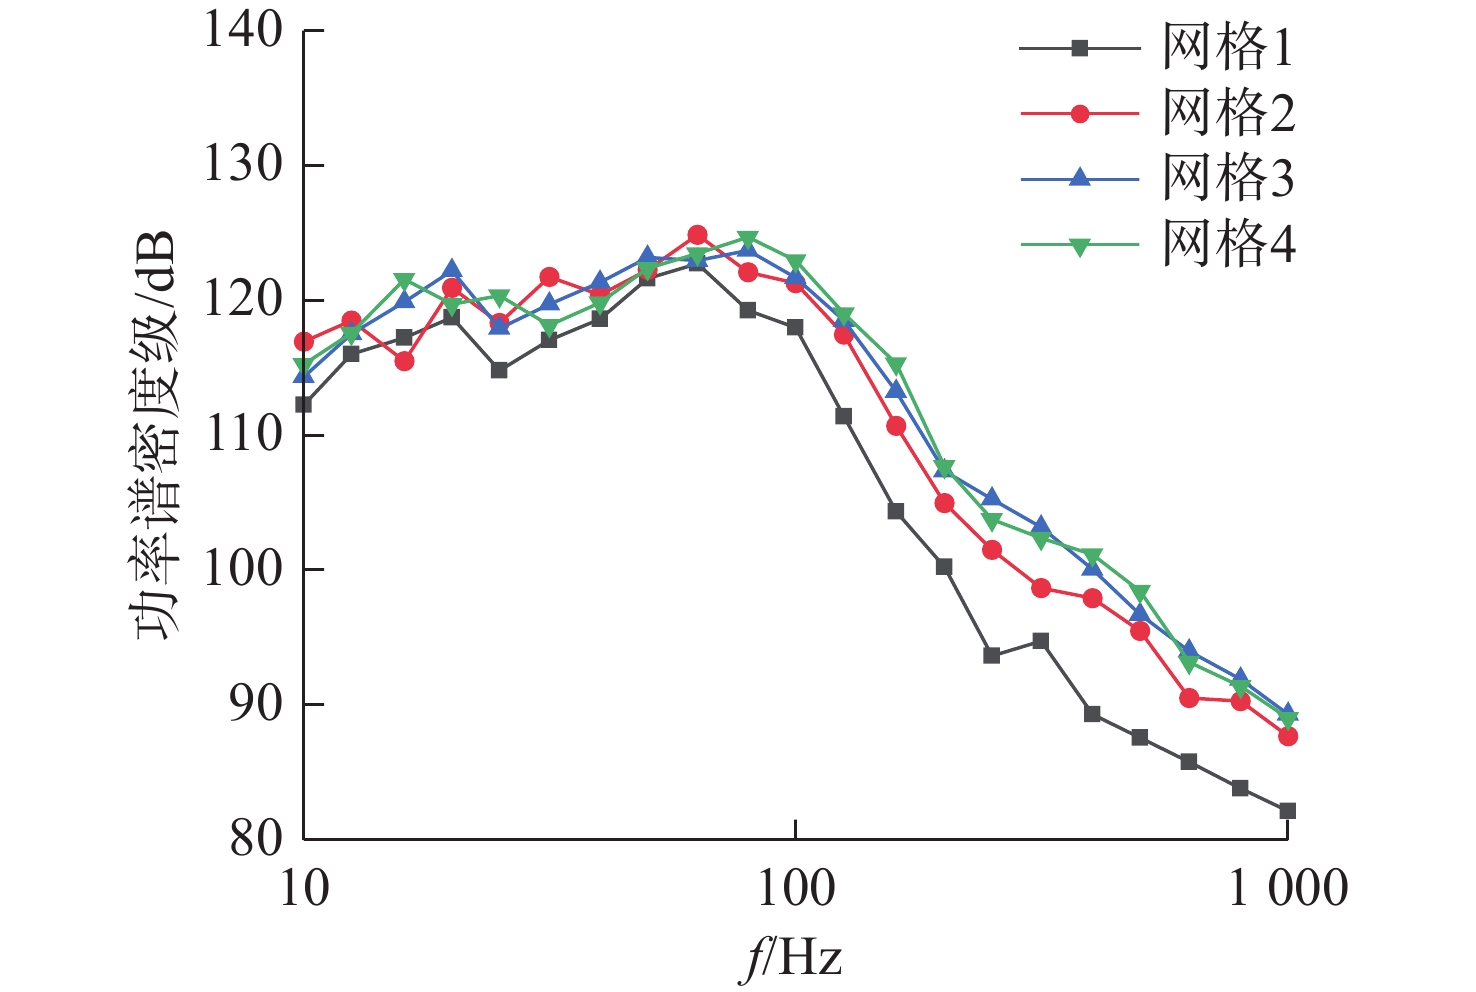
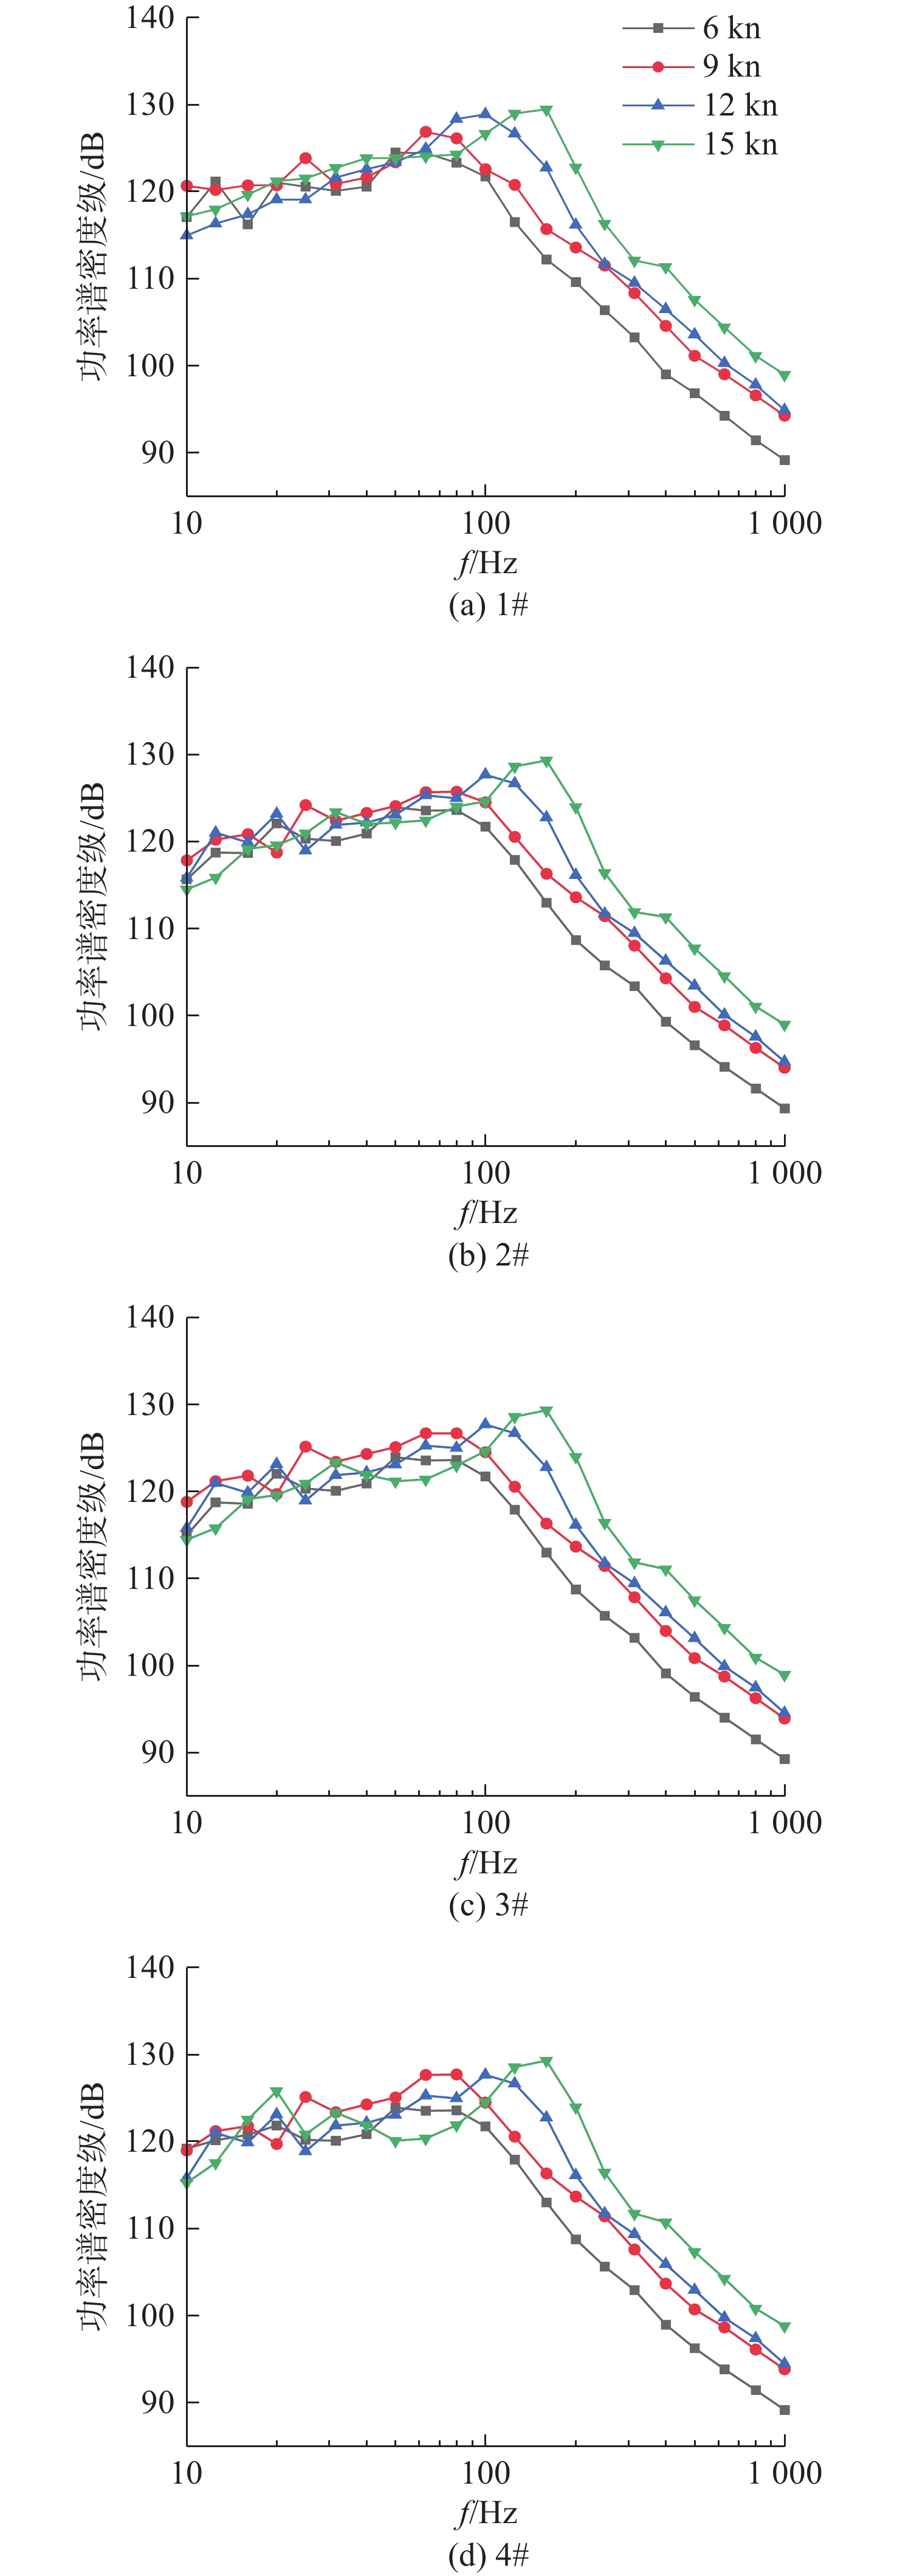
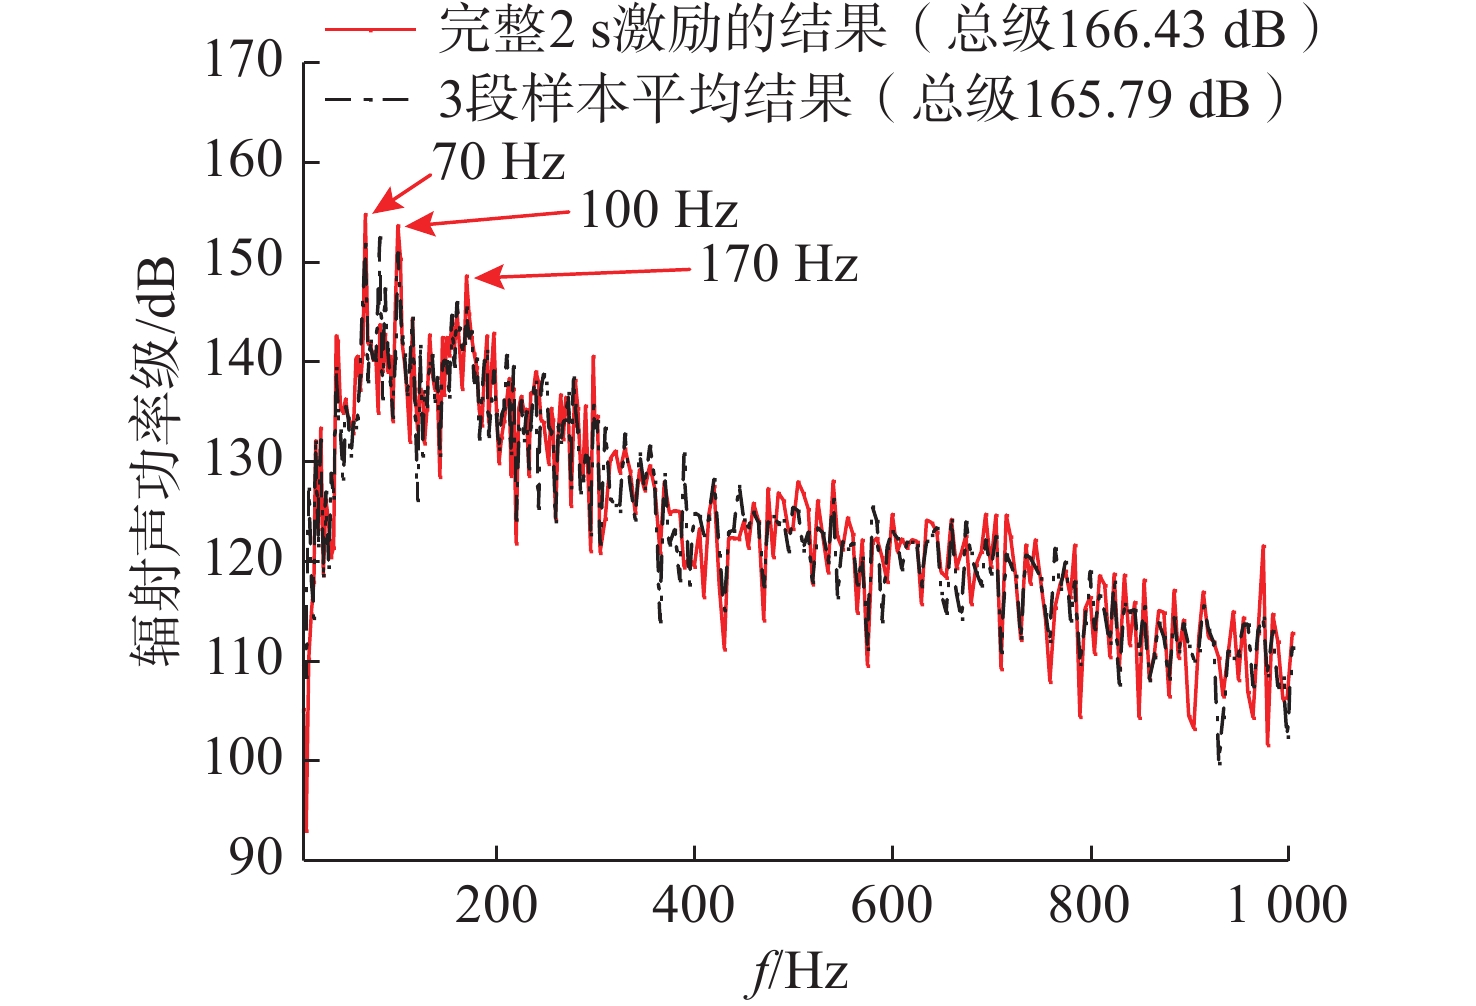
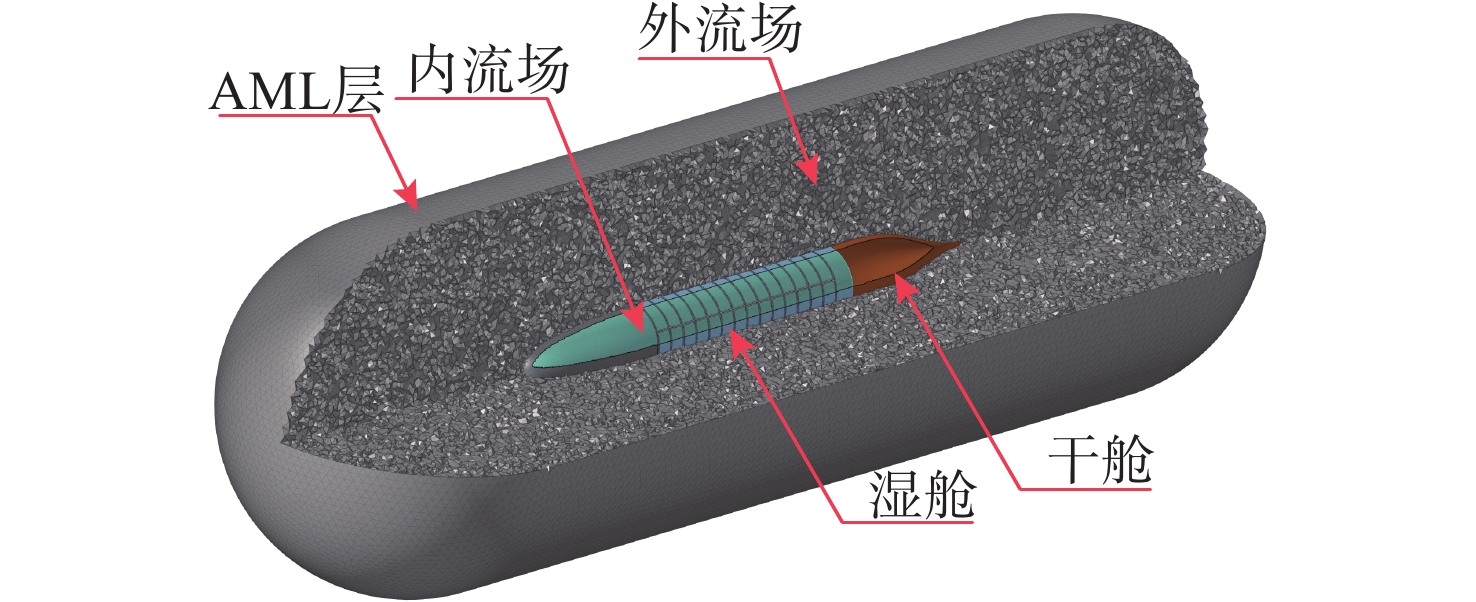
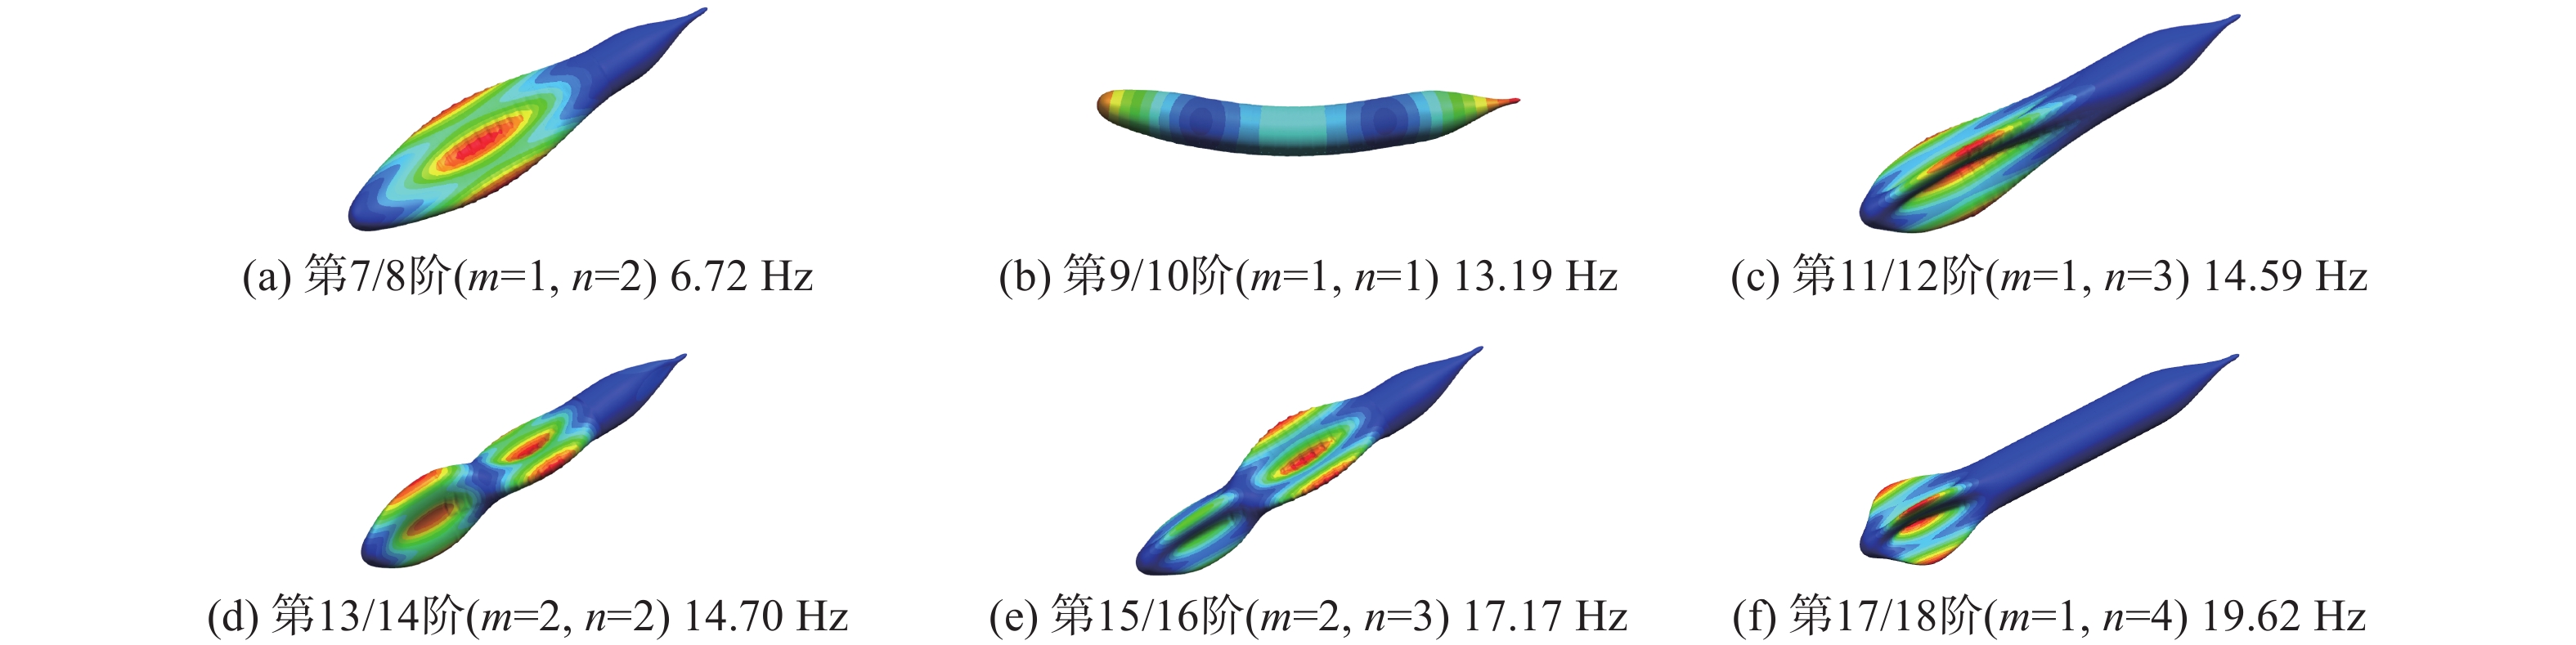
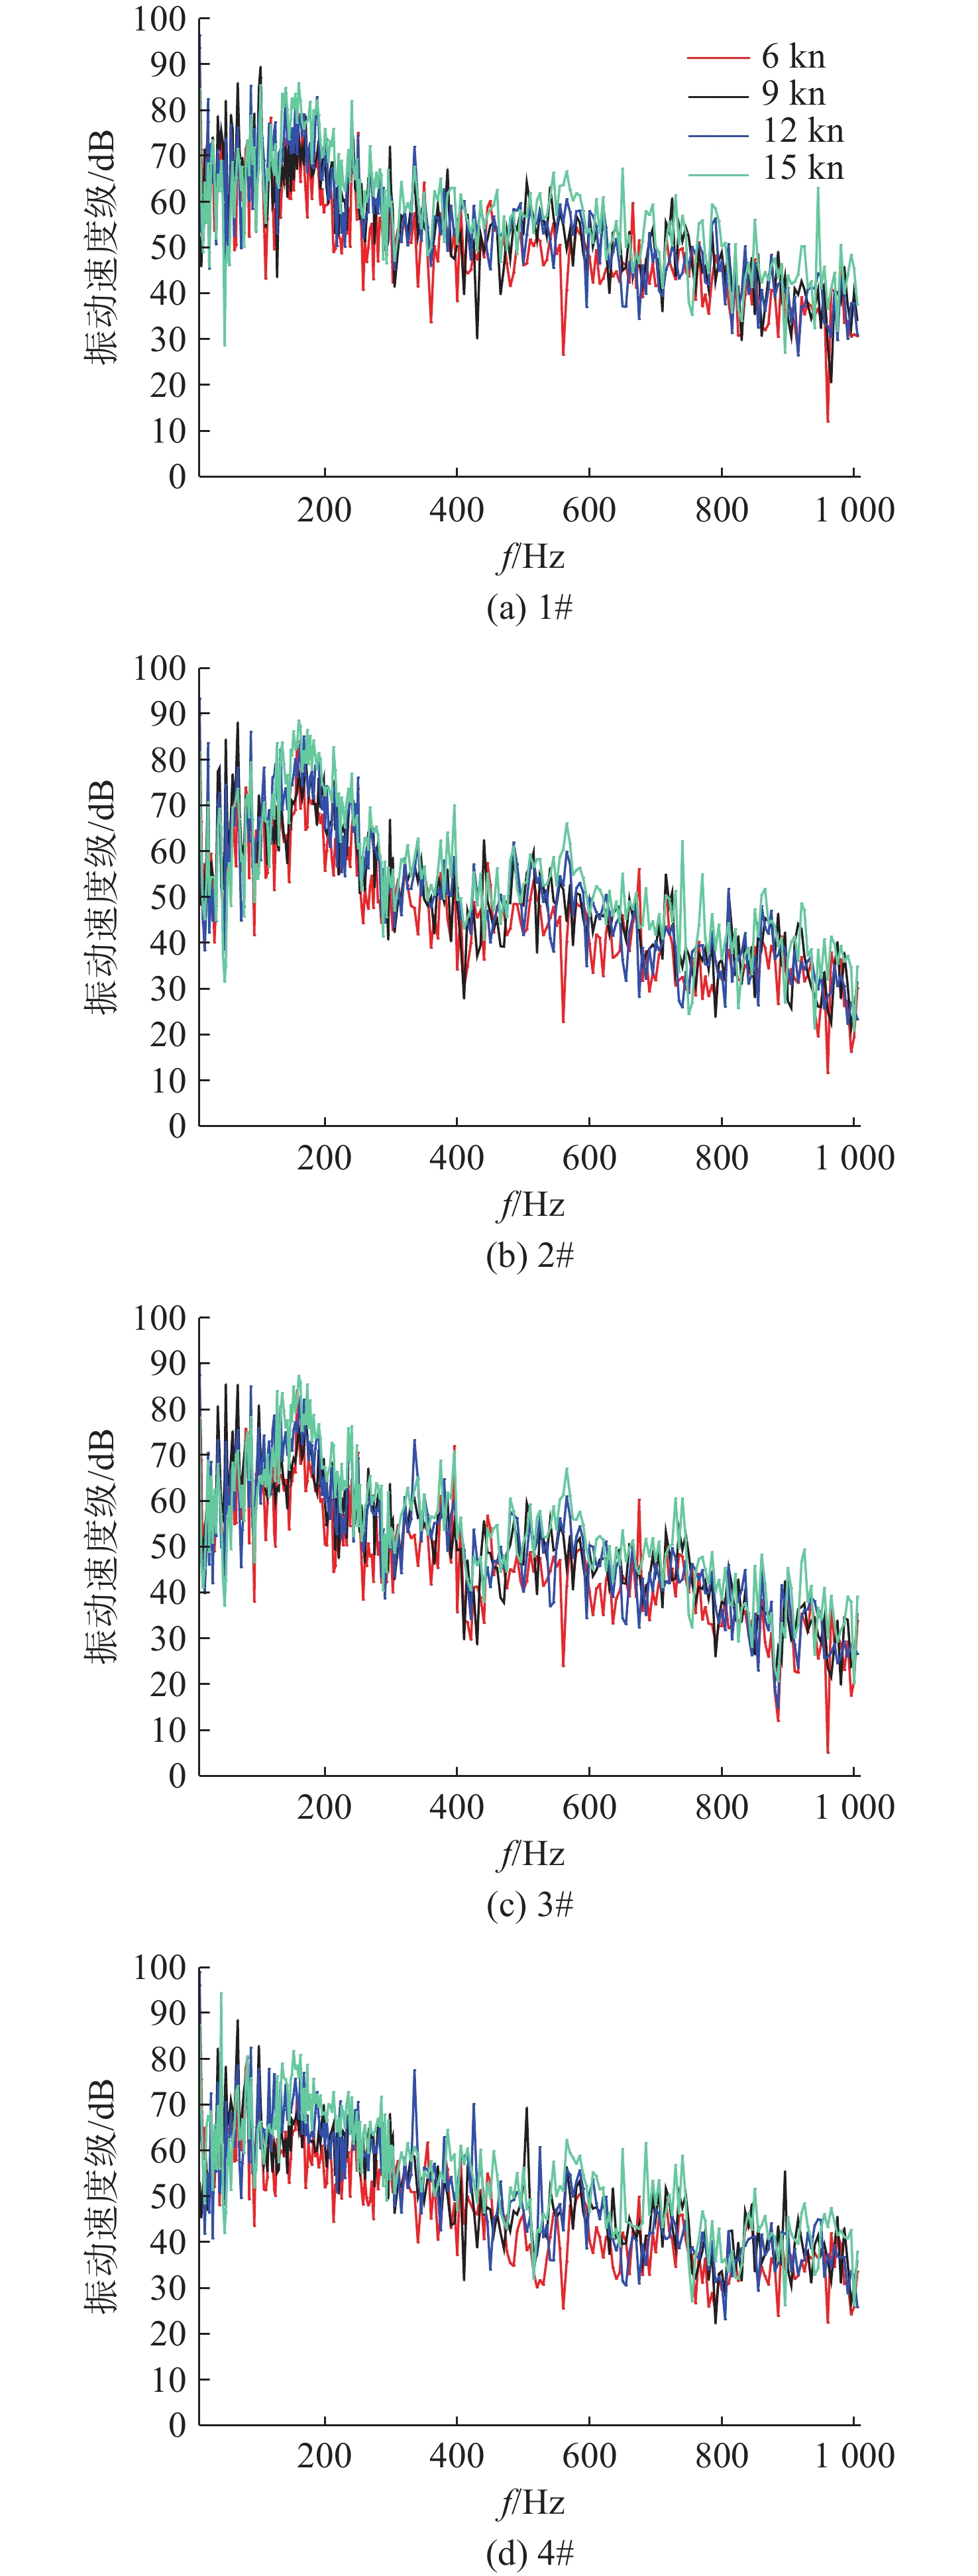
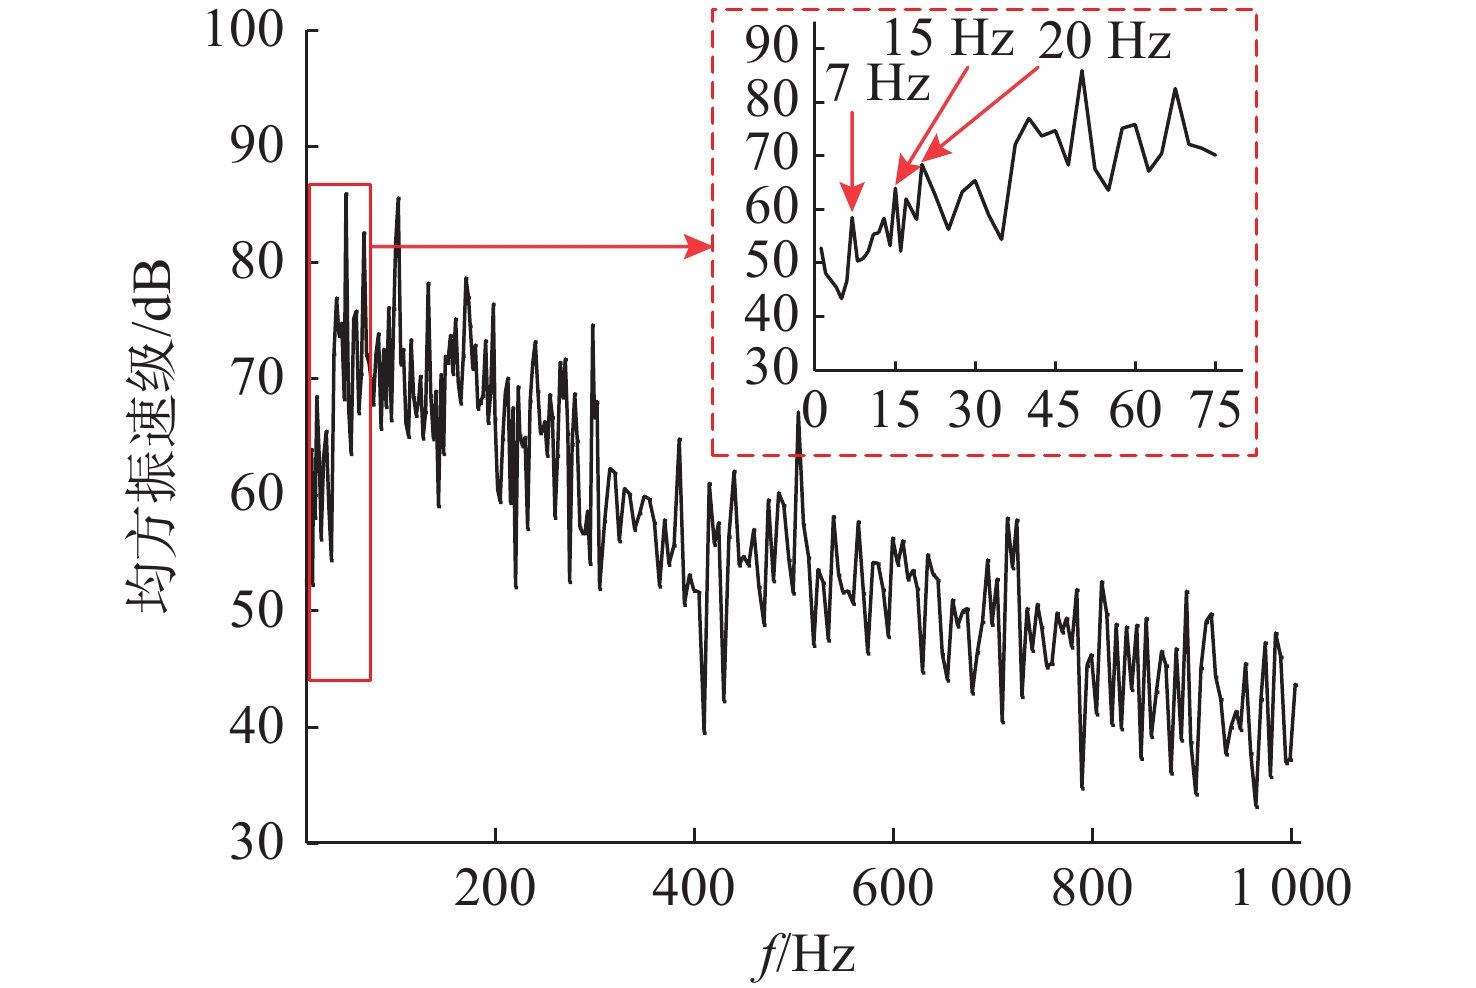
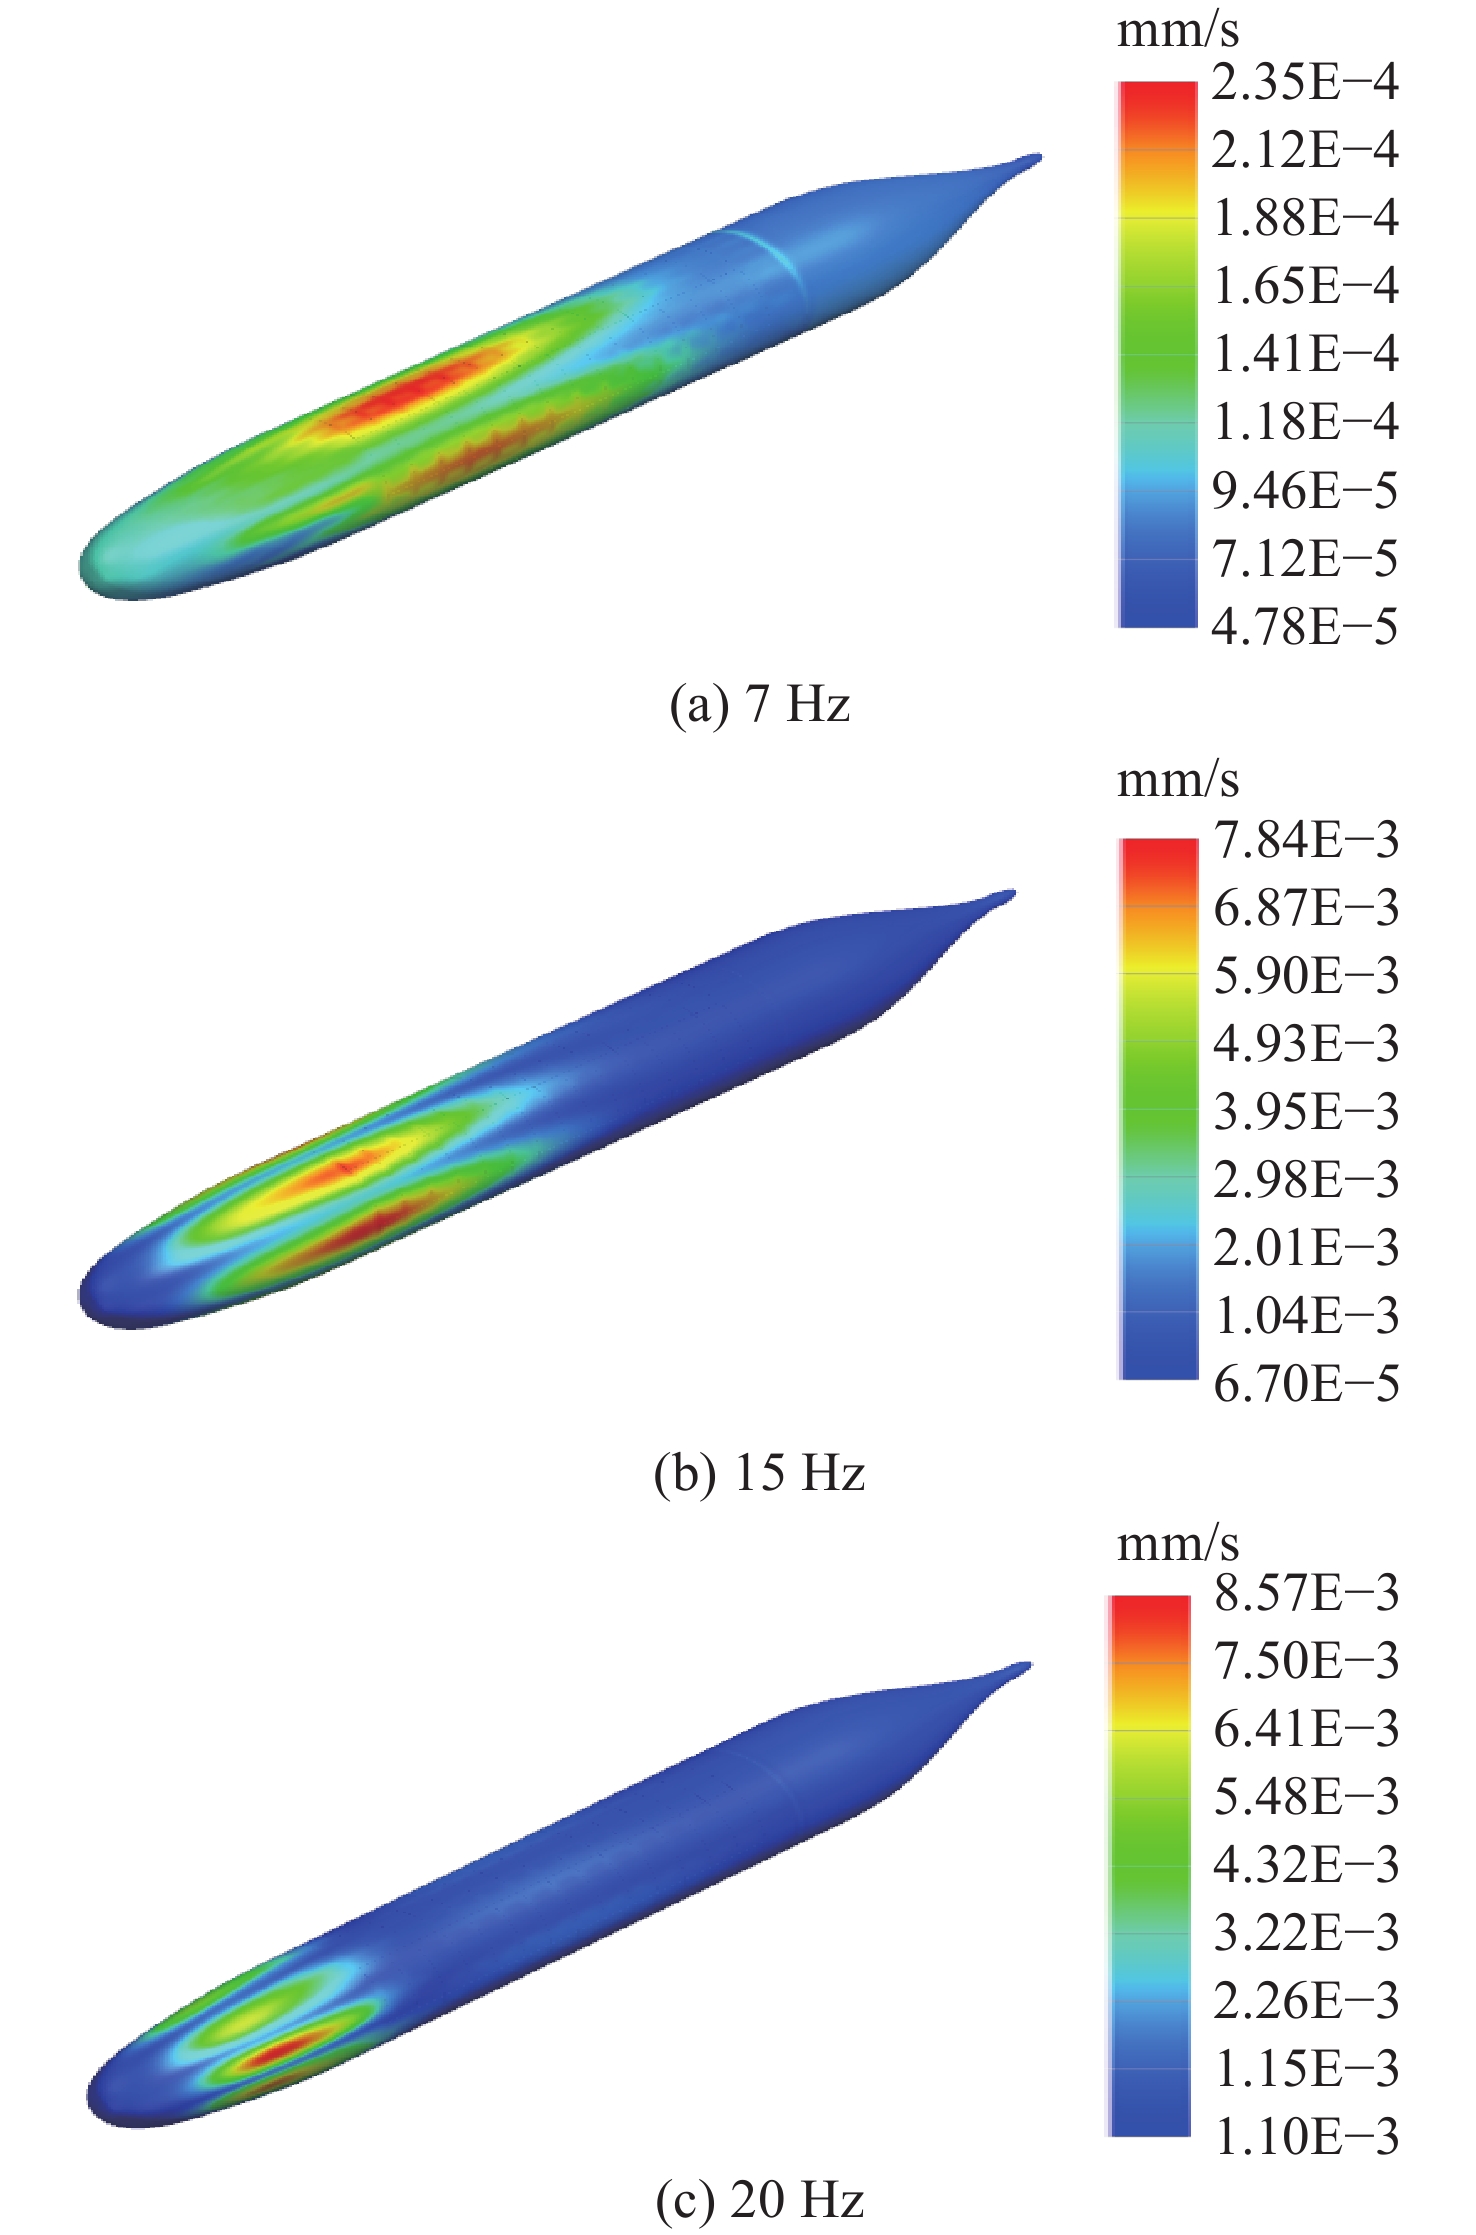
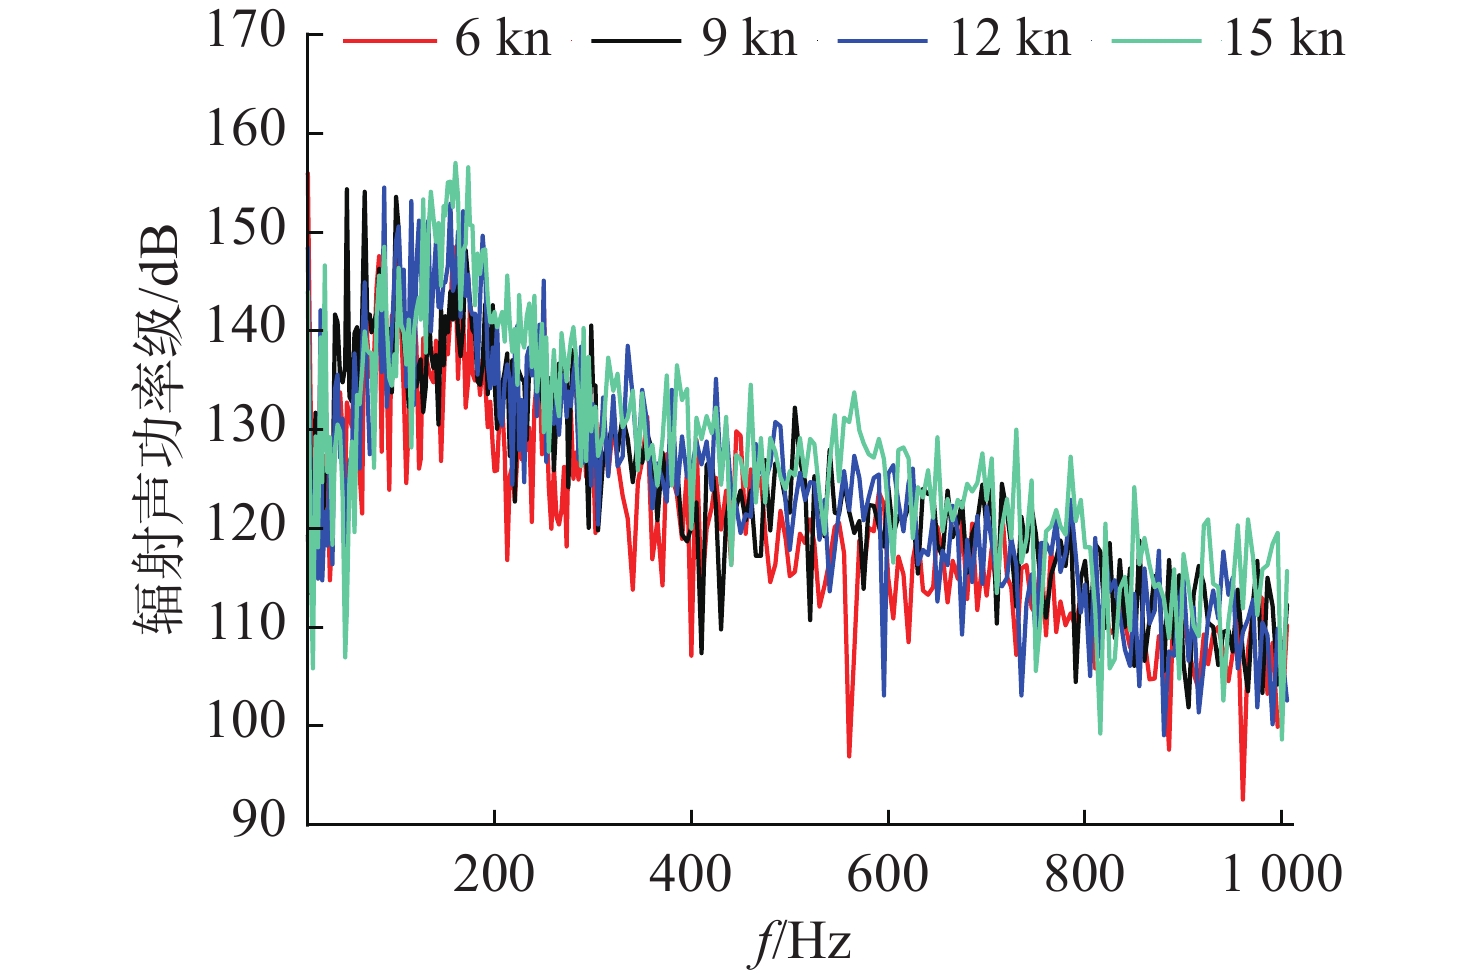
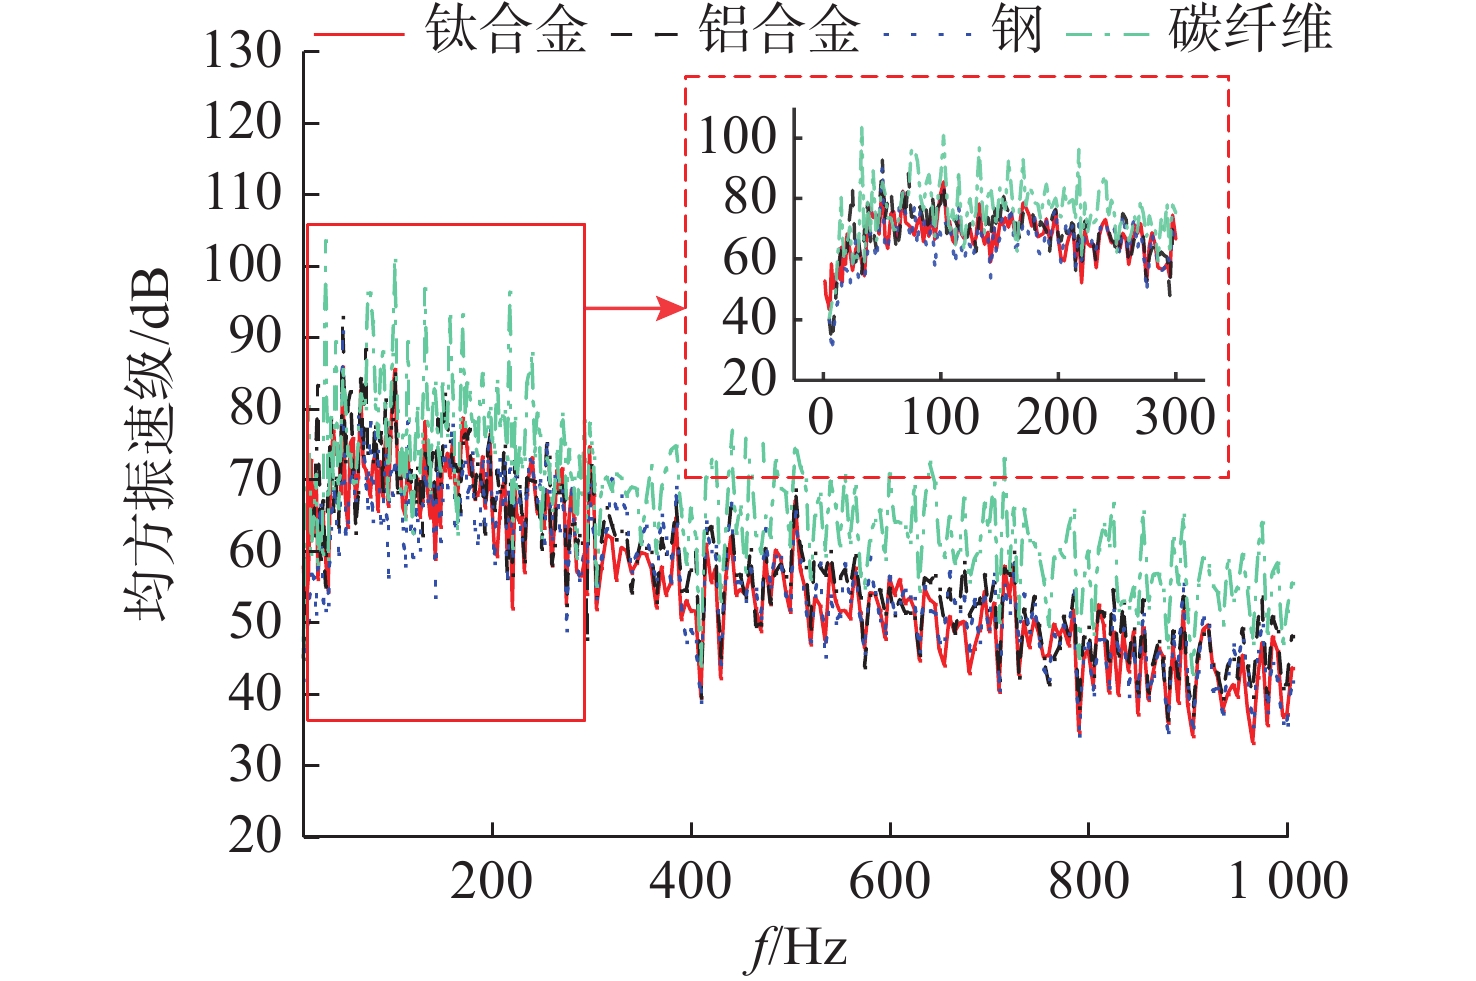
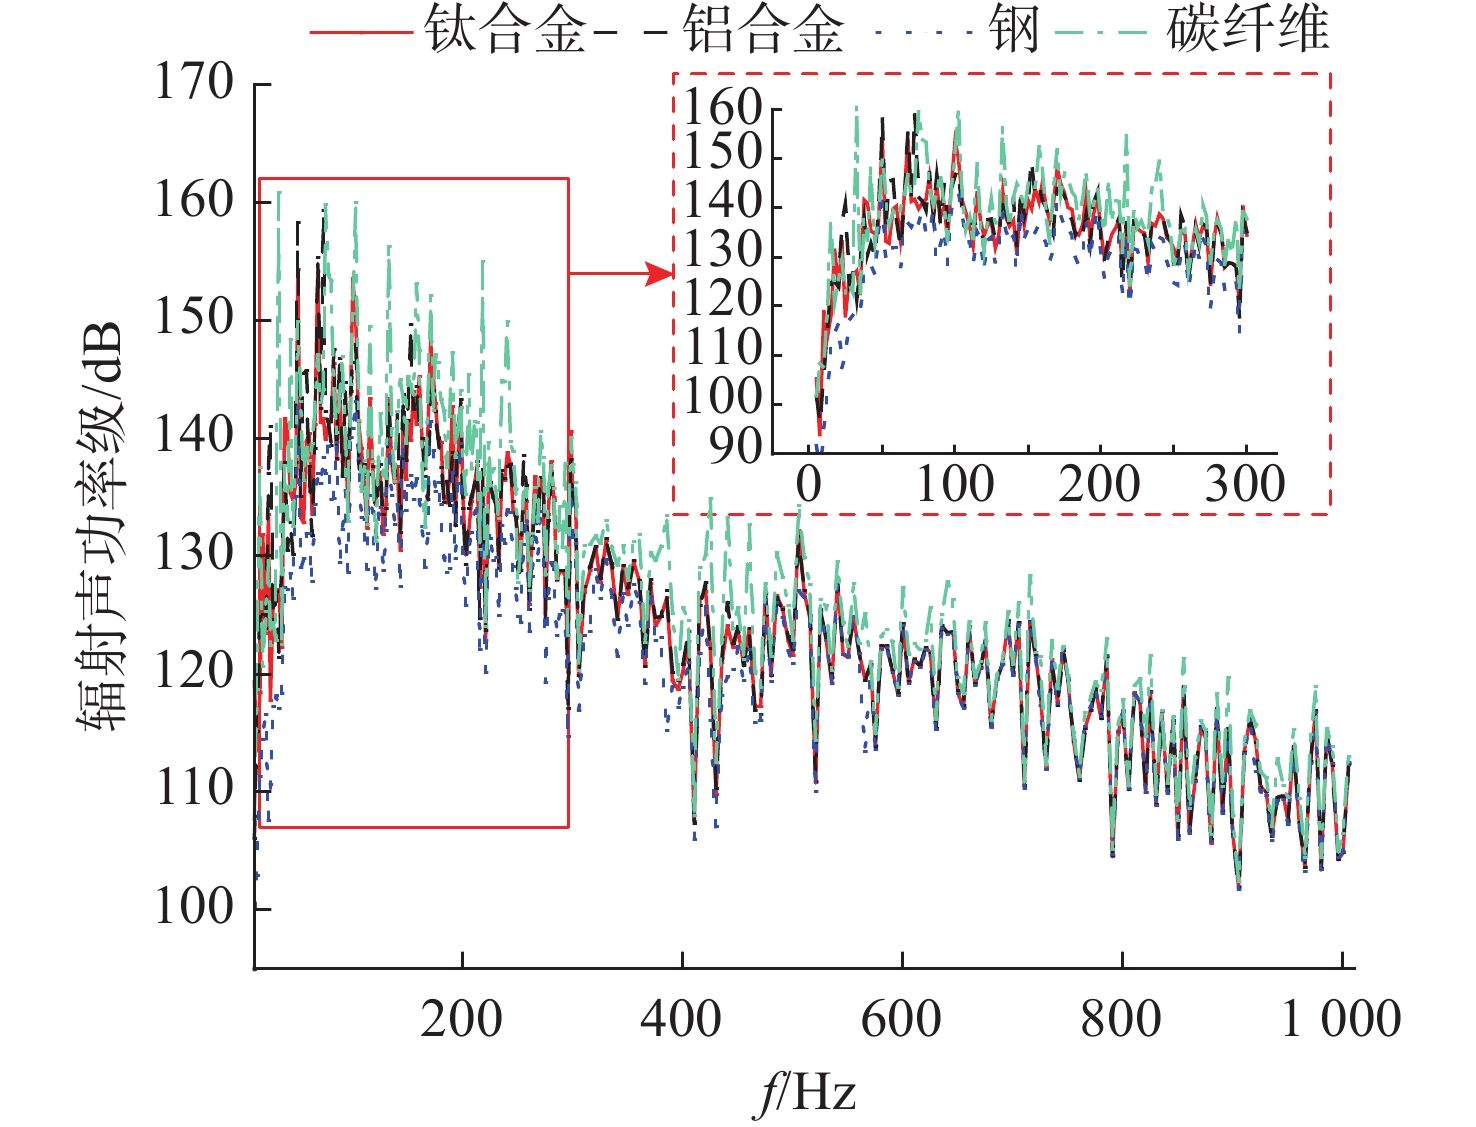
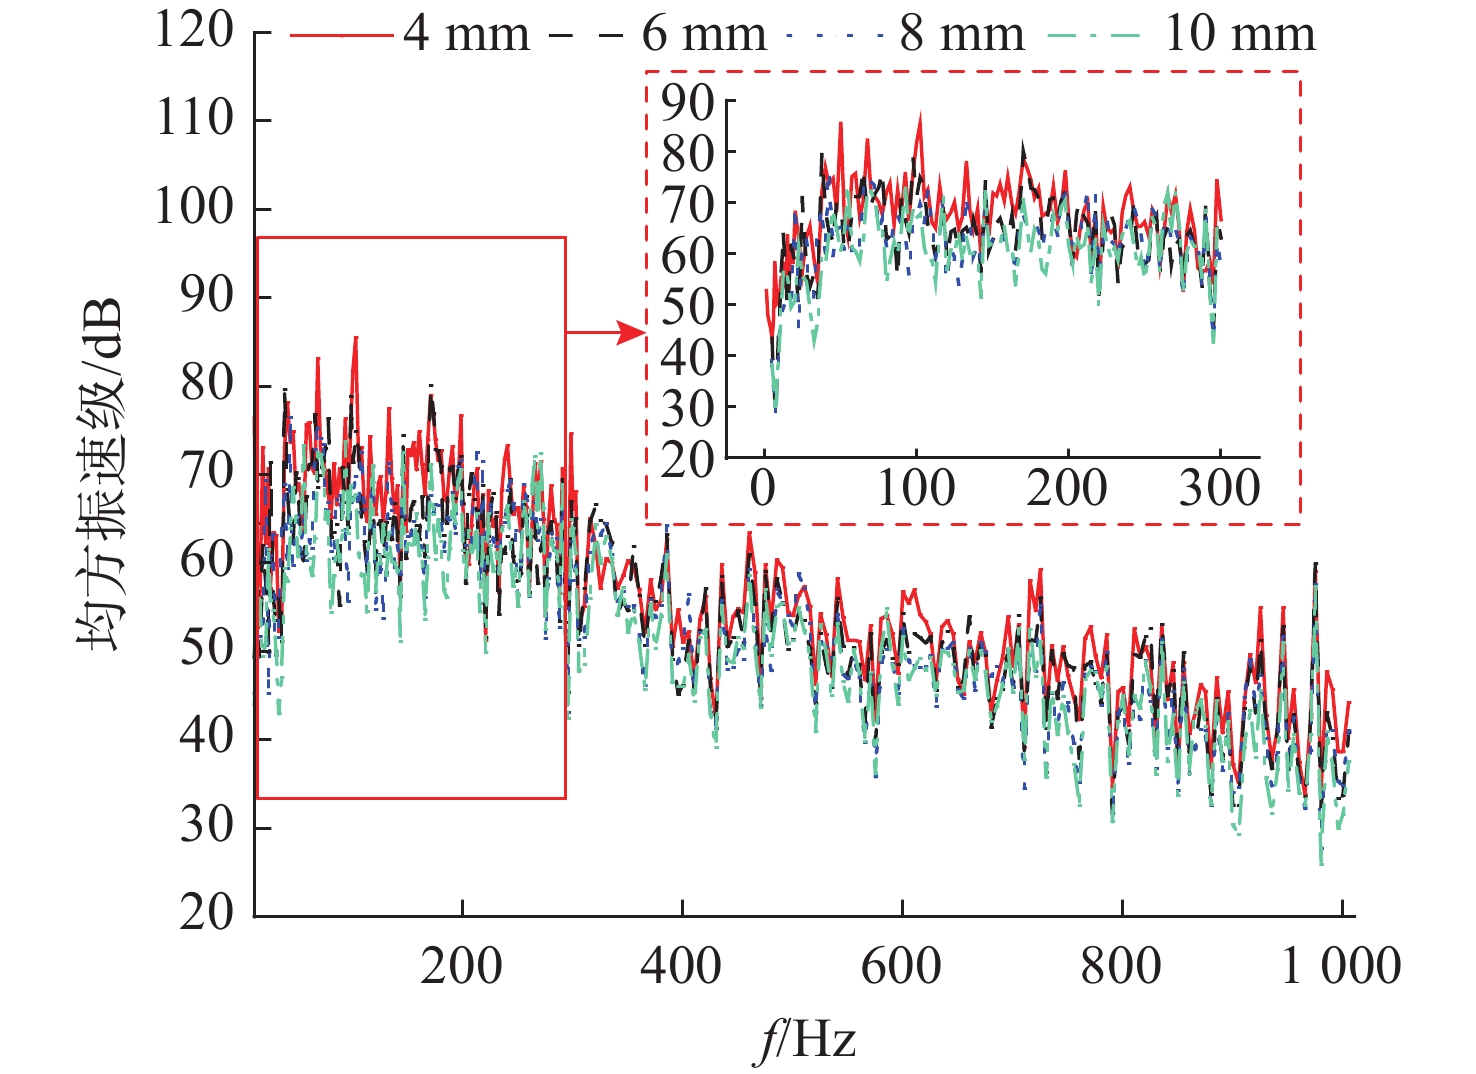
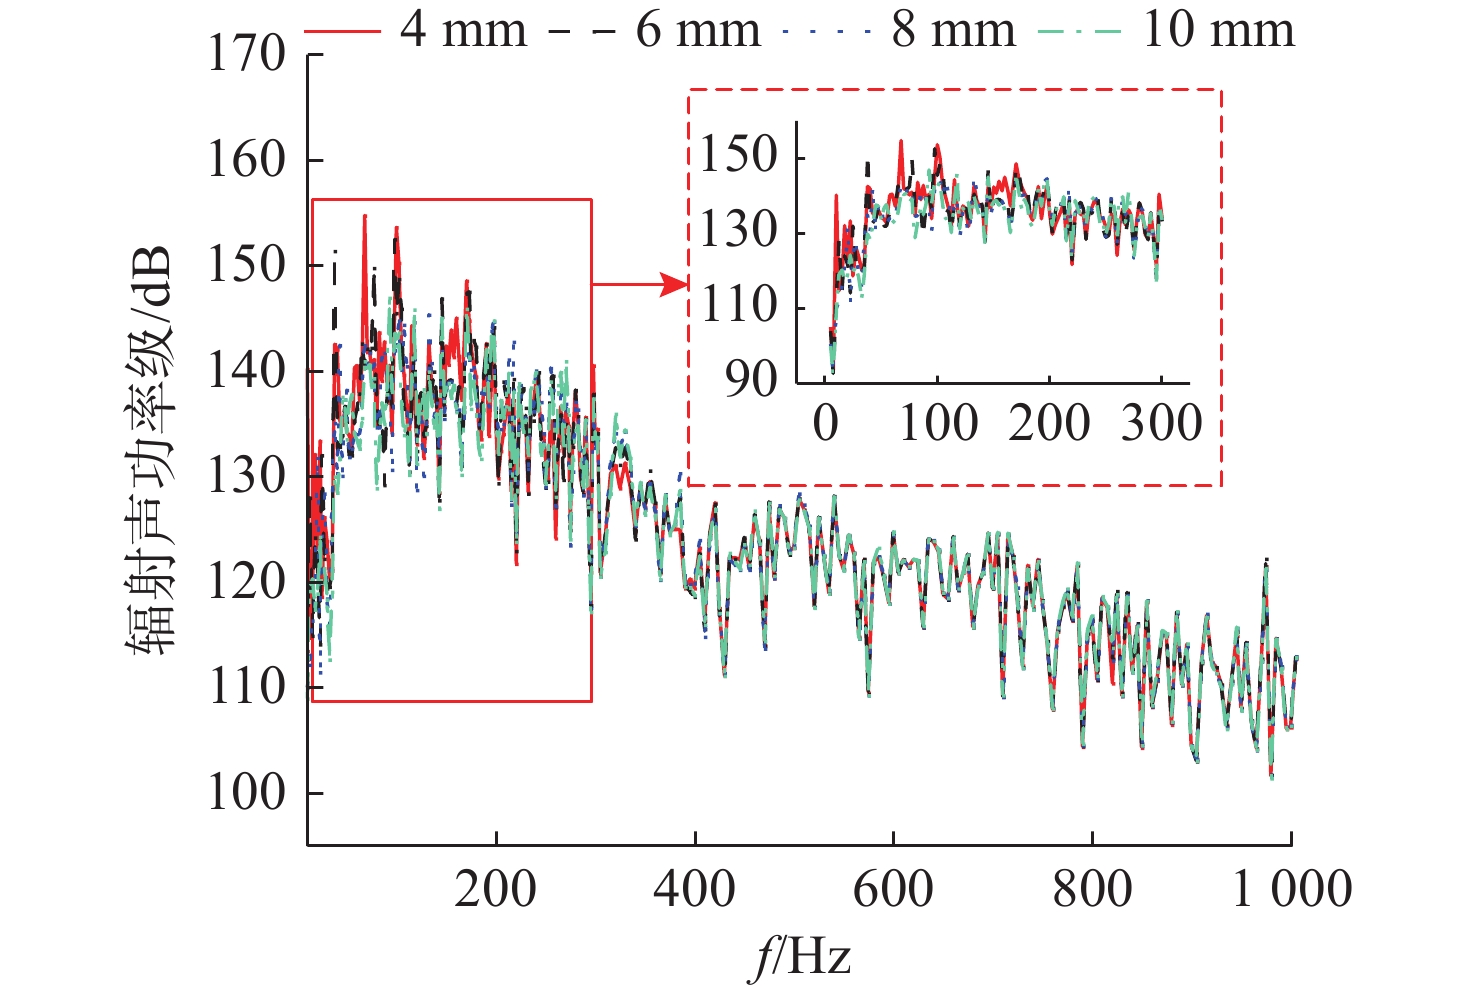
Large unmanned underwater vehicle(LUUV) are receiving increasing attention and often use wet compartments with thin, frame-stiffened shells. During navigation, fluctuating wall pressure excites shell vibration and generates energetic, slowly attenuating radiated noise. To support noise control, this study combines improved delayed detached-eddy simulation(IDDES) and finite element/automatic matching layer(FEM/AML) to analyze flow-induced vibration and sound radiation up to 1 kHz. Results indicate that wall pressure fluctuation energy concentrates in the low-frequency range. Due to bilateral added water mass, low-frequency vibration primarily manifests as local compartment modes. Overall radiated sound power increases with speed. Increasing wet-compartment shell thickness suppresses some low-frequency vibration but only slightly reduces the overall radiated sound power level, possibly owing to added-mass effects from two-sided water loading. Compared with the metallic shells considered, the low-density carbon-fiber shell exhibits the higher mean-square vibration and radiated sound power. These findings clarify the effects of speed, shell thickness, and material on LUUV noise and inform acoustic stealth design.
Acoustic Radiation Characteristics of Liquid-Filled Pipelines Coupled with Plates and Shells under Mechanical Force Excitation
ZHANG Rongli, LI Zhen, LIU Bilong
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0119
Abstract:
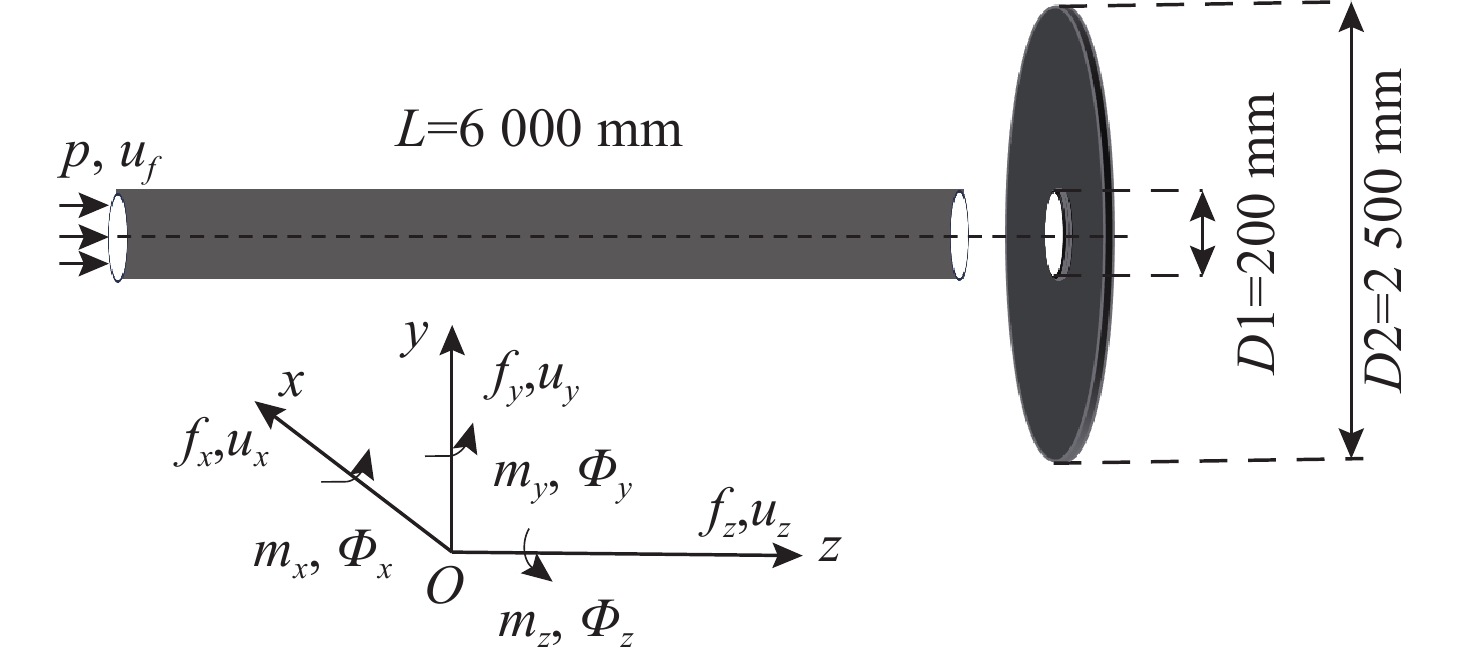
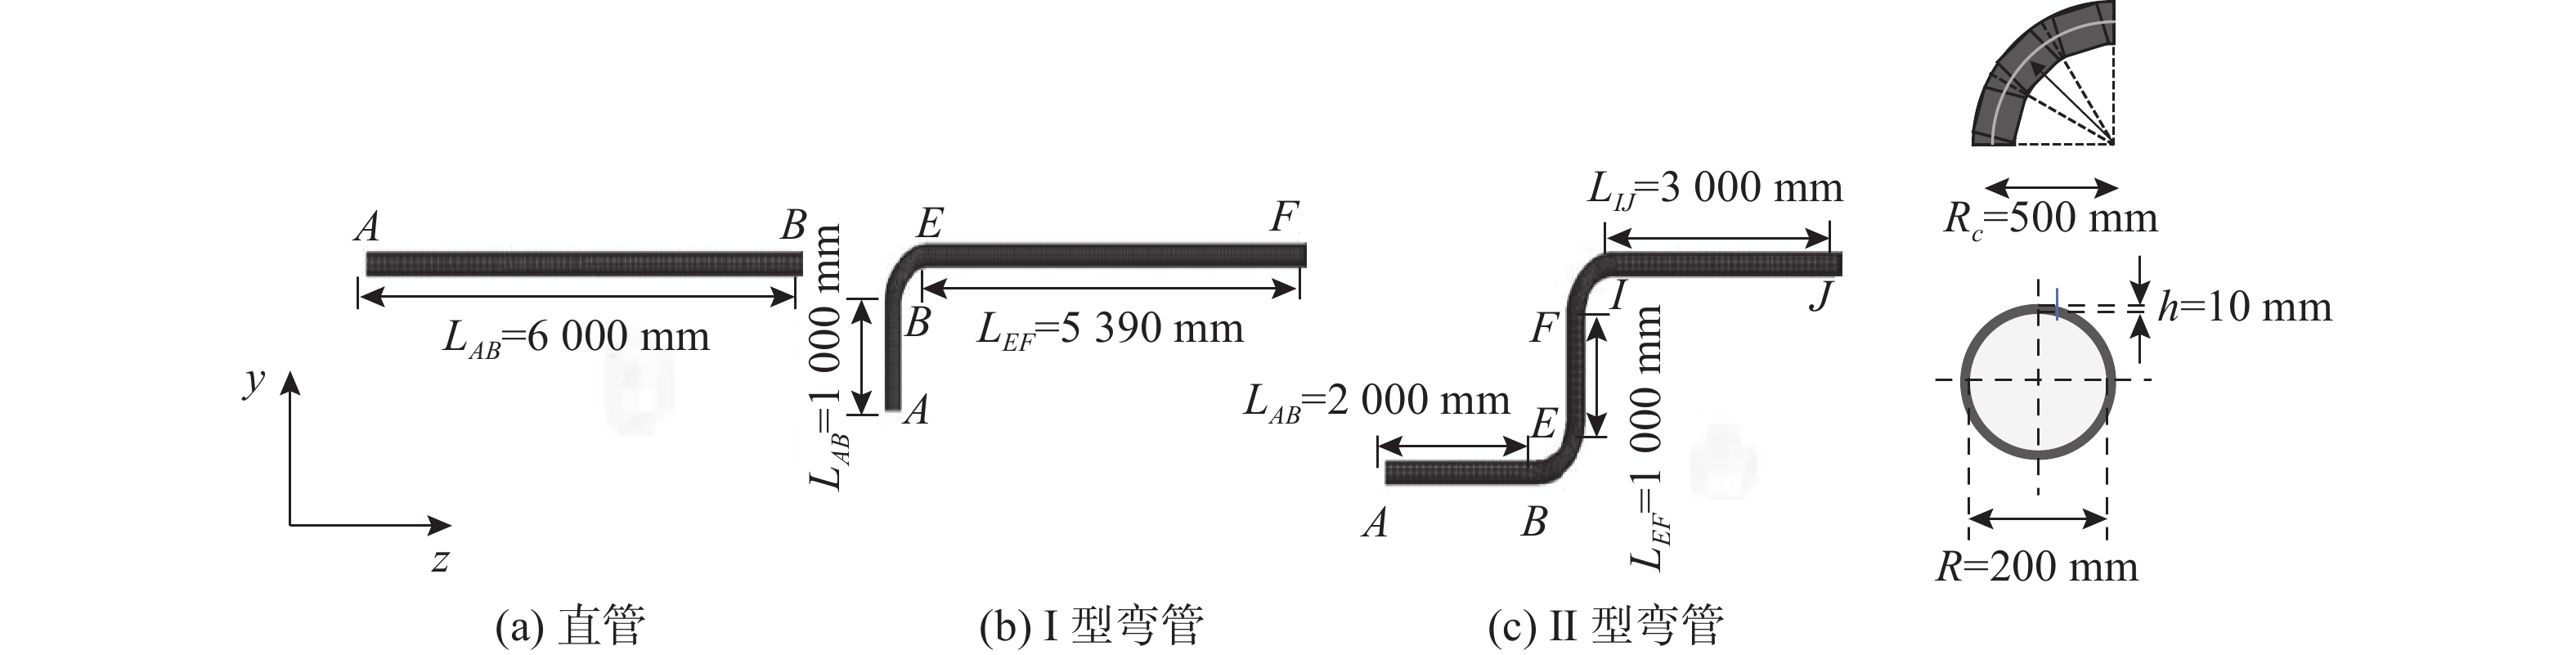
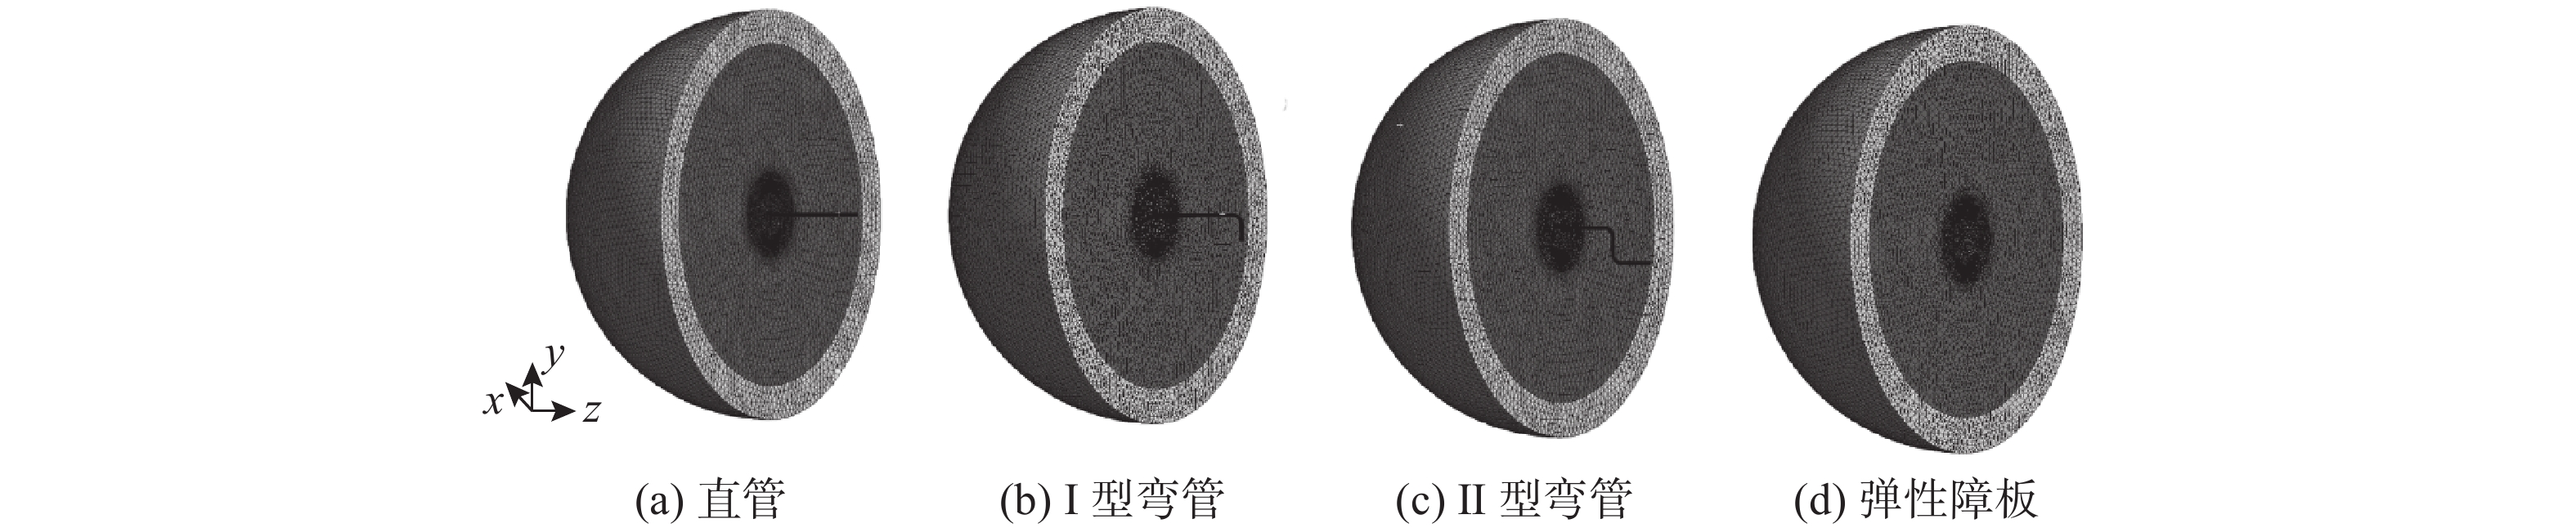
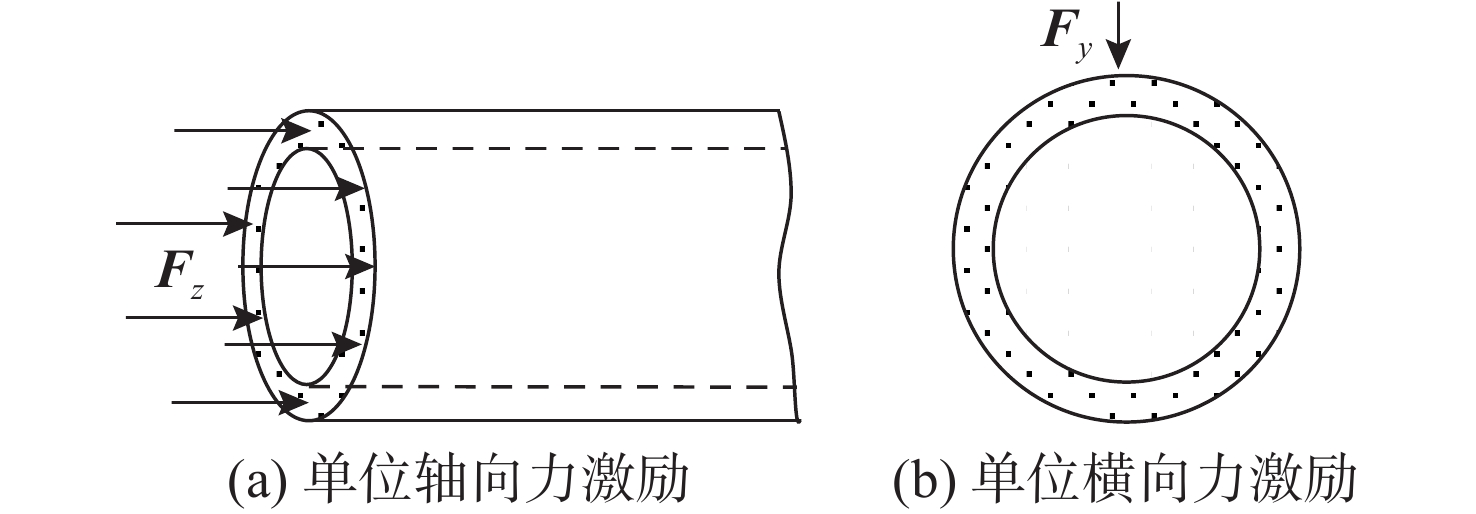
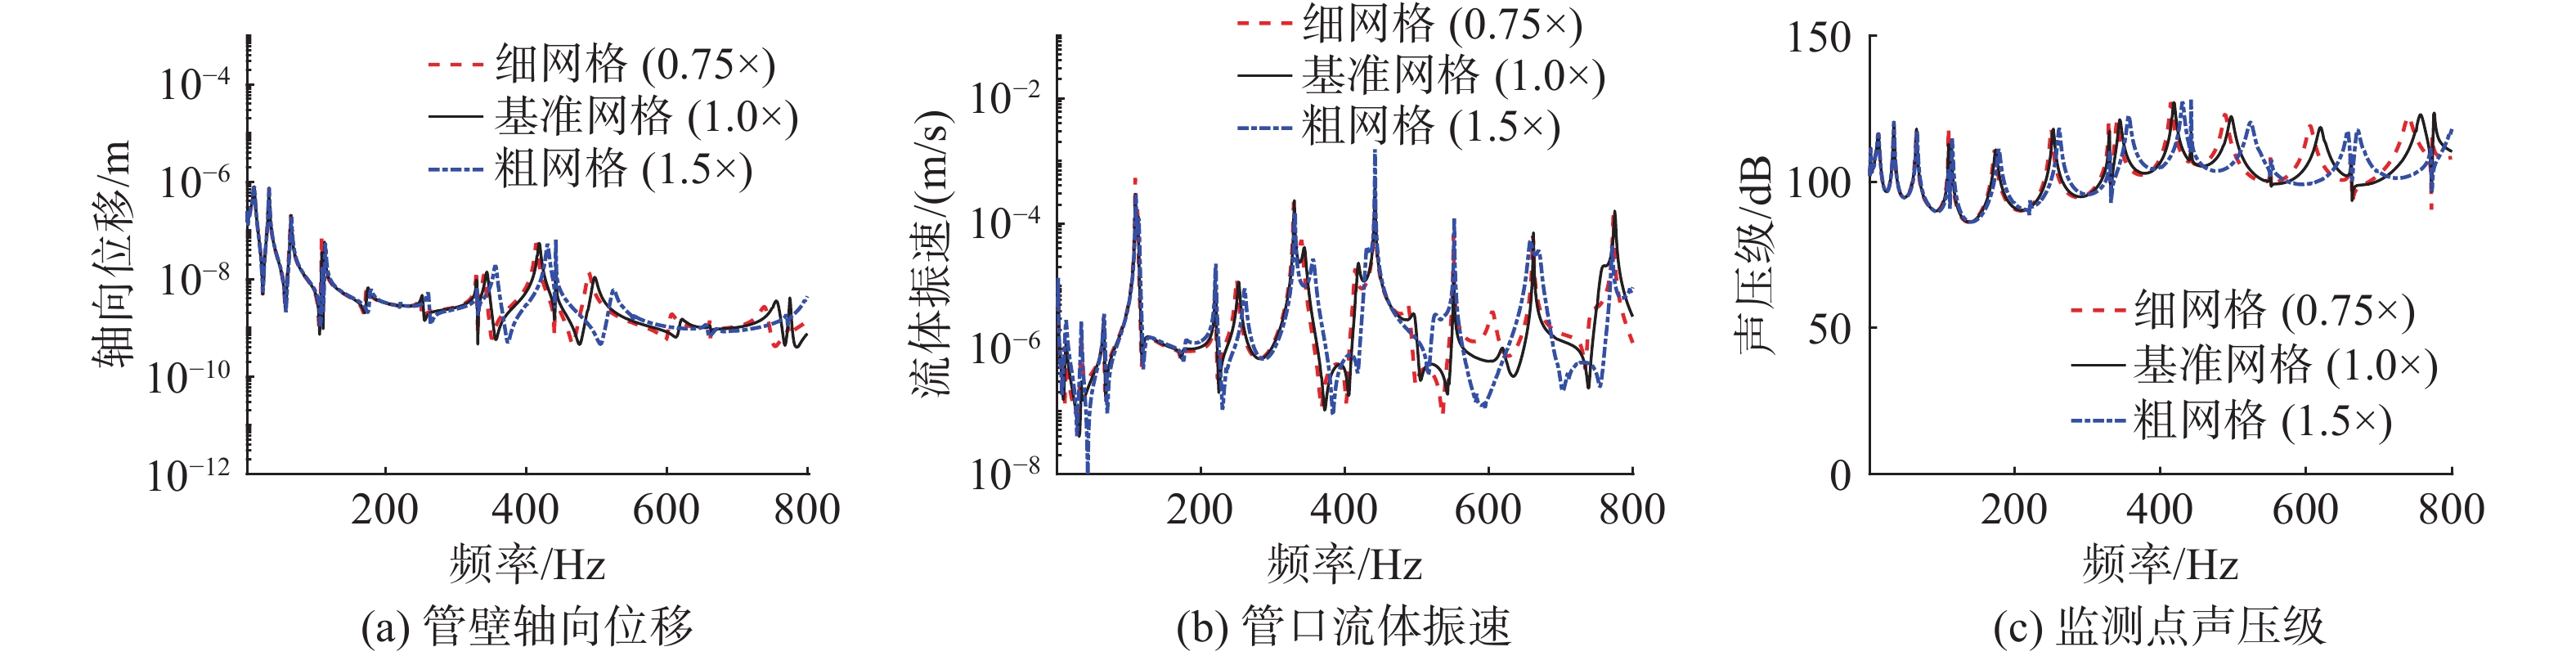
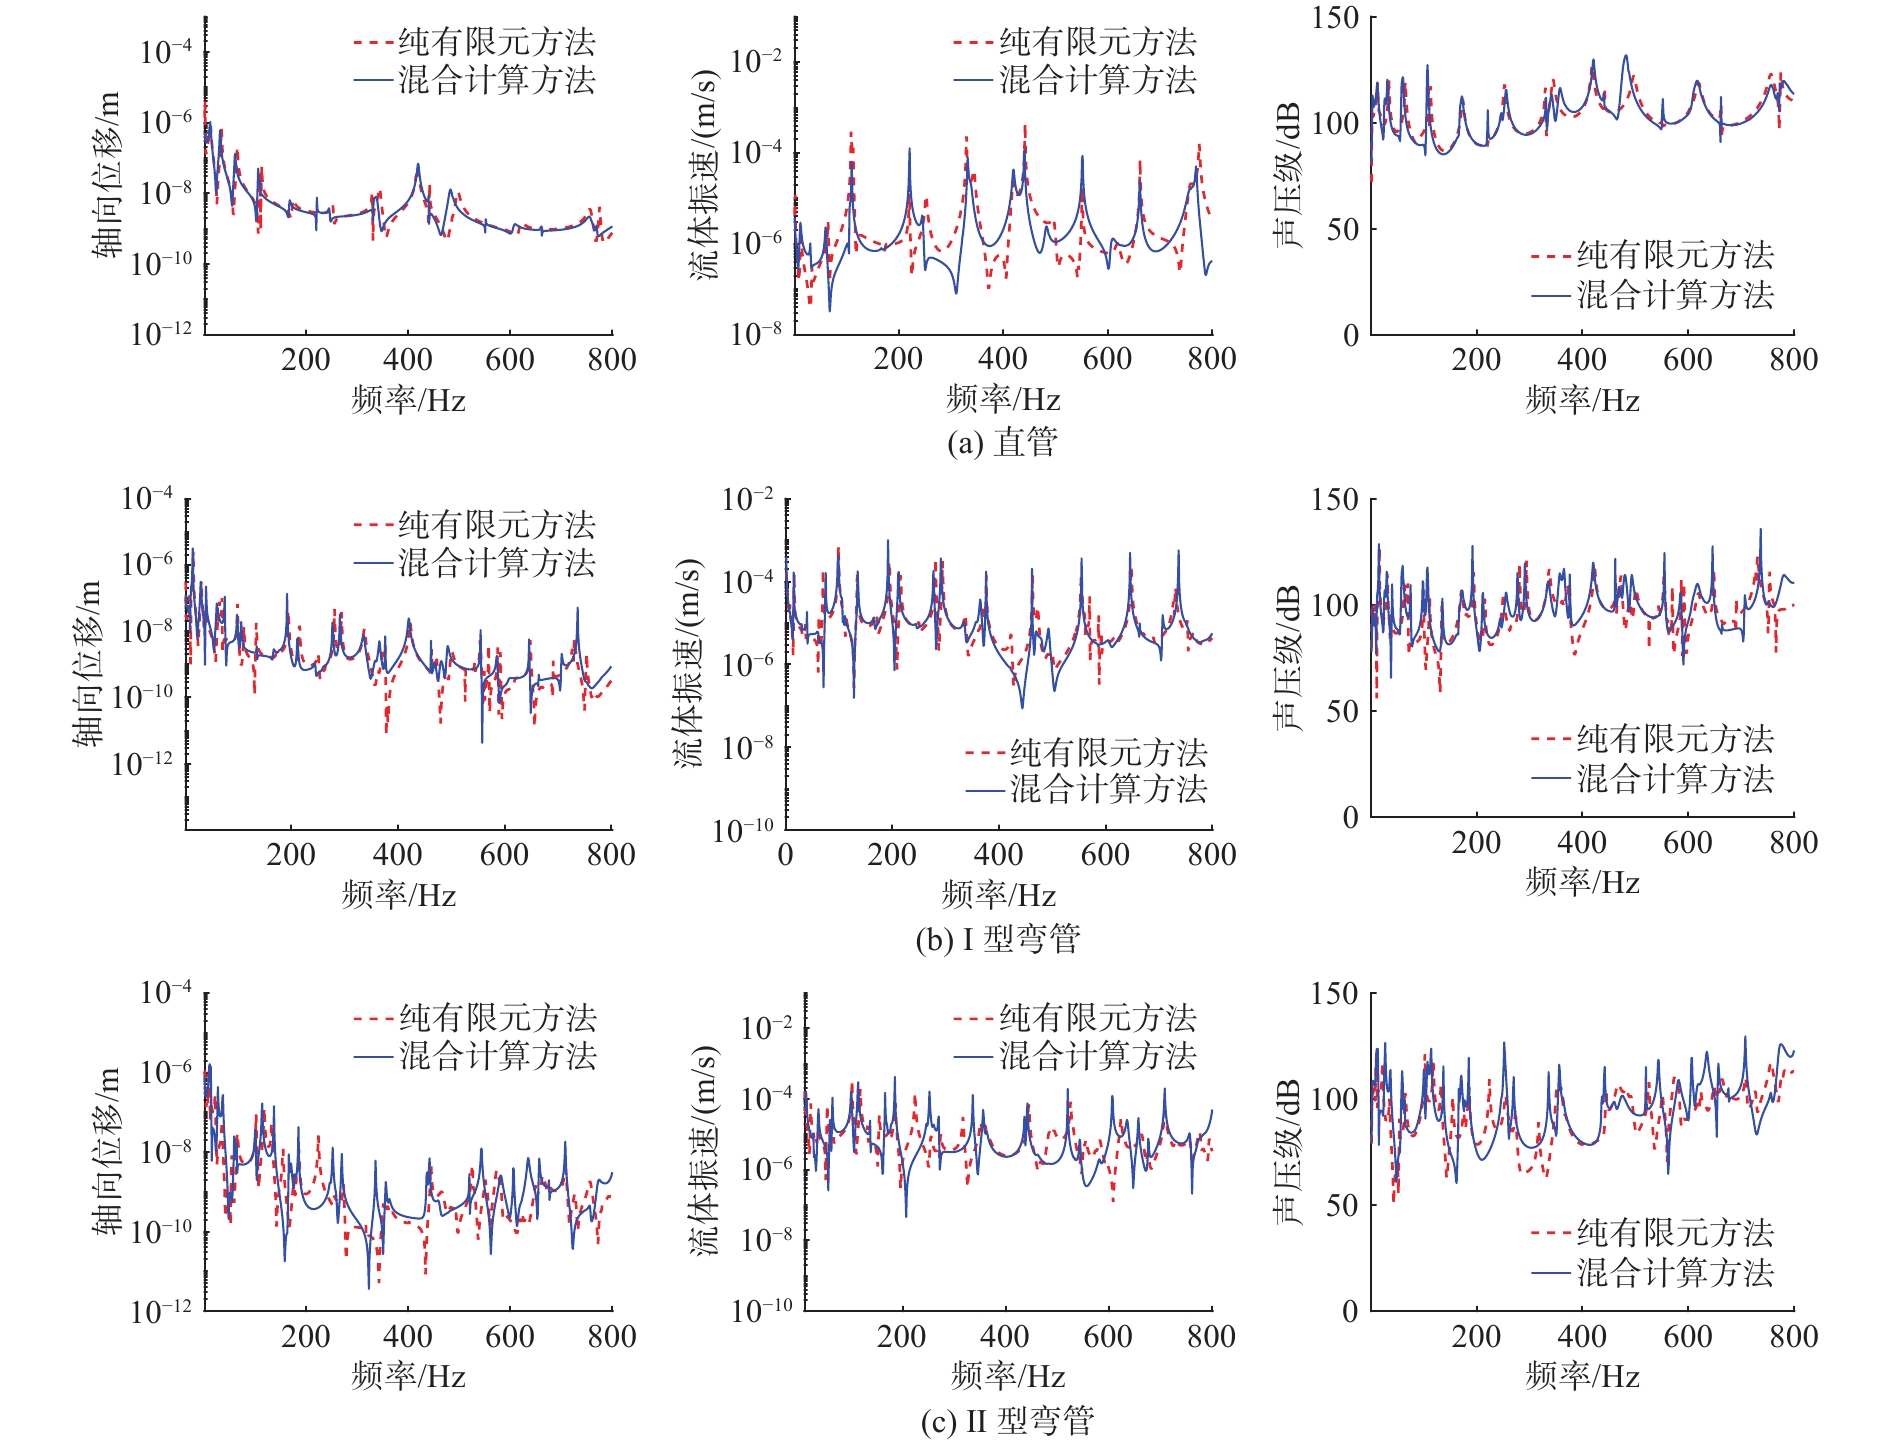
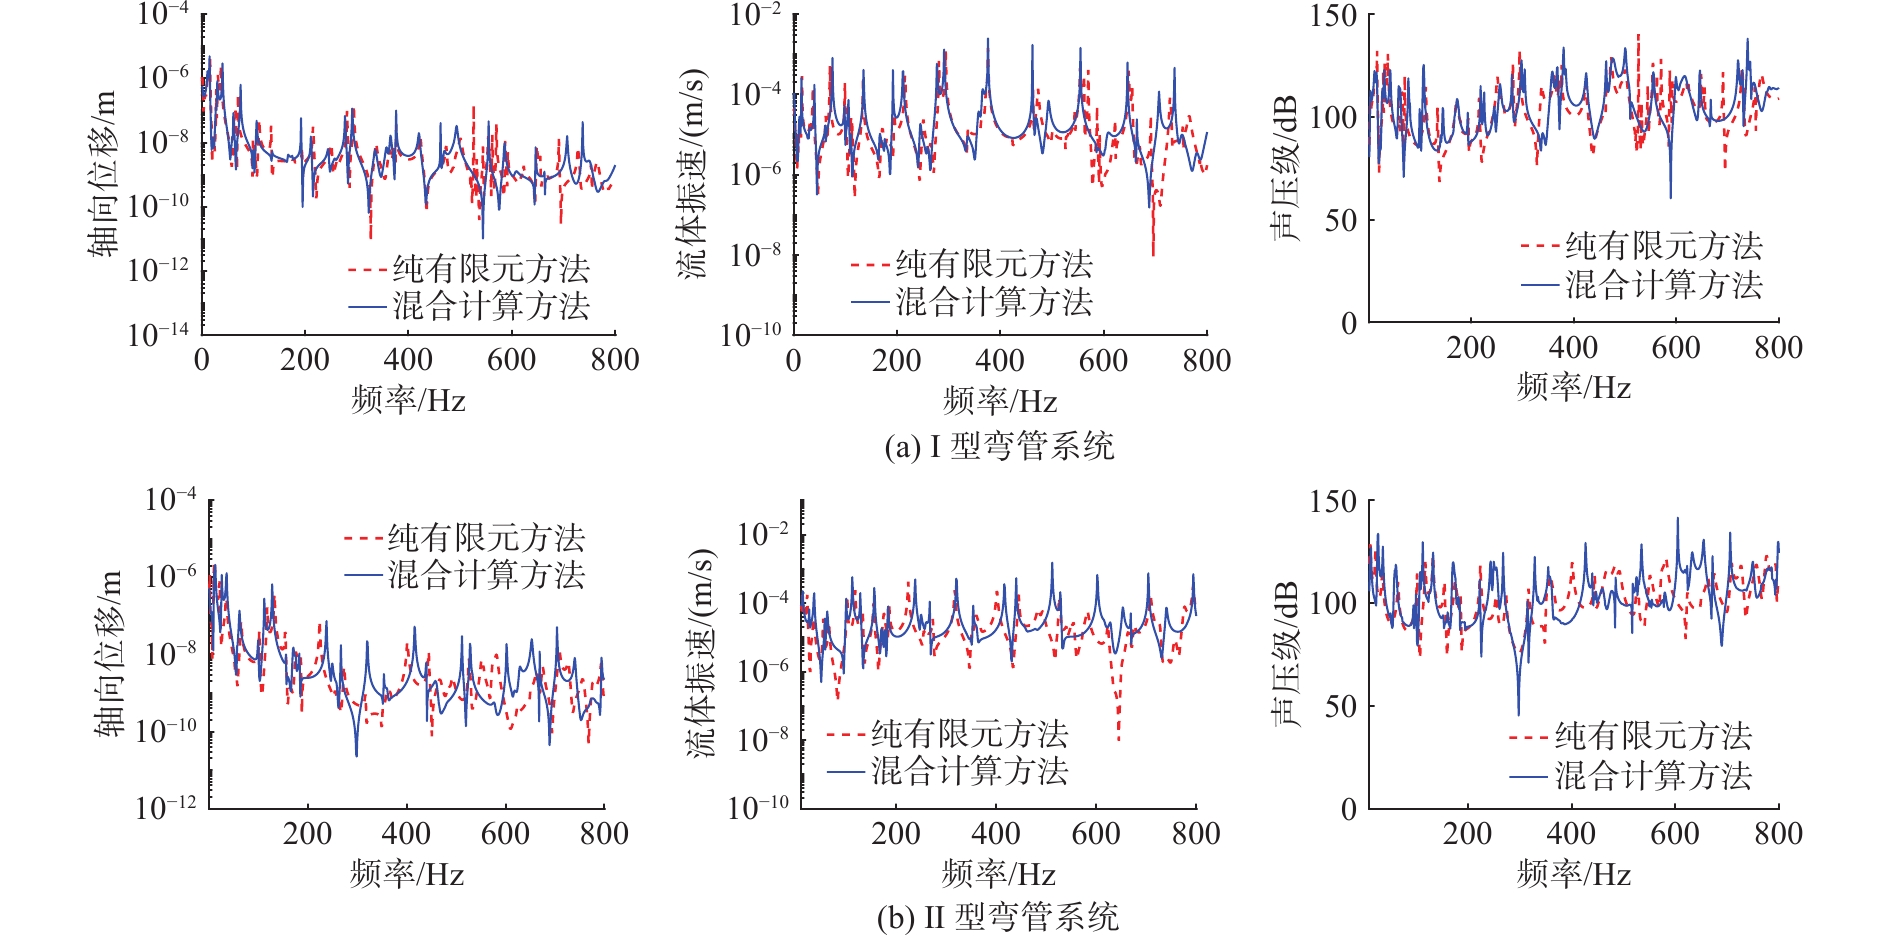
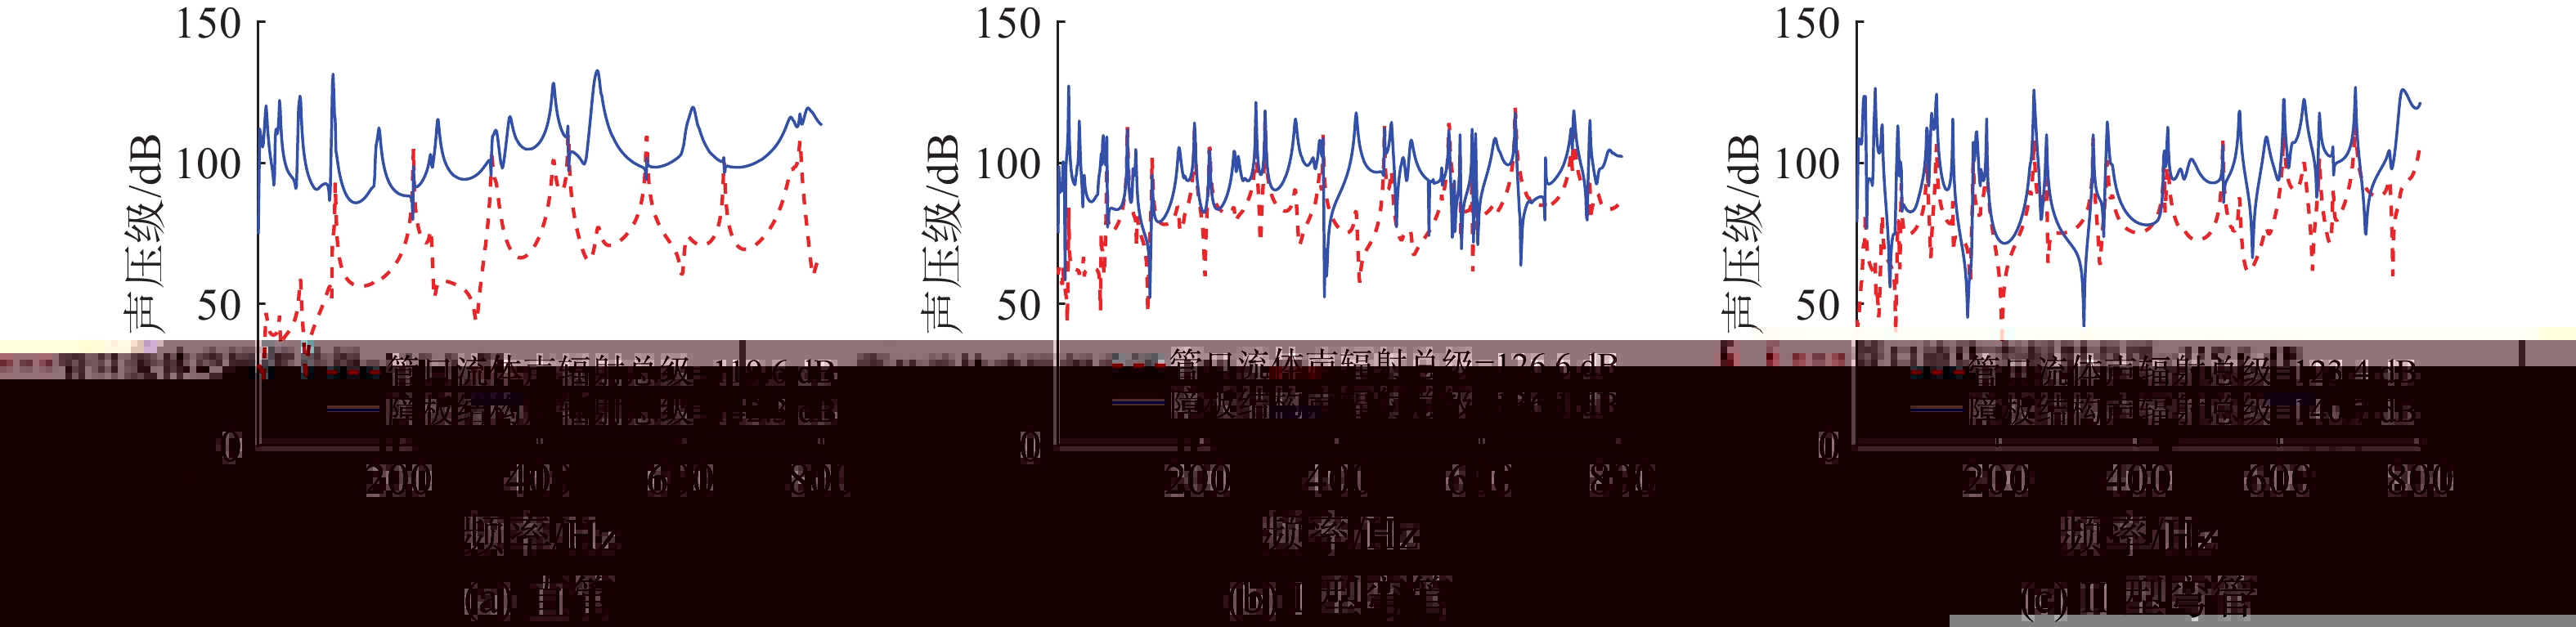
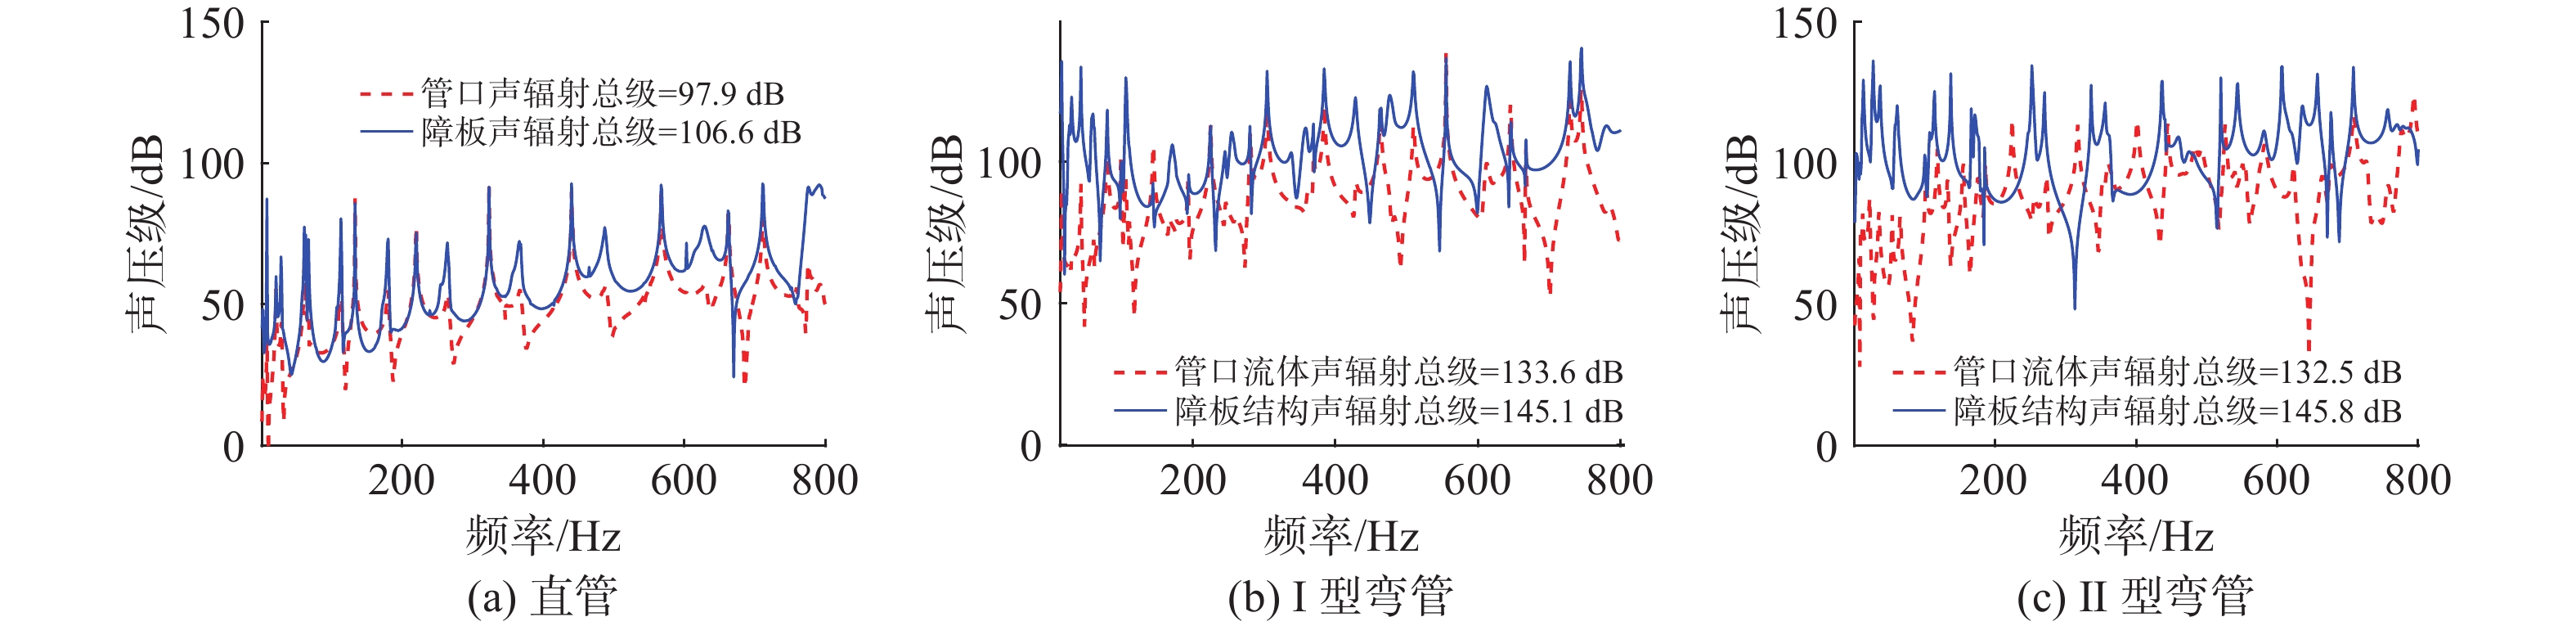
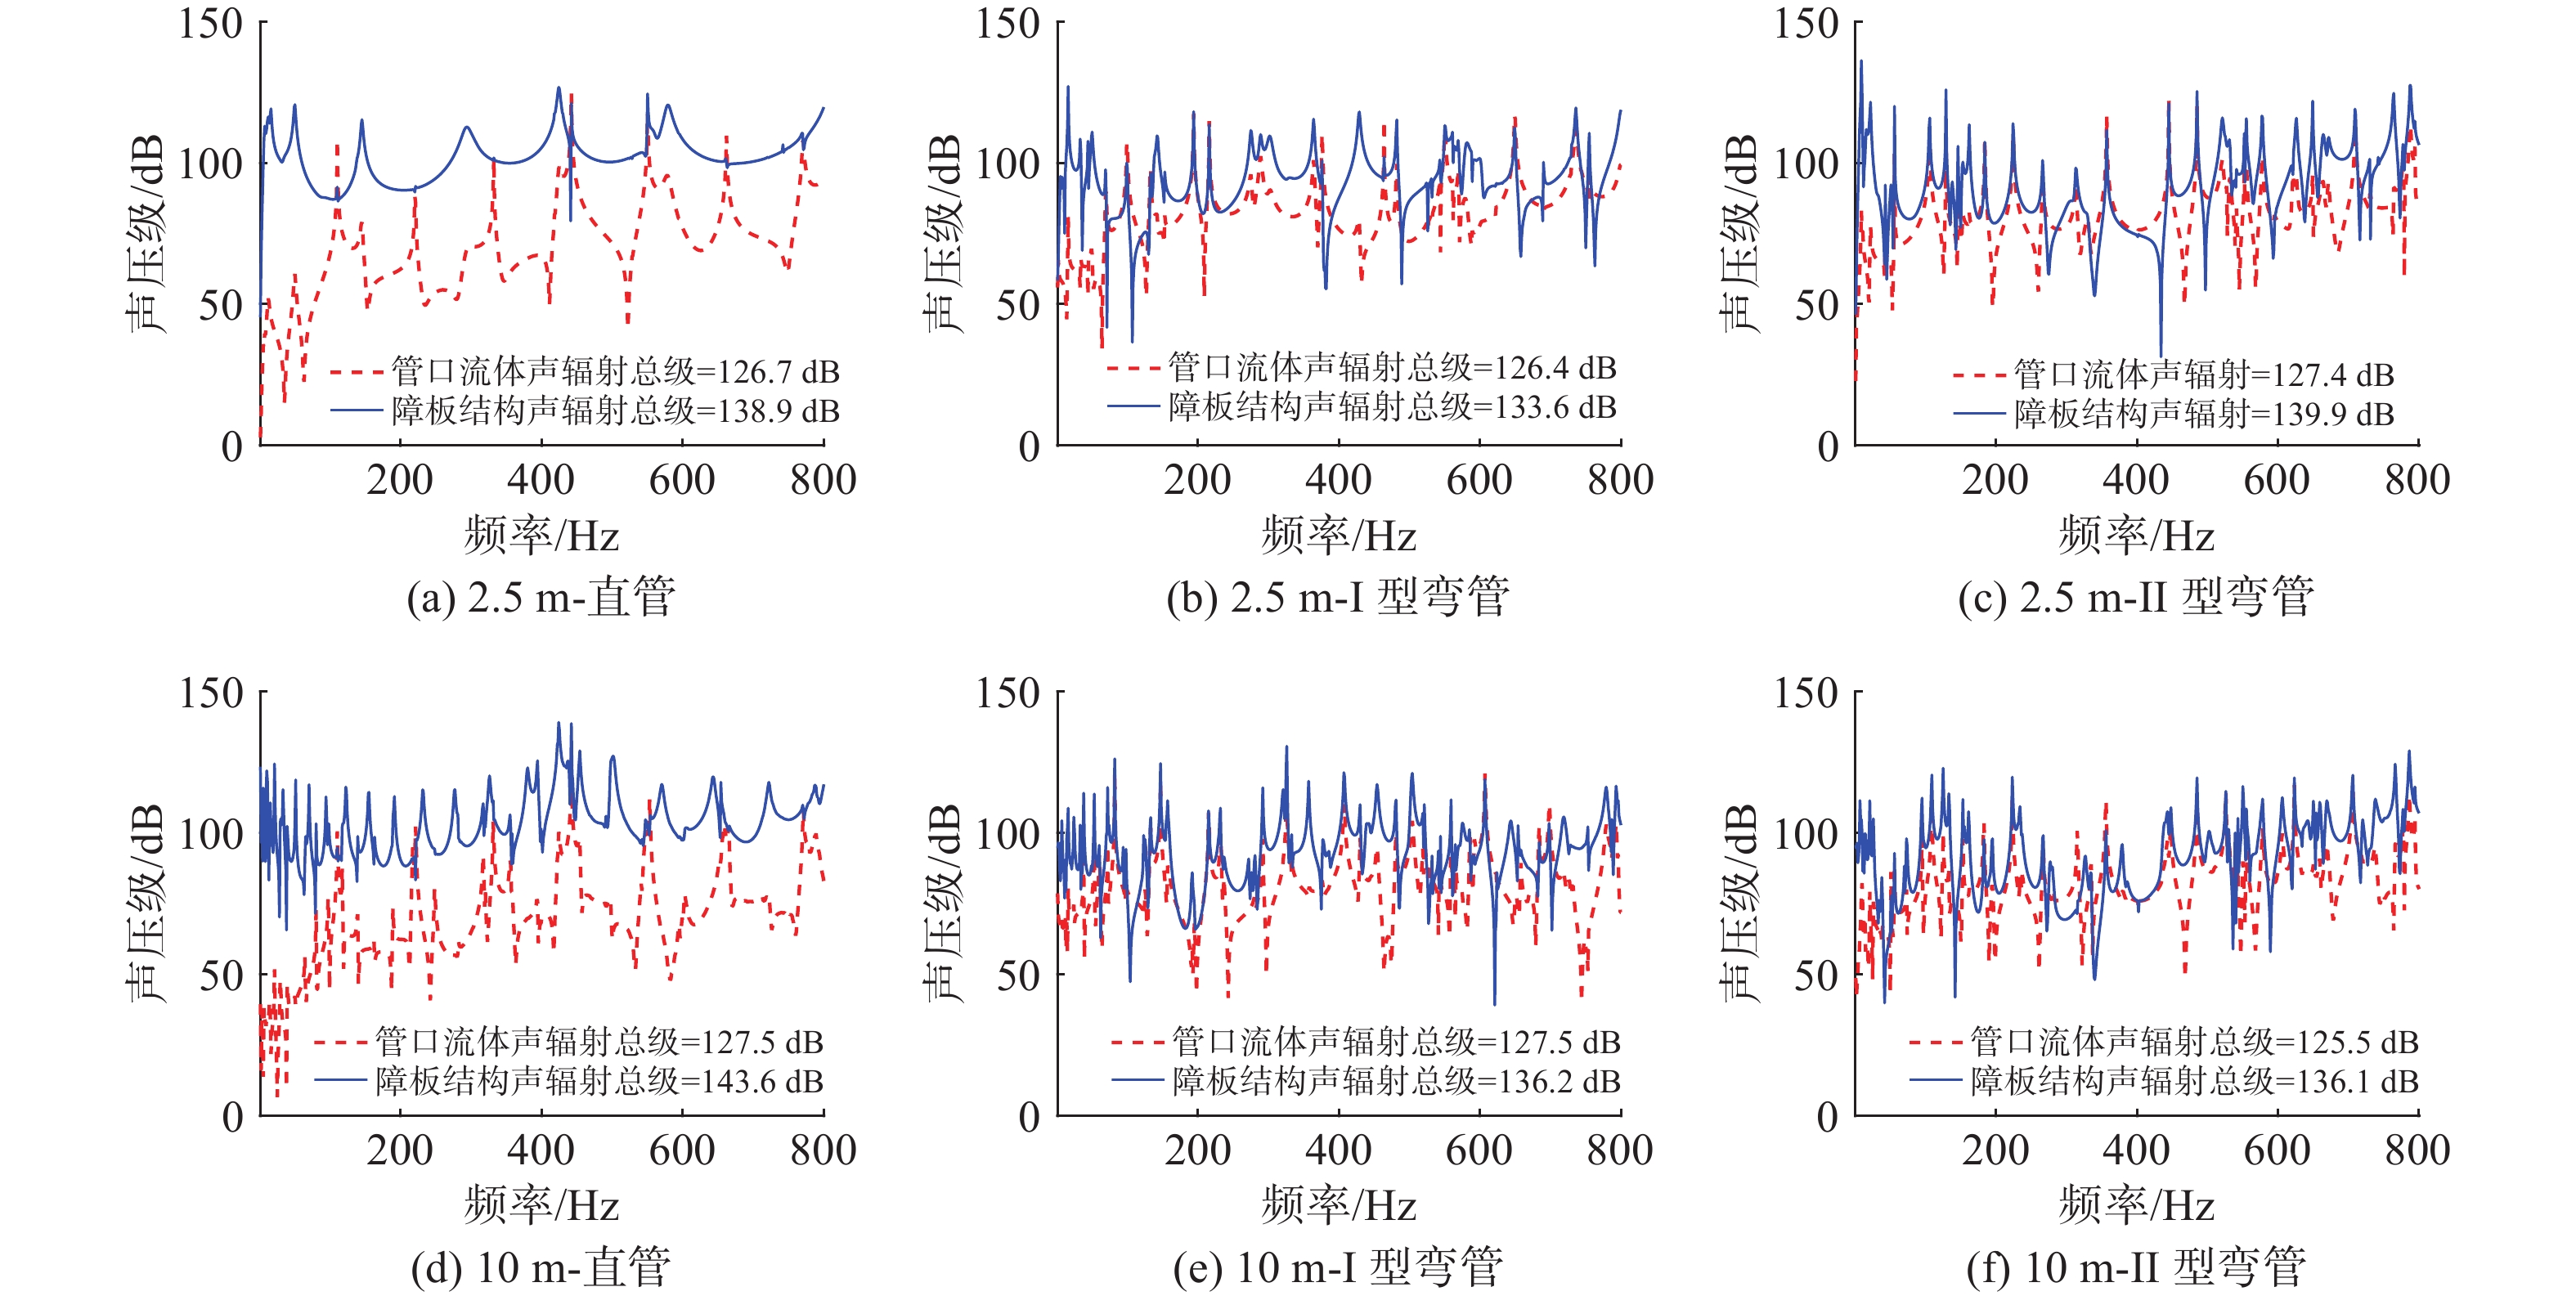
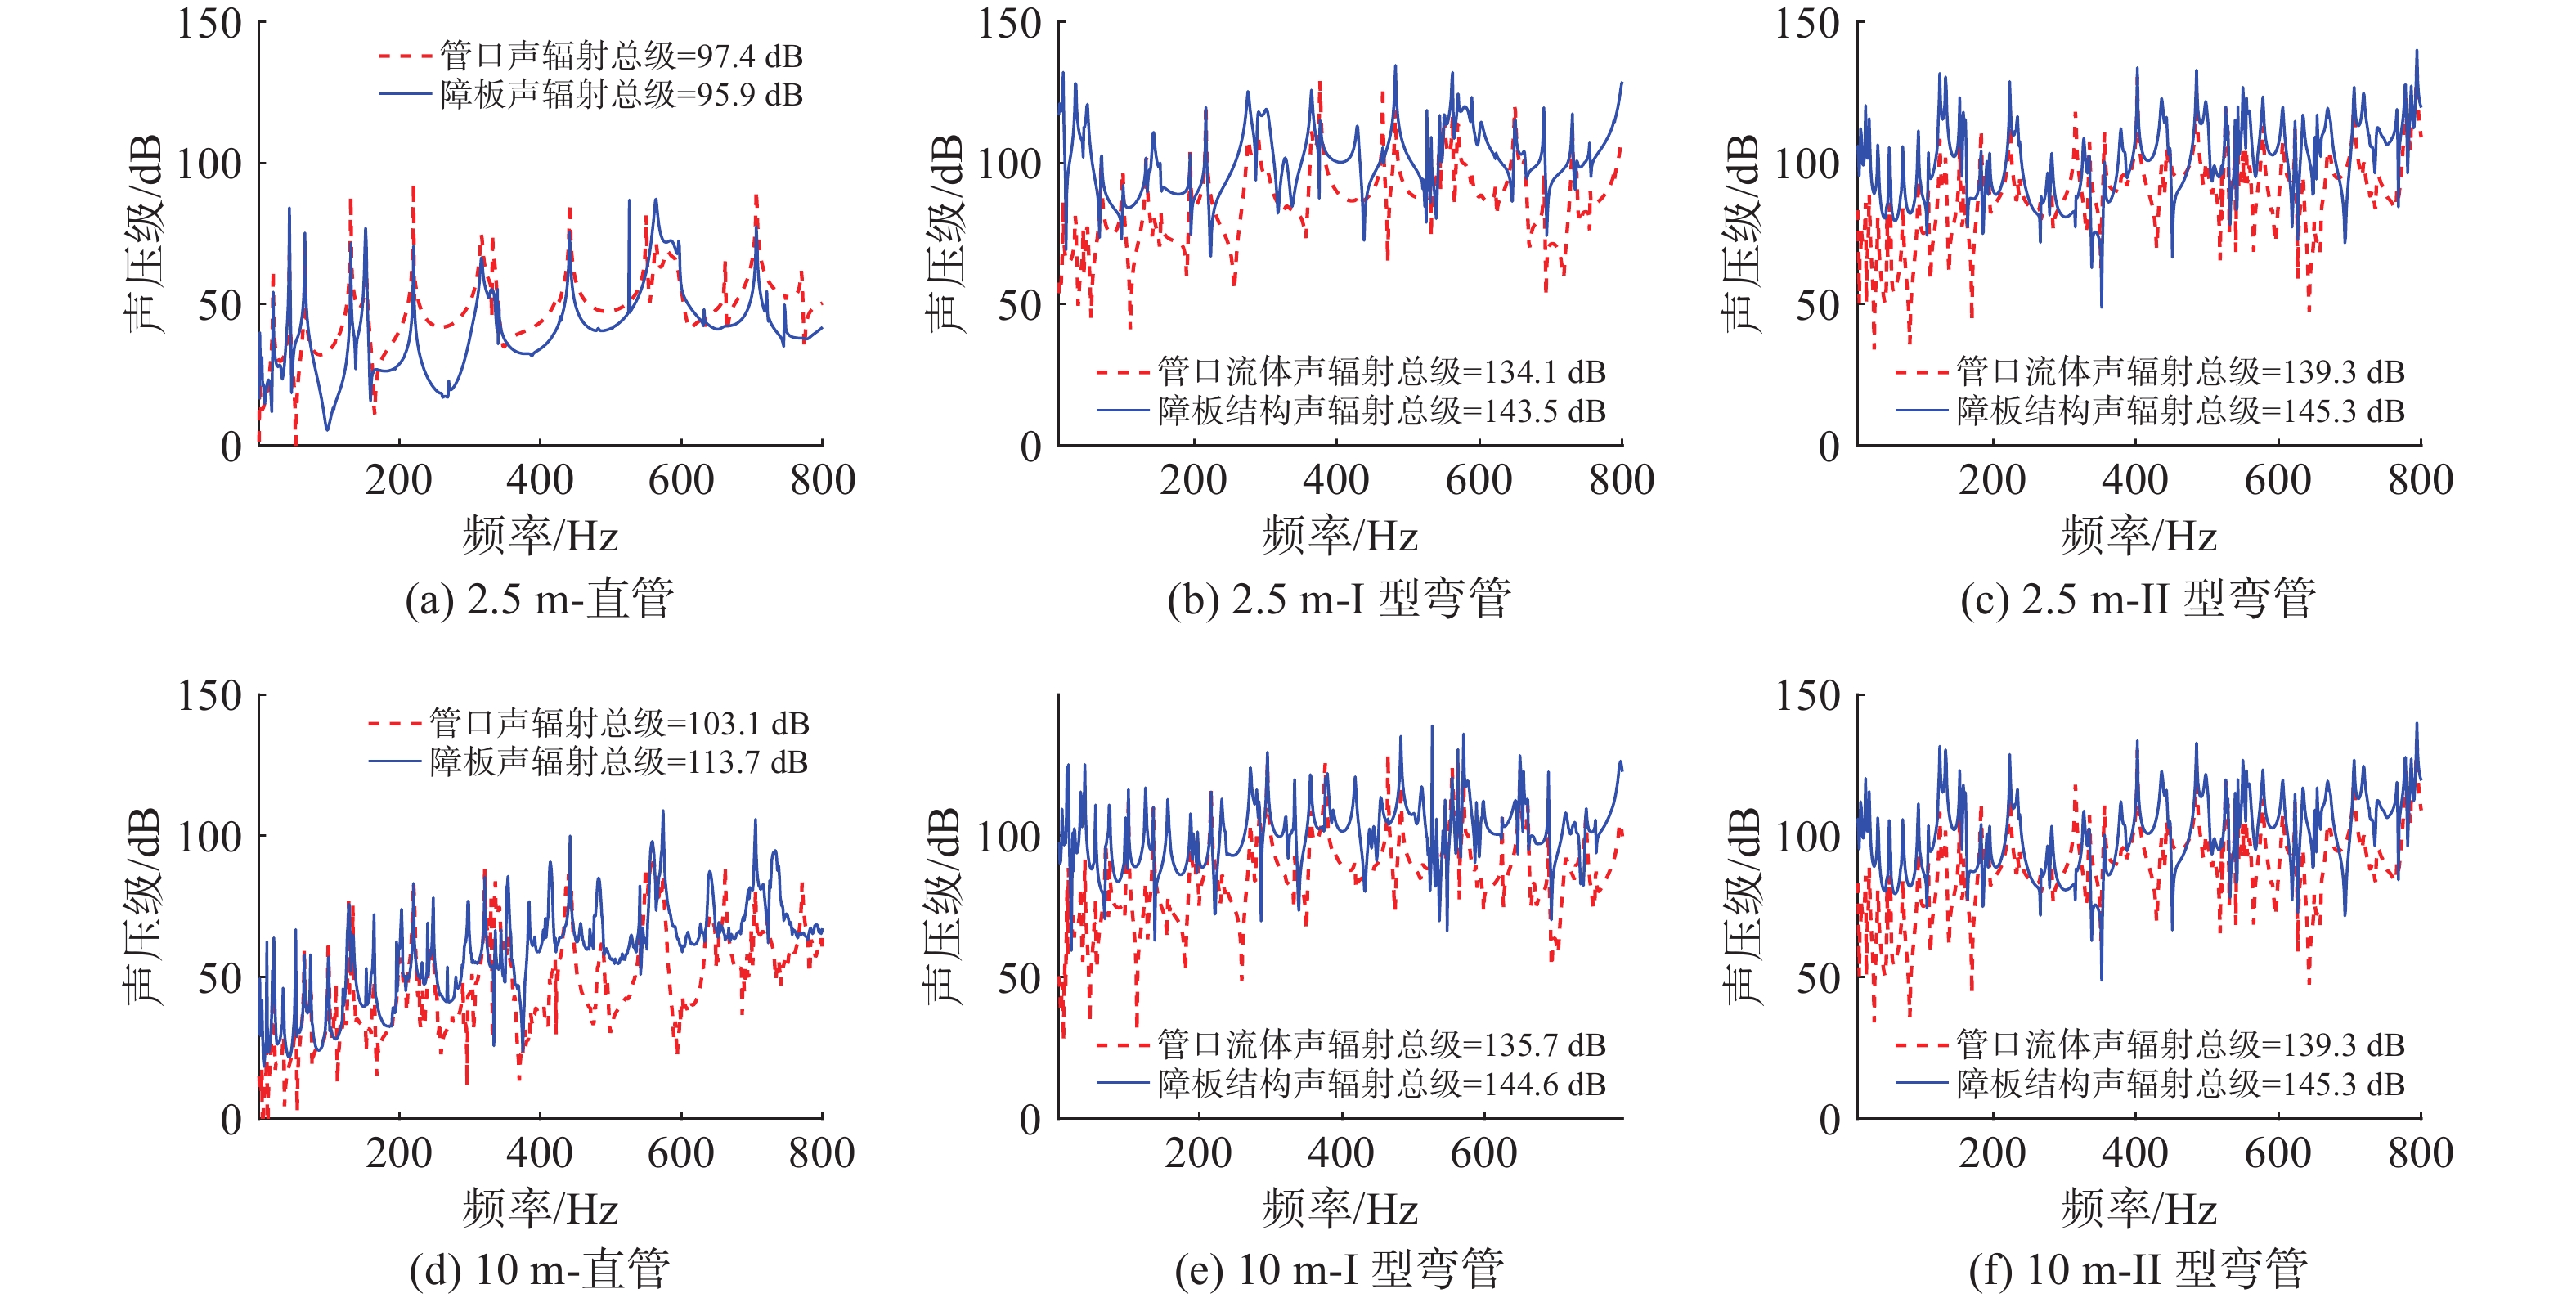
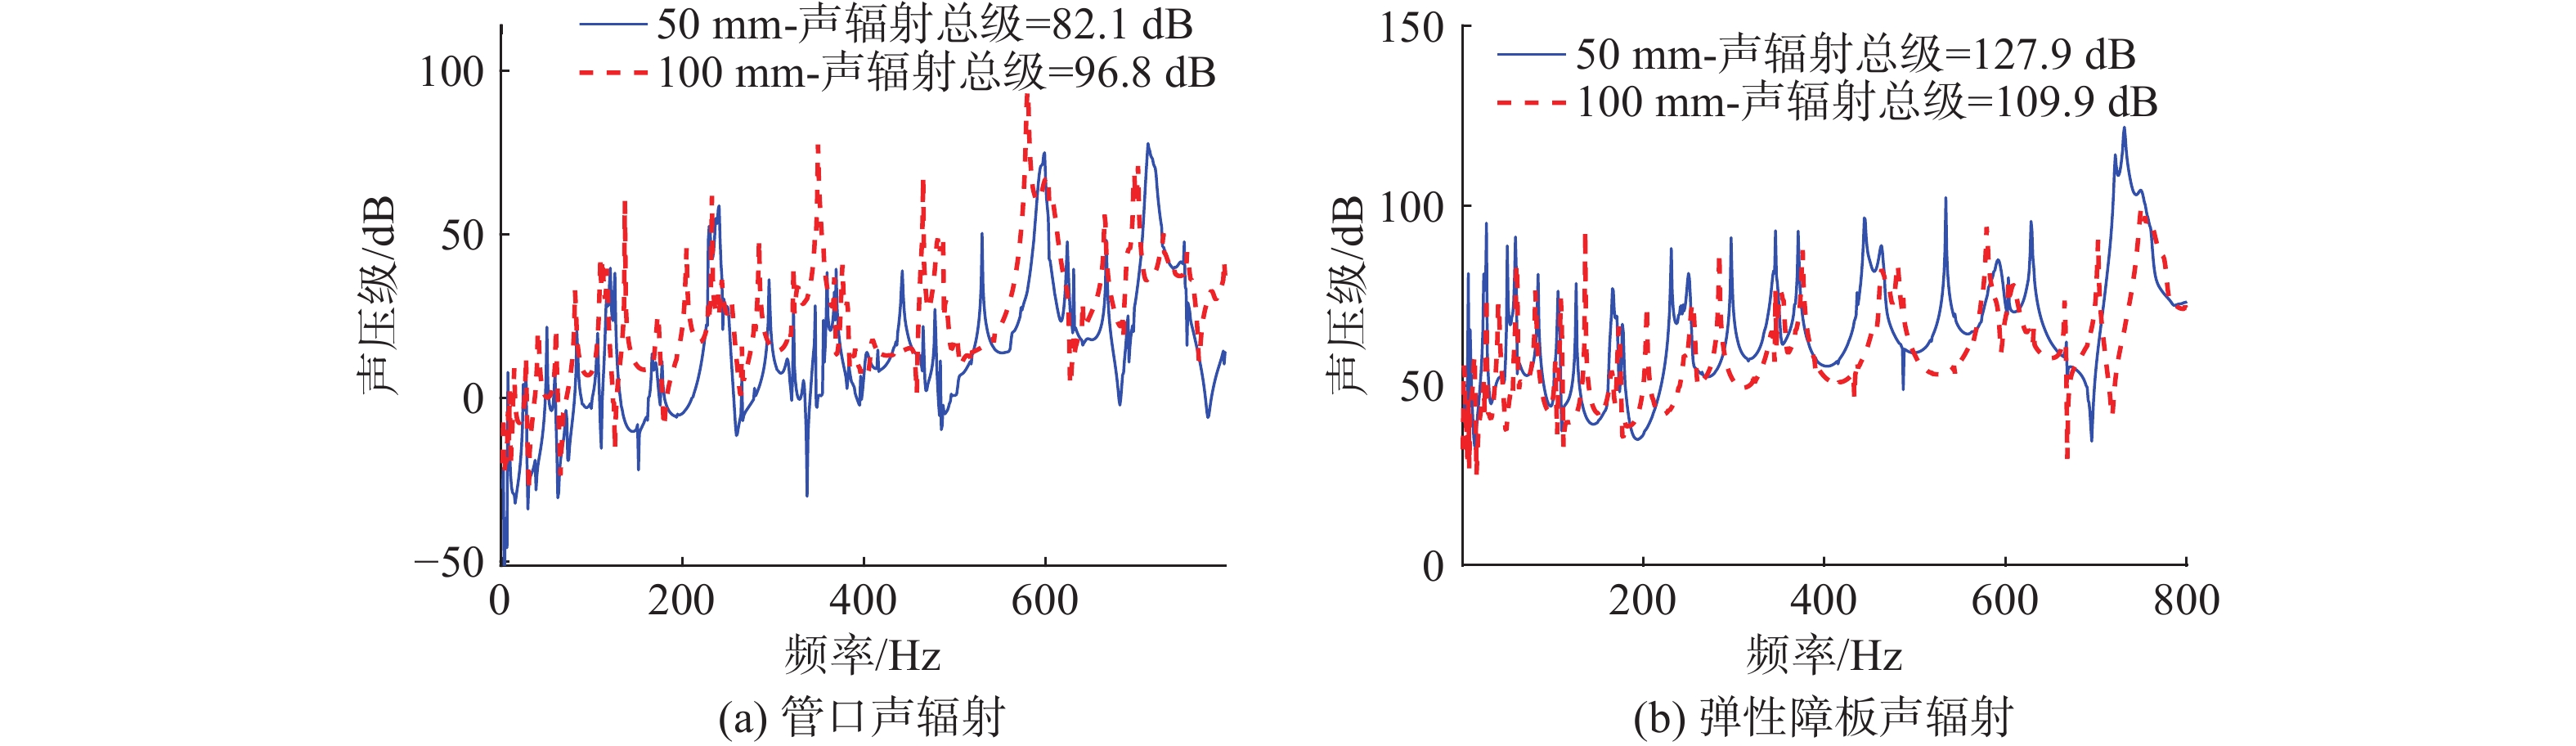
A hybrid computational method combining the transfer matrix method and the finite element method is developed to investigate the vibro-acoustic response and acoustic radiation characteristics of liquid-filled pipelines coupled with plate/shell structures. In this method, the transfer matrix method is employed to analytically model complex pipeline sections, while the finite element method is used to simulate the plate/shell structures and external acoustic field. The two methods are coupled through the impedance synthesis at the coupling interface by enforcing the continuity conditions of force and displacement. Taking liquid-filled pipelines coupled with elastic plates, including straight pipes and two types of bent pipes, as examples, the effects of bend configurations, elastic baffle dimensions, and pipe diameter on the acoustic radiation at the monitoring point under mechanical force excitation are investigated. The results show that the acoustic radiation from the elastic plate dominates in most cases. However, with increasing pipe diameter or decreasing baffle size, the contribution of pipe outlet radiation increases significantly and becomes comparable to or even exceeds that of the elastic plate radiation in some cases. The relative contributions of pipe outlet and elastic plate radiation are governed by pipeline configurations, excitation directions, and structural parameters, showing distinct radiation characteristics.
Design and dynamic analysis of suspended UVPMS for visual-assisted grasping of polymetallic nodules
CHANG Zongyu, ZHAO Yangzhi, HUANG Boyuan, XU Zhihao, TANG Chao, CHI Yanli, WANG Haibo
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0091
Abstract:
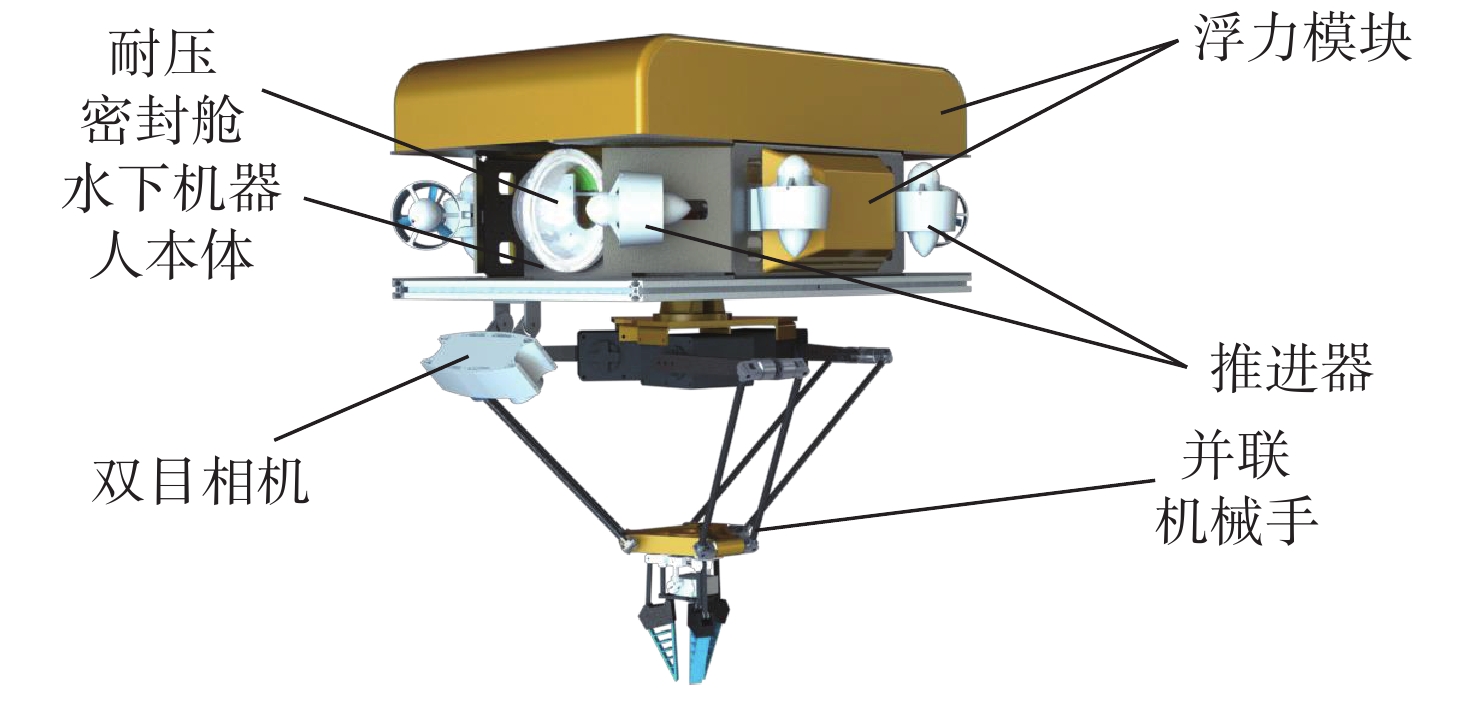
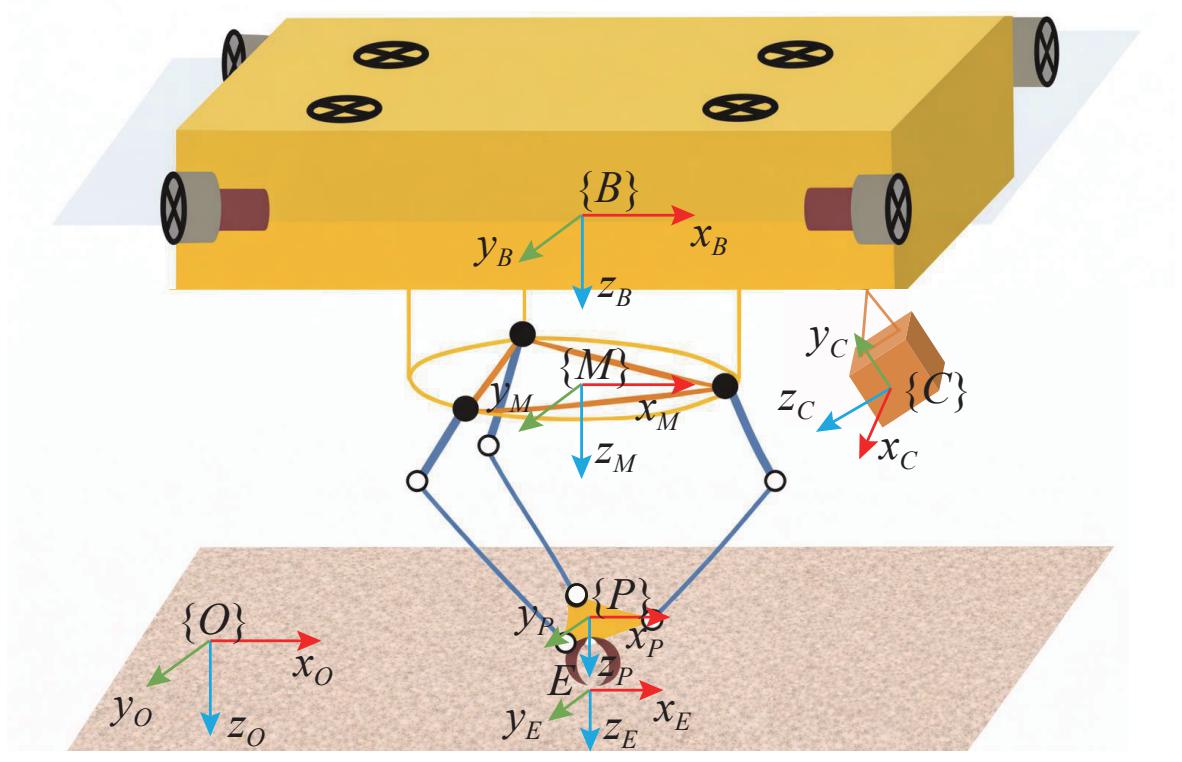
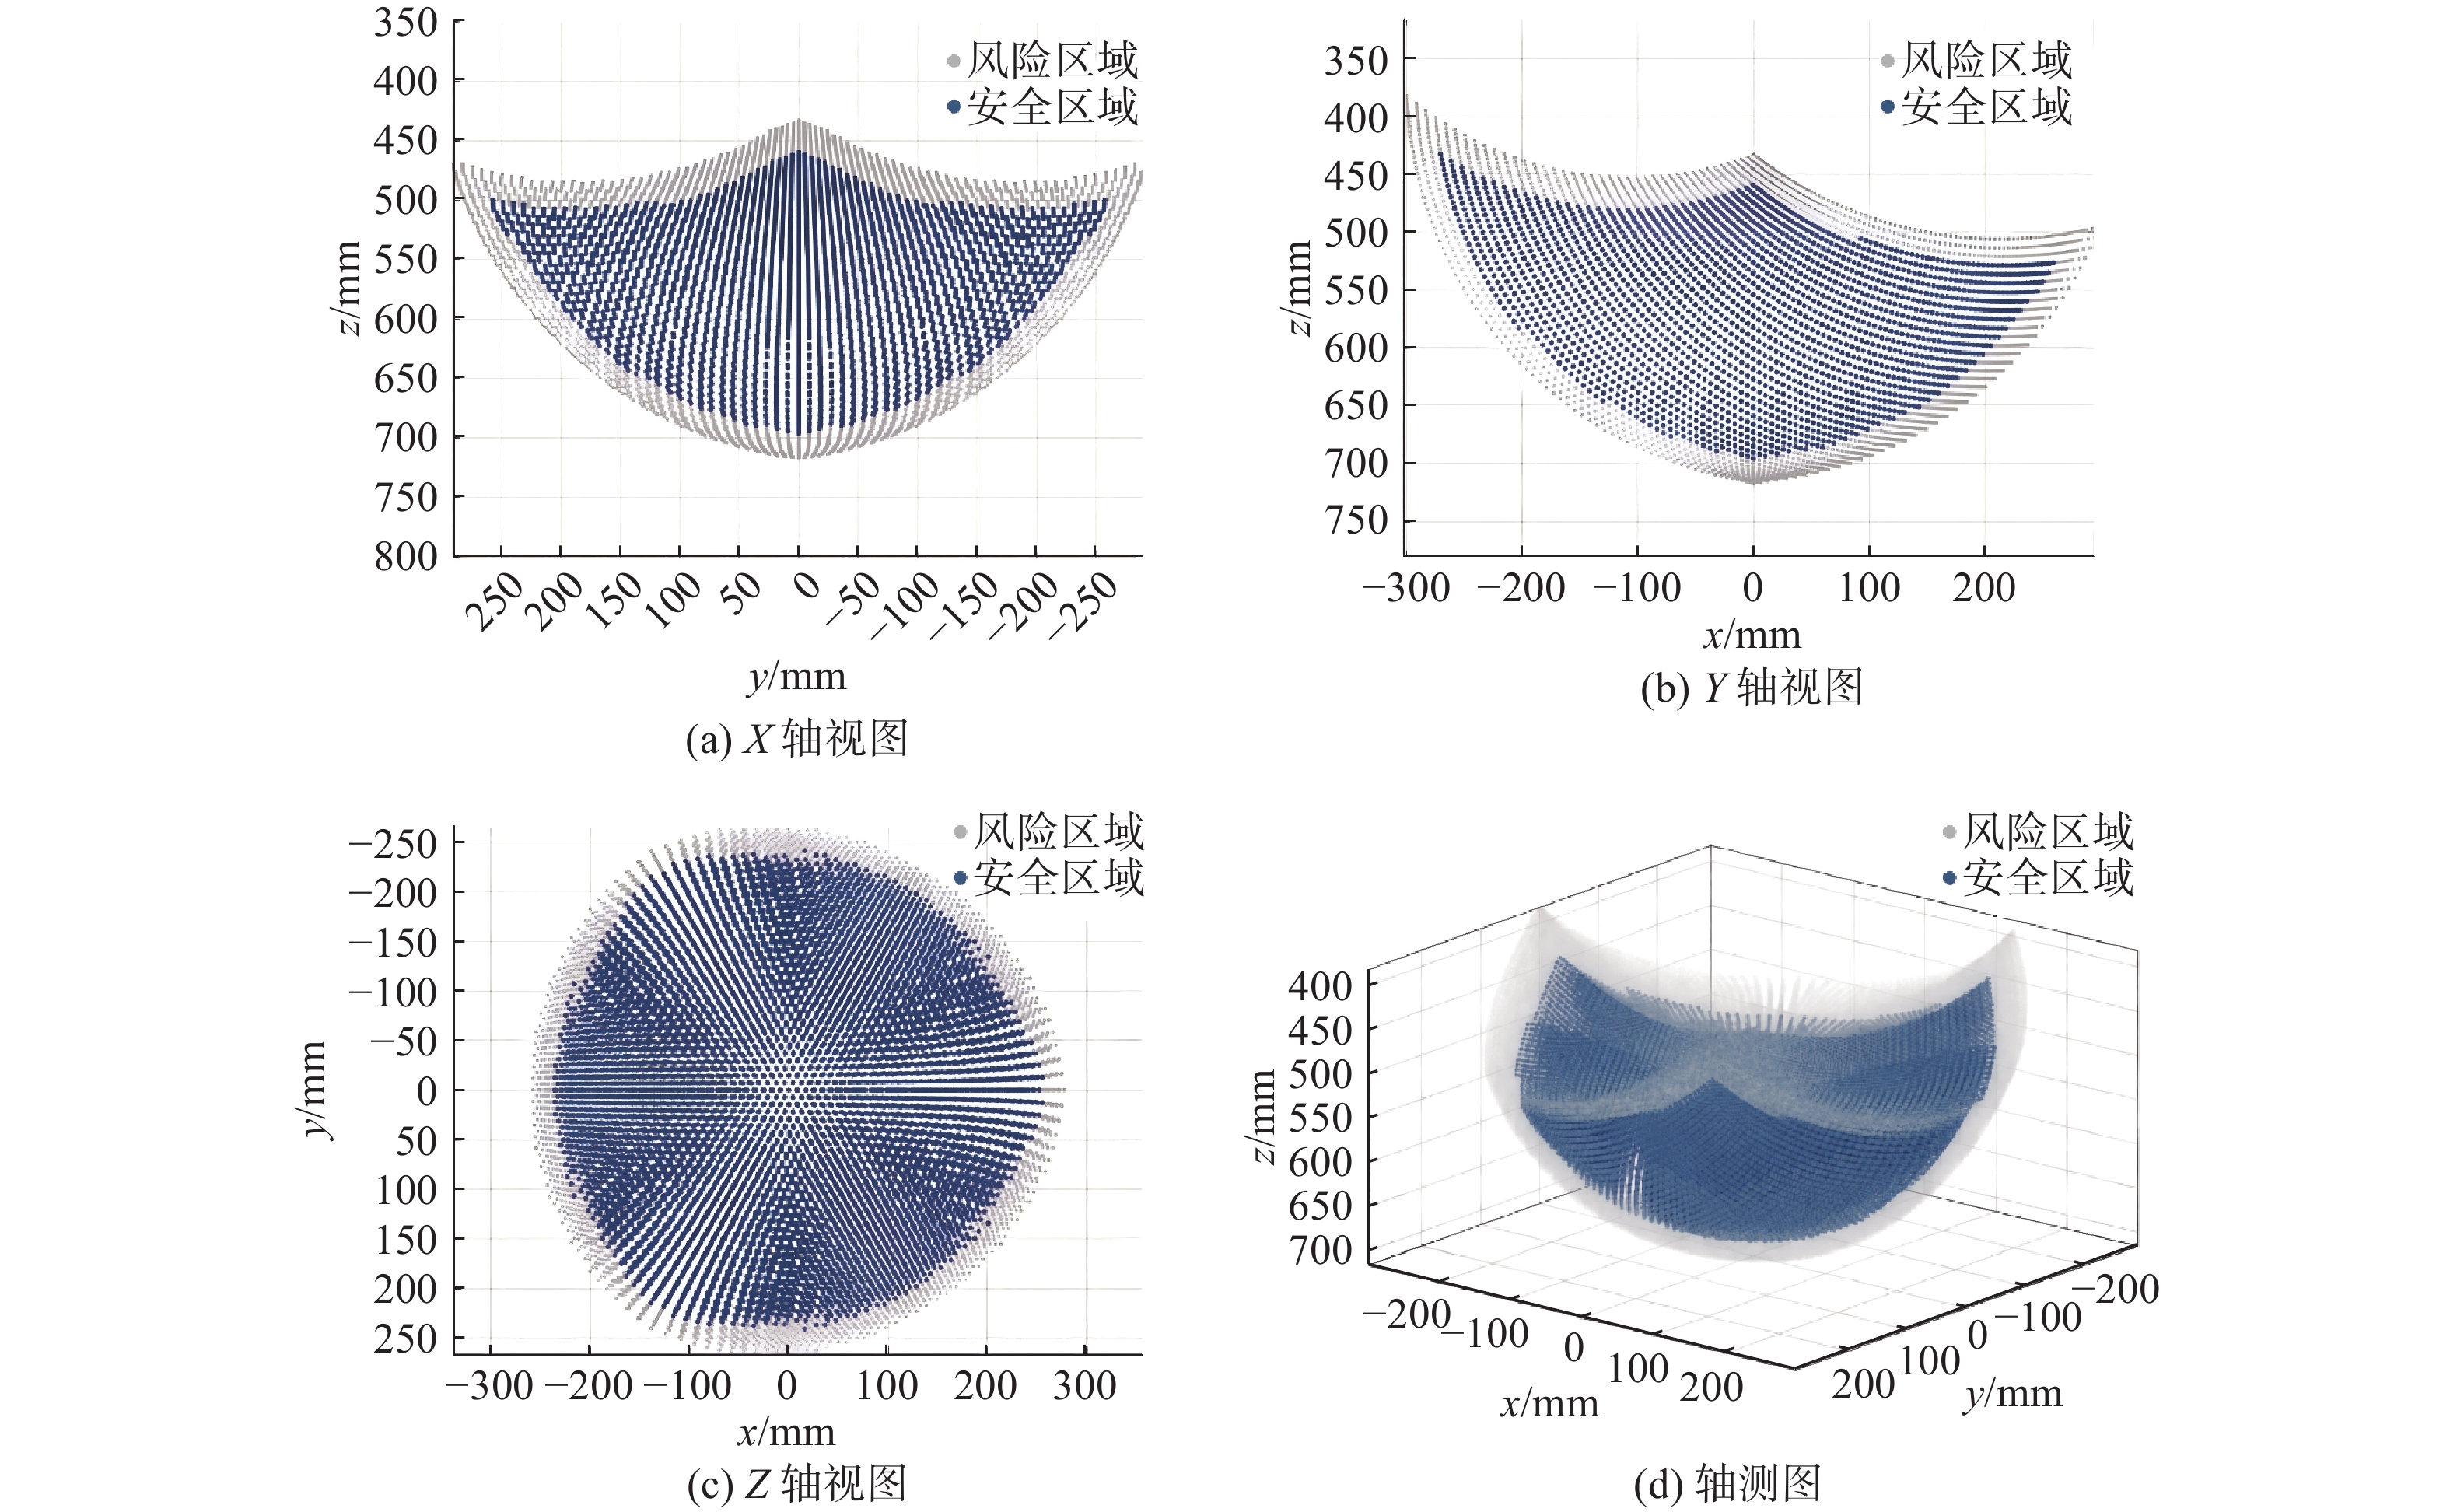
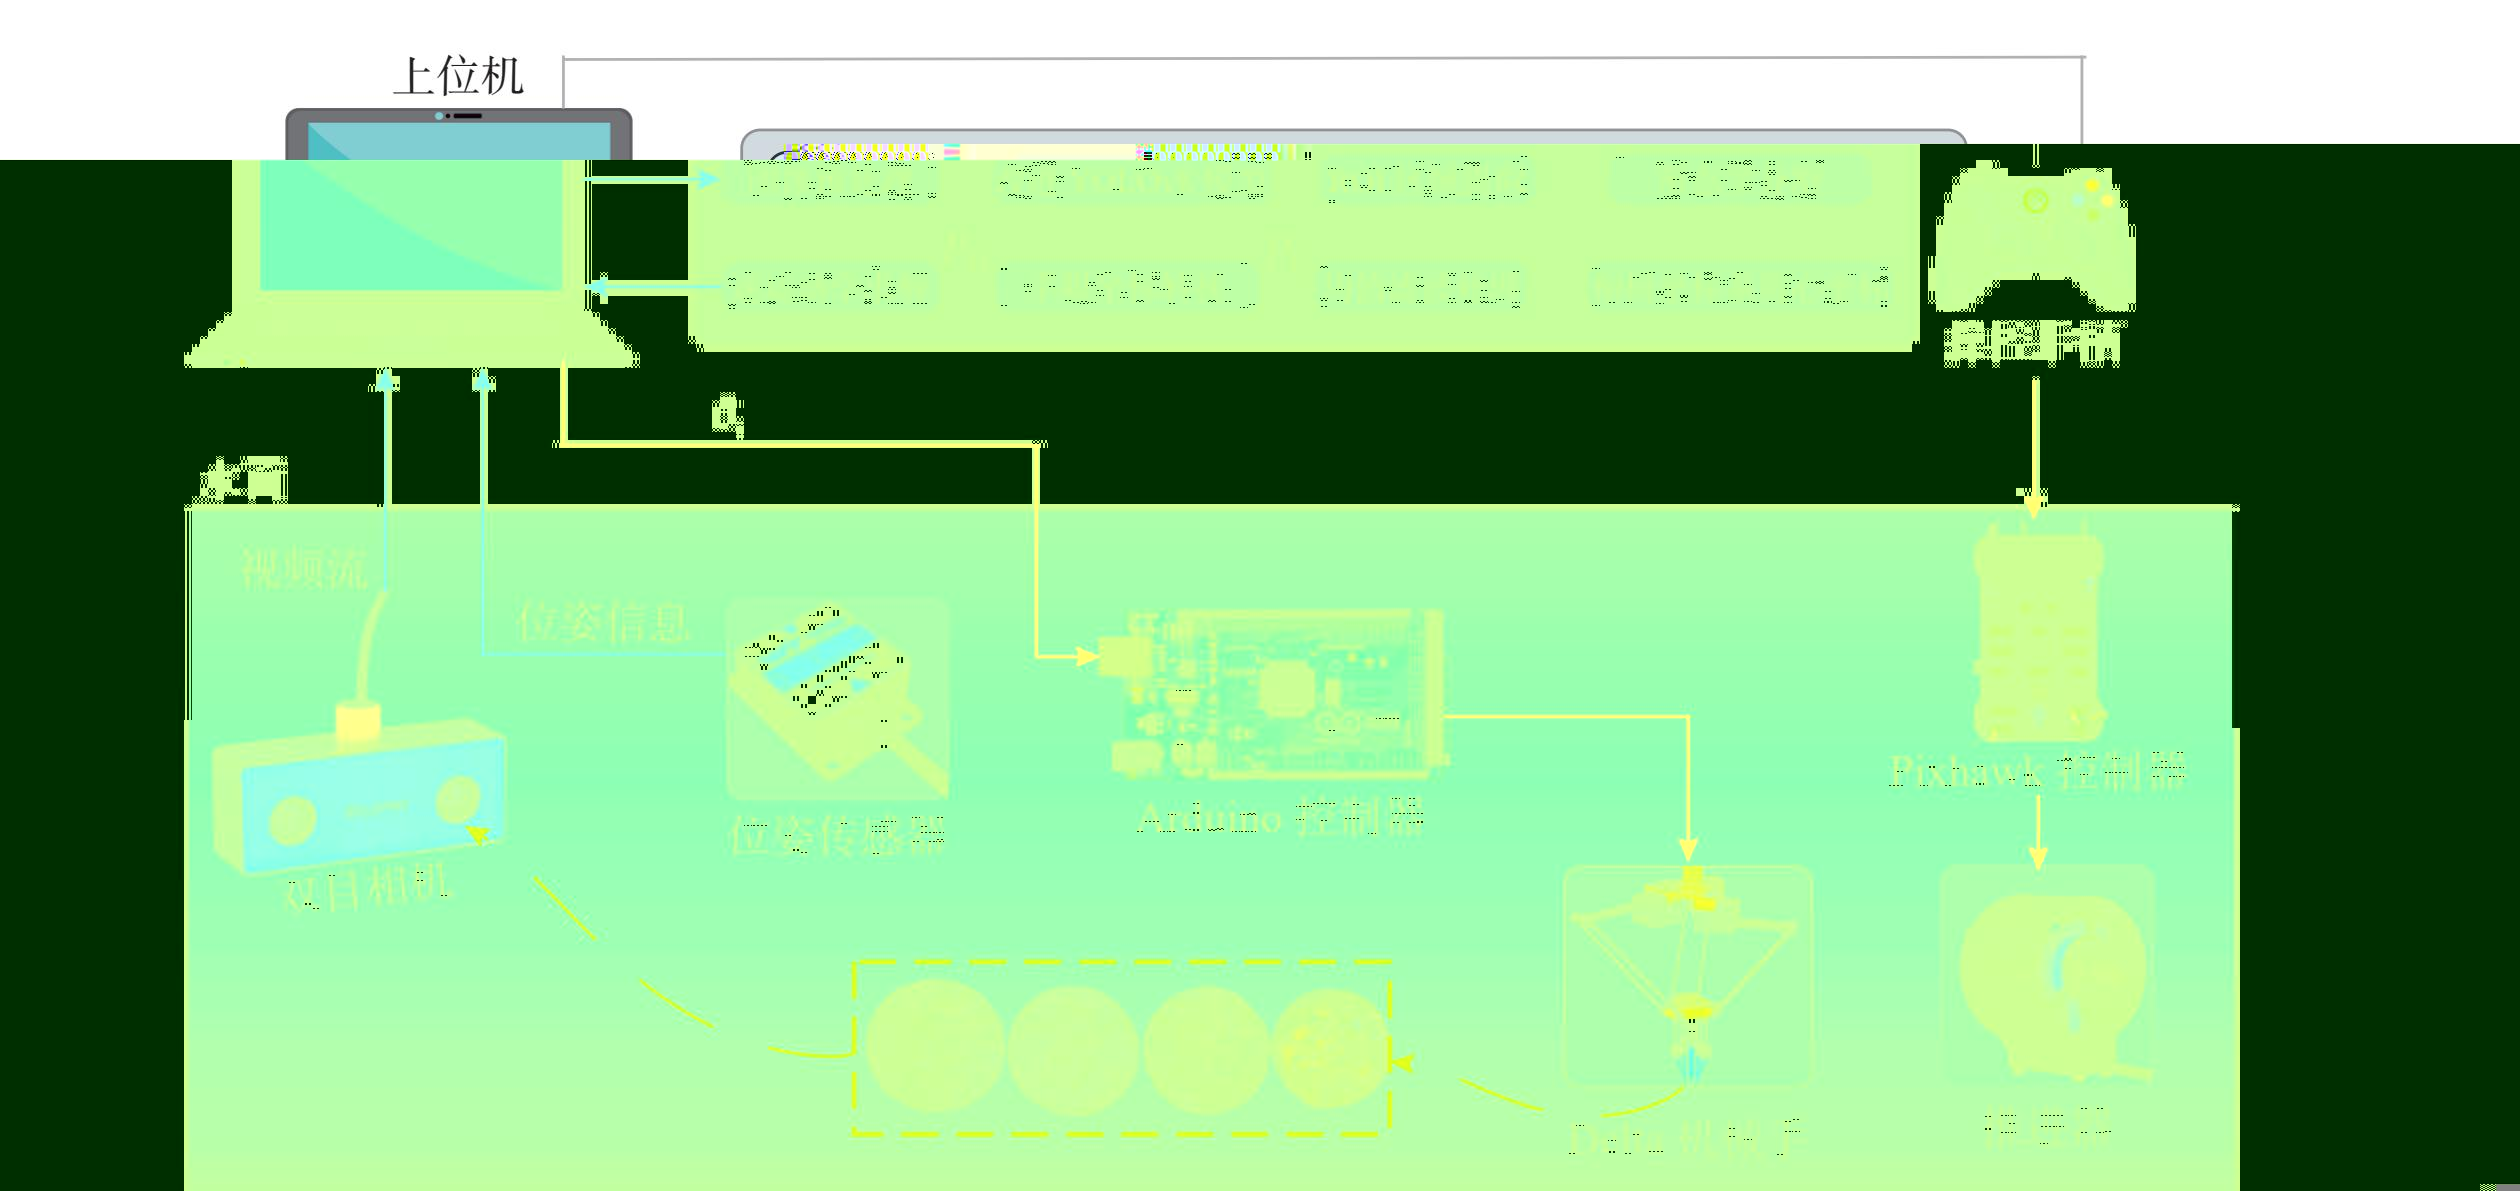
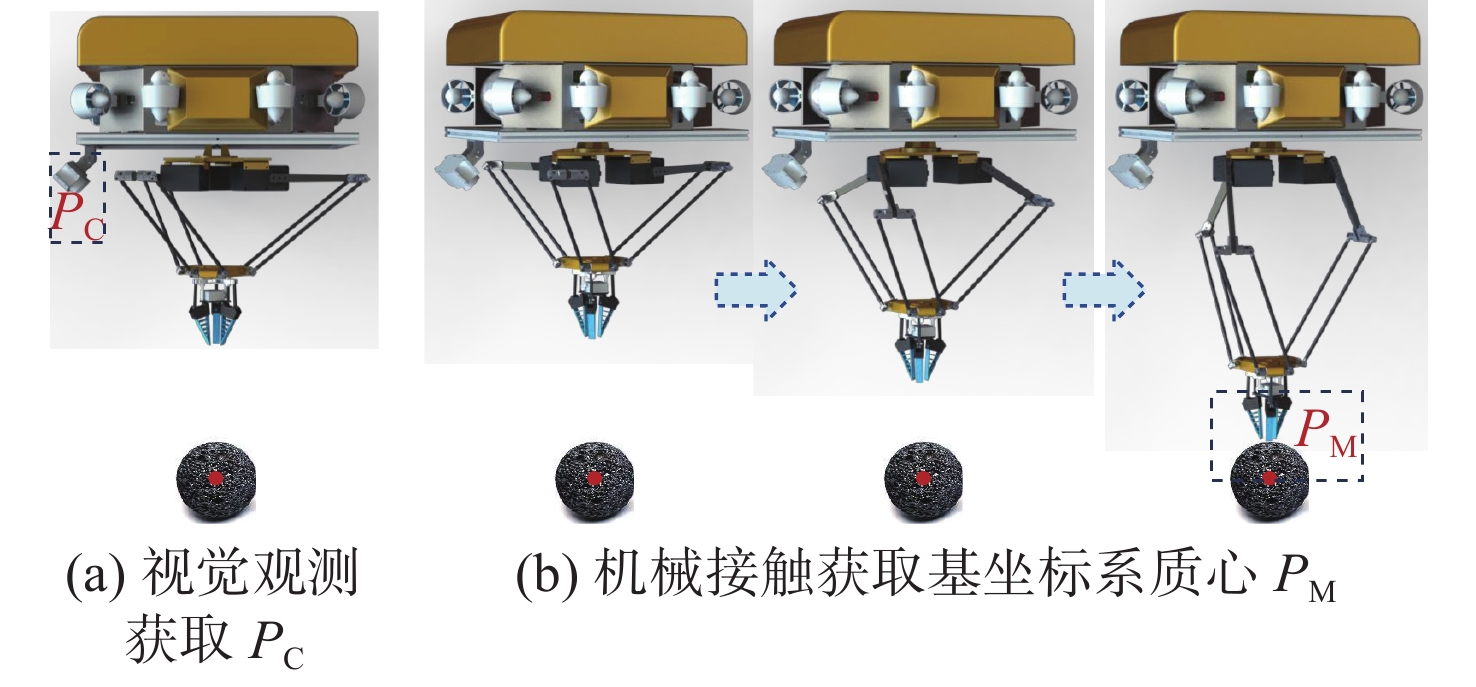
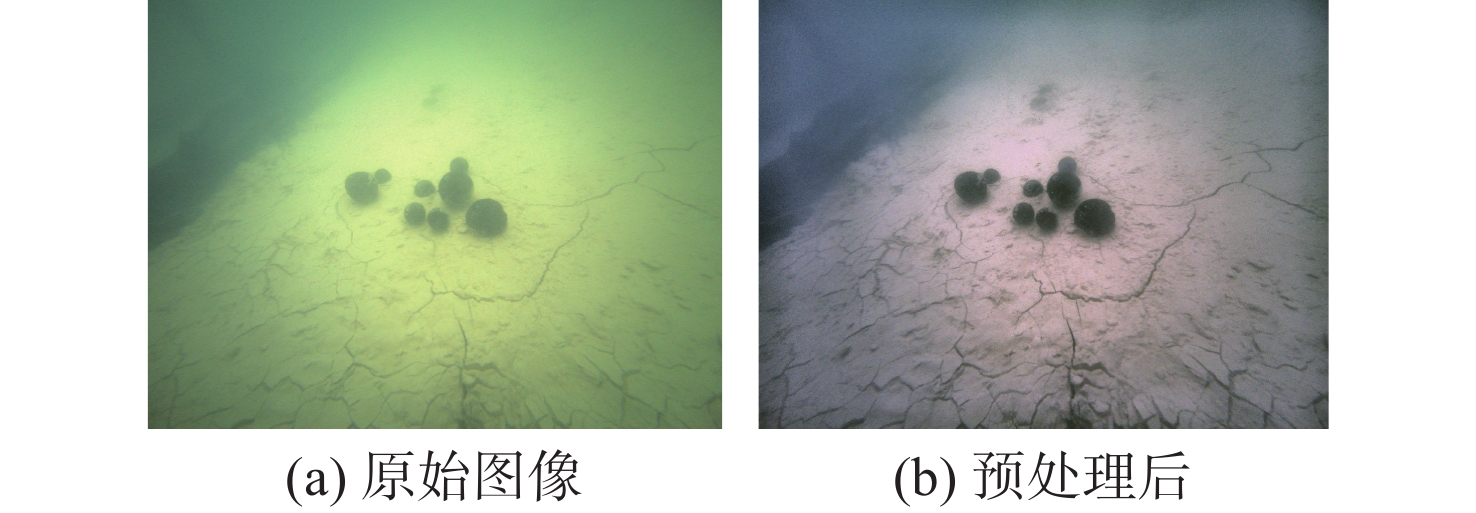
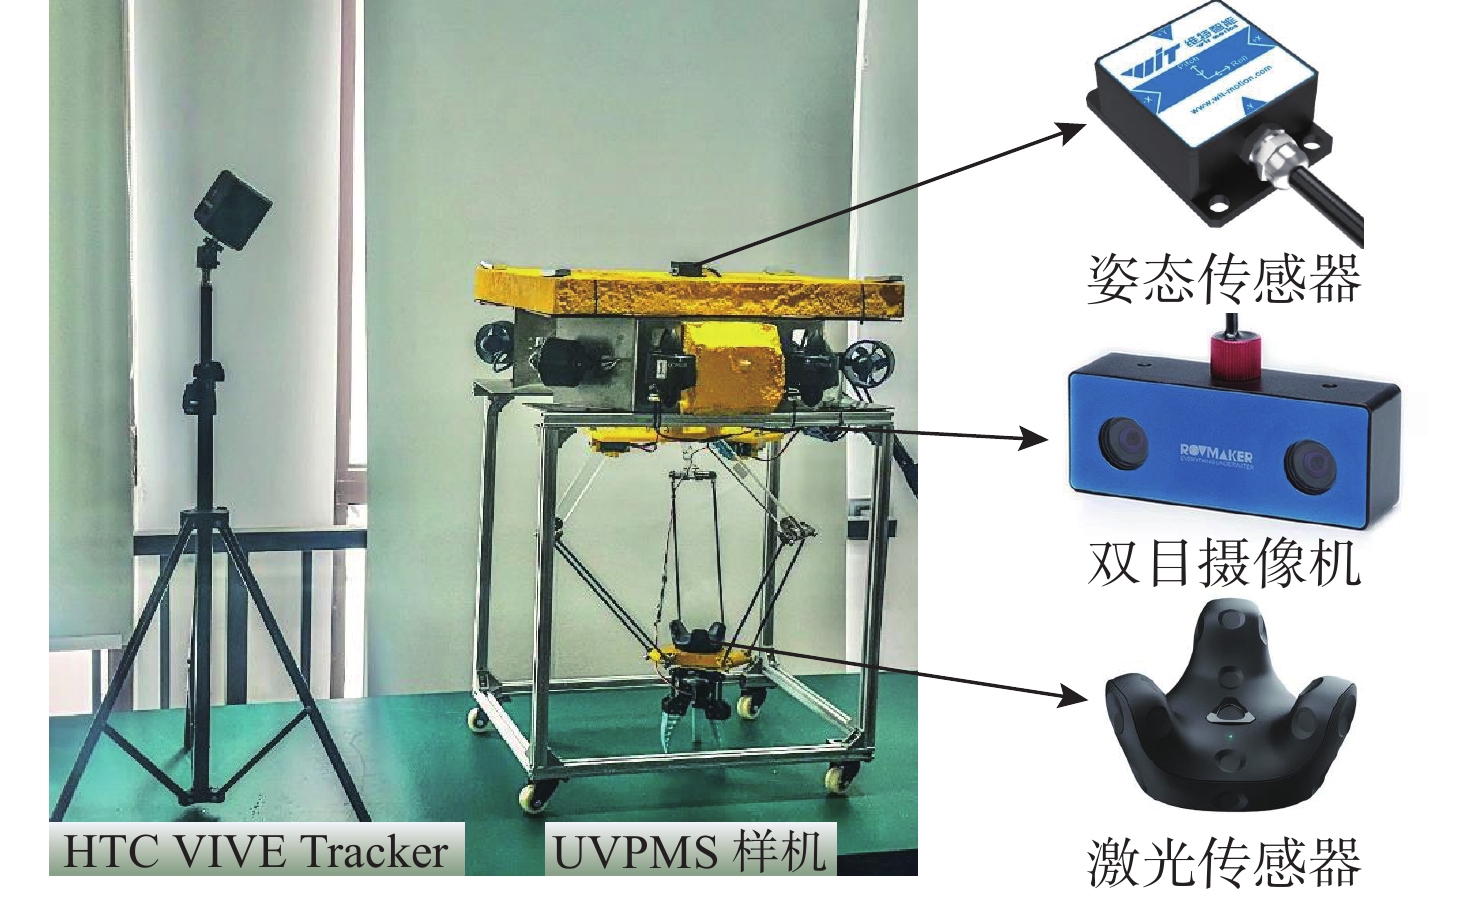
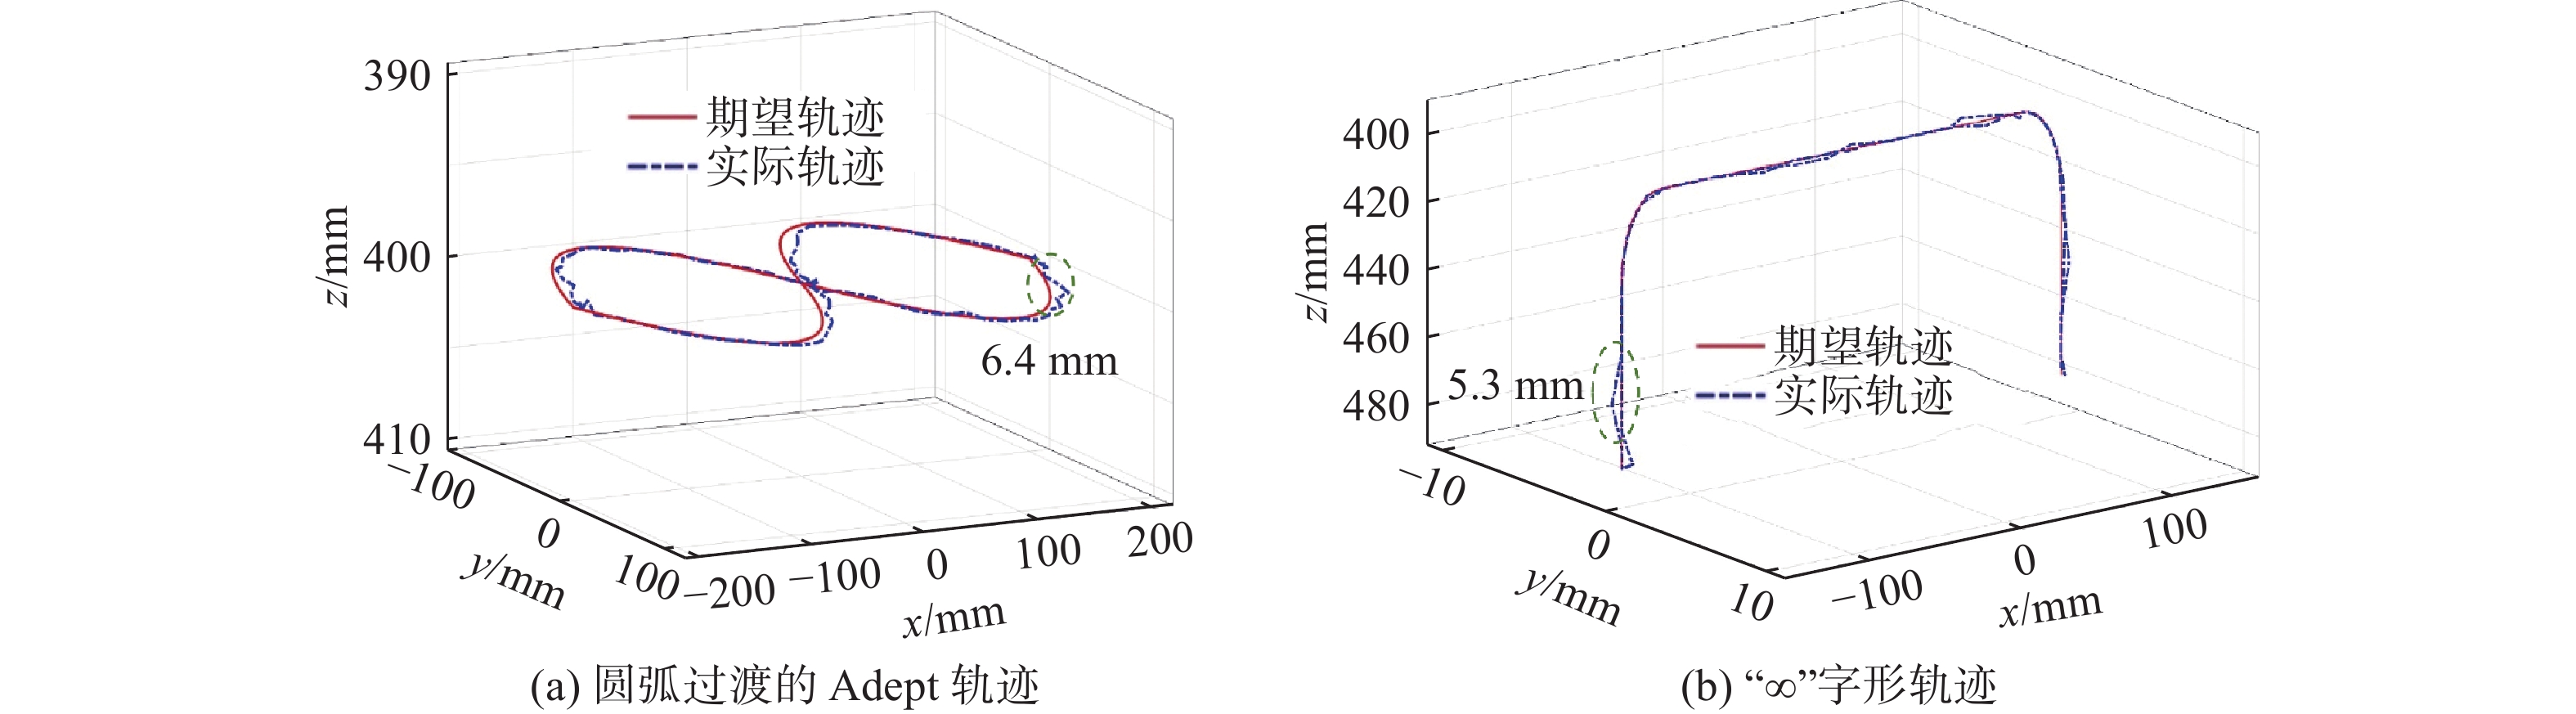
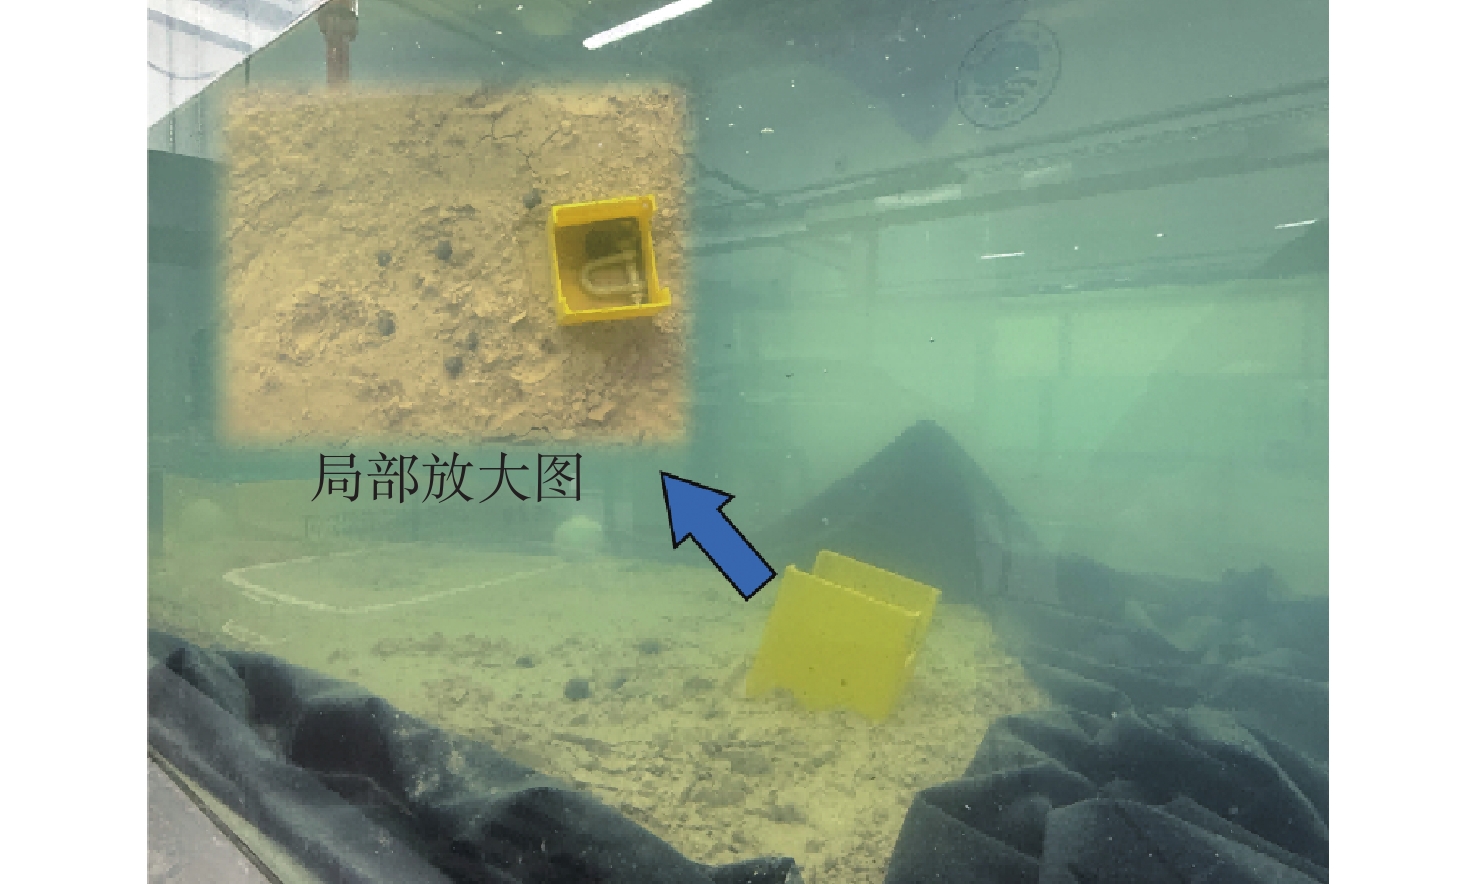
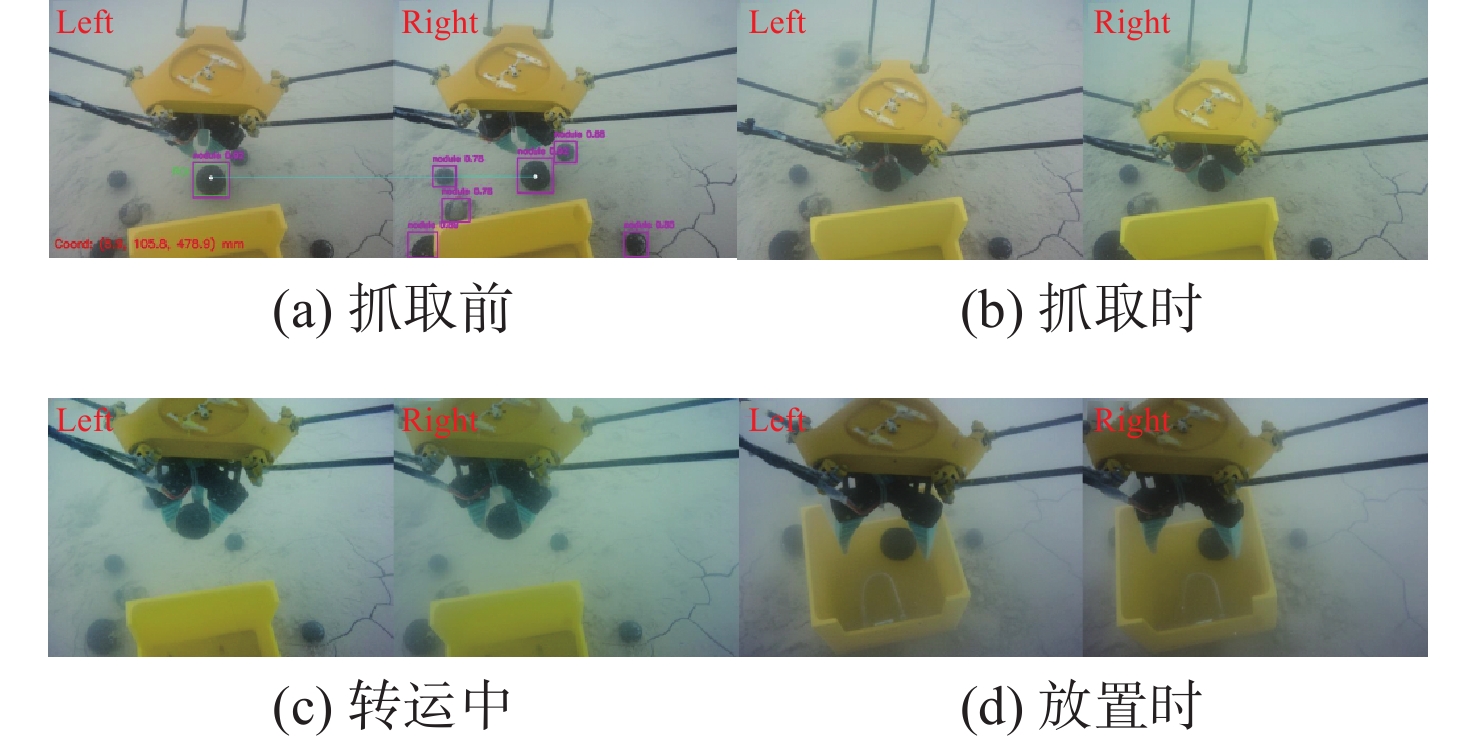
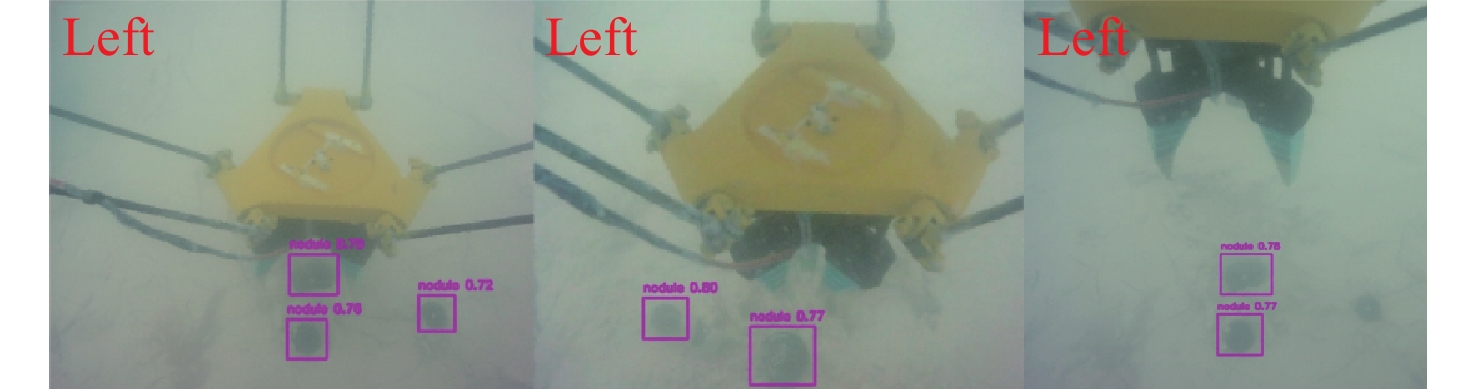
Aiming at the problems of seabed disturbance, sediment plume diffusion and limited trafficability in soft sediment environment caused by traditional crawler deep-sea mining equipment during operation, this paper proposes an underwater vehicle-parallel manipulator system (UVPMS) for visual-assisted grasping of polymetallic nodules. The system uses a frame-type suspension body, equipped with an under-mounted Delta parallel manipulator and integrated binocular vision perception to realize the identification, positioning and guided grasping of underwater metal nodules. Aiming at the system, the overall scheme design, Delta mechanism kinematics analysis and multi-body coupling dynamics modeling analysis are carried out in this paper. The execution process of image preprocessing, improved YOLOv8 recognition, binocular matching based on epipolar constraint, centroid extraction of target area and visual guided grasping is constructed. In the land trajectory tracking experiment, the maximum spatial tracking errors of the Delta parallel manipulator executing the Adept trajectory and the '∞'-shaped trajectory are 5.3 mm and 6.4 mm, respectively. The Precision, Recall and mAP @ 0.5 of the improved YOLOv8 model reached 96.0%, 94.6% and 96.5%, respectively. Under the condition of fixed body, the average absolute ranging error of binocular vision is about 9 mm, and the comprehensive error of end positioning after hand-eye transformation is 11 mm. A total of 55 continuous grasping tests were carried out in the grasping experiment of underwater polymetallic nodule simulant. Under the conditions of sediment disturbance and suspended particle interference, the success rate of grasping was 67.3%, and the comprehensive error of underwater grasping was about 15 mm. The results show that the proposed suspended UVPMS can complete the identification, positioning and low-disturbance visual-assisted grasping of polymetallic nodule simulants in a simulated deep-sea disturbance environment.
Bayesian Space-Time Adaptive Target Detector in Reverberation Edge Environments
MENG Dehao, WANG Tianqi, YIN Chaoran, XU Da, LIU Minggang
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0094
Abstract:
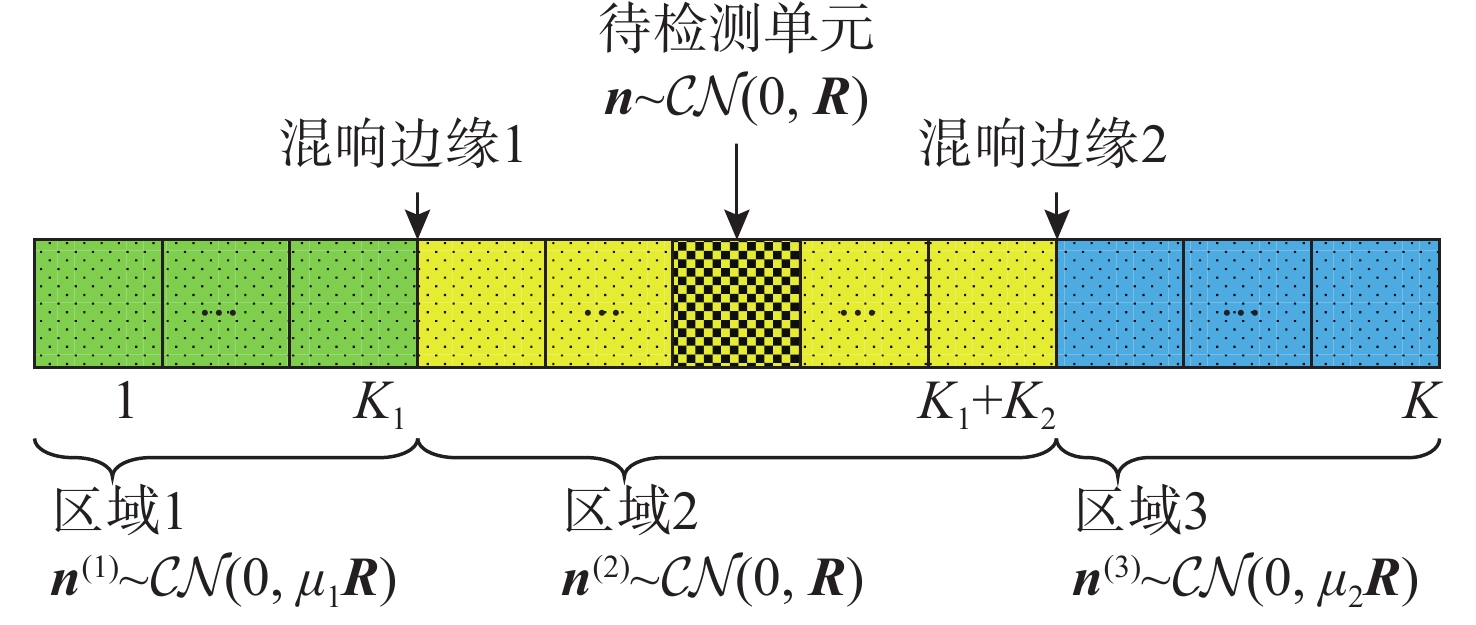
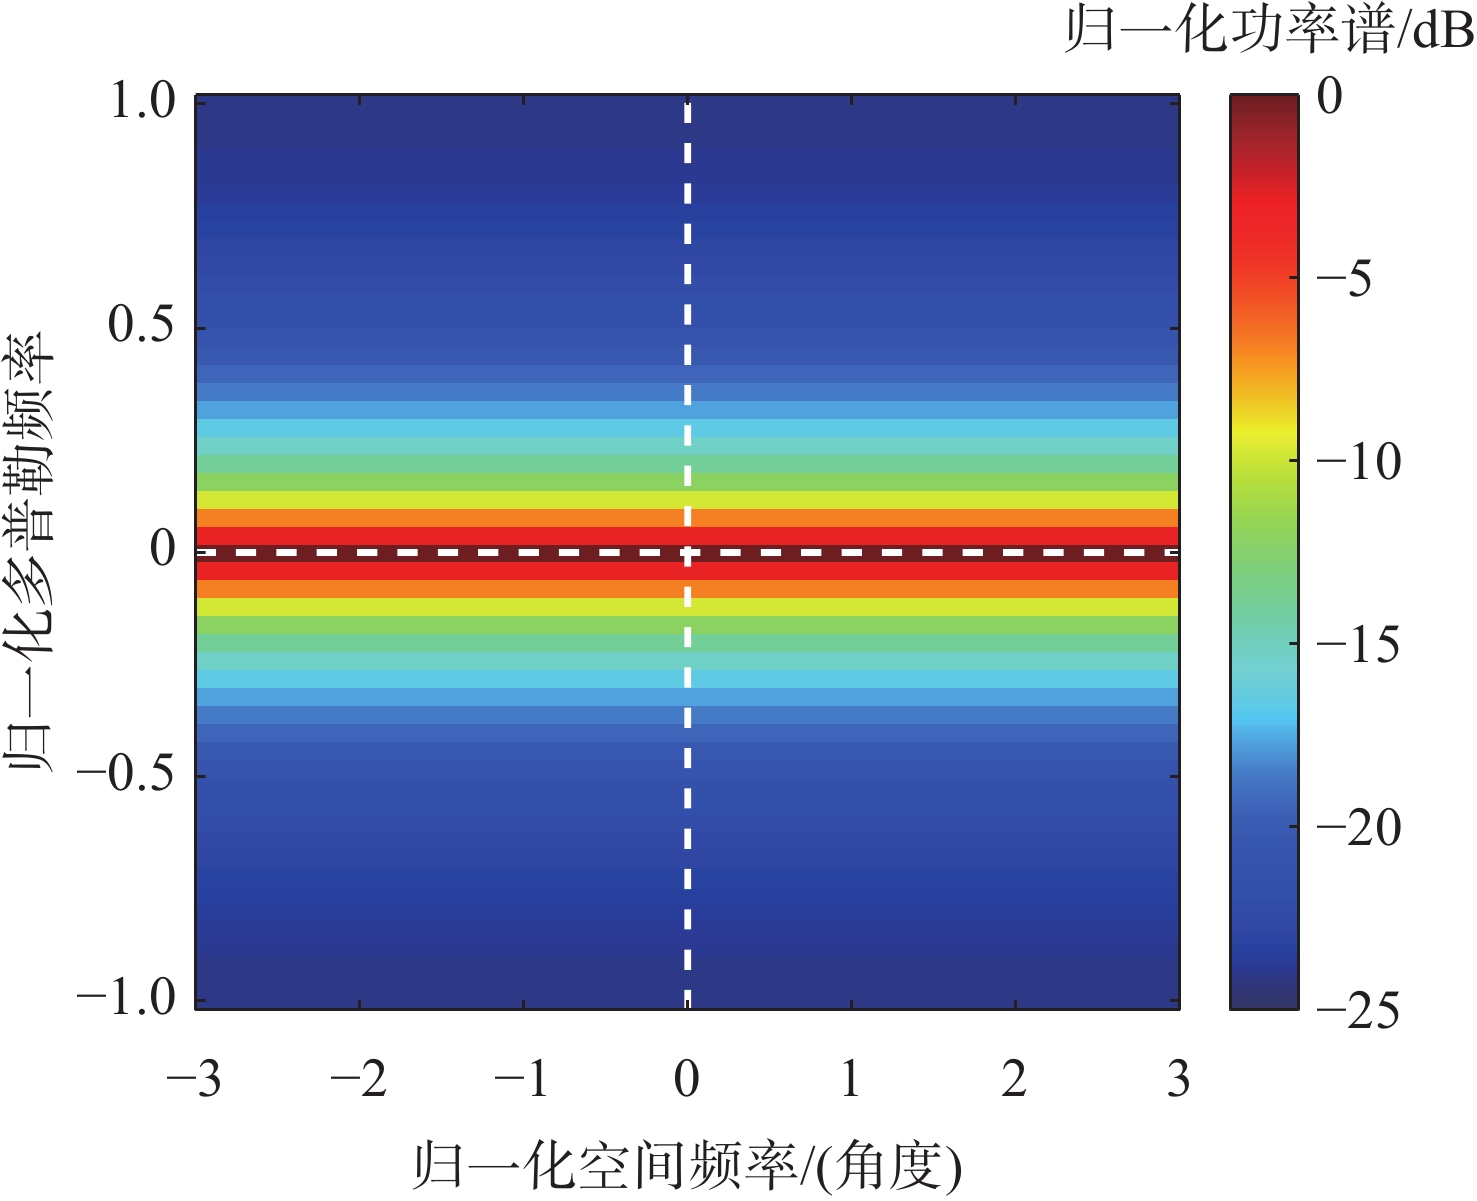
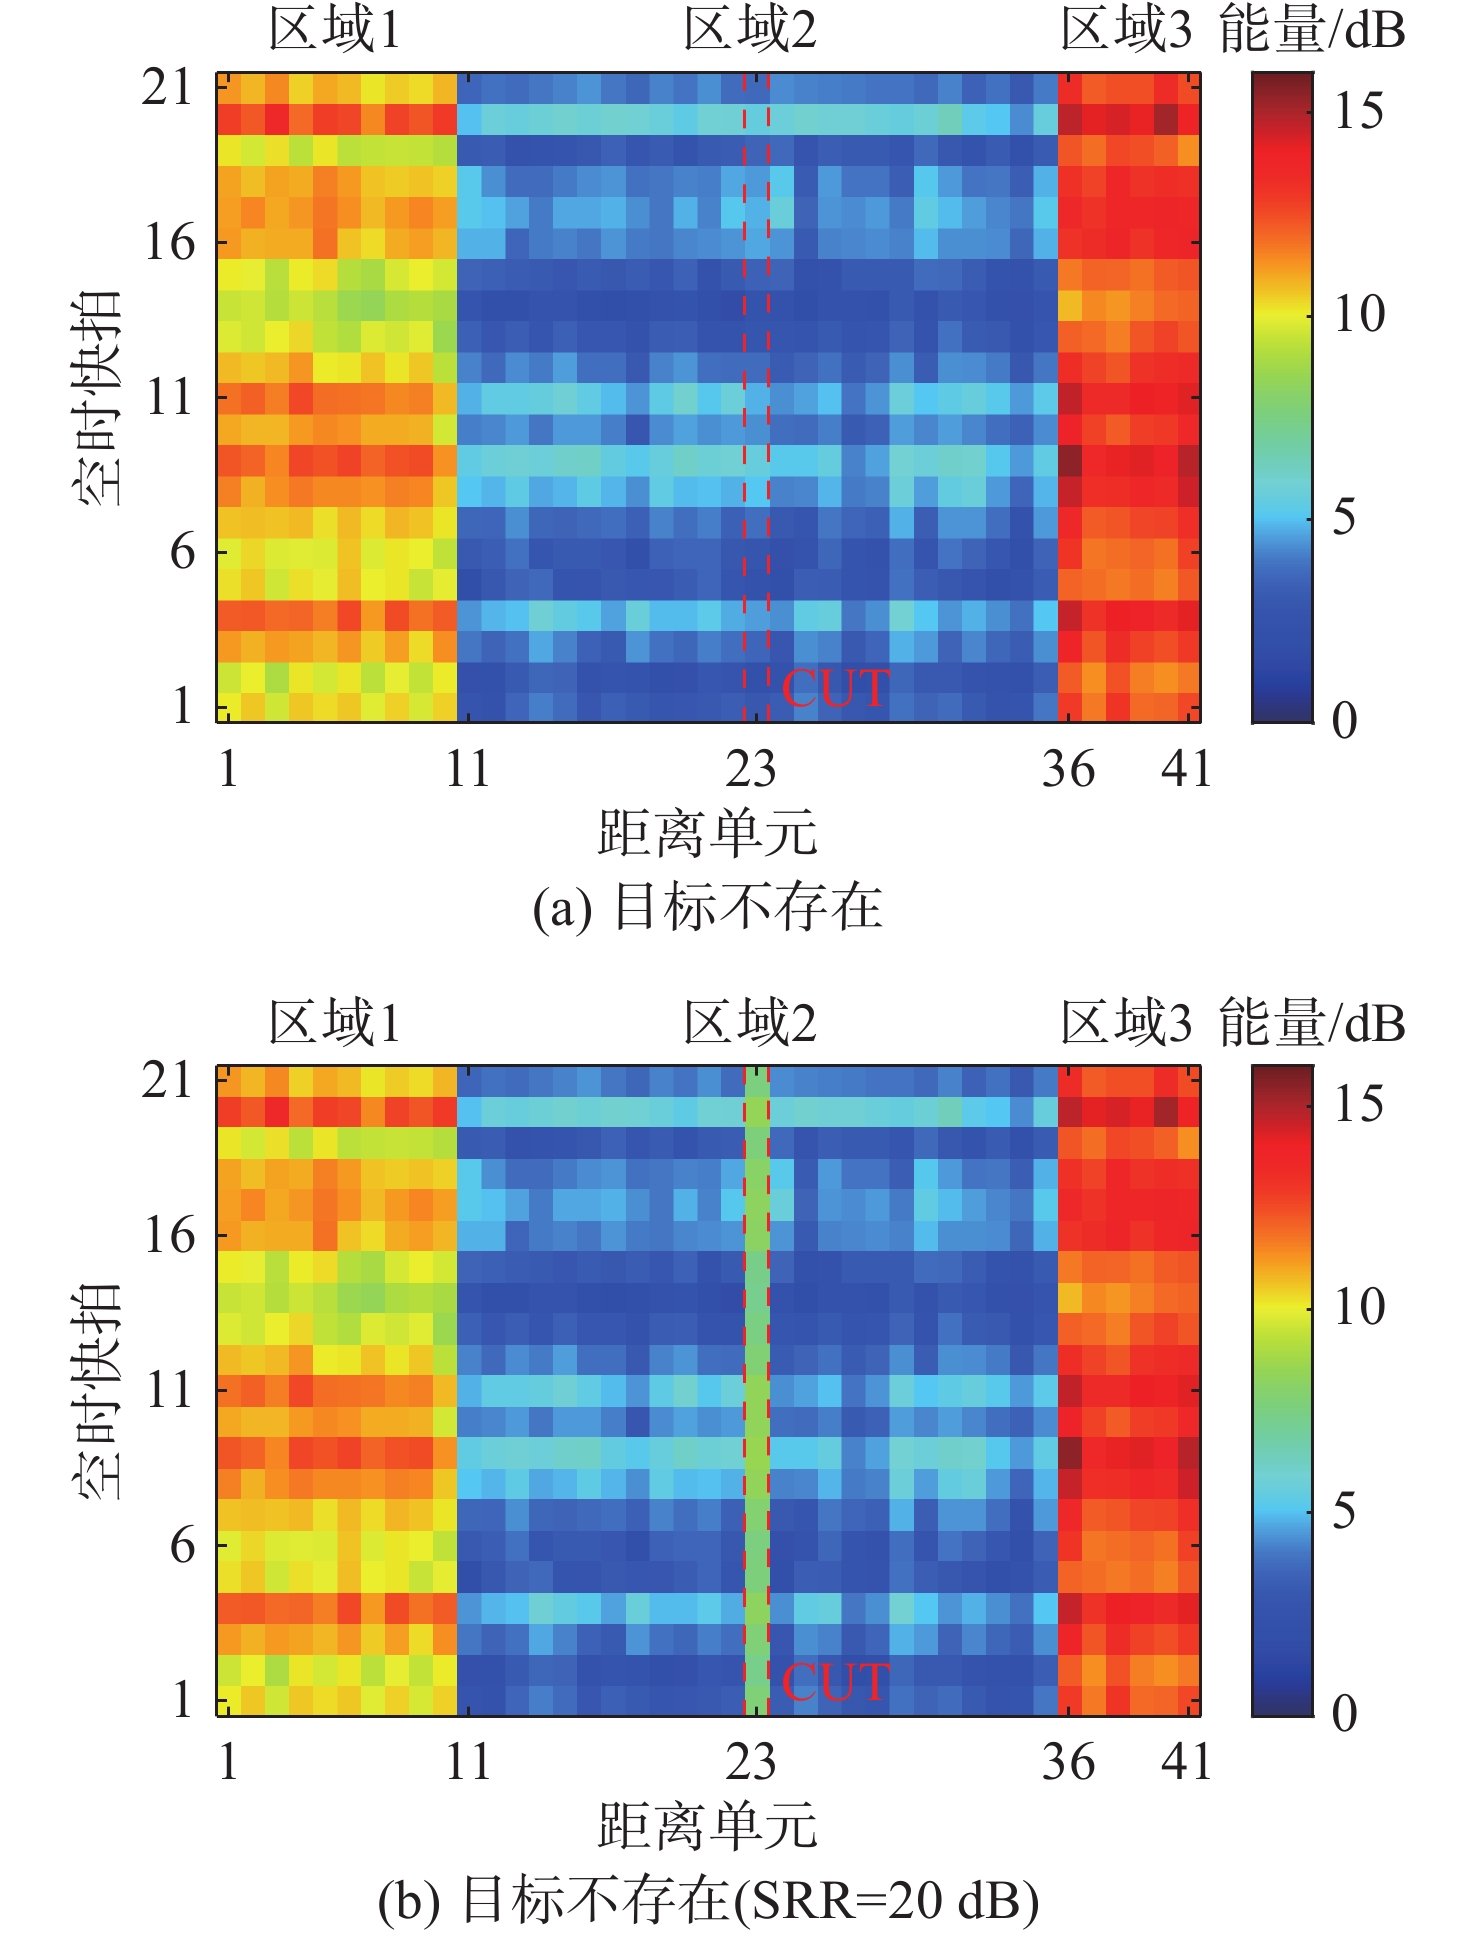
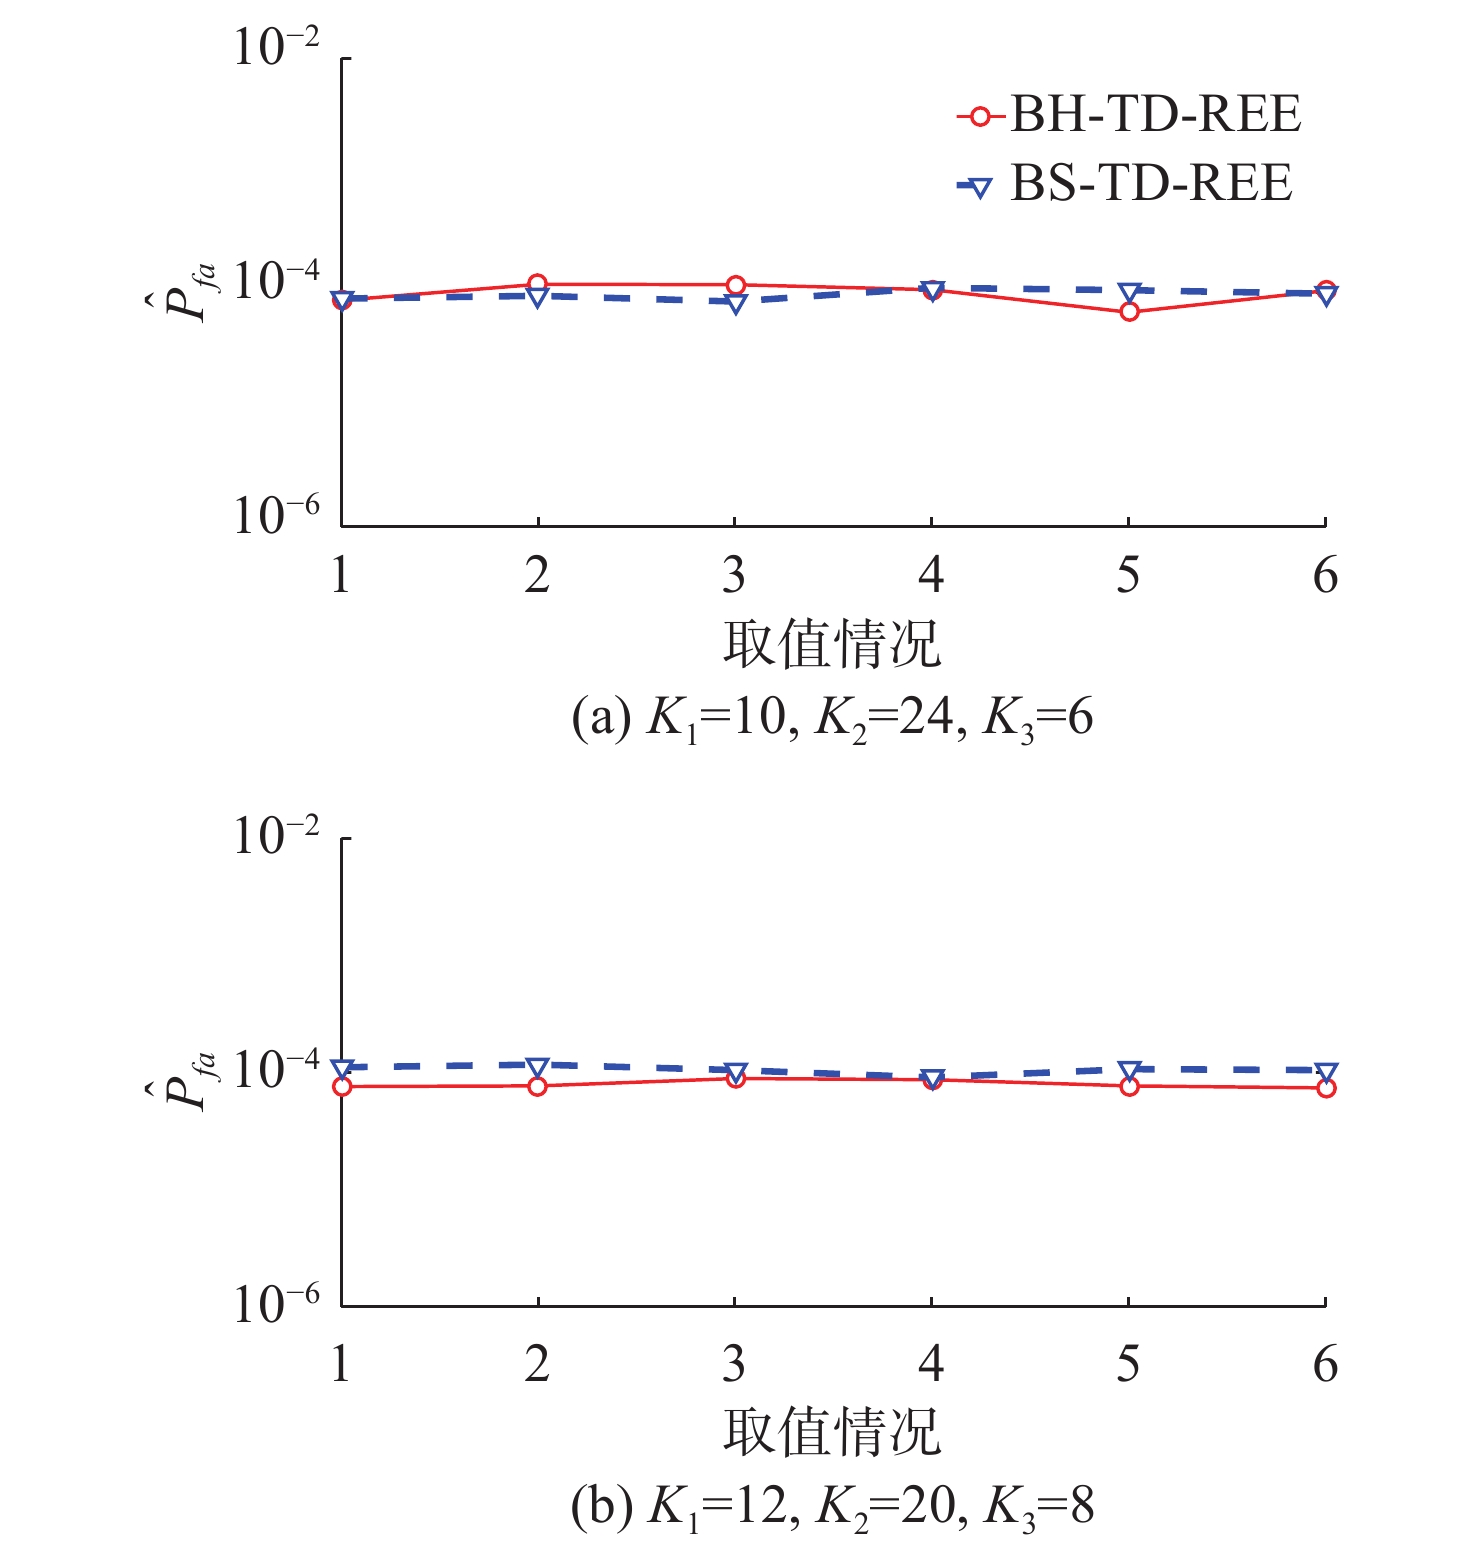
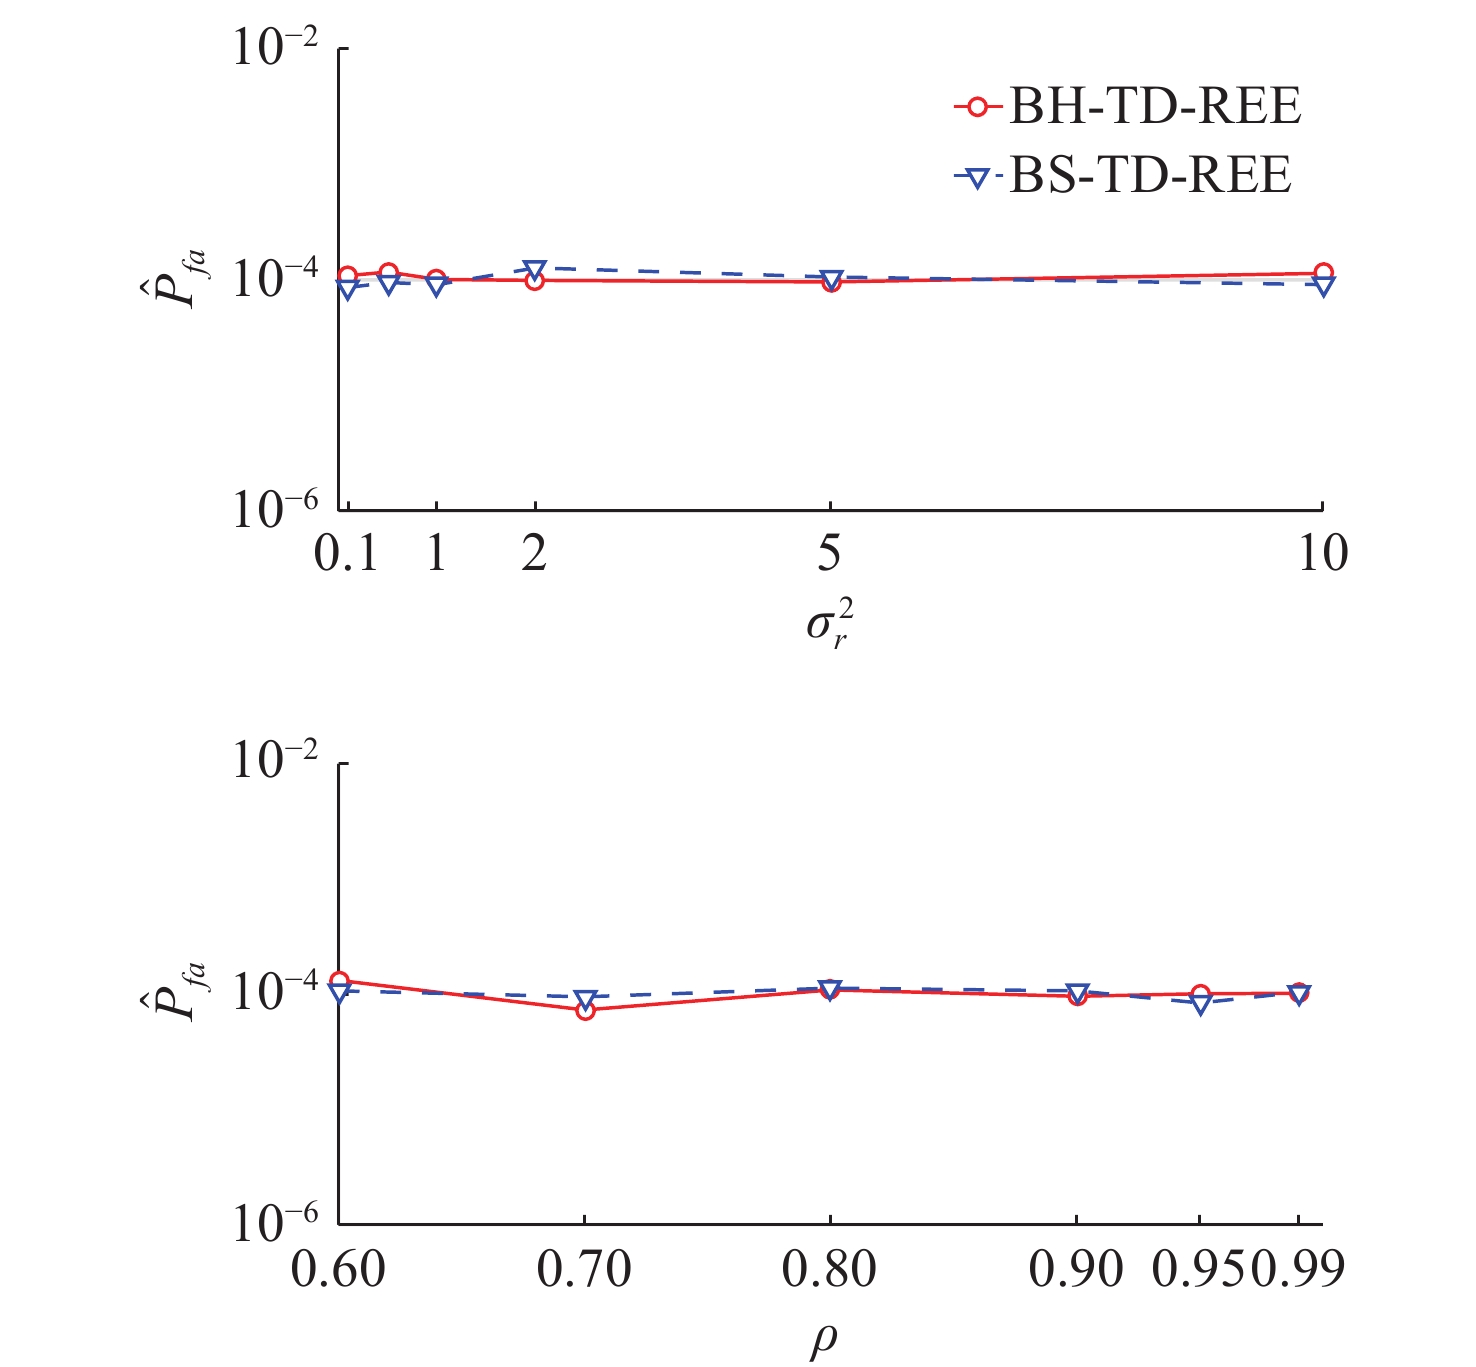
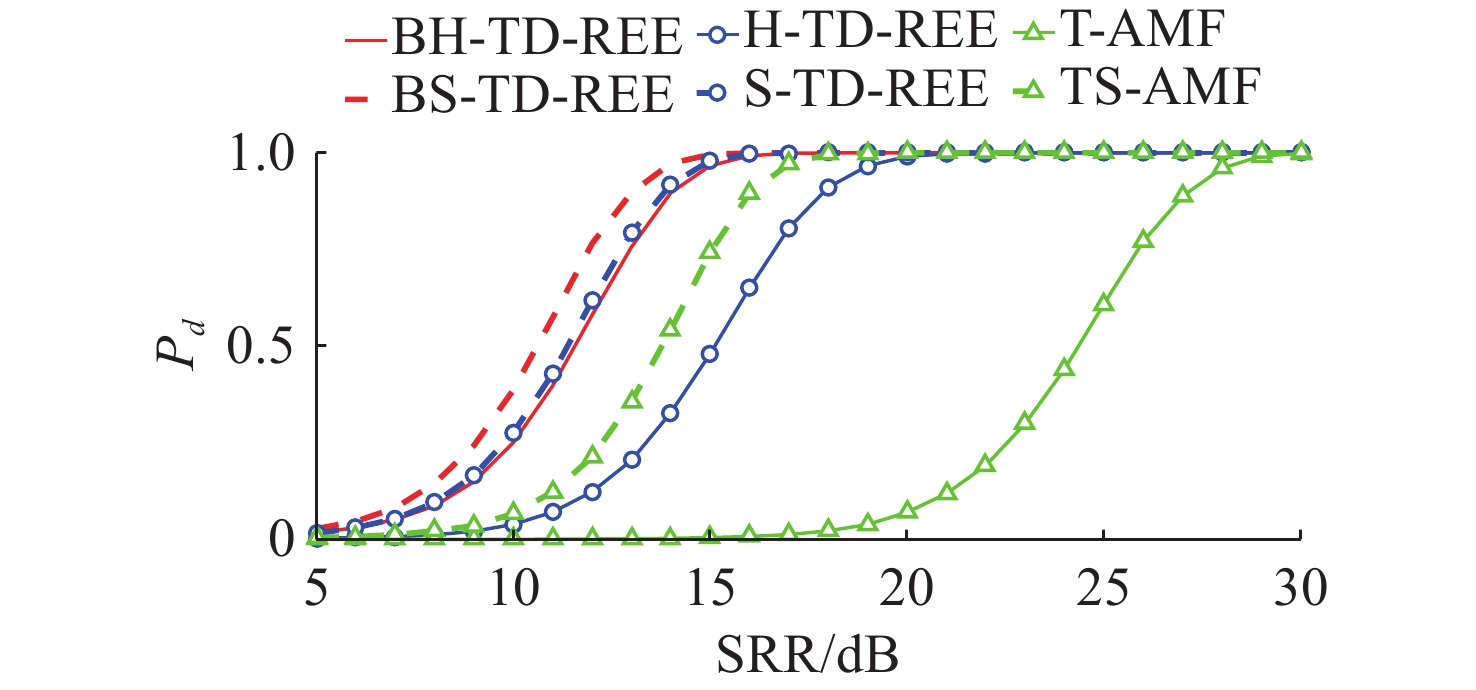
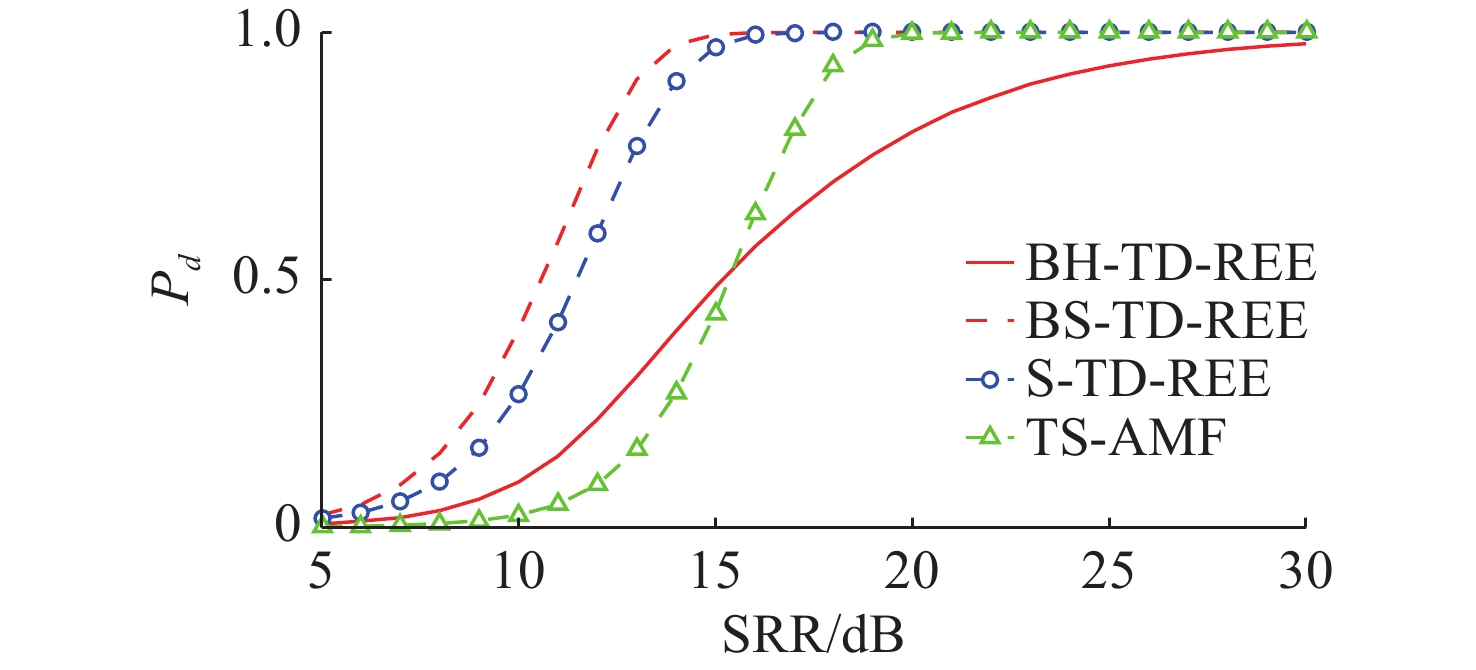
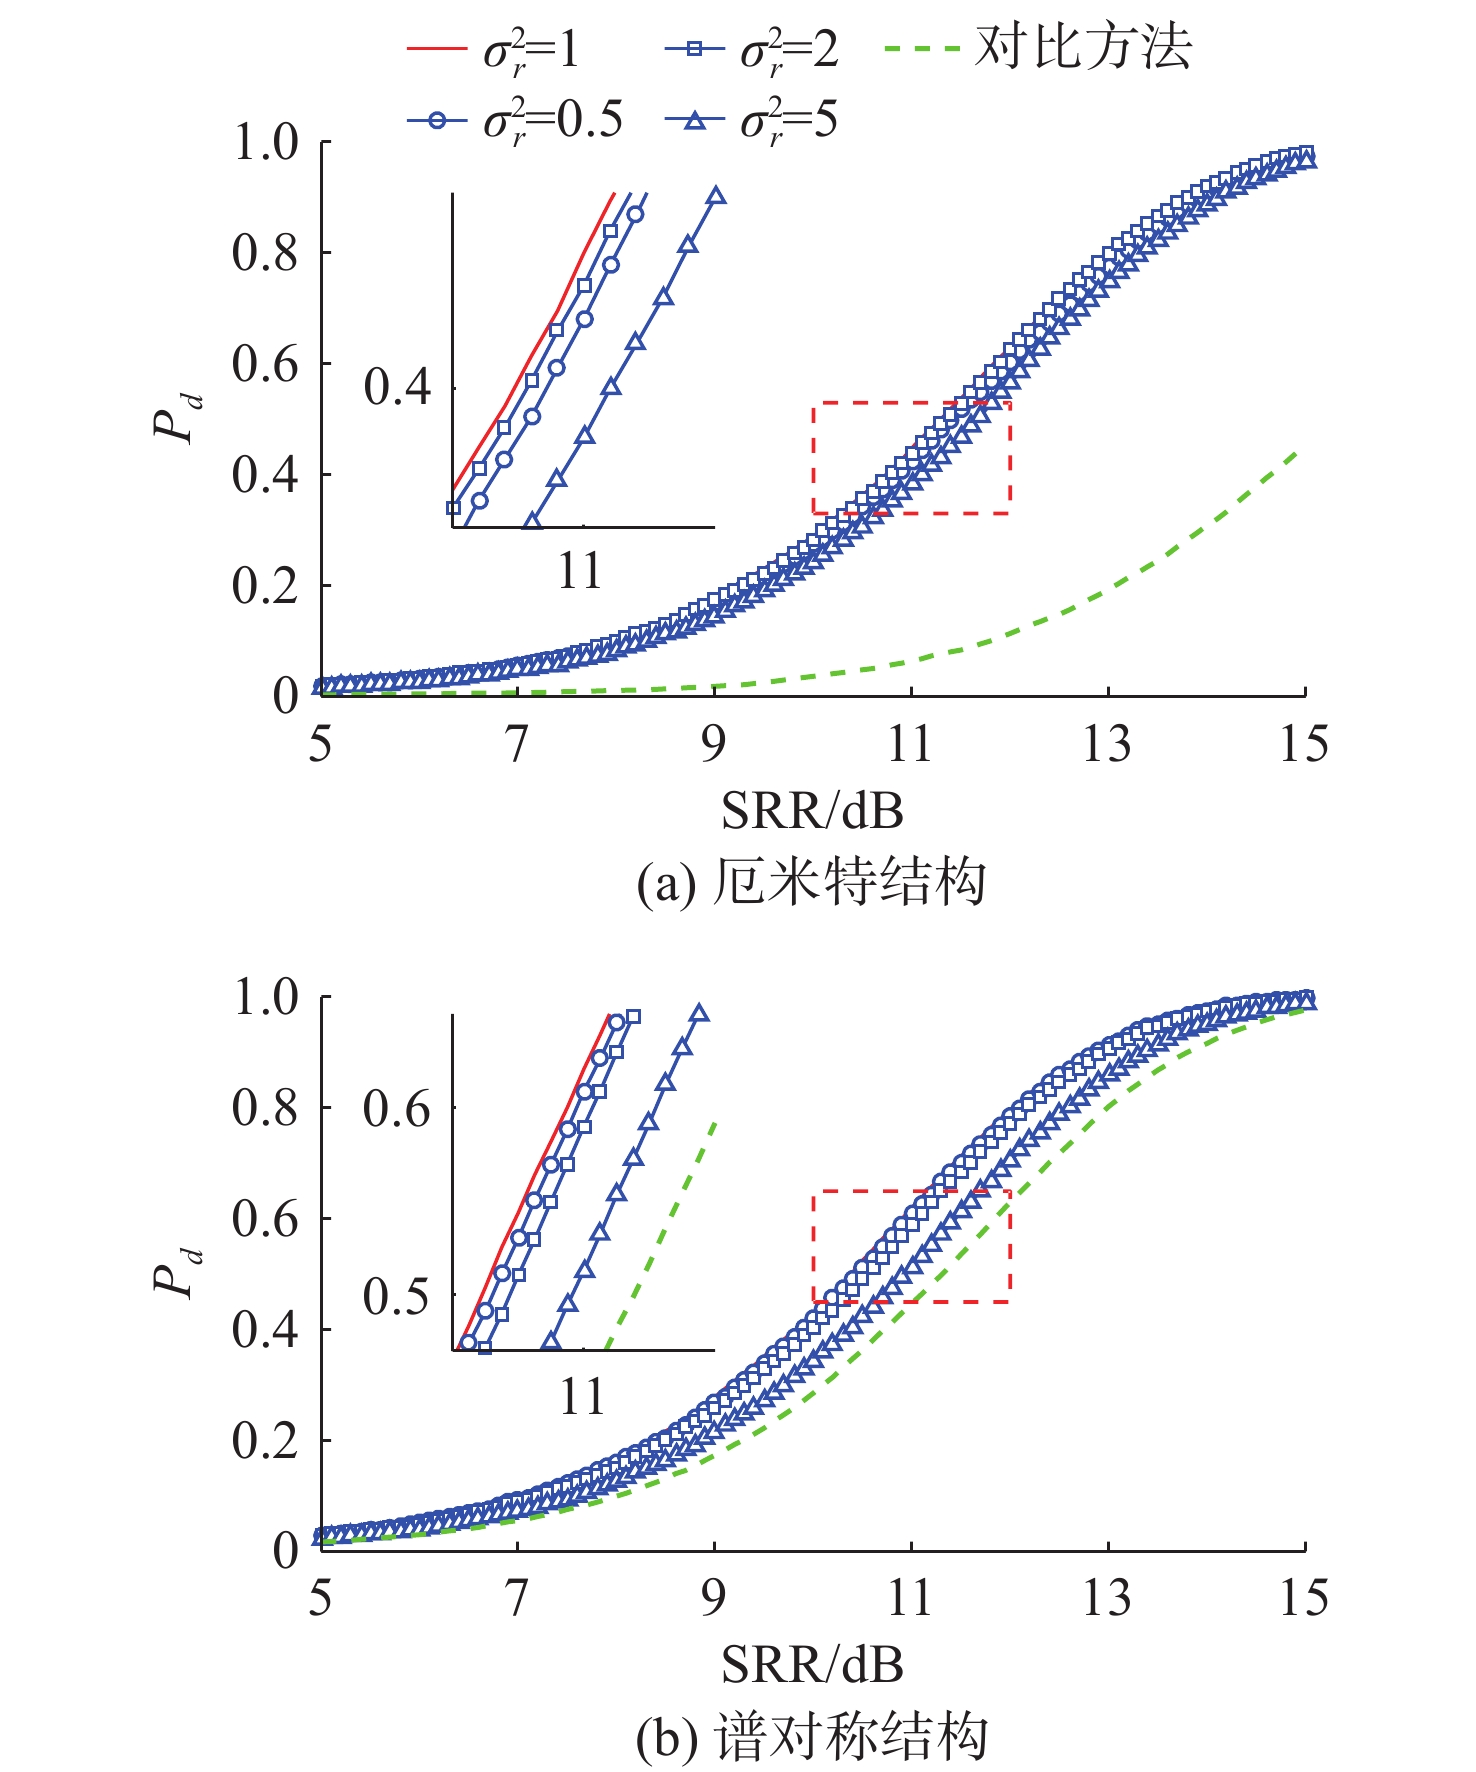
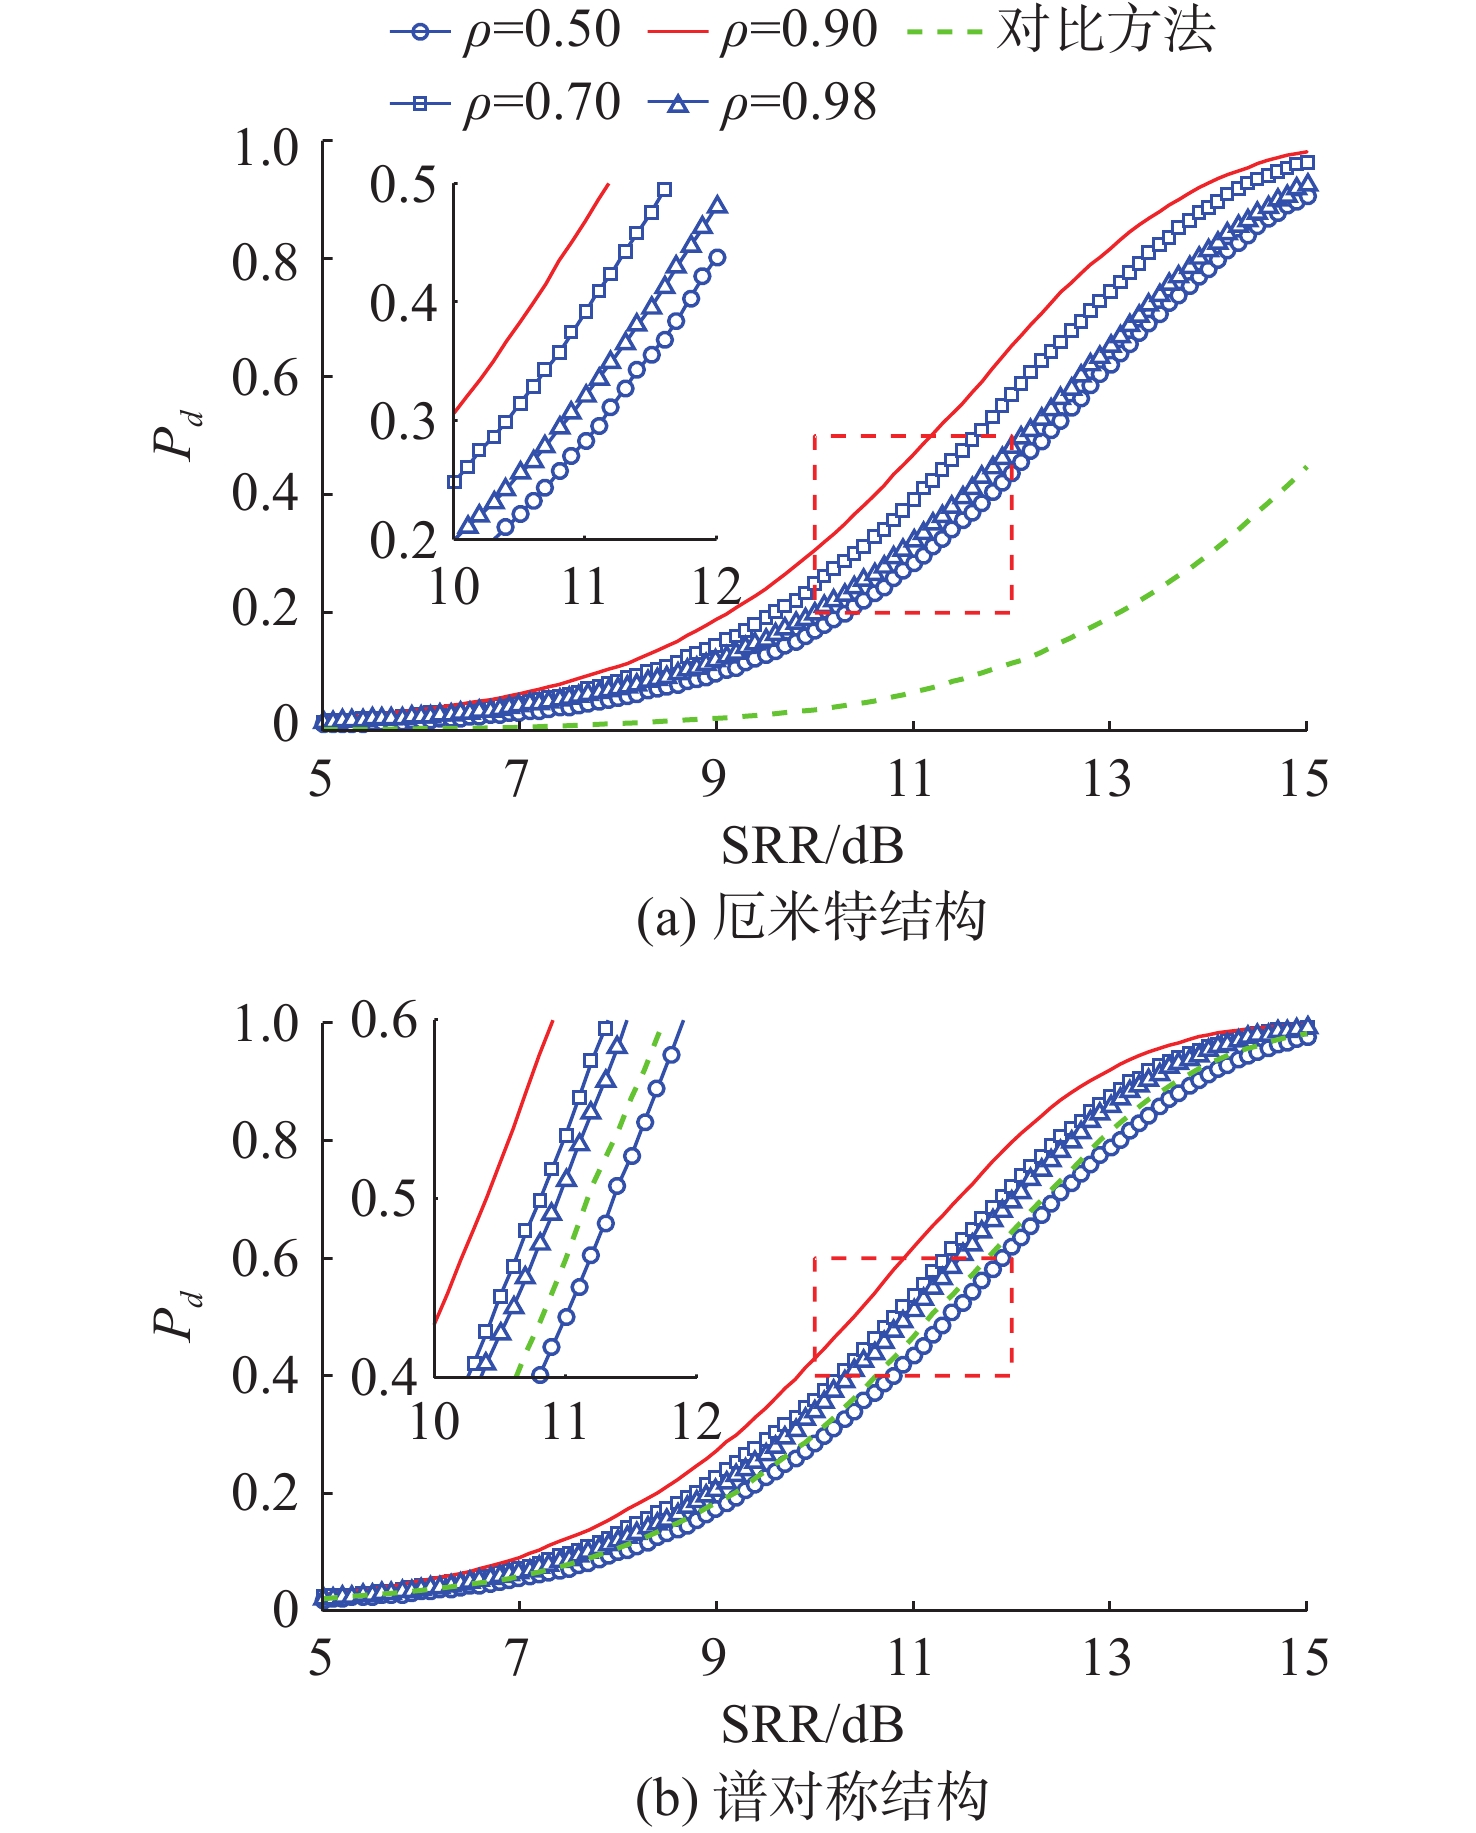
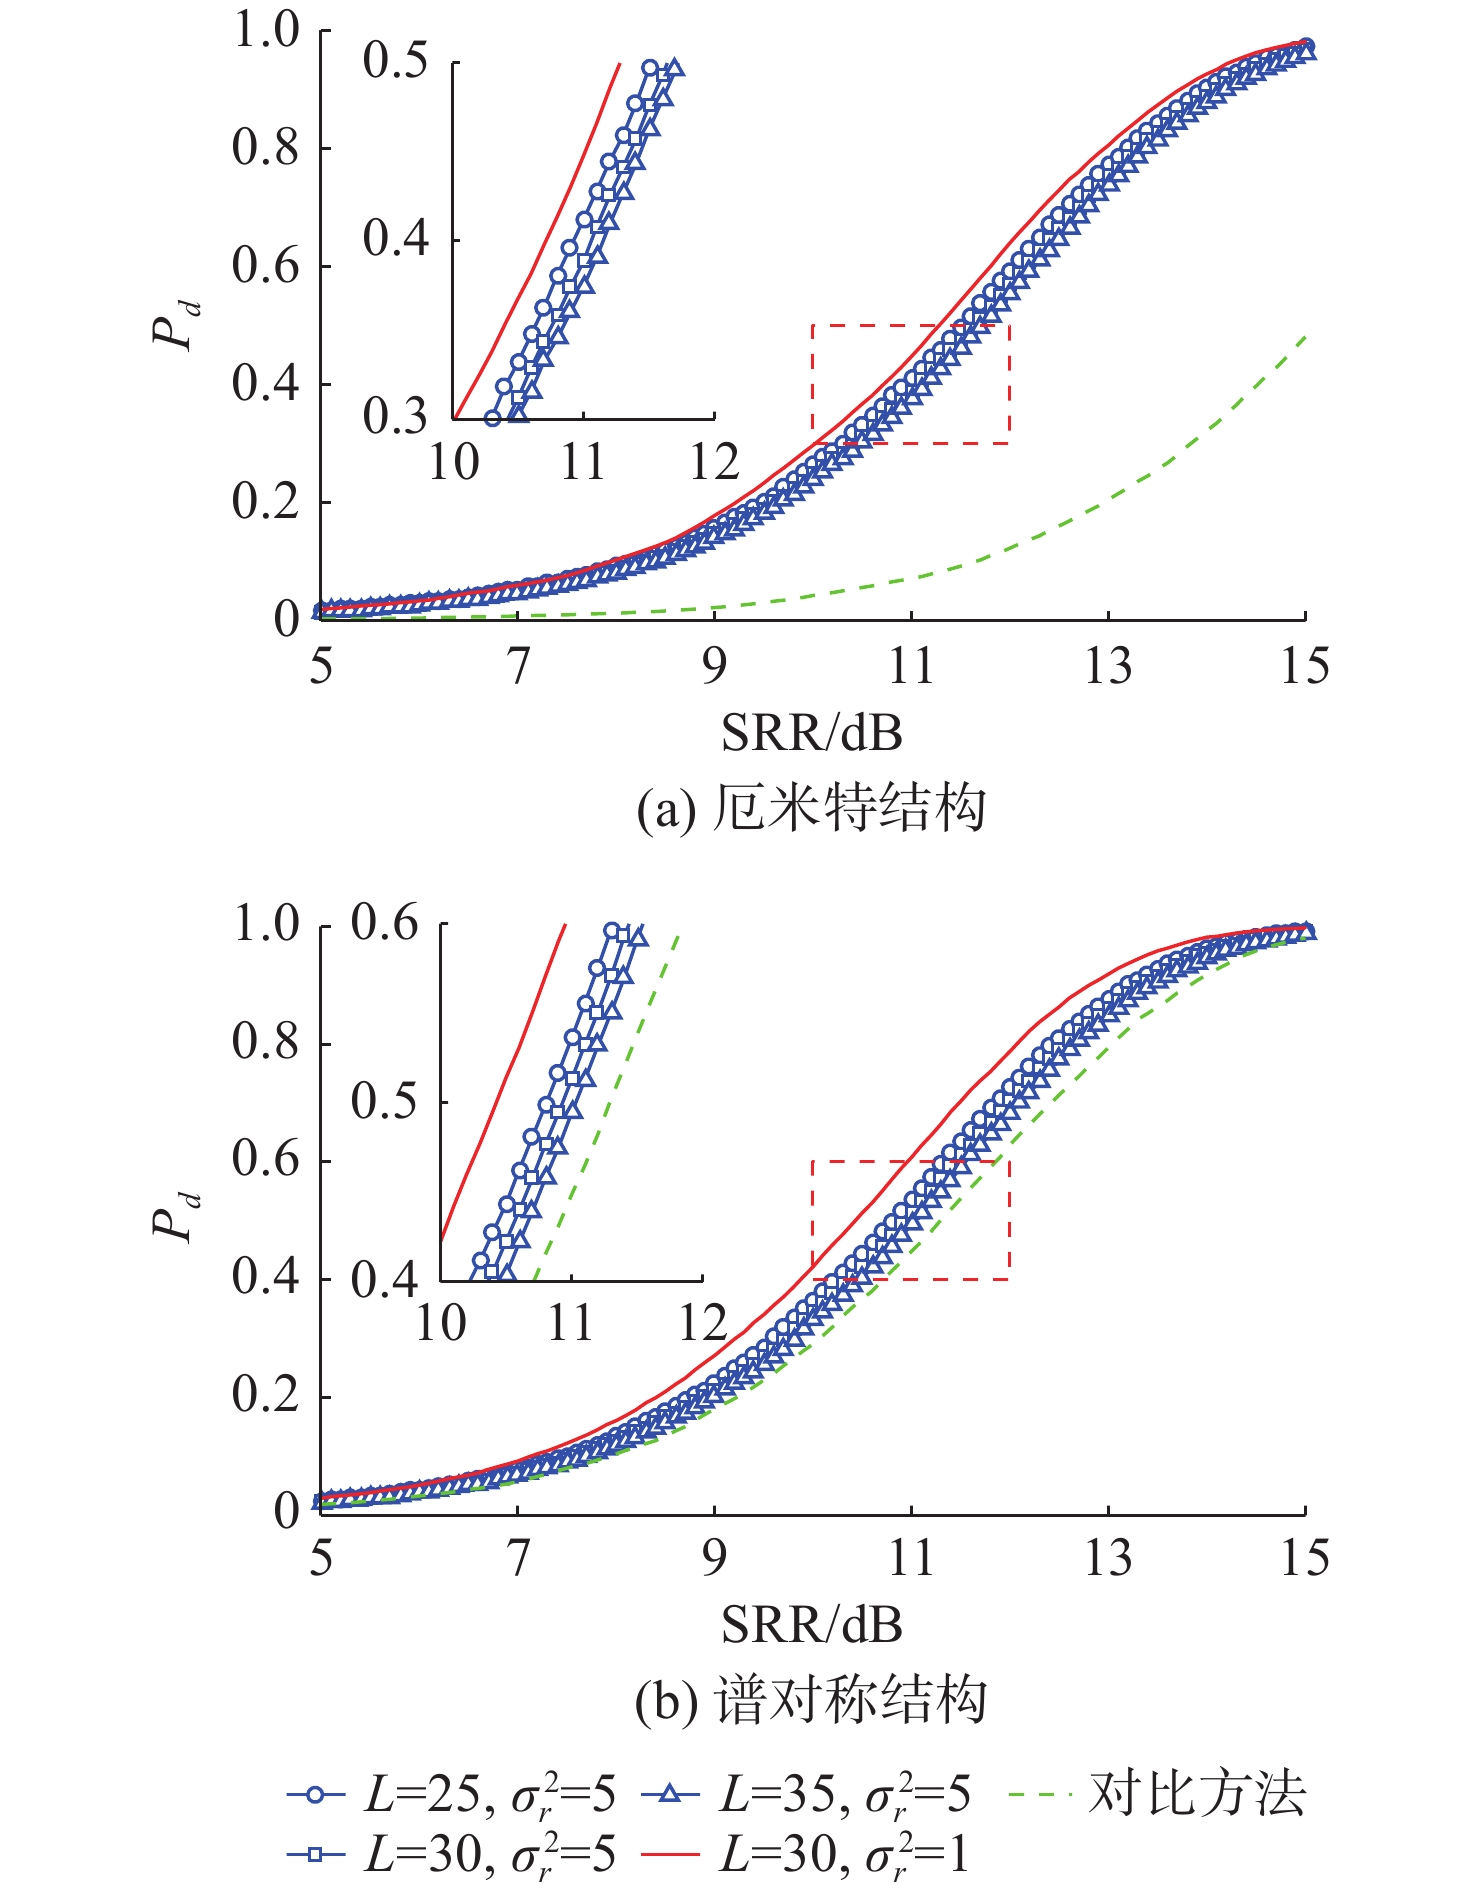
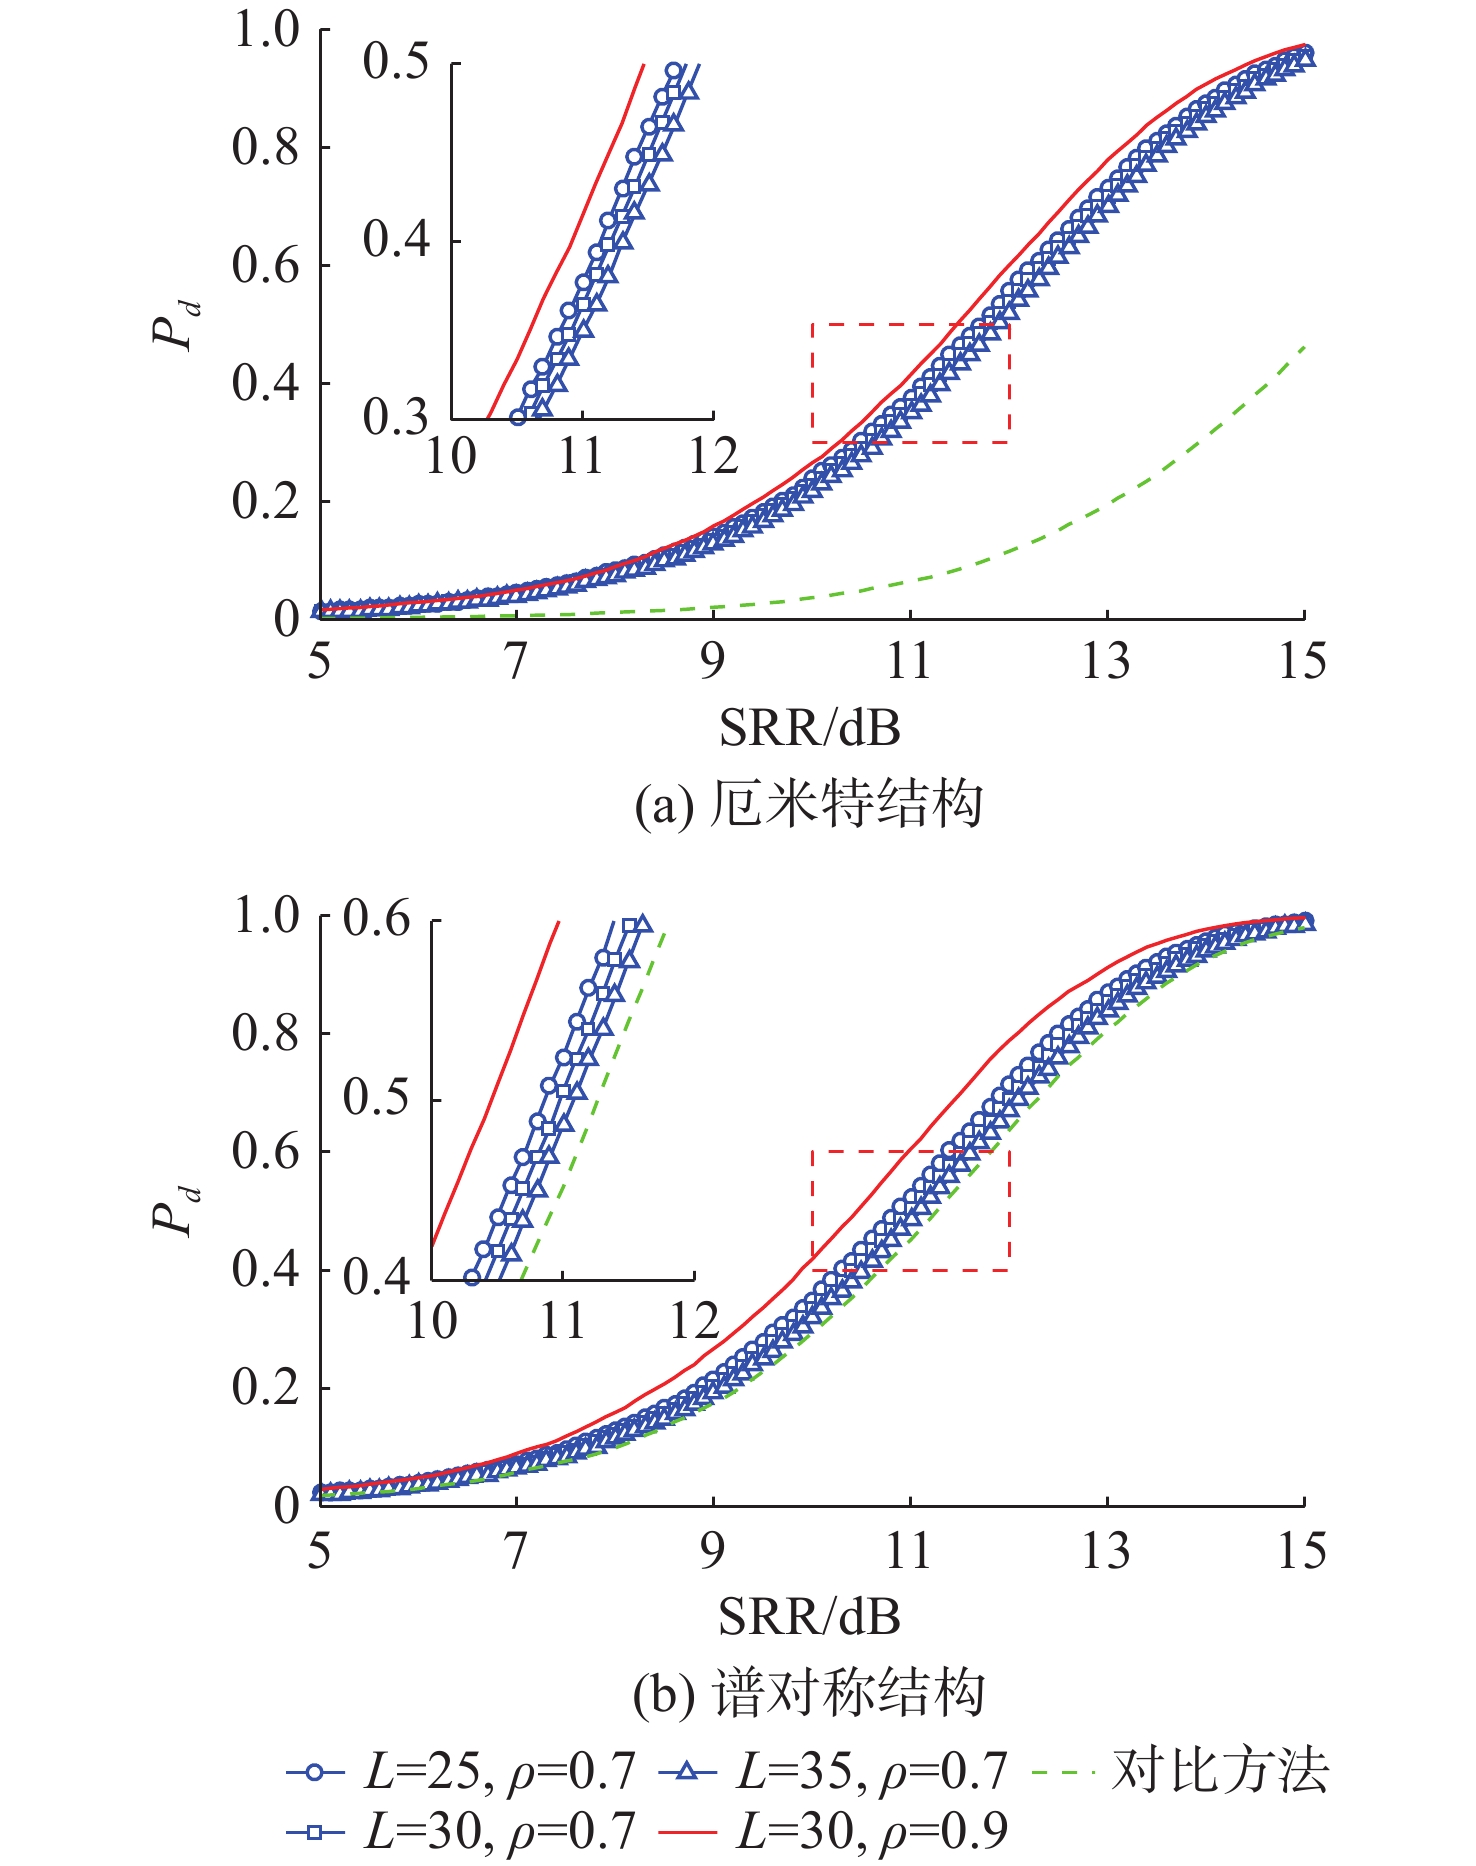
Active sonar faces the problem of non-uniform data in reverberation edge environments, leading to a sharp decrease in the amount of auxiliary data consistent with the background statistical characteristics of the cell under test. Meanwhile, existing methods utilize the sample covariance matrix of data when estimating the reverberant covariance matrix, which has limited the estimation accuracy, inevitably resulting in a loss of target detection performance. To address the above issues, this paper conducts research on two-step generalized likelihood ratio detection methods in reverberant edge environments based on Bayesian target detection, proposing two adaptive target detection methods: Bayesian Hermitian Target Detector in Reverberation Edge Environment, BH-TD-REE, and Bayesian Symmetric Target Detector in Reverberation Edge Environment, BS-TD-REE. Both the BH-TD-REE and BS-TD-REE methods treat the reverberation covariance matrix as a random variable and adopt the maximum a posteriori estimation criterion instead of the sample covariance estimation. Furthermore, the BS-TD-REE method also utilizes the spectral symmetry property of the reverberation covariance matrix, effectively expanding the number of auxiliary data and reducing the detector's demand for uniform auxiliary data. Simulation results show that both proposed methods effectively improve target detection performance and robustness, while the detection performance advantage is more significant under limited auxiliary data quantity.
Underwater optical beacon recognition based on dual image gray features and gaussian mixture model-triangle threshold algorithm
CHEN Zijun, YANG Ke, WANG Meng
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0112
Abstract:
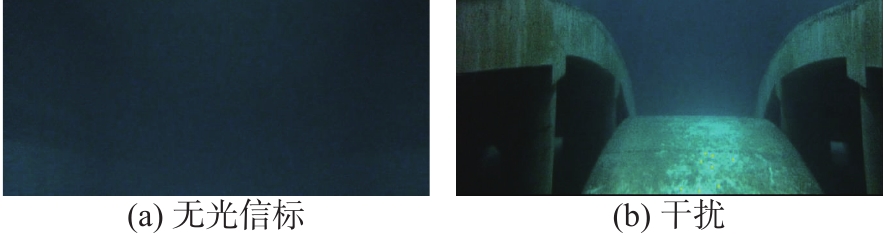
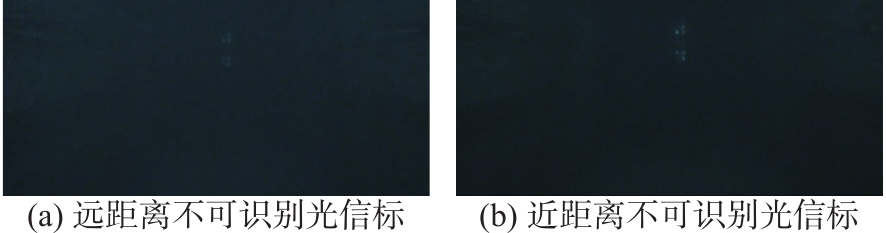
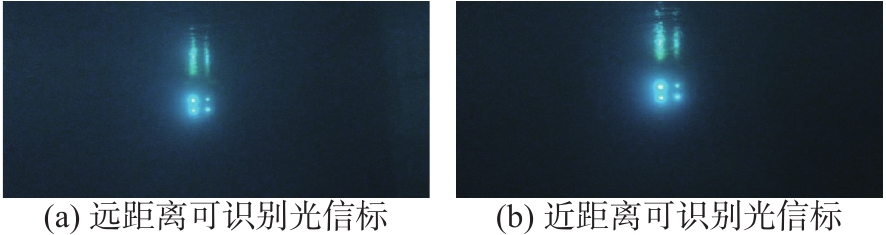
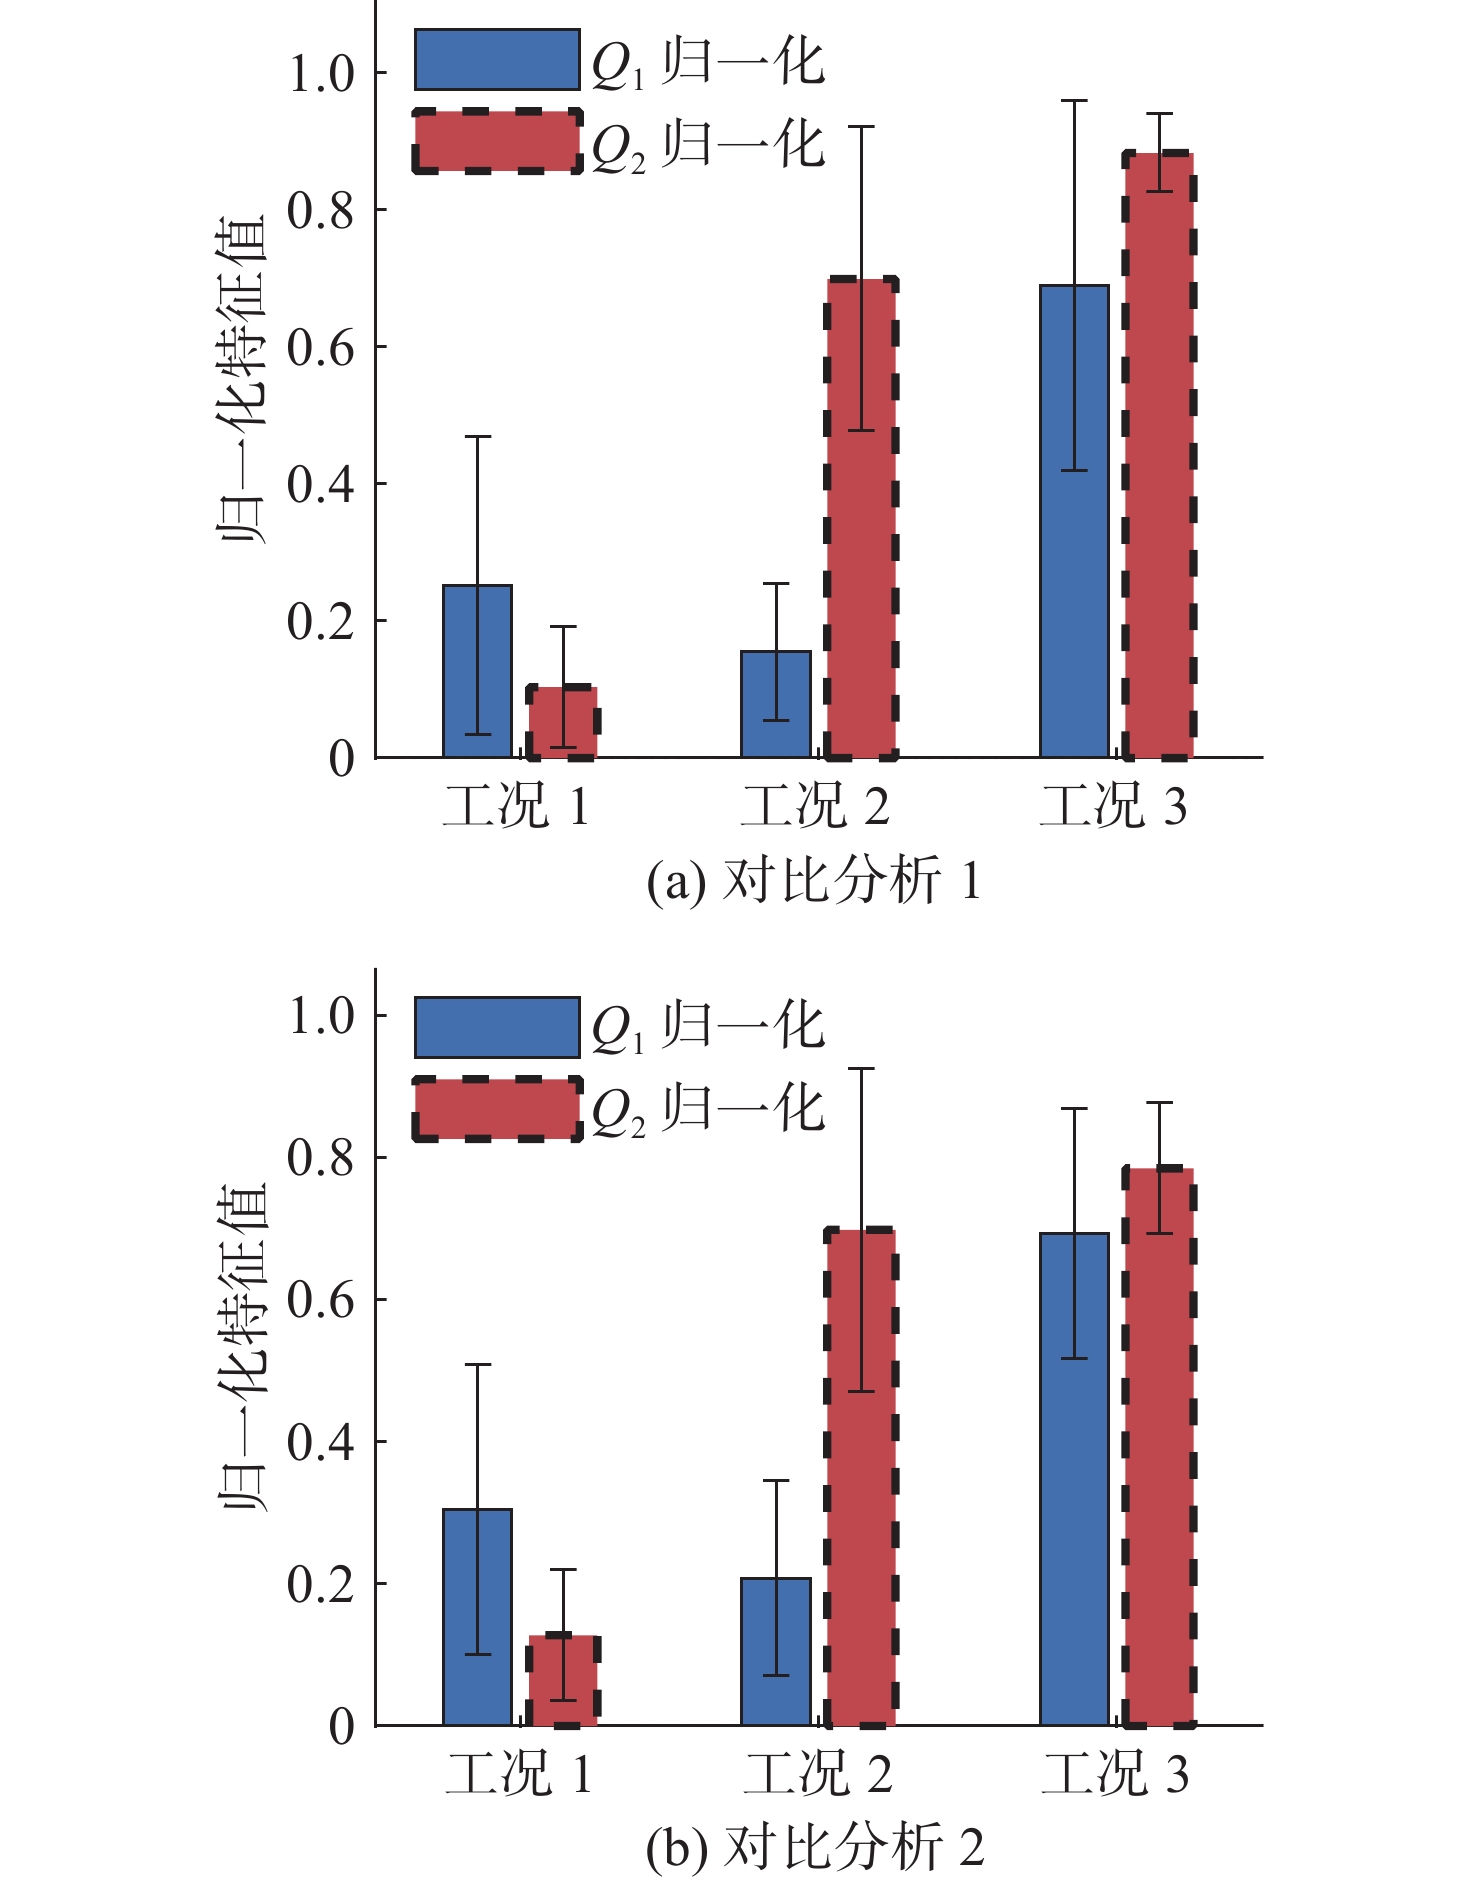
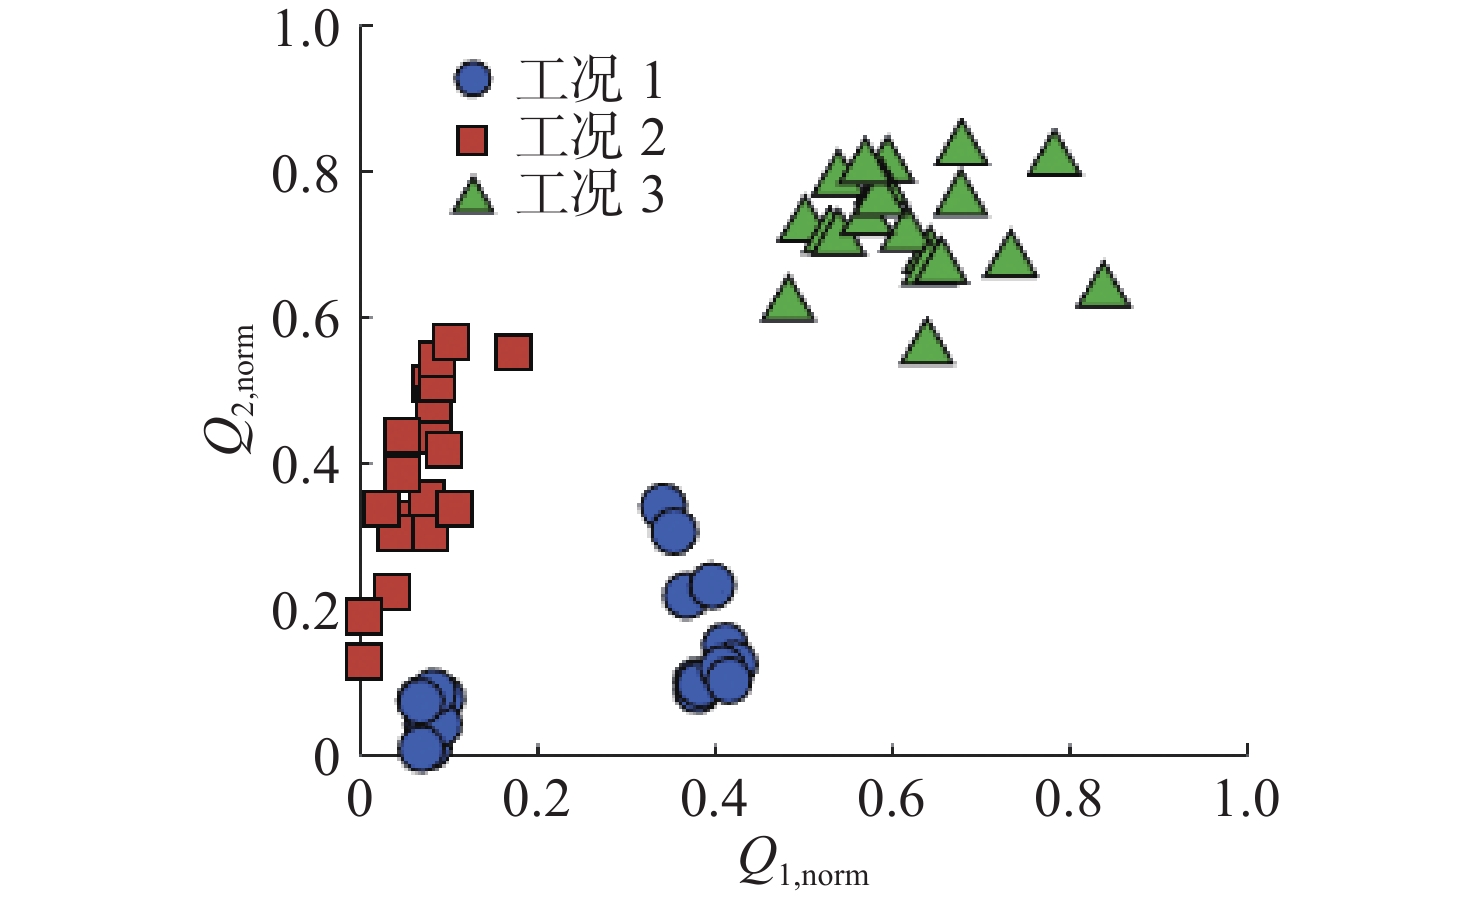
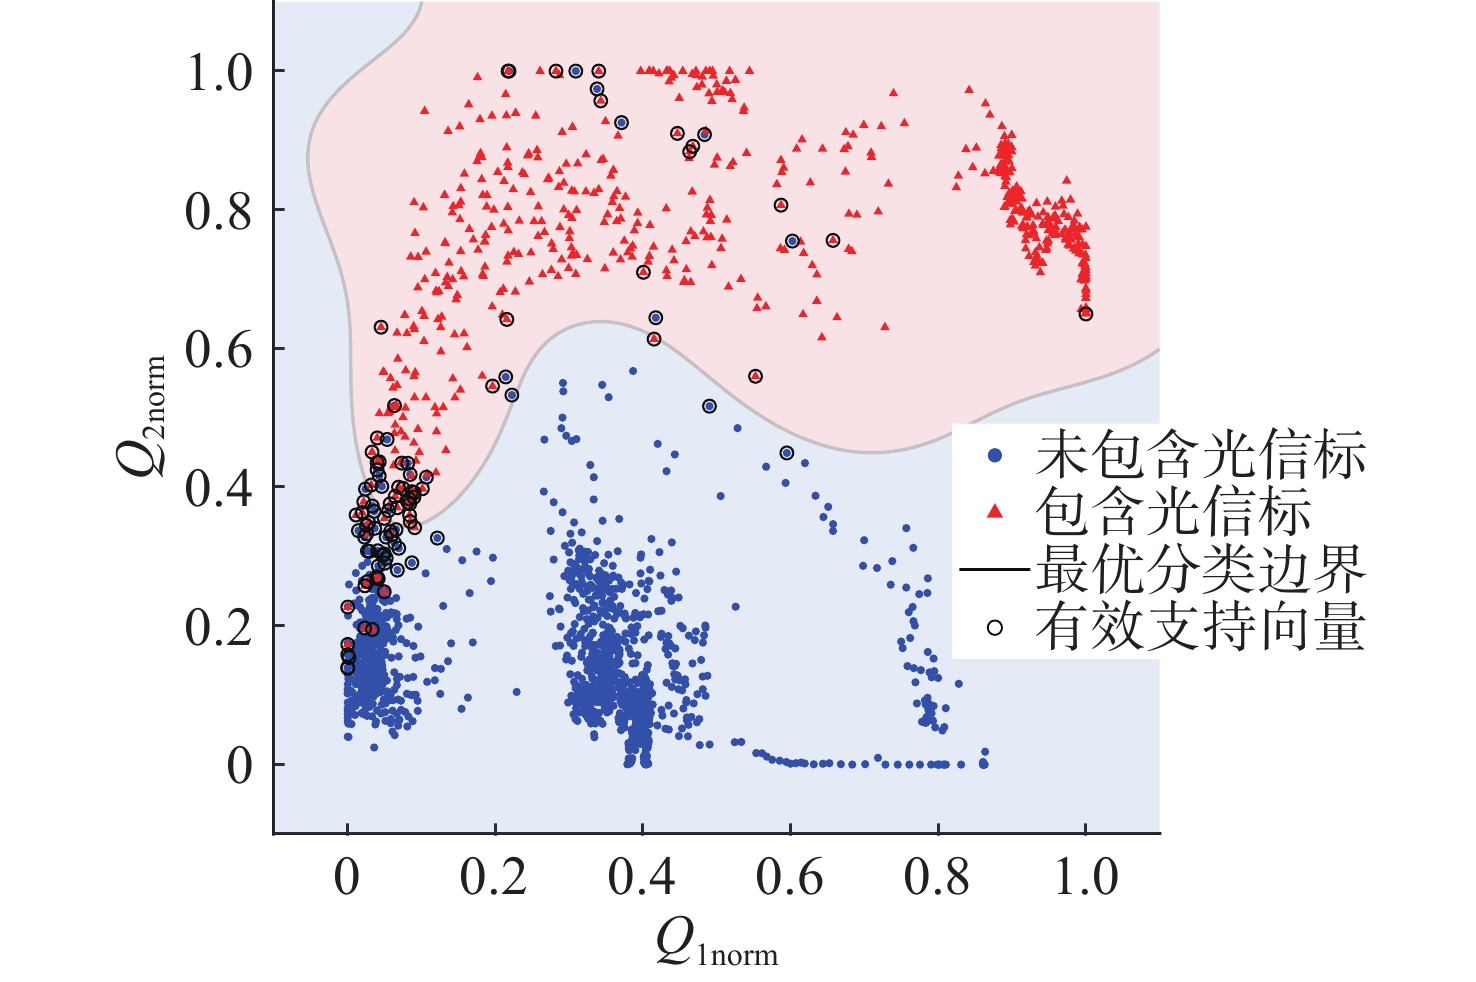
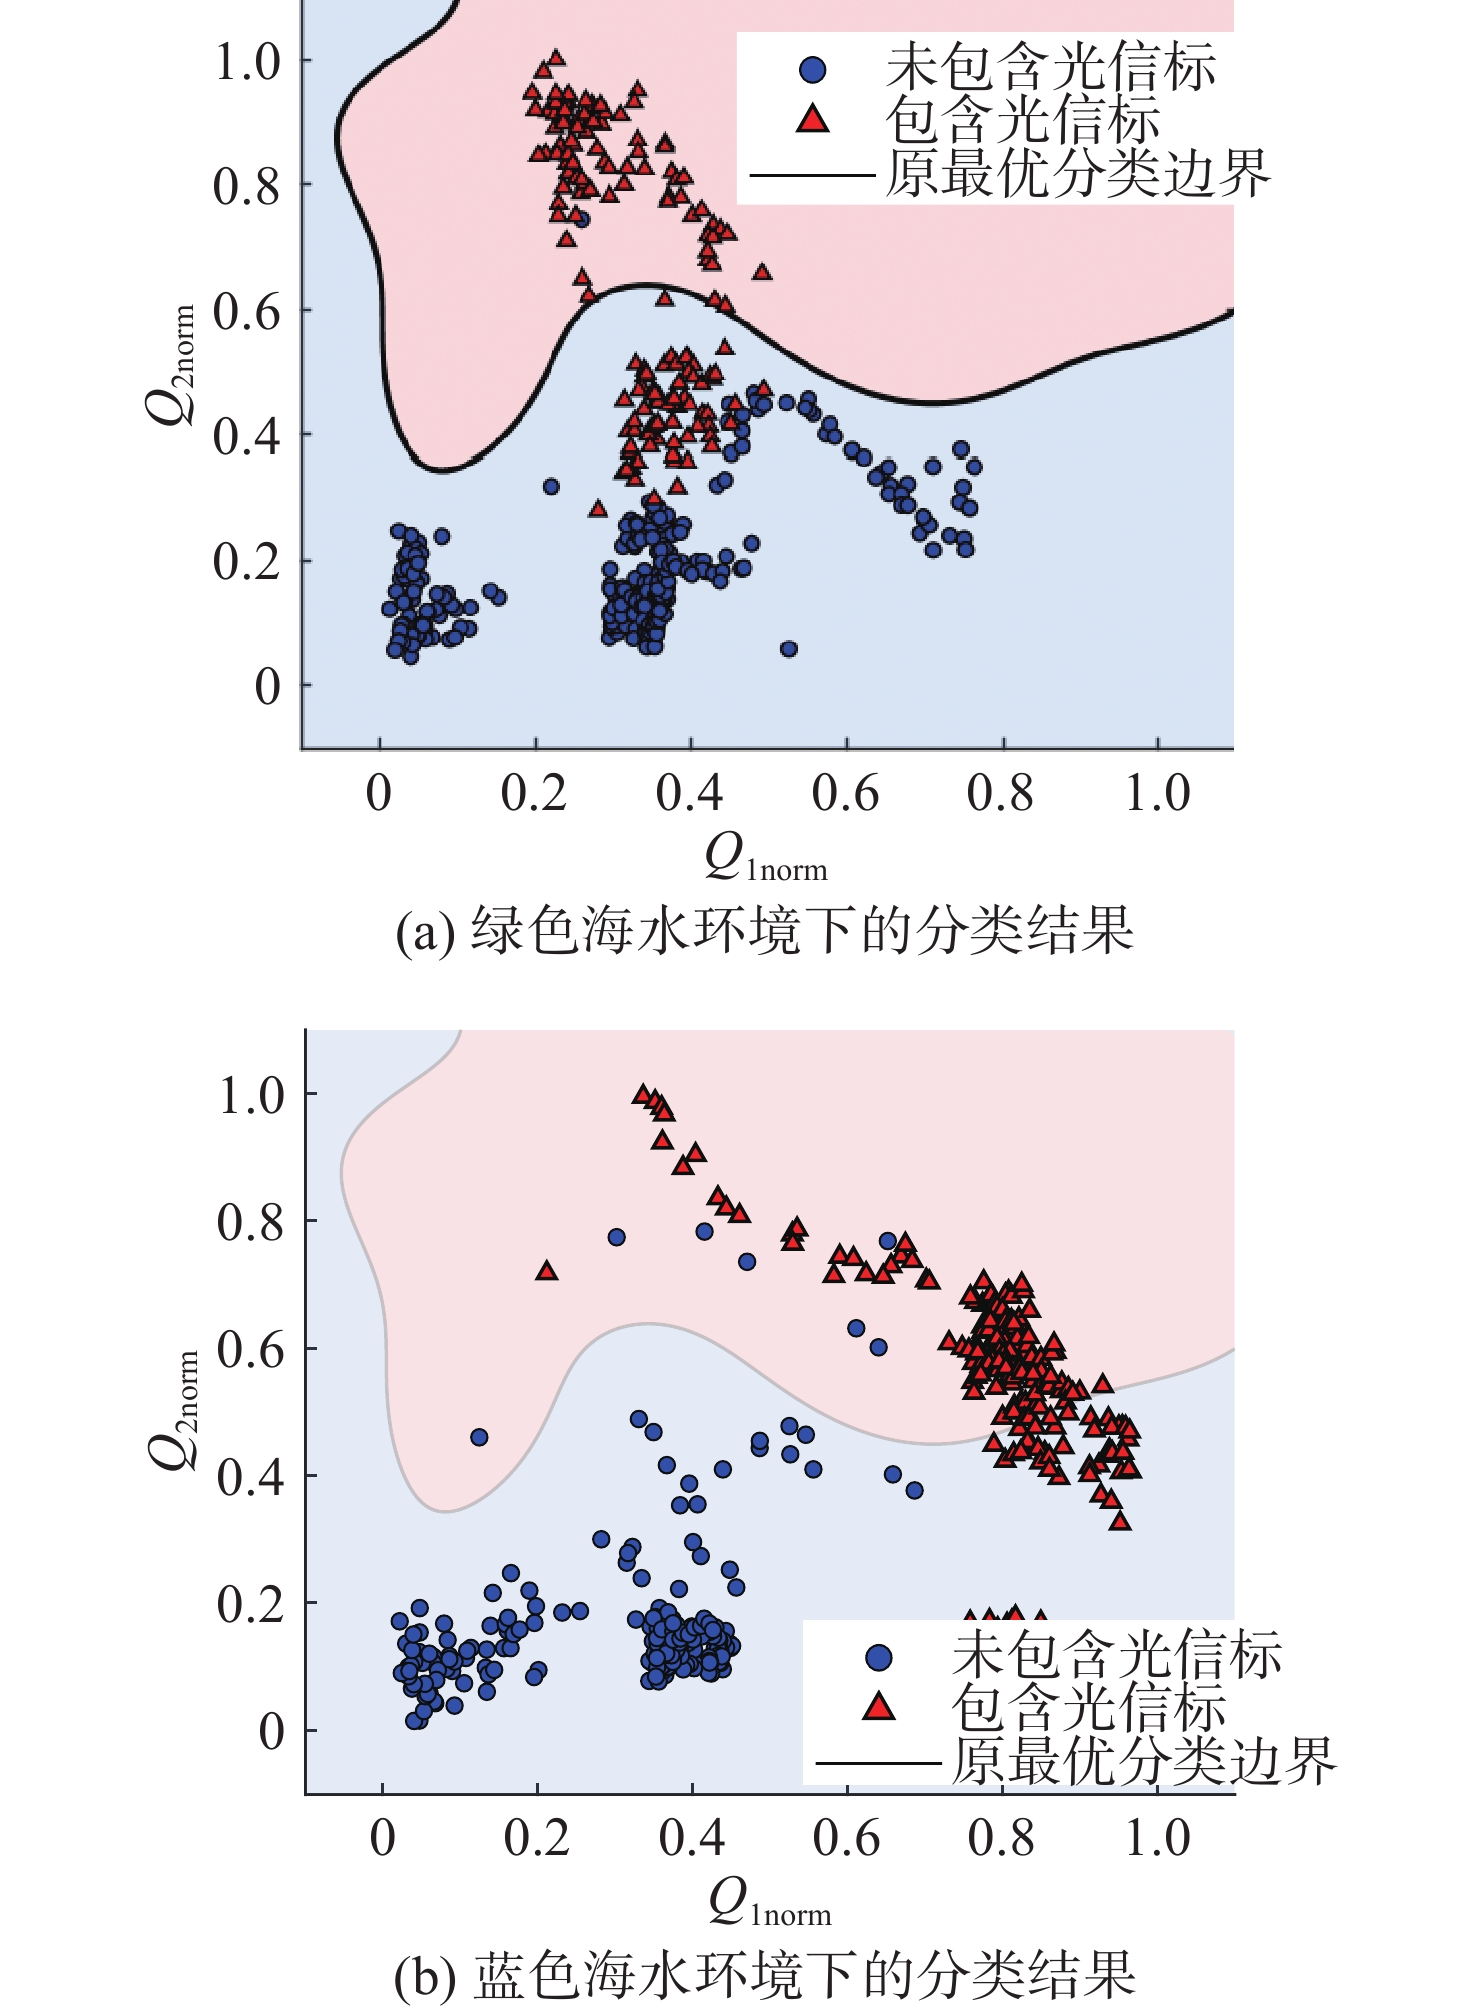
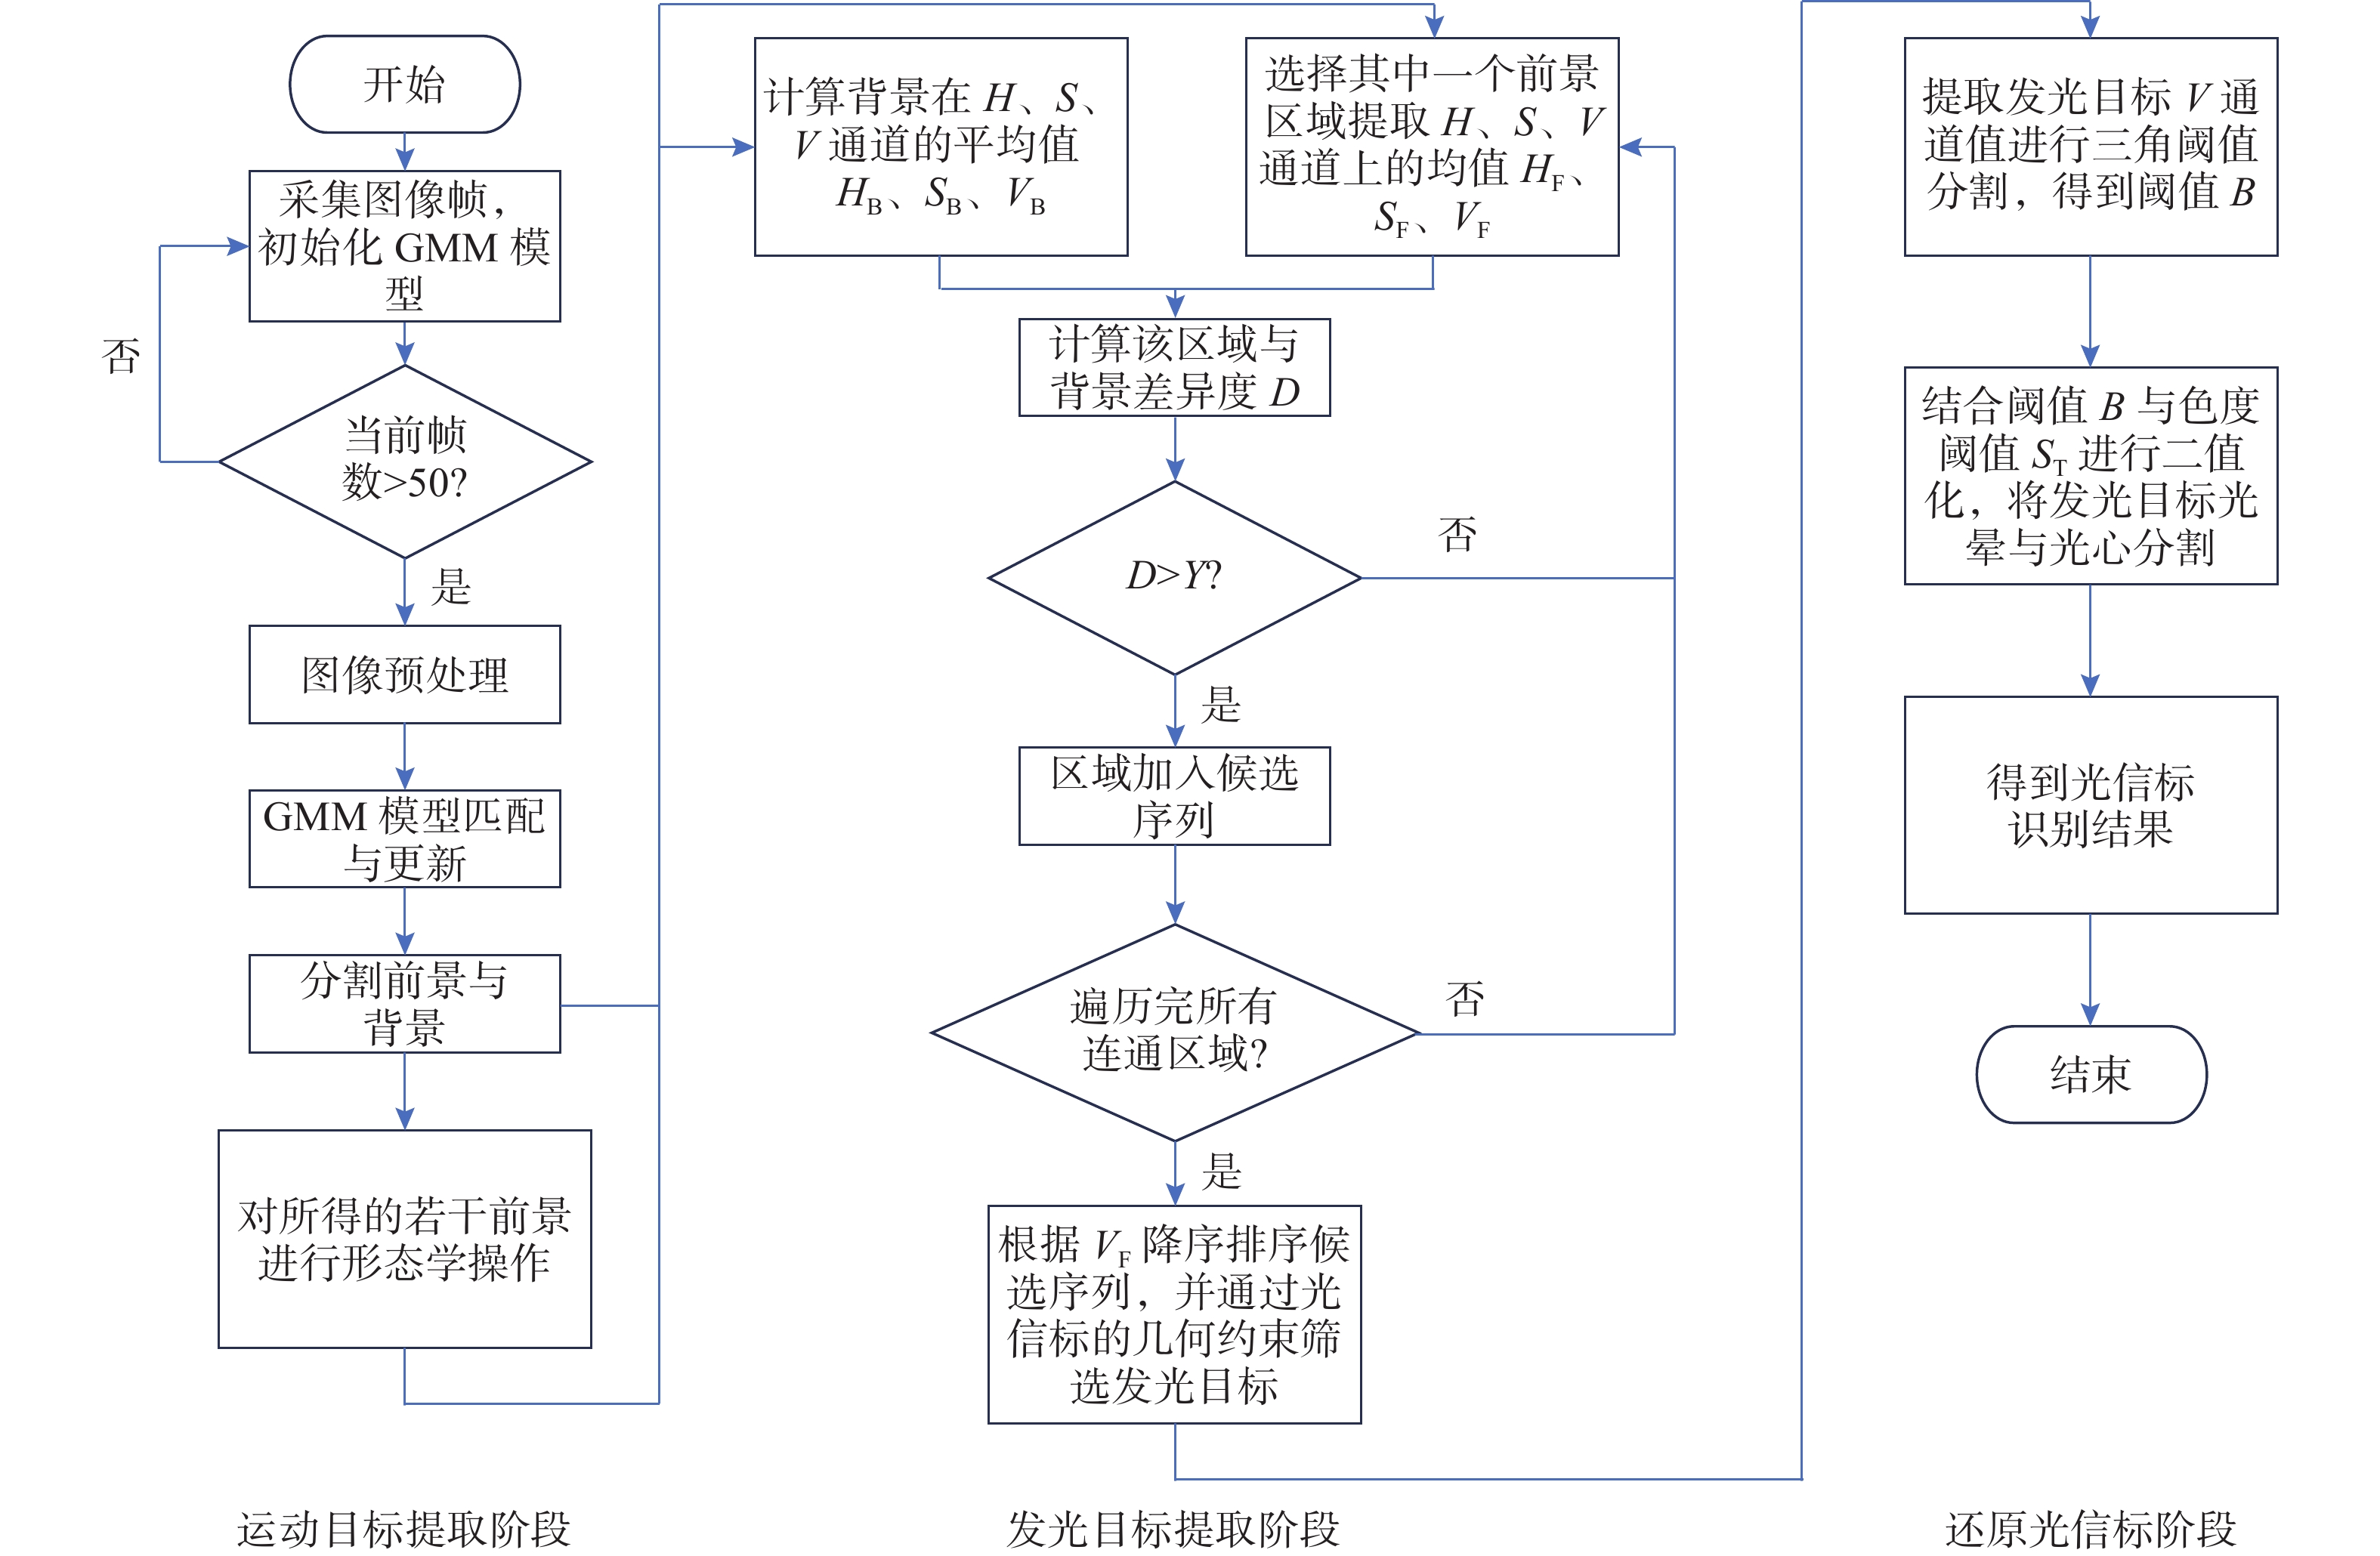
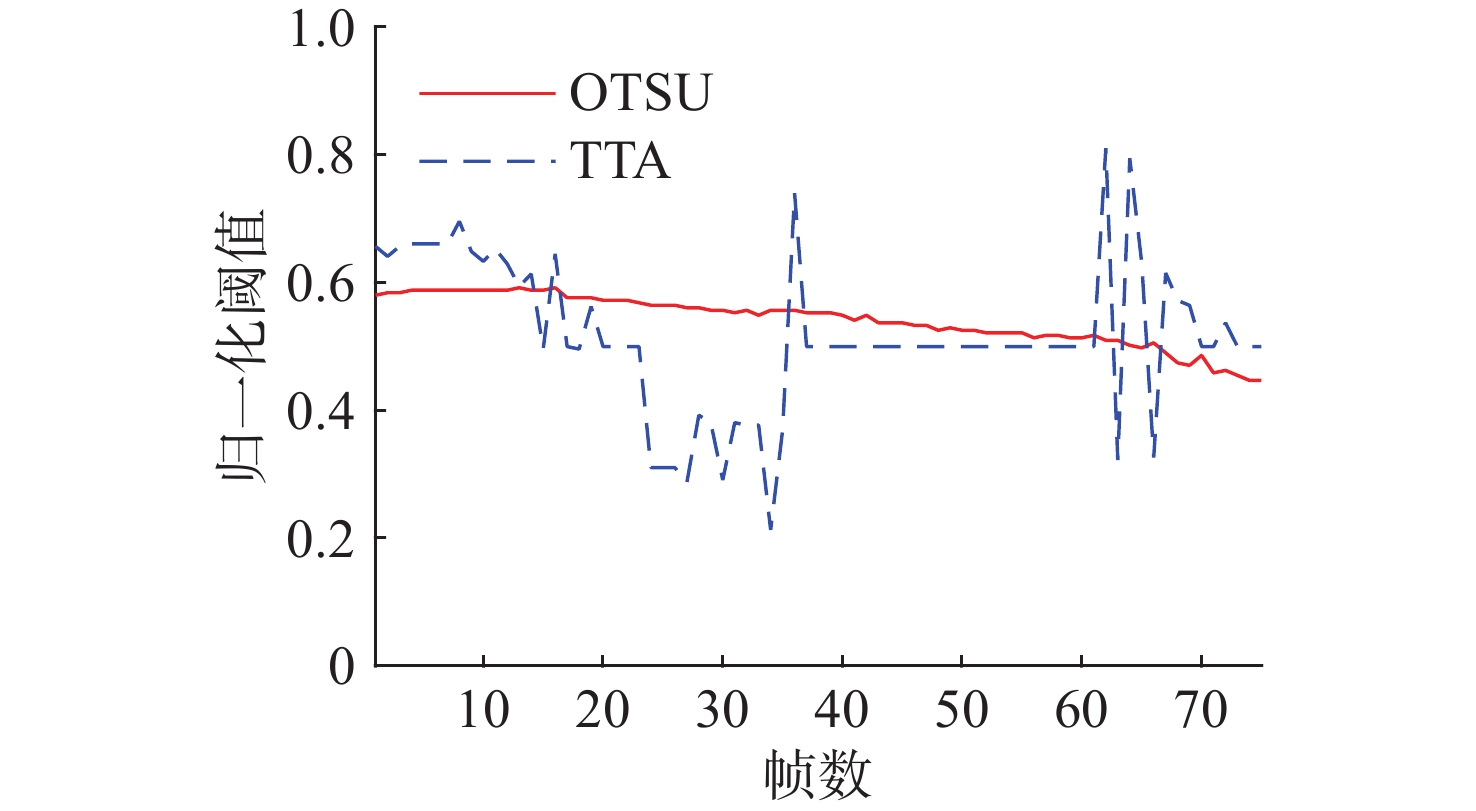
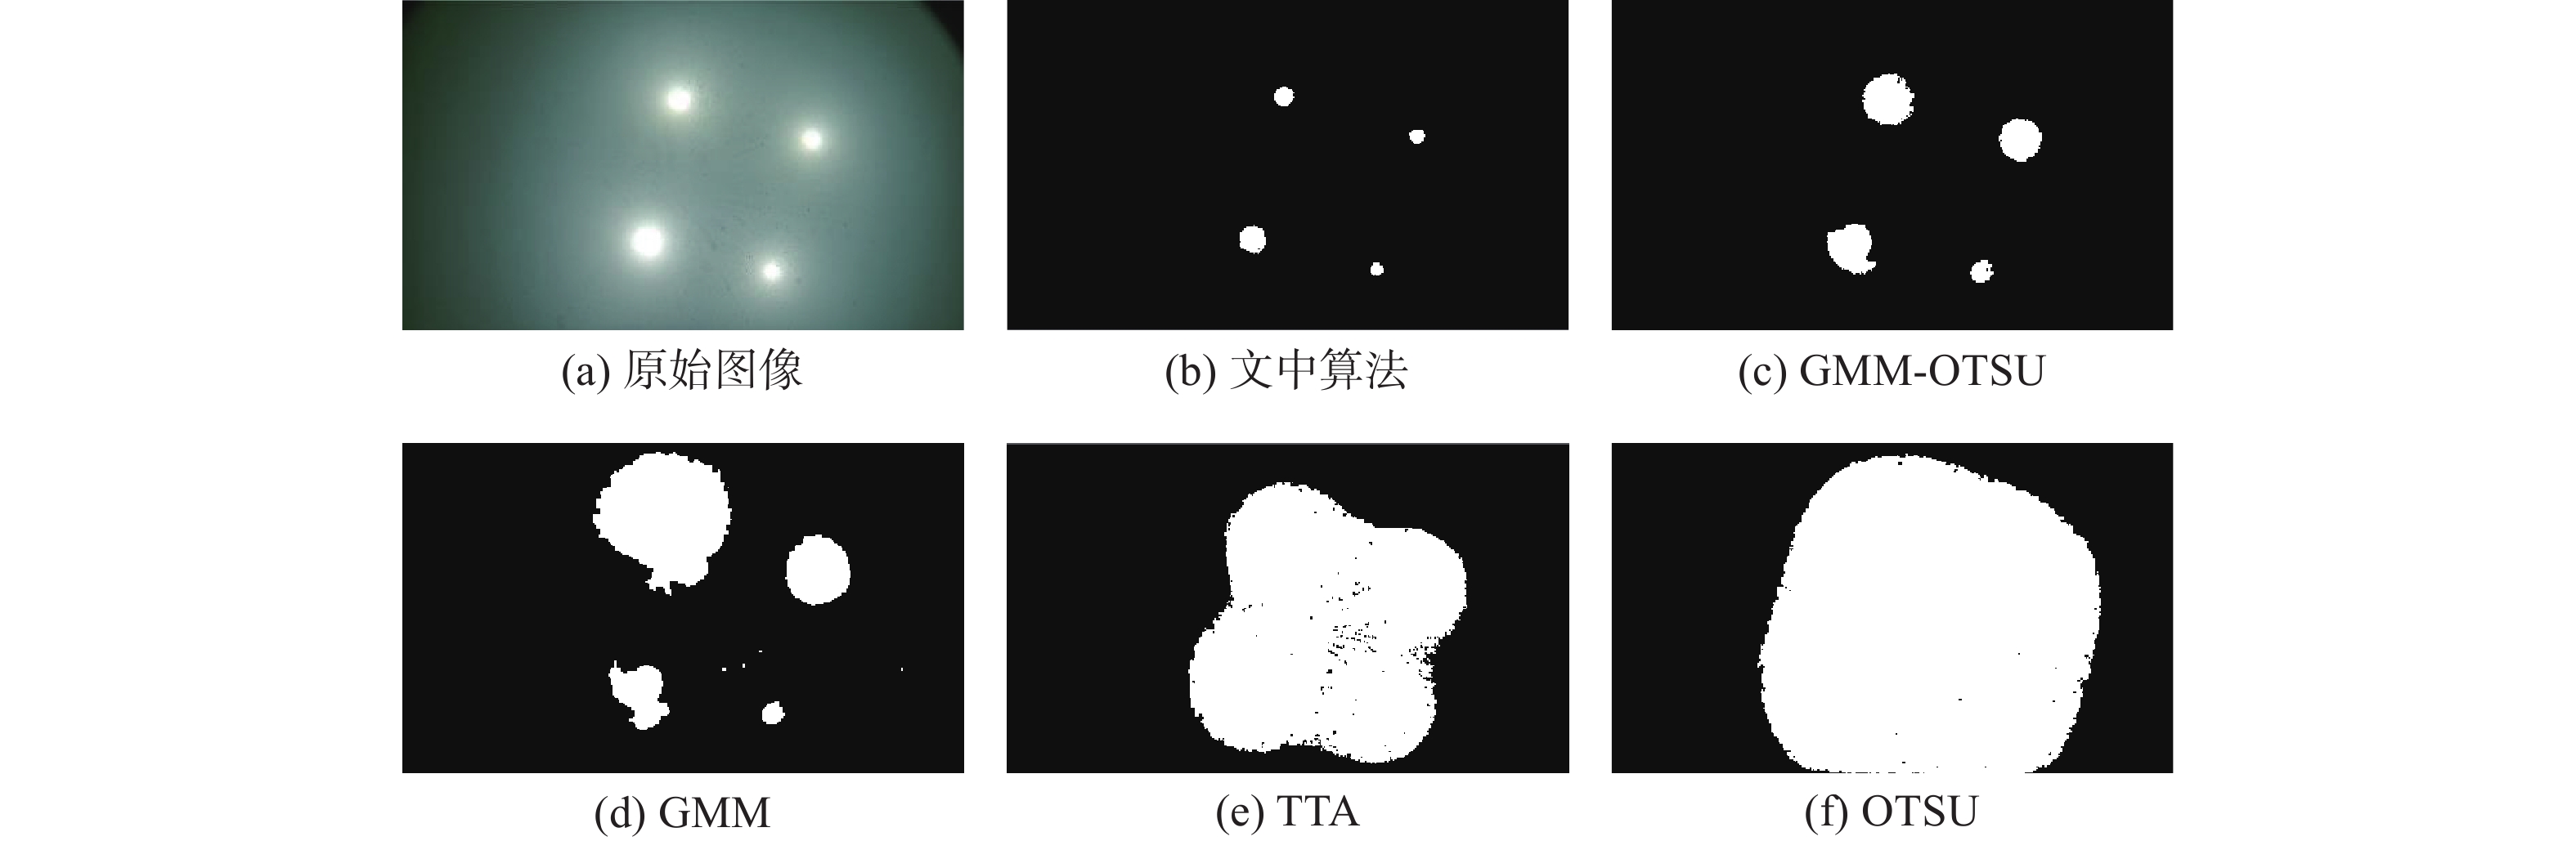
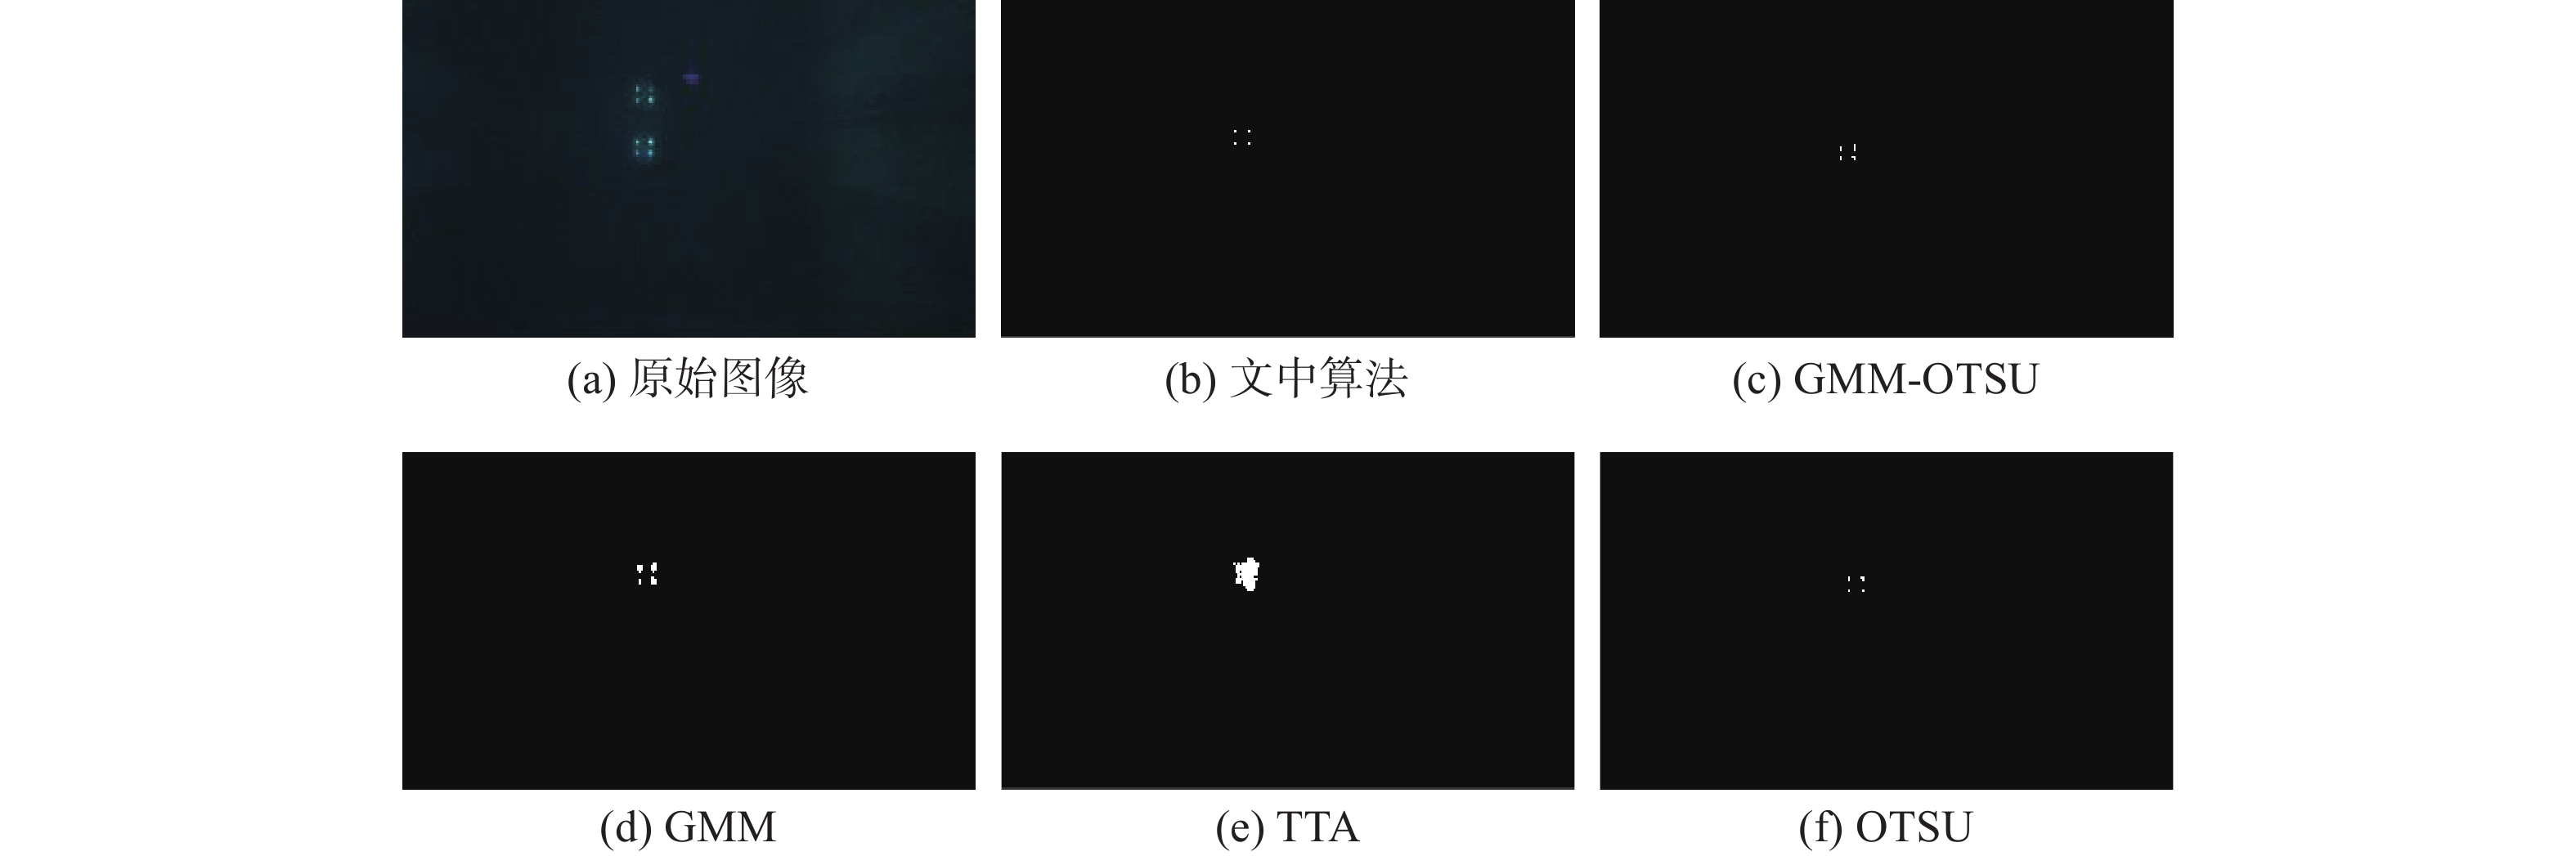
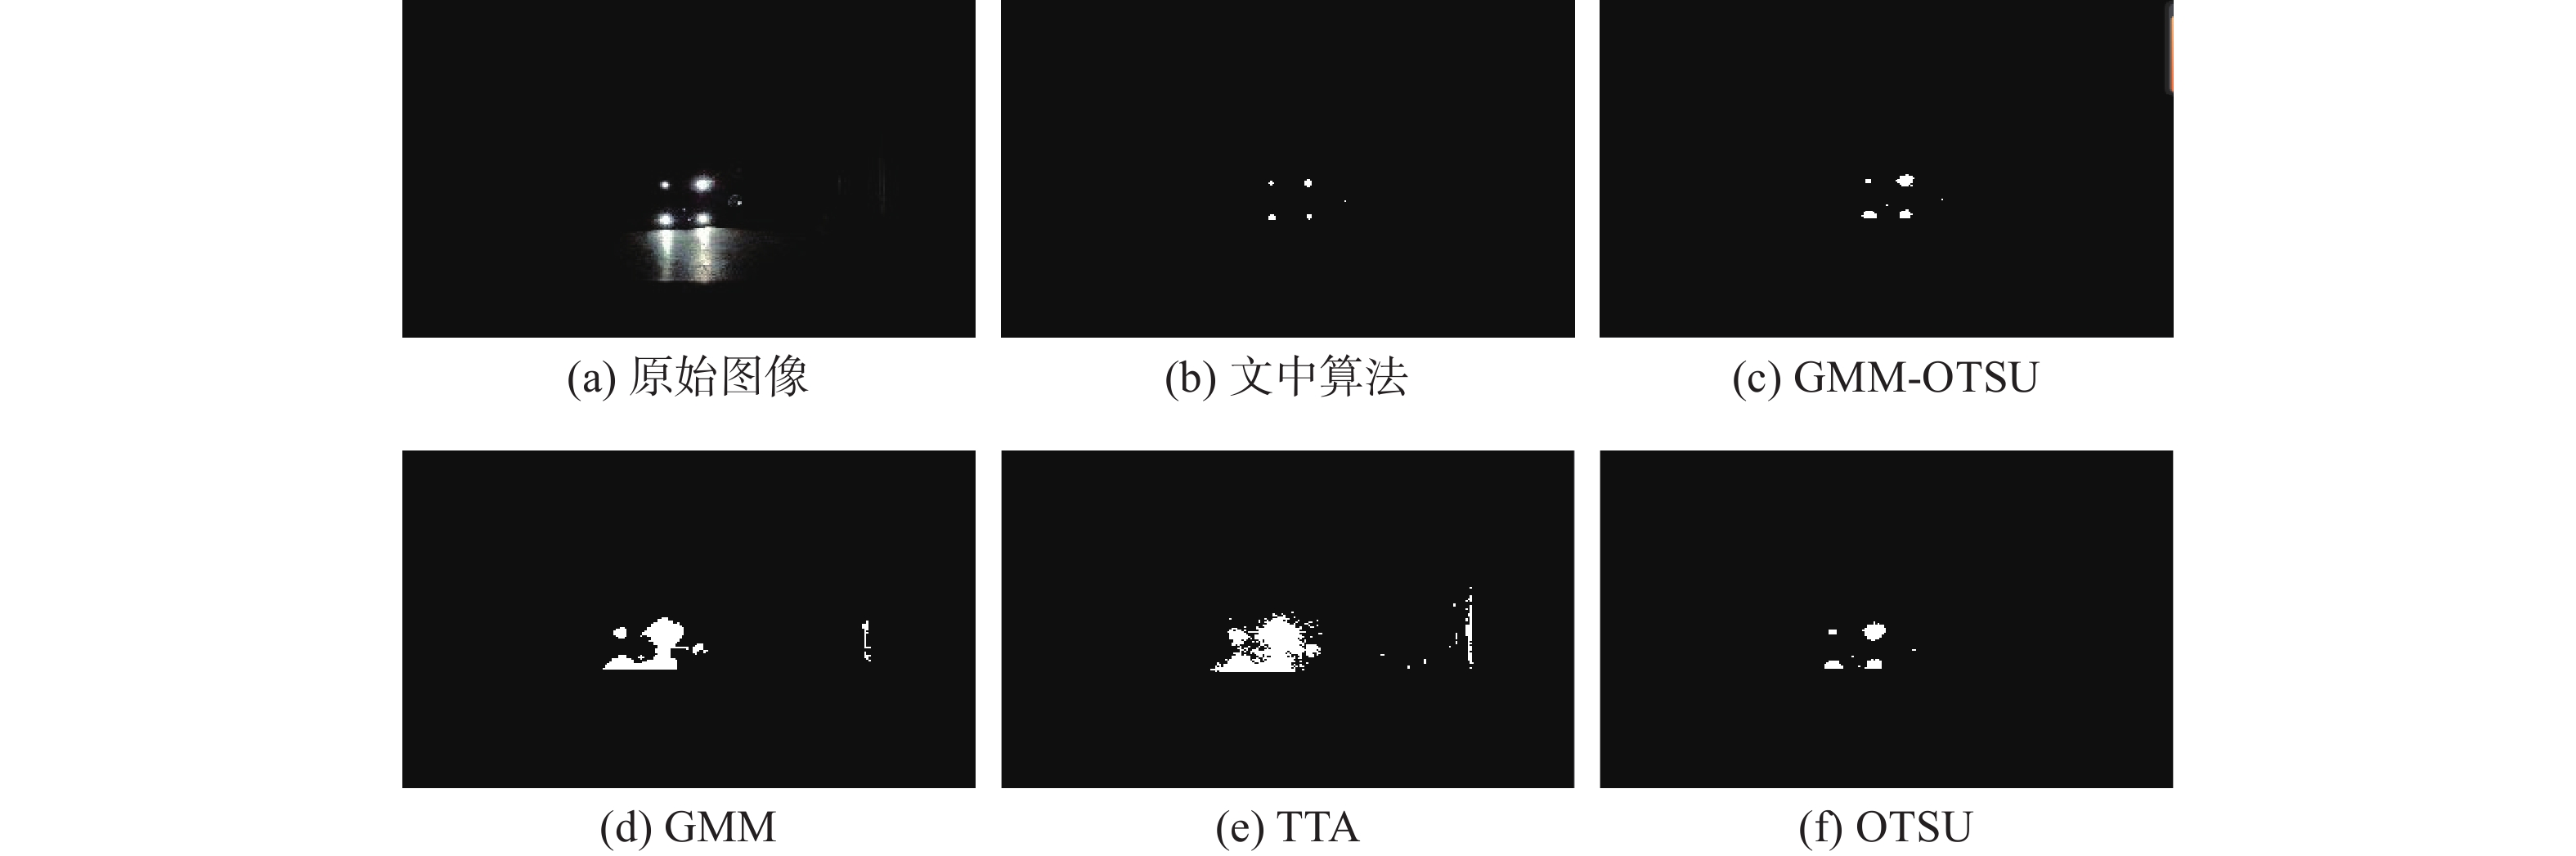
Underwater target recognition based on vision and optical beacon guidance is an important method to realize short-range underwater docking. The recognition accuracy of underwater optical beacons determines the positioning precision of underwater docking targets. A dual image gray feature-driven Gaussian Mixture Model (GMM)-Triangle Threshold Algorithm (TTA) is proposed to address the challenges of recognition accuracy and computational efficiency in underwater optical beacon segmentation. Firstly, taking dual image gray features as evaluation indices, the SVM is employed to determine whether an underwater image contains an optical beacon. Secondly, the GMM-TTA algorithm is designed to segment images to improve the recognition accuracy of underwater optical beacons. Finally, the proposed algorithm is verified using underwater images acquired from underwater docking experiments. The experimental results show that the proposed algorithm can accurately identify the existence of optical beacons in underwater images, effectively suppress strong underwater scattering halation during the image segmentation process, and the average roundness of extracted targets is superior to that of GMM, TTA, OTSU and GMM-OTSU algorithms.
Research Progress And Development Trend Of Underwater Positioning Technology For Underwater Robots
YI Zheng-yao, HUANG Meng-shi, SHEN Zhao-wen, YANG Tian-ci, WANG Quan, HUANG Chengtao
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0069
Abstract:
With the further implementation of China’s strategy of building a maritime power, the large-scale application of deep-sea equipment such as underwater robots has placed an urgent demand on underwater positioning technology with high precision, high reliability and long endurance. Constrained by physical factors including electromagnetic shielding in seawater, acoustic propagation interference and extreme environments, the international high-end market remains monopolized by foreign enterprises. Although China has achieved a leap from following to keeping pace with global advanced technologies, it still faces bottlenecks such as low localization rate of core components. Focusing on underwater robot positioning, this paper systematically reviews the three-stage evolution of underwater positioning technology, classifies and expounds the principles, performance and engineering applications of various positioning technologies, analyzes core challenges and predicts four major development trends, so as to provide theoretical references for the independent innovation and engineering application of China’s underwater positioning technology.
Dubins Path-based Dynamic Docking Trajectory Planning for Autonomous Underwater Vehicle
WANG Yue, RAN Qili, ZHANG Yuanxu, TANG Qinghua, CHEN Guofang, Gao Jian
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0088
Abstract:
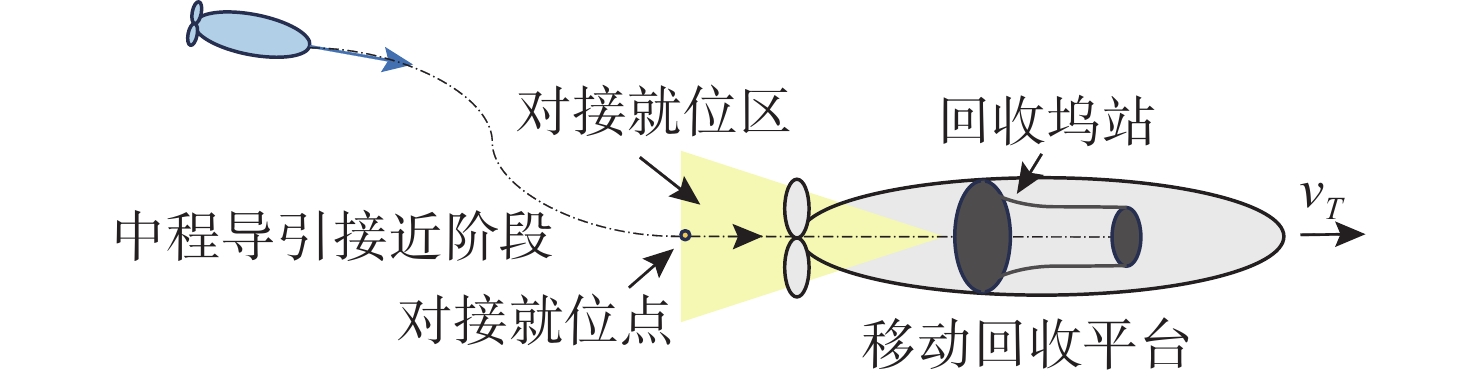
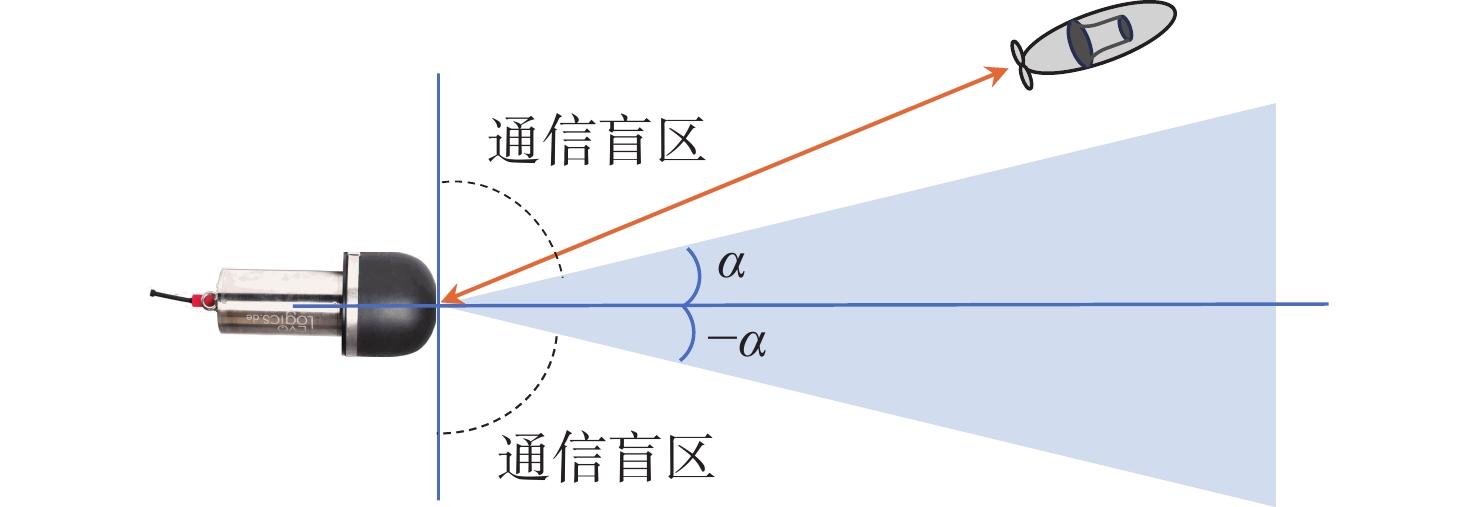
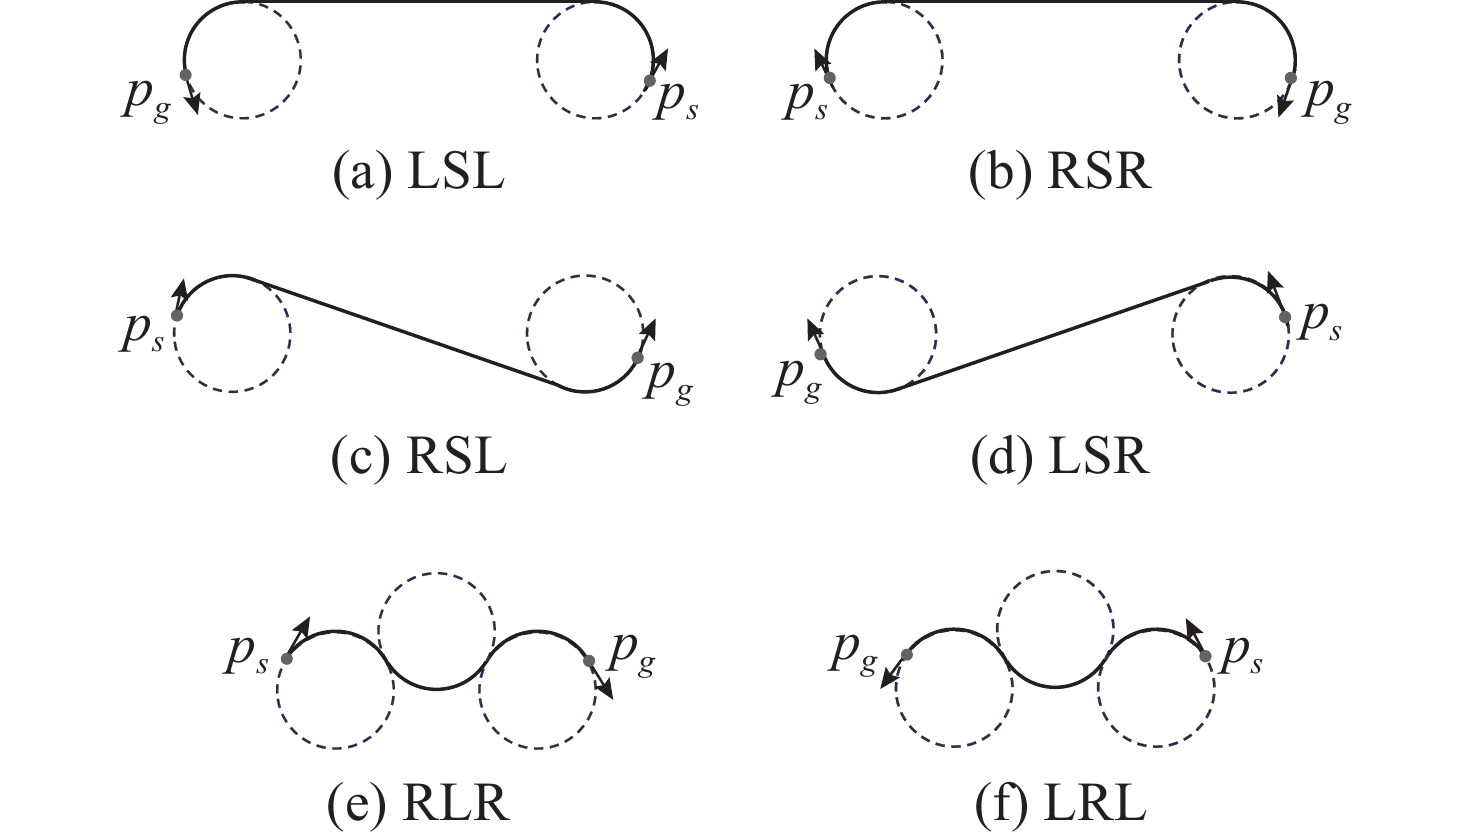
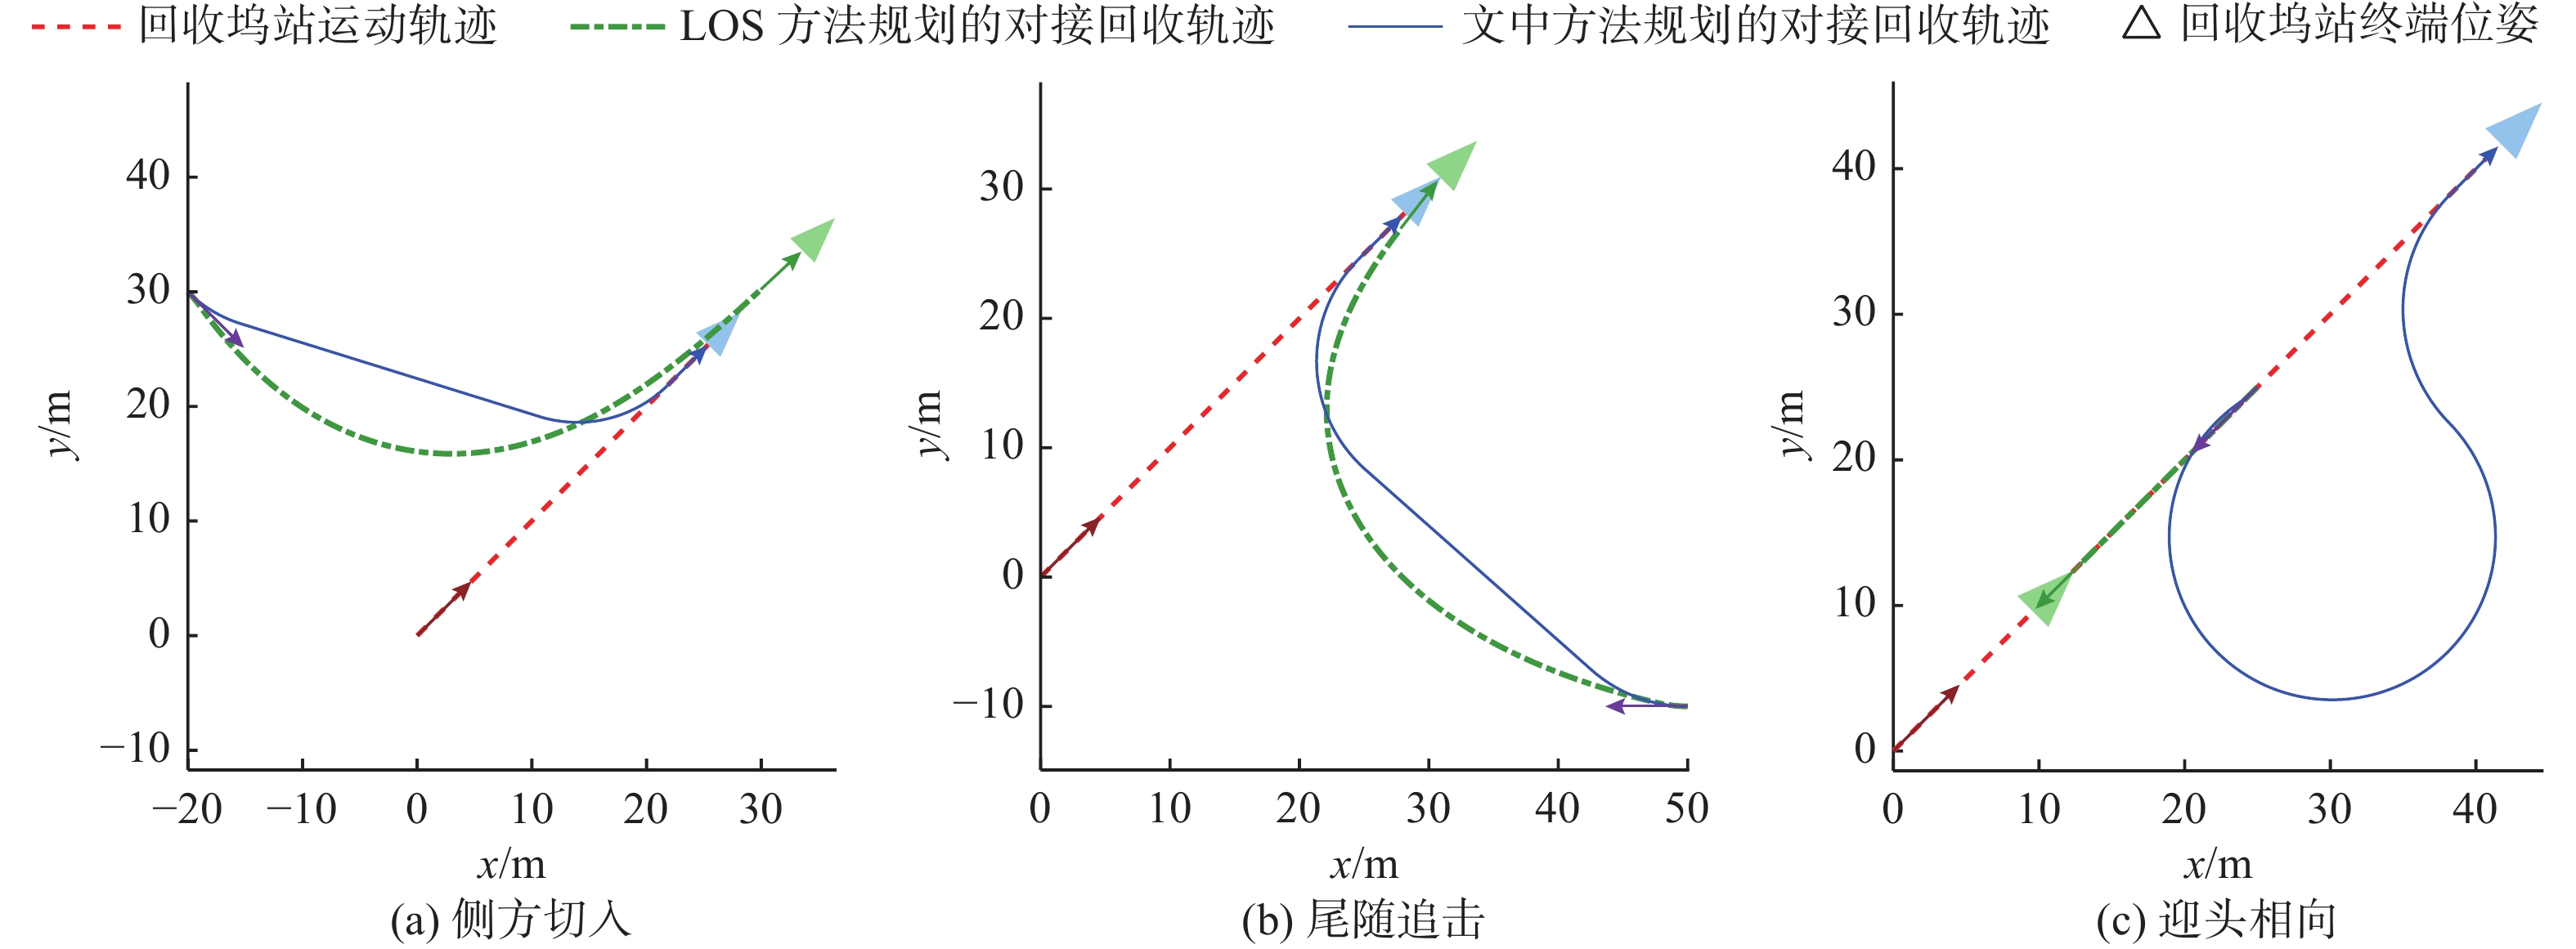
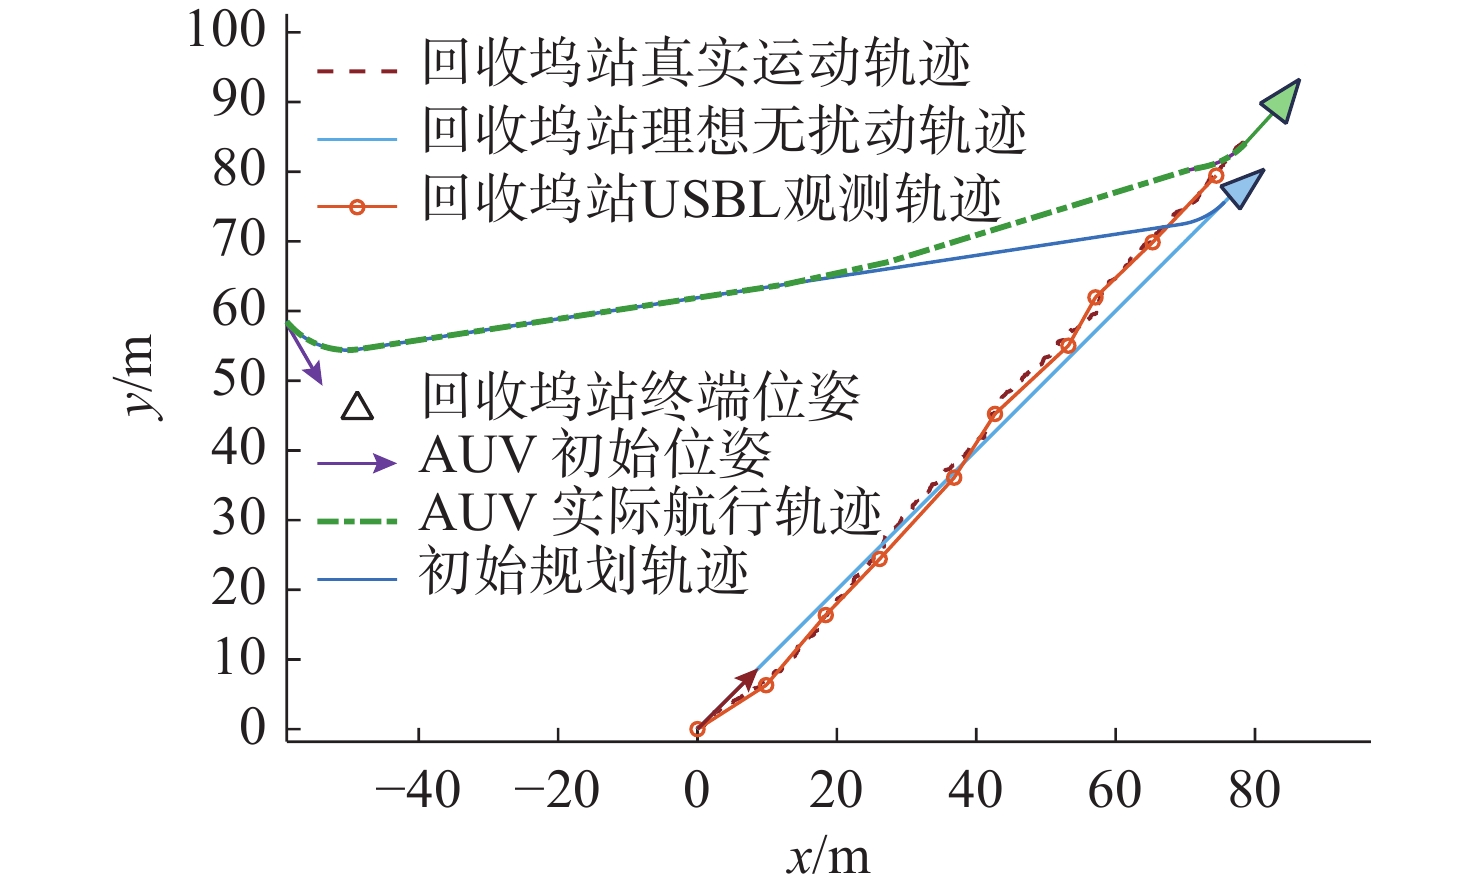
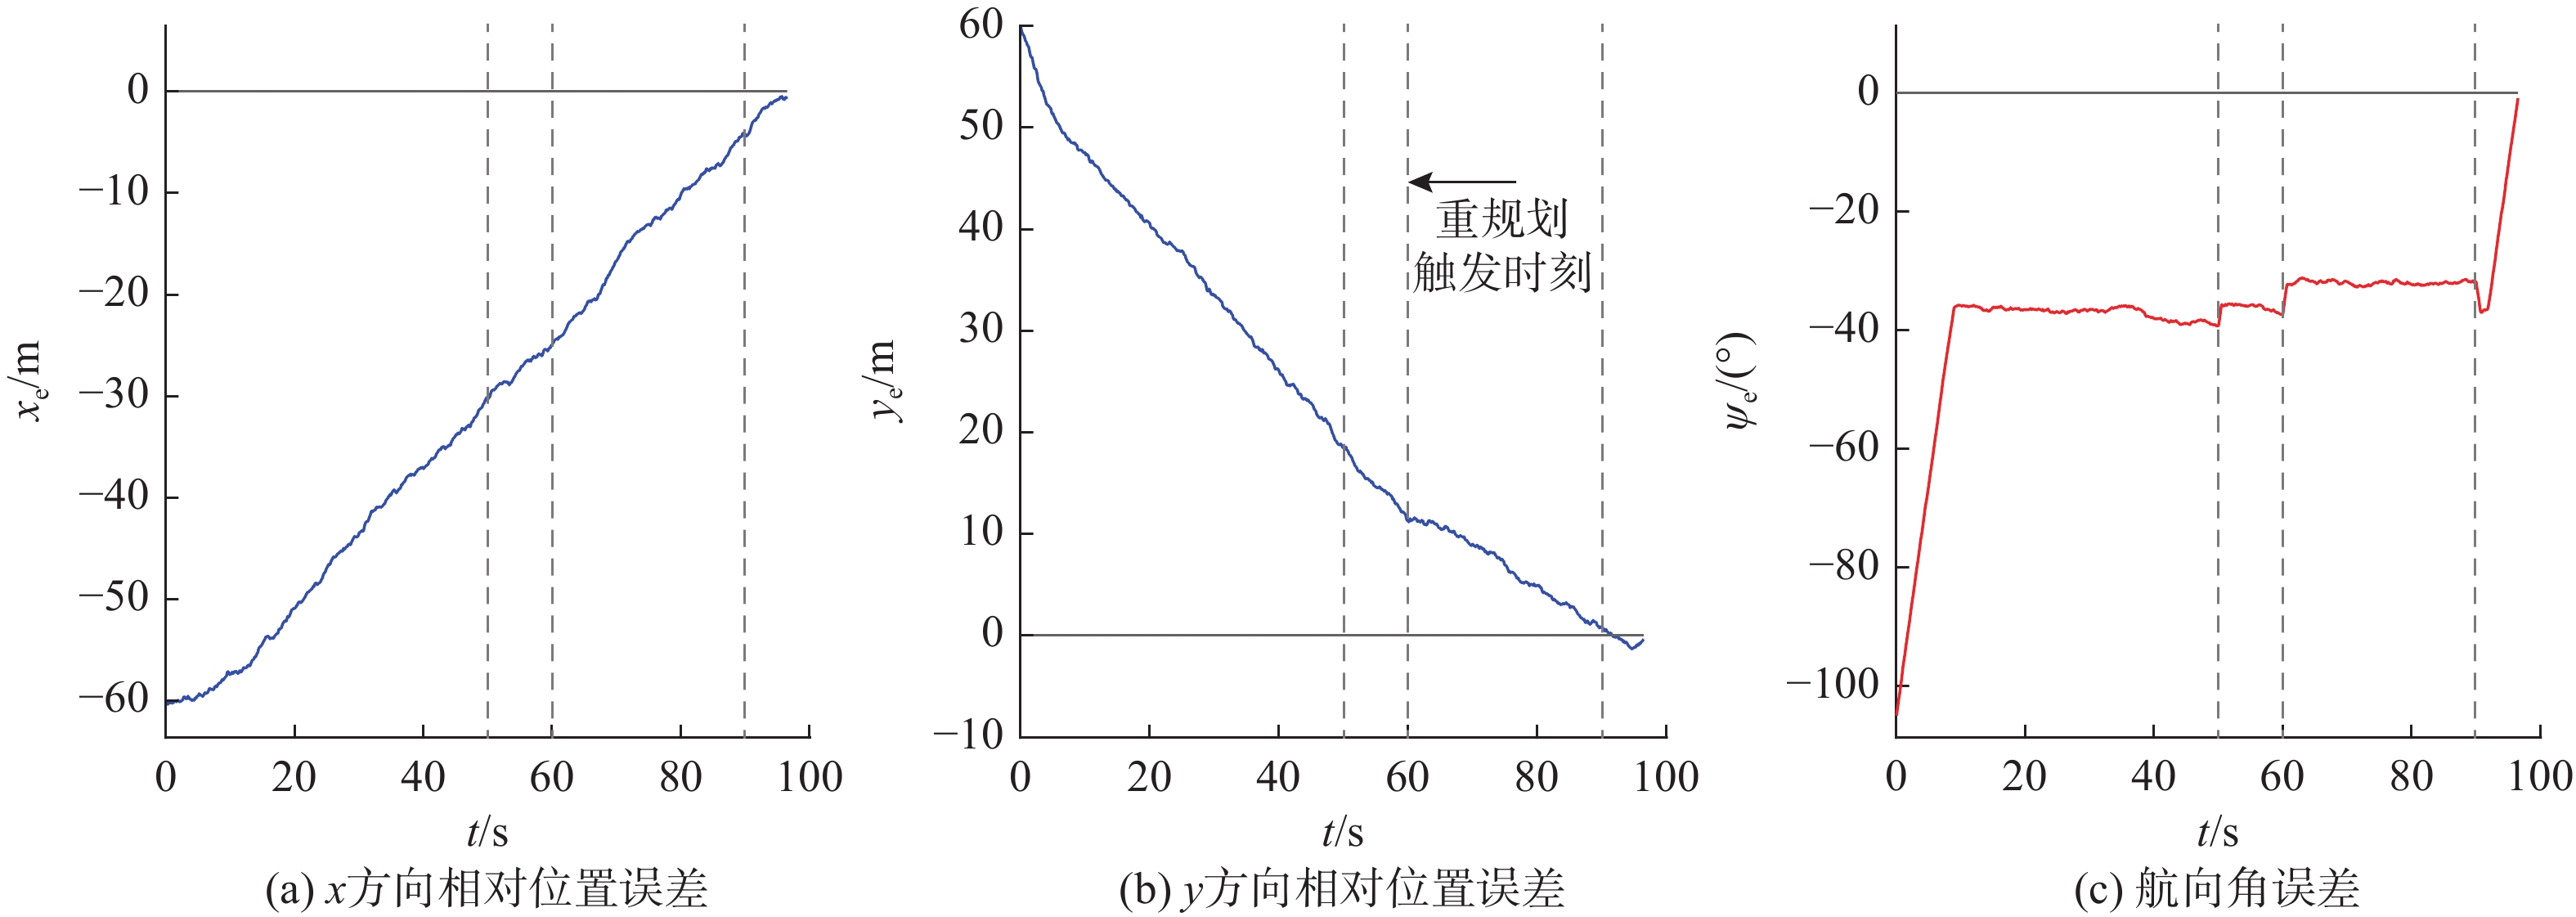
The dynamic docking recovery of autonomous undersea vehicle (AUV) faces multiple challenges, including moving-target rendezvous, terminal attitude alignment, and acoustic positioning limitations. Existing trajectory planning methods struggle to simultaneously achieve time optimality and robustness under these constraints. To address these challenges, this paper proposes a time-optimal dynamic docking trajectory planning method based on Dubins paths. First, the mid-range guidance phase is formulated as a constrained shortest-path problem in the horizontal plane. By constructing a time residual function, the dynamic arrival point of the moving recovery platform is predicted, and a feasible Dubins path satisfying the minimum turning radius constraint of the AUV is solved. Second, an online replanning mechanism triggered by the beamwidth of the Ultra-Short Baseline (USBL) system is designed to suppress trajectory divergence caused by environmental disturbances and observation noise. Multi-scenario simulation results demonstrate that, compared with the traditional line-of-sight guidance method, the proposed approach enables effective tracking of the moving platform and terminal heading alignment under typical dynamic docking conditions, while maintaining good trajectory convergence and anti-interference capability under disturbances and measurement errors.
Research on Dynamic Obstacle Avoidance Planning for Unmanned Surface Vessels Based on the Introduction of Attention Mechanism
LIU Zhenyi, LI Bin, ZHANG Jun, LI Peng, XIA Chao
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0076
Abstract:
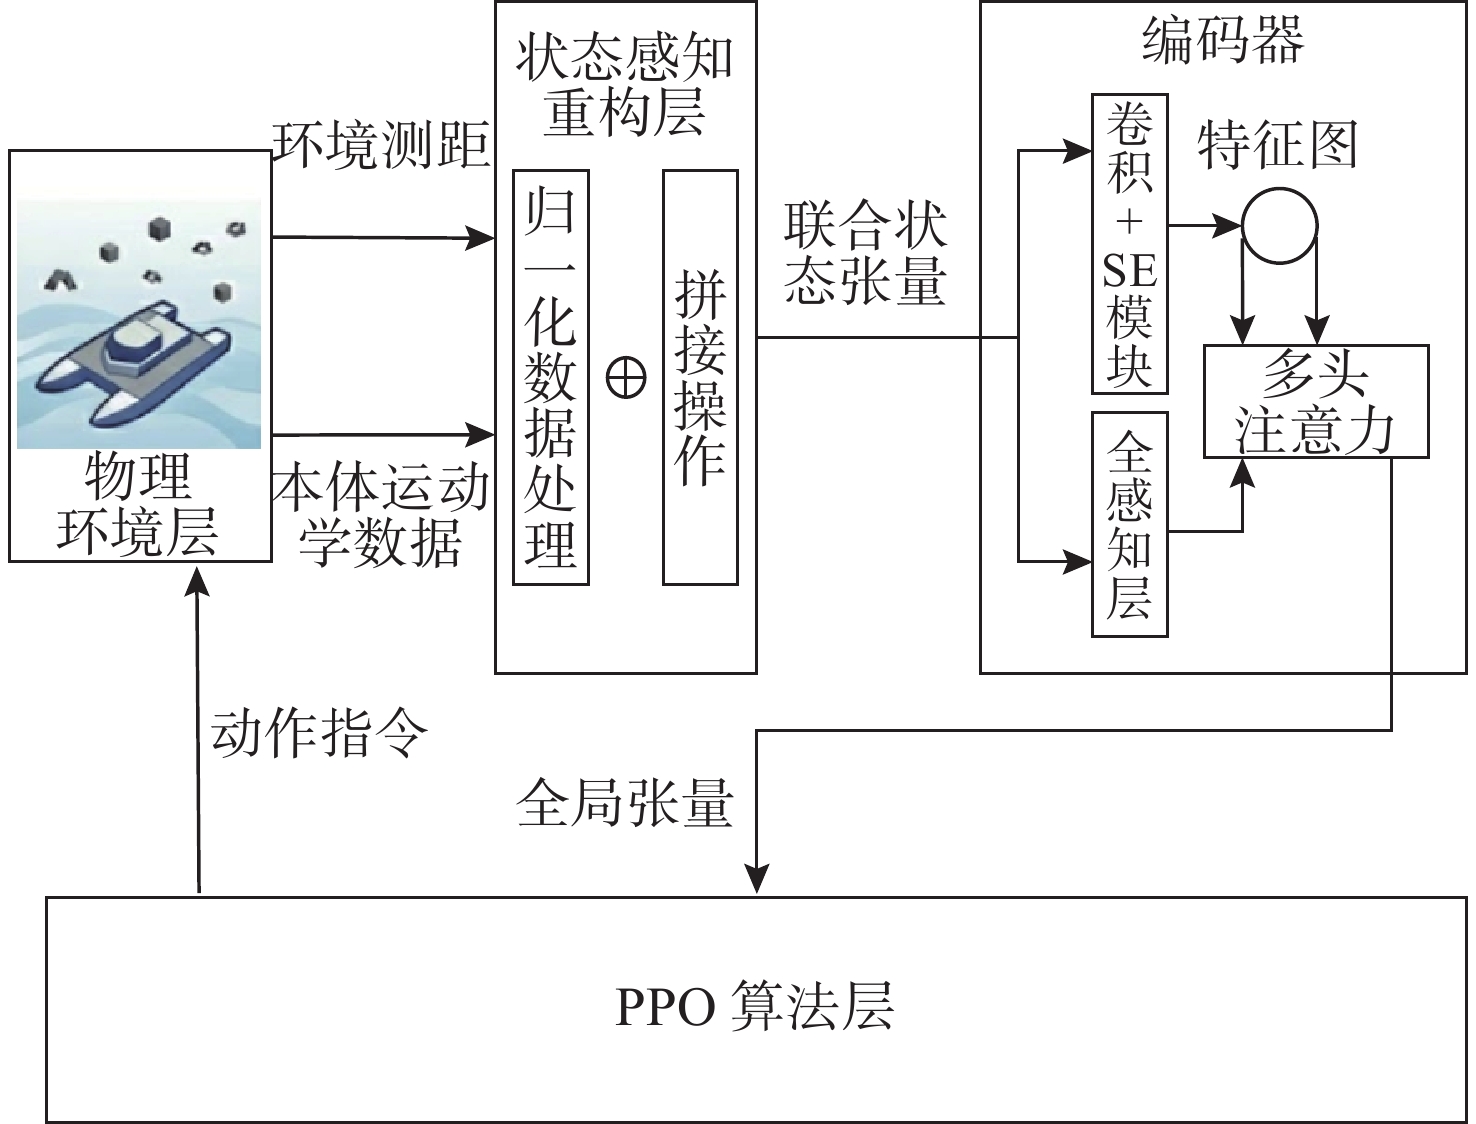
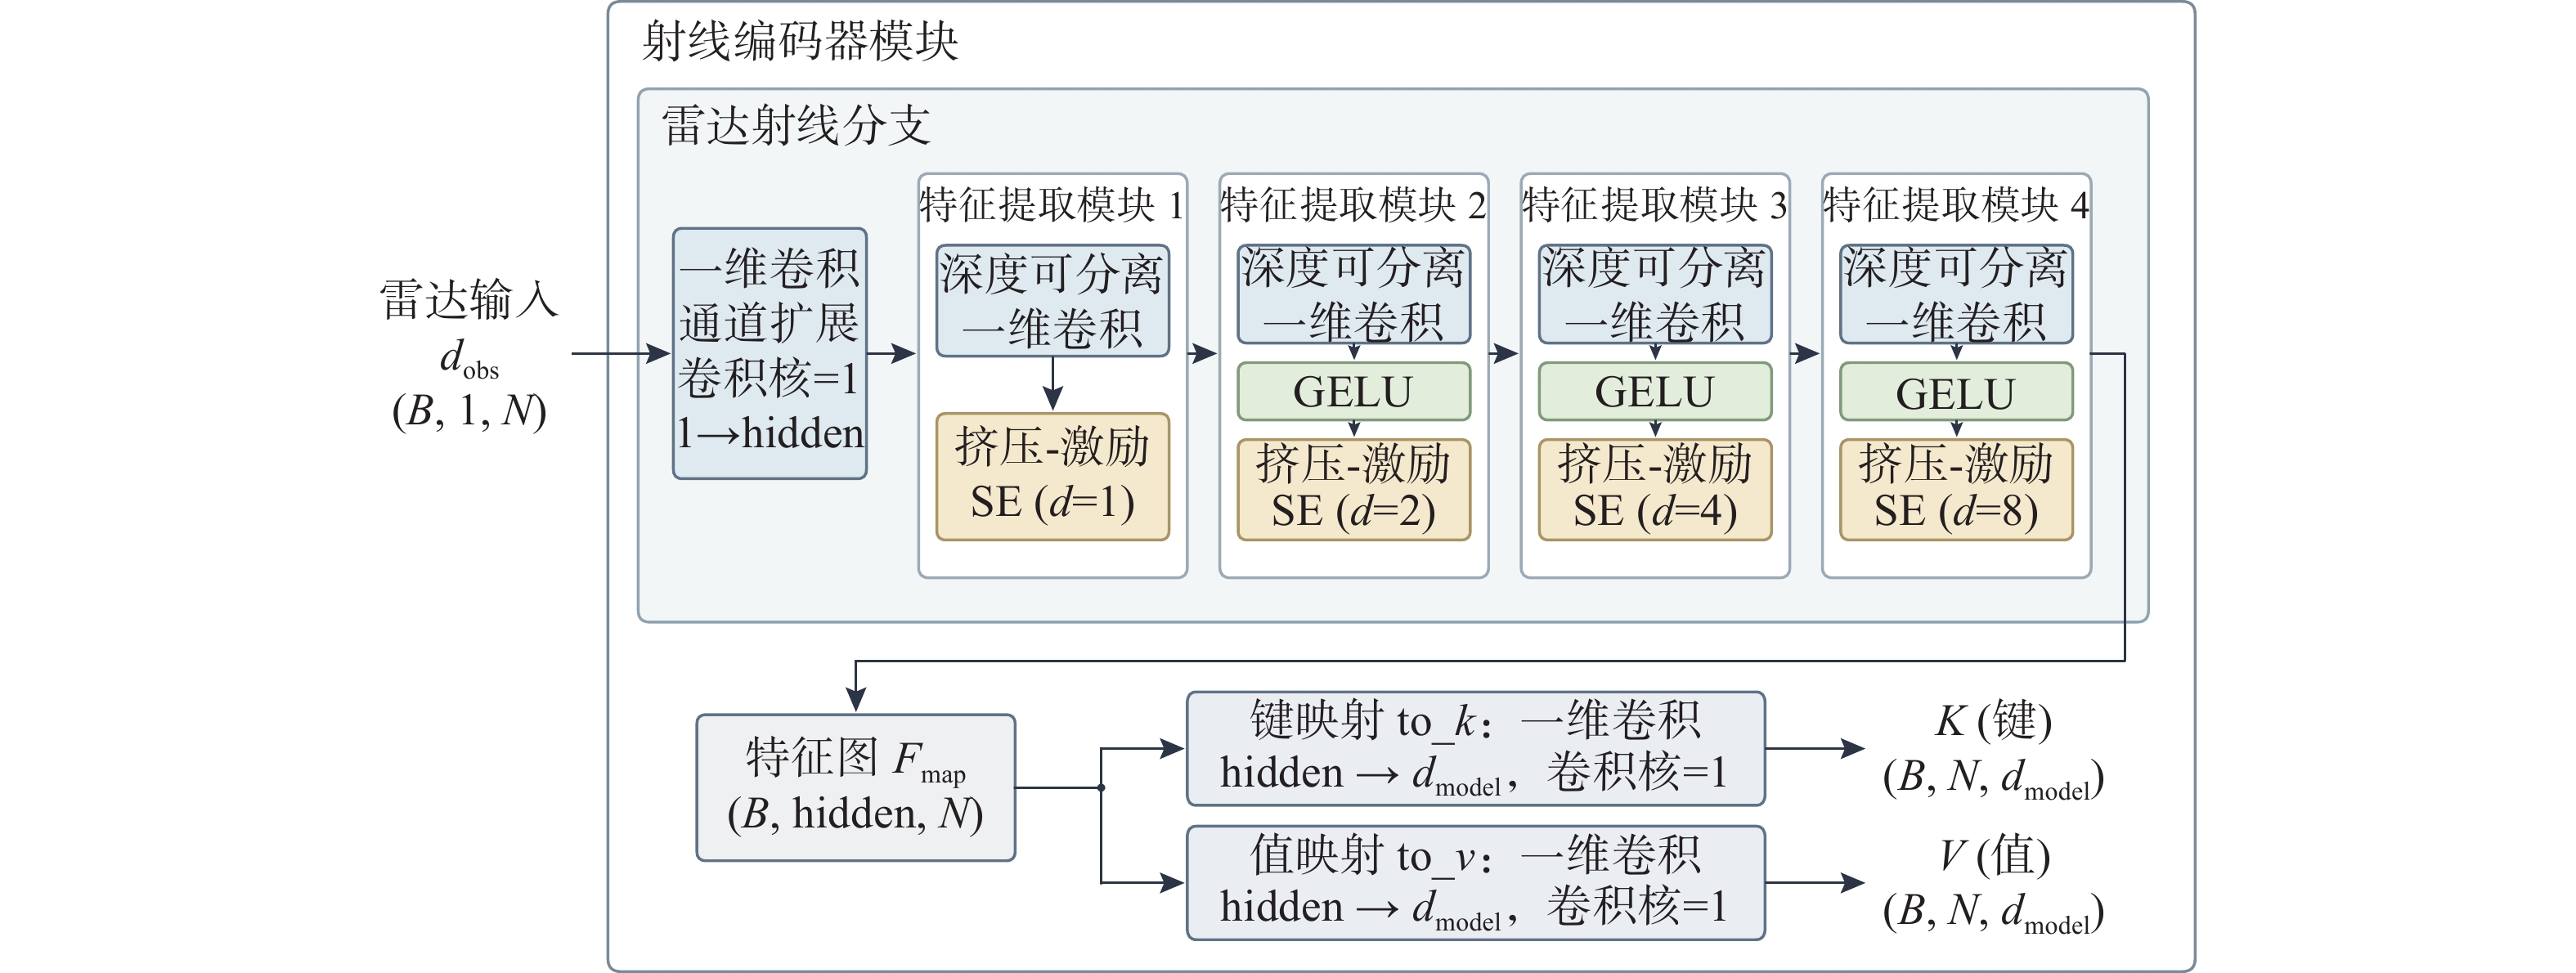
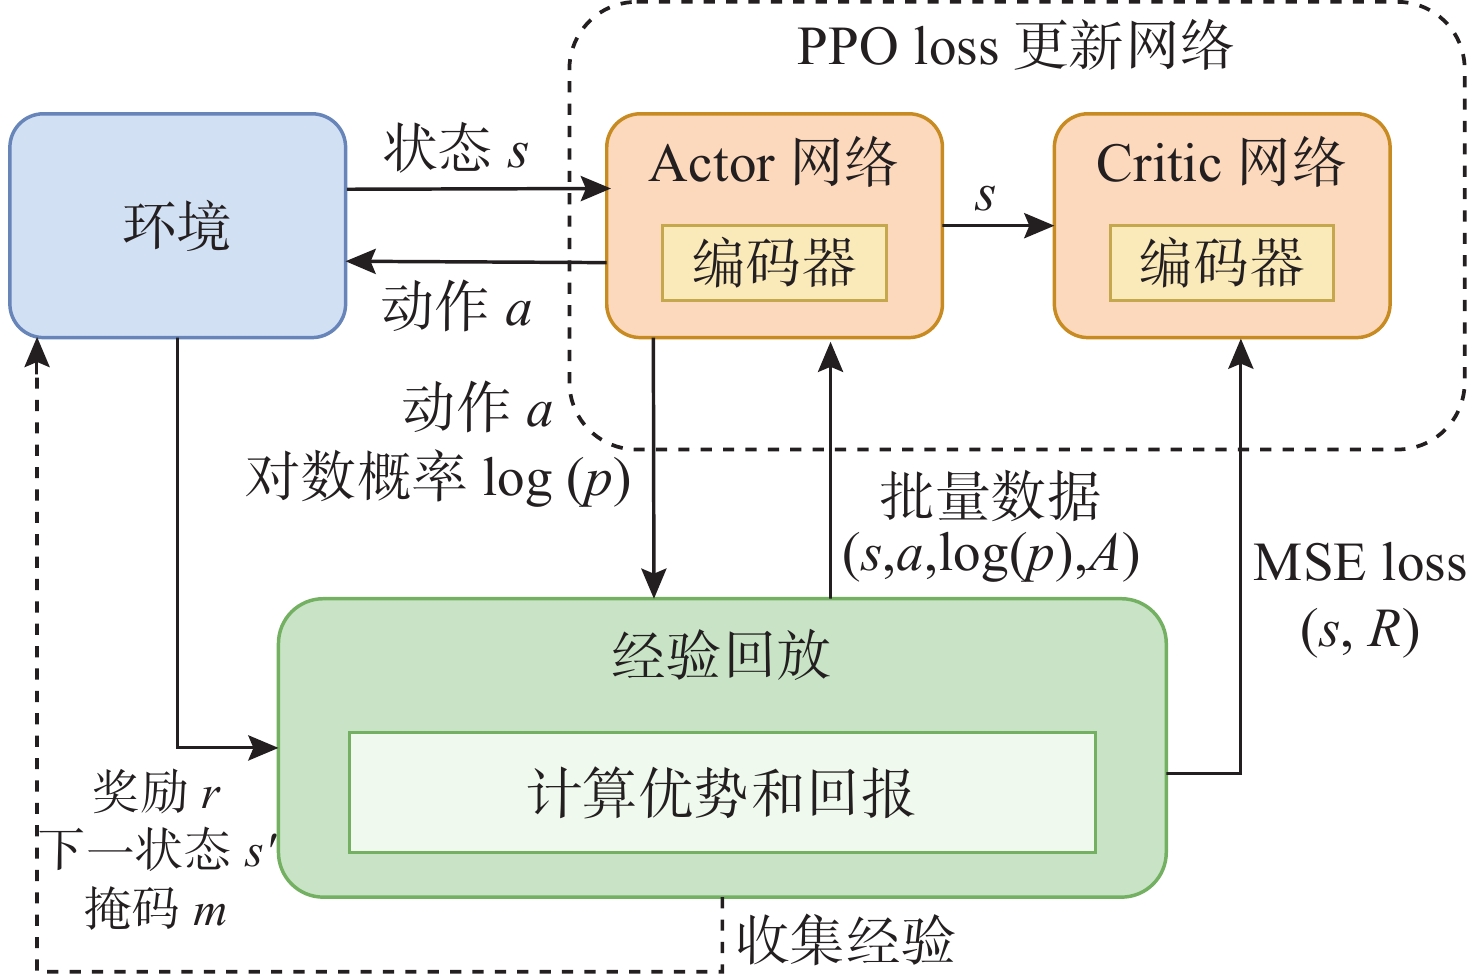
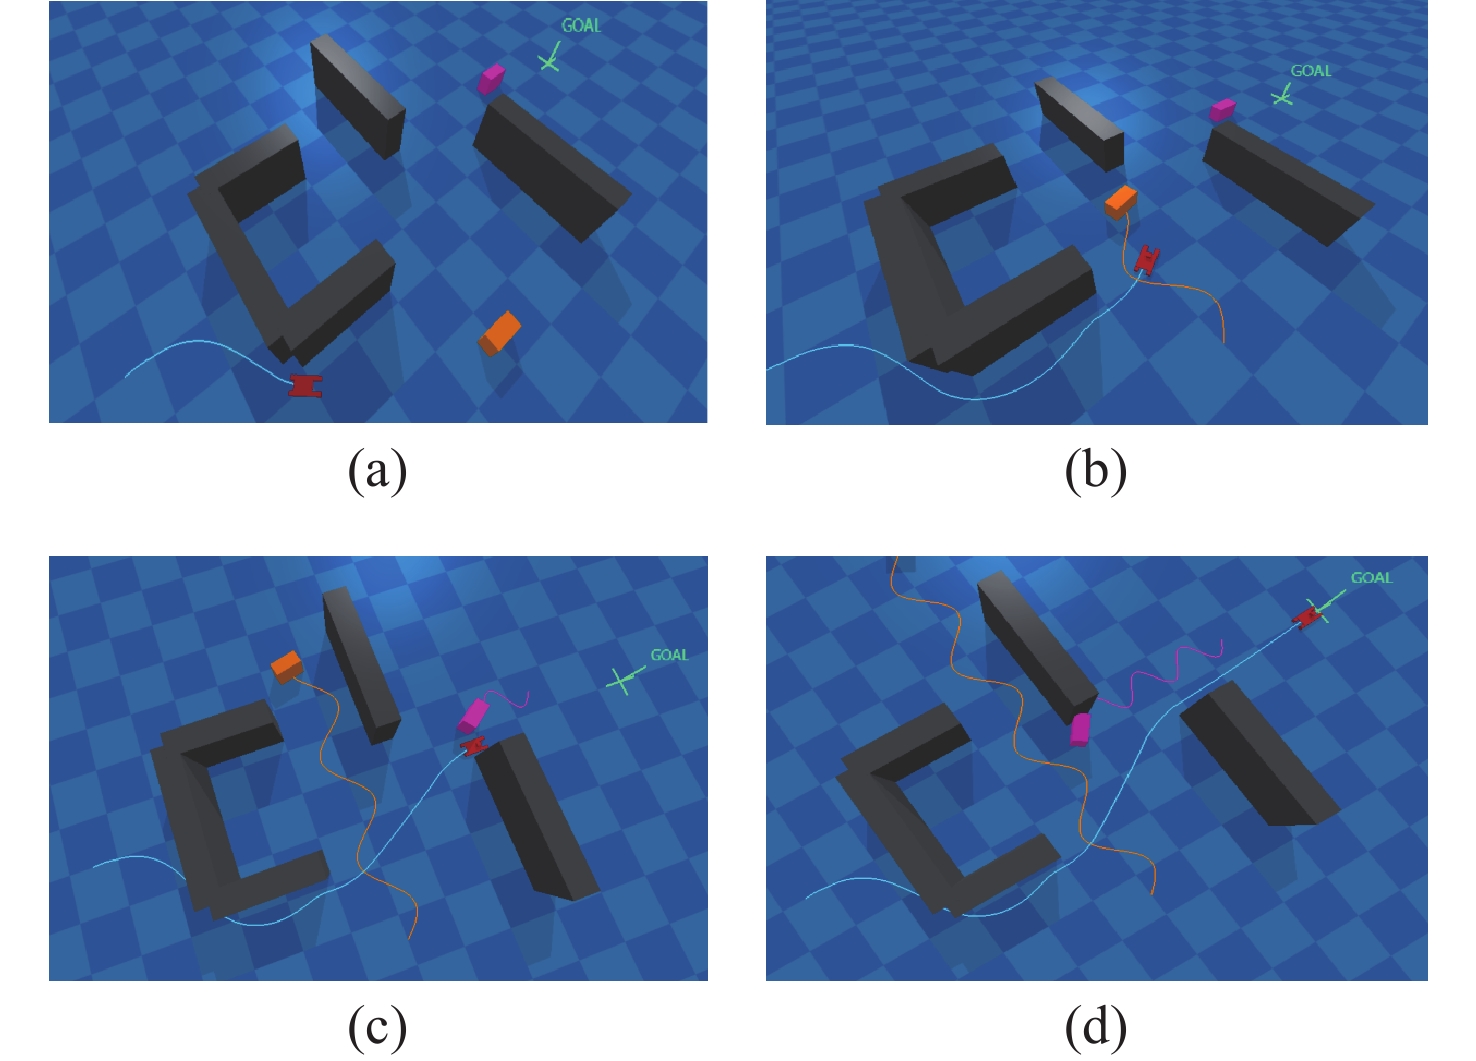
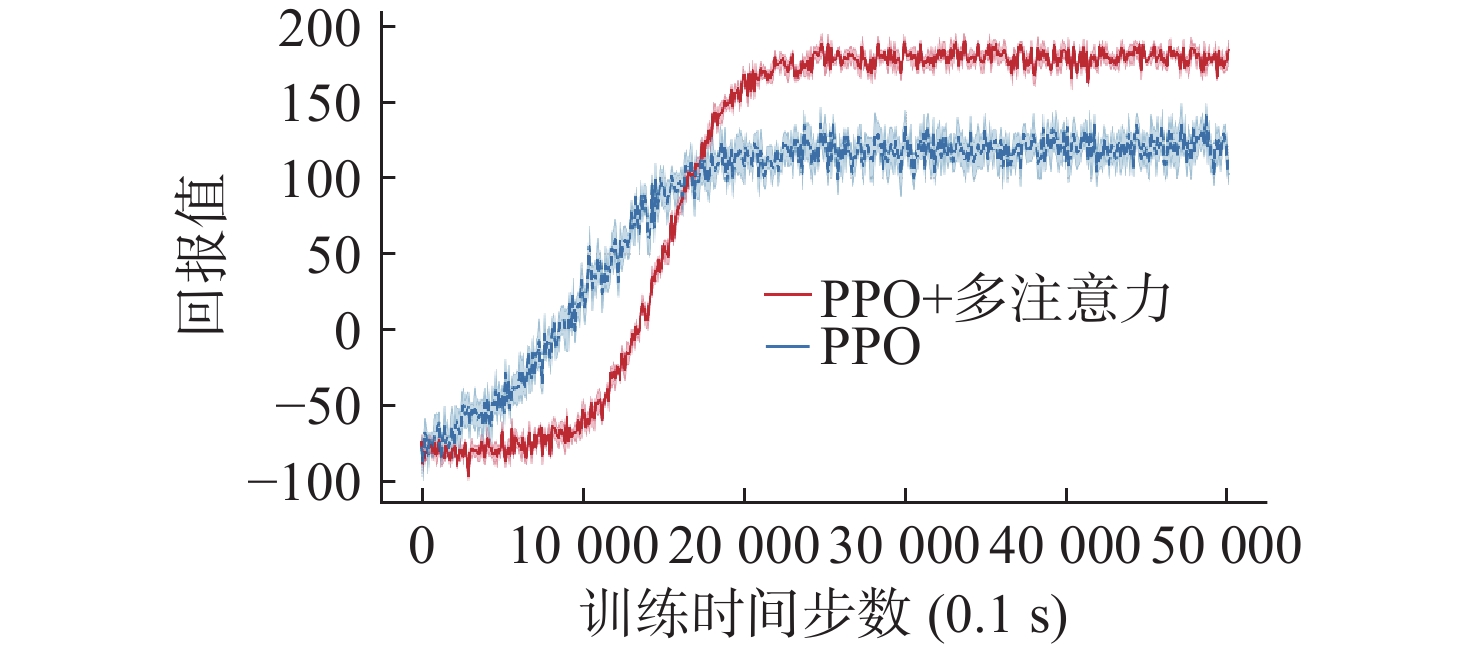
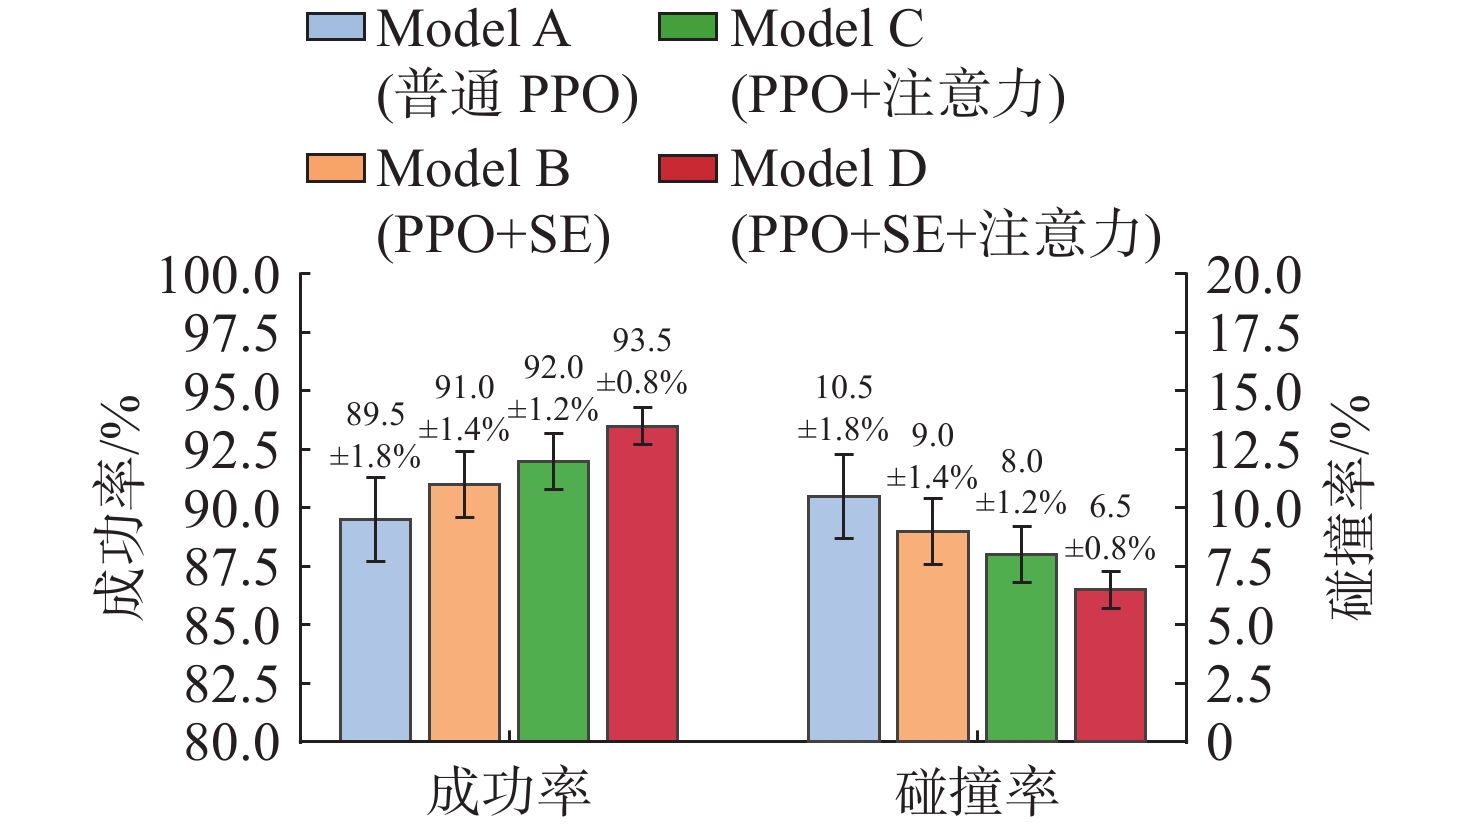
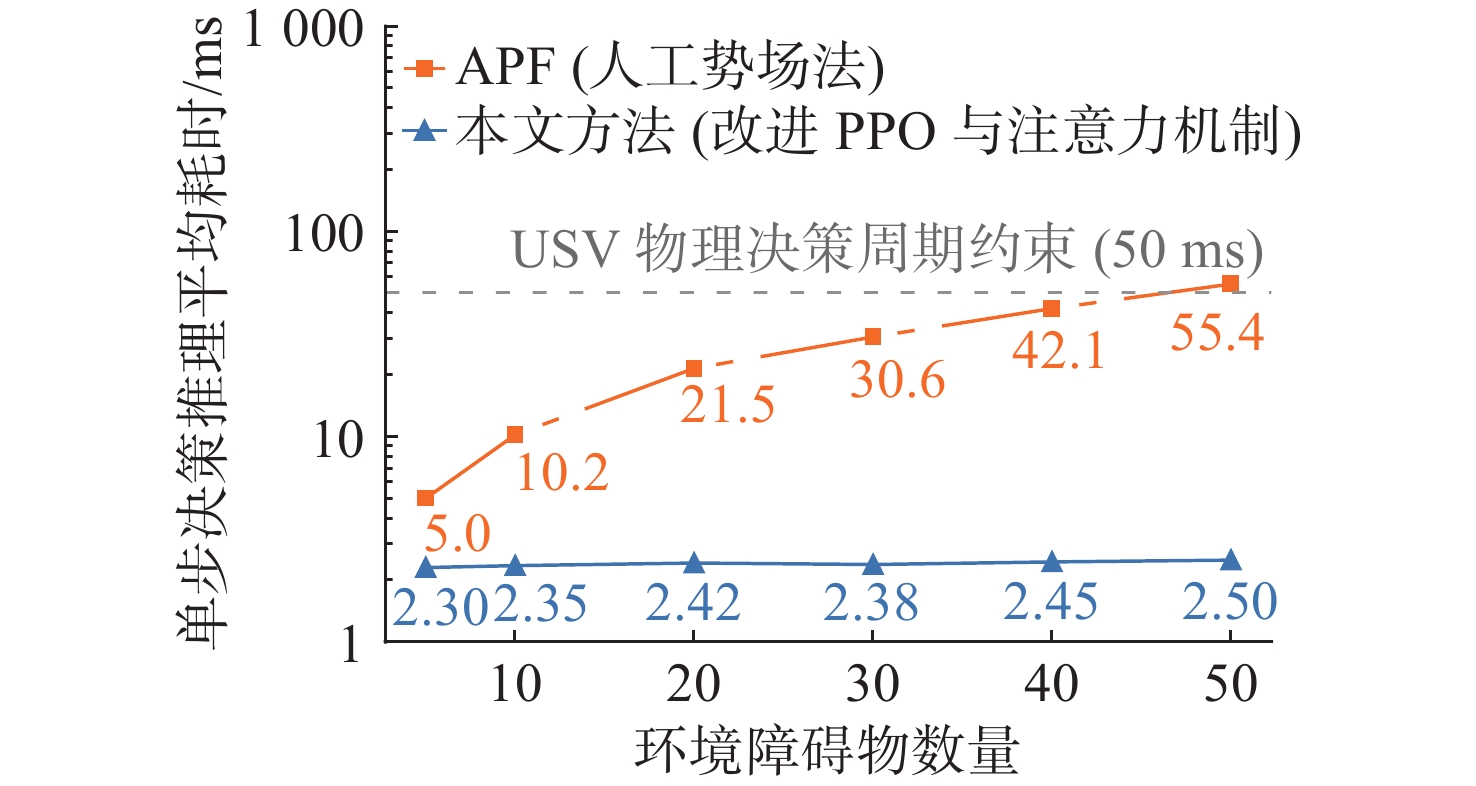
To address the problem of local obstacle avoidance and path planning for Unmanned Surface Vehicles in complex dynamic marine environments, this paper proposes an end-to-end control method based on deep reinforcement learning. The method employs the Proximal Policy Optimization algorithm and designs a feature extraction network that integrates one-dimensional depthwise separable convolution with a multi-head attention mechanism. Given the characteristics of sparse LiDAR data, the Squeeze-and-Excitation (SE) module is first utilized to enhance the representational capacity of channel features. Subsequently, a multi-head attention module based on the Transformer architecture is constructed, which uses the vehicle's own motion states as query vectors to dynamically weight environmental observation features, thereby achieving effective fusion of proprioception and environmental perception. Finally, complex scenarios comprising static reefs and dynamic interfering obstacles are constructed within the PyBullet physics simulation environment. Experimental results demonstrate that the proposed method effectively handles dynamic obstacles and achieves smooth autonomous obstacle avoidance control . Compared with standard PPO, the proposed method improves the obstacle-avoidance planning success rate by 4%.
ncc-audit-test-e0bf2fa9
, Available online  
Abstract:
Effects of Front-Side Angles of Floating Boxes on the Navigation Performance of an Amphibious Vehicle in Calm Water
ZHANG Zhewei, XU Xiaojun, FENG Yikun, ZHANG Guoqing, JIN Haobin, GE Qiqian, WANG Jiancheng, ZHANG Xin
, Available online  , doi: 10.11993/j.issn.2096-3920.2026-0092
Abstract:
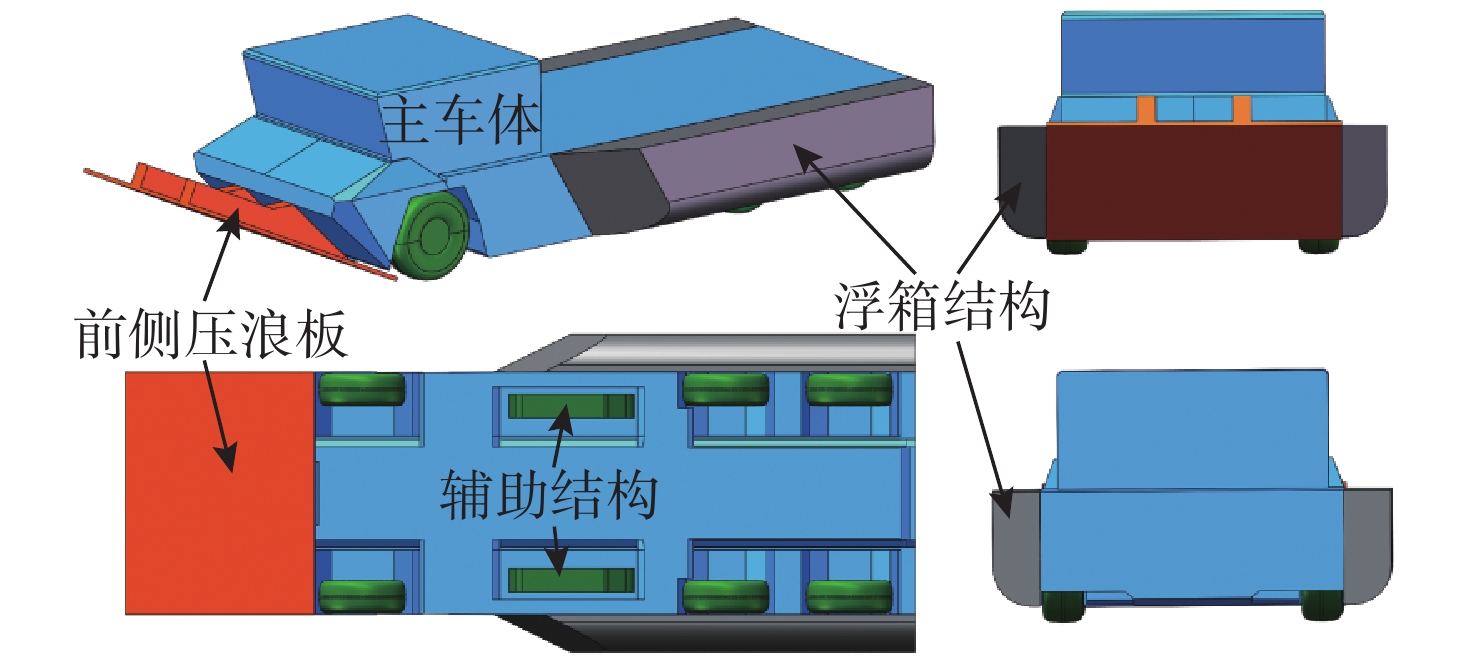
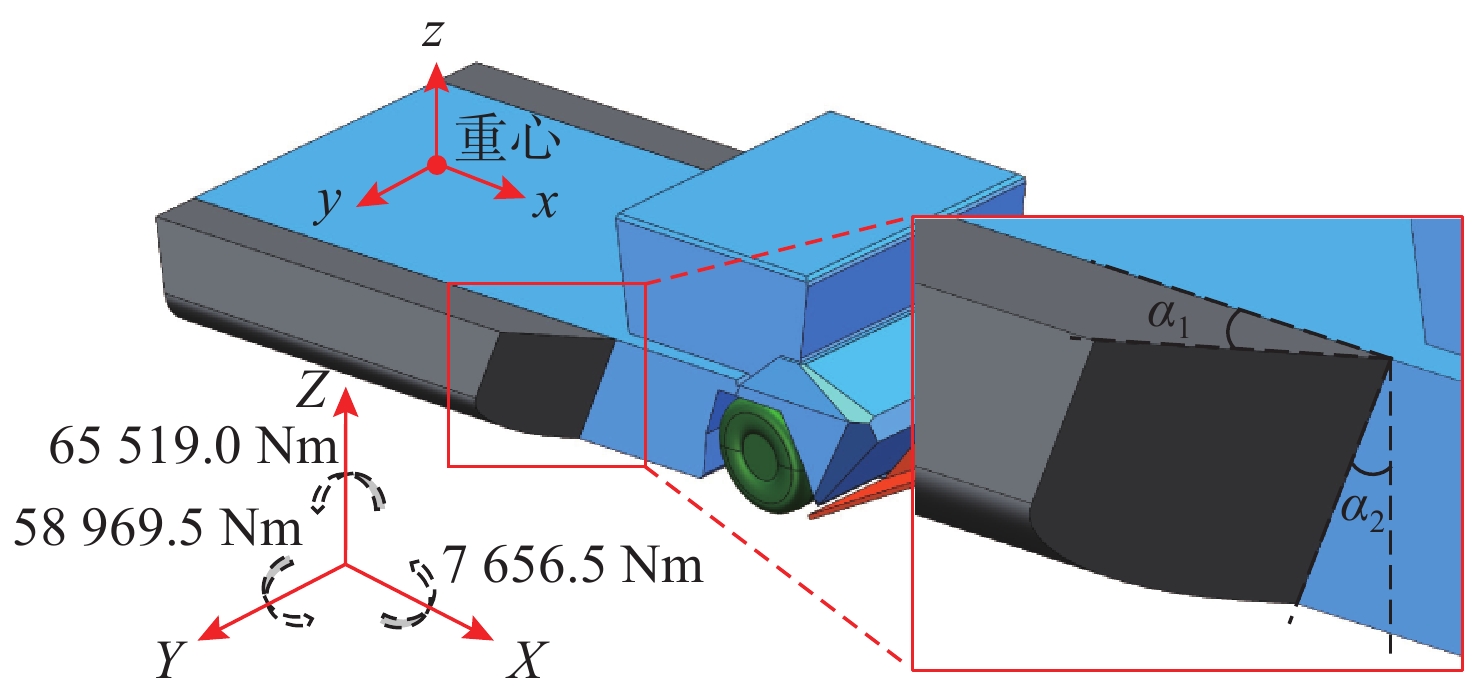
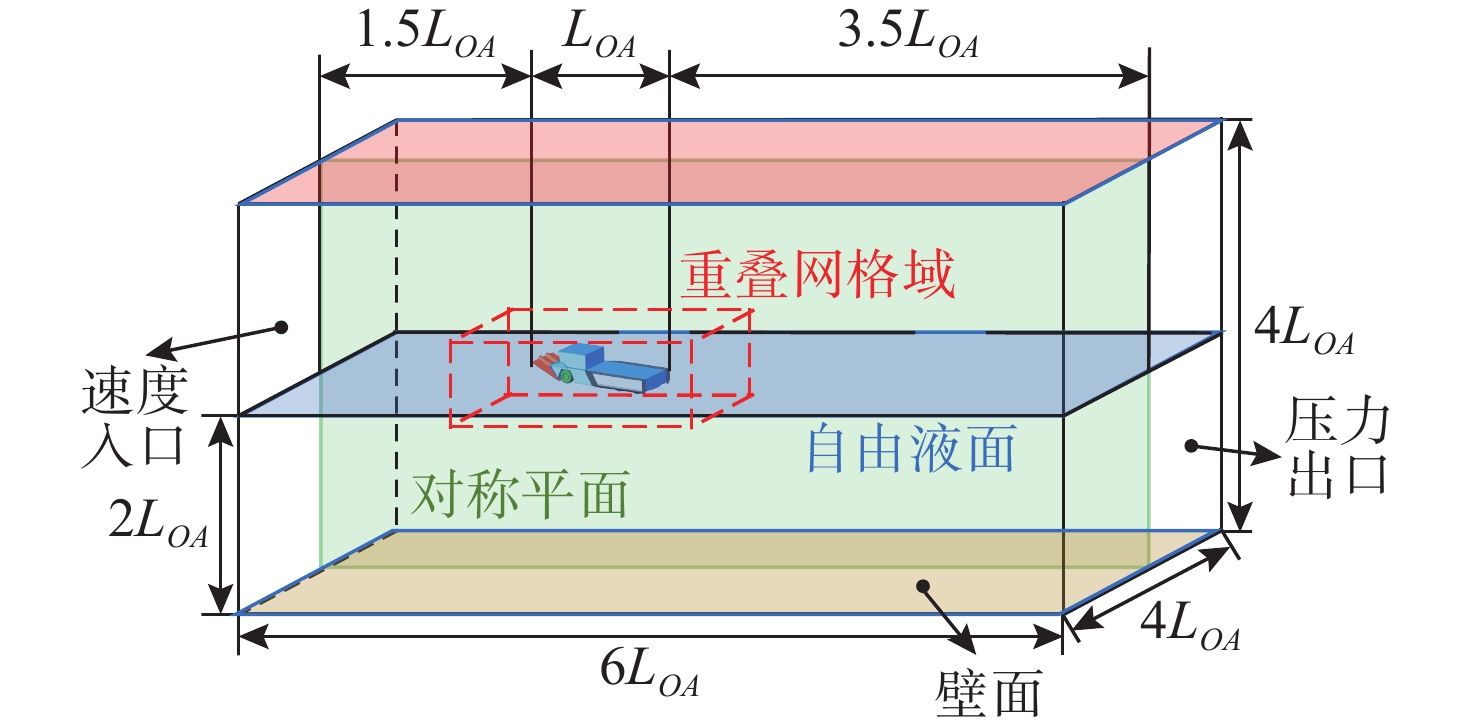
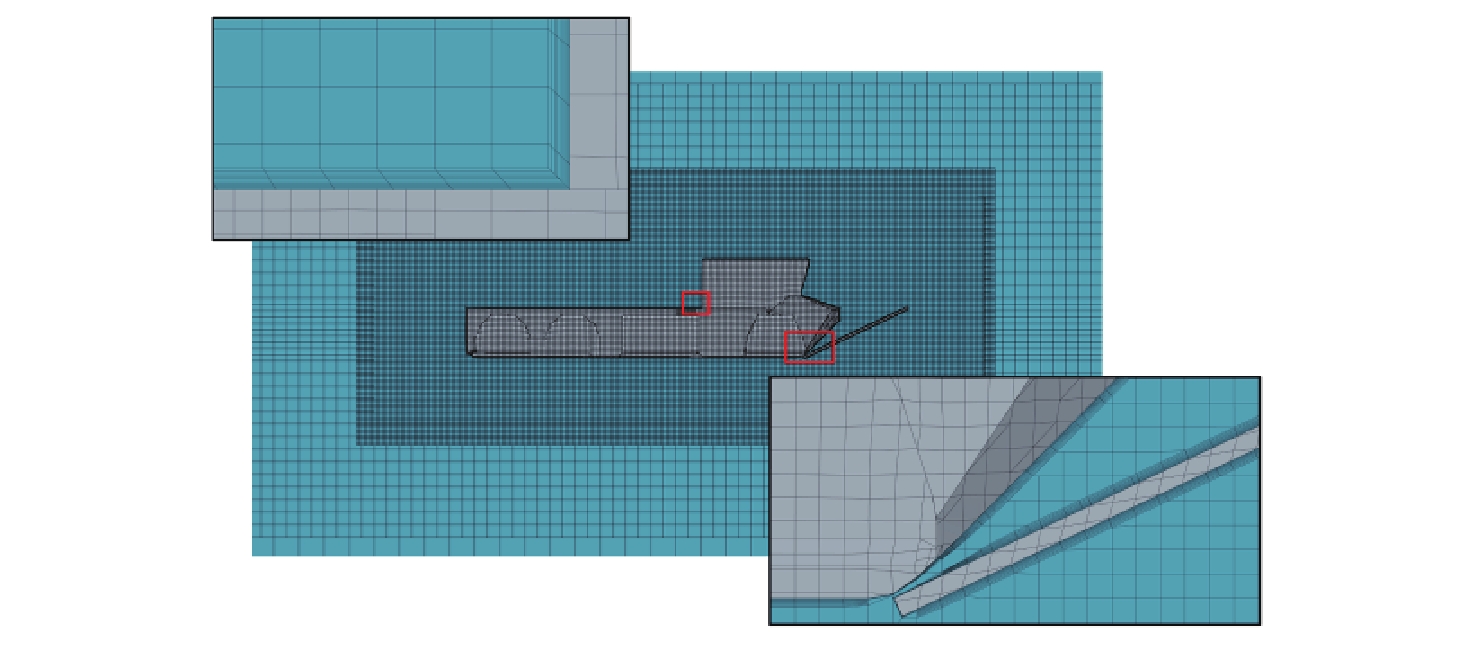
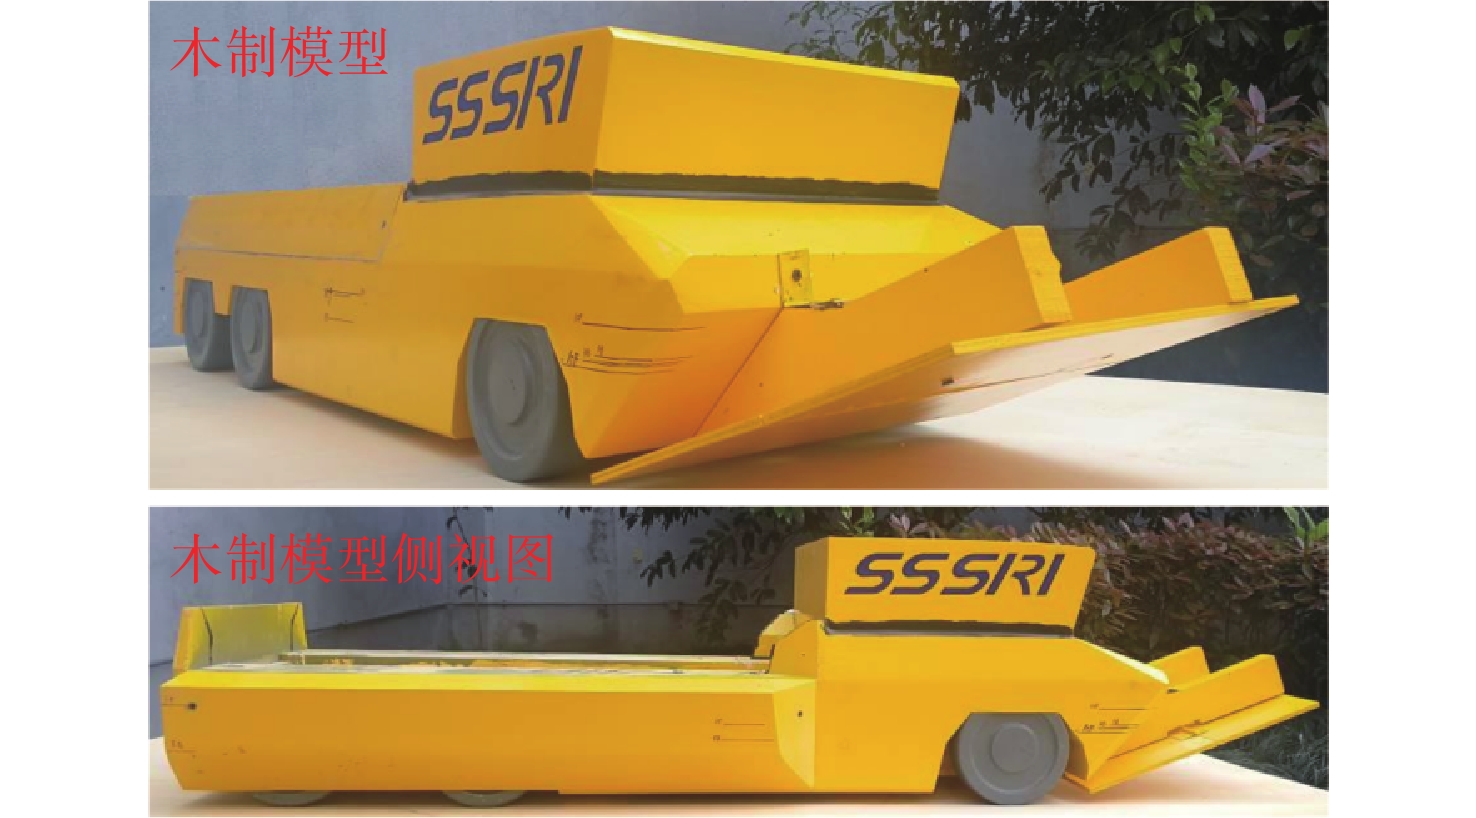
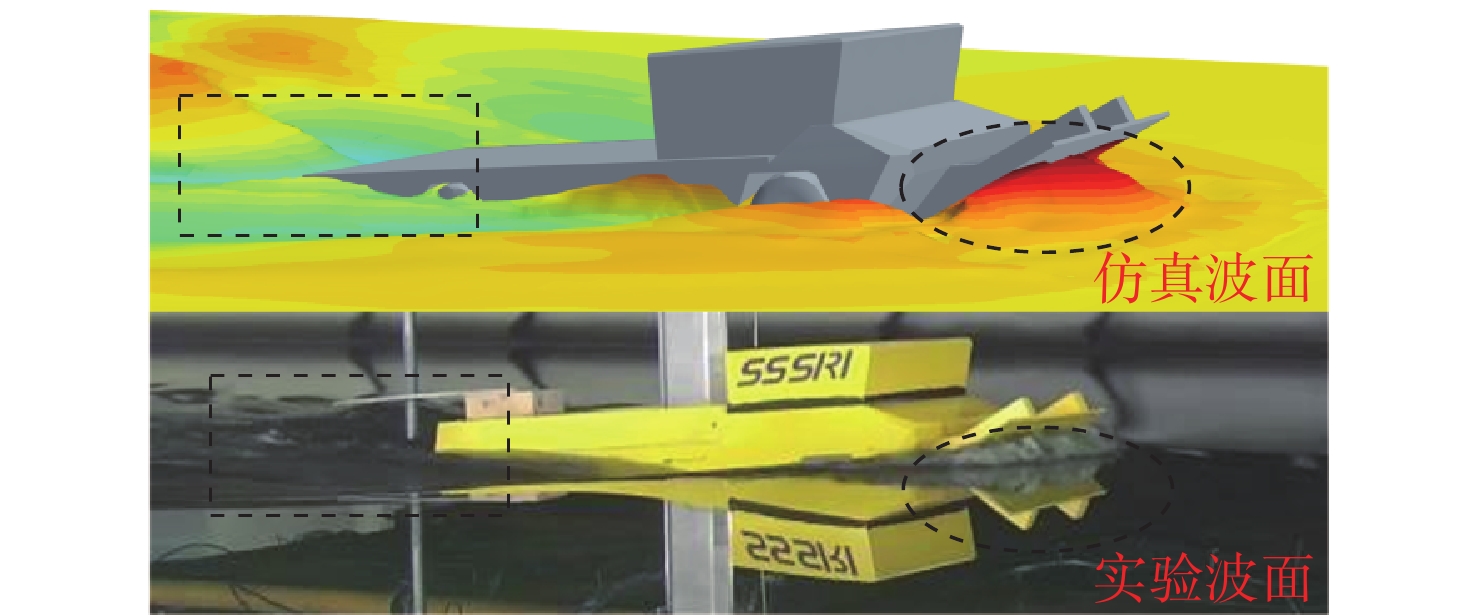
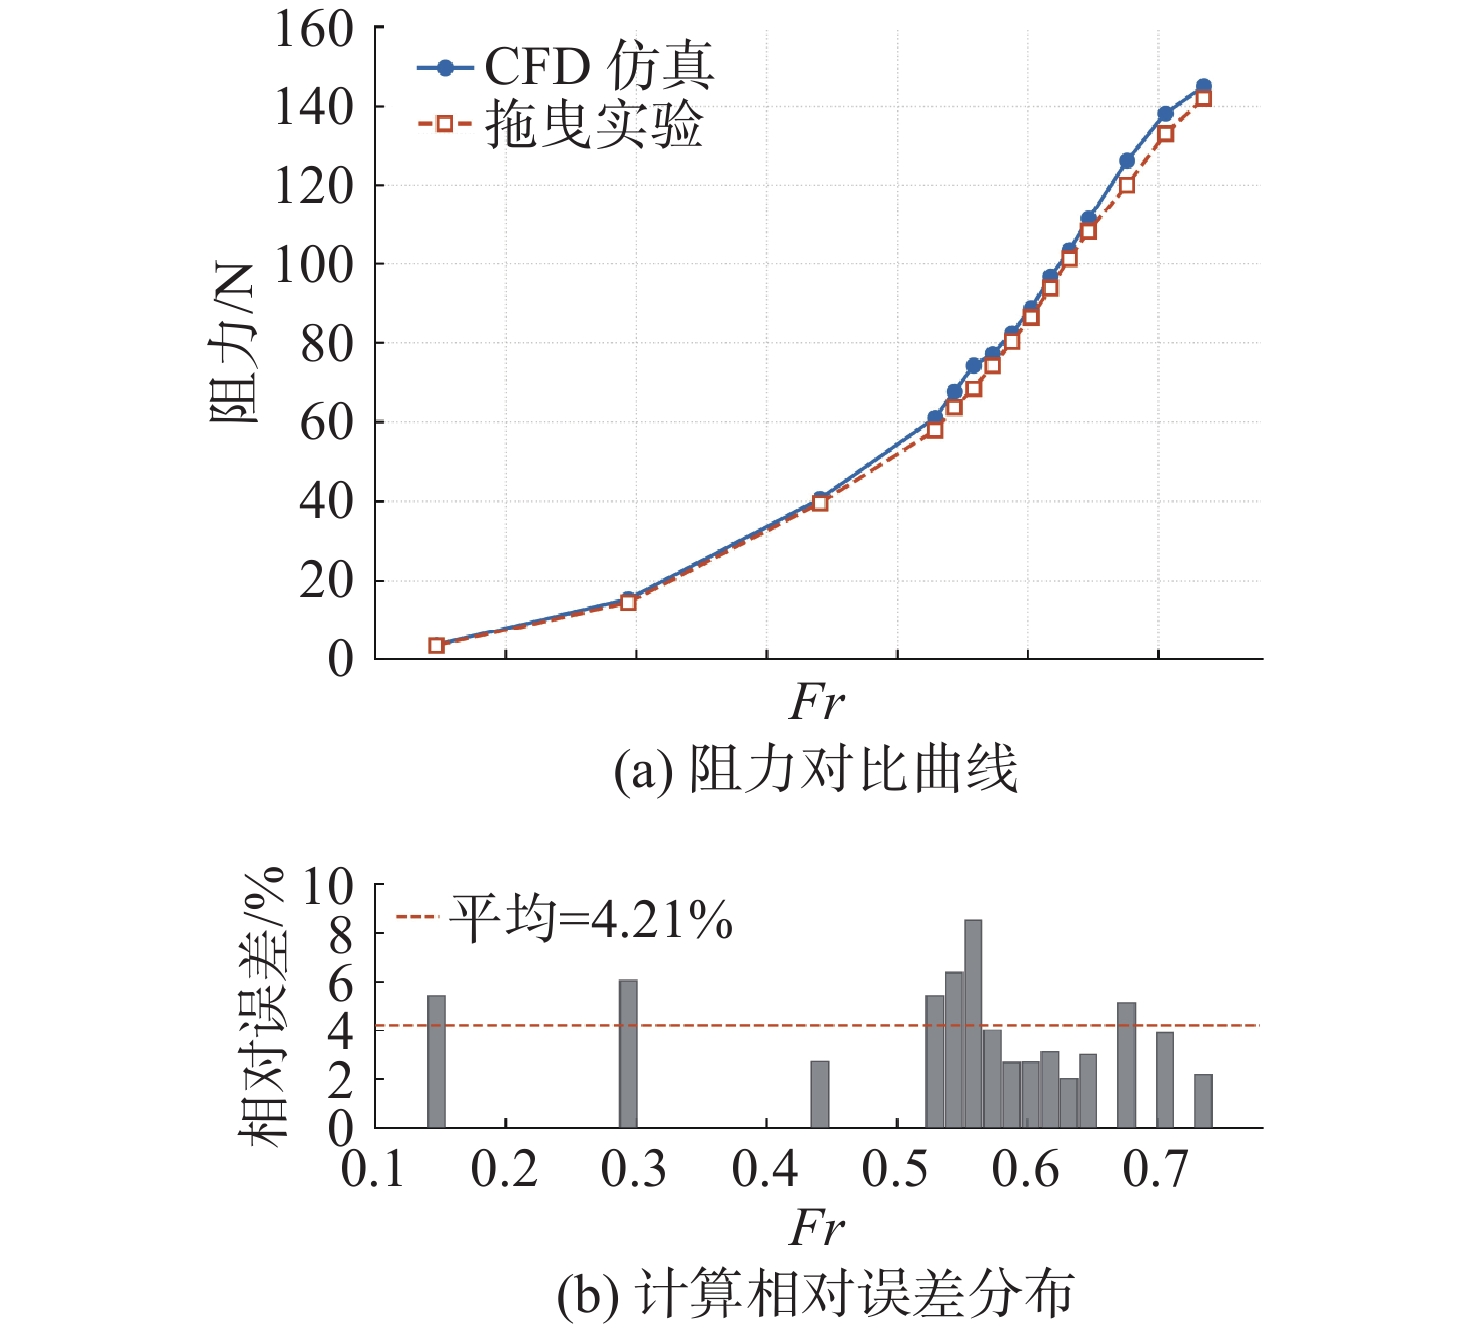
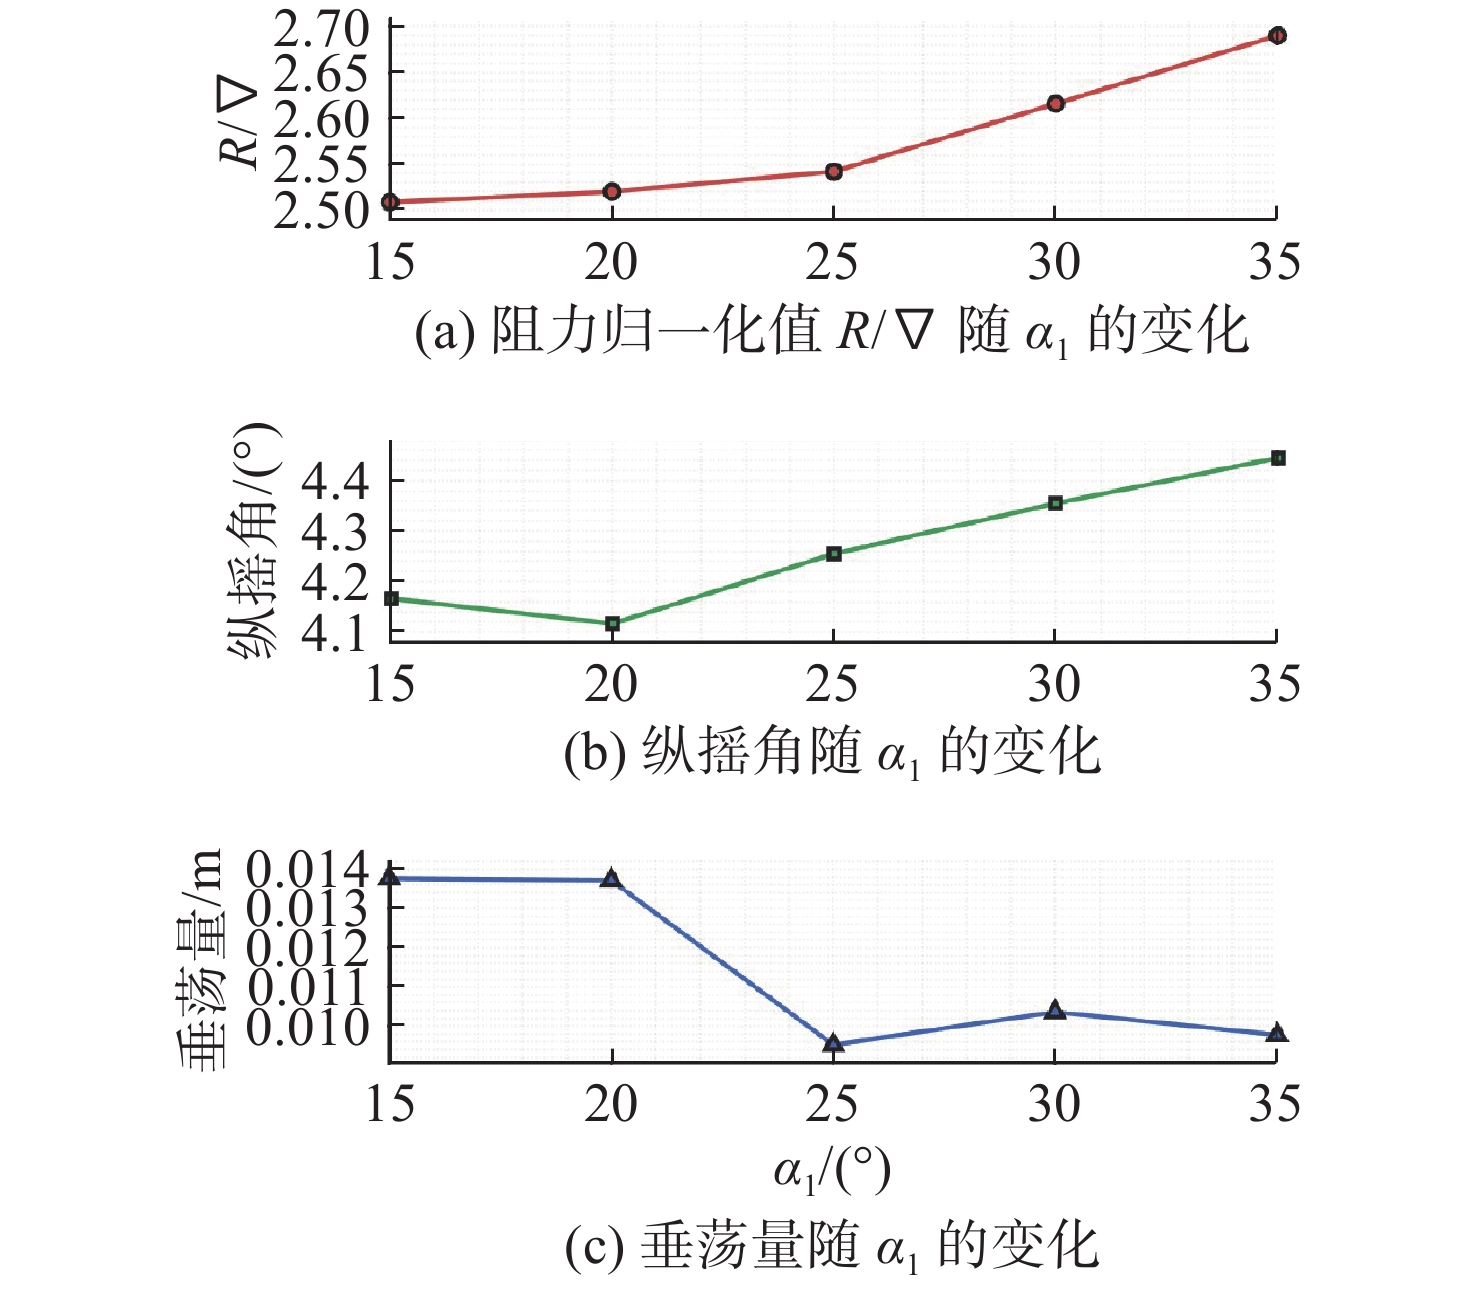
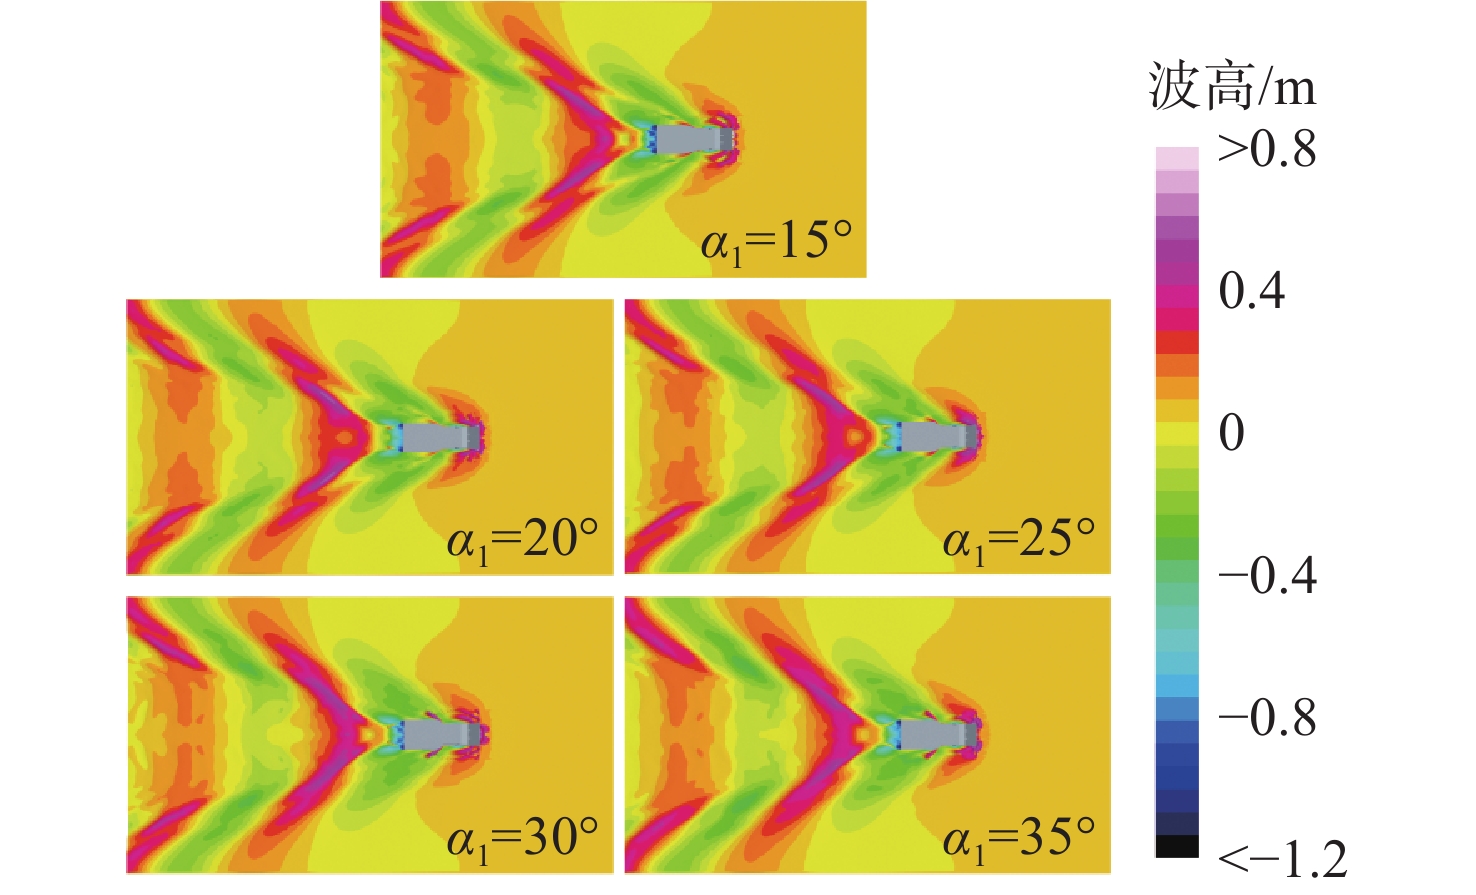
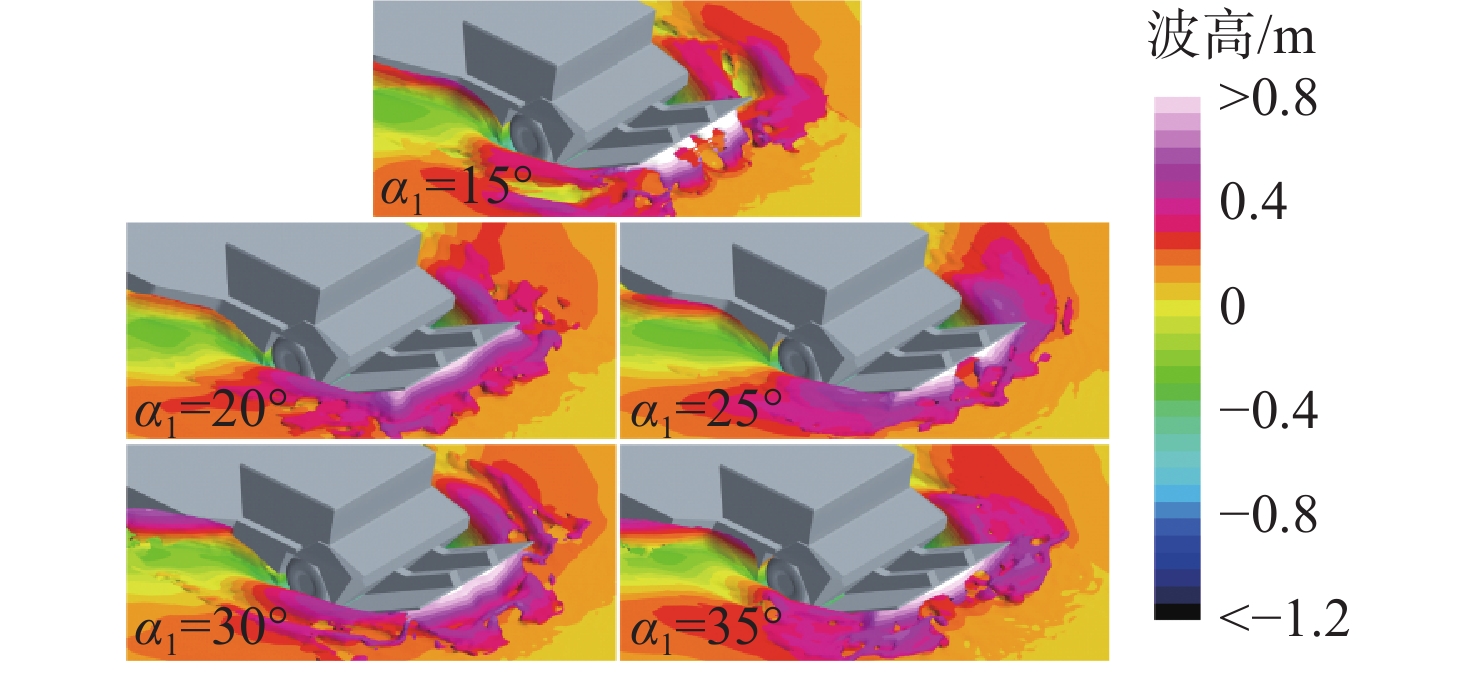
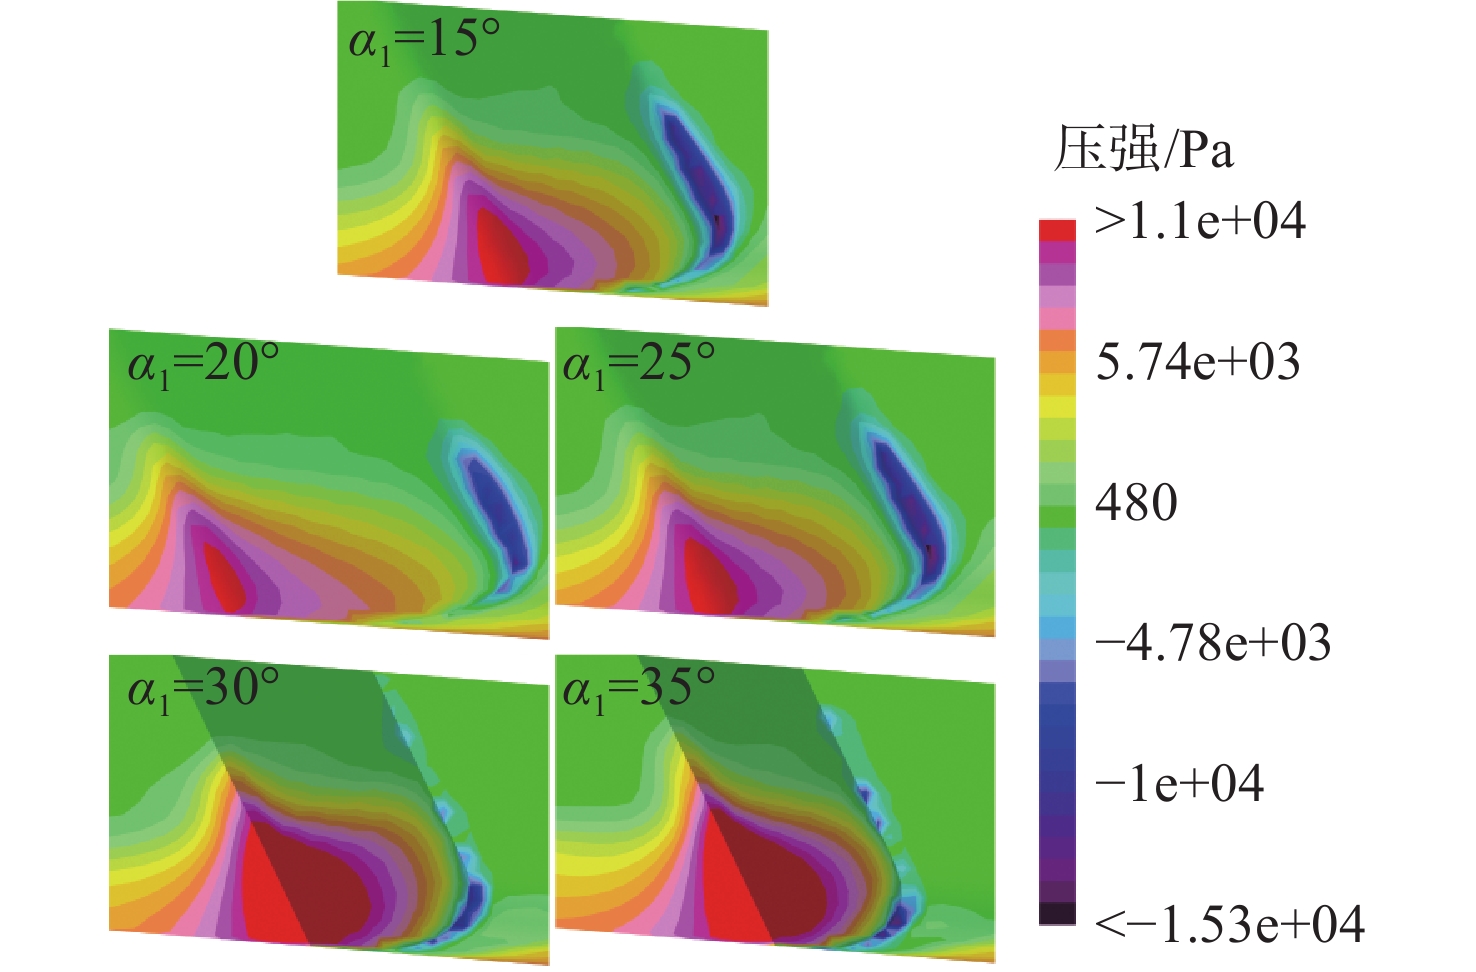
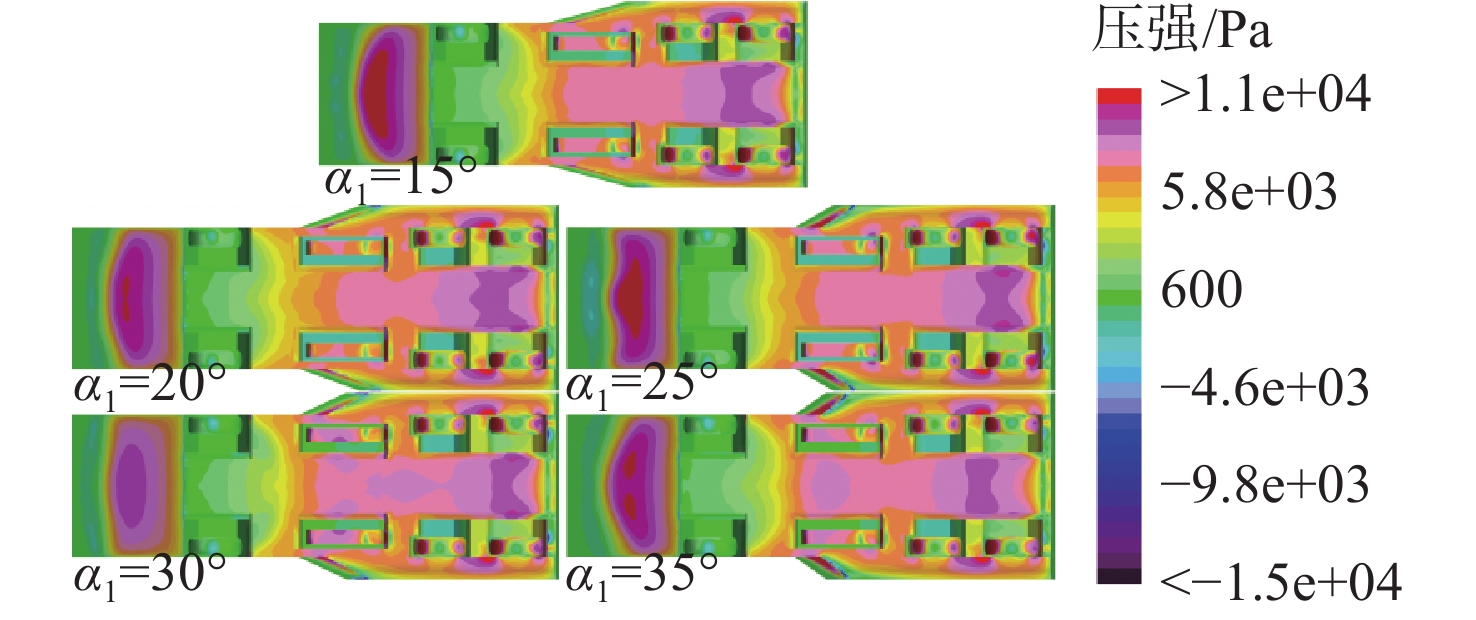
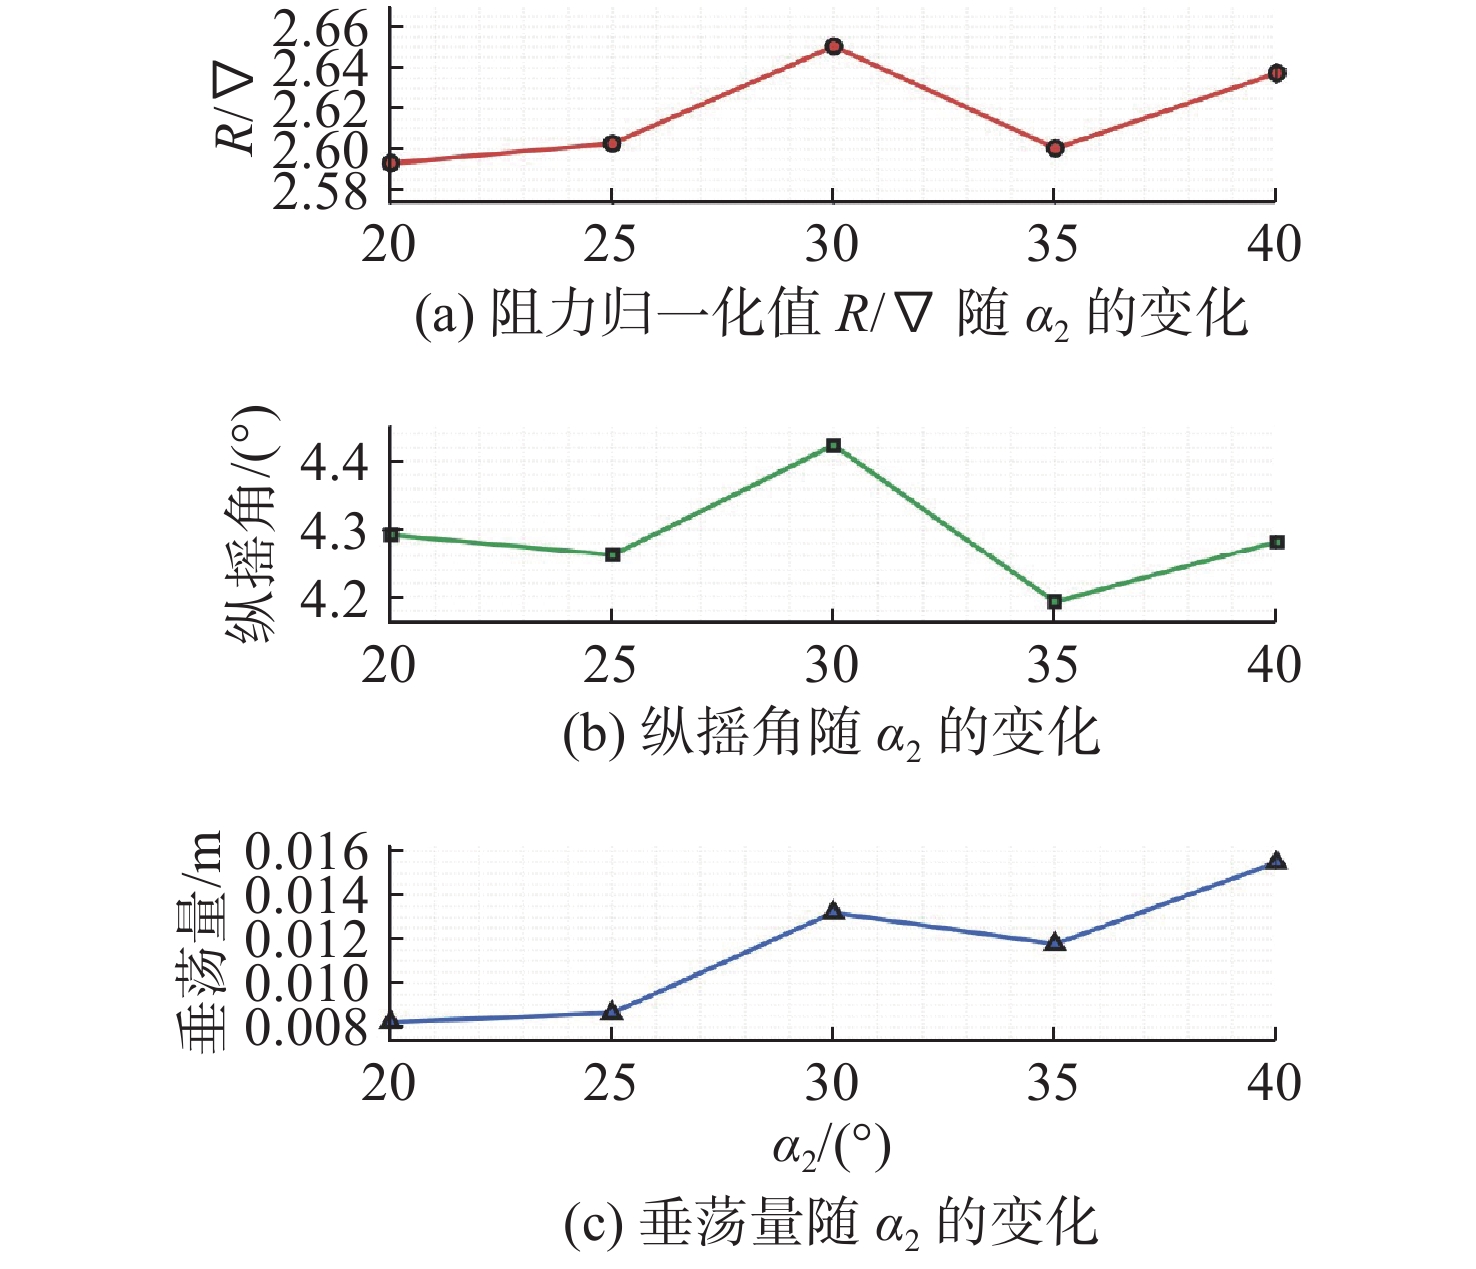
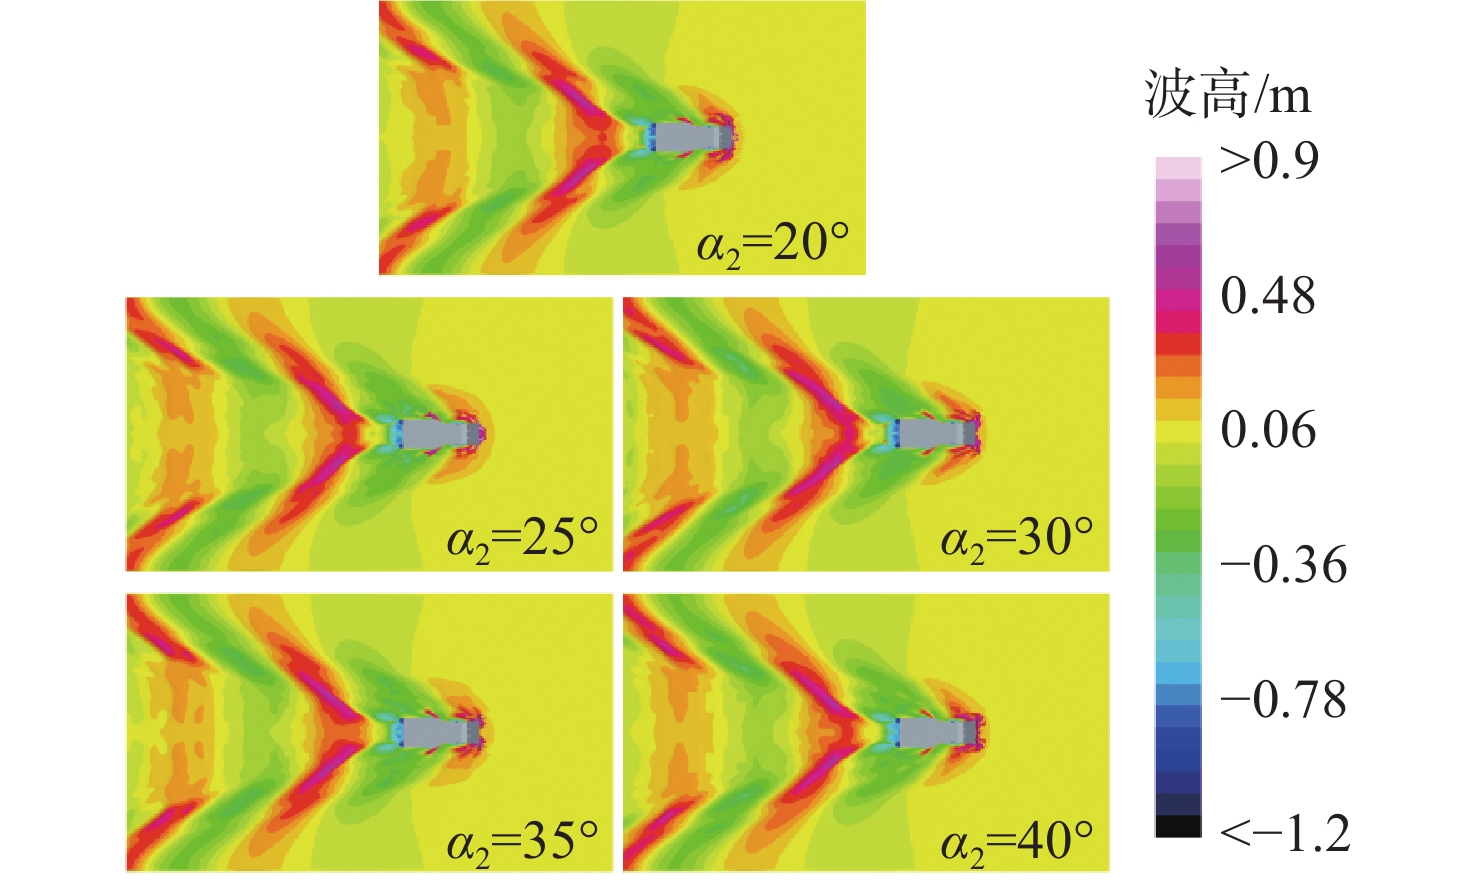
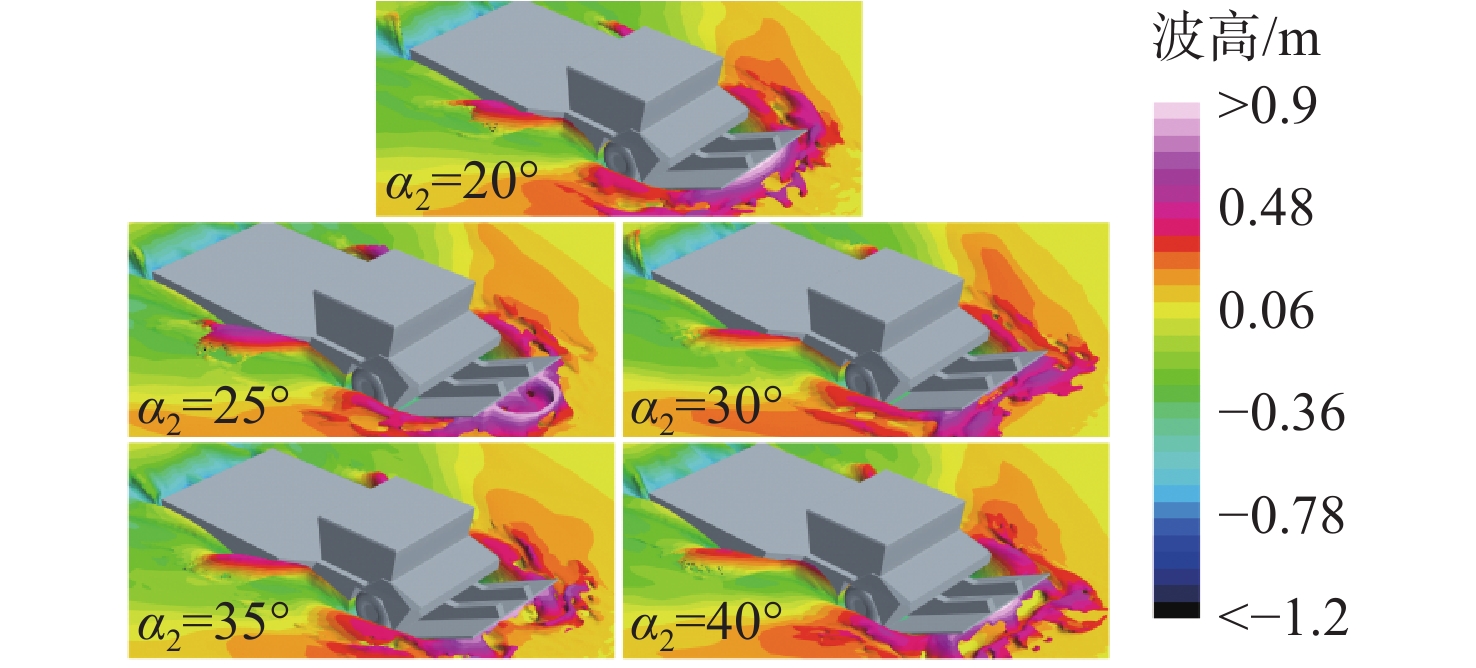
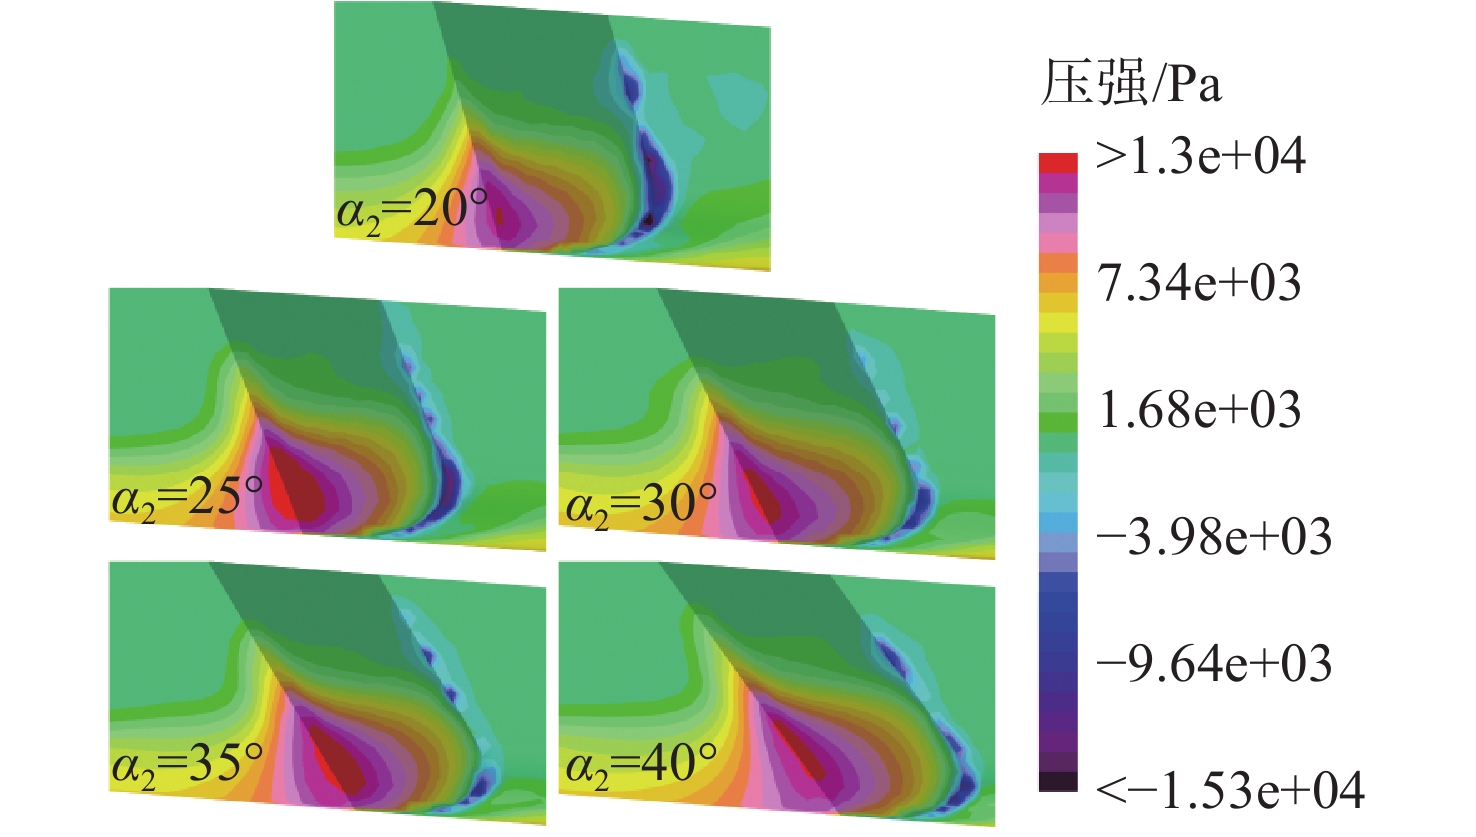
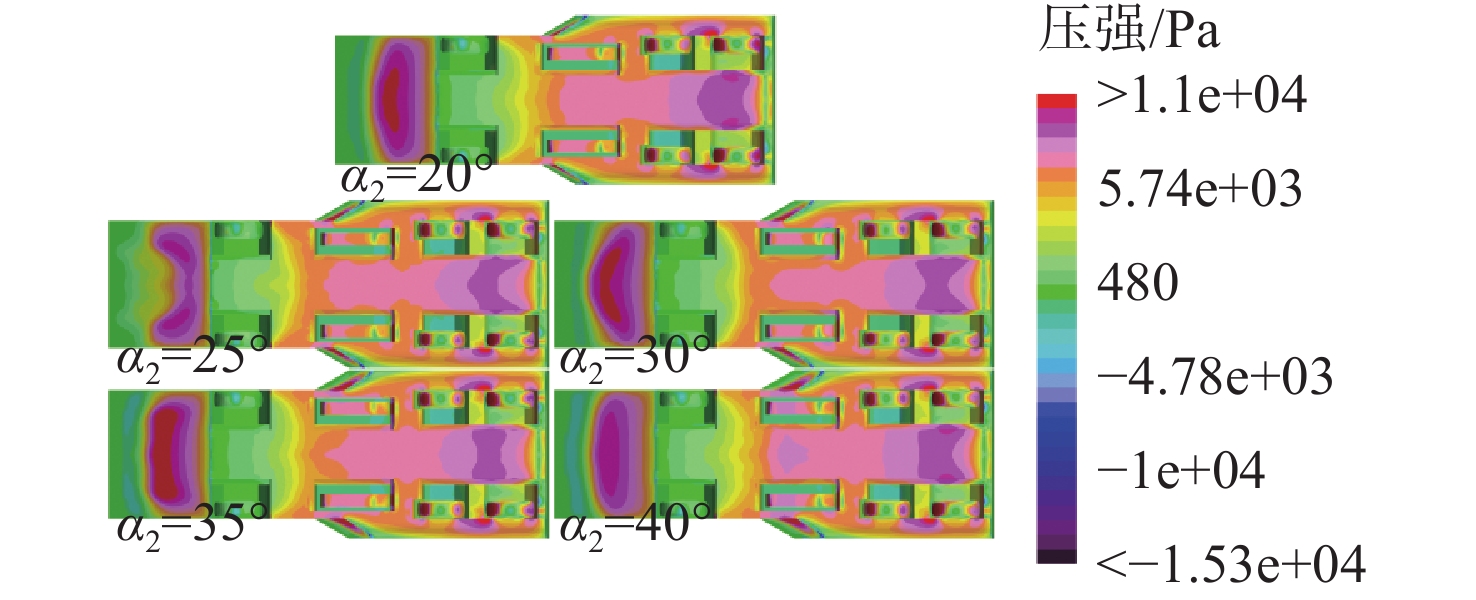
To clarify the effects of the front-side angles of floating boxes on the resistance, attitude response, and local flow field of an amphibious vehicle in calm water, a specific amphibious vehicle was investigated based on the Reynolds-Averaged Navier–Stokes(RANS) equations. Within the framework of computational fluid dynamics(CFD), the shear stress transport(SST) k-ω turbulence model and the volume of fluid (VOF) free-surface model were employed to analyze the hydrodynamic effects of the front-side geometric angles of the floating boxes. By varying the front inclined angle α1 and the outer guide-surface angle α2, the resistance, pitch, heave, free-surface patterns, and pressure distributions were comparatively analyzed at a fixed displacement condition and a speed of 6m·s−1. Towing-tank experiments were also conducted to validate the numerical method. The results show that, within the parameter ranges investigated, as α1 increases from 15° to 35°, the normalized resistance R/∇ increases from 2.509 to 2.690, corresponding to an increase of approximately 7.2%. At larger α1, the high-pressure region near the leading part of the floating box expands, accompanied by intensified free-surface disturbance and wave-making effects. The pitch angle first decreases slightly and then gradually increases, whereas the heave displacement first decreases and subsequently exhibits small fluctuations. Among the discrete cases investigated, the minimum heave displacement of 0.009 529 m occurs at α1=25°, where R/∇ is 2.542, approximately 1.3% higher than that at α1=15°, and the pitch angle is 4.255°. Therefore, the favorable values of α1 differ among individual hydrodynamic performance indices, and an overall optimum cannot be identified without an explicitly defined multi-objective evaluation criterion. In comparison, variations in α2 produce a smaller resistance response. At α2=30°, R/∇ reaches the maximum value of 2.650 among the investigated cases, accompanied by relatively strong transverse-wave interference. The results indicate that the front-side angles of the floating boxes affect navigation resistance through changes in local pressure distribution, vehicle attitude response, and free-surface wave patterns, providing a reference for the selection and further optimization of the front-side geometric parameters of the floating boxes for the vehicle investigated in this study.
Service
Subscribe